Clock Management in Embedded Systems: In the world of embedded systems, clock management plays a critical role in ensuring the stability, performance, and efficiency of electronic devices. Whether it’s a microcontroller-based system or a complex SoC (System on Chip), understanding how to manage clocks effectively can lead to optimized power consumption, faster processing, and smoother device operation.
This article delves into the significance of clock management in embedded systems, exploring its core concepts, strategies, and best practices, along with providing valuable insights on how to handle clock domains, synchronization, and the power implications in real-world embedded applications.
What is Clock Management in Embedded Systems?
Clock management refers to the technique of controlling and coordinating the various clocks that drive the different components of an embedded system. A clock is an essential timing signal that dictates the operation of processors, peripherals, and other hardware modules. Managing these clocks efficiently is crucial for optimizing performance and minimizing energy consumption.
Key Concepts in Clock Management
Clock Sources
Internal Clocks: Generated within the chip or microcontroller. These clocks are typically low-power and can be used for general system operation.
External Clocks: Sourced from external oscillators or crystals. External clocks are usually more accurate and are preferred for precise timing requirements.
Clock Domains
A clock domain refers to a group of circuits that are synchronized to the same clock signal. In complex embedded systems, multiple clock domains may exist, each responsible for different subsystems (e.g., CPU, peripherals, communication modules).
Clock Gating
Clock gating is a technique used to disable clocks to inactive circuits, reducing power consumption. By turning off the clock when it’s not needed, energy can be conserved, which is especially important in battery-powered devices.
Clock Synchronization
In systems with multiple clock domains, synchronization is key. Ensuring that different clock signals are aligned properly reduces the chance of data corruption or timing mismatches.
Phase-Locked Loop (PLL)
A PLL is a crucial component in embedded clock management. It adjusts the phase and frequency of a clock signal to synchronize it with an external reference signal, ensuring stability in system timing.
Low-Power Clocking
Embedded systems often need to operate under strict power constraints. Low-power clocking techniques, such as using slower clock frequencies or stopping unused peripherals, help minimize energy usage.
Why is Clock Management Important?
Performance Optimization
Clock management ensures that different subsystems within an embedded device are working at their optimal frequencies. By selecting the right clock speeds, you can boost performance without overburdening the power budget.
Power Efficiency
As mentioned earlier, power consumption is a critical factor in embedded systems, especially in battery-powered devices like wearables and IoT devices. Dynamic clock management, including techniques like clock gating and power scaling, allows embedded systems to reduce power consumption during periods of low activity.
System Stability
Clock synchronization across different components ensures data integrity and stable system operation. Misaligned clocks can lead to glitches, data corruption, or even system failure.
Cost Savings
Efficient clock management can reduce the need for extra power-hungry components, resulting in cost savings in both hardware and operational expenses, especially in large-scale deployments.
Techniques for Effective Clock Management
1. Dynamic Voltage and Frequency Scaling (DVFS)
DVFS allows you to adjust the voltage and clock frequency based on the system’s workload. By decreasing the clock frequency and voltage when the system is idle or under light load, you can significantly reduce power consumption. This technique is widely used in mobile and portable embedded devices.
Example Code:
if (system_load < LOW_THRESHOLD) {
    // Lower frequency and voltage
    set_frequency(LOW_FREQ);
    set_voltage(LOW_VOLTAGE);
} else {
    // Increase frequency and voltage
    set_frequency(HIGH_FREQ);
    set_voltage(HIGH_VOLTAGE);
}
2. Clock Gating
Clock gating is one of the simplest yet most effective techniques to save power. It involves shutting off the clocks to parts of the system that are not being used. For instance, if a peripheral is idle, its clock can be disabled to save energy.
Example Code:
if (peripheral_idle) {
    // Disable clock to the peripheral
    disable_clock(PERIPHERAL_CLOCK);
} else {
    // Enable clock to the peripheral
    enable_clock(PERIPHERAL_CLOCK);
}
3. PLL-Based Clock Management
When systems require high-frequency operation, but you want to minimize external clock sources, a Phase-Locked Loop (PLL) can be used to generate precise, high-frequency clocks from a low-frequency source. By adjusting the PLL multiplier, the system can obtain various clock frequencies without needing multiple external oscillators.
Example Code:
set_PLL_multiplier(PLLMULT_2X);
4. Adaptive Clocking
Adaptive clocking adjusts the clock frequencies based on environmental conditions, such as temperature or power consumption. This method is commonly used in automotive or industrial applications to ensure stable operation under varying conditions.
Best Practices for Clock Management in Embedded Systems
Understand the Power and Timing Requirements: Before implementing clock management, carefully analyze the system’s power requirements and timing constraints. This ensures that the clock management strategy aligns with the system’s operational goals.
Minimize Clock Sources: While external clock sources are necessary for certain high-precision tasks, minimizing the number of clock sources reduces complexity and power consumption. Use PLLs or internal oscillators where possible.
Efficient Use of Sleep Modes: Most embedded systems come with various sleep or idle modes that reduce power consumption. Integrate clock management with these modes, turning off unnecessary clocks when the system is in low-power states.
Implement Real-Time Monitoring: Continuously monitor clock states and adjust dynamically. Embedded systems can often benefit from real-time clock monitoring, especially in systems with multiple clock domains or variable load conditions.
Test Clock Handling in Different Conditions: Ensure that the system performs well under different clock frequencies, environmental conditions, and workload scenarios. Stability is key to ensuring the system operates without unexpected crashes or data corruption.
Real-World Applications of Clock Management
IoT Devices: These devices often run on battery power and require optimized clock management for power efficiency and extended battery life.
Automotive Systems: Automotive ECUs (Electronic Control Units) benefit from clock management to ensure reliability and performance, especially in real-time applications.
Wearables: Devices like smartwatches and fitness trackers need to manage clock frequencies efficiently to balance performance with battery longevity.
Consumer Electronics: Efficient clock management is key in modern electronics like smartphones, where power efficiency is essential.
Conclusion
Clock management is a cornerstone of embedded system design, ensuring that systems operate at peak efficiency without compromising performance or reliability. By leveraging techniques like clock gating, PLLs, and DVFS, developers can optimize both power consumption and system functionality.
Mastering clock management is essential for designing high-performance, power-efficient embedded systems. Whether you are working with microcontrollers, SoCs, or complex embedded architectures, understanding how to manage clocks effectively will lead to significant improvements in your designs.
Frequently Asked Questions (FAQ) on Clock Management in Embedded Systems
1. What is clock management in embedded systems?
Clock management refers to the techniques used to control and synchronize the timing signals (clocks) that drive different components of an embedded system. It involves managing clock sources, domains, and synchronization to optimize power consumption, performance, and stability.
2. Why is clock management important in embedded systems?
Effective clock management ensures that the system operates efficiently, balancing performance and power consumption. It also helps avoid system crashes, data corruption, and instability by synchronizing multiple clock domains and adjusting clock frequencies based on workload and power constraints.
3. What are clock domains?
A clock domain refers to a group of components in a system that are synchronized to the same clock signal. In embedded systems, different subsystems may operate in separate clock domains, which require careful synchronization to avoid data corruption and maintain system stability.
4. What is clock gating, and how does it help in power management?
Clock gating is a power-saving technique where the clock signal to inactive parts of the system is turned off. By disabling the clock to unused components, power consumption can be significantly reduced, making it an essential technique for energy-efficient embedded systems.
5. How does Dynamic Voltage and Frequency Scaling (DVFS) work in clock management?
DVFS dynamically adjusts the system’s clock frequency and voltage according to the workload. When the system is under low load, the clock frequency and voltage are reduced to save power. Conversely, when the load increases, the frequency and voltage are increased to maintain performance.
6. What is a Phase-Locked Loop (PLL) and how is it used in embedded systems?
A Phase-Locked Loop (PLL) is a circuit that synchronizes the frequency of a clock signal with a reference signal. In embedded systems, PLLs are used to generate high-precision clock signals from lower-frequency sources, ensuring that the system operates with accurate and stable timing.
7. What are the common techniques for clock synchronization in embedded systems?
Common techniques for clock synchronization include using PLLs, clock domain crossing (CDC) techniques, and using asynchronous FIFOs or buffers to ensure that data is correctly transferred between different clock domains.
8. How does clock management impact system stability?
Proper clock management ensures that all components within a system operate in sync, preventing timing mismatches that could lead to glitches, data loss, or system failures. Stable clock management is vital for the reliable operation of embedded systems, especially in real-time applications.
9. What is low-power clocking, and why is it important?
Low-power clocking involves adjusting the system’s clock frequencies or stopping clocks for unused peripherals to minimize energy consumption. This technique is especially important in battery-powered devices like wearables and IoT sensors where power efficiency is a primary concern.
10. What are the real-world applications of clock management in embedded systems?
Clock management is widely used in various embedded systems, such as IoT devices, automotive systems, wearables, and consumer electronics. It is crucial for ensuring that these devices operate efficiently, provide accurate timing, and conserve energy.
11. How can I implement clock management in my embedded project?
To implement clock management in your embedded project, you should:
Analyze the system’s power and timing requirements.
Select appropriate clock sources and configure PLLs.
Use techniques like clock gating and DVFS to manage power.
Ensure proper synchronization across different clock domains.
Integrate low-power modes and dynamically adjust clocks based on workload.
You can also Visit other tutorials of Embedded Prep
Direct Memory Access : In the world of embedded systems, microcontrollers, and modern computing, Direct Memory Access (DMA) is a powerful concept that dramatically improves system performance. Whether you’re a beginner or diving deeper into system architecture, understanding DMA is essential.
Imagine you’re designing a high-speed drone that streams live video to a control station. Every millisecond counts — if the video data lags, your drone’s operator could lose control.
You first try a normal approach: the CPU handles every task — reading sensor data, processing it, and sending it to memory. But the result? The CPU gets overloaded, the video stutters, and the drone’s performance suffers.
Then you discover Direct Memory Access (DMA) — a powerful technique that allows data to flow directly between memory and devices without involving the CPU. Suddenly, your drone streams smooth video, processes sensor data faster, and frees up the CPU for intelligent decision-making.
That’s the magic of DMA — a behind-the-scenes hero in high-performance computing. In this article, we’ll explore what DMA is, how it works, its advantages, disadvantages, and real-time applications that make it a game-changer in embedded systems and beyond.
Let’s break down DMAstep by step—from what it is to how it works and why it matters.
Meaning of DMA (Direct Memory Access)
Direct Memory Access (DMA) is a technique that allows hardware devices (like sensors, sound cards, or network cards) to directly read from or write to the system memory (RAM) without involving the CPU in each step of the data transfer.
In simple terms:
DMA = Data transfer without CPU interference
This feature frees the CPU from routine memory-handling tasks, allowing it to focus on critical processing instead of moving data back and forth.
Working Principle of DMA
Here’s how DMA works in a nutshell:
Peripheral requests DMA: A hardware device (like an ADC or UART) signals the DMA controller to start a transfer.
DMA controller takes charge: It communicates with the memory and initiates the transfer.
Data moves automatically: Data is sent from peripheral → memory or memory → peripheral, depending on the need.
Completion signal: DMA notifies the CPU via an interrupt or flag when the task is done.
This seamless transfer happens in the background, while the CPU continues with other operations.
Types of DMA
There are several modes or types of DMA depending on how data is transferred and how the CPU is affected:
1. Burst Mode DMA
Transfers an entire block of data at once.
CPU is paused during the operation.
Suitable for high-speed transfers.
2. Cycle Stealing DMA
DMA controller “steals” one CPU cycle at a time.
Slower than burst but lets CPU work in between.
Good for multitasking environments.
3. Block Transfer DMA
Similar to burst, but in smaller blocks.
CPU regains control after each block.
Balances speed and CPU availability.
4. Demand Mode DMA
DMA transfer happens only when the peripheral is ready.
It’s more dynamic and resource-efficient.
DMA Controller – The Brain Behind DMA
A DMA controller (DMAC) is a dedicated hardware component responsible for managing DMA operations. It includes:
Address register: Where to read/write data.
Count register: How much data to transfer.
Control logic: Determines transfer direction and method.
Some microcontrollers have built-in DMA channels, while others use external DMAC chips.
Why Use DMA? | Key Benefits
Using DMA significantly enhances system efficiency, especially in data-heavy or real-time applications. Here’s how:
1. Frees Up the CPU
CPU doesn’t get stuck doing data transfers.
More time for processing, decision-making, or running applications.
2. Speeds Up Data Transfers
DMA handles bulk data faster than CPU instructions.
Ideal for audio/video, communication, and high-speed sensors.
3. Reduces Latency
Less waiting time = better real-time performance.
4. Saves Power
Less CPU usage means lower energy consumption.
Great for battery-powered embedded systems.
Common Use Cases of DMA
Audio streaming: DMA moves audio data from memory to DAC without CPU.
Sensor reading: Continuous ADC sampling with DMA in embedded systems.
Networking: Fast packet processing using DMA.
Display refresh: High-speed framebuffer transfer in GUIs or TFT screens.
DMA in Embedded Systems
In microcontrollers like STM32, ESP32, or AVR, DMA is widely used to:
Read ADC data continuously.
Transfer data over SPI, UART, or I2C without delays.
Offload repetitive tasks from firmware loops.
How Does Direct Memory Access (DMA) Work?
Let’s understand how DMA works step by step, in a simple and clear manner:
Step-by-Step Working of DMA
1. Peripheral Requests Data Transfer
A hardware peripheral (like an ADC, UART, or SPI device) generates a DMA request. This request is sent to the DMA controller when data needs to be read from or written to memory.
Example: A temperature sensor sends data to the microcontroller. Instead of asking the CPU every time, it uses DMA.
2. DMA Controller Takes Control
Once the request is received, the DMA controller (DMAC) takes over the system data and address bus temporarily. The CPU pauses memory access for that short time.
3. Data is Transferred
The DMA controller moves the data:
From peripheral to RAM (e.g., sensor readings)
From RAM to peripheral (e.g., playing audio from memory)
It does this without the CPU executing read/write instructions.
4. CPU Works in Parallel
While DMA is busy transferring data, the CPU continues its main tasks, such as calculations, control logic, or user interface updates.
This is a major benefit—it prevents the CPU from being “blocked” by data transfer jobs.
5. Completion and Notification
When the data transfer is complete:
DMA raises an interrupt or sets a flag.
The CPU gets notified that the data transfer is done.
If needed, the CPU can then process or act on the received data.
Example Scenario , DMA Flow
Let’s say you want to read a stream of data from a temperature sensor (ADC):
Without DMA:
CPU repeatedly polls the ADC
CPU reads data
CPU writes data to memory
High CPU usage
With DMA:
CPU configures DMA once
DMA reads data from ADC and writes it to RAM
CPU gets interrupted only when the entire buffer is full
This reduces CPU load and speeds up the process.
Diagram Summary
Peripheral (ADC, UART, etc.)
         ↓
   DMA Request
         ↓
DMA Controller ───► RAM
         ↑             ↓
     CPU is notified (interrupt)
Practical Example of STM32 DMA
Practical example of using DMA on an STM32 microcontroller to transfer data from memory to a peripheral — specifically, transmitting a string over USART using DMA.
Objective:
Send a string "Hello, DMA!" over USART using DMA on an STM32 board (e.g., STM32F103C8T6 or STM32F4 series).
Prerequisites:
STM32CubeMX (to generate initialization code)
STM32CubeIDE (for coding and uploading)
USB to TTL serial converter for monitoring output
USART is enabled and working
DMA is enabled for USART TX
Steps:
1. Configure in STM32CubeMX:
Enable USART1 in Asynchronous mode.
Set Baud rate (e.g., 9600), TX enabled.
Enable DMA for USART1_TX (under DMA settings).
Generate code.
2. Code Example (main.c):
#include "main.h"
#include <string.h>

extern UART_HandleTypeDef huart1;

const char dmaMessage[] = "Hello, DMA!\r\n";

int main(void)
{
  HAL_Init();
  SystemClock_Config();
  MX_GPIO_Init();
  MX_USART1_UART_Init();
  MX_DMA_Init();

  // Start USART transmission using DMA
  HAL_UART_Transmit_DMA(&huart1, (uint8_t *)dmaMessage, strlen(dmaMessage));

  while (1)
  {
    // main loop can continue running while DMA handles transmission
  }
}
How It Works:
DMA controller handles transferring each byte from dmaMessage to USART TX register.
CPU is free to do other tasks during this time — great for performance.
Once complete, an optional DMA complete interrupt can be used for signaling.
Why Use DMA in STM32?
Offloads data transfer tasks from the CPU.
Useful for high-speed communication (e.g., ADC to memory, memory to UART/SPI).
Reduces power consumption and improves real-time performance.
Evolution and significance of DMA
DMA (Direct Memory Access) plays a crucial role in improving how data moves inside a computer system by allowing certain hardware devices to communicate with memory directly, without constantly relying on the CPU. This reduces the CPU’s workload and speeds up overall performance. Over the years, DMA technology has grown more advanced and flexible:
1950s–1970s (Early beginnings): In the early days, DMA was used in mainframe systems to reduce the CPU’s burden during data transfers. These early DMA systems could only handle basic data movement tasks, mostly involving simple block transfers between memory and I/O devices.
1980s (Peripheral integration): As personal computers became widespread, DMA started being used in systems with built-in hardware like hard drives and graphics cards. This helped improve system responsiveness by allowing these components to handle their own data movement.
1990s (Multimedia and networking): With the boom of audio, video, and internet applications, faster data movement became a necessity. DMA support grew to handle higher data rates and reduce delays. New DMA modes were introduced to deal with larger and more complex data loads efficiently.
2000s (Advanced buses): Hardware buses like PCI and PCIe were developed to allow faster communication between the CPU and connected devices. These improvements in system architecture allowed DMA transfers to become much quicker and more efficient.
2010s (Multi-core optimization): As CPUs with multiple cores became the standard, DMA controllers were updated to handle data transfers simultaneously across different processing cores. This helped in better parallelism and smoother performance in complex computing tasks.
2010s–2020s (Embedded and IoT systems): In recent years, DMA has become important for small and low-power devices like those used in IoT and embedded applications. Modern DMA controllers are now designed to work efficiently even with limited resources, making them ideal for compact and energy-efficient devices.
Direct Memory Access (DMA) Modes
DMA allows hardware devices to transfer data directly to or from memory without heavily relying on the CPU, improving performance in data-intensive operations. Below are the distinct DMA modes, each tailored for specific transfer needs:
Block Transfer Mode (Burst Mode) In block mode, the DMA controller gains temporary exclusive access to the system bus and transfers an entire block of data in one go. This uninterrupted sequence minimizes bus control overhead, making it ideal for high-speed data transfers like audio or video streaming. Once the block is transferred, the bus is released back to the CPU.
Demand Transfer Mode Here, the DMA controller remains passive until an external device or the CPU asserts a request signal. Upon detection, the controller initiates the data transfer and halts when the demand ceases. This on-demand nature makes it efficient for devices that generate sporadic data, such as printers or network cards.
Cycle Stealing Mode This mode enables the DMA controller to intermittently “steal” single bus cycles from the CPU. Instead of taking full control like in burst mode, it transfers data in small units during the CPU’s idle or less-critical operations. It’s a balanced approach where both CPU and DMA can function without major disruption.
Fly-By Mode (Transfer-on-the-Fly) Fly-by DMA doesn’t temporarily store data in the controller; instead, it streams data directly between a peripheral and memory. The data “flies by” the DMA controller without halting, enabling real-time data movement between two endpoints—especially useful in audio and graphics where latency must be minimal.
Pros of Direct Memory Access
Faster Data Transfer
DMA enables peripherals (like disk drives, sound cards, etc.) to transfer data to/from memory without CPU involvement, significantly increasing throughput.
CPU Offloading
Since the CPU is not burdened with data movement, it can perform other tasks, improving overall system performance.
Efficient I/O Handling
DMA is ideal for high-speed I/O operations, such as file transfers, network communication, and audio/video streaming.
Low Latency
Minimizes the delay between data request and response, crucial in real-time systems.
Reduces Interrupt Overhead
Fewer CPU interrupts are needed, as DMA can transfer large blocks of data with a single interrupt.
Cons of Direct Memory Access
Complex Hardware and Software Design
Requires additional hardware (DMA controller) and more sophisticated software logic for buffer management and error handling.
Memory Access Conflicts
The CPU and DMA controller may compete for memory access, leading to bus contention or slower memory access for the CPU.
Security Risks
Direct access to memory can be a security risk if unauthorized devices or malicious code utilize DMA improperly.
Debugging Difficulty
DMA operations are less visible to traditional debugging tools, making errors harder to trace and fix.
Limited Control
CPU has less real-time control over the data transfer process, which may be problematic in certain tightly timed operations.
Direct Memory Access (DMA) interview questions :
Now that you have a comprehensive understanding of Direct Memory Access (DMA), you are well-equipped to confidently solve related problems and excel in interviews in one shot. Focus on mastering questions such as
Basic Level Questions
What is Direct Memory Access (DMA)?
Why is DMA used in embedded systems?
How does DMA differ from programmed I/O and interrupt-driven I/O?
What are the advantages of using DMA?
What are the typical components involved in a DMA transfer?
Intermediate Level Questions
Describe how DMA transfer works step-by-step.
What is a DMA controller, and what is its role?
How does DMA reduce CPU overhead?
What are the different types of DMA transfers (e.g., burst, cycle stealing, block)?
Explain the difference between memory-to-memory and peripheral-to-memory DMA transfers.
Advanced Level Questions
How is DMA implemented in a specific microcontroller (e.g., STM32, ARM Cortex-M)?
What are some challenges in using DMA in real-time systems?
How do you handle data integrity and synchronization when using DMA?
How can DMA lead to memory contention or bus arbitration issues?
Explain how to configure a DMA transfer in an RTOS environment.
How do you debug DMA-related issues in embedded systems?
What security concerns arise from using DMA?
How can you implement double buffering using DMA?
How does cache memory affect DMA performance?
What is scatter-gather DMA and where is it used?
Direct Memory Access (DMA) – FAQ
1. What is DMA and why is it important?
Answer: DMA (Direct Memory Access) allows peripherals to read/write memory directly without CPU intervention. It’s important for fast, efficient data transfers, especially in high-speed or real-time applications.
2. How does DMA work?
Answer: DMA works by using a DMA controller which handles data transfers between memory and a peripheral. The CPU initializes the DMA with source, destination, and transfer size, and then the DMA controller takes over the transfer autonomously.
3. What are the advantages of using DMA?
Answer:
Faster data transfers
Reduced CPU workload
Better multitasking performance
Lower interrupt overhead
Ideal for real-time systems
4. What are the types of DMA transfer modes?
Answer:
Burst mode: DMA transfers the entire block in one go.
Cycle stealing: DMA takes control of the bus for each word, allowing CPU and DMA to share access.
Transparent mode: DMA transfers data only when CPU is not using the system bus.
5. What are some use cases for DMA?
Answer:
Audio/video streaming
File transfers from SD cards or flash memory
ADC data reading
Communication interfaces (SPI, UART, I2C)
6. What is the role of the DMA controller?
Answer: The DMA controller manages the transfer process, including address counting, triggering, handshaking with peripherals, and generating interrupts upon completion.
7. What is double buffering in DMA?
Answer: Double buffering uses two memory buffers. While one is being filled by DMA, the other is processed by the CPU. It ensures continuous data flow without gaps or delays.
8. What is scatter-gather DMA?
Answer: Scatter-gather allows non-contiguous memory segments to be transferred using a linked list of descriptors. It is used in complex data transfer scenarios like multimedia processing and networking.
9. Can DMA and CPU access the same memory simultaneously?
Answer: Yes, but they may compete for memory access, causing bus contention. Many systems have bus arbitration mechanisms to manage this.
10. Is DMA safe to use in all systems?
Answer: No. Improper use can lead to:
Security risks (e.g., unauthorized memory access)
Data corruption
Difficult debugging
Proper configuration, memory protection, and cache coherency handling are required.
You can also Visit other tutorials of Embedded Prep
Low Power Modes : In today’s world, where battery life and energy consumption are crucial factors for many devices, low power modes play an essential role. Whether you’re working on embedded systems, mobile applications, or IoT devices, understanding low power modes is vital for creating energy-efficient and long-lasting devices. This beginner-friendly guide will take you through the concept of low power modes, why they are important, and how to implement them in your projects.
What are Low Power Modes?
Low power modes refer to the operational states of a device that consume minimal power while still being able to perform necessary tasks. These modes are commonly used in devices like smartphones, wearables, IoT sensors, and embedded systems to extend battery life, reduce heat generation, and improve overall energy efficiency.
When a device enters a low power mode, it minimizes the use of its processing power, peripheral devices, and sensors, keeping only the essential functions active. In some cases, it may shut down non-essential systems to save energy.
Types of Low Power Modes
Active Mode This is the normal operation mode where the device is fully powered, and all components, including the CPU, sensors, and peripherals, are active. While it consumes more power, it ensures that the device can perform all tasks in real-time.
Idle Mode In idle mode, the CPU may be inactive or running at a reduced clock speed. However, the system remains ready to resume active tasks immediately. Idle mode is used when the device isn’t performing any heavy tasks, but it still needs to be responsive.
Sleep Mode Sleep mode is a deeper low-power state compared to idle mode. In this mode, the CPU and many peripherals are powered down, but the device still retains enough power to wake up when needed (e.g., when a button is pressed or an interrupt occurs). There are typically several sleep modes, each with varying levels of power consumption.
Deep Sleep Mode Deep sleep mode is a more advanced form of sleep mode, where almost all components are powered off except for a few essential ones like the Real-Time Clock (RTC) or low-power timers. This mode is typically used in battery-operated devices to maximize battery life, as the device draws minimal current while in this state.
Hibernate Mode Hibernate mode saves the device’s current state to non-volatile memory (like Flash storage) and shuts down most of the device, including the CPU. It is the deepest low power mode and is used when the device does not need to perform any tasks for an extended period. On resuming, the device restores its state, allowing it to continue where it left off.
Why are Low Power Modes Important?
Low power modes are crucial for several reasons:
Battery Efficiency: In portable devices like smartphones, wearables, and IoT sensors, battery life is essential. By using low power modes, devices can run longer without frequent recharging.
Thermal Management: Reducing power consumption reduces the heat generated by components. This is especially important in small form-factor devices or those operating in extreme environments.
Sustainability: In large-scale networks of connected devices (like smart cities or agriculture monitoring systems), reducing the overall power consumption can contribute to environmental sustainability.
Cost Savings: For companies developing devices that rely on battery power, using low power modes can reduce the need for larger, more expensive batteries, leading to lower costs in manufacturing.
How to Implement Low Power Modes in Your Projects
Implementing low power modes can vary depending on the platform you are working with, such as microcontrollers, embedded systems, or mobile devices. Below are some general guidelines for implementing low power modes in embedded systems:
Choose the Right Microcontroller or Processor Different microcontrollers have different power-saving capabilities. For instance, ARM Cortex-M series microcontrollers come with built-in low-power features like sleep modes, deep sleep modes, and power gating options that allow you to control the power consumption of individual peripherals.
Use Sleep Modes Efficiently Use sleep modes when the system is idle. Most microcontrollers allow you to put the CPU to sleep while keeping peripherals like timers or interrupts active. This can significantly reduce power consumption while still allowing the system to wake up and perform tasks as needed.
Optimize Peripherals Disable any unused peripherals (such as communication interfaces like UART, SPI, or I2C) when they are not needed. By turning off unused components, you can reduce the overall power consumption of the device.
Power Gating Power gating is the process of cutting off power to certain blocks of the chip when they are not in use. This technique can be used to reduce power consumption in both active and low-power modes.
Dynamic Voltage and Frequency Scaling (DVFS) DVFS involves adjusting the voltage and frequency of the processor dynamically based on the workload. Lowering the frequency and voltage during low-demand periods can reduce power consumption while maintaining the required performance for tasks.
Optimize Firmware and Software Efficient coding practices can help in reducing power consumption. For instance, minimizing the time the CPU spends in active mode, implementing efficient algorithms, and reducing unnecessary sensor polling are all good practices for power efficiency.
Examples of Low Power Modes in Action
Here are a few practical examples of how low power modes are implemented in embedded systems:
Arduino: The Arduino platform offers a sleep() function, allowing you to put the device into sleep mode. You can also use the LowPower library to implement different low power modes like deep sleep, where the Arduino consumes very little power, ideal for battery-operated devices.
ESP32: The ESP32, a popular microcontroller for IoT devices, has several deep sleep modes. It also offers a “light sleep” mode where the CPU is paused, and the device can quickly resume to active mode when an event occurs (like an interrupt).
STM32: STM32 microcontrollers have various low-power modes such as Sleep Mode, Stop Mode, and Standby Mode. These modes can be configured to optimize power consumption based on the system requirements.
Best Practices for Optimizing Low Power Consumption
Minimize Active Time: Limit the time the device spends in active mode. Only keep the device fully awake when necessary.
Use Interrupts Instead of Polling: Interrupt-driven designs are more power-efficient than polling-based designs, as the device stays in low-power mode until an interrupt triggers an action.
Tune Timers and Peripherals: Configure timers and peripherals to wake the system only when needed. Use low-power peripherals that consume minimal energy.
Power Management Libraries: Use available power management libraries provided by microcontroller manufacturers. These libraries simplify the process of implementing low power modes by providing functions for sleep, wake-up, and power control.
Conclusion
Low power modes are a critical aspect of modern embedded systems, IoT devices, and mobile applications. Understanding how to use and implement these modes will help you create energy-efficient, long-lasting devices. By choosing the right microcontroller, optimizing software, and using hardware features like sleep modes and power gating, you can significantly reduce the energy consumption of your projects.
Whether you’re working on a battery-powered device or an energy-efficient embedded system, mastering low power modes is essential for achieving the best performance while conserving power. So, start implementing these techniques in your next project and experience the benefits of longer battery life and lower energy consumption.
PWM Pulse Width Modulation : PWM stands for Pulse Width Modulation, a technique used to control the amount of power delivered to electrical devices. It is widely used in electronics, especially when dealing with motors, LEDs, and audio signals. PWM allows you to control the intensity, speed, or output of a device without changing the voltage — just by adjusting the signal’s duty cycle.In electronic engineering, PWM (Pulse Width Modulation) is a powerful technique used to control the power delivered to electronic devices. It is especially useful when you want to simulate analog output using digital signals.
PWM is commonly used in microcontrollers like Arduino, Raspberry Pi, and ESP32 to control devices such as LEDs, motors, and buzzers.
Why is PWM Important?
PWM is essential for many embedded systems and electrical engineering applications. Instead of sending a constant voltage, PWM sends a series of ON and OFF signals (called pulses). By varying how long the signal stays ON vs OFF, we can efficiently control the output without wasting energy as heat.
How PWM Works – The Basics
PWM works by switching a digital signal ON and OFF very quickly. The signal looks like a square wave, where the “HIGH” means ON and “LOW” means OFF.
Instead of giving full power all the time, you control how long the signal stays ON in each cycle. This gives the effect of partial power.
Key Concepts:
Duty Cycle: The percentage of time the signal is ON in one cycle.
0% = always OFF
50% = ON half the time
100% = always ON
Frequency: How fast the PWM signal cycles between ON and OFF. It’s measured in Hertz (Hz). A higher frequency gives smoother control.
Real-Life Examples of PWM
LED Dimming: PWM adjusts LED brightness by controlling how long it stays ON vs OFF.
Motor Speed Control: PWM drives DC motors at variable speeds using the same voltage.
Audio Signal Generation: PWM is used to generate and shape sound waves in digital audio systems.
Heater and Fan Control: In HVAC systems, PWM provides precise thermal and airflow control.
PWM with Arduino (Beginner Code Example)
Here’s a simple Arduino example to dim an LED using PWM:
This code increases and decreases the LED brightness smoothly using PWM.
A Pulse Width Modulation (PWM) signal is generated by rapidly switching a digital output pin ON and OFF at a fixed frequency, while varying the duration of the ON time (duty cycle) within each cycle. This switching creates a waveform that mimics an analog signal’s average power over time.
How PWM Signal is Generated – Step-by-Step
1. Select a PWM Frequency
Frequency defines how fast the signal repeats each cycle.
Common values: 490 Hz, 1 kHz, 20 kHz (used in motors, audio, LED dimming).
2. Set a Duty Cycle
This is the percentage of time the signal stays ON in one cycle.
For example:
25% duty cycle: ON for 25% of the time, OFF for 75%
75% duty cycle: ON for 75% of the time, OFF for 25%
3. Toggle the Digital Pin Accordingly
Use a timer or counter (hardware or software) to toggle the pin:
In Microcontrollers (like Arduino):
The hardware timers generate PWM by:
Counting clock pulses
Comparing the counter to a set value
Turning output HIGH until the match is reached
Resetting the counter to repeat the cycle
Software Example (Pseudocode):
loop every 1 ms {
  if (time < ON_time) {
    setPinHigh();
  } else {
    setPinLow();
  }
}
This code sends a square wave on pin 9 with a 50% duty cycle, effectively simulating half power output.
Important parameters associated with a PWM (Pulse Width Modulation)
1. Duty Cycle (%)
What It Is:
The percentage of one cycle in which the signal is HIGH (ON).
Formula:
Duty Cycle = (ON Time / Total Time) × 100%
Example:
0% = Always OFF
50% = ON half the time
100% = Always ON
Importance:
Controls the average power delivered to a device.
2. Frequency (Hz)
What It Is:
The number of PWM cycles per second.
Formula:
Frequency = 1 / Period
Example:
1 kHz = 1000 cycles per second
Importance:
Low frequency → Visible flicker (LEDs), noise (motors)
High frequency → Smoother response but harder on switching circuits
3. Period (T)
What It Is:
The total time for one complete PWM cycle.
Formula:
Period = 1 / Frequency
Importance:
Gives insight into how long each ON and OFF phase can last.
4. Resolution (Bits)
What It Is:
The number of discrete levels for duty cycle adjustment.
Example:
8-bit = 256 levels (0–255)
10-bit = 1024 levels (0–1023)
Importance:
Higher resolution = finer control over output (e.g., smoother dimming or speed control).
5. Pulse Width (ON Time)
What It Is:
The actual duration the signal stays HIGH in a single cycle.
Formula:
Pulse Width = Duty Cycle × Period
Importance:
Used to determine how much energy is transferred to the load during each cycle.
6. Rise Time / Fall Time
What It Is:
Rise Time: Time taken for signal to go from LOW to HIGH.
Fall Time: Time taken for signal to go from HIGH to LOW.
Importance:
Critical in high-speed or precision circuits, affects signal integrity and efficiency.
Summary Table
Parameter
Description
Units
Duty Cycle
% of time signal is ON
%
Frequency
Number of PWM cycles per second
Hertz (Hz)
Period
Time for one complete PWM cycle
Seconds (s)
Resolution
Levels of control over duty cycle
Bits
Pulse Width
Actual ON duration per cycle
Seconds (s)
Rise/Fall Time
Time to switch between states
Seconds (s)
Pulse Position Modulation vs. Pulse Width Modulation
Feature
Pulse Width Modulation (PWM)
Pulse Position Modulation (PPM)
Definition
Modulates the width (duration) of the pulse
Modulates the position (timing) of the pulse
How It Works
Varies how long the signal stays ON within a fixed period
Keeps the pulse width fixed but shifts its position in time
Signal Type
Pulse duration varies; position is fixed
Pulse position varies; duration is fixed
Duty Cycle
A key parameter (affects power output)
Not applicable
Timing Accuracy
Less sensitive to timing errors
Highly sensitive to synchronization and timing accuracy
Power Control
Excellent for power control in motors, LEDs, etc.
Less effective for power control
Analog Representation
Average voltage corresponds to analog input level
Pulse position corresponds to analog signal amplitude
Noise Immunity
Better resistance to noise and interference
More prone to noise due to time shift sensitivity
Hardware Complexity
Easier to generate with timers (common in microcontrollers)
More complex; needs precise timing circuits
Example Use Cases
Motor speed control, LED dimming, audio, power management
Remote control systems, optical communication
In Simple Terms:
PWM (Pulse Width Modulation): ➤ “Change the length of the pulse, but send it at the same time every cycle.” ➤ Best for controlling power, like in fans, lights, and speakers.
PPM (Pulse Position Modulation): ➤ “Send the pulse at different times, but keep its width the same.” ➤ Best for data transmission, like in radio control or optical links.
|‾|___     Low signal
___|‾|_     Medium signal
______|‾|  High signal
Types of Pulse Width Modulation Techniques Explained
Pulse Width Modulation (PWM) is a powerful method used to control power delivery by switching signals ON and OFF rapidly. While PWM always controls the duty cycle, there are several ways to implement PWM based on what is varied: width, leading edge, or trailing edge.
1. Leading Edge Modulation (LEM) / Trail Constant PWM
Description:
The rising edge (start of the pulse) is fixed.
The falling edge (end of the pulse) is varied to change the pulse width.
Diagram:
|‾‾‾|_____
|‾‾‾‾‾|___
|‾‾|______
Use Case:
Common in motor control and power supplies where starting edge alignment is needed.
2. Trailing Edge Modulation (TEM) / Lead Constant PWM
Description:
The falling edge (end of the pulse) is fixed.
The rising edge is moved to change the width.
Diagram:
__|‾‾‾|
_|‾‾‾‾‾|
___|‾‾|
Use Case:
Often used in digital circuits, especially when a clean pulse end is required for synchronization.
3. Center-Aligned PWM (Symmetric PWM)
Description:
The pulse is centered in the middle of the period.
Both rising and falling edges are varied symmetrically to maintain the center.
Diagram:
__|‾‾|__
_|‾‾‾‾‾|_
|‾‾‾‾‾‾‾|
Use Case:
Ideal for motor drives and inverters to minimize harmonic distortion.
4. Phase-Correct PWM
Description:
Counter counts up and then down (rather than resetting to 0), producing a symmetrical waveform.
Benefit:
Eliminates phase shift and reduces noise in sensitive applications.
Use Case:
Found in applications like servo motor control and DC motor speed control.
Summary Table
PWM Type
Fixed Edge
Variable Edge
Best Used In
Leading Edge Modulation
Rising (Start)
Falling (End)
Power electronics, SMPS
Trailing Edge Modulation
Falling (End)
Rising (Start)
Digital and timing-sensitive apps
Center-Aligned PWM
Centered Pulse
Both Edges
AC motor drives, inverters
Phase-Correct PWM
Symmetric Count
Time-balanced
Servo motors, precision control
1. PWM Using Arduino (ATmega328p)
The Arduino UNO uses an 8-bit timer by default for PWM. It typically supports Fast PWM and Phase Correct PWM.
Basic Fast PWM (e.g., Trailing Edge Modulation)
// Generates PWM on pin 9 with 50% duty cycle
void setup() {
  pinMode(9, OUTPUT);
  analogWrite(9, 127); // 127 = ~50% of 255
}

void loop() {
  // Nothing needed here for static PWM
}
Phase Correct PWM (Using Timer1 Directly)
This gives symmetrical PWM for precision applications.
void setup() {
  pinMode(9, OUTPUT); // OC1A pin

  // Configure Timer1 for Phase Correct PWM
  TCCR1A = (1 << COM1A1) | (1 << WGM11);
  TCCR1B = (1 << WGM13) | (1 << CS11); // Prescaler = 8
  ICR1 = 39999;       // TOP value (for 50 Hz PWM)
  OCR1A = 2999;       // Duty cycle = 7.5% (centered)
}

void loop() {
  // You can adjust OCR1A dynamically for servo control
}
2. PWM Using STM32 (HAL-based, Center-Aligned & Edge PWM)
STM32 microcontrollers offer flexible PWM control using TIMx timers.
Center-Aligned PWM (HAL/STM32CubeIDE)
Set the timer in Center-Aligned Mode 1:
// Pseudo-code for STM32 HAL (CubeMX generated setup assumed)
HAL_TIM_PWM_Start(&htim1, TIM_CHANNEL_1);
__HAL_TIM_SET_COMPARE(&htim1, TIM_CHANNEL_1, pulseValue);
Efficient Power Control: Less heat and energy waste.
Digital Control: Easy to implement using microcontrollers.
High Precision: Fine-grained control over devices.
Low Cost: No need for complex analog circuits.
Common Devices that Use PWM
Servo Motors
DC Motors
LED drivers
Power supplies
Embedded systems (like Arduino, ESP32, STM32)
Conclusion
PWM (Pulse Width Modulation) is a powerful and energy-efficient technique to control electrical devices using digital signals. From dimming lights to controlling motors, PWM is everywhere in electronics. If you’re starting your journey in embedded systems or electronics, mastering PWM will open the doors to building exciting and dynamic projects.
What are the applications of PWM in embedded systems?
How does PWM simulate analog output using digital signals?
What is the typical frequency range used in PWM?
What is the difference between duty cycle and frequency?
How does changing the duty cycle affect motor speed or LED brightness?
Which microcontroller pins are used for PWM output in Arduino?
What is the default PWM frequency on Arduino’s analogWrite()?
Can PWM signal be used to control both AC and DC devices?
Intermediate PWM Interview Questions
What are the different PWM modes in microcontrollers (e.g., Fast PWM, Phase Correct PWM)?
Explain how center-aligned PWM differs from edge-aligned PWM.
How is PWM implemented using timers?
What is the impact of frequency on the performance of a PWM system?
How do you generate a PWM signal using a timer peripheral in STM32?
What are the drawbacks of using PWM?
Explain how you would generate a 1 kHz PWM signal with 75% duty cycle.
What are dead-time and its importance in PWM-based motor control?
What is jitter in PWM signals, and how does it affect performance?
Describe how a low-pass filter converts a PWM signal into analog voltage.
Advanced PWM Interview Questions
How would you implement software PWM without using a hardware timer?
Explain the difference between Pulse Width Modulation (PWM) and Pulse Position Modulation (PPM).
How is PWM used in Class-D audio amplifiers?
What are harmonics in PWM, and how can they be reduced?
How would you synchronize multiple PWM channels in real-time control systems?
Describe how PWM is used in buck/boost converters.
What techniques are used to improve PWM resolution in low-frequency systems?
How is complementary PWM used in full-bridge motor driver circuits?
Explain phase-shifted PWM and its applications.
How does the resolution (bit-depth) of PWM affect output quality?
Frequently Asked Questions (FAQs) on PWM (Pulse Width Modulation)
What is PWM (Pulse Width Modulation)?
PWM (Pulse Width Modulation) is a technique used to control the average power delivered to electronic devices by rapidly switching the signal between ON and OFF states. The duty cycle determines how long the signal stays ON during one cycle.
What is the duty cycle in PWM?
The duty cycle is the percentage of one period in which the signal is ON. For example:
0% duty cycle = always OFF
100% duty cycle = always ON
50% duty cycle = ON for half the time
Where is PWM used?
PWM is commonly used in:
Motor speed control
LED dimming
Audio signal generation
Power delivery systems
Servo control (robotics, RC models)
How is PWM different from analog voltage?
PWM uses digital signals (ON/OFF pulses) to simulate analog output by changing the duty cycle. The average voltage over time can mimic analog behavior without using a true analog signal.
What are the types of PWM techniques?
The major types of PWM include:
Leading Edge Modulation (Fixed rising edge)
Trailing Edge Modulation (Fixed falling edge)
Center-Aligned PWM (Pulse is centered)
Phase-Correct PWM (Symmetrical counting)
What’s the difference between PWM and PPM?
PWM (Pulse Width Modulation) varies the pulse width to encode data or control power.
PPM (Pulse Position Modulation) varies the position of a constant-width pulse within a time frame.
How do I generate PWM in Arduino?
Use the built-in analogWrite(pin, value) function. It takes a value between 0–255, where:
0 = 0% duty cycle (always OFF)
255 = 100% duty cycle (always ON)
Example:
analogWrite(9, 127); // ~50% duty cycle on pin 9
How do I control motor speed using PWM?
PWM controls the motor’s speed by adjusting the average voltage supplied to the motor. A higher duty cycle = more speed; a lower duty cycle = slower speed.
Does PWM waste energy like linear voltage control?
No. PWM is more energy-efficient because the switching components (like transistors) are either fully ON or fully OFF, which reduces power loss.
Can PWM be used for audio signals?
Yes. PWM can represent analog waveforms such as audio tones. After low-pass filtering, the PWM signal can be used to produce audible sound.
You can also Visit other tutorials of Embedded Prep
Digital to Analog Converter : In the world of electronics and embedded systems, Digital to Analog Converters (DACs) play a crucial role in bridging the gap between the digital and analog domains. Most real-world signals, such as sound, light, and temperature, are analog, whereas microcontrollers and computers work with digital values (0s and 1s). A DAC converts these digital signals into analog output, enabling digital systems to interact with the real world.
What is a DAC?
A Digital to Analog Converter (DAC) is an electronic component or system that converts digital binary data (e.g., 10101010) into an equivalent analog voltage or current signal. It is the reverse of an Analog to Digital Converter (ADC).
Why is DAC Important?
DACs are essential in applications where digital devices need to produce real-world analog signals, such as:
Audio playback systems (e.g., smartphones, MP3 players)
Video displays
Signal generators
Control systems
Motor speed control
Industrial automation
How DAC Works: Simple Explanation
Imagine you want to play music stored in digital format (MP3) on a speaker. The microcontroller reads the music as digital numbers. To make the speaker vibrate and produce sound, it needs analog signals. A DAC takes those digital numbers and converts them into analog voltages, which can then be sent to the speaker.
Types of DAC
Binary Weighted DAC
Uses resistors weighted in powers of 2.
Simple but not practical for higher resolutions.
R-2R Ladder DAC
Uses only two resistor values (R and 2R).
Easier to fabricate and commonly used.
Sigma-Delta DAC
Very high resolution.
Often used in audio applications.
PWM DAC (Pulse Width Modulation)
Uses digital pulses and a low-pass filter.
Simple and used in microcontroller-based applications.
Digital Input (e.g., 8-bit) ──► DAC ──► Analog Output (Voltage)
For example:
Digital Input
Analog Output (for 8-bit, 5V range)
00000000
0V
10000000
~2.5V
11111111
~5V
Practical Example with Arduino (PWM-based DAC)
// Generates an analog output using PWM
int outputPin = 9; // PWM pin

void setup() {
  pinMode(outputPin, OUTPUT);
}

void loop() {
  analogWrite(outputPin, 128); // ~50% duty cycle → ~2.5V analog
}
Note: Use a low-pass RC filter to smooth the PWM signal into true analog.
Key Specifications of DAC
Resolution: Number of bits (e.g., 8-bit, 10-bit, 12-bit)
Sampling Rate: Speed at which data is converted
Output Range: Voltage or current output range
Linearity: Accuracy of conversion
DAC Applications in Real World
Audio Devices: Converts digital audio to analog sound.
Mobile Phones: For speaker output and display brightness control.
Medical Instruments: For accurate signal output.
Automotive Systems: For dashboard meters, speed control.
DAC vs ADC: Key Difference
Feature
DAC
ADC
Function
Digital → Analog
Analog → Digital
Example Use Case
Audio playback
Temperature sensor reading
Signal Direction
Output
Input
Conclusion
A Digital to Analog Converter (DAC) is a vital component in any system that outputs analog signals based on digital data. Whether you’re building an audio system, controlling a motor, or designing a smart device, understanding DACs is essential for creating real-world interfacing applications.
Interview questions related to Digital to Analog Converters (DAC) :
Basic Understanding of DAC:
What is a Digital to Analog Converter (DAC)?
Why do we need a DAC in embedded systems or electronics?
What are the main differences between DAC and ADC (Analog to Digital Converter)?
Explain the working principle of a DAC.
What is the role of a DAC in audio systems?
What types of signals can a DAC generate from digital input?
Can you explain how DACs are used in real-world applications like audio devices or medical equipment?
DAC Types and Technologies:
What are the different types of DACs?
Explain the working of a Binary Weighted DAC.
What is an R-2R Ladder DAC, and how does it work?
How does a Sigma-Delta DAC differ from other types of DACs?
What is a PWM DAC, and why is it commonly used in microcontroller systems?
What are the advantages of using an R-2R DAC over a Binary Weighted DAC?
DAC Performance and Characteristics:
What is the resolution of a DAC, and how is it related to its bit depth?
What is the significance of DAC resolution, and how does it affect the output signal?
What is a DAC’s sampling rate, and why is it important?
What do you understand by the linearity of a DAC, and why is it important for accurate signal conversion?
What is the output range of a DAC, and how does it depend on the reference voltage?
What factors affect the performance of a DAC?
Practical Applications and Usage:
Can you describe how to use a DAC in a microcontroller-based system?
How would you implement a DAC in an Arduino project?
How is a DAC used in audio playback systems?
What challenges might arise when designing a DAC for high-fidelity audio applications?
How would you use a low-pass filter with a PWM DAC to smooth the signal?
What are some common issues with DACs, and how can they be mitigated?
Troubleshooting and Testing:
How can you test the output of a DAC?
What tools are commonly used to troubleshoot DAC circuits?
What are some common issues you might face when using DACs in real-world applications?
How would you debug a problem where the DAC output is not as expected?
Advanced Topics:
What is the difference between a DAC with a high resolution vs. one with a low resolution?
What are some common challenges when designing DAC circuits for embedded systems?
Can you explain the concept of “quantization error” in DACs?
What is the role of DAC in digital audio conversion and its impact on sound quality?
FAQ: Digital to Analog Converter (DAC)
Q1. What is a DAC in electronics?
A: A DAC (Digital to Analog Converter) is an electronic device that converts digital data (binary format) into an analog signal (voltage or current). It’s commonly used to interface digital systems with the real world.
Q2. Where is DAC used in real life?
A: DACs are used in various real-life applications such as:
Audio devices (smartphones, MP3 players)
Televisions and displays
Signal generators
Industrial control systems
Medical equipment
Q3. What is the difference between DAC and ADC?
A:
DAC
ADC
Converts digital to analog
Converts analog to digital
Used for output signals
Used for input signals
Example: Speaker output
Example: Sensor input
Q4. What are the types of DAC?
A: Common types of DAC include:
Binary Weighted DAC
R-2R Ladder DAC
Sigma-Delta DAC
PWM-based DAC
Each has different characteristics suited for specific applications.
Q5. How is DAC resolution calculated?
A: DAC resolution is based on the number of bits. For example:
An 8-bit DAC provides 256 discrete levels.
A 10-bit DAC provides 1024 levels.
Resolution = Vref2n−1\frac{V_{ref}}{2^n – 1}, where nn = number of bits.
Q6. Can a microcontroller generate analog output?
A: Yes. Many microcontrollers simulate analog output using PWM (Pulse Width Modulation) with DAC-like behavior when filtered with an RC circuit. Some advanced microcontrollers have built-in DACs.
Q7. What is the use of a low-pass filter with PWM DAC?
A: A low-pass filter smooths the PWM signal to eliminate high-frequency components, converting the digital pulses into a steady analog voltage.
Q8. Which is better: R-2R Ladder DAC or Binary Weighted DAC?
A: The R-2R Ladder DAC is preferred in practice because it uses only two resistor values, making it easier to fabricate accurately and cost-effectively.
Q9. Is DAC needed for audio output?
A: Yes. Audio signals are analog. DAC is essential in any digital audio system to convert stored digital audio data into analog waveforms that speakers can play.
Q10. How do I test DAC output?
A: You can test DAC output using:
An oscilloscope (to see the waveform)
A multimeter (to measure voltage)
An amplifier and speaker (to hear audio output if applicable)
You can also Visit other tutorials of Embedded Prep
Master ADC (Analog to Digital Converter)? [Beginner-Friendly Guide 2025]
Introduction to ADC
An Analog to Digital Converter (ADC) is an essential electronic component that converts analog signals (continuous) into digital signals (discrete binary values). This is crucial because microcontrollers and computers can only process digital data.
Example: A temperature sensor gives analog voltage, but to display it on a digital screen or use it in calculations, it needs to be converted using an ADC.
Why is ADC Important?
🖥️ Microcontrollers can’t understand analog signals. ADC bridges this gap.
📷 Used in cameras, smartphones, IoT devices, and more.
🎧 Converts sound waves (analog) to digital for music players or voice assistants.
Types of ADC
Flash ADC – Fastest, used in high-speed applications.
Successive Approximation ADC (SAR) – Most common in microcontrollers.
Dual Slope ADC – Used in digital multimeters.
Sigma-Delta ADC – High resolution, used in audio and precision devices.
ADC Resolution Explained
Resolution means how finely the analog voltage is broken into steps.
Resolution
Number of Levels
Example (5V reference)
8-bit
256
5V/256 = ~0.0195V/step
10-bit
1024
5V/1024 = ~0.00488V/step
12-bit
4096
5V/4096 = ~0.00122V/step
Sampling Rate
The sampling rate is how many times per second the ADC samples the analog signal. It’s measured in samples per second (SPS) or Hz.
Higher sampling rate = more accurate representation of rapidly changing signals.
Common ADC Parameters to Know
Term
Meaning
Input Range
Allowed voltage range (e.g., 0–3.3V)
Reference Voltage
Maximum voltage ADC compares to
Resolution
Number of bits
Sampling Rate
Frequency of reading
Accuracy
How close the digital output is to real analog value
Reference Voltage = maximum voltage ADC can handle (e.g., 5V)
Behind the Scenes (SAR ADC Example)
Most microcontrollers (like Arduino) use Successive Approximation Register (SAR) ADC. Here’s how it works internally:
A sample-and-hold circuit captures and holds the input voltage.
The SAR ADC uses a binary search method to find the digital value closest to the input.
It starts from the MSB (Most Significant Bit) and moves to LSB (Least Significant Bit), adjusting with a comparator and DAC.
This allows fast and efficient conversion with minimal hardware.
Summary Table of Analog to Digital Converter
Step
Process
Output
1. Sampling
Takes voltage at regular intervals
Analog voltage snapshot
2. Quantization
Assigns voltage to a level
Discrete step
3. Encoding
Converts to binary
Digital value
Configure the ADC (Analog to Digital Converter) in an STM32F407 MCU
To configure the ADC (Analog-to-Digital Converter) in an STM32F407 microcontroller, you can either do it directly via registers or use STM32CubeMX with HAL drivers. Below is a beginner-friendly guide using HAL (Hardware Abstraction Layer) in STM32CubeMX and also a bare-metal (register-level) method if you’re not using HAL.
Method 1: Using STM32CubeMX + HAL Library (Recommended for Beginners)
1. Open STM32CubeMX
Create a new project for STM32F407VGTx (or your exact chip).
Go to the “Pinout & Configuration” tab.
2. Enable ADC
Click on the desired ADC input pin (e.g., PA0 → ADC1_IN0).
This will automatically enable ADC1.
3. Configure ADC Settings
Go to Peripherals > ADC1 and set:
Resolution: 12 bits
Scan Conversion Mode: Disabled (for single channel)
ADC1->CR2 |= ADC_CR2_SWSTART;         // Start conversion
while (!(ADC1->SR & ADC_SR_EOC));     // Wait for end of conversion
uint16_t result = ADC1->DR;           // Read value
Notes:
ADC result is 12-bit (0–4095 for 3.3V reference)
Voltage = (ADC_value / 4095.0) * Vref
Performance of Analog to Digital Converter (ADCs)
The performance of Analog-to-Digital Converters (ADCs) is determined by several key factors that affect accuracy, speed, resolution, and overall signal fidelity. Here are the most important performance factors:
1. Resolution
Definition: Number of bits used to represent the analog input.
Impact: Higher resolution means finer granularity in signal representation.
Example: A 12-bit ADC can represent 212=40962^{12} = 4096 levels.
2. Sampling Rate (Sampling Frequency)
Definition: Number of samples the ADC takes per second (measured in samples per second or Hz).
Impact: A higher sampling rate captures more detail in high-frequency signals (as per the Nyquist theorem).
Example: Audio ADCs typically sample at 44.1 kHz or higher.
3. Signal-to-Noise Ratio (SNR)
Definition: Ratio of the desired signal to background noise.
Impact: A higher SNR means cleaner digital output.
Related To: Resolution and noise characteristics of the ADC.
4. Total Harmonic Distortion (THD)
Definition: A measure of distortion introduced by the ADC.
Impact: Lower THD indicates better fidelity in signal reproduction.
5. Integral Non-Linearity (INL)
Definition: Deviation of the actual transfer function from a straight line.
Impact: Affects the overall accuracy across the entire input range.
6. Differential Non-Linearity (DNL)
Definition: Deviation in step size between adjacent digital codes.
Impact: High DNL can cause missing codes and reduced accuracy.
7. Effective Number of Bits (ENOB)
Definition: A measure of ADC performance accounting for noise and distortion.
Impact: Real-world indicator of usable resolution.
8. Conversion Time / Latency
Definition: Time taken to complete one analog-to-digital conversion.
Impact: Important in real-time applications.
9. Power Consumption
Definition: Amount of power used by the ADC.
Impact: Critical for battery-powered or embedded systems.
10. Input Bandwidth
Definition: The frequency range over which the ADC can accurately sample.
Impact: Determines the highest frequency the ADC can handle effectively.
Real-Life Examples of Analog to Digital Converter
🥵 Temperature monitoring using LM35 or DHT11
🔊 Audio signal processing in microphones
💡 Light detection using LDR
🧪 Chemical sensors (e.g., MQ135 gas sensor)
⚡ Battery voltage monitoring in IoT devices
Tips for Using Analog to Digital Converter Effectively
Use a decoupling capacitor near the ADC pin for stability.
Use averaging or filtering in code to smooth noisy signals.
Match reference voltage to expected signal range for best accuracy.
Applications of Analog-to-Digital Converters (ADCs)
Analog-to-Digital Converters (ADCs) are crucial in modern electronics, enabling the interface between the analog real world and digital systems. Here are some key applications:
1. Audio and Speech Processing
Use: Convert analog microphone signals to digital for processing, storage, and transmission.
Use: Interface analog signals like touch, light, and sound to digital processors.
Examples: Digital cameras, TVs, gaming consoles.
7. Automotive Systems
Use: Monitor engine parameters, temperature, and other analog sensor inputs.
Examples: Engine control units (ECUs), ADAS, electric vehicle battery management.
8. Instrumentation and Measurement
Use: High-precision digital conversion for scientific and industrial measurements.
Examples: Oscilloscopes, digital multimeters.
9. Image Processing
Use: Convert analog video signals to digital for enhancement and storage.
Examples: Scanners, digital surveillance cameras, medical imaging.
10. IoT (Internet of Things) Devices
Use: Sense the physical environment and feed data to cloud or edge systems.
Examples: Smart thermostats, health wearables, smart agriculture sensors.
Example Use Case of Analog to Digital Converter
Let’s say you connect a temperature sensor to a microcontroller with a 10-bit ADC and 5V reference. The sensor gives 2V: Digital Value=2V5V×1023=409\text{Digital Value} = \frac{2V}{5V} \times 1023 = 409
So, the microcontroller receives 409 as the digital representation of 2V.
Interview questions on ADC (Analog to Digital Converter)
Basic Conceptual Questions
What is an ADC (Analog to Digital Converter)?
Why do we need an ADC in embedded systems?
What is the difference between ADC and DAC?
What are the types of ADCs?
Explain the working principle of an ADC.
Functionality & Characteristics
What is resolution in an ADC?
What does sampling rate or sampling frequency mean in ADCs?
What is quantization and quantization error?
What is aliasing in ADC?
What is the Nyquist theorem and how does it relate to ADCs?
Technical Specifications
What is SNR (Signal-to-Noise Ratio) in an ADC?
Define INL (Integral Non-Linearity) and DNL (Differential Non-Linearity).
What is Effective Number of Bits (ENOB)?
What is ADC latency or conversion time?
How does ADC resolution affect accuracy?
Practical & Application-Based Questions
Where are ADCs used in real-world applications?
How do you interface an ADC with a microcontroller?
What happens if the sampling frequency is too low?
How do you select an ADC for a specific application?
Explain a use case where ADC plays a crucial role (e.g., temperature sensor, audio input).
Hands-On/Embedded Programming
How do you read ADC values in an embedded C program (e.g., for AVR, STM32, ESP32)?
What registers are involved in configuring an ADC?
What is polling vs interrupt vs DMA-based ADC conversion?
Can you write a simple code snippet to read ADC data?
How do you improve the accuracy of ADC readings in software?
ADC (Analog to Digital Converter) – FAQ
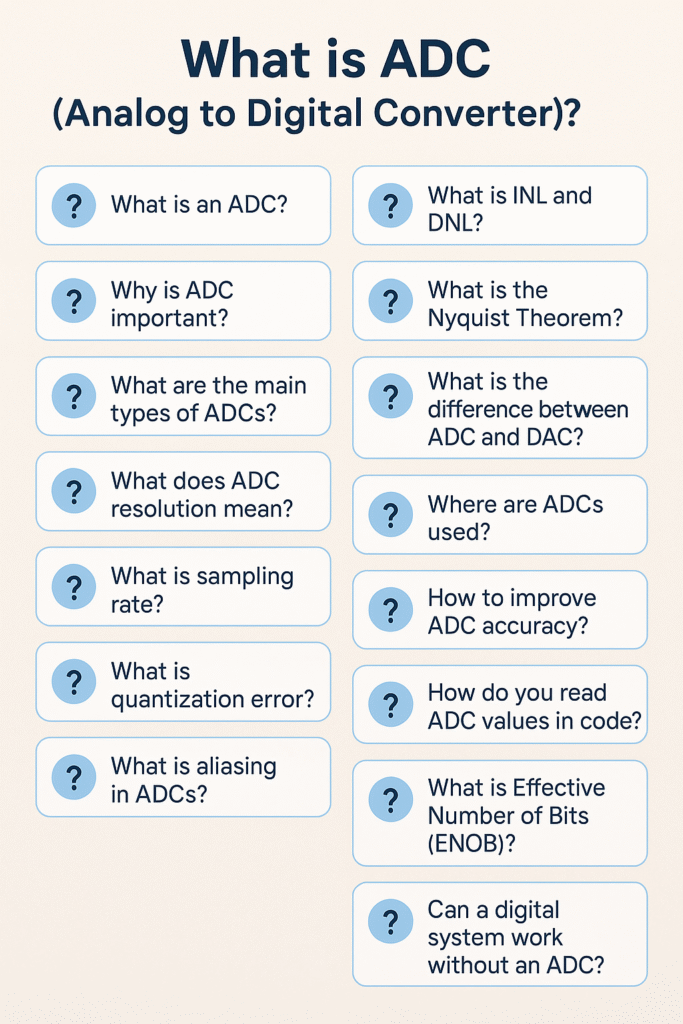
1. What is an ADC?
An ADC (Analog to Digital Converter) is an electronic device that converts continuous analog signals (like voltage) into discrete digital numbers that a microcontroller or computer can process.
2. Why is ADC important?
Digital systems (like microcontrollers) cannot understand analog signals directly. ADCs allow these systems to sense real-world signals such as temperature, sound, and light.
3. What are the main types of ADCs?
Successive Approximation Register (SAR) ADC
Flash ADC
Sigma-Delta (ΔΣ) ADC
Dual Slope ADC
Pipelined ADC
4. What does ADC resolution mean?
ADC resolution refers to the number of bits used to represent the analog signal. For example, a 10-bit ADC divides the voltage range into 210=10242^{10} = 1024 levels.
5. What is sampling rate?
Sampling rate is the number of times per second the ADC samples the analog signal. It’s measured in samples per second (S/s or Hz).
6. What is quantization error?
Quantization error is the difference between the actual analog input and its closest digital representation. It’s an inherent limitation of ADC resolution.
7. What is aliasing in ADCs?
Aliasing occurs when the signal is sampled below the Nyquist rate (less than twice the highest signal frequency), causing distortion. An anti-aliasing filter is used to prevent this.
8. What is INL and DNL?
INL (Integral Non-Linearity): Deviation of ADC output from the ideal line across the full range.
DNL (Differential Non-Linearity): Deviation in step size between adjacent digital codes.
9. What is the Nyquist Theorem?
It states that to accurately sample a signal, the sampling rate must be at least twice the highest frequency present in the signal.
10. What is the difference between ADC and DAC?
ADC: Converts analog to digital.
DAC (Digital to Analog Converter): Converts digital back to analog.
11. Where are ADCs used?
Microcontrollers (sensors)
Audio recording systems
Medical devices (ECG)
Communication systems
Industrial automation
12. How to improve ADC accuracy?
Use a stable voltage reference
Reduce electrical noise
Use averaging in software
Shield analog paths from digital interference
13. How do you read ADC values in code?
You configure the ADC module (select channel, resolution, start conversion) and then read the digital value from a register (e.g., ADC_READ() in many platforms).
14. What is Effective Number of Bits (ENOB)?
ENOB indicates the actual resolution of an ADC considering all sources of noise and distortion.
15. Can a digital system work without an ADC?
Yes, if it only processes digital signals. But to interact with the real world (sensors, audio, etc.), an ADC is essential.
You can also Visit other tutorials of Embedded Prep
GPIO : In the world of electronics and embedded systems, GPIO is a term you will encounter very often. GPIO stands for General Purpose Input/Output. It refers to programmable pins on a microcontroller, microprocessor, or SoC (System on Chip) that can be controlled through software to perform simple tasks like reading a sensor value or controlling an LED.
In this beginner-friendly tutorial, we will break down GPIOs in a very simple way, perfect for those just getting started!
What is GPIO?
GPIO pins are versatile electrical connections. They can be configured either as input or output depending on what you want to do:
Input Mode: The GPIO pin reads a signal, such as a button press.
Output Mode: The GPIO pin sends a signal, such as turning on an LED or running a motor.
Think of GPIO pins as the communication wires between your software and hardware.
Why is GPIO Important?
GPIO pins allow microcontrollers and processors to interact with the physical world. Without GPIO, you wouldn’t be able to connect buttons, sensors, LEDs, or many other hardware components to your board.
They are used for:
Reading data from sensors (temperature, humidity, motion, etc.)
Controlling outputs (LEDs, motors, relays)
Communicating with other devices (using protocols like SPI, I2C, UART)
How Does GPIO Work?
Basic Steps:
Configure the Pin Direction
Set the GPIO pin as either INPUT or OUTPUT.
Write or Read Data
If OUTPUT, send a HIGH (1) or LOW (0) voltage.
If INPUT, read the voltage level to determine the signal (pressed, not pressed, etc.).
Use Pull-up or Pull-down Resistors
These resistors ensure the GPIO pin has a default voltage when nothing is connected.
Real-World Example: Blinking an LED with GPIO
Let’s understand GPIO with a simple example: Blinking an LED using a microcontroller like Arduino.
Components Needed:
1 x LED
1 x 220-ohm resistor
1 x Arduino board
Breadboard and wires
Circuit Connection:
Connect the longer leg of the LED (anode) to GPIO pin 13 through the resistor.
Connect the shorter leg (cathode) to GND (Ground).
Arduino Code Example:
void setup() {
  pinMode(13, OUTPUT); // Set GPIO 13 as OUTPUT
}

void loop() {
  digitalWrite(13, HIGH); // Turn LED ON
  delay(1000);            // Wait for 1 second
  digitalWrite(13, LOW);  // Turn LED OFF
  delay(1000);            // Wait for 1 second
}
Explanation:
pinMode(13, OUTPUT) configures pin 13 as an output pin.
digitalWrite(13, HIGH) sends a HIGH voltage to turn on the LED.
digitalWrite(13, LOW) sends a LOW voltage to turn off the LED.
delay(1000) waits for 1000 milliseconds (1 second) between ON and OFF.
Important GPIO Terms You Should Know
Term
Meaning
HIGH
Logical 1 or 3.3V/5V (depending on board)
LOW
Logical 0 or 0V (Ground)
Pull-up resistor
Keeps input HIGH when switch is open
Pull-down resistor
Keeps input LOW when switch is open
Best Practices When Working with GPIOs
Always check the maximum voltage and current that your GPIO pin can handle.
Use resistors to protect your GPIO pins from damage.
Debounce inputs like buttons to avoid false triggering.
When using output GPIOs to drive high-power devices (like motors), use transistors or relays.
GPIO Practical Example on ARM Cortex-M4 Processor (STM32)
Introduction
When working with ARM Cortex-M4 microcontrollers (like STM32F4 series), controlling GPIO pins is one of the first and most important tasks you’ll learn.
In this tutorial, we’ll show you how to configure a GPIO pin to blink an LED using STM32 microcontroller, and understand what’s happening step-by-step!
Let’s dive right in. 🚀
Prerequisites
Before we start, you should have:
An STM32F4 (or similar Cortex-M4 board)
STM32CubeIDE installed (free official IDE from STMicroelectronics)
A basic setup (board, USB cable)
GPIO Basics on ARM Cortex-M4
On STM32, each pin is part of a GPIO port like GPIOA, GPIOB, GPIOC, etc.
Step-by-Step: Blinking an LED on STM32 (Cortex-M4)
1. Hardware Setup
Use the on-board LED (usually connected to Pin PA5 on Nucleo-F401RE, or check your board’s datasheet).
If no onboard LED, connect an LED through a resistor to PA5 and GND.
2. Software Setup (STM32CubeIDE)
Create a New STM32 Project:
Open STM32CubeIDE.
Click File > New > STM32 Project.
Select your MCU (example: STM32F401RE).
Name your project (GPIO_Blink).
Configure GPIO:
In the Pinout & Configuration view:
Click on pin PA5 (or your chosen pin).
Set it as GPIO_Output.
CubeIDE automatically configures the GPIO clock and settings!
3. Write the Code
Go to Src/main.c and edit the code:
#include "main.h"

int main(void)
{
  HAL_Init(); // Initialize Hardware Abstraction Layer

  __HAL_RCC_GPIOA_CLK_ENABLE(); // Enable clock for GPIOA

  GPIO_InitTypeDef GPIO_InitStruct = {0};

  // Configure PA5 as Output
  GPIO_InitStruct.Pin = GPIO_PIN_5;
  GPIO_InitStruct.Mode = GPIO_MODE_OUTPUT_PP; // Push-Pull Output
  GPIO_InitStruct.Pull = GPIO_NOPULL;
  GPIO_InitStruct.Speed = GPIO_SPEED_FREQ_LOW;
  HAL_GPIO_Init(GPIOA, &GPIO_InitStruct);

  while (1)
  {
    HAL_GPIO_TogglePin(GPIOA, GPIO_PIN_5); // Toggle LED
    HAL_Delay(500);                        // Delay 500 ms
  }
}
4. Build and Flash the Code
Click the hammer icon (build project).
Connect your board.
Click the green play button (flash and run).
You should see the LED blinking every 500ms!
What’s Happening Behind the Scenes?
Step
Description
HAL_Init()
Initializes the HAL Library.
__HAL_RCC_GPIOA_CLK_ENABLE()
Enables the clock for GPIOA peripheral.
HAL_GPIO_Init()
Sets pin PA5 as output, no pull-up/down, low speed.
HAL_GPIO_TogglePin()
Changes pin state (HIGH to LOW or LOW to HIGH).
HAL_Delay()
Creates a software delay to control blink rate.
Tips for GPIO on ARM Cortex-M4
Always enable the clock for the GPIO port before configuring.
Use HAL library for easier and safer coding (good for beginners).
For high-speed GPIO, set GPIO Speed to GPIO_SPEED_FREQ_HIGH.
Read the Reference Manual of your microcontroller to understand more detailed control.
Imagine it like this:
A GPIO pin is like a small door.
When you listen at the door → It’s an input.
When you shout through the door → It’s an output.
And you (the programmer) decide whether to listen or shout through the door!
How GPIO Works Internally (Step-by-Step)
1. GPIO Pin is Connected to Internal Hardware
Every GPIO pin is connected to a small electrical circuit inside the microcontroller. This circuit can behave differently based on how you configure it.
At its heart, the pin connects to:
Logic gates
Pull-up/pull-down resistors
Drive transistors
MUX (Multiplexer for selecting function)
2. Configure the Pin as Input or Output
When you write software for your MCU, the first thing you do is configure the pin:
Input mode: The pin will listen to outside voltage (HIGH or LOW).
Output mode: The pin will send a voltage signal (HIGH or LOW) outside.
💬 In most microcontrollers, you configure this using special control registers (small memory locations inside the chip).
Example (STM32):
GPIOA->MODER |= (1 << (2 * 5)); // Set PA5 as output
This means you’re telling the chip: “Hey, PA5, work as output!“
3. How Input Mode Works
When the pin is in input mode:
It waits and senses if the voltage on the pin is High (1) or Low (0).
High means ~3.3V (depends on MCU).
Low means ~0V.
If the signal is unstable, internal pull-up or pull-down resistors can be activated to stabilize it.
4. How Output Mode Works
When the pin is in output mode:
The software can write 1 or 0 to the pin.
Writing 1: The internal circuit connects the pin to 3.3V (HIGH).
Writing 0: The internal circuit connects the pin to GND (LOW).
Example (STM32 HAL):
HAL_GPIO_WritePin(GPIOA, GPIO_PIN_5, GPIO_PIN_SET); // Set PA5 High
HAL_GPIO_WritePin(GPIOA, GPIO_PIN_5, GPIO_PIN_RESET); // Set PA5 Low
Thus, the pin can turn ON an LED, activate a motor, or send data to another device.
5. Special Features Inside GPIO
GPIOs are not just dumb wires. They have smart features:
Feature
Meaning
Pull-up / Pull-down
Stabilize input when nothing connected
Open-Drain
Pin can pull LOW but not drive HIGH (external pull-up needed)
Speed Control
Control how fast pin changes (important for EMI)
Alternate Functions
GPIO can become UART, SPI, I2C pins when needed
Interrupt Capability
GPIO can detect changes and alert CPU instantly
GPIO Life Cycle in Software
Typical steps in a C program:
Enable the GPIO port clock (power the module).
Configure the pin mode (input/output/alternate).
Set pull-up or pull-down resistors if needed.
Set speed (for output pins).
Read or Write data.
This process never changes — whether you’re working on STM32, NXP, or TI boards.
Real-Life Practical Example (ARM Cortex-M4)
Example Task: Blink an LED using PA5 pin
Software Steps:
// 1. Enable GPIOA Clock
RCC->AHB1ENR |= (1 << 0); // Enable clock to GPIOA

// 2. Set PA5 as output
GPIOA->MODER &= ~(3 << (2 * 5)); // Clear Mode Bits
GPIOA->MODER |= (1 << (2 * 5));  // Set Output Mode

// 3. Toggle PA5 forever
while(1) {
    GPIOA->ODR ^= (1 << 5); // Toggle PA5
    for (volatile int i = 0; i < 100000; i++); // Small delay
}
Result: The LED connected to PA5 will blink continuously.
Important Concepts to Remember
Concept
Summary
Input Mode
Reads voltage from external world
Output Mode
Sends voltage to external world
Floating
Input pin without pull-up/down can behave randomly
Pull-up/Pull-down
Avoid undefined signals on inputs
Open-Drain Output
Safer for multi-device communication
Alternate Functions
Turn GPIO into UART, SPI, I2C, PWM, etc.
Debounce
Clean noisy signals from mechanical buttons
GPIO Interview Questions for Embedded Systems
Basic Level
What is GPIO? Explain its role in microcontrollers.
What is the difference between GPIO input and GPIO output?
What are pull-up and pull-down resistors? Why are they important in GPIO input mode?
How do you configure a GPIO pin as an output in ARM Cortex-M4?
What happens if you leave a GPIO input pin floating?
What is the difference between push-pull and open-drain output configurations?
Explain the concept of debouncing. Why is it needed for GPIO inputs?
Intermediate Level
Describe the steps needed to configure a GPIO pin manually (without using a HAL library).
What registers are involved in GPIO configuration on ARM Cortex-M4 (STM32)?
How would you implement GPIO interrupts for a button press?
Explain the importance of enabling the peripheral clock before accessing GPIO registers.
What is alternate function mode in GPIOs? Give examples where it’s used.
How would you drive an LED matrix using GPIOs?
What are the power considerations when using GPIOs, especially in battery-operated devices?
What is GPIO drive strength? Why does it matter in certain designs?
Advanced Level
Explain how you would design a low-power GPIO input system.
Describe a scenario where open-drain GPIO configuration is preferred over push-pull.
How do you configure GPIO wake-up from sleep or standby mode in ARM Cortex-M4?
How would you handle a situation where multiple peripherals share the same GPIO pins?
What are the risks of GPIO glitches during boot or reset, and how can you minimize them?
How do GPIO multiplexers work internally in microcontrollers?
How would you optimize GPIO control for high-speed applications (e.g., toggling pins in MHz range)?
Practical / Coding Level
Write a C code snippet to configure PA0 as input with pull-up resistor on STM32.
Write a code to toggle a GPIO pin at a 1-second interval without using HAL libraries.
How would you structure GPIO initialization code for easy scalability in large embedded projects?
Bonus Questions (for Deeper Insight)
Have you ever used GPIO pins for bit-banging protocols like I2C or SPI? Explain how.
What are the key differences in GPIO handling between STM32, NXP, and TI microcontrollers?
How would you simulate a GPIO toggle using a timer interrupt?
GPIO FAQs (Frequently Asked Questions)
1. What is GPIO in a microcontroller?
Answer: GPIO stands for General Purpose Input/Output. It allows microcontrollers to read external signals (input) or control external devices (output) like LEDs, buttons, sensors, motors, etc.
2. What is the difference between GPIO input and GPIO output?
GPIO Output: Sends signals to control external devices (like LEDs, buzzers, relays).
3. What are pull-up and pull-down resistors in GPIO?
Answer: Pull-up and pull-down resistors prevent GPIO input pins from floating (i.e., being in an undefined state) by tying them to a known voltage:
Pull-up: Connects the pin weakly to Vcc (logic high).
Pull-down: Connects the pin weakly to GND (logic low).
4. Why do we enable the GPIO clock before using GPIO?
Answer: Microcontrollers use clock gating to save power. Without enabling the GPIO clock, the GPIO registers are inaccessible, and the pin cannot function properly.
5. What is the purpose of GPIO alternate function mode?
Answer: Alternate function mode allows a GPIO pin to be repurposed for other hardware functions like:
UART (Serial communication)
SPI (Serial Peripheral Interface)
I2C (Inter-Integrated Circuit)
PWM (Pulse Width Modulation)
6. What is push-pull vs open-drain GPIO configuration?
Answer:
Push-Pull: The pin can actively drive both high and low voltage levels.
Open-Drain: The pin can only pull the line low or stay floating (external pull-up required).
Tip: Open-drain is commonly used in I2C and shared-bus designs.
7. What happens if a GPIO input pin is left floating?
Answer: If left floating, the GPIO input can randomly read HIGH or LOW, causing unpredictable behavior due to electrical noise. Solution: Always configure input pins with a pull-up or pull-down resistor.
8. How to configure a GPIO pin in STM32?
Answer: Steps to configure:
Enable the GPIO port clock.
Set the pin mode (Input/Output/Alternate/Analog).
Configure output type (Push-Pull/Open-Drain).
Set pull-up/pull-down resistors.
Define pin speed (Low/Medium/High).
Write or read data to/from the pin.
9. How to toggle a GPIO pin in C?
Answer: Example (STM32 HAL):
HAL_GPIO_TogglePin(GPIOA, GPIO_PIN_5);
This function toggles the state of the specified GPIO pin.
10. What is debouncing and why is it needed for GPIO inputs?
Answer: Debouncing is the process of removing noisy, fast-changing signals generated by mechanical switches when pressed or released. Without debouncing, a single button press might be registered as multiple presses.
Solutions:
Software debounce (adding small delay)
Hardware debounce (using capacitors or circuits)
11. Can GPIOs be used for interrupts?
Answer: Yes! GPIOs can be configured to generate interrupts on events like:
Rising edge (LOW to HIGH)
Falling edge (HIGH to LOW)
Both edges
This is useful for buttons, sensors, and real-time events.
12. How fast can a GPIO toggle?
Answer: It depends on:
Microcontroller clock speed
GPIO speed settings (Low/Medium/High/Fast)
Code execution time
With direct register access (bare-metal), GPIOs can toggle at several megahertz (MHz) frequencies.
13. How can I reduce GPIO power consumption?
Answer: To minimize GPIO power use:
Set unused GPIOs to analog mode.
Avoid floating inputs.
Use pull-downs or pull-ups appropriately.
Reduce output toggle frequency if not needed.
14. How to protect GPIO pins from damage?
Answer: Protection methods:
Use series resistors.
Use TVS (Transient Voltage Suppression) diodes.
Never exceed the maximum voltage/current ratings.
Add current-limiting resistors for outputs like LEDs.
15. What is GPIO multiplexing?
Answer: GPIO multiplexing allows one physical pin to perform multiple functions based on configuration (e.g., GPIO, UART TX, SPI MISO, etc.). The correct function is selected by setting MUX bits in the configuration registers.
Special thanks to @mr-raj for contributing to this article on Embedded Prep
Polling in Embedded Systems : In the world of embedded systems, efficient communication and control are the backbone of creating robust, reliable devices. One of the most common techniques used in embedded systems is polling. Whether you’re building a microcontroller-based project, working with real-time operating systems (RTOS), or diving into low-level programming, understanding how polling works is essential.
This article will walk you through the concept of polling in embedded systems, making it easy for beginners to grasp. Plus, we’ll discuss how it compares to other methods like interrupt-driven systems. By the end of this article, you’ll have a clear understanding of polling, its applications, and how to implement it effectively in embedded projects.
What are Embedded Systems?
An embedded system is a specialized computer designed to perform specific tasks within a larger system. Unlike general-purpose computers (like your laptop or desktop), embedded systems are designed to do a single job efficiently. Examples include smart thermostats, automobiles, washing machines, and smartwatches.
Key characteristics of embedded systems:
Dedicated Functionality: They are designed to perform a specific task or a set of related tasks.
Real-time Operation: Many embedded systems need to meet real-time constraints, which means they must respond to events within a specified time.
Low Power Consumption: These systems are often battery-powered or energy-efficient.
Hardware-Software Integration: Embedded systems typically combine both hardware (e.g., microcontrollers, sensors) and software (e.g., embedded C code, firmware).
Polling in Embedded Systems: An Overview
Polling is a method used in embedded systems to continuously check or “poll” a specific resource, sensor, or status register at regular intervals. It involves checking the status of a peripheral or input/output (I/O) device to determine if any action is needed.
How Polling Works:
Check the Status: The system regularly checks whether a certain condition or event has occurred (e.g., button press, sensor data available).
Wait for Action: If the condition is met, the system performs the required action (e.g., turning on a light, sending data).
Repeat the Process: After performing the action, the system continues to check the status in a continuous loop.
Example of Polling:
Imagine a simple embedded system connected to a temperature sensor. The system might check the sensor’s value every second to determine if the temperature has crossed a threshold. If the threshold is exceeded, the system might trigger a fan or an alarm.
Polling vs. Interrupts: What’s the Difference?
While polling is a simple and easy-to-understand approach, it’s not always the most efficient. The main alternative to polling is the interrupt-driven approach.
Polling:
Process: The system checks for events at regular intervals.
Efficiency: Polling can be inefficient, especially when there are no events to handle.
CPU Load: It consumes CPU cycles even if no action is needed, which may lead to unnecessary power consumption.
Simplicity: Polling is easy to implement, making it a popular choice for simple applications.
Interrupts:
Process: The system waits for an external event, and when the event occurs, it triggers an interrupt to immediately respond to the event.
Efficiency: Interrupts are more efficient since the CPU doesn’t have to constantly check for events.
CPU Load: The CPU remains idle until an interrupt occurs, saving energy.
Complexity: Interrupt-driven systems are more complex to implement and require careful management.
Which One to Use?
For simple applications with limited resources (e.g., small microcontrollers), polling is a straightforward and practical choice. However, for more complex systems that need to handle multiple events simultaneously, interrupts provide better performance and efficiency.
Advantages and Disadvantages of Polling
Advantages of Polling:
Simplicity: Polling is easy to implement and understand, making it ideal for beginners.
Predictability: Polling allows you to have complete control over the timing of checks and actions.
Low Overhead: In small systems with minimal processing power, polling can be a low-overhead approach.
Disadvantages of Polling:
Inefficiency: If the system is checking for events continuously, but nothing happens, it’s wasting processing power.
Latency: In some cases, polling may introduce delays in responding to events, especially if the polling interval is too long.
CPU Intensive: Polling can put unnecessary strain on the CPU, especially when many resources are being monitored.
Applications of Polling in Embedded Systems
Polling is commonly used in many embedded system applications. Here are a few examples:
Button Press Detection: Polling can be used to detect when a button is pressed. The microcontroller continuously checks the state of the button, and once it detects a press, it can perform an action (e.g., turning on a light).
Sensor Monitoring: In systems where sensors continuously measure parameters (e.g., temperature, humidity, or pressure), polling can be used to check sensor data at regular intervals.
Communication Protocols: Polling is often used in communication protocols like UART or SPI, where data is checked periodically to determine if new information is available.
LED Status Checking: Simple systems that involve controlling LEDs based on specific conditions can use polling to monitor input values and determine if the LED needs to be turned on or off.
How to Implement Polling in Embedded Systems
Implementing polling in an embedded system can be as simple as using a while loop or timer interrupt. Here’s a basic example of polling a button press on a microcontroller using C:
#define BUTTON_PIN 3

void setup() {
  pinMode(BUTTON_PIN, INPUT);
}

void loop() {
  // Poll the button state every cycle
  int buttonState = digitalRead(BUTTON_PIN);

  if (buttonState == HIGH) {
    // Button is pressed, perform action
    digitalWrite(LED_PIN, HIGH);
  } else {
    // Button is not pressed, turn off LED
    digitalWrite(LED_PIN, LOW);
  }

  delay(100); // Delay to avoid busy-waiting
}
In this simple code, the system continuously checks if a button is pressed and controls an LED based on the button’s state.
Implement polling for a button press on the STM32
Here’s how you can implement polling for a button press on the STM32F407VG microcontroller, specifically for a simple embedded system that checks the state of a button and toggles an LED when the button is pressed.
Prerequisites:
STM32CubeMX for generating initialization code.
STM32 HAL library for easy peripheral management.
A button connected to a GPIO pin (e.g., GPIO pin PA0).
An LED connected to another GPIO pin (e.g., GPIO pin PC13).
Step-by-Step Implementation
Step 1: Setting up the STM32CubeMX Project
Open STM32CubeMX and create a new project for the STM32F407VG.
Configure the Button Pin:
Set PA0 (or any other GPIO pin) as an input pin.
Configure the LED Pin:
Set PC13 (or any other GPIO pin) as an output pin.
Enable the Clock for GPIO: CubeMX will automatically enable the necessary clocks.
Generate the initialization code for your project by clicking on Project -> Generate Code.
Step 2: Writing the Code
Once the code has been generated, open it in STM32CubeIDE and write the logic for polling the button state.
Open the main.c file to implement the logic.
In the main.c, include the necessary headers and initialize the GPIO pins.
#include "main.h"

int main(void)
{
  // HAL Initialization
  HAL_Init();

  // Initialize the System Clock
  SystemClock_Config();

  // Initialize the GPIO for button (PA0) and LED (PC13)
  MX_GPIO_Init();

  while (1)
  {
    // Poll the button state
    if (HAL_GPIO_ReadPin(GPIOA, GPIO_PIN_0) == GPIO_PIN_SET)  // If button is pressed
    {
      // Turn ON the LED
      HAL_GPIO_WritePin(GPIOC, GPIO_PIN_13, GPIO_PIN_SET);
    }
    else
    {
      // Turn OFF the LED
      HAL_GPIO_WritePin(GPIOC, GPIO_PIN_13, GPIO_PIN_RESET);
    }

    // Small delay to avoid bouncing issues
    HAL_Delay(50);  // 50ms delay
  }
}
Step 3: Configure the GPIO Pins in gpio.c
The GPIO configuration will be handled by the generated MX_GPIO_Init() function, but ensure that the input and output pins are configured as follows:
void MX_GPIO_Init(void)
{
  GPIO_InitTypeDef GPIO_InitStruct = {0};

  // Enable GPIOA and GPIOC clocks
  __HAL_RCC_GPIOA_CLK_ENABLE();
  __HAL_RCC_GPIOC_CLK_ENABLE();

  // Configure GPIO pin for the button (PA0) as input
  GPIO_InitStruct.Pin = GPIO_PIN_0;
  GPIO_InitStruct.Mode = GPIO_MODE_INPUT;
  GPIO_InitStruct.Pull = GPIO_NOPULL;
  HAL_GPIO_Init(GPIOA, &GPIO_InitStruct);

  // Configure GPIO pin for the LED (PC13) as output
  GPIO_InitStruct.Pin = GPIO_PIN_13;
  GPIO_InitStruct.Mode = GPIO_MODE_OUTPUT_PP;
  GPIO_InitStruct.Pull = GPIO_NOPULL;
  GPIO_InitStruct.Speed = GPIO_SPEED_FREQ_LOW;
  HAL_GPIO_Init(GPIOC, &GPIO_InitStruct);
}
Step 4: System Clock Configuration
Ensure the SystemClock_Config() function is correctly implemented to set the system clock. This is usually automatically configured by STM32CubeMX.
void SystemClock_Config(void)
{
  // System Clock Configuration code generated by STM32CubeMX
}
Step 5: Compiling and Flashing
Compile the project by clicking on the “Build” button in STM32CubeIDE.
Flash the code onto the STM32F407VG using a programmer like ST-Link or J-Link.
Step 6: Testing
When you press the button connected to PA0, the LED on PC13 will turn ON.
When you release the button, the LED will turn OFF.
Notes:
Button Debouncing: In real-world applications, button presses can cause multiple transitions due to contact bounce. To handle this, you can implement software debouncing by introducing a small delay after detecting a button press. For example: if (HAL_GPIO_ReadPin(GPIOA, GPIO_PIN_0) == GPIO_PIN_SET) // If button is pressed { HAL_Delay(200); // Wait for 200ms for debounce if (HAL_GPIO_ReadPin(GPIOA, GPIO_PIN_0) == GPIO_PIN_SET) // Confirm button press { HAL_GPIO_WritePin(GPIOC, GPIO_PIN_13, GPIO_PIN_SET); // Turn ON LED } }
Conclusion
Polling is a fundamental technique used in embedded systems for monitoring peripherals and sensors. While it may not be as efficient as interrupts, polling remains a great choice for simple applications where ease of implementation and control are key priorities.
Understanding polling helps you build a foundation in embedded system development and prepares you for more advanced concepts, such as interrupt handling and real-time operating systems.
By leveraging polling effectively, you can build efficient embedded systems that perform their tasks reliably. Now that you’ve got a basic understanding of polling, experiment with it in your projects and see how it can simplify your embedded designs!
Polling Interview Questions in Embedded Systems
1. Basic Concept of Polling
What is polling in embedded systems?
How does polling differ from interrupt-driven I/O in embedded systems?
What are the advantages of using polling over interrupts?
What are the disadvantages of using polling over interrupts?
2. Polling Mechanism
How does the polling mechanism work in microcontrollers?
What is the role of a loop in a polling system?
What happens if polling does not check the condition in time?
How do you implement polling in an embedded system using a microcontroller?
3. Performance and Efficiency
How does polling affect the performance of an embedded system?
What are the power consumption implications of using polling?
How can polling impact the responsiveness of real-time systems?
When is polling an appropriate method for handling input/output operations?
4. Polling vs Interrupts
What are the main differences between polling and interrupts?
When would you choose polling over interrupts in an embedded system?
Can polling be used for real-time applications? Why or why not?
What are the trade-offs between using polling and interrupts for managing hardware resources?
5. Polling in Practice
How would you use polling to check the status of a button press in an embedded system?
How do you implement polling for an analog-to-digital conversion (ADC) in an embedded system?
How does polling work in a sensor-based system (e.g., temperature or pressure sensors)?
How can you poll multiple devices in an embedded system without affecting performance?
6. Timing and Delays in Polling
How do you manage timing and delays in polling-based systems?
What is the role of software timers in polling systems?
How can you avoid excessive CPU usage in polling systems with tight timing requirements?
7. Polling and System Design
How does polling impact the overall system design in an embedded system?
Can polling be used in safety-critical embedded systems? Why or why not?
How can you optimize a polling-based embedded system for better performance?
What are some examples of systems that are ideal candidates for polling-based designs?
8. Polling and Real-Time Operating Systems (RTOS)
How does polling interact with an RTOS in embedded systems?
What are the challenges of implementing polling in a system with an RTOS?
How does an RTOS handle polling tasks in comparison to interrupt-based tasks?
9. Advanced Polling Techniques
How do you implement efficient polling for high-frequency data in embedded systems?
What strategies can be used to handle multiple input devices through polling without bottlenecking?
How can you combine polling with other techniques (e.g., interrupt handling) to improve performance?
10. Polling in Communication Protocols
How does polling work in communication protocols like SPI, I2C, or UART?
How do you handle polling when multiple devices are involved in a communication protocol?
How do polling and baud rates relate in serial communication?
Here’s an FAQ for “Introduction to Embedded Systems: Polling Explained for Beginners”:
FAQ: Polling in Embedded Systems
1. What is polling in embedded systems?
Answer: Polling is a technique in embedded systems where the microcontroller continuously checks the status of an input or a device at regular intervals. The system “polls” the device to see if any action is required, such as reading a sensor or checking for an interrupt.
2. Why is polling used in embedded systems?
Answer: Polling is used in embedded systems for simple tasks where real-time performance is not critical. It provides a way to monitor inputs or devices without complex interrupt-driven mechanisms. It’s easy to implement and doesn’t require handling interrupts, which can complicate system design.
3. What are the advantages of polling?
Answer:
Simplicity: Polling is straightforward to implement and doesn’t require additional configuration like interrupts.
Control: The system has control over when and how often it checks inputs, which can be useful in some applications.
No need for interrupts: Polling eliminates the need for interrupt handling, which can be complex to manage in some systems.
4. What are the disadvantages of polling?
Answer:
Inefficiency: Polling constantly uses the CPU, which can lead to wasted processing power, especially if the event being polled for happens infrequently.
Latency: If the polling interval is too large, the system may take longer to detect and respond to important events.
No real-time response: Since the system is busy checking the device regularly, it may not respond quickly to other tasks or inputs that require immediate attention.
5. How does polling differ from interrupt handling?
Answer: Polling involves checking a device’s status at regular intervals, while interrupt handling allows the system to respond to events immediately when they occur. With interrupts, the system can react to a specific event as soon as it happens without constantly checking the device.
6. When should polling be used?
Answer: Polling is best suited for simple tasks where the event rate is low, and real-time performance is not a strict requirement. For instance, it can be used to read sensors periodically or check switches in low-complexity systems.
7. What is the typical polling frequency in embedded systems?
Answer: The polling frequency depends on the application. It can range from milliseconds to seconds, based on the nature of the task. In some cases, polling might happen every few milliseconds, while in others, it could be slower, depending on how often the device or sensor needs to be checked.
8. Can polling be used in real-time systems?
Answer: Polling can be used in real-time systems, but it is not ideal for systems requiring quick responses to external events. For real-time systems, interrupts or other real-time scheduling techniques are preferred to achieve low latency.
9. What is the role of polling in low-power embedded systems?
Answer: In low-power systems, polling can be designed to minimize power consumption by having the system enter low-power states between polling intervals. However, if not properly managed, polling can increase power usage, especially in devices that need to be continuously active.
10. What are some examples of polling in embedded systems?
Answer:
Reading temperature sensors in a weather station.
Checking for a button press in a microcontroller-based device.
Monitoring a status register in a peripheral device, such as an ADC (Analog-to-Digital Converter).
11. Can polling be combined with interrupts?
Answer: Yes, polling and interrupts can be combined. For example, polling can be used for less time-critical tasks, while interrupts handle more urgent events. This hybrid approach allows a system to manage different types of tasks effectively.
12. What is a polling loop?
Answer: A polling loop is a continuous loop in the code where the system repeatedly checks the status of a device or sensor. The loop keeps running until a specific condition is met, such as a button being pressed or a sensor reading exceeding a threshold.
You can also Visit other tutorials of Embedded Prep
Interrupts in Embedded Systems : An interrupt is a way for hardware or software to get the processor’s attention when something important happens. It’s like someone tapping you on the shoulder while you are busy working, saying, “Hey, look at this right now!”
When an interrupt happens, the processor doesn’t stop immediately. It first finishes the instruction it is currently working on. After that, it quickly moves to a special piece of code called the Interrupt Service Routine (ISR) or Interrupt Handler.
The ISR is like a small program that tells the processor what to do when a specific interrupt occurs. For example, if you press a button connected to your device, the processor will run the ISR to check which button was pressed and what action should be taken.
In the world of embedded systems, interrupts are powerful tools that help a device respond quickly to important events. Instead of constantly checking (polling) whether something has happened, interrupts alert the processor immediately, saving time and power.
What is an Interrupt?
An interrupt is a signal that pauses the normal flow of a program and forces the CPU to run a special piece of code called an Interrupt Service Routine (ISR).
After the ISR finishes, the CPU resumes its previous work as if nothing happened.
In simple words: An interrupt is like someone tapping your shoulder to get your attention while you are busy working.
Why are Interrupts Important?
Interrupts offer several benefits in embedded systems:
Real-time Response: Immediate reaction to critical events like button presses, sensor readings, or incoming data.
Efficiency: No need to waste CPU time constantly checking for events.
Power Saving: Processor can stay in low-power modes and wake up only when needed.
Multitasking: Perform multiple tasks effectively without missing important signals.
How Interrupts Work: Step-by-Step
Here’s a simple flow of how interrupts work:
Normal Execution: CPU is busy running the main program.
Interrupt Event: An external or internal event occurs (like a button press).
Interrupt Request: The event triggers an interrupt request to the CPU.
Interrupt Handling:
CPU pauses the main program.
CPU saves the current program state (so it can return later).
CPU jumps to the Interrupt Service Routine (ISR).
ISR Execution: Special code in ISR runs to handle the event.
Return to Main Program: CPU restores the saved state and continues where it left off.
Real-World Example of Interrupt
Imagine a smart doorbell:
Normally, the microcontroller is managing Wi-Fi or saving battery in sleep mode.
When a visitor presses the doorbell button, it sends an interrupt.
The microcontroller wakes up immediately and rings the chime or sends a notification.
Without interrupts, the microcontroller would have to keep checking the button all the time, wasting energy.
Key Components of an Interrupt System
Interrupt Request (IRQ): The signal that notifies the CPU about an event.
Interrupt Vector Table (IVT): A table that holds the addresses of all ISRs.
Interrupt Service Routine (ISR): A short program that handles the interrupt.
Interrupt Controller: Manages multiple interrupts and prioritizes them if needed.
Simple Code Example (Pseudocode)
#include <some_microcontroller_library.h>

// Define Interrupt Service Routine
void button_press_ISR(void) {
    // Code to handle button press
    turnOnLED();
}

int main() {
    setupButtonInterrupt(button_press_ISR); // Link ISR to button press
    while (1) {
        // Main program continues
        doOtherTasks();
    }
}
Explanation:
setupButtonInterrupt() configures the button to generate an interrupt.
When the button is pressed, button_press_ISR() runs.
The main program (doOtherTasks()) keeps working without constantly checking the button.
Best Practices When Using Interrupts
Keep ISR Short: The interrupt service routine should be as fast as possible.
Avoid Heavy Operations: No complex calculations or long delays inside the ISR.
Protect Shared Data: Use techniques like disabling interrupts or using volatile variables when accessing shared data.
Set Priorities Wisely: If multiple interrupts can occur, assign proper priorities.
Types of Interrupts
Interrupts are mainly divided into two big categories:
Hardware Interrupts
Software Interrupts
And under these, there are some more types based on behavior.
Let’s dive into each of them :
1. Hardware Interrupts
Definition: Hardware interrupts are triggered by external hardware devices like a keyboard, mouse, sensor, timer, or network card.
Example:
Pressing a key on the keyboard
Clicking a mouse
Receiving data from a sensor
When these hardware components want CPU attention, they send a signal to the CPU — “Hey, I need you now!”
Types inside hardware interrupts:
a) Maskable Interrupt
Meaning: These are interrupts that can be ignored (masked) by the CPU if needed.
Example:
You have a low-priority temperature sensor reading. CPU may postpone or disable it temporarily if a higher-priority task is running.
Real use: Useful for less urgent tasks.
b) Non-Maskable Interrupt (NMI)
Meaning: These interrupts cannot be ignored by the CPU. They are critical.
Example:
Hardware failure like memory errors
Power failure warning
Real use: To handle very serious issues that must be fixed immediately to prevent damage.
2. Software Interrupts
Definition: Software interrupts are triggered by programs or instructions inside the CPU — not by external hardware.
Example:
A program might intentionally request a service from the operating system, like asking to print a document 🖨️.
How it works: The software uses a special instruction (often called INT) to generate an interrupt.
Real-world Example:
A C program calling an operating system function like printf() indirectly uses a software interrupt to talk to the printer or screen.
Special Classifications
Apart from the basic two types, interrupts are often further classified based on how they are handled:
3. Synchronous Interrupts
Meaning: Happen at predictable times, usually caused by the instruction flow of the program.
Example:
Division by zero error (mathematical mistake)
Invalid memory access (segmentation fault)
Real use: Catching software bugs or errors.
4. Asynchronous Interrupts
Meaning: Happen at unpredictable times, triggered by external hardware.
Example:
User pressing a keyboard key at any moment.
Receiving network data.
Real use: Handling random real-world events.
5. Vectored Interrupts
Meaning: CPU knows exactly where the Interrupt Service Routine (ISR) is located — because the address is predefined.
Example:
In ARM Cortex-M processors, vector tables store all ISR addresses.
Real use: Faster because CPU jumps directly to the correct code.
6. Non-Vectored Interrupts
Meaning: CPU does not know directly where to go — it must find the ISR address first.
Example:
Older systems using interrupt controllers.
Real use: Slower but more flexible for dynamic interrupt management.
Quick Summary Table
Type of Interrupt
Triggered By
Can Be Masked?
Predictability
Hardware Interrupt
External device
Maskable/Non-Maskable
Asynchronous
Software Interrupt
Software program
Generally Maskable
Synchronous
Synchronous Interrupt
Program execution
Depends
Predictable
Asynchronous Interrupt
External event
Depends
Unpredictable
Vectored Interrupt
Predefined address
–
Fast access
Non-Vectored Interrupt
Dynamic address
–
Slower
Final Picture
Think of interrupts like urgent notifications in your phone:
🛎️ Hardware interrupts = Phone call from someone (external event)
🛎️ Software interrupts = Reminder set by yourself (internal event)
🔕 Maskable = You can put it on silent
🔔 Non-Maskable = Emergency call — can’t ignore
📍 Vectored = Direct link to caller
🔍 Non-Vectored = You have to search who’s calling first
What is an Interrupt Service Routine (ISR)?
Imagine you are watching your favorite TV show and suddenly your phone rings. You pause the show, answer the call, finish talking, and then return to watching the show.
This is exactly what an interrupt is in a microcontroller!
Answering the call = Executing the Interrupt Service Routine (ISR)
Returning to TV = Going back to the main program after handling the interrupt
In technical words: An interrupt is a signal that temporarily stops the main program and forces the microcontroller to do something else immediately.
When an interrupt happens, the microcontroller needs to know:
What to do?
Which code to run?
The special piece of code that runs when an interrupt occurs is called the Interrupt Service Routine (ISR).
➡️ In short: ISR = A function that is automatically called when an interrupt happens.
How Does the Microcontroller Know Which ISR to Run?
Every interrupt has a fixed place in memory where the microcontroller looks to find the address of the ISR. This fixed list of addresses is called the Interrupt Vector Table.
Think of it like an emergency contact list.
Each type of interrupt (like Timer, UART, External Pin) has its own slot in this table.
The table points to the correct ISR for that interrupt.
So, Interrupt Vector Table = List of addresses that point to ISRs.
Step-by-Step Flow of What Happens During an Interrupt:
Interrupt Occurs (Example: A timer overflow, a button press, or a sensor signal)
Microcontroller Pauses Main Program (It saves where it was in the main code.)
Microcontroller Looks at Interrupt Vector Table (Finds the address of the ISR.)
Microcontroller Jumps to the ISR (Starts executing the interrupt service routine.)
ISR Executes (Handles the emergency or event.)
Return to Main Program (After ISR finishes, the microcontroller goes back exactly where it left off.)
Important Points About ISRs
Fast and Short: ISRs should be quick. Don’t put slow operations inside ISR.
No Return Value: ISRs usually do not return any value.
Special Syntax: In some programming languages (like C), you have to tell the compiler that a function is an ISR (using special keywords or attributes).
Global Variables: If you change variables inside an ISR, be careful — you might need to use volatile keyword.
Real Life Example
Suppose you have a doorbell system:
The microcontroller is busy displaying the time on a screen.
When someone presses the doorbell button, it triggers an interrupt.
The microcontroller pauses updating the time, rings the bell (by running the ISR), and then returns to updating the time.
Simple, right?
In a Simple Diagram:
Main Program --> [Interrupt Occurs] --> ISR Runs --> Main Program Continues
Simple External Interrupt ISR in C
Imagine:
You have a button connected to a GPIO pin (say Pin 2).
When the button is pressed, the microcontroller should turn ON an LED.
C Code Example:
#include <avr/io.h>      // Header for I/O functions (AVR microcontrollers)
#include <avr/interrupt.h> // Header for Interrupt functions

void setup()
{
    // Set Pin 2 (PD2) as input (button)
    DDRD &= ~(1 << PD2);

    // Set Pin 5 (PB5) as output (LED)
    DDRB |= (1 << PB5);

    // Enable external interrupt INT0 (which is usually on PD2)
    EIMSK |= (1 << INT0);

    // Set interrupt on rising edge (button press)
    EICRA |= (1 << ISC01) | (1 << ISC00);

    // Enable global interrupts
    sei();
}

ISR(INT0_vect)
{
    // This function will run when the button is pressed
    PORTB ^= (1 << PB5); // Toggle LED (ON if OFF, OFF if ON)
}

int main(void)
{
    setup(); // Call the setup function

    while (1)
    {
        // Main program loop does nothing
        // Microcontroller waits here until interrupt happens
    }
}
Now let’s explain this code line-by-line:
1. Header Files
#include <avr/io.h>
#include <avr/interrupt.h>
avr/io.h: To control input/output pins.
avr/interrupt.h: To use interrupt-related functions and macros.
2. Setup Function
void setup()
{
    // Set Pin 2 as Input
    DDRD &= ~(1 << PD2);
DDRD is the Data Direction Register for Port D.
PD2 means Pin 2 of Port D.
&= ~(1 << PD2) sets that pin as input.
    // Set Pin 5 as Output
    DDRB |= (1 << PB5);
DDRB is the Data Direction Register for Port B.
PB5 usually controls the on-board LED.
|= (1 << PB5) sets it as output.
3. Enable External Interrupt
EIMSK |= (1 << INT0);
EIMSK is the External Interrupt Mask Register.
INT0 is the external interrupt for Pin 2.
This enables external interrupt 0.
4. Set Interrupt Trigger (Rising Edge)
EICRA |= (1 << ISC01) | (1 << ISC00);
EICRA is the External Interrupt Control Register A.
ISC01 and ISC00 bits control how the interrupt is triggered.
Setting both = trigger interrupt on rising edge (button press).
5. Enable Global Interrupts
sei();
sei() function enables global interrupts.
Without this, no interrupt would happen!
6. Interrupt Service Routine (ISR)
ISR(INT0_vect)
{
    PORTB ^= (1 << PB5);
}
ISR(INT0_vect) defines the Interrupt Service Routine for External Interrupt 0.
Inside the ISR, we toggle the LED:
If LED was OFF, it turns ON.
If LED was ON, it turns OFF.
7. Main Loop
int main(void)
{
    setup();
    while (1)
    {
        // Main code does nothing
    }
}
We call setup() once to configure pins and interrupts.
Then, we sit in a forever loop.
The real work (turning the LED ON/OFF) happens inside the ISR when the button is pressed.
Important Note:
Never put delay or slow code inside an ISR. (Because it blocks the microcontroller from responding to new interrupts!)
Keep ISRs short and fast!
Final Big Picture Diagram:
Button Press (on PD2) --> Trigger INT0 Interrupt --> Run ISR(INT0_vect) --> Toggle LED --> Return to Main Loop
Quick Summary
Term
Meaning
Interrupt
A sudden event that needs immediate attention
ISR
Special function that runs when an interrupt occurs
Interrupt Vector Table
List that stores addresses of all ISRs
Why Do We Need to Enable or Disable Interrupts?
Enable interrupts when you want your system to listen and respond to external or internal events.
Disable interrupts temporarily if:
You are performing a critical task that should not be interrupted (example: updating shared memory).
You want to avoid conflicts between normal code and interrupt code.
How to Enable and Disable an Interrupt?
In general, enabling and disabling interrupts can happen in two ways:
Globally — affecting all interrupts.
Individually — affecting a specific interrupt.
Let’s see both!
Enabling and Disabling Global Interrupts
When you disable global interrupts, all interrupts are temporarily ignored. When you enable global interrupts, the CPU starts accepting interrupts again.
Common in C programming (Microcontrollers like AVR, ARM):
// Disable all interrupts globally
__disable_irq();  // For ARM Cortex (CMSIS standard)
cli();            // For AVR (Atmel chips)

// Enable all interrupts globally
__enable_irq();   // For ARM Cortex
sei();            // For AVR
Notes:
cli() = Clear Interrupt Flag (disable all interrupts)
sei() = Set Interrupt Flag (enable all interrupts)
Enabling and Disabling Specific Interrupts
Sometimes you don’t want to disable all interrupts — only a specific one (like just disabling the timer interrupt).
Example: Disabling specific interrupt in C
// Assuming you're using an AVR microcontroller
TIMSK0 &= ~(1 << TOIE0); // Disable Timer0 Overflow Interrupt

// To enable it back
TIMSK0 |= (1 << TOIE0);  // Enable Timer0 Overflow Interrupt
TIMSK0 is the Timer Interrupt Mask Register.
TOIE0 is the Timer Overflow Interrupt Enable bit.
Important Best Practices for Beginners
Only disable interrupts for a very short time (few microseconds) to avoid missing important events.
Always re-enable interrupts after your critical code section.
Never disable interrupts during long tasks like delays, communication, etc.
If you disable interrupts and forget to enable them again:
Your system may stop responding to events.
Timers, communication (UART, SPI, I2C), and other peripherals may fail.
It can freeze parts of your program.
Always double-check: if you disable interrupts, enable them back!
Summary for Enable / Disable Interrupts
Task
C Code (ARM Cortex)
C Code (AVR)
Disable all interrupts
__disable_irq();
cli();
Enable all interrupts
__enable_irq();
sei();
Disable specific interrupt
Clear relevant bit in interrupt mask register
Same
Enable specific interrupt
Set relevant bit in interrupt mask register
Same
Interrupt Priority in 8051 Microcontroller
Interrupt Priority means deciding which interrupt should be serviced first if two or more interrupts happen at the same time.
The 8051 microcontroller allows us to assign priorities to each interrupt:
Higher priority interrupt gets serviced first.
Lower priority interrupt waits until higher priority one finishes.
Thus, even if multiple events occur together, the CPU always knows which one is more important to handle first.
How Many Interrupts Are There in 8051?
The standard 8051 microcontroller has five interrupt sources:
Interrupt Name
Type
Description
INT0
External
External Interrupt 0 (P3.2 pin)
Timer 0
Internal
Timer 0 Overflow
INT1
External
External Interrupt 1 (P3.3 pin)
Timer 1
Internal
Timer 1 Overflow
Serial
Internal
Serial Communication (Receive/Transmit Complete)
How is Interrupt Priority Set in 8051?
In 8051, interrupt priorities are set using a special register called the Interrupt Priority Register (IP).
Each bit of the IP register corresponds to one interrupt:
Bit = 1 → High Priority
Bit = 0 → Low Priority
Structure of IP Register:
Bit
Name
Interrupt
7
–
(Reserved)
6
–
(Reserved)
5
PS
Serial Port
4
PT1
Timer 1
3
PX1
External Interrupt 1
2
PT0
Timer 0
1
PX0
External Interrupt 0
0
–
(Reserved)
Example:
IP = 0x10; // Set Timer 1 (PT1) as high priority
Default Interrupt Priority Order (Without Manual Setting)
If you don’t set anything manually, the default priority order is:
External Interrupt 0 (INT0)
Timer 0 Overflow
External Interrupt 1 (INT1)
Timer 1 Overflow
Serial Communication
👉 Lower number = Higher default priority
Example: Practical Understanding
Suppose:
External Interrupt 0 (INT0) is set to high priority.
Timer 1 Overflow is set to low priority.
If both interrupts occur together:
INT0 will be serviced immediately.
Timer 1 must wait until INT0’s ISR is completed.
Can Higher Priority Interrupt Interrupt an Ongoing ISR?
✅ Yes! If the CPU is executing a low-priority ISR and a high-priority interrupt occurs, the CPU pauses the low-priority ISR, services the high-priority ISR, and then returns back to complete the low-priority ISR.
But if two interrupts have the same priority, no interrupt nesting happens. The CPU finishes the current ISR first and then services the next interrupt.
Comparison between Interrupts and Polling:
Aspect
Interrupts
Polling
Definition
CPU is alerted by hardware when attention is needed.
CPU repeatedly checks the device status at regular intervals.
CPU Usage
Efficient; CPU works on other tasks until interrupted.
Inefficient; CPU wastes cycles checking status.
Response Time
Immediate (when interrupt occurs).
Depends on polling frequency; can be delayed.
System Efficiency
High, as CPU can perform other tasks.
Low, especially if polling rate is high.
Complexity
More complex to implement (needs ISR – Interrupt Service Routine).
Simpler to implement.
Power Consumption
Lower (saves power by sleeping/waiting).
Higher (continuous checking uses more power).
Suitability
Best for time-critical applications.
Suitable for simple, non-time-critical tasks.
Example Use Case
Keyboard input handling, real-time systems.
Reading sensor data at fixed intervals.
Interrupt Triggering Methods
Interrupts can be triggered in multiple ways, each with its own behavior and use case:
1. Level Triggered Interrupts
Level-triggered interrupts occur when a signal stays high (or low) for a certain period. The interrupt is triggered as long as the level condition is met.
Example: A button connected to the GPIO pin. If the button is pressed, the voltage level changes, and the interrupt is triggered as long as the button remains pressed.
2. Edge Triggered Interrupts
Edge-triggered interrupts occur when the signal changes state, such as from low to high (rising edge) or high to low (falling edge). These are often used when you only want to respond once to a signal transition.
Example: An external clock or pulse generator. You might want to trigger an interrupt every time the signal transitions from low to high.
3. Both Edge Triggered Interrupts
Some systems support interrupts on both rising and falling edges. This means the interrupt will be triggered whenever the signal transitions from low to high or high to low.
Example: A system that needs to respond to every clock pulse, whether it’s rising or falling.
Setting Up Interrupts in Embedded Systems
Setting up interrupts typically involves the following steps:
Configure the Interrupt: Set the interrupt priority, triggering method (rising edge, falling edge, level triggered), and the pin to which the interrupt is connected.
Enable the Interrupt: Enable the interrupt in the processor’s interrupt controller to start listening for the event.
Write an Interrupt Service Routine (ISR): The ISR is the function executed when the interrupt occurs. The ISR should be as fast as possible to avoid interrupting other important processes.
Enable Global Interrupts: After setting up the individual interrupt, enable global interrupts in the system to allow interrupts to occur.
Example Code for Setting up an Interrupt in C (Embedded Systems)
#include <avr/io.h>
#include <avr/interrupt.h>

void init_interrupt()
{
    // Set INT0 (external interrupt 0) to trigger on the rising edge
    EICRA |= (1 << ISC01) | (1 << ISC00);   // ISC01 and ISC00 bits for rising edge
    EIMSK |= (1 << INT0);                    // Enable INT0 interrupt
    sei();                                   // Enable global interrupts
}

ISR(INT0_vect)
{
    // Interrupt Service Routine (ISR) for INT0
    // This code will execute when the interrupt occurs
    PORTB ^= (1 << PB0);  // Toggle LED on PB0
}

int main()
{
    DDRB |= (1 << PB0);   // Set PB0 as output for LED
    init_interrupt();      // Initialize interrupt
    while (1)
    {
        // Main program loop
        // The program will continue running while waiting for interrupts
    }
}
Common Interrupts in Embedded Systems
Timer Interrupts: Used to trigger an interrupt after a specific time delay.
External Interrupts: Triggered by external events such as a button press or signal change on a GPIO pin.
USART Interrupts: Triggered when there is data received or transmitted via UART/USART.
ADC Interrupts: Triggered when an Analog-to-Digital Conversion (ADC) is completed.
Best Practices for Handling Interrupts
Keep ISRs Short and Efficient: Interrupts should be serviced as quickly as possible to avoid blocking other interrupts or tasks.
Minimize Global Variables in ISR: Avoid using global variables directly in the ISR. If needed, mark them volatile to prevent optimization issues.
Use Interrupt Priorities: In complex systems, interrupt priorities ensure that more important interrupts are processed first.
Disable Interrupts When Necessary: In critical sections of your code, disable interrupts temporarily to avoid unexpected behavior.
Differentiating the level-triggered and edge-triggered interrupt methods:
Aspect
Level-Triggered Interrupts
Edge-Triggered Interrupts
Triggering Condition
Triggered when the signal remains at a specific level (high or low) for a period of time.
Triggered when there is a transition in the signal, either from low to high (rising edge) or from high to low (falling edge).
Behavior
Interrupt remains active as long as the condition (level) is met.
Interrupt is triggered only once per signal transition.
Examples
A button press (signal stays high or low while the button is pressed).
A pulse generator (interrupt triggered on each pulse).
Type of Signal
Continuous (signal level stays constant).
Discrete (signal changes state).
Use Case
Typically used for continuous monitoring of a signal state (e.g., power-on signals, continuous sensor readings).
Used for detecting specific events like edges of clock signals, pulse counting, or event-driven systems.
Complexity
Simpler to implement but may result in longer interrupt durations.
More complex but allows for precise handling of events at the signal transition.
Example Application
Button press detection, monitoring constant voltage levels.
Clock edge detection, signal pulse measurement.
Frequently Asked Questions (FAQ) on Embedded System Interrupts
Q1: What is an interrupt in embedded systems?
An interrupt is a mechanism by which a processor’s normal execution flow is interrupted to handle an event or a condition that needs immediate attention. It allows the processor to deal with high-priority tasks in real-time.
Q2: What are the types of interrupts?
Hardware Interrupts: Triggered by external devices like sensors or timers, which notify the processor of the need for attention.
Software Interrupts: Generated by software instructions to request specific services, such as system calls.
Q3: What are interrupt vectors?
Interrupt vectors are memory addresses associated with each interrupt. When an interrupt occurs, the processor looks up the corresponding interrupt vector to find the appropriate service routine.
Q4: What is an interrupt vector table (IVT)?
The Interrupt Vector Table (IVT) is a table of addresses that defines where the processor should jump when an interrupt occurs. It contains the addresses of interrupt service routines (ISR) for each interrupt source.
Q5: What is an Interrupt Service Routine (ISR)?
An ISR is a function or routine that is executed when a specific interrupt occurs. It handles the interrupt, performs necessary tasks, and then returns control back to the main program.
Q6: What is interrupt priority?
Interrupt priority determines the order in which multiple interrupts are handled. High-priority interrupts are handled before low-priority ones, ensuring time-sensitive tasks are addressed first.
Q7: What are nested interrupts?
Nested interrupts allow a higher-priority interrupt to interrupt the ISR of a lower-priority interrupt. This ensures that critical tasks can preempt less important tasks.
Q8: How does interrupt masking work?
Interrupt masking is used to disable or enable specific interrupts. The processor may mask certain interrupts to prevent them from interrupting the current process, which can be useful for critical sections in the code.
Q9: What is the difference between edge-triggered and level-triggered interrupts?
Edge-triggered interrupts: Triggered by a change in the signal (either rising or falling edge).
Level-triggered interrupts: Triggered when the interrupt signal remains at a certain level (high or low) for a period of time.
Q10: How are interrupts managed in microcontrollers?
Microcontrollers usually have a dedicated interrupt controller (such as a Nested Vectored Interrupt Controller – NVIC) to handle and prioritize interrupts. This controller determines the response and execution order for interrupts.
Q11: What are the common uses of interrupts in embedded systems?
Interrupts are used in time-sensitive applications like handling external sensors, timers, communication protocols (e.g., UART, SPI, I2C), and real-time processing.
Q12: What is interrupt latency?
Interrupt latency is the time taken by the processor to start executing an ISR after an interrupt has occurred. Lower latency is critical for real-time applications.
Q13: What is the importance of context switching in interrupt handling?
Context switching refers to saving the state of the current process and loading the state of the ISR when an interrupt occurs. It ensures that the main program can resume after the ISR is executed.
Q14: How do you avoid interrupt handling issues like jitter and race conditions?
Proper synchronization techniques such as disabling interrupts, using flags, or employing atomic operations can help avoid issues like jitter (variability in interrupt response time) and race conditions (conflict between interrupt and main program).
Q15: What is the difference between polling and interrupt-based systems?
Polling: The processor continuously checks if an event has occurred.
Interrupt-based: The processor is alerted to an event only when it happens, reducing unnecessary CPU usage.
Q16: What are interrupt-driven I/O systems?
In interrupt-driven I/O systems, the processor is interrupted when I/O operations (such as reading from a sensor or writing to a peripheral) are ready to be processed, instead of constantly checking the status.
Q17: How do you implement an interrupt in an embedded system?
Steps include:
Enable the interrupt source (e.g., a peripheral or timer).
Configure the interrupt vector table.
Write the ISR to handle the interrupt.
Enable global interrupts.
Ensure proper return from the ISR to resume normal execution.
You can also Visit other tutorials of Embedded Prep
System Tick Timer: In embedded systems, timers are crucial for scheduling tasks, generating delays, and handling periodic events. One of the most commonly used timers in ARM-based microcontrollers is the SysTick Timer. It provides a simple and efficient way to keep track of time and manage periodic operations, making it an essential feature in embedded software development.
In this tutorial, we’ll walk through the fundamentals of the SysTick Timer, how it works, and how to configure and use it in embedded systems.
What is SysTick Timer?
The SysTick Timer is a special-purpose timer built into ARM Cortex-M microcontrollers. It’s designed to generate time delays and periodic interrupts at regular intervals. It’s part of the ARM Cortex-M core and is available on all Cortex-M-based processors.
Reload Value: The SysTick timer counts down from a specified value, generating interrupts when it reaches zero.
Clock Source: The timer can be configured to use the system clock or an external clock.
Interrupt Handling: SysTick can generate an interrupt on every count-down, which is useful for periodic task scheduling.
Automatic Reload: After the timer reaches zero, it automatically reloads with the value specified by the user, continuing the cycle.
Programmable Frequency: You can set the interval at which the timer triggers an interrupt, giving flexibility to control periodic events.
How the SysTick Timer Works
The SysTick Timer operates in a countdown mode. Here’s a breakdown of how it works:
Initialization: The timer is configured with a reload value and a clock source. The reload value determines how many clock cycles the timer will count before triggering an interrupt.
Countdown: The timer starts counting down from the reload value.
Interrupt: When the timer reaches zero, it triggers an interrupt (if enabled), and the timer automatically reloads to the specified value to begin the next countdown.
System Clock: The timer operates based on the system clock or an external clock, and its frequency is dependent on the clock source.
Configuring the SysTick Timer
Let’s walk through how to configure and use the SysTick timer on a typical ARM Cortex-M microcontroller.
1. Setting Up the SysTick Timer The first step is to include the necessary header files for accessing the registers and configuring the SysTick timer.
#include "stm32f4xx.h"
2. Configuring the Timer The next step is to configure the SysTick timer’s reload value and clock source. Let’s say we want a periodic interrupt every 1 millisecond. To achieve this, we’ll configure the timer with the following steps:
Set the reload value based on the clock speed (system clock).
Enable the timer and interrupt.
void SysTick_Init(void) {
    // Assuming system clock is 16 MHz
    uint32_t reload_value = 16000 - 1;  // For 1 ms tick with 16 MHz clock

    // Set the reload value
    SysTick->LOAD = reload_value;

    // Set the clock source to system clock and enable interrupt
    SysTick->CTRL |= SysTick_CTRL_CLKSOURCE_Msk | SysTick_CTRL_TICKINT_Msk;

    // Enable the SysTick timer
    SysTick->CTRL |= SysTick_CTRL_ENABLE_Msk;
}
3. Handling the SysTick Interrupt To handle the SysTick interrupt, you need to write an interrupt service routine (ISR) to handle the periodic task triggered by the timer.
Here’s an example of a simple SysTick ISR:
void SysTick_Handler(void) {
    // Code to execute every time SysTick timer reaches zero (every 1 ms)
    // For example, toggle an LED or increment a counter
    static uint32_t counter = 0;
    counter++;
}
Example: Blinking an LED using SysTick Timer
Let’s now implement a simple example where an LED blinks every second using the SysTick timer. Assume we have an LED connected to a GPIO pin and want it to toggle every 1 second.
1. Configure the GPIO for LED
void GPIO_Init(void) {
    // Enable GPIO clock (assuming using STM32F4)
    RCC->AHB1ENR |= RCC_AHB1ENR_GPIOAEN;

    // Configure PA5 as output for LED (on-board LED for STM32F4)
    GPIOA->MODER |= GPIO_MODER_MODE5_0;
    GPIOA->MODER &= ~GPIO_MODER_MODE5_1;
}
2. Modify SysTick ISR to Toggle LED
In the SysTick interrupt, we’ll toggle the LED every time the counter reaches 1000 (i.e., 1 second).
void SysTick_Handler(void) {
    static uint32_t counter = 0;
    counter++;

    if (counter >= 1000) {  // 1000 ms = 1 second
        GPIOA->ODR ^= GPIO_ODR_OD5;  // Toggle LED
        counter = 0;  // Reset counter
    }
}
Benefits of Using SysTick Timer
Low Overhead: SysTick is part of the ARM Cortex-M core, so it’s very efficient in terms of resource usage.
Time Management: It simplifies time management in embedded systems, making it easier to implement periodic tasks.
Easy to Use: Configuring the SysTick timer is straightforward and requires minimal code.
Interrupt Handling: SysTick allows efficient interrupt-based handling of time-sensitive tasks.
Conclusion
The SysTick Timer is a valuable tool in embedded systems for managing time, generating delays, and handling periodic events. It’s simple to configure, offers low overhead, and is available on all ARM Cortex-M microcontrollers. With this timer, you can handle time-based tasks more efficiently in your embedded applications.
By following this beginner-friendly tutorial, you should now have a solid understanding of how to use the SysTick timer and its key features. Experiment with different configurations and interrupt handling to explore more advanced uses in your projects!
FAQ on SysTick Timer for Embedded Systems
Here’s a detailed FAQ covering all key aspects of the SysTick Timer in embedded systems. This FAQ is SEO-optimized with relevant keywords and answers common queries related to the SysTick timer.
1. What is the SysTick Timer in Embedded Systems?
The SysTick timer is a special-purpose timer built into ARM Cortex-M microcontrollers that helps manage time, generate delays, and handle periodic tasks. It’s a system tick timer designed for embedded systems to provide a simple, efficient way to manage time-based operations like task scheduling and periodic interrupts.
2. What Are the Key Features of SysTick Timer?
Some key features of the SysTick timer include:
Reload Value: Determines how many clock cycles the timer counts before triggering an interrupt.
Clock Source: Can be configured to use the system clock or an external clock source.
Interrupt Handling: Triggers an interrupt when the timer reaches zero, ideal for periodic tasks.
Automatic Reload: Reloads with the original value after reaching zero to start the next cycle.
Programmable Frequency: Allows configuration of the interval at which the timer triggers an interrupt.
3. How Does the SysTick Timer Work in ARM Cortex-M Microcontrollers?
The SysTick timer in ARM Cortex-M microcontrollers counts down from a specified reload value and triggers an interrupt when it reaches zero. The timer automatically reloads with the specified value to restart the countdown. It works based on the system clock or an external clock, and the interrupt generated can be used to handle time-critical operations in embedded systems.
4. How Do I Configure the SysTick Timer for Periodic Interrupts?
To configure the SysTick timer for periodic interrupts, follow these steps:
Set the Reload Value: This determines the timer’s interval based on the system clock. For example, if you want a periodic interrupt every 1 ms with a 16 MHz clock, you would set the reload value to 16000 - 1.
Enable Interrupts: You need to enable the SysTick interrupt and configure the SysTick control register to use the system clock and trigger interrupts.
Start the Timer: The SysTick timer is started by setting the appropriate control bits in the SysTick register.
Example code snippet:
void SysTick_Init(void) {
    uint32_t reload_value = 16000 - 1;  // For 1 ms with 16 MHz clock
    SysTick->LOAD = reload_value;
    SysTick->CTRL |= SysTick_CTRL_CLKSOURCE_Msk | SysTick_CTRL_TICKINT_Msk;
    SysTick->CTRL |= SysTick_CTRL_ENABLE_Msk;
}
5. What is the SysTick Interrupt Service Routine (ISR)?
The SysTick ISR is the function that gets executed every time the SysTick timer reaches zero. This ISR is triggered by the interrupt generated when the timer countdown completes. In this routine, you can perform tasks like toggling LEDs, updating counters, or executing other periodic actions.
Example SysTick ISR:
void SysTick_Handler(void) {
    static uint32_t counter = 0;
    counter++;
    if (counter >= 1000) {  // 1000 ms = 1 second
        GPIOA->ODR ^= GPIO_ODR_OD5;  // Toggle LED
        counter = 0;  // Reset counter
    }
}
6. How Do I Use the SysTick Timer to Blink an LED?
To blink an LED using the SysTick timer, you can configure the timer to trigger every 1 second (1000 ms). Inside the SysTick ISR, toggle the LED each time the counter reaches 1000.
Here’s how you can set it up:
Configure GPIO for the LEDvoid GPIO_Init(void) { RCC->AHB1ENR |= RCC_AHB1ENR_GPIOAEN; GPIOA->MODER |= GPIO_MODER_MODE5_0; GPIOA->MODER &= ~GPIO_MODER_MODE5_1; }
Configure SysTick for 1-second interruptsvoid SysTick_Init(void) { uint32_t reload_value = 16000 - 1; // For 1 ms with 16 MHz clock SysTick->LOAD = reload_value; SysTick->CTRL |= SysTick_CTRL_CLKSOURCE_Msk | SysTick_CTRL_TICKINT_Msk; SysTick->CTRL |= SysTick_CTRL_ENABLE_Msk; }
Toggle the LED in the ISRvoid SysTick_Handler(void) { static uint32_t counter = 0; counter++; if (counter >= 1000) { // 1000 ms = 1 second GPIOA->ODR ^= GPIO_ODR_OD5; // Toggle LED counter = 0; // Reset counter } }
7. What Are the Benefits of Using the SysTick Timer in Embedded Systems?
The SysTick timer offers several benefits in embedded systems:
Low Overhead: Being a part of the ARM Cortex-M core, the SysTick timer operates with minimal resource usage.
Accurate Time Management: It simplifies time management, ensuring periodic tasks run at precise intervals.
Interrupt Handling: SysTick provides an efficient mechanism to handle periodic interrupts, ideal for managing real-time operations.
Easy to Configure: With simple register settings, configuring the SysTick timer is straightforward and doesn’t require complex code.
8. How Do I Calculate the SysTick Timer’s Reload Value?
The reload value is calculated based on the system clock frequency and the desired interrupt interval. Use the following formula to calculate the reload value: Reload Value=(Desired Interval×System Clock Frequency)−1\text{Reload Value} = (\text{Desired Interval} \times \text{System Clock Frequency}) – 1
For example, if your system clock is 16 MHz and you want a 1 ms interval: Reload Value=(1 ms×16,000,000)−1=16,000−1=15,999\text{Reload Value} = (1 \, \text{ms} \times 16,000,000) – 1 = 16,000 – 1 = 15,999
9. Can I Use the SysTick Timer for Delays?
Yes, the SysTick timer can be used to generate delays in embedded systems. By configuring it to trigger at regular intervals, you can create precise delays. This is useful for creating timed operations without blocking the main program flow.
10. What Are Some Common Applications of SysTick Timer in Embedded Systems?
Some common uses of the SysTick timer in embedded systems include:
Generating periodic interrupts for task scheduling.
Creating time delays for sensor sampling or display updates.
Managing real-time operations like polling buttons or controlling motors.
Timekeeping for system uptime or clock generation.