Why is Yocto used instead of a traditional Linux OS? Learn how Yocto builds custom embedded Linux systems and why it beats Ubuntu or Debian for devices.
If Linux is already powerful, flexible, and open source, a very natural question comes up for anyone entering embedded systems:
Why is Yocto used rather than directly using a Linux OS?
Why not just install Ubuntu, Debian, or some other Linux distribution and move on?
This question is asked by beginners, debated by intermediate developers, and still carefully considered by experienced embedded Linux engineers. The short answer is simple: embedded systems have very different requirements than desktop or server Linux. The long answer is what this article is about.
Let’s break it down calmly, honestly, and practically
What is the Yocto Project in simple terms?
Before comparing yocto vs linux os, let’s clear up one major confusion.
Yocto is NOT an operating system. Yocto is NOT a Linux distribution.
The Yocto Project is a build system and framework that helps you create your own custom Linux distribution specifically for embedded devices.
Think of Yocto as:
A factory, not the product
A kitchen, not the meal
A toolchain for building Linux, not Linux itself
Using Yocto, you define:
Which kernel to use
Which drivers are included
Which libraries exist
Which services start at boot
How big the final image should be
How updates and security patches are handled
This is why people often ask:
Is Yocto a Linux distribution? No.
Is Yocto an operating system? No.
Yocto builds a custom Linux OS tailored exactly for your hardware and product.
What does “using Linux directly” mean in embedded systems?
When people say “just use Linux directly,” they usually mean:
Installing Ubuntu
Using Debian
Using Fedora
Using Red Hat
Using Ubuntu Core
These are general-purpose Linux distributions. They are designed for:
PCs
Laptops
Servers
Cloud environments
They assume:
Plenty of RAM
Large storage
Keyboard, mouse, display
Frequent package updates
Human interaction
Embedded systems are different.
An embedded device might have:
128 MB RAM
256 MB flash
No display
No keyboard
Boot time requirements
Real-time constraints
A product lifecycle of 10 to 15 years
This difference is the root of yocto vs linux debates.
Yocto vs Linux OS: the fundamental difference
Here is the core idea:
Linux is a kernel. Ubuntu, Debian, Red Hat are distributions. Yocto is a build system to create distributions.
When you use Ubuntu:
You adapt your product to the OS
When you use Yocto:
You adapt the OS to your product
That single difference explains why Yocto dominates embedded Linux.
Yocto vs Ubuntu for embedded systems
Let’s talk about the most common comparison: yocto vs ubuntu.
Ubuntu is great when:
You want fast prototyping
You have powerful hardware
You want quick access to packages
Storage and RAM are not critical
Ubuntu struggles when:
You need a minimal image
You need full control over boot
You need reproducible builds
You need long-term maintenance without surprise updates
With Yocto:
You decide exactly what goes into the root filesystem
You remove everything unnecessary
You control every dependency
You rebuild the same image years later
This is why yocto linux vs ubuntu strongly favors Yocto for production devices.
Yocto vs Debian
Debian is stable, reliable, and loved by many engineers. So why not Debian?
In a yocto vs debian comparison:
Debian:
Uses prebuilt binary packages
Assumes general-purpose hardware
Pulls in many indirect dependencies
Is harder to strip down safely
Yocto:
Builds everything from source
Creates a minimal root filesystem
Avoids unused packages entirely
Ensures deterministic builds
Debian works well for development boards. Yocto works better for shipping products.
Yocto vs Red Hat
Red Hat focuses on:
Enterprise servers
Certified hardware
Subscription-based support
Long-term enterprise updates
In yocto vs redhat, the difference is simple:
Red Hat is not designed for deeply embedded devices
Yocto is built specifically for embedded use cases
Most embedded hardware vendors provide Yocto-based BSPs, not Red Hat images.
Yocto vs Ubuntu Core
Ubuntu Core is Canonical’s answer to embedded Linux.
In yocto vs ubuntu core:
Ubuntu Core uses snap packages
Updates are transactional
It works well for IoT gateways
But Ubuntu Core:
Still limits deep customization
Locks you into Canonical tooling
Is less flexible at low-level system design
Yocto gives you:
Complete architectural freedom
No vendor lock-in
Full control over system behavior
Customization: where Yocto wins clearly
Customization is the biggest reason why Yocto is used rather than directly using a Linux OS.
With Yocto, you control:
Kernel configuration
Device tree
Init system
Filesystem layout
Boot scripts
Package versions
Compiler flags
This is done using:
Recipes
Layers
BitBake
BSPs
Images
Nothing is hidden. Nothing is forced.
With standard Linux distros, customization often means fighting defaults.
Performance and footprint
Embedded systems care deeply about:
Boot time
Memory usage
Storage footprint
Ubuntu or Debian images often:
Include unused services
Include extra libraries
Consume more RAM
Increase attack surface
Yocto images:
Include only what you need
Boot faster
Use less memory
Fit into small flash sizes
This alone explains many yocto vs linux os decisions.
Security and long-term maintenance
Security is not just about patches. It’s about control.
Yocto enables:
Known package versions
Controlled updates
CVE tracking
Rebuilding images with fixes
Long-term maintenance strategies
Embedded products often live in the field for a decade. Yocto supports that reality better than rolling Linux distributions.
Real-world use cases where Yocto dominates
Automotive
Infotainment systems
Instrument clusters
ADAS platforms
Automotive Linux almost always uses Yocto.
Industrial devices
PLCs
HMIs
Control systems
These systems demand stability and long lifecycles.
Medical devices
Strict certification
Controlled software environments
Predictable updates
IoT and edge devices
Gateways
Sensors
Smart controllers
This is why Yocto is everywhere in production embedded Linux.
Common beginner doubts and myths about Yocto
“Yocto is too complex”
Yes, there is a learning curve. But complexity exists because embedded systems are complex.
“Yocto is slow”
Initial builds are slow. Incremental builds are fast and reliable.
“Yocto replaces Linux”
No. Yocto builds Linux-based systems.
“Yocto is only for experts”
Beginners use Yocto every day. They just learn it step by step.
When Yocto is NOT the right choice
Yocto is powerful, but not always needed.
Avoid Yocto if:
You are doing quick demos
Hardware is powerful
Product lifespan is short
You want fast experimentation
In these cases, Ubuntu or Debian may be better.
Advantages and disadvantages of Yocto (text table)
Advantages
Full system customization
Minimal footprint
Reproducible builds
Long-term maintenance
Industry standard for embedded
Disadvantages
Steep learning curve
Longer initial setup
Build time can be high
Requires discipline and structure
Yocto Linux versions explained
A common question is about yocto linux versions.
Yocto releases:
Are named after characters
Follow predictable release cycles
Offer Long Term Support versions
Yocto tracks kernel versions but does not lock you into one. You choose your kernel.
Frequently Asked Questions
Is Yocto a Linux distribution?
No. Yocto builds Linux distributions.
Is Yocto an operating system?
No. The OS is what Yocto creates.
Can Yocto replace Ubuntu?
Yocto does not replace Ubuntu. It serves a different purpose.
Do I need Yocto for embedded Linux?
Not always. But for production systems, usually yes.
Why do companies prefer Yocto?
Control, stability, customization, and long-term support.
Final conclusion: Why is Yocto used rather than directly using a Linux OS?
So, let’s come back to the core question:
Why is Yocto used rather than directly using a Linux OS?
Because embedded systems are not desktops.
Because products need control, not convenience.
Because long-term stability matters more than quick installs.
Because hardware-specific customization is non-negotiable.
Because reproducibility and maintainability define success.
Standard Linux distributions are excellent tools.
Yocto exists for when those tools are no longer enough.
If you are building an embedded product that must run reliably for years, Yocto is not overkill. It is the right tool.
That is why Yocto is used.
Many engineers start understanding why Yocto is used rather than directly using a Linux OS when they face real interview scenarios. Going through practical Yocto interview questions for professionals helps connect theory with industry expectations. https://embeddedprep.com/yocto-interview-questions-for-professionals/
Master Yocto Interview Questions for Professionals a complete beginner-to-pro guide with real-time scheduling, interrupts, task management, and practical embedded tips.
It was a cold night of December when I was sitting in front of my laptop, sipping hot coffee, watching yet another bitbakebuild hang at 92%. The office was quiet, only the sound of fans from our build server filled the air.
If you’ve ever worked with the Yocto Project, you know this feeling—long builds, strange errors, and sometimes a kernel panic staring at you from the serial console. In that moment, I realized something important:
This is exactly what interviewers want to know. Not if you can run bitbake core-image-minimal, but if you can survive when Yocto throws problems at you.
Below are real-world problems I faced, retold as interview-style questions—the kind that test whether you’ve lived through these moments or just read the documentation.
Yocto Interview Questions for Professionals
1.What do you do when bitbake hangs?
I remember one Friday evening—everyone was leaving early, but my build refused to move forward. The trick was simple:
First, crank up the logs with bitbake <target> -DDD.
While that ran, I opened htop and saw memory usage was maxed out.
Cleaning the recipe with bitbake -c clean <recipe> and restarting the build saved me.
Lesson: Don’t just panic, look at logs and resources first.
2. How do you debug a kernel panic in a Yocto-built image?
The first time I saw a kernel panic on my embedded board, I thought the hardware was dead. But no—it was just the software. The serial console showed me a crash address. Using:
addr2line -e vmlinux <address>
I traced it back to a missing driver configuration. After enabling CONFIG_DEBUG_KERNEL, I finally got readable logs.
Lesson: Always capture logs from the panic before touching the code.
3. How do you find which package provides a given binary?
One night, a teammate asked: “Which recipe gives us lsusb?” Instead of guessing, I ran:
oe-pkgdata-util find-path /usr/bin/lsusb
Within seconds, we had the package name.
Lesson: Yocto has hidden gems of tools—learn them.
4. How do you rebuild only a single recipe instead of the full image?
Waiting 3 hours for a full image rebuild is pain. The smart way:
bitbake -c clean <recipe>
bitbake <recipe>
And then just repack into the image. Saved me countless nights.
5. Difference between clean commands
I learned this the hard way when I used cleanall and lost my entire source download at 2 AM.
clean → removes build artifacts.
cleansstate → removes build + sstate cache.
cleanall → wipes everything, including source.
Lesson: Use cleanall only if you suspect corrupted source.
6. How do you apply a patch to the kernel or a package?
I still remember applying my first patch. I created a bbappend, added:
SRC_URI += "file://fix.patch"
Dropped the patch inside files/, rebuilt, and boom—it worked.
7. How do you verify the root filesystem contents?
There was a time we shipped an image without scp installed—disaster! Now I always check rootfs:
With oe-pkgdata-util list-pkgs.
Or mount the .ext4 image and inspect manually.
8. How do you debug missing shared libraries?
Nothing hurts more than seeing “error while loading shared libraries” on boot. My fix:
ldd <binary>
Then track the missing library using oe-pkgdata-util find-path. Finally, add the package in:
IMAGE_INSTALL_append = " libxyz"
9. How do you integrate debugging tools (gdb, strace, perf)?
When I was new, debugging meant printing logs. But then I discovered the real power:
IMAGE_INSTALL_append = " gdb strace perf"
Suddenly, I could trace syscalls, debug processes, and even profile performance.
10. How do you handle dependency issues in Yocto builds?
This is where patience wins. Once, my build broke because a recipe forgot to depend on zlib. Using:
I generated a dependency graph. The missing link was obvious. Adding it to DEPENDS fixed everything.
Final Thoughts
When I look back at those long debugging nights, I realize they made me a stronger engineer. Yocto is not just about writing recipes—it’s about learning how to fight through errors, crashes, and panics.
If you can tell such stories in an interview, you’ll stand out. Because at the end of the day, Yocto is less about memorizing commands and more about proving that you can debug under pressure.
Frequently Asked Questions (FAQ)
Q1. Why do interviewers focus on debugging and troubleshooting in Yocto interviews?
A1. Because real-world Yocto projects are full of unexpected issues—build hangs, kernel panics, missing libraries. Interviewers want to see if you can solve practical problems, not just run simple commands.
Q2. What is the most common issue developers face in Yocto builds?
A2. The most common are build hangs, missing dependencies, and runtime errors like missing shared libraries. Knowing how to debug these quickly is a key skill.
Q3. How can I prepare for Yocto debugging interview questions?
A3. Practice real scenarios: trigger build errors, break recipes intentionally, and then fix them. Reading only documentation won’t give you the confidence that hands-on troubleshooting will.
Q4. What’s the difference between bitbake -c clean, cleansstate, and cleanall?
Q5. How do you debug a kernel panic in a Yocto-built image?
A5. Use the serial console to capture logs, enable kernel debug configs, and trace the crash address with addr2line. Then check drivers and device tree settings.
Q6. What tools help debug missing shared libraries?
A6. Run ldd <binary> to check dependencies, and use oe-pkgdata-util find-path to locate the missing library’s package.
Q7. Can I add debugging tools like gdb and strace directly in Yocto?
A7. Yes, add them to your image using: IMAGE_INSTALL_append = ” gdb strace perf”
Q8. How do I check the contents of a Yocto root filesystem before flashing?
A8. You can list packages with oe-pkgdata-util list-pkgs or mount the .ext4 rootfs image and browse its contents.
Q9. Why is bitbake sometimes very slow or hangs?
A9. Common reasons are insufficient system resources, corrupted sstate-cache, or deadlocks in tasks. Debug logs (-DDD) and system monitoring help pinpoint the issue.
Q10. Is debugging Yocto mostly about memorizing commands?
A10. No—debugging Yocto is about systematic problem-solving. Commands help, but the real skill lies in understanding logs, dependencies, and how the build system works.
You can also Visit other tutorials of Embedded Prep
Prepare for your embedded Linux career with our comprehensive guide on Yocto Interview Questions. This article covers common and advanced questions, practical tips, and step-by-step explanations to help you confidently crack Yocto-related interviews. Ideal for beginners and experienced developers aiming to strengthen their Yocto knowledge and ace technical rounds.
When Ravi, a young embedded developer, first joined an automotive company, he was super excited about working with Yocto. On his very first task, he was asked to customize the Linux kernel and add a new package to the image. But he froze—he only knew the basics of Yocto and BitBake. His senior smiled and said:
“Don’t worry, once you understand the intermediate concepts, Yocto will feel less scary and more powerful.”
That’s exactly what this article is about. If you’ve already covered the Yocto basics, these intermediate interview questions will help you prepare for real-world scenarios like Ravi’s.
Intermediate Yocto Interview Questions
1.Explain the Yocto build process step by step.
Meet Priya, an embedded engineer who needs a custom Linux image for a BeagleBone. She’s never built a full Yocto image before, so she treats the work like a recipe: gather ingredients, prepare the kitchen, follow the steps, and taste-test the result. Below is the recipe Priya followed — written so you can copy, paste, and run it yourself.
Short roadmap (what you’ll do)
Prepare your build host and install prerequisites.
Fetch Yocto (poky) and any BSP/meta layers.
Create a build directory and source the environment.
Configure local.conf and bblayers.conf.
Add custom layers or recipes (optional).
Run bitbake <image> to build.
Inspect outputs, SDKs, and caches.
Debug and iterate.
The step-by-step story (with commands & why)
1) Prepare the build host
Priya installs the packages the Yocto docs list (Python, git, required dev libs). Having the recommended host packages avoids weird failures later. The Yocto Quick Start lists the build-host prerequisites and the basic flow to get started. (Yocto Project Documentation)
Why: Yocto builds are heavy and sensitive to host tools. Install the distro packages the docs recommend before you start.
2) Get the source: clone poky and layers
Priya clones poky (the Yocto reference distribution) and any layers she needs (for example meta-openembedded, vendor BSP layers, or meta-myproject).
git clone git://git.yoctoproject.org/poky
cd poky
git clone git://git.openembedded.org/meta-openembedded ../meta-openembedded
# add other BSP/meta layers as needed
This is the usual starting point for a Yocto build. The Quick Build shows the typical checkout-and-build flow. (Yocto Project Documentation)
3) Create a build directory and source the environment
Priya runs the helper script to create and enter a build environment:
That script creates build/conf/ and sets up environment variables so bitbake works from the build directory. (Yocto Project Documentation)
4) Configure the build (local.conf & bblayers.conf)
Inside build/conf/ there are two files you edit:
local.conf — set MACHINE, BB_NUMBER_THREADS, PARALLEL_MAKE, and paths for DL_DIR and SSTATE_DIR.
bblayers.conf — list the layers (paths) the build should use.
Priya sets MACHINE to her board (e.g., beaglebone), points DL_DIR and SSTATE_DIR to a big fast disk, and tweaks thread counts so the build uses her CPU effectively. The Yocto build docs explain how these files control the build and where to set caches and machine targets. (Yocto Project Documentation)
Tip: Use a shared sstate-cache if you build multiple images or share between developers — it saves a lot of rebuild time.
5) Add or create a layer (optional; for your recipes)
If Priya needs to add a custom driver or recipe, she either adds an existing layer with:
bitbake-layers add-layer ../meta-my-layer
or creates one (yocto-layer helper or templates) and puts .bb recipes there. Layers let you keep custom code separate from upstream meta layers. The Yocto docs and common tasks sections show how layers and recipes organize metadata. (Yocto Project Documentation, The Yocto Project)
6) Build the image with BitBake
Now the main command:
bitbake core-image-minimal # or your custom-image
What happens under the hood? BitBake parses recipes, resolves dependencies, and runs recipe tasks in order (for each recipe: do_fetch → do_unpack → do_patch → do_configure → do_compile → do_install → do_package → do_populate_sysroot / image assembly). These tasks and their ordering are defined in the build system and are executed automatically. (Yocto Project Documentation)
Practical notes:
Build time depends on what needs to be compiled and whether artifacts exist in sstate/DL_DIR.
Use bitbake -k <image> to keep building other packages when failures occur, or bitbake -c cleansstate <recipe> to force rebuilding a recipe from scratch.
7) Where the results live (artifacts)
When the build succeeds, Priya finds images and packages under:
build/tmp/deploy/images/<MACHINE>/
There will be kernel zImage/uImage, rootfs tarballs, wic images, and package feeds. If she built an SDK, it appears from bitbake -c populate_sdk <image> (or bitbake <image>-sdk). The Yocto Quick Build and build docs describe where these outputs are placed. (Yocto Project Documentation)
8) Caching & downloads — why they matter
Two folders are critical:
DL_DIR — stores downloaded source tarballs.
SSTATE_DIR — shared state cache with prebuilt intermediate results.
Priya points these to persistent storage so subsequent builds (or other developers) reuse downloads and compiled pieces — massively speeding up rebuilds. The docs emphasize using DL_DIR and SSTATE_DIR to optimize builds. (Yocto Project Documentation)
9) Useful BitBake commands for iteration & debugging
bitbake -c listtasks <recipe> — show available tasks.
bitbake -c fetch <recipe> — fetch sources only.
bitbake -c cleansstate <recipe> — erase sstate for a recipe.
bitbake -e <recipe> — show environment variables.
bitbake <recipe> -c devshell — drop into a build shell for debugging (if supported).
Inspect logs: build/tmp/work/<arch>/<recipe>/<version>/temp/log.* for do_compile, do_configure, etc. See the tasks and common tasks docs for more debugging workflows. (Yocto Project Documentation)
If a dependency fails to fetch: check DL_DIR and proxy settings.
If compile fails: inspect the recipe’s log.do_compile and try bitbake -c cleansstate <recipe> and rebuild.
If build is slow: increase BB_NUMBER_THREADS and PARALLEL_MAKE in local.conf and ensure sstate is on fast storage.
If image missing a package: add it to IMAGE_INSTALL in local.conf or the image recipe.
Final — a one-paragraph recap
Priya’s Yocto build was a sequence of preparation (host packages), pulling the right metadata (poky and layers), configuring local.conf/bblayers.conf, and running bitbake which orchestrates many recipe tasks (fetch → configure → compile → package → assemble image). Artifacts end up in tmp/deploy/images/<MACHINE>, while DL_DIR and SSTATE_DIR speed up future builds. The Yocto docs (Quick Start, build/dev manual, and BitBake tasks reference) are excellent companions while you learn and iterate. (Yocto Project Documentation, The Yocto Project)
2.What is a .bbclass file and why is it used?
Imagine you are working in a kitchen that serves hundreds of recipes every day. Instead of writing the same steps like “wash vegetables, cut onions, add oil to the pan” in every recipe card, you create a shared guidebook. Every new recipe just says “follow the guidebook for chopping and frying” — simple, clean, and reusable.
That’s exactly what a .bbclass file does in Yocto.
A .bbclass file is a BitBake class file used in Yocto. It contains common functions, tasks, and variables that can be inherited by multiple recipes (.bb files).
Instead of duplicating code across recipes, developers put shared logic in a .bbclass file and then use:
inherit <classname>
inside their .bb recipe.
Why is it used? (Benefits)
Code Reuse → Write once, use everywhere. Example: packaging steps, fetching from Git, or autotools build flow.
Consistency → Ensures all recipes follow the same structure for similar tasks.
Simplifies Maintenance → Fix a bug or update logic in one .bbclass file, and all recipes that inherit it get the fix automatically.
Customization → Developers can create their own custom classes (like mycompany-update.bbclass) to enforce company-specific build rules.
Examples in Yocto
autotools.bbclass → Provides standard tasks for configure/compile/install when building with GNU Autotools.
cmake.bbclass → Defines how to build packages using CMake.
kernel.bbclass → Provides helper tasks for building Linux kernels.
In short: A .bbclass file in Yocto is like a shared recipe guide. It holds reusable build instructions that multiple recipes can inherit, making builds more efficient, cleaner, and easier to maintain.
Rreal-life mini example to show how .bbclass makes your Yocto recipes clean and reusable.
Step 1: Create a custom .bbclass file
Let’s say you often write recipes that install a simple script into /usr/bin. Instead of repeating the do_install task everywhere, you can create a .bbclass file:
my-common.bbclass
# my-common.bbclass
# A reusable class to install scripts into /usr/bin

do_install() {
    install -d ${D}${bindir}
    install -m 0755 ${WORKDIR}/${PN}.sh ${D}${bindir}/${PN}
}
What this does:
Creates /usr/bin in the rootfs (${bindir}).
Installs a script named after the recipe (${PN}.sh) into /usr/bin.
Step 2: Create two recipes that use this class
Now we’ll write two recipes that inherit this class.
hello-script.bb
SUMMARY = "A simple hello world script"
LICENSE = "MIT"
SRC_URI = "file://hello-script.sh"

S = "${WORKDIR}"

inherit my-common
goodbye-script.bb
SUMMARY = "A simple goodbye script"
LICENSE = "MIT"
SRC_URI = "file://goodbye-script.sh"

S = "${WORKDIR}"

inherit my-common
Step 3: Add the scripts
Inside each recipe’s files/ directory, add the scripts:
hello-script.sh
#!/bin/sh
echo "Hello, Yocto World!"
goodbye-script.sh
#!/bin/sh
echo "Goodbye, Yocto World!"
Step 4: Build and check
When you run:
bitbake hello-script
bitbake goodbye-script
👉 Both will install their scripts into /usr/bin/hello-script and /usr/bin/goodbye-script, but thanks to my-common.bbclass, you didn’t duplicate the do_install logic in each recipe.
Key Takeaway: The .bbclass file acts like a reusable library of tasks. Instead of repeating installation steps across multiple recipes, you write them once and just inherit it.
Typical Layer Structure
When you create a new layer (say meta-mycustom), the structure looks like this:
This tells Yocto where to look for recipes (.bb) and classes (.bbclass).
Step 3: Inherit the class in your recipes
Inside each recipe (hello-script.bb or goodbye-script.bb), add:
inherit my-common
That’s it — now both recipes reuse the logic from your .bbclass.
Step 4: Build and verify
From your build directory:
bitbake hello-script
bitbake goodbye-script
After build, check inside the rootfs (tmp/work/.../image/usr/bin/) and you should see:
/usr/bin/hello-script
/usr/bin/goodbye-script
In short:
.bbclass files live in classes/ inside your layer.
Point to them via layer.conf.
Inherit them in recipes to avoid duplicating code.
3.Difference Between .bb and .bbappend Files in Yocto
Imagine you’re a chef in a big kitchen.
A recipe card (.bb file) tells you exactly how to cook a dish — what ingredients to fetch, how to prepare them, and how to plate it.
But sometimes, you don’t want to rewrite the whole recipe. Instead, you just want to say: “Add extra spices” or “Serve with salad”. That’s where a .bbappend file comes in — it lets you extend or modify the original recipe without copying the entire thing.
What is a .bb file?
A BitBake recipe file (.bb) describes how to build a package.
It contains instructions like:
where to fetch source code (SRC_URI)
how to configure and compile (do_compile, do_install)
# Add an extra patch to hello recipe
SRC_URI += "file://hello-fix.patch"

do_install_append() {
    echo "Hello Yocto!" > ${D}${bindir}/extra.txt
}
This doesn’t replace the original recipe — it piggybacks on it and adds modifications.
Key Differences
Feature
.bb File
.bbappend File
Purpose
Defines a recipe from scratch
Extends or modifies an existing recipe
Content
Full build instructions (fetch, compile, install)
Only contains changes or additions
Naming
<recipe>_<version>.bb
<recipe>_<version>.bbappend
Use Case
When creating a new package/recipe
When tweaking an existing recipe (add patches, change variables, etc.)
In short:
.bb → full recipe (like the original cookbook entry).
.bbappend → patch/extension to an existing recipe (like adding your own notes on the cookbook page).
4.How do you use the bitbake-layers command?
Ans: Imagine you’ve just started working on a Yocto project. You open the project folder and see so many files and directories that it feels like walking into a big library with no map. Every book (or in Yocto’s case, every recipe) is kept in a section called a layer. But the question is: how do you quickly find out which sections exist, what books are inside, or where a new book should go?
That’s where the bitbake-layers command becomes your guide. Think of it as the librarian of Yocto layers.
What can this “librarian” do for you?
Show all the sections (layers) you already havebitbake-layers show-layers => Just like asking the librarian, “Which sections are in this library?”
List all the books (recipes) insidebitbake-layers show-recipes => You’ll see all the recipes Yocto knows about.
Find out who provides a specific bookbitbake-layers show-recipes <recipe-name> => If the same book exists in two sections, this command tells you which one is being used.
Add a new section to your librarybitbake-layers add-layer ../meta-myproject => Imagine bringing a brand-new section of books and placing it in the library.
Remove a section you no longer needbitbake-layers remove-layer ../meta-myproject => Just like taking out an old, unused section.
Check which books have special notes (appends)bitbake-layers show-appends => Shows you all .bbappend files—like sticky notes attached to certain books with extra instructions.
Why is this helpful for beginners?
When you’re new to Yocto, it’s easy to get lost. The bitbake-layers command gives you clarity and control:
You know which layers are active.
You can quickly spot which recipe is being used.
Adding or removing layers becomes simple.
In short: The bitbake-layers command is like a friendly librarian for your Yocto project—it shows you the layers, recipes, and lets you manage them without confusion.
5.What is the purpose of DL_DIR, SSTATE_DIR, and TMPDIR in Yocto?
Ans: Imagine you are building a huge Lego city with thousands of pieces. To make it faster and smoother, you don’t want to run to the shop every time you need a piece, right? You’ll keep some parts in storage, reuse old ones, and have a special workbench where you assemble everything.
In Yocto, these three directories act just like that:
1. DL_DIR → The Lego Shop Bag
Whenever you need new Lego parts, you first download them. In Yocto, source codes, patches, and tarballs are downloaded and saved inside DL_DIR.
Purpose:
Stores all downloaded source files.
Prevents downloading the same thing again in future builds.
Saves internet bandwidth and time.
Think of it as the bag you bring home from the Lego shop—you keep it safe so you don’t need to buy the same piece twice.
2. SSTATE_DIR → The Reusable Parts Box
As you build, sometimes you already assembled something earlier, like a Lego house wall. Instead of rebuilding it from scratch, you pull it out of your reusable box.
Purpose:
Stores precompiled and cached build outputs.
Allows Yocto to reuse previous builds.
Makes repeated builds much faster.
It’s like your personal storage of pre-built Lego walls, windows, and doors—ready to plug in without wasting time.
3. TMPDIR → The Workbench
This is where the real action happens. You open the bag, take out pieces, use some from your reusable box, and build on your workbench.Purpose:
Stores all temporary build files.
Contains the working space for compiling, assembling, and linking.
Usually the largest directory in size.
It’s like the big table where you build your Lego city before showing it to the world.
Why are these three important together?
DL_DIR ensures you don’t keep downloading sources.
SSTATE_DIR ensures you don’t rebuild the same thing again.
TMPDIR is where Yocto actually builds your final image.
By using these three smartly, Yocto saves time, resources, and makes the build process efficient.
In short:
DL_DIR = Download bag (sources).
SSTATE_DIR = Reusable parts box (cached builds).
TMPDIR = Workbench (active build area).
Where do DL_DIR, SSTATE_DIR, and TMPDIR exist?
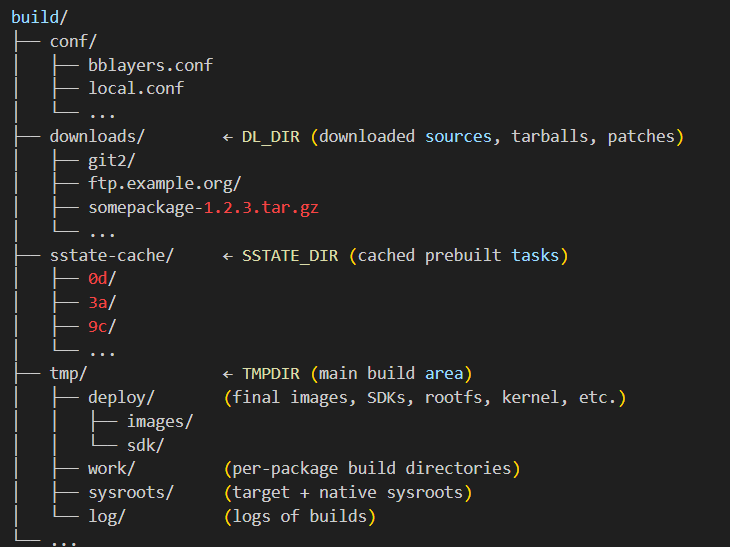
When you set up a Yocto build environment (by sourcing oe-init-build-env), a new folder called build/ (or whatever you named it) gets created. Inside this, there is a configuration folder called conf/local.conf.
This is the place where DL_DIR, SSTATE_DIR, and TMPDIR are defined.
Default locations:
DL_DIR
Default: build/downloads/
You can change it in local.conf: DL_DIR ?= "${TOPDIR}/downloads"
This folder will contain all the tarballs, source code archives, and patches.
SSTATE_DIR
Default: build/sstate-cache/
You can change it in local.conf: SSTATE_DIR ?= "${TOPDIR}/sstate-cache"
This is where Yocto saves prebuilt shared state objects (cache).
TMPDIR
Default: build/tmp/
You can change it in local.conf: TMPDIR ?= "${TOPDIR}/tmp"
This folder is the biggest one—it contains all intermediate build files, sysroots, and the final images.
So, do they always exist?
Yes, by default they get created automatically when you run your first bitbake build.
Their locations are controlled from local.conf (inside build/conf/).
You can move them outside the build folder if you want to share downloads or sstate across multiple projects.
In short:
These three directories exist inside your Yocto build directory by default.
You’ll see them as:
build/downloads → (DL_DIR)
build/sstate-cache → (SSTATE_DIR)
build/tmp → (TMPDIR)
6.How do you add a new package to a Yocto image?
Ans: Imagine you are preparing a lunchbox for a school trip. By default, the lunchbox already has some food items—like rice, vegetables, and water. But suddenly your friend says: “Hey, can you also add some chocolates?”
In Yocto, your image is just like that lunchbox. It already contains some software packages, but you can add extra packages (like chocolates) to it before it is built.
Step-by-Step (with Story)
Find the package you want
First, make sure the package exists in one of your Yocto layers.Example: Let’s say you want to add nano (a text editor).
It’s like checking if chocolates are available in your kitchen before packing. bitbake-layers show-recipes | grep nano
Edit the Image Recipe 🥡
Open your custom image recipe or local.conf.Add the package under IMAGE_INSTALL_append.
Example (inside local.conf): IMAGE_INSTALL_append = " nano" Just like putting chocolates inside the lunchbox.
Rebuild the Image
Now build the image again using:
bitbake core-image-minimal (or whichever image recipe you are using). This is like closing the lunchbox and preparing it for the trip.
Flash and Check
Once the image is built, flash it to your board and boot.Run:
nano --version If you see the version, it means your “chocolate” (package) is inside the lunchbox.
Why is this important?
Adding packages to a Yocto image is how you customize your embedded Linux system. Instead of shipping a plain box, you create a tailored image that has exactly the tools and applications you need.
In short: To add a new package to a Yocto image, you:
Check if the package recipe exists.
Add it to your image (IMAGE_INSTALL_append).
Rebuild the image.
Boot and verify.
It’s just like packing extra food in your lunchbox before a trip—simple, flexible, and under your control.
Adding Packages in Yocto: local.conf vs. Custom Image Recipe
Continuing with our lunchbox story
Imagine you are preparing lunch for a short picnic today. You quickly add a chocolate bar 🍫 inside your own lunchbox. But when you open a canteen business (serving hundreds of students every day), you wouldn’t go and edit each lunchbox one by one—you’d create a standard menu 🍱 that always includes chocolates.
That’s exactly the difference between using local.conf and a custom image recipe in Yocto.
Method 1: Add Packages in local.conf
This is the quick and easy way, like packing your own lunchbox just for today.
Open build/conf/local.conf.
Add your package: IMAGE_INSTALL_append = " nano htop"
Build the image.
Best for testing and experimenting with packages. Not good for long-term projects, because your changes stay only in your local setup.
Method 2: Create a Custom Image Recipe
This is the professional way, like writing a canteen’s fixed lunch menu 🍱. Every lunchbox that comes out will automatically follow this recipe.
Steps:
Create a new recipe inside your own layer, e.g.: meta-myimage/recipes-core/images/my-image.bb
Inside the .bb file, define your image: SUMMARY = "My Custom Image" LICENSE = "MIT" IMAGE_INSTALL += " \ nano \ htop \ vim \ " inherit core-image
Build with: bitbake my-image
Best for real projects and teams where you want reproducibility and a clean history of changes.
Comparison Table
Method
When to Use
Example Use Case
local.conf
Quick testing, one-time changes
Adding nano just to try
Custom Image Recipe
Permanent project setup
Your product image always needs nano + htop + vim
7.What Steps Are Involved in Customizing the Linux Kernel in Yocto?
Ans : Let’s imagine a real-life story:
You bought a smart coffee machine that runs on an embedded Linux system. The company shipped it with basic features—make coffee, adjust temperature, etc. But as an engineer, you want to customize it. Maybe you want to add support for a new touchscreen display, or optimize the system to boot faster in the morning when you’re half-asleep.
This is exactly like customizing the Linux kernel in Yocto. The kernel is the heart of your embedded device, and Yocto lets you tune it for your hardware.
Here are the steps you’d follow in Yocto:
1. Identify Your Kernel Recipe
In Yocto, everything is managed with recipes. The Linux kernel recipe is usually found inside:
meta/recipes-kernel/linux/
For example: linux-yocto.bb or a vendor-specific kernel recipe.
In our coffee machine story: This is like finding the original recipe for your coffee—what beans, water temperature, and milk ratio are used.
2. Create Your Own Layer for Customization
Never edit Yocto’s default files directly. Instead, create a new layer (example: meta-coffee-kernel). This keeps your changes clean and separate.
Just like in real life: Instead of spoiling the company’s recipe book, you make your own recipe notes in a new diary.
3. Use a .bbappend File
To modify the kernel, create a .bbappend file that matches the original kernel recipe’s name. Example:
linux-yocto_%.bbappend
Here you can add patches, extra configurations, or point to a different kernel source.
Think of it like adding your own twist to the coffee recipe—extra chocolate powder or almond milk—without rewriting the whole recipe.
4. Add Kernel Configuration Changes
Yocto allows kernel configs using fragments. You can create a file like myconfig.cfg:
CONFIG_SPI=y
CONFIG_I2C=y
CONFIG_USB_SERIAL=m
Then reference it in your .bbappend.
In the coffee machine: This is like saying, “Always enable the steam nozzle, but make milk frother optional.”
5. Apply Kernel Patches (if needed)
If you want deeper customization (e.g., new driver, bug fix), you add a patch file (.patch) and tell Yocto to apply it.
Like fixing your coffee machine’s button that sometimes doesn’t work—you solder a fix and update the design.
6. Rebuild the Kernel
Run:
bitbake linux-yocto
Yocto will fetch, patch, configure, and build the kernel.
This is like brewing the coffee with your new recipe. You test if it tastes better.
7. Deploy and Test
Flash the newly built kernel to your board or device. Boot it and check logs:
dmesg
Make sure your new features are working.
Like sipping the coffee ☕—if it’s too strong, adjust again. If perfect, enjoy .
[
Step 1 ] ➝ Find Kernel Recipe
   📂 Location: meta/recipes-kernel/linux/
   Example: linux-yocto.bb

        |
        v

[ Step 2 ] ➝ Create Custom Layer
   📂 Example: meta-coffee-kernel
   (Keep changes clean, separate from Yocto core)

        |
        v

[ Step 3 ] ➝ Add .bbappend File
   📝 File: linux-yocto_%.bbappend
   (Extend original recipe without modifying it)

        |
        v

[ Step 4 ] ➝ Add Kernel Configurations
   🛠️ Example: myconfig.cfg
   CONFIG_SPI=y
   CONFIG_I2C=y
   CONFIG_USB_SERIAL=m

        |
        v

[ Step 5 ] ➝ Apply Kernel Patches (if needed)
   🧩 Add .patch files for drivers, bug fixes, or features

        |
        v

[ Step 6 ] ➝ Rebuild Kernel
   💻 Command: bitbake linux-yocto

        |
        v

[ Step 7 ] ➝ Deploy & Test
   📱 Flash new kernel → Boot device
   🔍 Check logs with: dmesg
8.How Do You Enable or Disable systemd in a Yocto Build?
Ans : Imagine you’re setting up a smart home system .
If you want everything automated (lights turn on, coffee machine starts, doors lock), you choose a modern manager to handle all tasks → this is like systemd.
If you want an old-school approach where you manually start things one by one, you stick with SysVinit.
In Yocto, you can decide which init system (startup manager) your embedded device should use.
Steps to Enable or Disable systemd in Yocto
1. Add systemd to DISTRO_FEATURES
Edit your distro configuration file (e.g., local.conf or your custom distro .conf file):
SysVinit = Old manual filter coffee maker 🫖 (still works, but step by step). In Yocto, you decide which one your “kitchen” (embedded device) should use.
9.What is the purpose of MACHINE, DISTRO, and TCLIBC variables?
1. MACHINE
What it means: It tells Yocto for which hardware (board/SoC/CPU architecture) you are building the image.
Why it matters: Each board has different bootloaders, kernel configs, and device trees. The MACHINE variable ensures Yocto picks the right BSP (Board Support Package).
Example:MACHINE = "beaglebone-yocto" MACHINE = "qemuarm64" 👉 If you set MACHINE="beaglebone-yocto", the image will include BeagleBone-specific kernel, bootloader, and drivers.
2. DISTRO
What it means: It defines the distribution policy — i.e., the set of rules about how the image is built, what features are included, and how packages are managed.
Why it matters: Different distros can enable/disable systemd, package managers, debug tools, or optimizations.
Example:DISTRO = "poky" DISTRO = "nodistro" 👉 If you use DISTRO="poky", you get the standard Poky distribution (Yocto’s reference distro). If you use nodistro, you get a very minimal build without distro-specific policies.
3. TCLIBC
What it means: It specifies which C library implementation will be used as the standard C library for the build.
Why it matters: The C library affects performance, footprint, and compatibility.
Options:
glibc → Default, full-featured, widely used
musl → Lightweight, fast, good for embedded
uclibc → Older, small footprint, but less common now
Example:TCLIBC = "glibc" TCLIBC = "musl" 👉 For a resource-constrained IoT device, you might choose musl. For a general Linux system, glibc is standard.
In short:
MACHINE → Which hardware/board am I targeting?
DISTRO → What distribution rules/policies should I follow?
TCLIBC → Which C library will power my programs?
Real-life analogy: Imagine you are cooking 👩🍳:
MACHINE = Which kitchen are you cooking in? (big restaurant kitchen vs. small home kitchen)
DISTRO = Which recipe book are you following? (Indian, Italian, or minimal diet plan)
TCLIBC = Which cooking oil are you using? (butter = full flavor, olive oil = light, coconut oil = minimal)
Let’s go step by step so you see where and how Yocto actually sets these variables.
Where MACHINE, DISTRO, and TCLIBC are set
MACHINE
Where it is set:
Usually in your conf/local.conf file (in the build/conf/ directory).
Machine-specific details (bootloader, kernel, device tree) live inside meta-<board>/conf/machine/<machine>.conf.
Example (local.conf):MACHINE ?= "beaglebone-yocto"
Machine config file (beaglebone-yocto.conf):require conf/machine/include/tune-arm926ejs.inc UBOOT_MACHINE = "am335x_boneblack_config" KERNEL_DEVICETREE = "am335x-boneblack.dtb" -> This tells Yocto to use BeagleBone’s bootloader and kernel device tree.
DISTRO
Where it is set:
In conf/local.conf (to pick which distribution you want).
The actual distro configuration file is inside meta-poky/conf/distro/poky.conf (if you’re using Poky).
Example (local.conf):DISTRO ?= "poky"
Distro config file (poky.conf):DISTRO_NAME = "Poky (Yocto Project Reference Distro)" DISTRO_VERSION = "4.0" INIT_MANAGER = "systemd" PACKAGE_CLASSES ?= "package_rpm" -> Here Yocto decides: use systemd as init, RPM as package format, etc.
TCLIBC
In short:
MACHINE → Set in local.conf, details in machine/*.conf.
DISTRO → Set in local.conf, rules defined in distro/*.conf.
TCLIBC → Set in local.conf, C library recipes chosen accordingly.
Real-life story: Imagine you’re running a food delivery kitchen:
MACHINE = Which branch kitchen you are cooking from (Delhi branch vs. Bangalore branch).
DISTRO = Which menu card you follow (North Indian thali, Italian pasta, or a custom diet menu).
TCLIBC = Which cooking base you use (butter, olive oil, or ghee).
All three work together so the customer (your embedded device) gets the right dish (final Linux image).
10.How to Minimize the Size of a Yocto Root Filesystem
Ans: When we build an operating system image with Yocto, the root filesystem (rootfs) contains all the programs, libraries, and files that your device will use. But in embedded devices (like routers, IoT boards, or automotive systems), storage is very limited. So, we must make the rootfs as small as possible.
Simple Ways to Minimize Yocto Rootfs
Use a Smaller Base Distribution
Instead of using the full poky (which is like a big buffet meal), you can use poky-tiny, which only gives you the essentials. This way, your system only gets what it really needs to run, nothing extra.
Remove Extra Tools and Debug Packages
By default, Yocto may add tools for debugging, profiling, or package management.
If your device doesn’t need them, remove them. It’s like packing your travel bag — if you’re going on a weekend trip, you don’t need to carry an iron, a heavy coat, or five pairs of shoes. Just take what’s necessary.
Use BusyBox Instead of Full Utilities
BusyBox is like a Swiss Army knife: it combines many small tools (like ls, cp, rm) into one lightweight binary.
This drastically cuts down size. Imagine instead of carrying 10 different kitchen tools (spoon, knife, peeler, corkscrew, opener…), you just carry a single Swiss knife that does all the jobs.
Choose a Lightweight C Library (musl)
Most Linux systems use glibc, but it’s heavy.
For small embedded devices, musl is a better option. It’s like choosing a lightweight sports bike instead of a heavy truck when you only need to move around the city.
Strip Debug Information
Programs often include debugging details, which are helpful for developers but unnecessary on the final device.
Removing this information saves space. It’s like buying new clothes — you don’t keep the price tags and extra packaging, you throw them away before wearing them.
Disable Package Manager (if you don’t need updates)
Package managers like RPM or opkg allow you to install new software later, but they also take up space.
If your device has a fixed purpose (like showing weather data on a screen), you don’t need a package manager. It’s like a set-top box — you don’t install apps on it every day, so why keep that extra overhead?
Compress the Filesystem
Use compressed filesystems like squashfs to shrink the final image size. This is like vacuum-packing clothes before a trip — same items, but taking up half the space.
Real-Life Application
Imagine you’re designing a smart home temperature monitor with an ESP32 or BeagleBone:
You only need:
A Linux kernel
Drivers for Wi-Fi and sensors
A small web server
A few basic commands
You don’t need:
Big GUI libraries
Multimedia tools
Heavy debugging utilities
By following the above tricks:
Your rootfs might shrink from 200 MB → 20 MB.
That means it fits easily into the device’s flash memory, and your product becomes faster and cheaper to produce.
In short:
Pick the smallest base (like poky-tiny).
Use BusyBox + musl.
Remove extras and strip binaries.
Compress the filesystem.
Your embedded device then becomes like a minimal backpack for a short trip — small, light, and only carrying what you need.
Minimal local.conf Example for Small Root Filesystem
# ================================
# Yocto Minimal RootFS Configuration
# ================================

# 1. Select target machine (board/SoC)
MACHINE ?= "beaglebone-yocto"

# 2. Use a small distribution
DISTRO ?= "poky-tiny"

# 3. Use lightweight C library
TCLIBC ?= "musl"

# 4. Keep only minimal image features
IMAGE_FEATURES = "splash"
EXTRA_IMAGE_FEATURES = ""

# 5. Remove unnecessary tools (debug, profiling, package management)
IMAGE_FEATURES_remove = "tools-debug tools-profile package-management"

# 6. Prefer BusyBox over full GNU utilities
PREFERRED_PROVIDER_virtual/ps = "busybox"
PREFERRED_PROVIDER_virtual/init = "busybox"

# 7. Strip debug symbols to reduce binary size
INHERIT += "rm_work"
IMAGE_GEN_DEBUGFS = "0"

# 8. Choose smaller package format (ipk is usually lighter than rpm/deb)
PACKAGE_CLASSES ?= "package_ipk"

# 9. Add compressed root filesystem type
IMAGE_FSTYPES += "squashfs"

# 10. Set default image to a minimal base image
CORE_IMAGE_EXTRA_INSTALL = ""
What This Does in Real Life
Imagine you are making a smart home gateway (like a Wi-Fi hub for IoT devices).
✅ poky-tiny + musl = minimal Linux base → fits into 16 MB flash.
✅ busybox = one tool instead of many → reduces space.
Master the most important Yocto interview questions for 2025. Prepare effectively for embedded software engineer roles with beginner to advanced level questions. The Yocto Project has become a standard in the embedded Linux world. Companies across automotive, industrial, IoT, and consumer electronics rely on Yocto to build custom Linux distributions. If you are preparing for an interview as an Embedded Software Engineer, having a strong grasp of Yocto is crucial.
This article covers carefully structured Yocto interview questions ranging from basic concepts to real-world problem-solving. Whether you are a fresher, intermediate developer, or senior engineer, this guide will help you prepare confidently.
I still remember the first time I heard the word Yocto. It was during a late-night debugging session on an automotive project. Our team had been struggling to bring up a custom Linux distribution on new hardware. Someone casually mentioned, “Why don’t we just use Yocto for this?” At that moment, Yocto felt like a mysterious black box—powerful, but intimidating.
Weeks later, after diving into documentation, recipes, and layers, I realized that Yocto wasn’t just another build system. It was the toolchain that empowered companies across automotive, IoT, industrial, and consumer electronics to build Linux their way. And the more I learned, the more I noticed a pattern—every serious embedded Linux interview I attended started testing my Yocto knowledge.
One interviewer leaned forward and asked me: “If you had to add a new package into your image, what steps would you follow in Yocto?”
Another one challenged me with: “How would you debug a build failure in BitBake, especially when dependencies aren’t obvious?”
At first, these questions felt overwhelming. But over time, I saw the logic: Yocto interviews are not about memorizing commands—they are about proving you can handle the real challenges teams face every day.
That’s why I decided to put together this collection of Yocto interview questions for 2025. It’s not just theory—it’s structured from the ground up, the same way you grow in your career:
Basics for freshers to break the ice
Intermediate for developers who’ve shipped at least one Linux product
Advanced, real-world problem-solving for senior engineers who need to think beyond commands
By the end of this guide, you won’t just know the answers—you’ll understand the why behind them. And that’s exactly what interviewers are looking for.
Yocto Interview Questions
Basic Yocto Interview Questions
1.What is the Yocto Project, and why is it used in embedded systems?
Ans: The Yocto Project is an open-source project that helps developers build custom Linux operating systems for embedded devices. Instead of downloading a ready-made Linux distribution like Ubuntu or Debian, Yocto gives you the tools to create your own Linux system that is lightweight, flexible, and tailored exactly to your hardware and project needs.
In simple words, think of Yocto as a kitchen for Linux:
You don’t get a pre-cooked meal (like Ubuntu).
Instead, you get all the ingredients, recipes, and tools to cook your own dish (a custom Linux).
This means you can decide what to include (drivers, libraries, applications) and what to leave out.
It is widely used in embedded systems (like automotive systems, IoT devices, routers, and medical equipment) because:
Customization – Embedded devices often have limited memory, storage, and processing power. Yocto lets you strip away unnecessary features and keep only what’s needed.
Cross-Compilation – It can build Linux for different processor architectures (ARM, x86, PowerPC, etc.), which is common in embedded systems.
Consistency – It ensures the same build process can be repeated, making development and debugging easier across teams.
Long-Term Support – Embedded devices usually run for years, so having a reliable and maintainable Linux system is critical.
Imagine you are building a smart thermostat for your home. This thermostat needs to:
Read the room temperature from a sensor
Show the temperature on a small display
Connect to Wi-Fi and send data to a mobile app
Now, you don’t need a full Linux desktop with web browsers, office apps, or games—most of that would just waste space and memory.
Here’s where Yocto comes in:
You use Yocto to build a Linux system specifically for your thermostat.
You include only the necessary pieces: drivers for the temperature sensor, display support, Wi-Fi libraries, and your app.
You leave out everything else, making the system lightweight and fast.
Yocto also lets you cross-compile, meaning you can build this Linux system on your PC and then run it on the thermostat’s ARM processor.
Later, if you want to update the thermostat’s software, you can rebuild it the same way, keeping everything consistent.
So, in simple terms, Yocto is like custom-building the engine and body of a car instead of buying a full car you don’t need—you get exactly what your device needs to run perfectly.
2.How Yocto Differs from Buildroot and Other Build Systems
Ans: When it comes to building Linux for embedded systems, there are several tools you can use, like Yocto and Buildroot. Both help you create a custom Linux system for your device, but they work differently and have different strengths.
Purpose and Scope
Yocto is more like a complete toolkit for building a full Linux distribution. It’s not just about compiling the kernel; it helps you create everything — the root filesystem, libraries, applications, and even your own custom packages.
Buildroot is simpler. It’s mostly focused on generating a minimal root filesystem and cross-compiling packages for your target device. It’s faster and easier to get started with but doesn’t offer as much flexibility for complex systems.
Flexibility
Yocto is extremely flexible. You can fine-tune almost every part of your system, like which version of libraries to use, how packages are built, and even create your own custom layers.
Buildroot is more limited in flexibility. It’s great if you need a small, simple system quickly, but for very complex projects, you might feel restricted.
Complexity and Learning Curve
Yocto has a steeper learning curve. It uses concepts like recipes, layers, and BitBake commands, which can seem overwhelming at first. But once you understand it, it’s very powerful for managing large projects.
Buildroot is beginner-friendly and easier to understand. You can get a working Linux system in a shorter time without learning too many advanced concepts.
Reproducibility and Maintenance
Yocto shines in creating reproducible builds. If you rebuild your project on a different machine, you’re likely to get the exact same result. It’s designed for long-term maintenance and large projects.
Buildroot is okay for reproducibility but not as robust as Yocto for maintaining complex or large-scale systems.
Community and Ecosystem
Yocto has a large ecosystem and is widely used in industries like automotive, telecom, and IoT. It supports a wide range of hardware and has extensive documentation.
Buildroot is smaller and simpler, mainly used for smaller embedded projects.
In short:
Use Yocto if you need a fully customized, maintainable Linux system for a complex embedded device. Use Buildroot if you want something quick, small, and easy.
3.What is BitBake, and what role does it play?
Ans: When working with the Yocto Project, you’ll often hear about something called BitBake. Think of BitBake as the “engine” that powers Yocto.
BitBake is the chef who reads all those recipes, makes sure the ingredients are ready, cooks everything in the right order, and finally serves the complete meal (your Linux image).
What is BitBake? BitBake is a build tool (like make in traditional Linux builds). It reads instructions (called recipes) that tell it how to download, configure, compile, and package software for your embedded system.
A recipe in Yocto is just a text file with steps that describe how to build a piece of software (like BusyBox, Python, or even your custom app).
BitBake then follows these recipes to create the final system image for your board.
What role does it play?
Task manager: BitBake breaks big jobs (like building an entire Linux system) into smaller tasks and runs them in the right order.
Automation: Instead of you manually downloading, compiling, and installing everything, BitBake automates the process.
Cross-compilation: Since embedded devices often use processors different from your PC, BitBake takes care of compiling software for the target hardware (not just your host machine).
Reproducibility: BitBake makes sure if you build the system today or months later, you’ll get the same results.
Simple Analogy Imagine you’re cooking a big meal. The recipes are like cooking instructions for each dish.
In short: BitBake is the build engine of the Yocto Project. It reads recipes, manages dependencies, and automates the entire process of building a Linux system for embedded devices.
4.Define a recipe (.bb file) in Yocto.
Ans: In the Yocto Project, a recipe is a text file with a .bb extension that tells BitBake how to build a piece of software for your embedded system.
Think of it as a set of instructions for BitBake — it explains:
Where to get the source code
The recipe tells BitBake where to download the software, whether from a URL, Git repository, or local files.
How to build it
It defines the compilation steps, configuration options, and dependencies needed to build the software.
How to install it
The recipe specifies where to place the compiled files in the target filesystem.
Other metadata
It can include version numbers, license information, or checksums to verify the source.
Example Analogy
If BitBake is the chef, the .bb recipe is like the detailed cooking instruction for a dish:
“Get these ingredients (source code),
Chop and cook them this way (compile),
Put them on the plate here (install into the root filesystem).”
do_install(): How to install into the target filesystem.
In short: A recipe (.bb file) is the core instruction file in Yocto that tells BitBake what to build, how to build it, and where to put it in the final embedded Linux image.
5.What is a layer in Yocto? Provide an example.
Ans: In the Yocto Project, a layer is a collection of recipes, configuration files, and other resources that are grouped together to add specific functionality to your embedded Linux build.
Think of a layer as a building block. You can stack multiple layers to customize your Linux system. Each layer can contain:
Recipes (.bb files) to build software
Configuration files (.conf) for build settings
Patches or modifications for existing software
Why Layers Are Useful
Organization: Keeps recipes and configurations organized by functionality (e.g., one layer for GUI, one for networking).
Reusability: You can reuse layers across different projects. For example, a “Wi-Fi driver layer” can be used in multiple device builds.
Customization: Makes it easier to maintain your own modifications without touching the core Yocto files.
Example of Layers in Yocto
Core layer (poky/meta)
Comes with Yocto by default. Contains essential recipes like the Linux kernel, core libraries, and utilities.
Board Support Package (BSP) layer (meta-beaglebone)
Contains recipes and configurations specific to BeagleBone hardware, like kernel patches and device tree files.
Custom application layer (meta-myapp)
You can create your own layer for building your applications or scripts.
Simple Analogy
Imagine building a house:
The core layer is the foundation and walls.
The BSP layer is the wiring and plumbing customized for your house.
Your custom layer is the furniture, decorations, and personal touches.
✅ In short: A layer in Yocto is a modular collection of recipes and configurations that you can add to your build to customize or extend your embedded Linux system.
6.Difference between local.conf and bblayers.conf in Yocto
Ans: When working with the Yocto Project, you’ll often hear about two important configuration files: local.conf and bblayers.conf. Both are essential, but they serve different purposes. Let’s break it down simply:
local.conf
Think of local.conf as your personal workspace settings.
It defines how you want to build your image. For example:
Which machine you are building for (MACHINE = "beaglebone")
How many cores to use for compilation (PARALLEL_MAKE or BB_NUMBER_THREADS)
What type of image to generate (CORE_IMAGE_MINIMAL vs CORE_IMAGE_FULL_CFP)
You can also override default build options here.
Basically, it’s your local tweaks and preferences for a Yocto build.
bblayers.conf
bblayers.conf is more like a map of all the layers Yocto should use.
Layers are collections of recipes, configurations, and metadata. For example:
meta (core Yocto layer)
meta-openembedded (extra recipes like Python or networking tools)
meta-ti (Texas Instruments support for BeagleBone or other boards)
Without layers listed here, BitBake won’t know where to find recipes to build your image.
It’s essentially a list of sources that make your build possible.
In short:
local.conf → “How I want to build” (my settings, preferences, and tweaks).
bblayers.conf → “Where to get the ingredients” (the layers and recipes used for building).
7.What is Poky in the Yocto Project?
Ans: In the Yocto Project, Poky is like the starter kit or reference system. It’s not a board or a physical product—it’s a collection of essential tools, configurations, and metadata that helps you build custom Linux distributions for embedded devices.
You can think of Poky as a foundation layer that includes:
BitBake – The build engine that processes recipes and builds your images.
Reference layers – Basic recipes and configurations for building a minimal Linux system.
Example settings – Such as machine configurations and image types, so you can get started quickly.
In simple terms:
Poky = Yocto Project’s ready-made starting point
It gives you all the tools you need to create a custom Linux image for your hardware without starting from scratch.
Even if you add extra layers (like meta-openembedded or meta-ti), Poky remains the core reference that makes everything work together smoothly.
8.How do you set the target machine in Yocto?
Ans: In Yocto, the target machine is the hardware or board you want to build your Linux image for, like BeagleBone, Raspberry Pi, or QEMU. Setting the target machine tells Yocto which configuration, kernel, and drivers to use.
There are two main ways to set it:
Using local.conf
Open the conf/local.conf file inside your build directory.
Look for the line that starts with MACHINE ?=.
Set your board name. For example, for BeagleBone: MACHINE ?= "beaglebone"
Save the file and run bitbake <image-name>—Yocto will build the image for that specific machine.
Using environment variable
Before building, you can export the machine name in the terminal: export MACHINE=beaglebone bitbake core-image-minimal
This method is temporary and works only for the current terminal session.
Key point:
The machine name must match a machine configuration in the Yocto layers you are using. Otherwise, BitBake will throw an error.
What are the differences between core-image-minimal and core-image-full-cmdline?
Here’s a beginner-friendly, realistic, and plagiarism-free explanation:
9.Differences between core-image-minimal and core-image-full-cmdline in Yocto
Ans: In Yocto, images are ready-to-use Linux system builds for your target hardware. Two common reference images are core-image-minimal and core-image-full-cmdline. They differ in size, features, and intended use:
Feature
core-image-minimal
core-image-full-cmdline
Purpose
Bare minimum Linux image
Full-featured command-line Linux image
Size
Very small (~10–20 MB)
Larger (~50–100 MB)
Included software
Only essential system files (kernel, init system, shell)
Includes essential system files plus many utilities, libraries, networking tools, and command-line programs
Use case
Ideal for testing, learning, or creating a custom minimal image
Good for development and debugging, when you need more tools and a complete command-line environment
Boot behavior
Boots to a basic shell
Boots to a standard command-line login prompt with more utilities available
Key point:
Use core-image-minimal when you want a tiny, lightweight system.
Use core-image-full-cmdline when you need a more complete Linux environment for development or testing.
10.Where are Yocto build outputs (images, SDK, logs) stored ?
When you build a Yocto project, all the output files such as images, SDKs, and logs are stored inside the build directory of your Yocto project. By default, this directory is created when you set up your build environment using source oe-init-build-env.
Inside the build directory, you’ll find some important subfolders:
tmp/deploy/images/ – This is where all the built images for your target machine are stored. For example, if you build core-image-minimal for BeagleBone, the .wic, .tar.bz2, or .rootfs files will be here.
tmp/work/ – This folder contains all the work directories for each recipe being built. It’s like Yocto’s workspace where it compiles each package.
tmp/sysroots/ – Contains sysroot files used for cross-compilation.
tmp/deploy/sdk/ – If you build an SDK using bitbake -c populate_sdk <image>, the generated SDK installer will appear here.
tmp/log/ – All the build logs are stored here. If a build fails, you can check these logs to debug the issue.
So essentially, build/tmp/deploy is your main folder for final outputs like images and SDKs, while logs and intermediate files are inside other tmp subfolders.
You can also Visit other tutorials of Embedded Prep