
Tag: QNX Debugging

  • Master QNX OS Interview Questions and Answer 2026

    QNX OS interview questions and answers for 2026, explained in simple language. Covers microkernel architecture, IPC, scheduling, resource managers, and real-time concepts for embedded and automotive engineers.

    This collection of QNX OS interview questions and answers is designed for engineers who want to truly understand QNX, not just memorize definitions. The questions are written in a practical way, similar to what is actually asked in real technical interviews, especially for automotive, embedded, and RTOS roles.

    The content starts from basic concepts, such as what QNX is, why it is called a microkernel OS, and how it differs from Linux. As the questions progress, they move into core internal topics like kernel space vs user space, message passing, processes and threads, scheduling, IPC, and resource managers. Advanced sections cover fault tolerance, adaptive partitioning, real-time behavior, priority scheduling, and system reliability, which are commonly discussed in senior-level interviews.

    Each answer is written in simple language, focusing on clarity and understanding, not textbook definitions. Wherever possible, explanations reflect real-world behavior, how QNX works internally, and how engineers actually use it in production systems like automotive ECUs, medical devices, and industrial controllers.

    This material is especially useful for:

    • Embedded Software Engineers
    • Automotive/QNX Developers
    • RTOS and System Programming Interviews
    • Engineers working with QNX Neutrino

    The goal is not to impress with complex wording, but to help you explain QNX confidently and naturally during interviews just like an experienced engineer would.

    QNX is a POSIX-compliant, microkernel-based real-time operating system used in embedded and safety-critical systems. It provides deterministic real-time performance, high reliability, and fault isolation, making it ideal for automotive, medical, industrial, and aerospace applications.

    Key Points to Mention in Interviews

    • RTOS (Real-Time OS) → Guarantees predictable response times
    • Microkernel architecture → Only essential services (scheduler, IPC, interrupts) run in kernel
    • Fault tolerant → A crashing driver doesn’t crash the whole system
    • POSIX compliant → Familiar Linux/UNIX APIs
    • High reliability & safety → Used in ADAS, infotainment, medical devices
    • Message-passing IPC → Core communication mechanism
    • Certified OS → ISO 26262, IEC 61508, etc.

    Where QNX is Used

    • Automotive (Infotainment, ADAS, Digital Cockpits)
    • Medical Devices
    • Industrial Automation
    • Aerospace & Defense
    • Robotics

    QNX is a real-time operating system (RTOS).

    Interview-Ready Answer

    QNX is a hard real-time operating system that provides deterministic and predictable response times, which makes it suitable for safety-critical embedded systems.

    Why QNX is Real-Time

    • Deterministic scheduling → Guaranteed response within deadlines
    • Microkernel architecture → Minimal kernel, faster interrupt handling
    • Priority-based preemptive scheduling
    • Message-passing IPC → Core real-time communication mechanism
    • Low interrupt latency & jitter

    Hard vs Soft Real-Time

    • QNX = Hard real-time OS
      Missing a deadline is considered a system failure (important for automotive, medical systems).

    Interview One-Liner (Strong)

    QNX is a POSIX-compliant, microkernel-based hard real-time operating system designed for deterministic and safety-critical applications.

    In QNX, a microkernel means that only the most essential operating system services run in the kernel, such as the scheduler, interrupt handling, and inter-process communication (IPC). All other services like device drivers, file systems, networking, and protocol stacks run as user-space processes.

    Key Points to Mention

    1. Minimal Kernel → Only critical functions run in kernel space.
    2. User-space Services → Most OS services run as separate processes, improving stability and fault isolation.
    3. Fault Isolation → If a driver or service crashes, it won’t crash the whole system.
    4. Message-Passing IPC → Kernel facilitates communication between processes efficiently.
    5. Real-Time Friendly → Microkernel keeps latency low, making it suitable for hard real-time applications.

    Example Explanation

    • Suppose the audio driver crashes in QNX → Only that driver stops; the OS and other applications continue running.
    • Contrast this with monolithic kernels (like Linux), where a driver crash can crash the whole system.

    One-Liner for Interviews

    QNX’s microkernel architecture runs only essential services in the kernel, while other services run in user space, providing fault tolerance and real-time performance.

    QNX is a microkernel-based real-time operating system designed for deterministic, safety-critical embedded systems, while Linux is a monolithic, general-purpose OS that is not inherently real-time (unless using PREEMPT_RT patches).

    Key Differences to Mention

    FeatureQNXLinux
    Kernel TypeMicrokernelMonolithic
    Real-Time SupportHard real-time (deterministic)General-purpose; soft real-time with PREEMPT_RT
    Fault IsolationHigh – services run in user space; crashes don’t crash OSLow – kernel modules can crash entire system
    Inter-Process Communication (IPC)Message-passing via microkernelShared memory, signals, pipes (less deterministic)
    Typical Use CaseAutomotive, medical, industrial, aerospaceDesktop, servers, embedded systems (non-critical)
    Memory FootprintSmall, lightweightLarger, heavier
    Boot TimeFast, optimized for embedded systemsSlower, general-purpose boot
    CertificationISO 26262, IEC 61508, DO-178Not generally certified for safety-critical applications

    Example for Interview

    • Automotive Infotainment: QNX → Digital dashboard (hard real-time, fault-tolerant).
    • Desktop Application: Linux → Ubuntu OS on a laptop.

    One-Liner for Interviews

    QNX is a real-time, microkernel OS optimized for safety-critical embedded systems, whereas Linux is a general-purpose monolithic OS with limited real-time support.

    QNX is widely used in embedded and safety-critical systems where reliability, fault tolerance, and real-time performance are essential.

    Key Areas / Industries

    1. Automotive
      • Infotainment systems (digital dashboards, touchscreens)
      • Advanced Driver Assistance Systems (ADAS)
      • Digital cockpits and instrument clusters
    2. Medical Devices
      • Life-support equipment, patient monitors
      • Imaging systems
    3. Industrial Automation
      • Robotics, PLCs, factory automation controllers
      • Process control systems
    4. Aerospace & Defense
      • Avionics and flight control systems
      • Mission-critical embedded electronics
    5. Telecommunications
      • Network switches, base stations
    6. IoT and Embedded Devices
      • Smart appliances, robotics, edge devices

    Example for Interview

    “For example, in automotive, QNX is used in digital dashboards where a crash in the media player or Bluetooth module won’t take down the whole system, thanks to its microkernel architecture.”

    One-Liner

    QNX is commonly used in automotive, medical, industrial, aerospace, and telecommunications systems where reliability and real-time performance are critical.

    QNX is a microkernel-based real-time operating system with features designed for embedded and safety-critical systems, providing high reliability, determinism, and fault tolerance.

    Key Features

    1. Microkernel Architecture
      • Only essential services run in the kernel (scheduler, IPC, interrupts)
      • Other services (drivers, file systems, networking) run in user space
      • Ensures fault isolation and system stability
    2. Real-Time Performance
      • Hard real-time deterministic scheduling
      • Low interrupt latency and predictable response times
      • Priority-based preemptive multitasking
    3. POSIX Compliance
      • Supports standard UNIX/Linux APIs
      • Eases application porting from other systems
    4. Inter-Process Communication (IPC)
      • Efficient message-passing mechanism
      • Supports synchronous and asynchronous communication between processes
    5. Fault Tolerance & High Reliability
      • Crashing of a driver or service does not crash the OS
      • Critical for safety-certified applications
    6. Scalability
      • Runs on small microcontrollers to complex multi-core systems
      • Suitable for both resource-constrained devices and high-end embedded platforms
    7. File System Support
      • Journaling and networked file systems for reliability
      • Can integrate custom embedded file systems
    8. Networking & Communication
      • Supports TCP/IP, CAN, USB, and other industrial protocols
      • Suitable for connected embedded systems
    9. Security & Safety Certification
      • ISO 26262 (Automotive), IEC 61508 (Industrial), DO-178B/C (Aerospace)
      • Enables use in safety-critical applications
    10. Modularity
      • Easy to add/remove components without affecting the kernel
      • Lightweight and customizable for specific embedded use cases

    Example for Interview

    “For instance, in an automotive digital dashboard, QNX ensures that even if the media or Bluetooth service crashes, the display of speed, fuel, and engine status continues to work reliably, thanks to its microkernel architecture and fault isolation.”

    One-Liner for Interviews

    QNX features a microkernel architecture, hard real-time performance, fault tolerance, POSIX compliance, scalable modular design, and is certified for safety-critical systems.

    POSIX compliance in QNX means that the operating system supports standard UNIX/Linux APIs and interfaces, allowing developers to write portable applications that can run on QNX with minimal changes.

    Key Points to Mention

    1. Standardized API
      • QNX provides POSIX-compliant system calls for file I/O, process management, threading, signals, and IPC.
      • Makes it familiar to developers coming from Linux or UNIX environments.
    2. Portability
      • Applications written using POSIX APIs can be easily ported between QNX and other POSIX-compliant systems.
    3. Real-Time Extensions
      • QNX extends POSIX with real-time features, such as real-time scheduling (SCHED_FIFO, SCHED_RR) and priority inheritance mutexes.
    4. Example APIs in QNX
      • File operations: open(), read(), write(), close()
      • Threads: pthread_create(), pthread_join()
      • IPC: mq_open(), mq_send(), mq_receive() (message queues)
    5. Why It Matters
      • Reduces development time and learning curve
      • Enables cross-platform development for embedded systems
      • Ensures consistency and standard compliance in embedded applications

    Example for Interview

    “If you have an application written for Linux using standard POSIX threads and message queues, you can port it to QNX almost directly because QNX supports the same POSIX APIs, while also providing real-time guarantees.”

    One-Liner for Interviews

    POSIX compliance in QNX ensures standard UNIX/Linux API support, enabling application portability and consistent development while adding real-time capabilities.

    QNX is a proprietary operating system developed by BlackBerry. It is not open source, and its source code is licensed under commercial terms.

    Key Points to Mention

    1. Proprietary License
      • QNX requires a commercial license for development and deployment.
      • Source code is not freely available to the public.
    2. Commercial Support
      • BlackBerry provides official support, updates, and safety certifications.
      • Essential for automotive, medical, and industrial applications.
    3. Contrast with Open Source OS
      • Linux, FreeRTOS → Open source, source code freely available.
      • QNX → Closed-source, with guaranteed reliability and certification.
    4. Why Proprietary Matters
      • Ensures controlled development, rigorous testing, and compliance with safety standards like ISO 26262 or IEC 61508.

    One-Liner for Interviews

    QNX is a proprietary, commercially licensed real-time operating system with source code controlled by BlackBerry.

    Neutrino is the microkernel-based real-time operating system (RTOS) at the core of QNX. It provides the fundamental services like scheduling, inter-process communication (IPC), and interrupt handling, enabling QNX to deliver deterministic, reliable, and fault-tolerant performance in embedded systems.

    Key Points to Mention

    1. Core of QNX
      • Neutrino is the actual OS kernel.
      • All QNX services (file system, networking, drivers) run on top of Neutrino.
    2. Microkernel Architecture
      • Only essential functions (scheduler, IPC, interrupt handling) are in the Neutrino kernel.
      • Other services run in user space → better fault isolation.
    3. Real-Time Capabilities
      • Supports hard real-time scheduling.
      • Ensures predictable response times for critical applications.
    4. POSIX Compliance
      • Neutrino implements POSIX APIs, allowing applications to be portable from UNIX/Linux.
    5. Fault-Tolerant
      • If a driver or service crashes, Neutrino keeps the system running.

    Example for Interview

    “In an automotive dashboard, Neutrino ensures that the speedometer and fuel gauge continue updating even if a non-critical service like media playback crashes, thanks to its microkernel design.”

    One-Liner for Interviews

    Neutrino is the microkernel RTOS at the heart of QNX, providing deterministic real-time performance, POSIX compliance, and fault tolerance for embedded systems.

    Deterministic behavior in an RTOS means that the system responds to events or interrupts within a guaranteed, predictable amount of time, regardless of system load. This is essential for real-time applications where timing is critical.

    Key Points to Mention

    1. Predictable Response
      • A deterministic RTOS ensures that tasks meet their deadlines consistently.
      • Example: If a sensor triggers an interrupt, the OS handles it within a fixed maximum latency.
    2. Critical for Real-Time Systems
      • Timing guarantees are required in automotive, medical, aerospace, and industrial systems.
      • Missing deadlines can lead to system failures or safety hazards.
    3. Determinism vs Speed
      • Determinism focuses on predictability, not just fast execution.
      • Even if execution is slightly slower, as long as timing is predictable, it’s considered deterministic.
    4. Example
      • In a car’s ABS system, the RTOS must read wheel speed sensors and control brakes within exact deadlines. QNX ensures this deterministic behavior.

    One-Liner for Interviews

    Deterministic behavior in an RTOS means predictable, guaranteed response times to events or interrupts, ensuring real-time deadlines are always met.

    The latest major version of QNX is QNX Software Development Platform (SDP) 8.0. It includes:

    • QNX OS 8.0 – The core microkernel-based real-time operating system.
    • QNX OS for Safety 8.0 – Safety-certified edition for critical systems (ISO 26262, IEC 61508).
    • QNX Hypervisor 8.0 – Embedded virtualization platform.
    • QNX Momentics IDE 8.0.x – Development environment supporting SDP 8.0.

    Key Points:

    • Designed for embedded and safety-critical systems.
    • Provides deterministic real-time performance.
    • Supports fault isolation and microkernel architecture.

    One-Liner for Interviews:

    “QNX SDP 8.0 is the latest version, with QNX OS 8.0 at its core, optimized for embedded and safety-critical applications.”

    QNX Architecture

    QNX Architecture Overview

    QNX is a microkernel-based real-time operating system (RTOS). Its architecture is designed for high reliability, modularity, and real-time performance.

    The main layers are:

    1. Microkernel

    • Core of QNX.
    • Very small and minimal: only contains the most essential OS functions.
    • Responsibilities:
      • Task scheduling (prioritized, real-time scheduling)
      • Interprocess communication (IPC)
      • Interrupt handling
      • Timers
      • Low-level memory management
    • All other OS services run as user-space processes, not inside the kernel.

    Key point: This design improves stability because a crash in a service doesn’t crash the entire system.

    2. Process Managers (User-space Services)

    These are system services that run outside the kernel, providing higher-level OS functionalities:

    ServiceFunction
    File SystemManages files, directories, and storage devices.
    Network StackHandles TCP/IP, UDP, and network protocols.
    Device DriversHardware control (keyboard, serial, audio, display) as user-space tasks.
    Resource ManagersUnified interface for devices & files, exposing them as files (/dev).
    Timers / ClocksUser-space timers and scheduling assistance.
    • These services communicate with each other and with the microkernel via IPC.
    • Because they are separate from the kernel, if one fails, the system can continue running.

    3. Application Layer

    • Your user applications run here.
    • They request services via standard APIs or POSIX calls, which get translated into IPC messages to the microkernel or system services.
    • Applications are fully isolated, which enhances reliability.

    4. Communication Model

    • QNX uses message-passing IPC instead of traditional system calls.
    • Every process can send and receive messages synchronously or asynchronously.
    • This ensures determinism, essential for real-time systems.

    5. Memory Architecture

    • Microkernel handles basic memory protection.
    • Applications and services are isolated in their own address space, preventing accidental overwrites.
    • Memory faults in one service usually do not affect the kernel or other services.

    6. Highlights of QNX Architecture

    • Modular & Scalable: Add/remove services without touching the kernel.
    • Fault-Tolerant: Crashes in user-space services don’t crash the kernel.
    • Deterministic: Real-time scheduling ensures predictable behavior.
    • POSIX-Compliant: Supports standard APIs for portability.

    Architecture Diagram (Text Representation)

    +----------------------------------+
    |         User Applications        |
    +----------------------------------+
    |        POSIX APIs / Libraries    |
    +----------------------------------+
    |       User-Space Services        |
    |  (File System, Network, Drivers)|
    +----------------------------------+
    |           Microkernel            |
    |  (Scheduler, IPC, Interrupts)   |
    +----------------------------------+
    |           Hardware Layer         |
    +----------------------------------+
    

    Interview-Friendly Answer:

    “QNX has a microkernel-based architecture, where the kernel is minimal and handles only essential functions like task scheduling, interprocess communication (IPC), interrupt handling, and memory management. All other services, such as file systems, network stacks, and device drivers, run as user-space processes, communicating with the kernel and each other via IPC. Applications run on top of these services using POSIX APIs. This modular design ensures high reliability, fault tolerance, and deterministic real-time performance, making QNX ideal for embedded and safety-critical systems.”
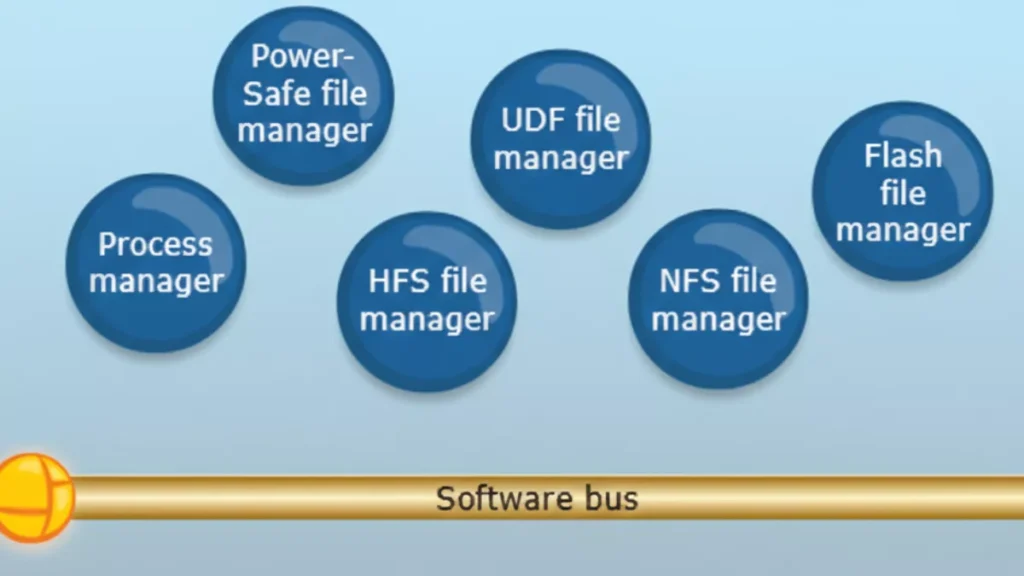
    Explanation of the Diagram

    1. Software Bus (Middle Layer)
      • Acts as a communication backbone for all user-space managers and applications.
      • All managers (file, network, GUI, character, etc.) and applications communicate with each other through this message-passing mechanism.
      • Essentially, this is how QNX implements microkernel principles: minimal kernel + IPC.
    1. Upper Layer: File and Process Managers
      These are system-level services running in user space:
      • Process Manager: Handles process creation, deletion, and scheduling requests.
      • File Managers: Manage different types of file systems:
        • Power-Safe file manager
        • UDF file manager
        • HFS file manager
        • NFS file manager
        • Flash file manager
      • These managers communicate via the software bus, instead of being inside the kernel.
    1. Lower Layer: Applications and Resource Managers
      • GUI Manager: Handles graphical interface.
      • Character Manager: Handles character devices (e.g., keyboard, serial port).
      • Network Manager: Handles network services.
      • Mqueue Manager: Manages message queues (IPC feature).
      • CIFS File Manager: For network file sharing (SMB/CIFS).
      • Applications: End-user or embedded applications running on top of these managers.

    Key Takeaways

    • This diagram shows QNX’s modular microkernel architecture in action:
      • Microkernel: Handles only essential kernel tasks (not shown explicitly in this diagram; it’s below the software bus, managing IPC, scheduling, and interrupts).
      • Software bus: Allows all user-space managers and applications to communicate.
      • Managers: Implement higher-level OS services in user space.
      • Applications: Sit at the top and use these services via message passing.
    • If one manager crashes, it doesn’t crash the kernel or other managers, highlighting QNX’s fault-tolerant design.

    Interview Tip:
    You can say:

    “This diagram shows QNX Neutrino’s user-space architecture. System managers like file managers, network manager, GUI manager, and process manager run as independent processes in user space. Applications communicate with these managers via the software bus, which implements the microkernel’s message-passing IPC. This design makes QNX highly modular, fault-tolerant, and suitable for real-time embedded systems.”

    QNX uses a microkernel architecture, meaning the operating system kernel is kept very small and only contains the most critical functions.
    All other OS services run as separate user-space processes, not inside the kernel.

    What Runs Inside the QNX Microkernel?

    The QNX Neutrino microkernel includes only four core responsibilities:

    1. Thread scheduling
      • Priority-based, fully preemptive
      • Ensures deterministic real-time behavior
    2. Inter-Process Communication (IPC)
      • Message passing (MsgSend, MsgReceive, MsgReply)
      • This is the heart of QNX
    3. Interrupt handling
      • Fast and predictable interrupt response
    4. Low-level thread and process management

    Nothing else runs in kernel space

    What Runs Outside the Kernel (User Space)?

    All higher-level OS services are implemented as user-space servers:

    • File systems (e.g., /fs-qnx6.so)
    • Device drivers (UART, I2C, SPI, Audio, Network)
    • Networking stack (TCP/IP)
    • Process manager (procnto)
    • Memory manager
    • Resource managers

    These components communicate using message passing.

    QNX Architecture Overview (Logical Flow)

    +-----------------------+
    |   Applications          |
    +-----------------------+
              |
              |  Message Passing (IPC)
              |
    +-----------------------+
    | OS Services / Servers |
    | (Drivers, FS, Net)         |
    +-----------------------+
              |
              | IPC
              |
    +-----------------------+
    |   Microkernel         |
    | (Scheduler, IPC, IRQ)|
    +-----------------------+
              |
    +-----------------------+
    |      Hardware         |
    +-----------------------+
    

    Message Passing – The Core Concept

    Unlike Linux (which uses system calls heavily), QNX uses:

    • Synchronous message passing
    • Client sends request → server processes → replies

    Example:

    • App wants to write to a UART
    • App sends message to UART driver
    • UART driver responds after operation
    • No shared memory required
    • Strong isolation
    • Predictable timing

    Why Microkernel? (Advantages)

    1. High Reliability

    • If a driver crashes, only that process restarts
    • Kernel remains unaffected

    2. Fault Tolerance

    • Ideal for safety-critical systems (ASIL-D)

    3. Deterministic Real-Time Behavior

    • Guaranteed response times
    • Used in automotive and medical systems

    4. Security

    • Smaller kernel → smaller attack surface

    QNX vs Linux (Interview Comparison)

    FeatureQNXLinux
    Kernel typeMicrokernelMonolithic
    DriversUser spaceKernel space
    IPCMessage passingSyscalls + shared memory
    Real-timeNativeNeeds RT patches
    Fault isolationStrongWeak
    Safety certificationYes (ASIL-D)Limited

    Real-World Example (Automotive)

    In a car infotainment system:

    • Audio driver crashes
    • Only audio service restarts
    • Navigation and UI keep running

    This is why QNX is used in automotive ECUs

    One-Line Interview Answer

    QNX uses a microkernel architecture where only scheduling, IPC, interrupts, and thread management run in the kernel, while all other services like drivers and file systems run in user space as separate processes, ensuring high reliability, fault isolation, and deterministic real-time behavior.

    In QNX (Neutrino), the kernel space contains only the most critical real-time components. Everything else runs in user space.

    The following run in kernel space:

    1. Thread Scheduling

    • Priority-based, fully preemptive scheduler
    • Ensures deterministic real-time behavior
    • Handles context switching

    2. Inter-Process Communication (IPC)

    • Core message passing mechanism
    • MsgSend(), MsgReceive(), MsgReply()
    • Fast, synchronous IPC

    IPC is the heart of QNX

    3. Interrupt Handling

    • Low-latency interrupt dispatching
    • Interrupt Service Routines (ISRs)
    • Interrupt events delivery to threads

    4. Low-Level Thread & Process Management

    • Thread creation and destruction
    • Basic process control
    • Kernel-level synchronization primitives

    What Does NOT Run in Kernel Space?

    These run in user space, not kernel space:

    • Device drivers (UART, I2C, SPI, Audio, Network)
    • File systems
    • Memory manager
    • Network stack (TCP/IP)
    • Process manager (procnto)
    • Resource managers

    One-Line Interview Answer

    In QNX, kernel space contains only the microkernel responsible for scheduling, message-passing IPC, interrupt handling, and low-level thread management; all other OS services and drivers run in user space.

    Memory Tip for Interviews

    Think S-I-I-T:

    • Scheduling
    • IPC
    • Interrupts
    • Threads

    In QNX Neutrino, almost everything except the microkernel runs in user space as separate processes (servers).

    Major Components Running in User Space

    1. Process Manager (procnto)

    • Handles:
      • Process creation (fork, spawn)
      • Signal delivery
      • POSIX compliance
    • Acts as the root server of the system

    2. Memory Manager

    • Virtual memory management
    • Address space creation
    • Memory protection
    • Page faults handling (with kernel support)

    3. Device Drivers

    • UART, I2C, SPI, CAN
    • Audio, Display, Camera
    • GPIO, ADC, PWM
    • Network drivers
    • Run as normal user processes
    • Can be restarted if they crash

    4. File Systems

    • QNX6 filesystem
    • Flash file systems
    • Network file systems
    • Mounted under /

    5. Network Stack

    • TCP/IP stack
    • Ethernet, Wi-Fi drivers
    • Socket services

    6. Resource Managers

    • Implement POSIX-style resources
    • Expose services as files (e.g. /dev/ser1)
    • Handle open/read/write/ioctl

    7. System Services & Daemons

    • Audio services
    • Power management
    • Clock services
    • Logging services

    8. User Applications

    • HMI / UI apps
    • Control logic
    • Diagnostic tools
    • Middleware

    QNX User Space Layout (Conceptual)

    +----------------------+
    |   User Applications  |
    +----------------------+
    | System Services      |
    | File Systems         |
    | Network Stack        |
    | Device Drivers       |
    | Resource Managers    |
    | procnto              |
    +----------------------+
            |
            | IPC (message passing)
            |
    +----------------------+
    |   Microkernel        |
    +----------------------+
    

    Why This Design Matters

    Fault Isolation

    • Driver crash ≠ system crash

    Easy Recovery

    • Restart a single service

    Safety Certification

    • Ideal for ASIL-D systems

    Secure Architecture

    • Minimal kernel attack surface

    One-Line Interview Answer

    In QNX, user space contains the process manager, memory manager, device drivers, file systems, network stack, resource managers, system services, and all applications—each running as separate processes that communicate via message passing.

    QNX uses message passing as its core communication mechanism to achieve deterministic real-time behavior, fault isolation, reliability, and scalability in a microkernel architecture.

    1. Fits the Microkernel Design

    QNX keeps the kernel very small.
    Since drivers, file systems, and services run in user space, they must communicate safely.

    ➡ Message passing replaces shared kernel data structures

    • No direct function calls across protection boundaries
    • Clean client–server model

    2. Deterministic Real-Time Behavior (Key Reason)

    Message passing in QNX is:

    • Synchronous
    • Priority-aware

    What this means:

    • Client blocks until server replies
    • Server temporarily inherits the client’s priority (priority inheritance)

    ✔ Prevents priority inversion
    ✔ Guarantees bounded latency
    ✔ Ideal for hard real-time systems

    3. Strong Fault Isolation & Reliability

    • Each driver/service runs as a separate process
    • If a driver crashes:
      • Kernel stays alive
      • Other services keep running
      • Only the failed service is restarted

    ➡ Message passing enforces strict process isolation

    4. Security by Design

    • No shared memory by default
    • No arbitrary kernel access
    • Services only expose controlled interfaces

    ➡ Smaller attack surface than monolithic kernels

    5. Unified Communication Model

    QNX uses one mechanism everywhere:

    OperationImplemented via
    File I/O (read/write)Messages
    Device accessMessages
    Network stackMessages
    Signals & eventsMessages

    ➡ Simpler OS design
    ➡ Easier to reason about timing

    6. Zero-Copy Efficiency

    Despite being message-based:

    • QNX supports zero-copy transfers
    • Uses shared memory only when explicitly needed

    ➡ High performance with real-time guarantees

    7. Easier Debugging & Maintenance

    • Services can be:
      • Stopped
      • Replaced
      • Restarted
    • No kernel rebuild required

    ➡ Faster development and safer updates

    Real Example (Automotive)

    • Audio application → sends message to audio driver
    • Audio driver crashes
    • Audio service restarts
    • Navigation & safety systems continue running

    ➡ System does not reboot

    One-Line Interview Answer

    QNX uses message passing to enable safe and deterministic communication between user-space services in its microkernel architecture, providing real-time predictability, fault isolation, priority inheritance, and high system reliability.

    Memory Trick for Interviews

    Think D-R-F-S-U:

    • Determinism
    • Reliability
    • Fault isolation
    • Security
    • Unified IPC

    Resource managers in QNX are user-space server processes that implement POSIX-style resources (files, devices, pseudo-devices) and expose them through the filesystem namespace using message passing.

    In simple words:

    A resource manager lets a user-space service behave like a file or device (e.g. /dev/ser1).

    Why Resource Managers Exist

    QNX follows the principle:

    “Everything is a file”

    Instead of placing drivers in kernel space (like Linux), QNX uses resource managers in user space to handle:

    • open()
    • read()
    • write()
    • ioctl()
    • close()

    All these calls are translated into messages.

    Where Do Resource Managers Run?

    • User space
    • As normal processes
    • Communicate with clients via QNX IPC (message passing)
    • Crash-safe
    • Restartable
    • Isolated

    Common Examples of Resource Managers

    ResourceExample
    Serial driver/dev/ser1
    GPIO/dev/gpioX
    Audio/dev/snd/*
    Custom device/dev/mydevice
    Pseudo file/proc, /dev/random

    How a Resource Manager Works (Flow)

    1. Application calls:fd = open("/dev/ser1", O_RDWR);
    2. Kernel converts this into a message
    3. Message is sent to the resource manager
    4. Resource manager processes the request
    5. Sends a reply back to the application

    Key Components of a Resource Manager

    1. Dispatch Layer

    • Receives messages
    • Routes them to appropriate handlers

    2. Connect Functions

    • Handle:
      • open()
      • close()

    3. I/O Functions

    • Handle:
      • read()
      • write()
      • ioctl()

    Types of Resource Managers

    Device Resource Managers

    • Hardware drivers (UART, I2C, CAN)

    Filesystem Resource Managers

    • QNX6, Flash FS

    Pseudo Resource Managers

    • Virtual or logical devices

    Benefits of Resource Managers

    Fault Isolation

    • Driver crash ≠ system crash

    POSIX Compliance

    • Standard file APIs

    Real-Time Friendly

    • Priority inheritance during IPC

    Easy Debugging

    • Run, stop, restart like any process

    QNX vs Linux (Quick Comparison)

    FeatureQNXLinux
    Driver locationUser spaceKernel space
    InterfaceFile-basedSyscalls
    Crash impactLocalOften system-wide
    IPCMessage passingFunction calls

    One-Line Interview Answer

    Resource managers in QNX are user-space processes that expose devices and services as POSIX-compliant files, handling open/read/write/ioctl requests via message passing, enabling fault isolation and real-time reliability.

    The microkernel’s role in QNX is to provide the core real-time foundation by handling thread scheduling, message-passing IPC, interrupt handling, and basic process/thread management, while all other OS services run in user space.

    QNX achieves fault tolerance by running drivers and OS services in user space, using message passing for isolation, and allowing failed components to be restarted without affecting the microkernel or the rest of the system.

    How QNX Achieves Fault Tolerance (Key Points)

    1. Microkernel Architecture
      • Kernel contains only scheduling, IPC, and interrupts
      • Minimal kernel → fewer failure points
    2. User-Space Drivers & Services
      • Device drivers, file systems, network stack run as separate processes
      • A crash affects only that component, not the whole OS
    3. Message Passing (Strong Isolation)
      • No shared kernel data by default
      • Faults are contained within a single process
    4. Service Restart & Recovery
      • Failed services/drivers can be restarted dynamically
      • System continues running
    5. Priority Inheritance in IPC
      • Prevents priority inversion during communication
      • Maintains real-time stability even under faults
    6. Health Monitoring (Optional)
      • Watchdogs and supervisors can detect failures and relaunch services

    Adaptive Partitioning in QNX is a CPU resource management mechanism that guarantees each group of threads a minimum percentage of CPU time, while dynamically redistributing unused CPU to other partitions.

    Key Points (Simple)

    • CPU time is divided into partitions
    • Each partition has a guaranteed minimum CPU budget
    • Unused CPU is adaptively shared with others
    • Ensures real-time tasks are never starved

    Why QNX Uses Adaptive Partitioning

    • Prevents CPU starvation
    • Improves system predictability
    • Supports mixed-criticality systems (safety + infotainment)

    Example

    PartitionCPU Guarantee
    Safety tasks40%
    Audio30%
    UI20%
    Background10%
    • If UI uses only 10%, the extra 10% is temporarily used by others
    • When UI needs CPU again, it gets its guaranteed share back

    Where It’s Used

    • Automotive ECUs
    • Medical devices
    • Industrial control systems

    One-Line Interview Answer

    Adaptive partitioning ensures guaranteed CPU bandwidth for critical tasks while efficiently sharing unused CPU among other processes.

    A thread in QNX is the smallest schedulable unit of execution that runs within a process and is scheduled by the microkernel based on priority.

    Key points:

    • Executes code
    • Has its own:
      • Program counter
      • Stack
      • Priority
    • Shares process resources (memory, file descriptors)
    • Scheduled directly by the QNX microkernel

    A process in QNX is a protected container that provides an address space and resources for one or more threads.

    Key points:

    • Owns:
      • Virtual address space
      • File descriptors
      • Signals
      • Permissions
    • Contains one or more threads
    • Provides isolation from other processes

    Relationship (Easy to Remember)

    • Process = container
    • Thread = worker
    Process
     ├── Thread 1 (main thread)
     ├── Thread 2
     └── Thread 3
    

    QNX-Specific Interview Highlight

    • Threads are the real-time scheduling entities, not processes
    • Priority, IPC, and interrupts are all thread-centric

    One-Line Comparison (Interview Gold)

    In QNX, a process provides isolation and resources, while threads are the actual execution units scheduled by the microkernel.

    Thread States in QNX

    In QNX Neutrino, a thread can exist in the following main states:

    1. READY

    • Thread is ready to run
    • Waiting for CPU
    • Placed in a priority-based ready queue

    2. RUNNING

    • Thread is currently executing on the CPU

    3. BLOCKED

    • Thread is waiting for an event or resource

    Common reasons:

    • Waiting for a message (MsgReceive)
    • Waiting for a reply (MsgSend)
    • Waiting for I/O
    • Waiting for a mutex or semaphore
    • Sleeping (nanosleep)

    4. STOPPED

    • Thread execution is suspended

    Causes:

    • Debugger attached
    • Job control signals (e.g. SIGSTOP)
    • Explicit suspension

    5. WAITING (ZOMBIE – process level)

    • Thread has exited
    • Waiting for parent process to collect status

    Note: Zombie is mainly a process concept, but threads can be in a terminated state internally.

    Simple State Diagram (Interview Friendly)

    READY → RUNNING → BLOCKED
      ↑        ↓         |
      └────────┴─────────┘
            STOPPED
    

    Important QNX Interview Points

    • Threads (not processes) are scheduled
    • Scheduling is priority-based and preemptive
    • IPC operations heavily influence BLOCKED states
    • Message passing directly affects thread transitions

    One-Line Interview Answer

    In QNX, threads transition between READY, RUNNING, BLOCKED, and STOPPED states, with scheduling handled at the thread level using priority-based preemption.

    Memory Trick

    Think R-R-B-S:

    • Ready
    • Running
    • Blocked
    • Stopped

    Thread Scheduling Algorithm in QNX

    QNX uses a priority-based, fully preemptive, deterministic thread scheduling algorithm, designed for hard real-time systems.

    Core Characteristics

    1. Priority-Based Scheduling

    • Each thread has a fixed priority
    • Priority range: 0 (lowest) to 255 (highest)
    • Highest-priority READY thread always runs

    2. Fully Preemptive

    • If a higher-priority thread becomes READY:
      • It immediately preempts the currently running thread
    • Ensures fast response for real-time tasks

    3. Round-Robin Within Same Priority

    • Threads with the same priority share CPU time
    • Each gets a time slice
    • Prevents starvation among equal-priority threads

    4. Thread-Centric Scheduling

    • QNX schedules threads, not processes
    • Each thread is an independent scheduling entity

    5. Deterministic Behavior

    • Scheduling decisions are predictable
    • No dynamic priority changes by default
    • Ideal for safety-critical systems

    Scheduling Flow (Simple)

    1. Scheduler checks READY queues (highest → lowest priority)
    2. Picks the highest-priority READY thread
    3. Thread runs until:
      • It blocks
      • Its time slice expires (same-priority case)
      • A higher-priority thread becomes READY

    Priority Inheritance (Very Important)

    • Used during message passing and mutex locking
    • If a high-priority thread is blocked by a lower-priority one:
      • Lower-priority thread temporarily inherits the higher priority
    • Prevents priority inversion

    Comparison with Linux (Interview Highlight)

    FeatureQNXLinux
    SchedulingFixed priorityCFS (dynamic)
    PreemptionAlwaysConfig-dependent
    DeterminismGuaranteedBest-effort
    Priority inheritanceBuilt-inPartial

    One-Line Interview Answer

    QNX uses a priority-based, fully preemptive scheduling algorithm where the highest-priority ready thread always runs, with round-robin scheduling among threads of equal priority and priority inheritance to prevent inversion.

    Conclusion

    QNX is not just another operating system—it is built for environments where reliability, predictability, and safety truly matter. Understanding QNX means understanding how real-time systems behave under pressure, how failures are isolated, and how software can continue running even when individual components crash.

    These interview questions and answers are meant to help you think like a QNX engineer, not just repeat definitions. By focusing on microkernel design, message passing, scheduling, fault tolerance, and system design choices, this content prepares you to explain why QNX works the way it does, not just what it is.

    If you can clearly explain these concepts in your own words during an interview, it shows strong fundamentals, real project exposure, and confidence in system-level thinking—qualities that interviewers look for in embedded and automotive roles.

    Master the concepts, relate them to real use cases, and you won’t just clear a QNX interview—you’ll stand out as someone who truly understands the system.

    FAQ : QNX OS Interview Questions

    1. What is QNX OS?

    QNX is a real-time operating system (RTOS) designed for systems that require high reliability, deterministic performance, and fault tolerance. It is widely used in automotive, medical, industrial, and safety-critical embedded systems.

    2. Why is QNX called a microkernel operating system?

    QNX uses a microkernel architecture, meaning only the most essential services (scheduling, IPC, interrupt handling) run in kernel space. All other services run in user space, improving system stability and fault isolation.

    3. How is QNX different from Linux?

    Linux uses a monolithic kernel, while QNX uses a microkernel. In QNX, drivers and services run in user space and can be restarted if they fail, whereas in Linux, a faulty driver can crash the entire system.

    4. What runs in kernel space in QNX?

    Only critical components run in kernel space:

    • Thread scheduling
    • Inter-process communication (IPC)
    • Interrupt handling
    • Low-level synchronization

    This keeps the kernel small and reliable.

    5. What runs in user space in QNX?

    Most system services run in user space, including:

    • Device drivers
    • File systems
    • Network stacks
    • Resource managers
    • System services

    This design improves fault tolerance.

    6. Why does QNX use message passing?

    QNX uses message passing for IPC to ensure:

    • Deterministic communication
    • Strong process isolation
    • Safer interaction between services
    • Easier debugging and recovery

    It is a core reason for QNX’s reliability.

    7. What is a resource manager in QNX?

    A resource manager is a user-space server that manages system resources like files, devices, or custom interfaces. Applications interact with resource managers using standard POSIX calls such as open(), read(), and write().

    8. What is the role of the microkernel in QNX?

    The microkernel acts as a traffic controller, handling communication, scheduling, and interrupts while letting user-space services do the rest. This separation makes the system robust and scalable.

    9. How does QNX achieve fault tolerance?

    QNX achieves fault tolerance through:

    • Process isolation
    • User-space drivers
    • Automatic service restart
    • Priority-based scheduling

    A failure in one component does not crash the entire system.

    10. What is adaptive partitioning in QNX?

    Adaptive partitioning ensures CPU time is reserved for critical processes. Even if one process misbehaves, real-time and safety-critical tasks continue to run without disruption.

    11. What is a process in QNX?

    A process is an independent program with its own memory space. It may contain one or more threads and communicates with other processes using message passing.

    12. What is a thread in QNX?

    A thread is the smallest unit of execution in QNX. Threads share the same address space within a process but are scheduled independently.

    13. What are the thread states in QNX?

    Common thread states include:

    • Running
    • Ready
    • Blocked (waiting for IPC or resources)
    • Stopped

    These states help manage real-time execution efficiently.

    14. What scheduling algorithm does QNX use?

    QNX uses priority-based preemptive scheduling. Higher-priority threads always run first, ensuring deterministic real-time behavior.
    Read More about Process : What is is Process
    Read More about System Call in Linux : What is System call
    Read More about IPC : What is IPC
  • QNX OS Interview Questions 2026 : Complete Guide from Beginner to Advanced

    Complete QNX OS interview guide with beginner to advanced questions on RTOS, IPC, scheduling, drivers, debugging, and automotive systems.

    QNX is widely used in safety-critical and real-time embedded systems such as automotive infotainment, ADAS, medical devices, and industrial automation. Preparing for a QNX interview requires much more than memorizing basic RTOS concepts it demands a deep understanding of microkernel architecture, message passing, real-time scheduling, device drivers, memory management, and system-level debugging.

    This article provides a complete and structured set of QNX OS interview questions, carefully arranged from beginner to advanced level. Whether you are a fresher stepping into embedded systems or an experienced engineer working on automotive or safety-critical platforms, these questions will help you assess your knowledge, identify gaps, and prepare confidently for real-world QNX interviews.

    Each section mirrors how QNX is actually used in production systems, making this guide practical, relevant, and industry-focused.

    Why These QNX Interview Questions Are Useful

    These questions are not random or theoretical. They are based on real interview patterns and day-to-day QNX development scenarios.

    Here’s why this question set is genuinely useful:

    • Covers the complete QNX ecosystem
      From microkernel basics to advanced topics like adaptive partitioning, audio services, drivers, and safety isolation, nothing important is skipped.
    • Matches real interview progression
      Interviews usually start with architecture and fundamentals, then move to IPC, scheduling, memory, drivers, and finally system design. This question flow follows the same pattern.
    • Builds strong conceptual clarity
      Many engineers “use” QNX but struggle to explain why things work the way they do. These questions force you to think at system level, not just API level.
    • Helps freshers and experienced engineers alike
      Beginners can start from the basics, while experienced candidates can focus on advanced debugging, performance tuning, audio, and safety-critical design.
    • Automotive and safety focused
      QNX is heavily used in automotive. Topics like ISO 26262, ASIL, hypervisor, fault tolerance, and real-time guarantees are frequently asked and fully covered here.
    • Excellent self-assessment tool
      If you can confidently explain most of these questions, you are interview-ready. If not, they clearly show where you need to revise.

    In short, this question set prepares you not just to pass interviews, but to think like a QNX system engineer.

    QNX OS Interview Questions

    BASIC LEVEL : QNX Fundamentals

    QNX Basics

    1. What is QNX?
    2. Is QNX a real-time operating system?
    3. What does “microkernel” mean in QNX?
    4. How is QNX different from Linux?
    5. Where is QNX commonly used?
    6. What are the main features of QNX?
    7. What does POSIX compliance mean in QNX?
    8. Is QNX open source or proprietary?
    9. What is Neutrino in QNX?
    10. What is deterministic behavior in RTOS?
    11. What is the latest version of QNX?

    QNX Architecture

    1. Explain QNX architecture
    2. Explain QNX microkernel architecture.
    3. What runs in kernel space in QNX?
    4. What runs in user space in QNX?
    5. Why does QNX use message passing?
    6. What are resource managers in QNX?
    7. What is the role of the microkernel?
    8. How does QNX achieve fault tolerance?
    9. What is adaptive partitioning?
    10. What is a thread in QNX?
    11. What is a process in QNX?

    For a detailed explanation of the answer, you can visit : QNX OS Interview Questions and Answer

    BASIC : Boot & Startup

    1. What is the QNX boot sequence?
    2. What is IPL (Initial Program Loader)?
    3. What is IFS (Image File System)?
    4. What is startup code in QNX?
    5. What is the role of procnto?
    6. What is io-pkt?
    7. What is devb-*?
    8. What is devc-*?
    9. What is a startup script?
    10. Where are startup scripts located?

    INTERMEDIATE : Process, Thread & Scheduling

    Processes & Threads

    1. Difference between process and thread in QNX?
    2. What is the default thread scheduling policy?
    3. What is priority inheritance?
    4. What is priority inversion?
    5. How does QNX handle priority inversion?
    6. What is round-robin scheduling?
    7. What is FIFO scheduling?
    8. What is sporadic scheduling?
    9. What is adaptive scheduling?
    10. How many priority levels does QNX support?

    Scheduling

    1. How does QNX guarantee real-time behavior?
    2. What happens if a high-priority thread blocks?
    3. How does QNX handle preemption?
    4. What is timeslice in QNX?
    5. What is thread affinity?
    6. How to bind threads to CPU cores?
    7. How does SMP work in QNX?
    8. How does QNX handle multicore systems?
    9. What is load balancing in QNX?
    10. What is interrupt latency?

    INTERMEDIATE : IPC & Synchronization

    IPC (Message Passing)

    1. Explain QNX message passing.
    2. What is MsgSend()?
    3. What is MsgReceive()?
    4. What is MsgReply()?
    5. What is synchronous vs asynchronous IPC?
    6. Why message passing is faster in QNX?
    7. What happens if a server crashes?
    8. How does QNX recover from server failure?
    9. What is pulse in QNX?
    10. What is a channel?

    Synchronization

    1. What is a mutex?
    2. What is a semaphore?
    3. Difference between mutex and semaphore?
    4. What is condition variable?
    5. What is read-write lock?
    6. How does QNX avoid deadlocks?
    7. What is priority ceiling?
    8. What is priority inheritance mutex?
    9. What are atomic operations?
    10. How to synchronize ISRs with threads?

    INTERMEDIATE : Memory Management

    1. How is memory managed in QNX?
    2. What is virtual memory?
    3. Does QNX support MMU?
    4. What is physical vs virtual address?
    5. What is shared memory?
    6. How to create shared memory in QNX?
    7. What is mmap()?
    8. What is memory partitioning?
    9. What is adaptive partitioning scheduler (APS)?
    10. How does QNX prevent memory starvation?

    INTERMEDIATE : Signals, Timers & Interrupts

    Signals

    1. What are signals in QNX?
    2. Difference between signals and pulses?
    3. How does QNX handle signals?
    4. What is sigaction()?
    5. What is signal masking?

    Timers

    1. What is a timer in QNX?
    2. Difference between POSIX timer and QNX timer?
    3. What is timer_create()?
    4. What is a watchdog timer?
    5. How are timers implemented internally?

    Interrupts

    1. What is ISR in QNX?
    2. How to attach an interrupt?
    3. What is InterruptAttach()?
    4. Difference between ISR and IST?
    5. What is interrupt latency?
    6. How does QNX handle nested interrupts?
    7. What is interrupt masking?
    8. What is pulse from ISR?
    9. Why ISR must be short?
    10. How does QNX handle interrupt priorities?

    ADVANCED : Device Drivers & Resource Managers

    Drivers

    1. What is a QNX device driver?
    2. Difference between Linux and QNX drivers?
    3. What is a resource manager?
    4. What is resmgr_attach()?
    5. What is iofunc_*?
    6. How does open/read/write work in QNX?
    7. What is pathname space?
    8. How does QNX handle /dev?
    9. What is io-pkt architecture?
    10. What is devb block driver?

    Character & Block Drivers

    1. How to write a character driver in QNX?
    2. How to write a block driver in QNX?
    3. How to expose hardware to user space?
    4. How does QNX handle DMA?
    5. How to handle interrupts in drivers?
    6. How to debug QNX drivers?
    7. What is driver hot-plug?
    8. What is devctl()?
    9. What is mount in QNX?
    10. How does filesystem driver work?

    ADVANCED – Networking, Filesystem & Storage

    Networking

    1. What is io-pkt?
    2. How TCP/IP stack works in QNX?
    3. Difference between QNX and Linux networking?
    4. What is socket API in QNX?
    5. How to debug network issues in QNX?
    6. What is PPS (Persistent Publish Subscribe)?
    7. What is Qnet?
    8. How IPC works across nodes?
    9. What is adaptive networking?
    10. How does QNX handle Ethernet drivers?

    Filesystem

    1. What filesystems are supported in QNX?
    2. What is QNX6 filesystem?
    3. What is flash filesystem?
    4. What is wear leveling?
    5. What is power-safe filesystem?
    6. How does QNX handle journaling?
    7. What is fs-qnx6.so?
    8. How to mount filesystem at boot?
    9. What is mount vs fstab?
    10. How to debug filesystem issues?

    EXPERT : Audio, Automotive & Safety

    Audio (Very Important for Automotive)

    1. How ALSA works in QNX?
    2. Difference between Linux ALSA and QNX audio?
    3. What is PCM in QNX?
    4. What is mixer in QNX?
    5. What is audio routing?
    6. What is TDM?
    7. What is I2S in QNX?
    8. How audio service starts in QNX?
    9. How to debug audio latency issues?
    10. How to write a custom audio codec driver?

    Automotive & Safety

    1. What is ASIL?
    2. How QNX supports functional safety?
    3. What is ISO 26262?
    4. What is safety partition?
    5. What is hypervisor in QNX?
    6. Difference between QNX Hypervisor and Linux?
    7. What is secure boot in QNX?
    8. What is trust zone usage in QNX?
    9. How to isolate safety-critical tasks?
    10. How QNX ensures freedom from interference?

    EXPERT : Debugging, Performance & Optimization

    Debugging

    1. How to debug QNX applications?
    2. What is gdb in QNX?
    3. What is pdebug?
    4. How to debug startup issues?
    5. How to debug boot failures?
    6. How to debug drivers?
    7. How to trace IPC?
    8. What is System Profiler?
    9. What is Momentics IDE?
    10. How to analyze thread states?

    Performance

    1. How to reduce IPC latency?
    2. How to optimize scheduling?
    3. How to measure interrupt latency?
    4. How to reduce boot time?
    5. How to optimize memory usage?
    6. How to profile CPU usage?
    7. How to handle CPU starvation?
    8. How to debug deadlocks?
    9. How to detect priority inversion?
    10. How to tune APS parameters?

    ARCHITECT / SYSTEM DESIGN LEVEL

    1. Design a fault-tolerant QNX system.
    2. Design an audio service architecture in QNX.
    3. Design multi-core scheduling for QNX.
    4. Design safe OTA update mechanism in QNX.
    5. Design driver recovery without reboot.
    6. Design IPC between safety and non-safety domains.
    7. Design fast boot system in QNX.
    8. Design logging framework in QNX.
    9. Design watchdog strategy.
    10. Design startup dependency ordering.

    BONUS : REAL INTERVIEW SCENARIO QUESTIONS

    1. Why did you choose QNX over Linux?
    2. How do you debug a hung QNX system?
    3. How do you recover from driver crash?
    4. How do you handle memory leaks in QNX?
    5. How do you ensure real-time guarantees?
    6. What challenges did you face in QNX?
    7. How do you debug race conditions?
    8. How do you handle CPU overload?
    9. How do you design high-availability service?
    10. Explain one QNX project you worked on.

    Conclusion

    QNX is not just another operating system — it is designed for systems where failure is not an option. That’s why interviewers expect more than surface-level knowledge. They look for engineers who understand real-time behavior, fault isolation, IPC, scheduling, drivers, and system reliability.

    This comprehensive list of QNX OS interview questions is designed to help you build that understanding step by step. If you go through these questions honestly and study the areas where you feel weak, you won’t just memorize answers — you’ll gain confidence in how QNX actually works in real products.

    Use this guide as:

    • A revision checklist before interviews
    • A learning roadmap for QNX
    • A benchmark for your embedded systems knowledge

    Mastering these concepts will not only help you clear QNX interviews, but also make you a stronger, more reliable embedded software engineer in real-world projects.

    Frequently Asked Questions (FAQ) : QNX OS Interview Preparation

    1. What is QNX and why is it used in embedded systems?

    QNX is a real-time operating system (RTOS) based on a microkernel architecture. It is widely used in embedded systems because it offers deterministic performance, high reliability, fault isolation, and strong support for safety-critical applications such as automotive infotainment, ADAS, medical devices, and industrial automation.

    2. Is QNX difficult to learn for beginners?

    QNX can feel challenging at first, especially if you are new to RTOS concepts. However, if you already understand C/C++, processes, threads, and basic OS concepts, learning QNX becomes much easier. Starting with microkernel fundamentals and message passing helps build a strong foundation.

    3. How is QNX different from Linux?

    Linux uses a monolithic kernel where most services run in kernel space, while QNX follows a microkernel approach. In QNX, drivers, filesystems, and network stacks run in user space, which improves fault tolerance and system stability—an important requirement for safety-critical systems.

    4. Why is message passing important in QNX?

    Message passing is the core IPC mechanism in QNX. It enables safe, deterministic communication between processes and threads. Because services run in user space, message passing ensures isolation while still delivering high performance and real-time guarantees.

    5. What topics are most important for a QNX interview?

    Interviewers usually focus on:

    • Microkernel architecture
    • IPC (MsgSend, MsgReceive, pulses)
    • Thread scheduling and priorities
    • Memory management
    • Interrupt handling
    • Resource managers and device drivers
    • Debugging and performance tuning
    • Automotive and safety concepts (ISO 26262, ASIL)

    6. Are QNX interview questions more theoretical or practical?

    Most QNX interviews are practical and scenario-based. Interviewers often ask how you debug issues, design fault-tolerant services, handle priority inversion, or recover from driver failures rather than just theoretical definitions.

    7. Is QNX mainly used in automotive projects?

    Automotive is the largest user of QNX today, especially for infotainment and digital cockpits. However, QNX is also widely used in medical devices, railway systems, industrial controllers, networking equipment, and aerospace applications.

    8. Do I need driver development experience to clear a QNX interview?

    Driver knowledge is not mandatory for entry-level roles, but it is a big advantage for experienced positions. Understanding resource managers, interrupt handling, and user-space drivers significantly improves your interview performance.

    9. How should I prepare for advanced QNX interview rounds?

    For advanced rounds, focus on:

    • Real-time scheduling policies
    • Adaptive partitioning (APS)
    • IPC performance tuning
    • Debugging tools (GDB, Momentics, System Profiler)
    • Multicore and SMP behavior
    • System design and fault recovery strategies

    10. Are QNX interviews harder than Linux embedded interviews?

    QNX interviews are usually more system-design oriented and focus heavily on real-time behavior and reliability. While Linux interviews test kernel and driver knowledge, QNX interviews test how well you understand deterministic systems and fault isolation.

    11. Can these QNX interview questions help in real projects?

    Yes. These questions are not just for interviews. They help you understand how QNX systems behave in real products, how services communicate, how failures are handled, and how performance is optimized—skills that are directly applicable to real-world projects.

    12. What level of C/C++ knowledge is required for QNX?

    A solid understanding of C is essential, and C++ is commonly used for application and service development. Knowledge of pointers, memory management, multithreading, and synchronization primitives is critical for working effectively with QNX.

    13. How long does it take to prepare for a QNX interview?

    Preparation time depends on your background. Freshers may need 6–8 weeks, while experienced embedded engineers can revise and prepare in 2–3 weeks by focusing on QNX-specific concepts and practical scenarios.

    14. Is QNX still relevant in 2026 and beyond?

    Yes. QNX continues to be a key platform for safety-critical and automotive systems. With the growth of software-defined vehicles and real-time computing, QNX remains highly relevant.

    15. How should I use this QNX interview question guide effectively?

    Go through the questions section by section. Try to explain each answer in your own words. Wherever you struggle, revise that topic and relate it to real scenarios. This approach will build confidence and improve both interview performance and practical understanding.

    Read More about Process : What is is Process
    Read More about System Call in Linux : What is System call
    Read More about IPC : What is IPC
  • Master QNX OS and Hypervisor Most Asked Interview Questions (2026)

    QNX OS Most Asked Interview Questions explained in a simple and beginner-friendly way. Learn about microkernel, message passing, scheduling, memory management, and debugging in QNX OS to prepare for your next embedded systems interview.

    If you are preparing for an interview where QNX OS is involved, you are in the right place. QNX (Quick UNIX) is a real-time operating system (RTOS) widely used in automotive, medical devices, industrial systems, and embedded applications. Many companies test candidates on their understanding of QNX fundamentals, process management, memory handling, and inter-process communication.

    This article will walk you through the most asked QNX interview questions with simple explanations so you can build confidence for your next interview.

    Master QNX OS Most Asked Interview Questions

    1. What is QNX OS?

    QNX is a microkernel-based real-time operating system designed for reliability and deterministic performance. Unlike monolithic kernels, QNX uses a microkernel that handles only essential functions like scheduling, message passing, and interrupt handling, while other services run as user-space processes.

    Why it matters in interviews?
    Interviewers want to know if you understand the core concept of microkernel vs monolithic kernel, because this is the foundation of QNX.

    2. What makes QNX different from other RTOS?

    • Microkernel design (high reliability, modularity).
    • Message passing architecture (efficient inter-process communication).
    • Deterministic response time (critical in automotive and medical systems).
    • POSIX compliance (developers can use familiar APIs).

    Tip: Be ready to compare QNX with Linux or VxWorks in your interview.

    3. Explain QNX Microkernel Architecture

    QNX runs only the microkernel in privileged mode, while everything else (drivers, file systems, services) runs in user mode.

    • This makes the system fault-tolerant – if one driver crashes, it doesn’t bring down the whole system.
    • Communication happens through message passing between processes.

    Beginner way to answer:
    Think of QNX like a city: the microkernel is the traffic controller, while drivers, applications, and services are like cars following rules.

    4. What is Message Passing in QNX?

    Message passing is the heart of QNX IPC (Inter-Process Communication).

    • Processes communicate using Send, Receive, and Reply (SRR) calls.
    • It ensures synchronous, safe communication without shared memory conflicts.

    Example Interview Point:
    If asked about performance, mention that message passing avoids race conditions and makes QNX highly predictable.

    5. How does Scheduling work in QNX?

    QNX uses priority-based preemptive scheduling.

    • The highest-priority ready thread always runs.
    • Supports round-robin among equal-priority threads.
    • Ideal for real-time systems where deadlines matter.

    Tip for Interviews: Always highlight deterministic response time.

    6. How is Memory Managed in QNX?

    • QNX supports protected virtual memory.
    • Each process has its own address space.
    • Memory faults in one process don’t affect others.

    This is a key difference from smaller RTOS that often lack memory protection.

    7. What are some common use cases of QNX?

    • Automotive infotainment and ADAS systems.
    • Industrial automation.
    • Medical devices.
    • Aerospace and defense applications.

    Why this question matters?
    Interviewers want to check if you know where QNX is actually used in the real world.

    8. How do you debug in QNX?

    • Using QNX Momentics IDE (based on Eclipse).
    • With tools like pidin, sloginfo, and tracelogger.
    • Remote debugging over target hardware.

    Beginner-friendly answer:
    Say you use pidin to check running processes, sloginfo to read system logs, and the IDE for step-by-step debugging.

    9. QNX vs Linux – Which is better for real-time?

    • QNX → More predictable, deterministic, lightweight.
    • Linux RT patches → Can achieve real-time, but not as reliable in critical systems.

    10. Why do Automotive Companies prefer QNX?

    • ISO 26262 safety certification.
    • High reliability in infotainment, ADAS, and digital clusters.
    • Fault isolation (one failing component doesn’t crash the system).

    All Possible QNX OS Interview Questions

    QNX Fundamentals (Beginner)

    1. What is QNX?
    2. Is QNX a real-time operating system?
    3. What type of kernel does QNX use?
    4. What does “microkernel” mean?
    5. Why is QNX considered a microkernel OS?
    6. What are the main features of QNX?
    7. Where is QNX commonly used?
    8. What is the difference between QNX and Linux?
    9. Is QNX POSIX compliant?
    10. What does POSIX compliance mean?
    11. Who develops QNX?
    12. What is Neutrino in QNX?
    13. Is QNX open source?
    14. What languages are supported in QNX?
    15. What hardware architectures does QNX support?
    16. What is real-time behavior?
    17. What is hard real-time vs soft real-time?
    18. Why is determinism important in QNX?
    19. What is latency?
    20. What is jitter?

    QNX Architecture & Microkernel

    1. What components run inside the QNX microkernel?
    2. What runs outside the microkernel in QNX?
    3. Why are drivers outside the kernel in QNX?
    4. How does microkernel improve reliability?
    5. How does QNX achieve fault isolation?
    6. What is a user-space driver?
    7. What happens if a driver crashes in QNX?
    8. How is IPC handled in QNX?
    9. What is the role of the QNX microkernel scheduler?
    10. What kernel services are provided by QNX?
    11. Compare monolithic kernel vs microkernel
    12. What are the advantages of QNX microkernel?
    13. What are the disadvantages of microkernel?
    14. How does QNX reduce IPC overhead?
    15. What is message passing?

    QNX Boot Process

    1. Explain the QNX boot sequence
    2. What is IPL (Initial Program Loader)?
    3. What is startup code in QNX?
    4. What is procnto?
    5. What does procnto do?
    6. What is the role of the bootstrap loader?
    7. What is the system page (syspage)?
    8. What information is stored in syspage?
    9. What is the difference between startup and procnto?
    10. What happens after procnto starts?
    11. What is the first user process in QNX?
    12. How are drivers started during boot?
    13. What is buildfile?
    14. What is a QNX image?
    15. How do you customize QNX boot image?

    QNX Processes & Threads

    1. What is a process in QNX?
    2. What is a thread?
    3. Difference between process and thread in QNX
    4. Does QNX support multi-threading?
    5. What is a thread ID (TID)?
    6. What is a process ID (PID)?
    7. How many threads can a process have?
    8. What is thread scheduling?
    9. What is preemptive scheduling?
    10. How does QNX handle context switching?
    11. What is thread state?
    12. What is thread priority?
    13. What is priority inversion?
    14. How does QNX handle priority inversion?
    15. What is priority inheritance?
    16. What is priority ceiling?

    QNX Scheduling

    1. What scheduling policies does QNX support?
    2. What is SCHED_FIFO?
    3. What is SCHED_RR?
    4. What is SCHED_OTHER?
    5. Difference between FIFO and Round Robin
    6. What is time slicing?
    7. What is quantum?
    8. What happens when two threads have same priority?
    9. Can a lower priority thread preempt a higher one?
    10. How do interrupts affect scheduling?
    11. What is CPU affinity?
    12. Does QNX support SMP?
    13. How does QNX schedule threads on multi-core systems?
    14. What is adaptive partition scheduling (APS)?

    QNX Inter-Process Communication (IPC)

    1. What IPC mechanisms does QNX use?
    2. What is message passing in QNX?
    3. What is MsgSend?
    4. What is MsgReceive?
    5. What is MsgReply?
    6. Why is message passing synchronous?
    7. What is a channel?
    8. What is a connection?
    9. Difference between channel and connection
    10. What happens if MsgSend blocks?
    11. What is pulse in QNX?
    12. What is a pulse used for?
    13. Difference between pulse and message
    14. What is sigevent?
    15. How are signals used in QNX?
    16. Difference between signals and pulses
    17. What is shared memory?
    18. When to use shared memory vs message passing?
    19. What synchronization mechanisms are used?
    20. What are mutexes and semaphores in QNX?

    QNX Resource Manager (Very Important)

    1. What is a resource manager?
    2. Why does QNX use resource managers?
    3. What is the pathname space in QNX?
    4. How does QNX handle files and devices uniformly?
    5. What is io_open?
    6. What is io_read?
    7. What is io_write?
    8. What is io_devctl?
    9. What is dispatch layer?
    10. What is resmgr_attach?
    11. What is iofunc?
    12. What is ocb (Open Control Block)?
    13. What is attr structure?
    14. How do permissions work in resource managers?
    15. How does QNX handle /dev entries?
    16. Difference between character and block devices
    17. How to create a custom device driver?
    18. How does read/write flow work internally?
    19. What happens when a process opens a device?
    20. How does QNX handle blocking I/O?

    QNX File System

    1. What file systems does QNX support?
    2. What is QNX6 file system?
    3. What is ETFS?
    4. What is flash file system?
    5. Difference between QNX6 and ext4
    6. What is mount?
    7. What is umount?
    8. What is inode?
    9. What is a file descriptor?
    10. How does QNX handle file permissions?
    11. What is virtual file system (VFS)?
    12. How are file systems implemented in QNX?
    13. How does QNX handle wear leveling?
    14. What is fs-qnx6?
    15. What happens if file system crashes?

    QNX Drivers & BSP

    1. What is a BSP in QNX?
    2. What does a BSP contain?
    3. What is startup code in BSP?
    4. What is board bring-up?
    5. How do you write a QNX driver?
    6. Difference between Linux driver and QNX driver
    7. What is devb?
    8. What is devc?
    9. What is devn?
    10. What is io-pkt?
    11. What is devctl?
    12. How are interrupts handled in QNX drivers?
    13. What is ISR in QNX?
    14. What is InterruptAttach?
    15. What is InterruptWait?

    Memory Management

    1. How does QNX manage memory?
    2. What is virtual memory?
    3. What is physical memory?
    4. What is MMU?
    5. Does QNX support demand paging?
    6. What is memory partitioning?
    7. What is stack memory?
    8. What is heap memory?
    9. What is shared memory object?
    10. What is shm_open?
    11. How does QNX prevent memory corruption?
    12. What happens on memory fault?
    13. What is page fault?
    14. How does QNX handle memory protection?
    15. What is mprotect?

    Networking in QNX

    1. What networking stack does QNX use?
    2. What is io-pkt?
    3. Does QNX support TCP/IP?
    4. What is socket API?
    5. Difference between TCP and UDP
    6. What is CAN stack in QNX?
    7. What is Ethernet driver architecture?
    8. How does QNX handle network interrupts?
    9. What is loopback interface?
    10. How do you debug network issues in QNX?

    Debugging & Tools

    1. What debugging tools are available in QNX?
    2. What is Momentics?
    3. What is gdb in QNX?
    4. How do you debug a crashed process?
    5. What is slogger?
    6. What is sloginfo?
    7. What is tracelogger?
    8. What is system profiler?
    9. What is latency measurement tool?
    10. How do you analyze CPU usage?
    11. How do you analyze memory leaks?
    12. What is dump file?
    13. What is core dump?
    14. How to debug IPC issues?
    15. How to debug deadlocks?

    Safety, Security & ISO 26262

    1. What is functional safety?
    2. Why is QNX used in safety-critical systems?
    3. What is ISO 26262?
    4. What is ASIL?
    5. What ASIL levels does QNX support?
    6. What is QNX Safe Kernel?
    7. Difference between QNX Neutrino and QNX Safe
    8. What is safety certification?
    9. How does microkernel help safety?
    10. What is freedom from interference?
    11. How is memory isolated?
    12. How is time partitioning achieved?
    13. What is secure boot?
    14. What is trusted execution?
    15. How does QNX handle cybersecurity?

    Advanced & Expert Level

    1. How does QNX guarantee deterministic latency?
    2. How do you design a real-time system in QNX?
    3. How do you handle overload conditions?
    4. How do you design fault-tolerant systems?
    5. How do you restart failed components?
    6. How does QNX support high availability?
    7. How does QNX compare with AUTOSAR OS?
    8. How does QNX compare with VxWorks?
    9. How does QNX handle mixed-criticality systems?
    10. How do you optimize IPC performance?
    11. How do you tune scheduler parameters?
    12. How do you reduce interrupt latency?
    13. How do you design a custom resource manager?
    14. How do you debug real-time violations?
    15. How do you port QNX to new hardware?

    Scenario / Practical Interview Questions

    1. How would you design a device driver in QNX?
    2. How would you implement inter-process communication?
    3. How would you recover from a crashed driver?
    4. How would you measure worst-case latency?
    5. How would you implement a watchdog?
    6. How would you handle priority inversion?
    7. How would you isolate a faulty application?
    8. How would you meet ASIL-D requirements?
    9. How would you debug boot failure?
    10. How would you optimize system startup time?

    QNX Security Architecture (Including TrustZone)

    Why Security Matters in QNX

    QNX is used in:

    • Automotive ECUs (IVI, ADAS, Digital Cockpit)
    • Industrial controllers
    • Medical devices

    So it must provide:

    • Strong isolation
    • Deterministic real-time behavior
    • Safety + security together

    Core Security Principles in QNX

    QNX security is based on:

    1. Microkernel isolation
    2. Least-privilege design
    3. Hardware-assisted security
    4. Defense-in-depth
    5. Separation of safety-critical and non-critical software

    Microkernel = First Security Layer

    How QNX Microkernel Improves Security

    • Only minimal code runs in kernel mode:
      • Scheduling
      • IPC
      • Interrupt handling
      • Low-level memory management
    • Drivers, filesystems, network stacks run in user space

    Security Benefits

    • Driver crash ≠ system crash
    • Compromised service can be restarted
    • Smaller attack surface
    • Easier security certification

    This is a huge advantage over monolithic kernels.

    Process & Memory Isolation

    🔹 Memory Protection

    • Each process has its own virtual address space
    • Enforced by MMU
    • No direct memory access between processes

    🔹 What Happens on Violation?

    • Memory fault
    • Process terminated
    • Kernel remains unaffected

    IPC Security (Message Passing)

    QNX uses synchronous message passing instead of shared memory by default.

    🔹 Security Advantages

    • No accidental memory sharing
    • Kernel validates message transfer
    • Controlled access through channels

    🔹 Credentials Propagation

    • QNX can pass:
      • PID
      • UID
      • GID
    • Enables authentication & authorization

    Capabilities & Permissions

    🔹 POSIX Permissions

    • File/device permissions
    • User & group based access

    🔹 Fine-Grained Control

    • Access to /dev nodes
    • Access to IPC channels
    • Access to system services

    Secure Boot in QNX

    🔹 What is Secure Boot?

    Ensures only trusted software runs on the system.

    🔹 Boot Chain

    1. ROM bootloader
    2. First-stage bootloader
    3. QNX IPL
    4. QNX startup
    5. QNX kernel (procnto)
    6. User processes

    🔹 Verification

    • Digital signatures
    • Cryptographic hash validation
    • Root of Trust (RoT)

    ❗ If verification fails → system does not boot.

    Trusted Execution Environment (TEE)

    QNX integrates with hardware TEE, such as:

    • ARM TrustZone
    • Secure enclaves

    ARM TrustZone + QNX (Very Important)

    What is TrustZone?

    ARM TrustZone splits the system into:

    • Secure World
    • Normal World

    How QNX Uses TrustZone

    Secure WorldNormal World
    Key storageApplications
    Crypto opsQNX Neutrino
    Secure bootIVI / ADAS
    HSM accessNetworking

    Use Cases

    • Secure key management
    • Certificate handling
    • DRM
    • Secure firmware update
    • Vehicle identity protection

    QNX typically runs in:

    • Normal World
    • Communicates with Secure World via SMC calls

    Hardware Security Module (HSM)

    What is HSM?

    • Dedicated hardware for cryptography

    QNX + HSM

    • Secure key storage
    • Hardware-accelerated crypto
    • Used for:
      • Secure boot
      • TLS
      • OTA updates
      • CAN authentication

    Secure Communication

    Network Security

    • TLS/SSL support
    • Secure sockets
    • Firewall & filtering

    Automotive

    • Secure CAN
    • Ethernet TSN security
    • DoIP protection

    QNX Hypervisor Security

    QNX Hypervisor

    • Runs multiple OSs (Linux, Android, QNX)
    • Strong partitioning

    Security Benefits

    • No shared kernel
    • Memory & CPU isolation
    • One OS compromise does not affect others

    Very important for digital cockpit systems.

    Safety + Security (ISO 26262 + Cybersecurity)

    QNX supports:

    • ISO 26262
    • ISO 21434 (Automotive Cybersecurity)

    Freedom From Interference

    • Time partitioning
    • Memory partitioning
    • Resource partitioning

    Secure + Safe Together

    • Secure boot protects safety software
    • Isolation prevents cascading failures

    Intrusion Detection & Monitoring

    • Secure logging
    • Process monitoring
    • Integrity checks
    • Watchdogs

    QNX Security Interview Questions

    1. How does QNX microkernel improve security?
    2. How does QNX ensure process isolation?
    3. What is secure boot in QNX?
    4. How does QNX integrate with TrustZone?
    5. Difference between TrustZone and Hypervisor?
    6. How does QNX protect cryptographic keys?
    7. How does QNX support ISO 21434?
    8. How does QNX prevent privilege escalation?
    9. How does QNX handle a compromised driver?
    10. Why is QNX preferred for automotive security?

    One-Line Interview

    QNX security is built on a microkernel architecture, strong process isolation, secure boot, hardware-assisted security like ARM TrustZone and HSMs, and certified safety/security standards, making it ideal for automotive and safety-critical systems.

    What is QNX Hypervisor?

    Short definition (for interviews)

    QNX Hypervisor is a Type-1 (bare-metal) hypervisor that allows multiple operating systems—such as QNX, Linux, and Android to run simultaneously on the same hardware with strong isolation, real-time performance, and safety certification support.

    Why Do We Need a Hypervisor in QNX Systems?

    Modern embedded systems (especially automotive) must run:

    • Safety-critical software (ADAS, instrument cluster)
    • Non-critical software (Android IVI, apps)
    • Real-time control tasks
    • High-performance graphics & networking

    Running everything in one OS is risky.

    Hypervisor solves this by isolating systems.

    What Type of Hypervisor is QNX Hypervisor?

    TypeDescription
    Type-1 (Bare-metal)Runs directly on hardware
    Type-2Runs on top of another OS

    QNX Hypervisor is Type-1, meaning:

    • No host OS
    • Lower latency
    • Stronger isolation
    • Better real-time behavior

    High-Level Architecture

    +-----------------------------+
    |   Guest OS (Android)        |
    +-----------------------------+
    |   Guest OS (Linux)          |
    +-----------------------------+
    |   Guest OS (QNX Neutrino)   |
    +-----------------------------+
    |        QNX Hypervisor       |
    +-----------------------------+
    |           Hardware          |
    +-----------------------------+
    

    Each Guest OS:

    • Thinks it owns the hardware
    • Is fully isolated from others

    Key Responsibilities of QNX Hypervisor

    🔹 CPU Virtualization

    • Assigns CPU cores to guests
    • Supports core pinning
    • Guarantees real-time behavior

    🔹 Memory Isolation

    • Each guest has a fixed memory region
    • Enforced using MMU & IOMMU
    • No memory overlap

    🔹 Device Virtualization

    • Shared devices (GPU, network)
    • Dedicated devices (CAN, SPI, UART)
    • Controlled access

    🔹 Interrupt Virtualization

    • Interrupt routing per guest
    • Priority-aware handling

    Real-Time Advantages

    Unlike general hypervisors:

    • Deterministic scheduling
    • Low interrupt latency
    • Predictable execution

    This is why QNX Hypervisor is used in ADAS and safety ECUs.

    Safety & Certification

    🔹 Functional Safety

    • Supports ISO 26262
    • Freedom from interference

    🔹 Why Hypervisor Helps Safety

    • Fault in Android ≠ fault in QNX safety app
    • Crash containment
    • Independent restart

    QNX Hypervisor vs TrustZone

    FeatureTrustZoneQNX Hypervisor
    PurposeSecure vs normal worldMulti-OS virtualization
    Worlds2Multiple guests
    IsolationSecurity-focusedSafety + security
    OS CountLimitedMany OSs
    Use caseKey storage, cryptoDigital cockpit

    They are complementary, not competitors.

    QNX Hypervisor vs Linux Hypervisor (KVM)

    FeatureQNX HypervisorKVM
    Real-timeExcellentLimited
    Safety certYesNo
    DeterminismHighMedium
    AutomotivePreferredRare

    Typical Automotive Use Case

    Digital Cockpit ECU

    Guest OSRole
    QNXInstrument cluster (ASIL-B/D)
    AndroidInfotainment
    LinuxMiddleware / services

    All running on one SoC.

    Device Sharing Example

    • GPU shared between Android & QNX
    • CAN dedicated to QNX safety OS
    • Ethernet shared via virtual NIC

    Boot Flow with Hypervisor

    1. Secure Boot ROM
    2. Bootloader
    3. QNX Hypervisor starts
    4. Guest OS images loaded
    5. Guests run independently

    Key Interview Questions

    1. What is QNX Hypervisor?
    2. Why is QNX Hypervisor Type-1?
    3. How does QNX Hypervisor ensure isolation?
    4. Difference between Hypervisor and microkernel?
    5. Hypervisor vs TrustZone?
    6. Why is QNX Hypervisor used in automotive?
    7. How does QNX Hypervisor support ISO 26262?
    8. How are devices shared between guests?

    One-Line Interview Answer

    QNX Hypervisor is a real-time, safety-certified, Type-1 hypervisor that allows multiple operating systems to run securely and independently on the same hardware, making it ideal for automotive and safety-critical systems.

    1. What is QNX Hypervisor?

    QNX Hypervisor is a Type-1 (bare-metal) hypervisor built on top of the QNX Neutrino RTOS microkernel.
    It allows multiple operating systems (guests) such as QNX, Linux, Android, or AUTOSAR Adaptive to run simultaneously on the same hardware, while remaining strictly isolated from each other.

    In simple words:

    QNX Hypervisor lets you safely run infotainment, ADAS, and safety-critical software on one SoC without interference.

    2. Why is QNX Hypervisor Type-1?

    A Type-1 hypervisor runs directly on hardware, not on top of another OS.

    Why QNX Hypervisor is Type-1:

    • Runs directly on the SoC
    • No host OS like Linux or Windows underneath
    • Has direct control over:
      • CPU cores
      • Memory (MMU)
      • Interrupts
      • Devices

    Why this matters:

    • Lower latency
    • Deterministic real-time behavior
    • Higher safety and security
    • Smaller attack surface

    This is mandatory for automotive safety systems.

    3. How does QNX Hypervisor ensure isolation?

    Isolation is the core strength of QNX Hypervisor.

    Isolation is achieved at multiple levels:

    CPU Isolation

    • Each guest OS is assigned:
      • Dedicated CPU cores or
      • Controlled time slices (scheduler enforced)
    • One guest cannot block or starve another

    Memory Isolation

    • Uses hardware MMU
    • Each guest has:
      • Its own virtual address space
    • No guest can:
      • Read
      • Write
      • Execute memory of another guest

    Device Isolation

    • Devices are either:
      • Exclusively assigned (pass-through)
      • Virtualized via QNX resource managers
    • A faulty guest cannot crash shared drivers

    Fault Containment

    • If one guest:
      • Crashes
      • Hangs
    • Other guests continue running normally

    This is critical for ASIL-D systems.

    4. Difference between Hypervisor and Microkernel?

    This is a very common interview trap question.

    AspectMicrokernel (QNX Neutrino)Hypervisor (QNX Hypervisor)
    PurposeOS architectureOS virtualization
    RunsCore OS servicesMultiple OS instances
    ControlsThreads, IPC, schedulingCPU, memory, devices
    Fault isolationBetween servicesBetween OSs
    ExampleQNX NeutrinoQNX Hypervisor

    Key relationship:

    QNX Hypervisor is built on top of the QNX microkernel

    The microkernel provides:

    • Message passing
    • Scheduling
    • Fault isolation

    The hypervisor adds:

    • Guest OS control
    • Hardware partitioning

    5. Hypervisor vs TrustZone?

    These are not competitors they work together.

    TrustZone (ARM):

    • Hardware security technology
    • Splits system into:
      • Secure world
      • Non-secure world
    • Used for:
      • Secure boot
      • Key storage
      • Crypto
      • DRM

    QNX Hypervisor:

    • Software virtualization layer
    • Runs multiple OSs
    • Provides:
      • Isolation
      • Scheduling
      • Resource control

    Key difference:

    FeatureTrustZoneQNX Hypervisor
    LevelHardware securitySoftware virtualization
    IsolationSecure vs non-secureOS-to-OS
    Use caseKeys, cryptoFull OS workloads
    FlexibilityLimitedVery high

    In automotive:

    • TrustZone protects secrets
    • QNX Hypervisor isolates systems

    6. Why is QNX Hypervisor used in automotive?

    Automotive systems demand safety + performance + consolidation.

    Reasons QNX Hypervisor is chosen:

    Mixed-Criticality Support

    • Run together:
      • ASIL-D safety apps
      • Infotainment (Linux/Android)
      • ADAS workloads

    ECU Consolidation

    • Multiple ECUs → Single powerful SoC
    • Reduces:
      • Cost
      • Wiring
      • Power consumption
      • Weight

    Real-Time Determinism

    • Guaranteed timing behavior
    • Mandatory for:
      • Braking
      • Steering
      • ADAS

    Proven Safety

    • Used by:
      • BMW
      • Mercedes
      • Volkswagen
      • Tesla (selected domains)

    7. How does QNX Hypervisor support ISO 26262?

    ISO 26262 is about functional safety.

    QNX Hypervisor supports ISO 26262 through:

    Safety-Certified Components

    • QNX Neutrino microkernel:
      • Certified up to ASIL-D
    • Safety manuals and documentation provided

    Freedom from Interference

    • Strong isolation ensures:
      • One guest cannot affect another
    • Required by ISO 26262 Part 6

    Deterministic Scheduling

    • Predictable execution
    • No priority inversion across guests

    Fault Detection and Recovery

    • Guest crashes are contained
    • Safety guest continues operating

    Auditable Design

    • Minimal trusted computing base
    • Easier certification

    This is why QNX is trusted for safety-critical ECUs.

    8. How are devices shared between guests?

    There are three main methods.

    Device Pass-Through

    • One device → one guest
    • Direct hardware access
    • Lowest latency
    • Example:
      • CAN controller → safety guest

    Virtual Devices

    • Hypervisor emulates a device
    • Guest sees a virtual hardware device
    • Actual hardware managed by QNX

    Example:

    • Virtual network card

    Shared Services via Resource Managers

    • QNX resource manager owns the device
    • Guests communicate using:
      • IPC
      • Shared memory
    • Controlled and safe sharing

    Example:

    • Display
    • Audio
    • Storage

    FAQ: QNX OS Interview Questions

    Q1. Is QNX a real-time operating system?
    Yes, QNX is an RTOS with deterministic scheduling and predictable response times.

    Q2. What is the core feature of QNX?
    The microkernel architecture with message passing.

    Q3. How do processes communicate in QNX?
    Using Send, Receive, and Reply (SRR) message passing calls.

    Q4. Which companies use QNX?
    Automotive (BlackBerry QNX, BMW, Audi), medical devices, aerospace, and industrial automation.

    Q5. How do you check running processes in QNX?
    By using the pidin command.

    Q6. What is the difference between QNX and Linux?
    QNX offers true real-time performance and fault tolerance, while Linux is more flexible but less predictable.

    Q7. What tools are used for debugging in QNX?
    Momentics IDE, pidin, sloginfo, tracelogger.

    Q8. Why is QNX preferred in automotive software?
    Because of safety certification, fault isolation, and reliability.

    Final Tips for Cracking QNX OS Interview

    Understand basic architecture (microkernel, message passing).
    Learn system utilities (pidin, sloginfo, ls, etc.).
    Be clear about real-time scheduling and priorities.
    Compare QNX vs Linux when asked.

  • Master How to Read and Understand Schematics: The Complete 2026 Guide

    Introduction | How to Read and Understand Schematics of Hardware

    How to Read and Understand Schematics of Hardware : In the world of embedded systems, understanding hardware schematics is an essential skill for both hardware and software engineers. Schematics act as the blueprints of electronic circuits, guiding engineers through the design, debugging, and troubleshooting phases.

    This blog post provides a step-by-step guide on how to effectively read and interpret hardware schematics, covering core symbols, power distribution, communication interfaces, and debugging techniques.

    1. Understanding the Basics of a How to Read and Understand Schematics

    A schematic diagram represents the electronic components and their connections in a circuit. It uses standardized symbols instead of physical representations of the components. The key elements of a schematic include:

    a) Reference Designators

    Each component in a schematic is labeled with a unique identifier, known as a reference designator. Common examples include:

    • R1, R2, R3 – Resistors
    • C1, C2, C3 – Capacitors
    • U1, U2 – Integrated Circuits (ICs)
    • D1, D2 – Diodes
    • Q1, Q2 – Transistors

    b) Symbols and Notations

    Some commonly used symbols include:

    • Resistor (R) – A zig-zag line
    • Capacitor (C) – Two parallel lines (polarized capacitors have a positive and negative marking)
    • Diode (D) – A triangle pointing to a line
    • Transistor (Q) – Different types (NPN, PNP, MOSFET) have unique symbols
    • Microcontroller (U) – A rectangular box with labeled pins
    • Power and Ground (VCC, GND) – Symbols representing power supply connections

    c) Nets and Nodes

    • Nets (Lines) – Represent electrical connections between components.
    • Nodes (Junctions) – Where multiple connections meet.
    • Net Labels – Named connections, reducing wire clutter (e.g., SDA, SCL for I2C communication).

    2. Power Distribution in a Schematic

    a) Identifying Power Sources

    Most circuits operate on specific voltage levels. Common designations include:

    • VCC (or VDD) – Positive power supply (+5V, +3.3V, etc.)
    • GND (or VSS) – Ground reference

    b) Voltage Regulators

    Voltage regulators ensure a stable power supply to the circuit. Examples:

    • 7805 Regulator – Provides a 5V output from a higher voltage source
    • AMS1117-3.3V – Converts 5V to 3.3V

    c) Decoupling and Filtering Capacitors

    Capacitors are used for noise reduction and power stability:

    • Ceramic capacitors (0.1µF, 1µF) – Placed near IC power pins
    • Electrolytic capacitors (10µF, 100µF) – Used in power regulation circuits

    3. Identifying the Core Components

    a) Microcontrollers and Processors

    • Identify the power pins (VCC, GND)
    • Locate I/O pins (GPIOs, ADCs, UART, SPI, I2C, etc.)
    • Check for external clock (crystal oscillator) and reset circuits

    b) Memory Components

    • EEPROM, Flash, RAM
    • Look for data and address bus connections

    c) Communication Interfaces

    • I2C (SDA, SCL) – Requires pull-up resistors (typically 4.7kΩ)
    • SPI (MOSI, MISO, SCK, CS) – Point-to-point high-speed interface
    • UART (TX, RX, GND) – Serial communication interface
    • CAN (CANH, CANL) – For automotive applications

    4. Understanding Peripheral Circuits

    a) Sensors and Actuators

    • Temperature Sensors (e.g., LM35, DHT11) – Analog or digital output
    • Motors (DC, Servo, Stepper) – Driven by H-bridge circuits

    b) Display Modules

    • OLED/LCD (I2C, SPI, Parallel) – Requires appropriate power levels
    • 7-segment Displays – Uses multiplexing

    5. Analyzing Protection Circuits

    a) Pull-up and Pull-down Resistors

    • Used for GPIO stabilization (e.g., 10kΩ pull-up on RESET pin)

    b) Reverse Polarity Protection

    • Diodes in series with power lines prevent reverse voltage damage

    c) Fuse and Overcurrent Protection

    • PTC Resettable Fuses – Protect against short circuits
    • TVS Diodes – Absorb voltage spikes

    6. Debugging Using Schematics

    a) Finding Test Points

    Test points are designated spots where you can measure signals with a multimeter or oscilloscope.

    b) Checking Signal Flow

    Trace the signals from power to microcontroller and peripherals.

    c) Identifying Common Issues

    • No power? Check the voltage regulator and power traces.
    • Unstable signals? Check capacitors and grounding.
    • Microcontroller not working? Verify clock and reset circuits.

    7. Tools for Schematic Analysis

    a) Software Tools

    • KiCad – Open-source schematic and PCB design tool
    • Altium Designer – Industry-standard for professional PCB design
    • Eagle – Used for PCB and schematic layout
    • OrCAD – Professional circuit design software

    b) Hardware Debugging Tools

    • Multimeter – For voltage and continuity checks
    • Oscilloscope – To analyze signal waveforms
    • Logic Analyzer – To debug communication protocols

    💛 Support Embedded Prep

    If you find our tutorials helpful and want to support our mission of sharing high-quality embedded system knowledge, you can contribute by buying us a coffee. Every small contribution helps us keep creating valuable content for learners like you. ☕

    Thank you for your support — it truly keeps Embedded Prep growing. 💻✨

    8. Practical Example (How to Read and Understand Schematics) Analyzing an Embedded Schematic

    Let’s analyze a simple ESP32-based IoT sensor circuit:

    • ESP32 Module
      • VCC → 3.3V Regulator (AMS1117-3.3V)
      • GND → Common ground
      • GPIO21 (SDA) & GPIO22 (SCL) → I2C OLED Display
      • GPIO4 → DHT11 Temperature Sensor (with a pull-up resistor)
      • UART TX/RX → Debugging interface
    • Power Management
      • 5V input from USB → 3.3V regulator
      • Decoupling capacitors (100µF, 10µF, 0.1µF) near power pins
    • Communication
      • I2C lines have 4.7kΩ pull-up resistors
      • UART connected to debugging console

    This schematic shows how power, communication, and sensors are connected in an embedded system.

    The topics required How to Read and Understand Schematics

    1. Basic Electrical & Electronics Engineering

    📚 Topics Covered:

    • Ohm’s Law, Kirchhoff’s Laws
    • Resistors, Capacitors, Inductors
    • Diodes, Transistors, MOSFETs
    • Power Supply Circuits (Voltage Regulators, SMPS, Batteries)
    • AC & DC Circuits

    👨‍🏫 Relevant Subject Names:

    • Basic Electrical Engineering (BEE)
    • Circuit Theory
    • Electronic Devices & Circuits (EDC)

    2. Analog & Digital Electronics

    📚 Topics Covered:

    • Op-Amps, Comparators
    • Filters, Amplifiers (LM386, etc.)
    • Logic Gates (AND, OR, NOT, XOR, etc.)
    • Flip-Flops, Counters, Registers
    • ADC/DAC Converters

    👨‍🏫 Relevant Subject Names:

    • Analog Electronics
    • Digital Logic Design
    • Digital Signal Processing (DSP)

    3. Microprocessors & Microcontrollers

    📚 Topics Covered:

    • Microcontroller Architecture (8051, ARM Cortex, STM32, ESP32)
    • GPIOs, Timers, Interrupts
    • Memory (Flash, EEPROM, RAM)
    • Peripheral Interfaces (SPI, I2C, UART, CAN, PCIe)

    👨‍🏫 Relevant Subject Names:

    • Microprocessor and Microcontroller (MPMC)
    • Embedded Systems

    4. Embedded System Design

    📚 Topics Covered:

    • Schematic Reading & PCB Layout
    • Bootloaders & Firmware
    • Low Power Design & Power Management
    • Real-Time Operating Systems (RTOS)

    👨‍🏫 Relevant Subject Names:

    • Embedded Systems
    • Real-Time Systems
    • Hardware-Software Co-design

    5. Communication Protocols & Interfaces

    📚 Topics Covered:

    • Serial & Parallel Communication (SPI, I2C, UART, CAN, USB)
    • Wireless Communication (Bluetooth, Wi-Fi, Zigbee, LoRa)
    • Signal Integrity & High-Speed PCB Design

    👨‍🏫 Relevant Subject Names:

    • Communication Systems
    • Data Communication & Networking
    • VLSI & Interfacing

    6. Power Electronics & Circuit Design

    📚 Topics Covered:

    • Power Supply Design (Buck/Boost Converters)
    • Motor Driver Circuits (H-Bridge, PWM)
    • Protection Circuits (Fuses, TVS Diodes, Surge Protection)

    👨‍🏫 Relevant Subject Names:

    • Power Electronics
    • Control Systems
    • Analog & Mixed-Signal Design

    7. PCB Design & Signal Processing

    📚 Topics Covered:

    • PCB Design using KiCad, Altium, Eagle
    • PCB Traces, Ground Planes, EMI/EMC Considerations
    • Oscilloscope & Multimeter Usage for Debugging

    👨‍🏫 Relevant Subject Names:

    • PCB Design & Manufacturing
    • Signal Processing

    8. Computer Architecture & System Programming

    📚 Topics Covered:

    • ARM, x86, RISC-V Architectures
    • Memory Mapping & DMA
    • Interrupt Handling & Low-Level Programming

    👨‍🏫 Relevant Subject Names:

    • System Programming
    • Computer Organization & Architecture

    Requirement Gathering Tools for Embedded Firmware Development | How to Read and Understand Schematics

    Requirement gathering is crucial in embedded firmware development to ensure clarity, traceability, and compliance. Here are some tools categorized based on their purpose:

    1. Requirements Management & Traceability Tools

    These tools help capture, manage, and track requirements throughout the development lifecycle.

    • IBM DOORS (Dynamic Object-Oriented Requirements System) – Industry-standard for requirements management, widely used in automotive (ASPICE), aerospace (DO-178C), and medical fields.
    • Jama Connect – Provides end-to-end requirements traceability, change management, and impact analysis.
    • Helix ALM (formerly TestTrack) – Manages requirements, test cases, and defects in a unified platform.
    • Polarion ALM – A Siemens tool that integrates requirements, test cases, and project tracking with compliance support.
    • codeBeamer ALM – Great for automotive, medical, and industrial embedded systems (supports ASPICE & ISO 26262).

    2. Open-Source & Lightweight Requirement Tools

    If you need simpler or open-source tools:

    • ReqView – Standalone, lightweight requirement management with a simple UI.
    • LibrePlan – Open-source tool for requirement gathering and project planning.
    • Excel / Google Sheets – Many teams still use spreadsheets for capturing simple requirements with custom templates.

    3. UML & SysML-Based Requirement Tools

    For model-driven requirement engineering (especially in embedded systems).

    • Enterprise Architect – Supports UML, SysML, and model-based requirements tracking.
    • IBM Rational Rhapsody – Integrates UML/SysML with requirement tracking.
    • Cameo Systems Modeler – Good for SysML-based embedded systems modeling.

    4. Agile & Collaboration Tools for Requirement Management

    If your team follows an Agile or Scrum process for firmware development:

    • Jira (with Jira Advanced Roadmaps) – Helps track requirements, epics, and user stories in Agile development.
    • Azure DevOps – Combines requirement tracking, version control, and test management.
    • Confluence – Great for documenting requirements collaboratively.
    • Notion – Flexible tool for creating structured requirement documents.

    5. Compliance-Focused Requirement Tools

    For functional safety and regulatory compliance (e.g., ISO 26262, IEC 61508, DO-178C):

    • Ansys medini analyze – Used in automotive, medical, and aerospace embedded projects.
    • PTC Integrity (Windchill RV&S) – Advanced tool for safety-critical firmware requirements.
    • Visure Requirements ALM – Focused on automotive (ASPICE), aerospace, and industrial compliance.

    Choosing the Right Tool for Embedded Systems

    Use CaseRecommended Tool
    Basic Requirement DocumentationExcel, Confluence, ReqView
    Agile-based Embedded ProjectsJira, Azure DevOps, Notion
    Safety-Critical Systems (ASPICE, ISO 26262)IBM DOORS, Jama Connect, codeBeamer ALM
    Model-Based Requirement EngineeringEnterprise Architect, Cameo Systems Modeler
    Open-Source SolutionLibrePlan, ReqView

    Interview questions on How to Read and Understand Schematics :

    Basic Questions on How to Read and Understand Schematics

    • What is a schematic diagram in electronics?
    • Why is it important to read and understand schematics in embedded systems?
    • What are the common symbols used in schematics?
    • How do you differentiate between power rails (Vcc, Vdd, GND, etc.) in a schematic?
    • What is the role of reference designators (R1, C1, U1, etc.) in a schematic?

    Components & Symbols for How to Read and Understand Schematics

    • How do you identify resistors, capacitors, inductors, diodes, and transistors in a schematic?
    • What is a pull-up resistor, and how can you recognize it in a schematic?
    • How can you tell if a capacitor is being used for decoupling or filtering in a circuit?
    • What does a fuse or TVS diode symbol indicate in a schematic?
    • How do you recognize an operational amplifier (Op-Amp) configuration in a schematic?

    Power and Signal Flow for How to Read and Understand Schematics

    • How do you determine the power source of a circuit from a schematic?
    • What are bypass capacitors, and where do they appear in a schematic?
    • How can you trace signal flow from input to output in a schematic?
    • How do you identify and differentiate between analog and digital signal paths?
    • What is a ground plane, and why is it important in PCB design?

    Microcontroller & Communication Interfaces for How to Read and Understand Schematics

    • How do you recognize a microcontroller (MCU) or processor in a schematic?
    • How can you identify and verify connections for I2C, SPI, UART, and CAN in a schematic?
    • What are the key components required for an external crystal oscillator in an MCU circuit?
    • How do you identify reset and boot mode circuits in a microcontroller schematic?
    • What is a JTAG/SWD header, and why is it used in embedded systems?

    Debugging & Troubleshooting Schematics for How to Read and Understand Schematics

    • How can you identify floating (unconnected) pins in a schematic?
    • How do you check for short circuits or incorrect connections in a schematic?
    • How can you use a multimeter or oscilloscope to verify circuit behavior based on a schematic?
    • What are test points, and why are they included in schematics?
    • How do you identify and correct a missing or incorrectly placed component in a schematic?

    Advanced & Industry-Specific Questions on How to Read and Understand Schematics

    • How do you read power management schematics (buck converters, LDOs, etc.)?
    • How can you interpret impedance-matching networks in high-speed PCB designs?
    • What is EMI/EMC shielding, and how can you recognize it in a schematic?
    • How do you analyze a differential pair (LVDS, USB, Ethernet) in a schematic?
    • How do you ensure compliance with industry standards (ISO 26262, IPC-2221, etc.) when analyzing schematics?
    Master the Art of How to Read and Understand Schematics of Hardware (2025)
    Master the Art of How to Read and Understand Schematics of Hardware (2025)

    Frequently Asked Questions (FAQ) on How to Read and Understand Schematics

    1. What is a schematic diagram in electronics?

    A schematic is a graphical representation of an electronic circuit, showing components and their connections using standardized symbols.

    2. Why is reading schematics important in embedded systems?

    Schematics help engineers understand circuit design, debug hardware issues, and integrate firmware with the correct electrical components.

    3. What are the most commonly used symbols in schematics?

    Some common schematic symbols include:

    • Resistor (R) – Zigzag line
    • Capacitor (C) – Two parallel lines
    • Inductor (L) – Coiled loops
    • Diode (D) – Triangle pointing to a line
    • Transistor (Q) – NPN/PNP or MOSFET symbols
    • Ground (GND) – Three descending lines
    • Microcontroller (U) – Rectangular block with pins

    4. How do I identify power and ground in a schematic?

    • Vcc/Vdd/Vss – Represents different voltage levels in the circuit
    • GND (Ground) – Common return path for current
    • Battery (BAT) – Alternating long and short lines

    5. How can I trace signal flow in a schematic?

    Start from inputs (sensors, buttons, communication lines) and follow the signal through processing elements (MCUs, ICs) to outputs (displays, motors, LEDs).

    6. How do I find the microcontroller in a schematic?

    Look for a large rectangle (U1, U2, etc.) with multiple labeled pins, often connected to memory, sensors, and communication interfaces.

    7. What is a pull-up/pull-down resistor, and how do I find it in a schematic?

    A pull-up resistor (connected between Vcc and a signal) ensures a default high state, while a pull-down resistor (between GND and a signal) ensures a default low state.

    8. How can I identify communication protocols like I2C, SPI, UART in a schematic?

    • I2C – Look for SDA (Data) and SCL (Clock) lines, often with pull-up resistors.
    • SPI – Consists of MOSI, MISO, SCK, and CS (Chip Select) lines.
    • UART – Identified by TX (Transmit) and RX (Receive) connections.

    9. What are decoupling/bypass capacitors, and why are they used?

    Decoupling capacitors (placed near IC power pins) stabilize voltage and filter out noise from the power supply.

    10. What are test points in a schematic?

    Test points are designated locations for measuring voltage, signals, and debugging during hardware testing.

    11. How do I detect errors in a schematic?

    Check for:

    • Floating (unconnected) pins
    • Short circuits or incorrect connections
    • Missing pull-up/pull-down resistors
    • Incorrect capacitor or diode placement

    12. What tools can help in reading schematics?

    • KiCad, Eagle, Altium Designer, OrCAD – For viewing and designing schematics
    • LTspice, Proteus, TINA-TI – For simulating circuits

    13. What is a ground plane, and why is it important?

    A ground plane is a large conductive layer used in PCBs to provide a low-resistance return path for current and reduce noise.

    14. How can I interpret differential pair signals (LVDS, USB, Ethernet)?

    Differential pairs use two closely routed traces with opposite signals to reduce noise and improve signal integrity.

    15. What is EMI/EMC shielding, and how is it represented in schematics?

    Electromagnetic Interference (EMI) shielding protects sensitive signals and is typically represented by grounded shielding enclosures or ferrite beads.

    16. What is the difference between schematic and PCB layout?

    A schematic is a logical diagram of a circuit, while a PCB layout is the physical design that places components on a board.

    17. How do I ensure a schematic follows industry standards?

    Follow IPC standards, ISO 26262 (automotive), and best practices like using proper symbols, grounding, and labeling.

    18. What is a Bill of Materials (BOM), and how is it related to schematics?

    A BOM lists all components used in a schematic, including part numbers, values, and footprints for PCB design.

    19. How do I verify a schematic before designing a PCB?

    • Cross-check with component datasheets
    • Simulate circuits using SPICE tools
    • Review connections using ERC (Electrical Rule Check)

    20. How can I improve my schematic reading skills?

    • Practice analyzing real schematics
    • Refer to component datasheets
    • Use online tools like Digi-Key, Mouser, and Altium for circuit examples

    Debugging & Testing Tools

    If you\’re interested in learning about debugging tools, check out below detailed guide about tools:

    • Multimeter – Basic voltage and continuity checking
    • Oscilloscope – Debugging signals in real-time
    • Logic Analyzer – Capturing and analyzing digital communication (I2C, SPI, UART)
    • JTAG/SWD Debuggers – Segger J-Link, ST-Link, OpenOCD for debugging and flashing firmware
    • GDB (GNU Debugger) – Debugging firmware, setting breakpoints, and inspecting registers

    Thank you for exploring How to How to Read and Understand Schematics Stay ahead in embedded systems with expert insights, hands-on projects, and in-depth guides. Follow Embedded Prep for the latest trends, best practices, and step-by-step tutorials to enhance your expertise. Keep learning, keep innovating!

    You can also Visit other tutorials of Embedded Prep