Tag: QNX OS

  • Master QNX OS Interview Questions and Answer 2026

    QNX OS interview questions and answers for 2026, explained in simple language. Covers microkernel architecture, IPC, scheduling, resource managers, and real-time concepts for embedded and automotive engineers.

    This collection of QNX OS interview questions and answers is designed for engineers who want to truly understand QNX, not just memorize definitions. The questions are written in a practical way, similar to what is actually asked in real technical interviews, especially for automotive, embedded, and RTOS roles.

    The content starts from basic concepts, such as what QNX is, why it is called a microkernel OS, and how it differs from Linux. As the questions progress, they move into core internal topics like kernel space vs user space, message passing, processes and threads, scheduling, IPC, and resource managers. Advanced sections cover fault tolerance, adaptive partitioning, real-time behavior, priority scheduling, and system reliability, which are commonly discussed in senior-level interviews.

    Each answer is written in simple language, focusing on clarity and understanding, not textbook definitions. Wherever possible, explanations reflect real-world behavior, how QNX works internally, and how engineers actually use it in production systems like automotive ECUs, medical devices, and industrial controllers.

    This material is especially useful for:

    • Embedded Software Engineers
    • Automotive/QNX Developers
    • RTOS and System Programming Interviews
    • Engineers working with QNX Neutrino

    The goal is not to impress with complex wording, but to help you explain QNX confidently and naturally during interviews just like an experienced engineer would.

    QNX is a POSIX-compliant, microkernel-based real-time operating system used in embedded and safety-critical systems. It provides deterministic real-time performance, high reliability, and fault isolation, making it ideal for automotive, medical, industrial, and aerospace applications.

    Key Points to Mention in Interviews

    • RTOS (Real-Time OS) → Guarantees predictable response times
    • Microkernel architecture → Only essential services (scheduler, IPC, interrupts) run in kernel
    • Fault tolerant → A crashing driver doesn’t crash the whole system
    • POSIX compliant → Familiar Linux/UNIX APIs
    • High reliability & safety → Used in ADAS, infotainment, medical devices
    • Message-passing IPC → Core communication mechanism
    • Certified OS → ISO 26262, IEC 61508, etc.

    Where QNX is Used

    • Automotive (Infotainment, ADAS, Digital Cockpits)
    • Medical Devices
    • Industrial Automation
    • Aerospace & Defense
    • Robotics

    QNX is a real-time operating system (RTOS).

    Interview-Ready Answer

    QNX is a hard real-time operating system that provides deterministic and predictable response times, which makes it suitable for safety-critical embedded systems.

    Why QNX is Real-Time

    • Deterministic scheduling → Guaranteed response within deadlines
    • Microkernel architecture → Minimal kernel, faster interrupt handling
    • Priority-based preemptive scheduling
    • Message-passing IPC → Core real-time communication mechanism
    • Low interrupt latency & jitter

    Hard vs Soft Real-Time

    • QNX = Hard real-time OS
      Missing a deadline is considered a system failure (important for automotive, medical systems).

    Interview One-Liner (Strong)

    QNX is a POSIX-compliant, microkernel-based hard real-time operating system designed for deterministic and safety-critical applications.

    In QNX, a microkernel means that only the most essential operating system services run in the kernel, such as the scheduler, interrupt handling, and inter-process communication (IPC). All other services like device drivers, file systems, networking, and protocol stacks run as user-space processes.

    Key Points to Mention

    1. Minimal Kernel → Only critical functions run in kernel space.
    2. User-space Services → Most OS services run as separate processes, improving stability and fault isolation.
    3. Fault Isolation → If a driver or service crashes, it won’t crash the whole system.
    4. Message-Passing IPC → Kernel facilitates communication between processes efficiently.
    5. Real-Time Friendly → Microkernel keeps latency low, making it suitable for hard real-time applications.

    Example Explanation

    • Suppose the audio driver crashes in QNX → Only that driver stops; the OS and other applications continue running.
    • Contrast this with monolithic kernels (like Linux), where a driver crash can crash the whole system.

    One-Liner for Interviews

    QNX’s microkernel architecture runs only essential services in the kernel, while other services run in user space, providing fault tolerance and real-time performance.

    QNX is a microkernel-based real-time operating system designed for deterministic, safety-critical embedded systems, while Linux is a monolithic, general-purpose OS that is not inherently real-time (unless using PREEMPT_RT patches).

    Key Differences to Mention

    FeatureQNXLinux
    Kernel TypeMicrokernelMonolithic
    Real-Time SupportHard real-time (deterministic)General-purpose; soft real-time with PREEMPT_RT
    Fault IsolationHigh – services run in user space; crashes don’t crash OSLow – kernel modules can crash entire system
    Inter-Process Communication (IPC)Message-passing via microkernelShared memory, signals, pipes (less deterministic)
    Typical Use CaseAutomotive, medical, industrial, aerospaceDesktop, servers, embedded systems (non-critical)
    Memory FootprintSmall, lightweightLarger, heavier
    Boot TimeFast, optimized for embedded systemsSlower, general-purpose boot
    CertificationISO 26262, IEC 61508, DO-178Not generally certified for safety-critical applications

    Example for Interview

    • Automotive Infotainment: QNX → Digital dashboard (hard real-time, fault-tolerant).
    • Desktop Application: Linux → Ubuntu OS on a laptop.

    One-Liner for Interviews

    QNX is a real-time, microkernel OS optimized for safety-critical embedded systems, whereas Linux is a general-purpose monolithic OS with limited real-time support.

    QNX is widely used in embedded and safety-critical systems where reliability, fault tolerance, and real-time performance are essential.

    Key Areas / Industries

    1. Automotive
      • Infotainment systems (digital dashboards, touchscreens)
      • Advanced Driver Assistance Systems (ADAS)
      • Digital cockpits and instrument clusters
    2. Medical Devices
      • Life-support equipment, patient monitors
      • Imaging systems
    3. Industrial Automation
      • Robotics, PLCs, factory automation controllers
      • Process control systems
    4. Aerospace & Defense
      • Avionics and flight control systems
      • Mission-critical embedded electronics
    5. Telecommunications
      • Network switches, base stations
    6. IoT and Embedded Devices
      • Smart appliances, robotics, edge devices

    Example for Interview

    “For example, in automotive, QNX is used in digital dashboards where a crash in the media player or Bluetooth module won’t take down the whole system, thanks to its microkernel architecture.”

    One-Liner

    QNX is commonly used in automotive, medical, industrial, aerospace, and telecommunications systems where reliability and real-time performance are critical.

    QNX is a microkernel-based real-time operating system with features designed for embedded and safety-critical systems, providing high reliability, determinism, and fault tolerance.

    Key Features

    1. Microkernel Architecture
      • Only essential services run in the kernel (scheduler, IPC, interrupts)
      • Other services (drivers, file systems, networking) run in user space
      • Ensures fault isolation and system stability
    2. Real-Time Performance
      • Hard real-time deterministic scheduling
      • Low interrupt latency and predictable response times
      • Priority-based preemptive multitasking
    3. POSIX Compliance
      • Supports standard UNIX/Linux APIs
      • Eases application porting from other systems
    4. Inter-Process Communication (IPC)
      • Efficient message-passing mechanism
      • Supports synchronous and asynchronous communication between processes
    5. Fault Tolerance & High Reliability
      • Crashing of a driver or service does not crash the OS
      • Critical for safety-certified applications
    6. Scalability
      • Runs on small microcontrollers to complex multi-core systems
      • Suitable for both resource-constrained devices and high-end embedded platforms
    7. File System Support
      • Journaling and networked file systems for reliability
      • Can integrate custom embedded file systems
    8. Networking & Communication
      • Supports TCP/IP, CAN, USB, and other industrial protocols
      • Suitable for connected embedded systems
    9. Security & Safety Certification
      • ISO 26262 (Automotive), IEC 61508 (Industrial), DO-178B/C (Aerospace)
      • Enables use in safety-critical applications
    10. Modularity
      • Easy to add/remove components without affecting the kernel
      • Lightweight and customizable for specific embedded use cases

    Example for Interview

    “For instance, in an automotive digital dashboard, QNX ensures that even if the media or Bluetooth service crashes, the display of speed, fuel, and engine status continues to work reliably, thanks to its microkernel architecture and fault isolation.”

    One-Liner for Interviews

    QNX features a microkernel architecture, hard real-time performance, fault tolerance, POSIX compliance, scalable modular design, and is certified for safety-critical systems.

    POSIX compliance in QNX means that the operating system supports standard UNIX/Linux APIs and interfaces, allowing developers to write portable applications that can run on QNX with minimal changes.

    Key Points to Mention

    1. Standardized API
      • QNX provides POSIX-compliant system calls for file I/O, process management, threading, signals, and IPC.
      • Makes it familiar to developers coming from Linux or UNIX environments.
    2. Portability
      • Applications written using POSIX APIs can be easily ported between QNX and other POSIX-compliant systems.
    3. Real-Time Extensions
      • QNX extends POSIX with real-time features, such as real-time scheduling (SCHED_FIFO, SCHED_RR) and priority inheritance mutexes.
    4. Example APIs in QNX
      • File operations: open(), read(), write(), close()
      • Threads: pthread_create(), pthread_join()
      • IPC: mq_open(), mq_send(), mq_receive() (message queues)
    5. Why It Matters
      • Reduces development time and learning curve
      • Enables cross-platform development for embedded systems
      • Ensures consistency and standard compliance in embedded applications

    Example for Interview

    “If you have an application written for Linux using standard POSIX threads and message queues, you can port it to QNX almost directly because QNX supports the same POSIX APIs, while also providing real-time guarantees.”

    One-Liner for Interviews

    POSIX compliance in QNX ensures standard UNIX/Linux API support, enabling application portability and consistent development while adding real-time capabilities.

    QNX is a proprietary operating system developed by BlackBerry. It is not open source, and its source code is licensed under commercial terms.

    Key Points to Mention

    1. Proprietary License
      • QNX requires a commercial license for development and deployment.
      • Source code is not freely available to the public.
    2. Commercial Support
      • BlackBerry provides official support, updates, and safety certifications.
      • Essential for automotive, medical, and industrial applications.
    3. Contrast with Open Source OS
      • Linux, FreeRTOS → Open source, source code freely available.
      • QNX → Closed-source, with guaranteed reliability and certification.
    4. Why Proprietary Matters
      • Ensures controlled development, rigorous testing, and compliance with safety standards like ISO 26262 or IEC 61508.

    One-Liner for Interviews

    QNX is a proprietary, commercially licensed real-time operating system with source code controlled by BlackBerry.

    Neutrino is the microkernel-based real-time operating system (RTOS) at the core of QNX. It provides the fundamental services like scheduling, inter-process communication (IPC), and interrupt handling, enabling QNX to deliver deterministic, reliable, and fault-tolerant performance in embedded systems.

    Key Points to Mention

    1. Core of QNX
      • Neutrino is the actual OS kernel.
      • All QNX services (file system, networking, drivers) run on top of Neutrino.
    2. Microkernel Architecture
      • Only essential functions (scheduler, IPC, interrupt handling) are in the Neutrino kernel.
      • Other services run in user space → better fault isolation.
    3. Real-Time Capabilities
      • Supports hard real-time scheduling.
      • Ensures predictable response times for critical applications.
    4. POSIX Compliance
      • Neutrino implements POSIX APIs, allowing applications to be portable from UNIX/Linux.
    5. Fault-Tolerant
      • If a driver or service crashes, Neutrino keeps the system running.

    Example for Interview

    “In an automotive dashboard, Neutrino ensures that the speedometer and fuel gauge continue updating even if a non-critical service like media playback crashes, thanks to its microkernel design.”

    One-Liner for Interviews

    Neutrino is the microkernel RTOS at the heart of QNX, providing deterministic real-time performance, POSIX compliance, and fault tolerance for embedded systems.

    Deterministic behavior in an RTOS means that the system responds to events or interrupts within a guaranteed, predictable amount of time, regardless of system load. This is essential for real-time applications where timing is critical.

    Key Points to Mention

    1. Predictable Response
      • A deterministic RTOS ensures that tasks meet their deadlines consistently.
      • Example: If a sensor triggers an interrupt, the OS handles it within a fixed maximum latency.
    2. Critical for Real-Time Systems
      • Timing guarantees are required in automotive, medical, aerospace, and industrial systems.
      • Missing deadlines can lead to system failures or safety hazards.
    3. Determinism vs Speed
      • Determinism focuses on predictability, not just fast execution.
      • Even if execution is slightly slower, as long as timing is predictable, it’s considered deterministic.
    4. Example
      • In a car’s ABS system, the RTOS must read wheel speed sensors and control brakes within exact deadlines. QNX ensures this deterministic behavior.

    One-Liner for Interviews

    Deterministic behavior in an RTOS means predictable, guaranteed response times to events or interrupts, ensuring real-time deadlines are always met.

    The latest major version of QNX is QNX Software Development Platform (SDP) 8.0. It includes:

    • QNX OS 8.0 – The core microkernel-based real-time operating system.
    • QNX OS for Safety 8.0 – Safety-certified edition for critical systems (ISO 26262, IEC 61508).
    • QNX Hypervisor 8.0 – Embedded virtualization platform.
    • QNX Momentics IDE 8.0.x – Development environment supporting SDP 8.0.

    Key Points:

    • Designed for embedded and safety-critical systems.
    • Provides deterministic real-time performance.
    • Supports fault isolation and microkernel architecture.

    One-Liner for Interviews:

    “QNX SDP 8.0 is the latest version, with QNX OS 8.0 at its core, optimized for embedded and safety-critical applications.”

    QNX Architecture

    QNX Architecture Overview

    QNX is a microkernel-based real-time operating system (RTOS). Its architecture is designed for high reliability, modularity, and real-time performance.

    The main layers are:

    1. Microkernel

    • Core of QNX.
    • Very small and minimal: only contains the most essential OS functions.
    • Responsibilities:
      • Task scheduling (prioritized, real-time scheduling)
      • Interprocess communication (IPC)
      • Interrupt handling
      • Timers
      • Low-level memory management
    • All other OS services run as user-space processes, not inside the kernel.

    Key point: This design improves stability because a crash in a service doesn’t crash the entire system.

    2. Process Managers (User-space Services)

    These are system services that run outside the kernel, providing higher-level OS functionalities:

    ServiceFunction
    File SystemManages files, directories, and storage devices.
    Network StackHandles TCP/IP, UDP, and network protocols.
    Device DriversHardware control (keyboard, serial, audio, display) as user-space tasks.
    Resource ManagersUnified interface for devices & files, exposing them as files (/dev).
    Timers / ClocksUser-space timers and scheduling assistance.
    • These services communicate with each other and with the microkernel via IPC.
    • Because they are separate from the kernel, if one fails, the system can continue running.

    3. Application Layer

    • Your user applications run here.
    • They request services via standard APIs or POSIX calls, which get translated into IPC messages to the microkernel or system services.
    • Applications are fully isolated, which enhances reliability.

    4. Communication Model

    • QNX uses message-passing IPC instead of traditional system calls.
    • Every process can send and receive messages synchronously or asynchronously.
    • This ensures determinism, essential for real-time systems.

    5. Memory Architecture

    • Microkernel handles basic memory protection.
    • Applications and services are isolated in their own address space, preventing accidental overwrites.
    • Memory faults in one service usually do not affect the kernel or other services.

    6. Highlights of QNX Architecture

    • Modular & Scalable: Add/remove services without touching the kernel.
    • Fault-Tolerant: Crashes in user-space services don’t crash the kernel.
    • Deterministic: Real-time scheduling ensures predictable behavior.
    • POSIX-Compliant: Supports standard APIs for portability.

    Architecture Diagram (Text Representation)

    +----------------------------------+
    |         User Applications        |
    +----------------------------------+
    |        POSIX APIs / Libraries    |
    +----------------------------------+
    |       User-Space Services        |
    |  (File System, Network, Drivers)|
    +----------------------------------+
    |           Microkernel            |
    |  (Scheduler, IPC, Interrupts)   |
    +----------------------------------+
    |           Hardware Layer         |
    +----------------------------------+
    

    Interview-Friendly Answer:

    “QNX has a microkernel-based architecture, where the kernel is minimal and handles only essential functions like task scheduling, interprocess communication (IPC), interrupt handling, and memory management. All other services, such as file systems, network stacks, and device drivers, run as user-space processes, communicating with the kernel and each other via IPC. Applications run on top of these services using POSIX APIs. This modular design ensures high reliability, fault tolerance, and deterministic real-time performance, making QNX ideal for embedded and safety-critical systems.”
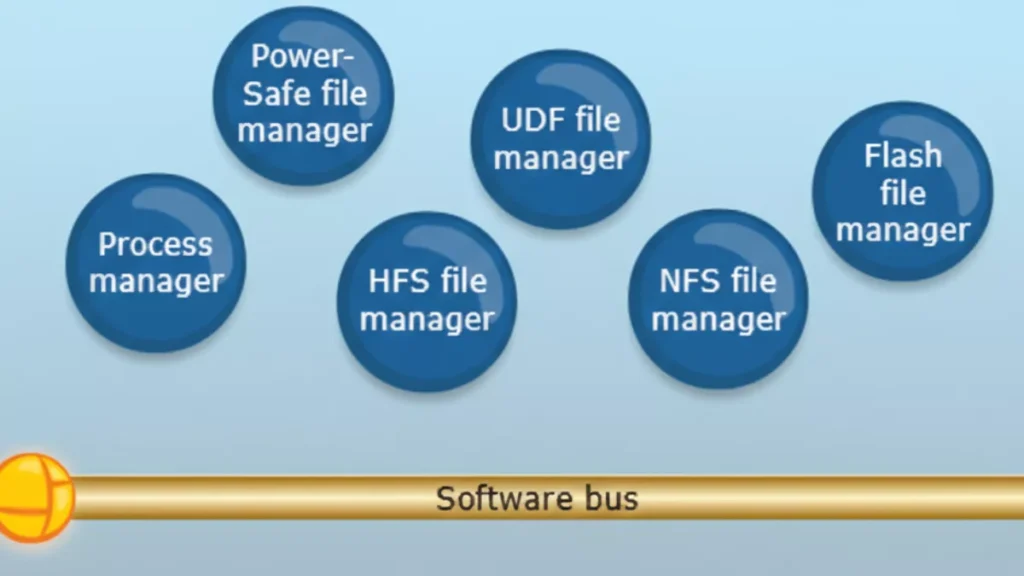
    Explanation of the Diagram

    1. Software Bus (Middle Layer)
      • Acts as a communication backbone for all user-space managers and applications.
      • All managers (file, network, GUI, character, etc.) and applications communicate with each other through this message-passing mechanism.
      • Essentially, this is how QNX implements microkernel principles: minimal kernel + IPC.
    1. Upper Layer: File and Process Managers
      These are system-level services running in user space:
      • Process Manager: Handles process creation, deletion, and scheduling requests.
      • File Managers: Manage different types of file systems:
        • Power-Safe file manager
        • UDF file manager
        • HFS file manager
        • NFS file manager
        • Flash file manager
      • These managers communicate via the software bus, instead of being inside the kernel.
    1. Lower Layer: Applications and Resource Managers
      • GUI Manager: Handles graphical interface.
      • Character Manager: Handles character devices (e.g., keyboard, serial port).
      • Network Manager: Handles network services.
      • Mqueue Manager: Manages message queues (IPC feature).
      • CIFS File Manager: For network file sharing (SMB/CIFS).
      • Applications: End-user or embedded applications running on top of these managers.

    Key Takeaways

    • This diagram shows QNX’s modular microkernel architecture in action:
      • Microkernel: Handles only essential kernel tasks (not shown explicitly in this diagram; it’s below the software bus, managing IPC, scheduling, and interrupts).
      • Software bus: Allows all user-space managers and applications to communicate.
      • Managers: Implement higher-level OS services in user space.
      • Applications: Sit at the top and use these services via message passing.
    • If one manager crashes, it doesn’t crash the kernel or other managers, highlighting QNX’s fault-tolerant design.

    Interview Tip:
    You can say:

    “This diagram shows QNX Neutrino’s user-space architecture. System managers like file managers, network manager, GUI manager, and process manager run as independent processes in user space. Applications communicate with these managers via the software bus, which implements the microkernel’s message-passing IPC. This design makes QNX highly modular, fault-tolerant, and suitable for real-time embedded systems.”

    QNX uses a microkernel architecture, meaning the operating system kernel is kept very small and only contains the most critical functions.
    All other OS services run as separate user-space processes, not inside the kernel.

    What Runs Inside the QNX Microkernel?

    The QNX Neutrino microkernel includes only four core responsibilities:

    1. Thread scheduling
      • Priority-based, fully preemptive
      • Ensures deterministic real-time behavior
    2. Inter-Process Communication (IPC)
      • Message passing (MsgSend, MsgReceive, MsgReply)
      • This is the heart of QNX
    3. Interrupt handling
      • Fast and predictable interrupt response
    4. Low-level thread and process management

    Nothing else runs in kernel space

    What Runs Outside the Kernel (User Space)?

    All higher-level OS services are implemented as user-space servers:

    • File systems (e.g., /fs-qnx6.so)
    • Device drivers (UART, I2C, SPI, Audio, Network)
    • Networking stack (TCP/IP)
    • Process manager (procnto)
    • Memory manager
    • Resource managers

    These components communicate using message passing.

    QNX Architecture Overview (Logical Flow)

    +-----------------------+
    |   Applications          |
    +-----------------------+
              |
              |  Message Passing (IPC)
              |
    +-----------------------+
    | OS Services / Servers |
    | (Drivers, FS, Net)         |
    +-----------------------+
              |
              | IPC
              |
    +-----------------------+
    |   Microkernel         |
    | (Scheduler, IPC, IRQ)|
    +-----------------------+
              |
    +-----------------------+
    |      Hardware         |
    +-----------------------+
    

    Message Passing – The Core Concept

    Unlike Linux (which uses system calls heavily), QNX uses:

    • Synchronous message passing
    • Client sends request → server processes → replies

    Example:

    • App wants to write to a UART
    • App sends message to UART driver
    • UART driver responds after operation
    • No shared memory required
    • Strong isolation
    • Predictable timing

    Why Microkernel? (Advantages)

    1. High Reliability

    • If a driver crashes, only that process restarts
    • Kernel remains unaffected

    2. Fault Tolerance

    • Ideal for safety-critical systems (ASIL-D)

    3. Deterministic Real-Time Behavior

    • Guaranteed response times
    • Used in automotive and medical systems

    4. Security

    • Smaller kernel → smaller attack surface

    QNX vs Linux (Interview Comparison)

    FeatureQNXLinux
    Kernel typeMicrokernelMonolithic
    DriversUser spaceKernel space
    IPCMessage passingSyscalls + shared memory
    Real-timeNativeNeeds RT patches
    Fault isolationStrongWeak
    Safety certificationYes (ASIL-D)Limited

    Real-World Example (Automotive)

    In a car infotainment system:

    • Audio driver crashes
    • Only audio service restarts
    • Navigation and UI keep running

    This is why QNX is used in automotive ECUs

    One-Line Interview Answer

    QNX uses a microkernel architecture where only scheduling, IPC, interrupts, and thread management run in the kernel, while all other services like drivers and file systems run in user space as separate processes, ensuring high reliability, fault isolation, and deterministic real-time behavior.

    In QNX (Neutrino), the kernel space contains only the most critical real-time components. Everything else runs in user space.

    The following run in kernel space:

    1. Thread Scheduling

    • Priority-based, fully preemptive scheduler
    • Ensures deterministic real-time behavior
    • Handles context switching

    2. Inter-Process Communication (IPC)

    • Core message passing mechanism
    • MsgSend(), MsgReceive(), MsgReply()
    • Fast, synchronous IPC

    IPC is the heart of QNX

    3. Interrupt Handling

    • Low-latency interrupt dispatching
    • Interrupt Service Routines (ISRs)
    • Interrupt events delivery to threads

    4. Low-Level Thread & Process Management

    • Thread creation and destruction
    • Basic process control
    • Kernel-level synchronization primitives

    What Does NOT Run in Kernel Space?

    These run in user space, not kernel space:

    • Device drivers (UART, I2C, SPI, Audio, Network)
    • File systems
    • Memory manager
    • Network stack (TCP/IP)
    • Process manager (procnto)
    • Resource managers

    One-Line Interview Answer

    In QNX, kernel space contains only the microkernel responsible for scheduling, message-passing IPC, interrupt handling, and low-level thread management; all other OS services and drivers run in user space.

    Memory Tip for Interviews

    Think S-I-I-T:

    • Scheduling
    • IPC
    • Interrupts
    • Threads

    In QNX Neutrino, almost everything except the microkernel runs in user space as separate processes (servers).

    Major Components Running in User Space

    1. Process Manager (procnto)

    • Handles:
      • Process creation (fork, spawn)
      • Signal delivery
      • POSIX compliance
    • Acts as the root server of the system

    2. Memory Manager

    • Virtual memory management
    • Address space creation
    • Memory protection
    • Page faults handling (with kernel support)

    3. Device Drivers

    • UART, I2C, SPI, CAN
    • Audio, Display, Camera
    • GPIO, ADC, PWM
    • Network drivers
    • Run as normal user processes
    • Can be restarted if they crash

    4. File Systems

    • QNX6 filesystem
    • Flash file systems
    • Network file systems
    • Mounted under /

    5. Network Stack

    • TCP/IP stack
    • Ethernet, Wi-Fi drivers
    • Socket services

    6. Resource Managers

    • Implement POSIX-style resources
    • Expose services as files (e.g. /dev/ser1)
    • Handle open/read/write/ioctl

    7. System Services & Daemons

    • Audio services
    • Power management
    • Clock services
    • Logging services

    8. User Applications

    • HMI / UI apps
    • Control logic
    • Diagnostic tools
    • Middleware

    QNX User Space Layout (Conceptual)

    +----------------------+
    |   User Applications  |
    +----------------------+
    | System Services      |
    | File Systems         |
    | Network Stack        |
    | Device Drivers       |
    | Resource Managers    |
    | procnto              |
    +----------------------+
            |
            | IPC (message passing)
            |
    +----------------------+
    |   Microkernel        |
    +----------------------+
    

    Why This Design Matters

    Fault Isolation

    • Driver crash ≠ system crash

    Easy Recovery

    • Restart a single service

    Safety Certification

    • Ideal for ASIL-D systems

    Secure Architecture

    • Minimal kernel attack surface

    One-Line Interview Answer

    In QNX, user space contains the process manager, memory manager, device drivers, file systems, network stack, resource managers, system services, and all applications—each running as separate processes that communicate via message passing.

    QNX uses message passing as its core communication mechanism to achieve deterministic real-time behavior, fault isolation, reliability, and scalability in a microkernel architecture.

    1. Fits the Microkernel Design

    QNX keeps the kernel very small.
    Since drivers, file systems, and services run in user space, they must communicate safely.

    ➡ Message passing replaces shared kernel data structures

    • No direct function calls across protection boundaries
    • Clean client–server model

    2. Deterministic Real-Time Behavior (Key Reason)

    Message passing in QNX is:

    • Synchronous
    • Priority-aware

    What this means:

    • Client blocks until server replies
    • Server temporarily inherits the client’s priority (priority inheritance)

    ✔ Prevents priority inversion
    ✔ Guarantees bounded latency
    ✔ Ideal for hard real-time systems

    3. Strong Fault Isolation & Reliability

    • Each driver/service runs as a separate process
    • If a driver crashes:
      • Kernel stays alive
      • Other services keep running
      • Only the failed service is restarted

    ➡ Message passing enforces strict process isolation

    4. Security by Design

    • No shared memory by default
    • No arbitrary kernel access
    • Services only expose controlled interfaces

    ➡ Smaller attack surface than monolithic kernels

    5. Unified Communication Model

    QNX uses one mechanism everywhere:

    OperationImplemented via
    File I/O (read/write)Messages
    Device accessMessages
    Network stackMessages
    Signals & eventsMessages

    ➡ Simpler OS design
    ➡ Easier to reason about timing

    6. Zero-Copy Efficiency

    Despite being message-based:

    • QNX supports zero-copy transfers
    • Uses shared memory only when explicitly needed

    ➡ High performance with real-time guarantees

    7. Easier Debugging & Maintenance

    • Services can be:
      • Stopped
      • Replaced
      • Restarted
    • No kernel rebuild required

    ➡ Faster development and safer updates

    Real Example (Automotive)

    • Audio application → sends message to audio driver
    • Audio driver crashes
    • Audio service restarts
    • Navigation & safety systems continue running

    ➡ System does not reboot

    One-Line Interview Answer

    QNX uses message passing to enable safe and deterministic communication between user-space services in its microkernel architecture, providing real-time predictability, fault isolation, priority inheritance, and high system reliability.

    Memory Trick for Interviews

    Think D-R-F-S-U:

    • Determinism
    • Reliability
    • Fault isolation
    • Security
    • Unified IPC

    Resource managers in QNX are user-space server processes that implement POSIX-style resources (files, devices, pseudo-devices) and expose them through the filesystem namespace using message passing.

    In simple words:

    A resource manager lets a user-space service behave like a file or device (e.g. /dev/ser1).

    Why Resource Managers Exist

    QNX follows the principle:

    “Everything is a file”

    Instead of placing drivers in kernel space (like Linux), QNX uses resource managers in user space to handle:

    • open()
    • read()
    • write()
    • ioctl()
    • close()

    All these calls are translated into messages.

    Where Do Resource Managers Run?

    • User space
    • As normal processes
    • Communicate with clients via QNX IPC (message passing)
    • Crash-safe
    • Restartable
    • Isolated

    Common Examples of Resource Managers

    ResourceExample
    Serial driver/dev/ser1
    GPIO/dev/gpioX
    Audio/dev/snd/*
    Custom device/dev/mydevice
    Pseudo file/proc, /dev/random

    How a Resource Manager Works (Flow)

    1. Application calls:fd = open("/dev/ser1", O_RDWR);
    2. Kernel converts this into a message
    3. Message is sent to the resource manager
    4. Resource manager processes the request
    5. Sends a reply back to the application

    Key Components of a Resource Manager

    1. Dispatch Layer

    • Receives messages
    • Routes them to appropriate handlers

    2. Connect Functions

    • Handle:
      • open()
      • close()

    3. I/O Functions

    • Handle:
      • read()
      • write()
      • ioctl()

    Types of Resource Managers

    Device Resource Managers

    • Hardware drivers (UART, I2C, CAN)

    Filesystem Resource Managers

    • QNX6, Flash FS

    Pseudo Resource Managers

    • Virtual or logical devices

    Benefits of Resource Managers

    Fault Isolation

    • Driver crash ≠ system crash

    POSIX Compliance

    • Standard file APIs

    Real-Time Friendly

    • Priority inheritance during IPC

    Easy Debugging

    • Run, stop, restart like any process

    QNX vs Linux (Quick Comparison)

    FeatureQNXLinux
    Driver locationUser spaceKernel space
    InterfaceFile-basedSyscalls
    Crash impactLocalOften system-wide
    IPCMessage passingFunction calls

    One-Line Interview Answer

    Resource managers in QNX are user-space processes that expose devices and services as POSIX-compliant files, handling open/read/write/ioctl requests via message passing, enabling fault isolation and real-time reliability.

    The microkernel’s role in QNX is to provide the core real-time foundation by handling thread scheduling, message-passing IPC, interrupt handling, and basic process/thread management, while all other OS services run in user space.

    QNX achieves fault tolerance by running drivers and OS services in user space, using message passing for isolation, and allowing failed components to be restarted without affecting the microkernel or the rest of the system.

    How QNX Achieves Fault Tolerance (Key Points)

    1. Microkernel Architecture
      • Kernel contains only scheduling, IPC, and interrupts
      • Minimal kernel → fewer failure points
    2. User-Space Drivers & Services
      • Device drivers, file systems, network stack run as separate processes
      • A crash affects only that component, not the whole OS
    3. Message Passing (Strong Isolation)
      • No shared kernel data by default
      • Faults are contained within a single process
    4. Service Restart & Recovery
      • Failed services/drivers can be restarted dynamically
      • System continues running
    5. Priority Inheritance in IPC
      • Prevents priority inversion during communication
      • Maintains real-time stability even under faults
    6. Health Monitoring (Optional)
      • Watchdogs and supervisors can detect failures and relaunch services

    Adaptive Partitioning in QNX is a CPU resource management mechanism that guarantees each group of threads a minimum percentage of CPU time, while dynamically redistributing unused CPU to other partitions.

    Key Points (Simple)

    • CPU time is divided into partitions
    • Each partition has a guaranteed minimum CPU budget
    • Unused CPU is adaptively shared with others
    • Ensures real-time tasks are never starved

    Why QNX Uses Adaptive Partitioning

    • Prevents CPU starvation
    • Improves system predictability
    • Supports mixed-criticality systems (safety + infotainment)

    Example

    PartitionCPU Guarantee
    Safety tasks40%
    Audio30%
    UI20%
    Background10%
    • If UI uses only 10%, the extra 10% is temporarily used by others
    • When UI needs CPU again, it gets its guaranteed share back

    Where It’s Used

    • Automotive ECUs
    • Medical devices
    • Industrial control systems

    One-Line Interview Answer

    Adaptive partitioning ensures guaranteed CPU bandwidth for critical tasks while efficiently sharing unused CPU among other processes.

    A thread in QNX is the smallest schedulable unit of execution that runs within a process and is scheduled by the microkernel based on priority.

    Key points:

    • Executes code
    • Has its own:
      • Program counter
      • Stack
      • Priority
    • Shares process resources (memory, file descriptors)
    • Scheduled directly by the QNX microkernel

    A process in QNX is a protected container that provides an address space and resources for one or more threads.

    Key points:

    • Owns:
      • Virtual address space
      • File descriptors
      • Signals
      • Permissions
    • Contains one or more threads
    • Provides isolation from other processes

    Relationship (Easy to Remember)

    • Process = container
    • Thread = worker
    Process
     ├── Thread 1 (main thread)
     ├── Thread 2
     └── Thread 3
    

    QNX-Specific Interview Highlight

    • Threads are the real-time scheduling entities, not processes
    • Priority, IPC, and interrupts are all thread-centric

    One-Line Comparison (Interview Gold)

    In QNX, a process provides isolation and resources, while threads are the actual execution units scheduled by the microkernel.

    Thread States in QNX

    In QNX Neutrino, a thread can exist in the following main states:

    1. READY

    • Thread is ready to run
    • Waiting for CPU
    • Placed in a priority-based ready queue

    2. RUNNING

    • Thread is currently executing on the CPU

    3. BLOCKED

    • Thread is waiting for an event or resource

    Common reasons:

    • Waiting for a message (MsgReceive)
    • Waiting for a reply (MsgSend)
    • Waiting for I/O
    • Waiting for a mutex or semaphore
    • Sleeping (nanosleep)

    4. STOPPED

    • Thread execution is suspended

    Causes:

    • Debugger attached
    • Job control signals (e.g. SIGSTOP)
    • Explicit suspension

    5. WAITING (ZOMBIE – process level)

    • Thread has exited
    • Waiting for parent process to collect status

    Note: Zombie is mainly a process concept, but threads can be in a terminated state internally.

    Simple State Diagram (Interview Friendly)

    READY → RUNNING → BLOCKED
      ↑        ↓         |
      └────────┴─────────┘
            STOPPED
    

    Important QNX Interview Points

    • Threads (not processes) are scheduled
    • Scheduling is priority-based and preemptive
    • IPC operations heavily influence BLOCKED states
    • Message passing directly affects thread transitions

    One-Line Interview Answer

    In QNX, threads transition between READY, RUNNING, BLOCKED, and STOPPED states, with scheduling handled at the thread level using priority-based preemption.

    Memory Trick

    Think R-R-B-S:

    • Ready
    • Running
    • Blocked
    • Stopped

    Thread Scheduling Algorithm in QNX

    QNX uses a priority-based, fully preemptive, deterministic thread scheduling algorithm, designed for hard real-time systems.

    Core Characteristics

    1. Priority-Based Scheduling

    • Each thread has a fixed priority
    • Priority range: 0 (lowest) to 255 (highest)
    • Highest-priority READY thread always runs

    2. Fully Preemptive

    • If a higher-priority thread becomes READY:
      • It immediately preempts the currently running thread
    • Ensures fast response for real-time tasks

    3. Round-Robin Within Same Priority

    • Threads with the same priority share CPU time
    • Each gets a time slice
    • Prevents starvation among equal-priority threads

    4. Thread-Centric Scheduling

    • QNX schedules threads, not processes
    • Each thread is an independent scheduling entity

    5. Deterministic Behavior

    • Scheduling decisions are predictable
    • No dynamic priority changes by default
    • Ideal for safety-critical systems

    Scheduling Flow (Simple)

    1. Scheduler checks READY queues (highest → lowest priority)
    2. Picks the highest-priority READY thread
    3. Thread runs until:
      • It blocks
      • Its time slice expires (same-priority case)
      • A higher-priority thread becomes READY

    Priority Inheritance (Very Important)

    • Used during message passing and mutex locking
    • If a high-priority thread is blocked by a lower-priority one:
      • Lower-priority thread temporarily inherits the higher priority
    • Prevents priority inversion

    Comparison with Linux (Interview Highlight)

    FeatureQNXLinux
    SchedulingFixed priorityCFS (dynamic)
    PreemptionAlwaysConfig-dependent
    DeterminismGuaranteedBest-effort
    Priority inheritanceBuilt-inPartial

    One-Line Interview Answer

    QNX uses a priority-based, fully preemptive scheduling algorithm where the highest-priority ready thread always runs, with round-robin scheduling among threads of equal priority and priority inheritance to prevent inversion.

    Conclusion

    QNX is not just another operating system—it is built for environments where reliability, predictability, and safety truly matter. Understanding QNX means understanding how real-time systems behave under pressure, how failures are isolated, and how software can continue running even when individual components crash.

    These interview questions and answers are meant to help you think like a QNX engineer, not just repeat definitions. By focusing on microkernel design, message passing, scheduling, fault tolerance, and system design choices, this content prepares you to explain why QNX works the way it does, not just what it is.

    If you can clearly explain these concepts in your own words during an interview, it shows strong fundamentals, real project exposure, and confidence in system-level thinking—qualities that interviewers look for in embedded and automotive roles.

    Master the concepts, relate them to real use cases, and you won’t just clear a QNX interview—you’ll stand out as someone who truly understands the system.

    FAQ : QNX OS Interview Questions

    1. What is QNX OS?

    QNX is a real-time operating system (RTOS) designed for systems that require high reliability, deterministic performance, and fault tolerance. It is widely used in automotive, medical, industrial, and safety-critical embedded systems.

    2. Why is QNX called a microkernel operating system?

    QNX uses a microkernel architecture, meaning only the most essential services (scheduling, IPC, interrupt handling) run in kernel space. All other services run in user space, improving system stability and fault isolation.

    3. How is QNX different from Linux?

    Linux uses a monolithic kernel, while QNX uses a microkernel. In QNX, drivers and services run in user space and can be restarted if they fail, whereas in Linux, a faulty driver can crash the entire system.

    4. What runs in kernel space in QNX?

    Only critical components run in kernel space:

    • Thread scheduling
    • Inter-process communication (IPC)
    • Interrupt handling
    • Low-level synchronization

    This keeps the kernel small and reliable.

    5. What runs in user space in QNX?

    Most system services run in user space, including:

    • Device drivers
    • File systems
    • Network stacks
    • Resource managers
    • System services

    This design improves fault tolerance.

    6. Why does QNX use message passing?

    QNX uses message passing for IPC to ensure:

    • Deterministic communication
    • Strong process isolation
    • Safer interaction between services
    • Easier debugging and recovery

    It is a core reason for QNX’s reliability.

    7. What is a resource manager in QNX?

    A resource manager is a user-space server that manages system resources like files, devices, or custom interfaces. Applications interact with resource managers using standard POSIX calls such as open(), read(), and write().

    8. What is the role of the microkernel in QNX?

    The microkernel acts as a traffic controller, handling communication, scheduling, and interrupts while letting user-space services do the rest. This separation makes the system robust and scalable.

    9. How does QNX achieve fault tolerance?

    QNX achieves fault tolerance through:

    • Process isolation
    • User-space drivers
    • Automatic service restart
    • Priority-based scheduling

    A failure in one component does not crash the entire system.

    10. What is adaptive partitioning in QNX?

    Adaptive partitioning ensures CPU time is reserved for critical processes. Even if one process misbehaves, real-time and safety-critical tasks continue to run without disruption.

    11. What is a process in QNX?

    A process is an independent program with its own memory space. It may contain one or more threads and communicates with other processes using message passing.

    12. What is a thread in QNX?

    A thread is the smallest unit of execution in QNX. Threads share the same address space within a process but are scheduled independently.

    13. What are the thread states in QNX?

    Common thread states include:

    • Running
    • Ready
    • Blocked (waiting for IPC or resources)
    • Stopped

    These states help manage real-time execution efficiently.

    14. What scheduling algorithm does QNX use?

    QNX uses priority-based preemptive scheduling. Higher-priority threads always run first, ensuring deterministic real-time behavior.

    Read More about Process : What is is Process
    Read More about System Call in Linux : What is System call
    Read More about IPC : What is IPC
  • Master Typed Memory in QNX OS (2026)

    Learn everything about Typed Memory in QNX OS what it is, how it works, and why it’s essential for real-time and embedded systems. Clear, simple

    When you work with QNX OS, especially in embedded or automotive systems, one of the terms you’ll often come across is Typed Memory.
    At first glance, it might sound complex, but once you understand how it works, you’ll realize it’s one of the most elegant solutions QNX provides for memory management in real-time systems.

    Let’s sit down like two engineers over coffee and go step by step to understand Typed Memory — what it is, why it exists, and how you can use it effectively in your next project.

    What Is Typed Memory?

    In simple words, Typed Memory in QNX OS is a named memory region or memory pool that is set aside for a specific purpose.

    Normally, when a program requests memory, it just asks the operating system for any available space from the system heap. But in embedded or real-time environments, we often can’t afford that kind of uncertainty.

    For example:

    • A driver might need a contiguous physical memory block for DMA (Direct Memory Access).
    • A graphics application might need a dedicated memory region for frame buffers.
    • An audio service might want to allocate buffers from a non-cached area to avoid latency.

    In these situations, you use Typed Memory — a mechanism that lets you allocate from predefined, named regions that you control.
    Think of it as saying, “Hey QNX, don’t just give me any memory; give me memory from this specific region.”

    How Typed Memory Works in QNX OS

    QNX divides the system’s physical memory into typed regions, which are described during system startup using an internal table called asinfo (Address Space Information).

    Each region gets a name (for example, /memory/ram/sysram or /memory/dma) and attributes like size, physical address range, and usage type.

    Applications can then access these regions through POSIX APIs designed for typed memory.

    The key functions are:

    • posix_typed_mem_open()
    • mmap()
    • shm_open() and shm_ctl()

    These functions allow your program to open a typed memory region, allocate space from it, and map it into virtual address space.

    Step-by-Step Example

    Let’s understand the workflow through an example.

    Imagine you’re building an embedded system with a QNX-based audio driver. The hardware requires a DMA-safe buffer below 1 GB of memory.

    Here’s how you’d do it using Typed Memory:

    1. Define a Memory Region

    During system startup, the region is defined in the asinfo table:

    as_add_containing(0x30000000, 0x3000FFFF, AS_ATTR_RAM, "dma_buf", "ram");
    

    This tells QNX that a region named "dma_buf" exists at that address range.

    2. Open the Typed Memory Region

    In your code:

    int fd = posix_typed_mem_open("/memory/dma_buf", O_RDWR, POSIX_TYPED_MEM_ALLOCATE_CONTIG);
    

    This opens the region and requests contiguous memory.

    3. Allocate and Map It

    Next, map it into your process:

    void* buffer = mmap(NULL, size, PROT_READ | PROT_WRITE, MAP_SHARED, fd, 0);
    

    4. Use and Release It

    Now buffer points to your DMA-safe memory block.
    When finished, simply:

    munmap(buffer, size);
    close(fd);
    

    Congratulations — you’ve just used Typed Memory the right way!

    Why Typed Memory Matters

    1. Predictable Memory Allocation

    In real-time systems, unpredictable heap allocations can cause performance spikes or failures.
    Typed Memory ensures your application always gets the memory it expects, from the region you’ve defined.

    2. Hardware Compatibility

    Some devices (like DMA engines or GPUs) require memory below certain addresses or physically contiguous memory.
    Typed Memory helps you meet these hardware constraints easily.

    3. Performance Optimization

    By separating system memory from device-specific pools, QNX avoids unnecessary contention and keeps latency low.

    4. System Stability

    Because Typed Memory regions are isolated, a faulty process cannot corrupt memory used by another subsystem.

    5. Better Debugging

    Named regions make it easy to trace memory usage. You know exactly which pool your data lives in.

    Understanding the Flags in Typed Memory

    When calling posix_typed_mem_open(), you can use specific flags to control allocation behavior.

    FlagDescription
    POSIX_TYPED_MEM_ALLOCATEAllocate normally from typed memory
    POSIX_TYPED_MEM_ALLOCATE_CONTIGAllocate physically contiguous memory
    POSIX_TYPED_MEM_MAP_ALLOCATABLEMap without consuming allocation
    SHMCTL_TYMEMUsed with shm_ctl() for shared typed memory

    These flags give developers complete control over how memory behaves in different contexts — from user space applications to device drivers.

    Typed Memory and QNX POSIX APIs

    QNX OS follows POSIX standards closely, and Typed Memory fits perfectly into that philosophy.
    The API posix_typed_mem_open() acts like a specialized version of open() for memory objects.

    You can then use standard POSIX calls like mmap() and shm_open() with Typed Memory descriptors.
    This design makes the system flexible and easy to integrate with existing C/C++ applications.

    Typed Memory vs Regular Memory

    Let’s compare them quickly:

    FeatureRegular MemoryTyped Memory
    Allocation SourceGeneral heapNamed memory region
    Control LevelLimitedFull control
    Suitable for DMANoYes
    Contiguous Physical MemoryNot guaranteedFully supported
    PerformanceMay varyDeterministic
    UsageGeneral-purpose appsReal-time, drivers, graphics, DMA

    So whenever you need deterministic and controlled allocation, Typed Memory is the right choice.

    Common Mistakes Developers Make

    Even though Typed Memory is powerful, a few mistakes can cause headaches:

    1. Wrong naming: Region names must match exactly what’s defined in the startup configuration.
    2. Insufficient permissions: Some memory pools require special privileges.
    3. Over-reserving memory: Don’t allocate more than necessary, or you’ll reduce available heap memory.
    4. Not cleaning up: Always unmap and close file descriptors.
    5. Ignoring physical limits: Ensure the pool actually fits in your device’s memory map.

    Avoid these pitfalls, and your Typed Memory setup will stay rock solid.

    Real-World Use Cases

    Here are some scenarios where Typed Memory shines:

    • Audio Systems: Buffer management for DMA audio streams.
    • Graphics Applications: Framebuffer allocation for displays.
    • Networking: Packet buffer pools in network drivers.
    • Automotive ECUs: Sensor data isolation in safety-critical zones.
    • Industrial Automation: Deterministic buffer access for sensors and actuators.

    In short, any embedded project that needs performance, isolation, and predictability can benefit from Typed Memory in QNX OS.

    Typed Memory for Embedded Developers

    If you’re developing with STM32, Qualcomm, or BeagleBone platforms running QNX, you’ll find Typed Memory especially useful.
    It helps you reserve memory for:

    • Audio and video buffers
    • Shared memory communication
    • Bootloader-reserved regions
    • Custom device driver memory

    The best part? You can configure it right from the QNX startup script, making it flexible across hardware architectures.

    Example 1 : Simple typed memory mapping (posix_typed_mem_open + mmap)

    This example opens a typed memory object (by name) and maps it into the process address space. Use this when the region already exists (defined in asinfo) and you just need to map it.

    /* typed_map.c
     * Simple example: open a typed memory object and mmap it
     * Build on QNX: qcc -Vgcc_ntoarmv7le -o typed_map typed_map.c
     */
    
    #include <stdio.h>
    #include <stdlib.h>
    #include <errno.h>
    #include <string.h>
    #include <fcntl.h>
    #include <unistd.h>
    #include <sys/mman.h>
    #include <sys/types.h>
    
    /* QNX-specific POSIX typed memory API */
    #include <sys/posix_typed_mem.h> /* On QNX this header exposes posix_typed_mem_open */
    
    int main(int argc, char *argv[]) {
        const char *tymem_name = "/memory/dma_buf"; /* change to your typed memory name */
        size_t map_size = 4096; /* example size; match what you expect from the pool */
    
        if (argc >= 2) tymem_name = argv[1];
        if (argc >= 3) map_size = (size_t)atoi(argv[2]);
    
        /* Open typed memory object */
        int tymem_fd = posix_typed_mem_open(tymem_name, O_RDWR, POSIX_TYPED_MEM_MAP_ALLOCATABLE);
        if (tymem_fd < 0) {
            fprintf(stderr, "posix_typed_mem_open(%s) failed: %s\n", tymem_name, strerror(errno));
            return 1;
        }
    
        /* Map typed memory */
        void *addr = mmap(NULL, map_size, PROT_READ | PROT_WRITE, MAP_SHARED, tymem_fd, 0);
        if (addr == MAP_FAILED) {
            fprintf(stderr, "mmap failed: %s\n", strerror(errno));
            close(tymem_fd);
            return 1;
        }
    
        printf("Mapped typed memory '%s' (%zu bytes) at %p\n", tymem_name, map_size, addr);
    
        /* Example: write/read a few bytes */
        memset(addr, 0xA5, map_size < 64 ? map_size : 64);
        printf("Wrote pattern to mapped region (first 16 bytes):\n");
        for (size_t i = 0; i < 16 && i < map_size; ++i) {
            printf("%02X ", ((unsigned char*)addr)[i]);
        }
        printf("\n");
    
        /* Cleanup */
        munmap(addr, map_size);
        close(tymem_fd);
        return 0;
    }
    

    How to run:

    • Compile: qcc -o typed_map typed_map.c (or gcc on QNX if configured)
    • Run: ./typed_map /memory/dma_buf 8192
    • Notes: Replace /memory/dma_buf with the typed memory name defined in your system asinfo. POSIX_TYPED_MEM_MAP_ALLOCATABLE maps without consuming allocatable capacity.

    Example 2 : Allocate typed memory via shm_open + shm_ctl (contiguous allocation for DMA)

    This example requests allocation from a typed memory region (useful when you need the kernel to allocate memory from the typed pool and return a shm descriptor you can map). This is commonly used when you want the typed memory allocation to be backed by the system and accessible by multiple processes.

    /* typed_shm_alloc.c
     * Example: allocate typed memory using shm_open + shm_ctl
     * Build on QNX: qcc -o typed_shm_alloc typed_shm_alloc.c
     */
    
    #include <stdio.h>
    #include <stdlib.h>
    #include <errno.h>
    #include <string.h>
    #include <fcntl.h>
    #include <unistd.h>
    #include <sys/mman.h>
    #include <sys/stat.h>
    #include <sys/types.h>
    #include <sys/shm.h>
    #include <sys/posix_typed_mem.h> /* posix_typed_mem_open */
    #include <sys/shm.h>             /* shm_open, shm_unlink */
    #include <sys/neutrino.h>        /* platform-specific constants if needed */
    
    /* Some QNX systems expect SHMCTL_* macros in <sys/shm.h> or another header.
     * If your platform's header differs, include the appropriate one.
     */
    
    int main(int argc, char *argv[]) {
        const char *tymem_name = "/memory/dma_buf"; /* typed memory pool name */
        size_t size = 64 * 1024; /* 64 KB example */
        int tymem_fd = -1, anon_shm_fd = -1;
        void *addr = MAP_FAILED;
        char shm_name[64];
    
        if (argc >= 2) tymem_name = argv[1];
        if (argc >= 3) size = (size_t)atoi(argv[2]);
    
        /* 1) Open typed memory */
        tymem_fd = posix_typed_mem_open(tymem_name, O_RDWR, POSIX_TYPED_MEM_ALLOCATE_CONTIG);
        if (tymem_fd < 0) {
            fprintf(stderr, "posix_typed_mem_open failed: %s\n", strerror(errno));
            return 1;
        }
    
        /* 2) Create anonymous shared memory object */
        snprintf(shm_name, sizeof(shm_name), "/tymem_shm_%d", getpid());
        anon_shm_fd = shm_open(shm_name, O_RDWR | O_CREAT | O_EXCL, S_IRUSR | S_IWUSR);
        if (anon_shm_fd < 0) {
            fprintf(stderr, "shm_open(%s) failed: %s\n", shm_name, strerror(errno));
            close(tymem_fd);
            return 1;
        }
    
        /* 3) Use shm_ctl to allocate from typed memory.
         * Note: SHMCTL_TYMEM and SHMCTL_ANON constants are QNX-specific.
         * The call below demonstrates intent; ensure your headers provide these macros.
         */
    #ifdef SHMCTL_TYMEM
        if (shm_ctl(anon_shm_fd, SHMCTL_ANON | SHMCTL_TYMEM, tymem_fd, size) < 0) {
            fprintf(stderr, "shm_ctl(SHMCTL_TYMEM) failed: %s\n", strerror(errno));
            shm_unlink(shm_name);
            close(anon_shm_fd);
            close(tymem_fd);
            return 1;
        }
    #else
        /* If your platform uses a different API, replace with the correct shm_ctl invocation */
        fprintf(stderr, "SHMCTL_TYMEM not defined on this platform header. Please check QNX headers.\n");
        shm_unlink(shm_name);
        close(anon_shm_fd);
        close(tymem_fd);
        return 1;
    #endif
    
        /* 4) Map the allocated shared memory into the process */
        addr = mmap(NULL, size, PROT_READ | PROT_WRITE, MAP_SHARED, anon_shm_fd, 0);
        if (addr == MAP_FAILED) {
            fprintf(stderr, "mmap on shm fd failed: %s\n", strerror(errno));
            shm_unlink(shm_name);
            close(anon_shm_fd);
            close(tymem_fd);
            return 1;
        }
    
        printf("Allocated %zu bytes from typed memory '%s' and mapped at %p\n", size, tymem_name, addr);
    
        /* Example write */
        memset(addr, 0x5A, size < 64 ? size : 64);
        printf("Wrote sample bytes (first 16 bytes): ");
        for (int i = 0; i < 16 && i < (int)size; ++i) {
            printf("%02X ", ((unsigned char*)addr)[i]);
        }
        printf("\n");
    
        /* Cleanup */
        munmap(addr, size);
        shm_unlink(shm_name);
        close(anon_shm_fd);
        close(tymem_fd);
        return 0;
    }
    

    How to run:

    • Compile: qcc -o typed_shm_alloc typed_shm_alloc.c
    • Run: ./typed_shm_alloc /memory/dma_buf 65536
    • Notes:
      • POSIX_TYPED_MEM_ALLOCATE_CONTIG requests contiguous allocation; useful for DMA.
      • SHMCTL_TYMEM / SHMCTL_ANON are QNX-specific macros — ensure your QNX SDK provides them and include the proper headers.
      • If SHMCTL_TYMEM is unavailable on your target, consult the platform manuals for the correct shm_ctl() invocation or use posix_typed_mem_open() + mmap() approach instead.

    Explanations & Best Practices

    • These examples show two common ways to use Typed Memory in QNX OS: direct mapping and typed allocation via shared memory.
    • Use direct mapping (posix_typed_mem_open + mmap) when the region is defined and you only need mapping access.
    • Use shm_open() + shm_ctl(... SHMCTL_TYMEM ...) when you want allocation semantics or to share the allocated memory between processes.
    • For DMA or driver use, prefer POSIX_TYPED_MEM_ALLOCATE_CONTIG to request physically contiguous memory from the Typed Memory pool.
    • Always match the typed memory region name exactly to the name defined in your asinfo / startup configuration.
    • Clean up: munmap(), close() typed mem fd, shm_unlink() for anonymous shared memory to avoid leaks.
    • Test boot-time asinfo configuration and validate with /proc/typedmem (or platform-specific tools) to see pools and usage.

    Compile & Run Checklist (QNX)

    1. Make sure QNX development headers and libraries are installed and your environment is set up (PATH, QNX_TARGET, etc.).
    2. Compile with the QNX compiler: qcc -o typed_map typed_map.c or qcc -o typed_shm_alloc typed_shm_alloc.c.
    3. Run on a QNX system image where the typed memory region (e.g., /memory/dma_buf) is defined.
    4. If you get ENODEV/EINVAL/EACCES from posix_typed_mem_open, check:
      • The typed memory name exists in asinfo.
      • Permissions (maybe root or specific capabilities needed).
      • Whether contiguous memory requests are satisfiable given system fragmentation.

    Advantages, Disadvantages, and Real-Time Applications of Typed Memory in QNX OS

    Let’s talk about why Typed Memory in QNX OS matters, what it gives you, what it costs, and where it shines in the real world. Think of it like a friend explaining why this feature is both powerful and occasionally picky.

    Advantages of Typed Memory in QNX OS

    1. Predictable Memory Access
      • The biggest advantage of Typed Memory in QNX OS is predictability. You know exactly where your memory comes from and what it’s meant for.
      • In real-time systems, this predictability helps ensure tasks meet strict timing deadlines.
    2. Improved Performance
      • By allocating memory directly from predefined regions (like DMA or fast RAM), Typed Memory in QNX OS reduces latency and avoids unnecessary copying.
      • Drivers and hardware components can access data faster, leading to smoother performance.
    3. Enhanced Security
      • Typed Memory isolates memory spaces, preventing regular applications from accidentally or maliciously touching hardware-specific memory.
      • This adds a strong layer of protection, especially in automotive and safety-critical systems.
    4. Fine-Grained Memory Control
      • Developers can define custom memory pools for specific purposes — for example, /memory/audio_buf for sound processing and /memory/video_buf for frame buffers.
      • This level of control gives embedded engineers the precision they love.
    5. Better Resource Management
      • Because each memory type has a defined purpose, Typed Memory in QNX OS helps prevent fragmentation and resource conflicts between system components.
    6. Deterministic Behavior
      • In real-time applications, you don’t want surprises. Typed memory ensures deterministic allocation and mapping, helping systems behave the same way every time.

    Disadvantages of Typed Memory in QNX OS

    1. Complex Configuration
      • You need to predefine memory regions in the system startup file or BSP (Board Support Package).
      • For beginners, setting up Typed Memory in QNX OS can feel tricky since it involves editing low-level configuration files like asinfo.
    2. Limited Flexibility
      • Once memory pools are defined, resizing them on the fly isn’t easy. If one pool runs out, the OS can’t automatically borrow space from another pool.
    3. Risk of Allocation Failure
      • If a process requests more memory than available in a specific typed region, the allocation fails — even if other system memory is free.
      • That’s why careful planning of pool sizes is critical.
    4. Steeper Learning Curve
      • Understanding how Typed Memory in QNX OS interacts with mmap(), posix_typed_mem_open(), and hardware drivers requires deeper OS knowledge.
      • Developers new to QNX may need extra time to get comfortable.
    5. Potential for Fragmentation
      • If memory pools are poorly configured or heavily fragmented, allocations might fail even when total free memory looks sufficient.

    Real-Time Applications of Typed Memory in QNX OS

    Here’s where Typed Memory in QNX OS truly shines — in real, production-grade embedded and automotive systems.

    1. Automotive Infotainment Systems
      • In car systems, audio and video processing demand predictable and fast access to memory buffers.
      • Typed Memory ensures audio playback or navigation rendering doesn’t lag due to shared resource contention.
    2. Industrial Automation
      • Machines using sensors, cameras, and controllers depend on real-time communication.
      • By assigning specific typed memory for DMA or shared buffers, QNX keeps control loops running smoothly.
    3. Medical Devices
      • Devices like imaging systems and patient monitors rely on Typed Memory in QNX OS to manage memory for sensor data and graphical displays safely.
    4. Aerospace and Defense
      • Safety-critical systems in aircraft or defense equipment require deterministic memory allocation to guarantee real-time response under load.
      • Typed Memory helps meet these hard real-time constraints.
    5. Audio and Multimedia Systems
      • Whether it’s sound processing, video capture, or playback, Typed Memory in QNX OS ensures each media component gets the right memory space for real-time performance.
    6. Networking and Communication
      • In routers or gateways built on QNX, Typed Memory is used to manage packet buffers, reducing latency in data transmission.

    Why Typed Memory Matters in Embedded Systems

    Think of Typed Memory in QNX OS as a disciplined traffic system for data.
    It keeps every process in its lane — fast tasks on fast lanes (like DMA memory) and regular tasks on standard lanes (general memory).
    That’s what makes QNX a favorite in industries where failure or delay is simply not an option.

    FeatureAdvantageReal-World Impact
    PredictabilityFixed memory regionsReal-time performance
    SecurityControlled accessSafe and stable operation
    SpeedFaster DMA / I/O accessLow latency
    ControlCustom pool creationOptimized resource usage
    ReliabilityNo random memory interferenceDeterministic system behavior

    Quick Recap of Typed Memory in QNX OS

    Let’s wrap up what we’ve learned:

    • Typed Memory is a named memory region defined at system startup.
    • It gives developers predictable, controllable, and deterministic memory allocation.
    • It’s ideal for DMA buffers, device drivers, and real-time processes.
    • APIs like posix_typed_mem_open() and mmap() let you use it easily.
    • With proper setup, Typed Memory boosts performance, reliability, and system stability.

    Once you start using Typed Memory, you’ll never want to go back to random heap allocations for time-critical tasks.

    Frequently Asked Questions (FAQ) about Typed Memory in QNX OS

    1. What is Typed Memory in QNX OS?

    Typed memory in QNX OS is a feature that lets developers categorize or “type” regions of physical memory so that only certain processes or drivers can use them. It ensures that specific hardware components or applications get access to the exact kind of memory they need — for example, DMA buffers, shared video memory, or reserved hardware regions. This makes typed memory in QNX OS a key part of efficient memory management.

    2. Why is Typed Memory important in real-time systems like QNX

    In a real-time operating system (RTOS) like QNX, timing is everything. Typed memory helps ensure that real-time tasks get access to predictable and fast memory blocks. It reduces memory contention between processes and improves system stability. In short, typed memory in QNX OS ensures that critical services never starve for the right memory type.

    3. How does Typed Memory differ from regular memory allocation?

    Regular memory allocation (like malloc() or mmap()) doesn’t care about the physical memory’s nature — it just gives you space. But typed memory in QNX OS allows fine-grained control. You can request specific memory types such as non-cached, DMA, or shared memory. This distinction helps embedded developers ensure performance and reliability.

    4. How do you allocate Typed Memory in QNX?

    You allocate typed memory in QNX OS using the posix_typed_mem_open() and mmap() functions.
    Here’s a simple example:

    int fd = posix_typed_mem_open("/memory/dma", O_RDWR, POSIX_TYPED_MEM_ALLOCATE);
    void* ptr = mmap(NULL, size, PROT_READ | PROT_WRITE, MAP_SHARED, fd, 0);
    

    This code requests a DMA memory region. The kernel ensures that this memory comes from the pool labeled “/memory/dma.”

    5. What are common use cases of Typed Memory?

    Some popular use cases for typed memory in QNX OS include:

    • Buffer allocation for audio and video drivers
    • Memory for network packets or DMA transfers
    • Isolating memory for real-time tasks
    • Providing secure regions for shared memory communication
      Each use case benefits from deterministic access and security.

    6. Can users create their own Typed Memory regions?

    Yes. Developers can define custom typed memory regions in QNX OS by editing the system’s startup script or using the BSP (Board Support Package) configuration. You can define names like /memory/fast or /memory/secure and map them to specific physical addresses. This gives developers complete control over how the OS manages memory layout.

    7. What happens if Typed Memory is exhausted?

    When typed memory in QNX OS is fully used, new allocation requests from that type fail, even if free memory exists elsewhere. That’s why memory planning is essential. Developers must ensure enough space for each memory pool based on expected workloads.

    8. How does Typed Memory improve system security?

    Typed memory enhances security by restricting who can access what kind of memory. For instance, only a driver can open /memory/dma, while applications use general memory. This prevents accidental or malicious access to sensitive physical regions — an important feature for embedded and automotive systems.

    9. Is Typed Memory available in all QNX versions?

    Typed memory support was introduced in QNX Neutrino 6.3 and remains a core part of modern QNX OS versions, including QNX SDP 7.x. The APIs and naming conventions may differ slightly, but the core idea — tagged and restricted memory pools — remains the same.

    10. How to check available Typed Memory regions in QNX OS?

    You can check available typed memory in QNX OS using:

    ls /proc/typedmem
    

    This command lists all the defined memory pools, their names, and properties. You can also inspect the /proc filesystem for usage statistics.

    11. How does Typed Memory help in embedded audio or video systems?

    In multimedia systems, typed memory in QNX OS ensures audio and video buffers are placed in the right physical memory for fast access. This prevents jitter or delay in playback, improving the real-time performance of the system.

    12. Can Typed Memory be shared between processes?

    Yes, typed memory in QNX OS can be shared using shared memory mechanisms. Multiple processes can map the same memory region for fast inter-process communication (IPC) without copying data back and forth.

    13. What tools help analyze Typed Memory usage?

    Developers can use pidin mem and /proc interfaces to monitor memory consumption. These tools show how much typed memory in QNX OS each process consumes and help identify memory bottlenecks.

    14. What are the limitations of Typed Memory in QNX?

    While typed memory in QNX OS provides precision and security, it requires careful planning. Each pool has a fixed size, and incorrect configuration can lead to memory fragmentation or failed allocations. Also, too many custom types can complicate debugging.

    15. How does Typed Memory support deterministic behavior?

    Deterministic behavior means predictable response time — vital in automotive, aerospace, and industrial systems. Typed memory in QNX OS ensures specific tasks always get their reserved memory, removing uncertainty caused by dynamic allocation delays.

  • Heap Analysis : Top 10 Powerful Insights in QNX OS

    Learn Heap Analysis in QNX OS step-by-step. Understand memory leaks, allocation patterns, and debugging methods optimize embedded system

    When you write code on QNX OS and use dynamic memory (via malloc(), new, etc), you’re dealing with the heap. Doing heap analysis means inspecting how your program allocates memory, how it frees memory, how the heap grows or shrinks, and whether there are leaks or corruptions.

    In a QNX OS environment, heap analysis becomes especially important because many projects are embedded or real-time: they have constrained memory, high reliability demands, and the heap must behave well. If you skip heap analysis, you risk memory leaks, heap corruption, fragmentation, or unexpected crashes.

    Why heap analysis matters on QNX OS

    • The heap may grow over time if allocations aren’t freed; doing heap analysis helps you spot the steady growth.
    • Heap corruption (writing past the allocated block or freeing wrong pointers) is tricky in multithreaded embedded systems; good heap analysis helps reveal the source.
    • Fragmentation: many small blocks allocated/freed can leave the heap inefficient; heap analysis lets you track patterns.
    • QNX OS provides tools (like the debug allocation library librcheck, heap tracking APIs) that make heap analysis manageable. (qnx.com)

    How QNX OS manages the heap

    Understanding how the heap works under QNX OS helps your heap analysis be meaningful:

    • In QNX OS, processes have virtual address spaces which include program text, stacks, shared libraries, objects, and the heap. (qnx.com)
    • The heap is dynamic memory allocated at runtime (via malloc(), calloc(), realloc(), or C++ new) and maintained by the allocator. (qnx.com)
    • The allocator works with “arenas” or chunks of memory, divides them into small/large-block pools, manages free lists. In QNX OS: “heap memory represents the dynamic memory used by programs at runtime.” (qnx.com)
    • Because of this internal logic, doing heap analysis means you must look at allocation patterns, sizes, free events, fragmentation, and the allocator’s behaviour.

    A step-by-step recipe for heap analysis on QNX OS

    Here’s a practical flow you can follow (and reuse) for heap analysis in your embedded or real-time project on QNX OS:

    Step 1: Establish a baseline

    Start your application under representative load and measure how the heap grows and shrinks. Use QNX Momentics IDE or whatever tooling you have. For heap analysis, note things like: maximum heap size, steady state size, peaks, free after heavy load, etc.

    Step 2: Enable detailed heap tracking

    Activate tools for deeper heap analysis:

    • In QNX OS you can use the Memory Analysis tool (part of the IDE) which uses librcheck to track allocation/free events, detect heap corruption. (qnx.com)
    • Launch your program with Memory Analysis mode: the tool reads data from librcheck and displays graphs and event info for allocations/deallocations. (qnx.com)
    • You can also use the libc allocator API to query current heap statistics programmatically for heap analysis. (qnx.com)

    Step 3: Profile and drill down

    Once you have tracking, you can identify which functions or modules are heavy in memory allocation or failing to free memory. For heap analysis you might:

    • Use the Application Profiler tool to break down heap usage per function. (qnx.com)
    • Track over time: how many blocks allocated, size distribution, free vs still allocated.
    • Look for patterns: e.g., after each cycle of some task the heap size goes up and doesn’t come down — that’s a red flag.

    Step 4: Interpret results and fix the issues

    With data from your heap analysis, you can act:

    • If heap usage increases steadily without drop → likely memory leak.
    • If there’s heavy allocation/frees causing fragmentation → consider using memory pooling or reuse buffers.
    • If you detect heap corruption (via librcheck or via crash in allocator) → trace back to wrong free, buffer overrun, interior pointer free. QNX OS doc says heap corruption is especially hard in multithreaded programs. (qnx.com)
    • After fixes, rerun the heap analysis to verify improvements: heap growth stabilises, allocations reduce, fragmentation less.

    Step 5: Automate and integrate

    Make heap analysis part of your test cycle:

    • On every build or major change, run automated test suites with heap tracking enabled.
    • Use baseline vs current comparison: has heap footprint grown? Are there new alloc/free hotspots?
    • For embedded systems using QNX OS, running on target hardware is key—behavior might differ from desktop simulation.

    Best practices for heap analysis in QNX OS

    Here are some helpful tips to keep your heap analysis efficient and effective:

    • Start early: do your first heap analysis when system is working but before heavy feature addition.
    • Get good test coverage: long-running test loops simulate embedded use; memory issues often show after many cycles.
    • Watch multi-threaded allocations: in QNX OS threads share heap space, so one thread’s corruption may show up elsewhere. Good heap analysis must consider thread interactions.
    • Look beyond totals: heap size alone isn’t enough; track fragmentation, size distribution, free vs still allocated blocks.
    • Keep an eye on allocator behaviour: in QNX OS, the allocator uses arenas and may return memory to OS only under certain conditions. Understanding that allows smarter heap analysis. (qnx.com)
    • Document your baseline heap behaviour: for a given system version/hardware, record normal heap usage so deviations are obvious.
    • Use tooling effectively: QNX Momentics IDE, Memory Analysis tool, librcheck, libc allocator API — these empower your heap analysis.
    • Tie your heap analysis to reliability: in an embedded or real-time system, memory behaviour isn’t just performance—it’s safety, uptime, predictable behaviour.

    Real-world scenario (coffee-chat style)

    Imagine you’re working on a QNX OS-based data acquisition system that runs 24/7. You allocate buffers for sensor data, you occasionally free them, you log to flash or send over network. Everything seems fine until after 30 days you see the system slow down or crash due to memory. You pull up your heap analysis logs and notice that after each hour, heap usage creeps up by 5 MB and never drops. Profiling shows that your buffer pool isn’t freed in one error path. You fix the leak, rerun the system, and heap analysis now shows stable heap usage. Crisis averted.

    That is the power of proactive heap analysis on QNX OS.

    QNX OS Heap Analysis Cheat Sheet

    Step 1: Understand What Heap Analysis Really Is

    Before running tools, know this:
    The heap is where dynamic memory (malloc(), calloc(), new) lives. Doing heap analysis means understanding how your program uses that space over time — what gets allocated, what never gets freed, and how heap growth affects your embedded system running QNX OS.

    Skipping heap analysis means ignoring silent memory leaks that can crash your application hours or days later.

    Step 2: Build Your Application in Debug Mode

    To use heap debugging tools, compile your project with debug information enabled:

    qcc -g -o myapp myapp.c
    

    The -g flag ensures you get symbol information that heap analysis tools like Momentics IDE can use to map allocations back to source code.

    Step 3: Link Against the Heap Debug Library (librcheck)

    QNX OS offers a special runtime library to track heap behavior: librcheck.so.
    It replaces standard malloc() and free() calls with debug versions that log allocations, sizes, call stacks, and invalid frees.

    To link with it, use:

    qcc -o myapp myapp.c -lrcheck
    

    Now when your app runs, every allocation is recorded — ideal for heap analysis.

    Step 4: Launch Memory Analysis Tool in QNX Momentics IDE

    1. Open QNX Momentics IDE.
    2. Go to: Run → Run Configurations → Memory Analysis
    3. Select your project.
    4. Under Profile Options, enable:
      • “Monitor Memory Allocation and Free Events”
      • “Track heap over time”
      • “Use librcheck for heap validation”
    5. Run the application on your QNX target.

    This step starts real-time heap analysis. The IDE will now record all heap events from your running program.

    Step 5: Interpret Heap Graphs

    Once your app runs, you’ll see graphs showing:

    • Heap size vs. time – checks if memory grows continuously (memory leak).
    • Allocation/Free events – identify imbalance between malloc/free calls.
    • Live allocations – total blocks still in use.
    • Fragmentation level – how scattered free memory blocks are.

    Pro tip: If your heap usage keeps increasing while workload stays constant, it’s a clear memory leak — fix it before production!

    Step 6: Perform Manual Heap Analysis via Command Line

    If you prefer CLI (or no GUI available), QNX provides similar functionality via the librcheck library.

    Example:

    export MALLOC_DEBUG=1
    ./myapp
    

    This enables runtime heap debugging even without the IDE.
    Output can be redirected to a log file for post-analysis.

    You can also use:

    export MALLOC_CHECK_=3
    

    This helps detect heap corruption and double frees.

    Use grep or awk to analyze logs for allocation patterns — a simple yet powerful heap analysis method for embedded builds.

    Step 7: Identify and Fix Problems

    When you spot memory leaks or suspicious patterns from heap analysis, trace them back:

    Common causes include:

    • Allocations inside loops not freed.
    • Mismatched new/delete or malloc()/free().
    • Missing frees on error paths.
    • Large heap fragmentation due to frequent variable-sized allocations.

    Fixing these improves both heap performance and system stability on QNX OS.

    Step 8: Automate Heap Analysis for Regression Testing

    You can script heap tests as part of your CI pipeline.

    Example script outline:

    #!/bin/sh
    export MALLOC_DEBUG=1
    ./myapp > heap_log.txt
    grep "leak" heap_log.txt
    

    Use it during nightly builds — if new leaks appear, your test fails.
    That’s continuous heap analysis done right for QNX OS.

    Step 9: Validate with Application Profiler

    After fixing leaks, use QNX Application Profiler to ensure your heap usage stabilizes.

    Steps:

    1. Open the Application Profiler view in Momentics.
    2. Record a session while your app runs.
    3. Filter by Heap Memory Events.
    4. Sort by “Allocated Bytes” — you’ll see which functions use most heap.

    Cross-check results with your heap analysis graphs to ensure consistency.

    Step 10: Best Practices for Continuous Heap Health

    Always test on the actual embedded target, not just simulator.
    Keep heap allocations predictable — use pools for fixed-size buffers.
    Never ignore small leaks; they accumulate in long uptime systems.
    Document normal heap usage baselines for every release.
    Run heap analysis after every major code change.

    Doing heap analysis in QNX OS is like giving your application a health checkup. It ensures that memory usage is clean, stable, and predictable — especially in real-time or automotive systems where crashes are unacceptable.

    By combining tools like librcheck, Momentics IDE Memory Analysis, and Application Profiler, you can visualize, detect, and fix memory problems before they reach the field.

    The goal isn’t just leak-free code — it’s confidence in your embedded software’s reliability.

    StepTool / CommandPurpose
    1qcc -gCompile with debug info
    2-lrcheckEnable heap tracking
    3Momentics IDEVisual heap analysis
    4MALLOC_DEBUGCLI heap tracing
    5Application ProfilerFunction-level memory insights
    6Automated ScriptRegression leak detection

    Quick summary

    • Heap analysis means tracking dynamic memory usage: allocations, frees, growth, fragmentation, corruption.
    • On QNX OS it’s critical because of embedded constraints, multi-threading, reliability demands.
    • Understand how QNX OS’s allocator and heap system work (arenas, free lists, small/large blocks) to make your heap analysis meaningful.
    • Use tools: Memory Analysis (with librcheck), Application Profiler, libc allocator API for data collection.
    • Interpret the data and take action: fix leaks, reduce fragmentation, stabilise heap size, ensure robustness.
    • Make heap analysis part of your development/test cycle; document baseline; monitor changes.
  • Master QNX OS and Hypervisor Most Asked Interview Questions (2026)

    QNX OS Most Asked Interview Questions explained in a simple and beginner-friendly way. Learn about microkernel, message passing, scheduling, memory management, and debugging in QNX OS to prepare for your next embedded systems interview.

    If you are preparing for an interview where QNX OS is involved, you are in the right place. QNX (Quick UNIX) is a real-time operating system (RTOS) widely used in automotive, medical devices, industrial systems, and embedded applications. Many companies test candidates on their understanding of QNX fundamentals, process management, memory handling, and inter-process communication.

    This article will walk you through the most asked QNX interview questions with simple explanations so you can build confidence for your next interview.

    Master QNX OS Most Asked Interview Questions

    1. What is QNX OS?

    QNX is a microkernel-based real-time operating system designed for reliability and deterministic performance. Unlike monolithic kernels, QNX uses a microkernel that handles only essential functions like scheduling, message passing, and interrupt handling, while other services run as user-space processes.

    Why it matters in interviews?
    Interviewers want to know if you understand the core concept of microkernel vs monolithic kernel, because this is the foundation of QNX.

    2. What makes QNX different from other RTOS?

    • Microkernel design (high reliability, modularity).
    • Message passing architecture (efficient inter-process communication).
    • Deterministic response time (critical in automotive and medical systems).
    • POSIX compliance (developers can use familiar APIs).

    Tip: Be ready to compare QNX with Linux or VxWorks in your interview.

    3. Explain QNX Microkernel Architecture

    QNX runs only the microkernel in privileged mode, while everything else (drivers, file systems, services) runs in user mode.

    • This makes the system fault-tolerant – if one driver crashes, it doesn’t bring down the whole system.
    • Communication happens through message passing between processes.

    Beginner way to answer:
    Think of QNX like a city: the microkernel is the traffic controller, while drivers, applications, and services are like cars following rules.

    4. What is Message Passing in QNX?

    Message passing is the heart of QNX IPC (Inter-Process Communication).

    • Processes communicate using Send, Receive, and Reply (SRR) calls.
    • It ensures synchronous, safe communication without shared memory conflicts.

    Example Interview Point:
    If asked about performance, mention that message passing avoids race conditions and makes QNX highly predictable.

    5. How does Scheduling work in QNX?

    QNX uses priority-based preemptive scheduling.

    • The highest-priority ready thread always runs.
    • Supports round-robin among equal-priority threads.
    • Ideal for real-time systems where deadlines matter.

    Tip for Interviews: Always highlight deterministic response time.

    6. How is Memory Managed in QNX?

    • QNX supports protected virtual memory.
    • Each process has its own address space.
    • Memory faults in one process don’t affect others.

    This is a key difference from smaller RTOS that often lack memory protection.

    7. What are some common use cases of QNX?

    • Automotive infotainment and ADAS systems.
    • Industrial automation.
    • Medical devices.
    • Aerospace and defense applications.

    Why this question matters?
    Interviewers want to check if you know where QNX is actually used in the real world.

    8. How do you debug in QNX?

    • Using QNX Momentics IDE (based on Eclipse).
    • With tools like pidin, sloginfo, and tracelogger.
    • Remote debugging over target hardware.

    Beginner-friendly answer:
    Say you use pidin to check running processes, sloginfo to read system logs, and the IDE for step-by-step debugging.

    9. QNX vs Linux – Which is better for real-time?

    • QNX → More predictable, deterministic, lightweight.
    • Linux RT patches → Can achieve real-time, but not as reliable in critical systems.

    10. Why do Automotive Companies prefer QNX?

    • ISO 26262 safety certification.
    • High reliability in infotainment, ADAS, and digital clusters.
    • Fault isolation (one failing component doesn’t crash the system).

    All Possible QNX OS Interview Questions

    QNX Fundamentals (Beginner)

    1. What is QNX?
    2. Is QNX a real-time operating system?
    3. What type of kernel does QNX use?
    4. What does “microkernel” mean?
    5. Why is QNX considered a microkernel OS?
    6. What are the main features of QNX?
    7. Where is QNX commonly used?
    8. What is the difference between QNX and Linux?
    9. Is QNX POSIX compliant?
    10. What does POSIX compliance mean?
    11. Who develops QNX?
    12. What is Neutrino in QNX?
    13. Is QNX open source?
    14. What languages are supported in QNX?
    15. What hardware architectures does QNX support?
    16. What is real-time behavior?
    17. What is hard real-time vs soft real-time?
    18. Why is determinism important in QNX?
    19. What is latency?
    20. What is jitter?

    QNX Architecture & Microkernel

    1. What components run inside the QNX microkernel?
    2. What runs outside the microkernel in QNX?
    3. Why are drivers outside the kernel in QNX?
    4. How does microkernel improve reliability?
    5. How does QNX achieve fault isolation?
    6. What is a user-space driver?
    7. What happens if a driver crashes in QNX?
    8. How is IPC handled in QNX?
    9. What is the role of the QNX microkernel scheduler?
    10. What kernel services are provided by QNX?
    11. Compare monolithic kernel vs microkernel
    12. What are the advantages of QNX microkernel?
    13. What are the disadvantages of microkernel?
    14. How does QNX reduce IPC overhead?
    15. What is message passing?

    QNX Boot Process

    1. Explain the QNX boot sequence
    2. What is IPL (Initial Program Loader)?
    3. What is startup code in QNX?
    4. What is procnto?
    5. What does procnto do?
    6. What is the role of the bootstrap loader?
    7. What is the system page (syspage)?
    8. What information is stored in syspage?
    9. What is the difference between startup and procnto?
    10. What happens after procnto starts?
    11. What is the first user process in QNX?
    12. How are drivers started during boot?
    13. What is buildfile?
    14. What is a QNX image?
    15. How do you customize QNX boot image?

    QNX Processes & Threads

    1. What is a process in QNX?
    2. What is a thread?
    3. Difference between process and thread in QNX
    4. Does QNX support multi-threading?
    5. What is a thread ID (TID)?
    6. What is a process ID (PID)?
    7. How many threads can a process have?
    8. What is thread scheduling?
    9. What is preemptive scheduling?
    10. How does QNX handle context switching?
    11. What is thread state?
    12. What is thread priority?
    13. What is priority inversion?
    14. How does QNX handle priority inversion?
    15. What is priority inheritance?
    16. What is priority ceiling?

    QNX Scheduling

    1. What scheduling policies does QNX support?
    2. What is SCHED_FIFO?
    3. What is SCHED_RR?
    4. What is SCHED_OTHER?
    5. Difference between FIFO and Round Robin
    6. What is time slicing?
    7. What is quantum?
    8. What happens when two threads have same priority?
    9. Can a lower priority thread preempt a higher one?
    10. How do interrupts affect scheduling?
    11. What is CPU affinity?
    12. Does QNX support SMP?
    13. How does QNX schedule threads on multi-core systems?
    14. What is adaptive partition scheduling (APS)?

    QNX Inter-Process Communication (IPC)

    1. What IPC mechanisms does QNX use?
    2. What is message passing in QNX?
    3. What is MsgSend?
    4. What is MsgReceive?
    5. What is MsgReply?
    6. Why is message passing synchronous?
    7. What is a channel?
    8. What is a connection?
    9. Difference between channel and connection
    10. What happens if MsgSend blocks?
    11. What is pulse in QNX?
    12. What is a pulse used for?
    13. Difference between pulse and message
    14. What is sigevent?
    15. How are signals used in QNX?
    16. Difference between signals and pulses
    17. What is shared memory?
    18. When to use shared memory vs message passing?
    19. What synchronization mechanisms are used?
    20. What are mutexes and semaphores in QNX?

    QNX Resource Manager (Very Important)

    1. What is a resource manager?
    2. Why does QNX use resource managers?
    3. What is the pathname space in QNX?
    4. How does QNX handle files and devices uniformly?
    5. What is io_open?
    6. What is io_read?
    7. What is io_write?
    8. What is io_devctl?
    9. What is dispatch layer?
    10. What is resmgr_attach?
    11. What is iofunc?
    12. What is ocb (Open Control Block)?
    13. What is attr structure?
    14. How do permissions work in resource managers?
    15. How does QNX handle /dev entries?
    16. Difference between character and block devices
    17. How to create a custom device driver?
    18. How does read/write flow work internally?
    19. What happens when a process opens a device?
    20. How does QNX handle blocking I/O?

    QNX File System

    1. What file systems does QNX support?
    2. What is QNX6 file system?
    3. What is ETFS?
    4. What is flash file system?
    5. Difference between QNX6 and ext4
    6. What is mount?
    7. What is umount?
    8. What is inode?
    9. What is a file descriptor?
    10. How does QNX handle file permissions?
    11. What is virtual file system (VFS)?
    12. How are file systems implemented in QNX?
    13. How does QNX handle wear leveling?
    14. What is fs-qnx6?
    15. What happens if file system crashes?

    QNX Drivers & BSP

    1. What is a BSP in QNX?
    2. What does a BSP contain?
    3. What is startup code in BSP?
    4. What is board bring-up?
    5. How do you write a QNX driver?
    6. Difference between Linux driver and QNX driver
    7. What is devb?
    8. What is devc?
    9. What is devn?
    10. What is io-pkt?
    11. What is devctl?
    12. How are interrupts handled in QNX drivers?
    13. What is ISR in QNX?
    14. What is InterruptAttach?
    15. What is InterruptWait?

    Memory Management

    1. How does QNX manage memory?
    2. What is virtual memory?
    3. What is physical memory?
    4. What is MMU?
    5. Does QNX support demand paging?
    6. What is memory partitioning?
    7. What is stack memory?
    8. What is heap memory?
    9. What is shared memory object?
    10. What is shm_open?
    11. How does QNX prevent memory corruption?
    12. What happens on memory fault?
    13. What is page fault?
    14. How does QNX handle memory protection?
    15. What is mprotect?

    Networking in QNX

    1. What networking stack does QNX use?
    2. What is io-pkt?
    3. Does QNX support TCP/IP?
    4. What is socket API?
    5. Difference between TCP and UDP
    6. What is CAN stack in QNX?
    7. What is Ethernet driver architecture?
    8. How does QNX handle network interrupts?
    9. What is loopback interface?
    10. How do you debug network issues in QNX?

    Debugging & Tools

    1. What debugging tools are available in QNX?
    2. What is Momentics?
    3. What is gdb in QNX?
    4. How do you debug a crashed process?
    5. What is slogger?
    6. What is sloginfo?
    7. What is tracelogger?
    8. What is system profiler?
    9. What is latency measurement tool?
    10. How do you analyze CPU usage?
    11. How do you analyze memory leaks?
    12. What is dump file?
    13. What is core dump?
    14. How to debug IPC issues?
    15. How to debug deadlocks?

    Safety, Security & ISO 26262

    1. What is functional safety?
    2. Why is QNX used in safety-critical systems?
    3. What is ISO 26262?
    4. What is ASIL?
    5. What ASIL levels does QNX support?
    6. What is QNX Safe Kernel?
    7. Difference between QNX Neutrino and QNX Safe
    8. What is safety certification?
    9. How does microkernel help safety?
    10. What is freedom from interference?
    11. How is memory isolated?
    12. How is time partitioning achieved?
    13. What is secure boot?
    14. What is trusted execution?
    15. How does QNX handle cybersecurity?

    Advanced & Expert Level

    1. How does QNX guarantee deterministic latency?
    2. How do you design a real-time system in QNX?
    3. How do you handle overload conditions?
    4. How do you design fault-tolerant systems?
    5. How do you restart failed components?
    6. How does QNX support high availability?
    7. How does QNX compare with AUTOSAR OS?
    8. How does QNX compare with VxWorks?
    9. How does QNX handle mixed-criticality systems?
    10. How do you optimize IPC performance?
    11. How do you tune scheduler parameters?
    12. How do you reduce interrupt latency?
    13. How do you design a custom resource manager?
    14. How do you debug real-time violations?
    15. How do you port QNX to new hardware?

    Scenario / Practical Interview Questions

    1. How would you design a device driver in QNX?
    2. How would you implement inter-process communication?
    3. How would you recover from a crashed driver?
    4. How would you measure worst-case latency?
    5. How would you implement a watchdog?
    6. How would you handle priority inversion?
    7. How would you isolate a faulty application?
    8. How would you meet ASIL-D requirements?
    9. How would you debug boot failure?
    10. How would you optimize system startup time?

    QNX Security Architecture (Including TrustZone)

    Why Security Matters in QNX

    QNX is used in:

    • Automotive ECUs (IVI, ADAS, Digital Cockpit)
    • Industrial controllers
    • Medical devices

    So it must provide:

    • Strong isolation
    • Deterministic real-time behavior
    • Safety + security together

    Core Security Principles in QNX

    QNX security is based on:

    1. Microkernel isolation
    2. Least-privilege design
    3. Hardware-assisted security
    4. Defense-in-depth
    5. Separation of safety-critical and non-critical software

    Microkernel = First Security Layer

    How QNX Microkernel Improves Security

    • Only minimal code runs in kernel mode:
      • Scheduling
      • IPC
      • Interrupt handling
      • Low-level memory management
    • Drivers, filesystems, network stacks run in user space

    Security Benefits

    • Driver crash ≠ system crash
    • Compromised service can be restarted
    • Smaller attack surface
    • Easier security certification

    This is a huge advantage over monolithic kernels.

    Process & Memory Isolation

    🔹 Memory Protection

    • Each process has its own virtual address space
    • Enforced by MMU
    • No direct memory access between processes

    🔹 What Happens on Violation?

    • Memory fault
    • Process terminated
    • Kernel remains unaffected

    IPC Security (Message Passing)

    QNX uses synchronous message passing instead of shared memory by default.

    🔹 Security Advantages

    • No accidental memory sharing
    • Kernel validates message transfer
    • Controlled access through channels

    🔹 Credentials Propagation

    • QNX can pass:
      • PID
      • UID
      • GID
    • Enables authentication & authorization

    Capabilities & Permissions

    🔹 POSIX Permissions

    • File/device permissions
    • User & group based access

    🔹 Fine-Grained Control

    • Access to /dev nodes
    • Access to IPC channels
    • Access to system services

    Secure Boot in QNX

    🔹 What is Secure Boot?

    Ensures only trusted software runs on the system.

    🔹 Boot Chain

    1. ROM bootloader
    2. First-stage bootloader
    3. QNX IPL
    4. QNX startup
    5. QNX kernel (procnto)
    6. User processes

    🔹 Verification

    • Digital signatures
    • Cryptographic hash validation
    • Root of Trust (RoT)

    ❗ If verification fails → system does not boot.

    Trusted Execution Environment (TEE)

    QNX integrates with hardware TEE, such as:

    • ARM TrustZone
    • Secure enclaves

    ARM TrustZone + QNX (Very Important)

    What is TrustZone?

    ARM TrustZone splits the system into:

    • Secure World
    • Normal World

    How QNX Uses TrustZone

    Secure WorldNormal World
    Key storageApplications
    Crypto opsQNX Neutrino
    Secure bootIVI / ADAS
    HSM accessNetworking

    Use Cases

    • Secure key management
    • Certificate handling
    • DRM
    • Secure firmware update
    • Vehicle identity protection

    QNX typically runs in:

    • Normal World
    • Communicates with Secure World via SMC calls

    Hardware Security Module (HSM)

    What is HSM?

    • Dedicated hardware for cryptography

    QNX + HSM

    • Secure key storage
    • Hardware-accelerated crypto
    • Used for:
      • Secure boot
      • TLS
      • OTA updates
      • CAN authentication

    Secure Communication

    Network Security

    • TLS/SSL support
    • Secure sockets
    • Firewall & filtering

    Automotive

    • Secure CAN
    • Ethernet TSN security
    • DoIP protection

    QNX Hypervisor Security

    QNX Hypervisor

    • Runs multiple OSs (Linux, Android, QNX)
    • Strong partitioning

    Security Benefits

    • No shared kernel
    • Memory & CPU isolation
    • One OS compromise does not affect others

    Very important for digital cockpit systems.

    Safety + Security (ISO 26262 + Cybersecurity)

    QNX supports:

    • ISO 26262
    • ISO 21434 (Automotive Cybersecurity)

    Freedom From Interference

    • Time partitioning
    • Memory partitioning
    • Resource partitioning

    Secure + Safe Together

    • Secure boot protects safety software
    • Isolation prevents cascading failures

    Intrusion Detection & Monitoring

    • Secure logging
    • Process monitoring
    • Integrity checks
    • Watchdogs

    QNX Security Interview Questions

    1. How does QNX microkernel improve security?
    2. How does QNX ensure process isolation?
    3. What is secure boot in QNX?
    4. How does QNX integrate with TrustZone?
    5. Difference between TrustZone and Hypervisor?
    6. How does QNX protect cryptographic keys?
    7. How does QNX support ISO 21434?
    8. How does QNX prevent privilege escalation?
    9. How does QNX handle a compromised driver?
    10. Why is QNX preferred for automotive security?

    One-Line Interview

    QNX security is built on a microkernel architecture, strong process isolation, secure boot, hardware-assisted security like ARM TrustZone and HSMs, and certified safety/security standards, making it ideal for automotive and safety-critical systems.

    What is QNX Hypervisor?

    Short definition (for interviews)

    QNX Hypervisor is a Type-1 (bare-metal) hypervisor that allows multiple operating systems—such as QNX, Linux, and Android to run simultaneously on the same hardware with strong isolation, real-time performance, and safety certification support.

    Why Do We Need a Hypervisor in QNX Systems?

    Modern embedded systems (especially automotive) must run:

    • Safety-critical software (ADAS, instrument cluster)
    • Non-critical software (Android IVI, apps)
    • Real-time control tasks
    • High-performance graphics & networking

    Running everything in one OS is risky.

    Hypervisor solves this by isolating systems.

    What Type of Hypervisor is QNX Hypervisor?

    TypeDescription
    Type-1 (Bare-metal)Runs directly on hardware
    Type-2Runs on top of another OS

    QNX Hypervisor is Type-1, meaning:

    • No host OS
    • Lower latency
    • Stronger isolation
    • Better real-time behavior

    High-Level Architecture

    +-----------------------------+
    |   Guest OS (Android)        |
    +-----------------------------+
    |   Guest OS (Linux)          |
    +-----------------------------+
    |   Guest OS (QNX Neutrino)   |
    +-----------------------------+
    |        QNX Hypervisor       |
    +-----------------------------+
    |           Hardware          |
    +-----------------------------+
    

    Each Guest OS:

    • Thinks it owns the hardware
    • Is fully isolated from others

    Key Responsibilities of QNX Hypervisor

    🔹 CPU Virtualization

    • Assigns CPU cores to guests
    • Supports core pinning
    • Guarantees real-time behavior

    🔹 Memory Isolation

    • Each guest has a fixed memory region
    • Enforced using MMU & IOMMU
    • No memory overlap

    🔹 Device Virtualization

    • Shared devices (GPU, network)
    • Dedicated devices (CAN, SPI, UART)
    • Controlled access

    🔹 Interrupt Virtualization

    • Interrupt routing per guest
    • Priority-aware handling

    Real-Time Advantages

    Unlike general hypervisors:

    • Deterministic scheduling
    • Low interrupt latency
    • Predictable execution

    This is why QNX Hypervisor is used in ADAS and safety ECUs.

    Safety & Certification

    🔹 Functional Safety

    • Supports ISO 26262
    • Freedom from interference

    🔹 Why Hypervisor Helps Safety

    • Fault in Android ≠ fault in QNX safety app
    • Crash containment
    • Independent restart

    QNX Hypervisor vs TrustZone

    FeatureTrustZoneQNX Hypervisor
    PurposeSecure vs normal worldMulti-OS virtualization
    Worlds2Multiple guests
    IsolationSecurity-focusedSafety + security
    OS CountLimitedMany OSs
    Use caseKey storage, cryptoDigital cockpit

    They are complementary, not competitors.

    QNX Hypervisor vs Linux Hypervisor (KVM)

    FeatureQNX HypervisorKVM
    Real-timeExcellentLimited
    Safety certYesNo
    DeterminismHighMedium
    AutomotivePreferredRare

    Typical Automotive Use Case

    Digital Cockpit ECU

    Guest OSRole
    QNXInstrument cluster (ASIL-B/D)
    AndroidInfotainment
    LinuxMiddleware / services

    All running on one SoC.

    Device Sharing Example

    • GPU shared between Android & QNX
    • CAN dedicated to QNX safety OS
    • Ethernet shared via virtual NIC

    Boot Flow with Hypervisor

    1. Secure Boot ROM
    2. Bootloader
    3. QNX Hypervisor starts
    4. Guest OS images loaded
    5. Guests run independently

    Key Interview Questions

    1. What is QNX Hypervisor?
    2. Why is QNX Hypervisor Type-1?
    3. How does QNX Hypervisor ensure isolation?
    4. Difference between Hypervisor and microkernel?
    5. Hypervisor vs TrustZone?
    6. Why is QNX Hypervisor used in automotive?
    7. How does QNX Hypervisor support ISO 26262?
    8. How are devices shared between guests?

    One-Line Interview Answer

    QNX Hypervisor is a real-time, safety-certified, Type-1 hypervisor that allows multiple operating systems to run securely and independently on the same hardware, making it ideal for automotive and safety-critical systems.

    1. What is QNX Hypervisor?

    QNX Hypervisor is a Type-1 (bare-metal) hypervisor built on top of the QNX Neutrino RTOS microkernel.
    It allows multiple operating systems (guests) such as QNX, Linux, Android, or AUTOSAR Adaptive to run simultaneously on the same hardware, while remaining strictly isolated from each other.

    In simple words:

    QNX Hypervisor lets you safely run infotainment, ADAS, and safety-critical software on one SoC without interference.

    2. Why is QNX Hypervisor Type-1?

    A Type-1 hypervisor runs directly on hardware, not on top of another OS.

    Why QNX Hypervisor is Type-1:

    • Runs directly on the SoC
    • No host OS like Linux or Windows underneath
    • Has direct control over:
      • CPU cores
      • Memory (MMU)
      • Interrupts
      • Devices

    Why this matters:

    • Lower latency
    • Deterministic real-time behavior
    • Higher safety and security
    • Smaller attack surface

    This is mandatory for automotive safety systems.

    3. How does QNX Hypervisor ensure isolation?

    Isolation is the core strength of QNX Hypervisor.

    Isolation is achieved at multiple levels:

    CPU Isolation

    • Each guest OS is assigned:
      • Dedicated CPU cores or
      • Controlled time slices (scheduler enforced)
    • One guest cannot block or starve another

    Memory Isolation

    • Uses hardware MMU
    • Each guest has:
      • Its own virtual address space
    • No guest can:
      • Read
      • Write
      • Execute memory of another guest

    Device Isolation

    • Devices are either:
      • Exclusively assigned (pass-through)
      • Virtualized via QNX resource managers
    • A faulty guest cannot crash shared drivers

    Fault Containment

    • If one guest:
      • Crashes
      • Hangs
    • Other guests continue running normally

    This is critical for ASIL-D systems.

    4. Difference between Hypervisor and Microkernel?

    This is a very common interview trap question.

    AspectMicrokernel (QNX Neutrino)Hypervisor (QNX Hypervisor)
    PurposeOS architectureOS virtualization
    RunsCore OS servicesMultiple OS instances
    ControlsThreads, IPC, schedulingCPU, memory, devices
    Fault isolationBetween servicesBetween OSs
    ExampleQNX NeutrinoQNX Hypervisor

    Key relationship:

    QNX Hypervisor is built on top of the QNX microkernel

    The microkernel provides:

    • Message passing
    • Scheduling
    • Fault isolation

    The hypervisor adds:

    • Guest OS control
    • Hardware partitioning

    5. Hypervisor vs TrustZone?

    These are not competitors they work together.

    TrustZone (ARM):

    • Hardware security technology
    • Splits system into:
      • Secure world
      • Non-secure world
    • Used for:
      • Secure boot
      • Key storage
      • Crypto
      • DRM

    QNX Hypervisor:

    • Software virtualization layer
    • Runs multiple OSs
    • Provides:
      • Isolation
      • Scheduling
      • Resource control

    Key difference:

    FeatureTrustZoneQNX Hypervisor
    LevelHardware securitySoftware virtualization
    IsolationSecure vs non-secureOS-to-OS
    Use caseKeys, cryptoFull OS workloads
    FlexibilityLimitedVery high

    In automotive:

    • TrustZone protects secrets
    • QNX Hypervisor isolates systems

    6. Why is QNX Hypervisor used in automotive?

    Automotive systems demand safety + performance + consolidation.

    Reasons QNX Hypervisor is chosen:

    Mixed-Criticality Support

    • Run together:
      • ASIL-D safety apps
      • Infotainment (Linux/Android)
      • ADAS workloads

    ECU Consolidation

    • Multiple ECUs → Single powerful SoC
    • Reduces:
      • Cost
      • Wiring
      • Power consumption
      • Weight

    Real-Time Determinism

    • Guaranteed timing behavior
    • Mandatory for:
      • Braking
      • Steering
      • ADAS

    Proven Safety

    • Used by:
      • BMW
      • Mercedes
      • Volkswagen
      • Tesla (selected domains)

    7. How does QNX Hypervisor support ISO 26262?

    ISO 26262 is about functional safety.

    QNX Hypervisor supports ISO 26262 through:

    Safety-Certified Components

    • QNX Neutrino microkernel:
      • Certified up to ASIL-D
    • Safety manuals and documentation provided

    Freedom from Interference

    • Strong isolation ensures:
      • One guest cannot affect another
    • Required by ISO 26262 Part 6

    Deterministic Scheduling

    • Predictable execution
    • No priority inversion across guests

    Fault Detection and Recovery

    • Guest crashes are contained
    • Safety guest continues operating

    Auditable Design

    • Minimal trusted computing base
    • Easier certification

    This is why QNX is trusted for safety-critical ECUs.

    8. How are devices shared between guests?

    There are three main methods.

    Device Pass-Through

    • One device → one guest
    • Direct hardware access
    • Lowest latency
    • Example:
      • CAN controller → safety guest

    Virtual Devices

    • Hypervisor emulates a device
    • Guest sees a virtual hardware device
    • Actual hardware managed by QNX

    Example:

    • Virtual network card

    Shared Services via Resource Managers

    • QNX resource manager owns the device
    • Guests communicate using:
      • IPC
      • Shared memory
    • Controlled and safe sharing

    Example:

    • Display
    • Audio
    • Storage

    FAQ: QNX OS Interview Questions

    Q1. Is QNX a real-time operating system?
    Yes, QNX is an RTOS with deterministic scheduling and predictable response times.

    Q2. What is the core feature of QNX?
    The microkernel architecture with message passing.

    Q3. How do processes communicate in QNX?
    Using Send, Receive, and Reply (SRR) message passing calls.

    Q4. Which companies use QNX?
    Automotive (BlackBerry QNX, BMW, Audi), medical devices, aerospace, and industrial automation.

    Q5. How do you check running processes in QNX?
    By using the pidin command.

    Q6. What is the difference between QNX and Linux?
    QNX offers true real-time performance and fault tolerance, while Linux is more flexible but less predictable.

    Q7. What tools are used for debugging in QNX?
    Momentics IDE, pidin, sloginfo, tracelogger.

    Q8. Why is QNX preferred in automotive software?
    Because of safety certification, fault isolation, and reliability.

    Final Tips for Cracking QNX OS Interview

    Understand basic architecture (microkernel, message passing).
    Learn system utilities (pidin, sloginfo, ls, etc.).
    Be clear about real-time scheduling and priorities.
    Compare QNX vs Linux when asked.

  • QNX Boot Process | Master Beginner-Friendly In-Depth Guide 2026

    What is Booting?

    Booting is like waking up your computer or embedded device. When you press the power button, the system must go from “just hardware” to a fully running operating system (OS) that can run applications.

    In QNX Neutrino, the boot process is modular and layered, and it’s built to give maximum flexibility, especially for embedded systems.

    QNX Boot Process

    The QNX boot process is highly customizable and optimized for real-time embedded

    The QNX boot process involves several key steps to bring the system up from power-on to a fully operational state:

    1. Power-On and Bootloader: When the system is powered on, the bootloader is executed. It initializes the hardware (CPU, memory, peripherals) and loads the QNX kernel into memory.
    2. Kernel Loading: The QNX kernel is loaded and starts running. It manages system resources like memory, processes, and interrupts.
    3. System Initialization: The kernel initializes essential services, such as device drivers, file systems, and network services.
    4. User-Space Initialization: The system starts user-space processes and applications, often based on startup scripts. This includes services like login prompts and other essential applications.
    5. Normal Operation: The system enters its normal operational state, ready for user interaction and running background tasks.

    Main Components in QNX Boot Sequence

    Think of the QNX boot process like climbing a ladder. Each step builds on the one before it and gets closer to running real applications.

    Here are the 3 main software pieces involved after the hardware powers up:

    1. IPL (Initial Program Loader)
    2. Startup Program
    3. OS Image (with Kernel and Scripts)

    These parts are packaged together in something called an Image File System (IFS).

    QNX Boot Process Steps (Simplified with Explanation)

    Step 1: Hardware Initialization (Powering On)

    • This is when the board turns on.
    • The processor starts executing from a fixed address called the reset vector.
    • Depending on the hardware, something like a BIOS (x86), UEFI, or U-Boot (ARM) runs first.
    • These are low-level programs that check the system and hand over control to the QNX boot code.

    Step 2: IPL – Initial Program Loader

    • The IPL is the first piece of QNX software that runs.
    • It’s very small and is hardware-specific (custom to your board or chip).
    • The IPL’s job is to:
      • Initialize just enough hardware (like RAM or flash).
      • Load the rest of the QNX system from storage (like flash, SD card, etc.).
      • Specifically, it loads the IFS (Image File System).
      • Then, it passes control to the next step — the startup program.

    🧠 Think of the IPL as the stage crew that sets the stage and curtain before the actors (OS) come in.

    Step 3: Startup Program

    • The startup program runs immediately after the IPL.
    • It’s smarter than the IPL and does more complex hardware setup:
      • Initializes memory mapping.
      • Sets up interrupt controllers, timers, and CPU caches.
      • Prepares the environment so the QNX kernel can start.

    It’s still inside the IFS (Image File System) that was loaded by the IPL.

    Step 4: OS Kernel (procnto)

    • After startup finishes hardware setup, it hands control to the QNX microkernel (procnto).
    • procnto includes:
      • The QNX kernel.
      • The process manager (it handles creating and scheduling programs).
    • The kernel reads a script from the IFS (defined in the buildfile) and begins launching:
      • Drivers (e.g., for serial, USB, or storage).
      • System processes (e.g., file systems).
      • Initial applications (like the shell or custom software).

    This is where QNX becomes a real operating system and starts managing resources, files, and communication.

    What is an IFS (Image File System)?

    • IFS = Bootable image that contains:
      • The startup program
      • The QNX kernel (procnto)
      • Device drivers
      • Startup scripts
      • Libraries and initial apps

    You can think of the IFS like a suitcase with everything QNX needs to boot up and get started.

    You create an IFS using a buildfile and the tool mkifs.

    How Is the QNX Boot Image Customized?

    You can customize what goes into the IFS using a buildfile — a special text file that lists:

    • What drivers and applications to include
    • Which order to launch them
    • Any environment variables or arguments
    • File permissions and paths

    Customization Steps:

    1. Write a Buildfile: [virtual=x86,binary] .bootstrap = { startup-bios } [+script] startup-script.sh /procnto /devc-seromap /sbin/sh
    2. Build the IFS: mkifs buildfile.qnx image.ifs
    3. Flash the IFS to your board or load it via U-Boot.

    You control the boot sequence just by editing this buildfile — no need to recompile the entire OS.

    💛 Support Embedded Prep

    If you find our tutorials helpful and want to support our mission of sharing high-quality embedded system knowledge, you can contribute by buying us a coffee. Every small contribution helps us keep creating valuable content for learners like you. ☕

    Thank you for your support — it truly keeps Embedded Prep growing. 💻✨

    What Happens After QNX Boot?

    Once everything in the IFS is running, you may still need to start large or complex applications after boot, especially if:

    • Your app is made of multiple processes.
    • Processes must start in a specific order.
    • You want to manage failures or restarts.

    For this, QNX provides:

    SLM – System Launch and Monitor

    • Think of it as a supervisor for apps.
    • It can:
      • Launch multiple apps in the correct order.
      • Monitor them and restart if needed.
      • Let you change startup order without touching the IFS.

    Summary Table of QNX Boot Process

    ComponentPurpose
    IPLMinimal code that loads the IFS (hardware-specific).
    StartupSets up hardware (timers, cache, MMU) for the kernel.
    Kernel (procnto)Core of QNX; manages memory, processes, threads.
    IFSBoot image with startup, kernel, drivers, apps, scripts.
    BuildfileText file that defines what goes in the IFS.
    SLMTool to start complex apps after booting.