
Category: QNX OS

  • Master QNX Boot Process Interview Question Explained (2026)

    Learn the complete QNX Boot Process: IPL, Startup Code, IFS, SLM & Boot Manager explained step-by-step for embedded system interviews.

    Understanding the QNX boot process is a must if you’re preparing for embedded or automotive interviews. In this video, we break down the complete QNX boot flow step by step from power-on to application launch in a way that’s easy to understand and practical for real interviews.

    You’ll learn how IPL, startup code, IFS, the Neutrino microkernel, SLM, and the Boot Manager work together during system boot. Each concept is explained with clear logic, real-world examples, and common interview questions that are frequently asked in companies working with QNX RTOS.

    This content is designed for beginners, experienced engineers, and senior embedded developers who want clarity instead of textbook definitions. If you’re targeting roles in automotive, IVI, ADAS, or real-time systems, this guide will help you answer confidently and explain concepts like a professional.

    Perfect for:

    • QNX RTOS interview preparation
    • Embedded software engineers
    • Automotive and safety-critical system roles

    Explain QNX booting process

    0️⃣ Power-On / Reset

    • CPU resets and starts execution from a fixed reset vector
    • Control goes to platform firmware
      • ROM code / SoC boot ROM
      • BIOS / UEFI (x86)
      • Trusted firmware (ARM)

    1️⃣ Firmware / Platform Initialization

    Responsibilities:

    • Basic silicon initialization
    • Select boot media (eMMC, SD, NOR, NAND, network)
    • Load the Initial Program Loader (IPL)

    Still not QNX OS yet.

    2️⃣ Initial Program Loader (IPL)

    First QNX-specific software

    Responsibilities:

    • Initialize minimum hardware:
      • DRAM controller
      • CPU caches
      • Basic clocking
    • Locate and load the QNX IFS (Image File System) into RAM
    • Transfer execution to the startup program inside the IFS

    IPL is board-specific and extremely small.

    3️⃣ Image File System (IFS)

    The IFS is a single binary image containing:

    • Startup program (startup-*)
    • procnto (kernel + process manager)
    • Boot scripts
    • Drivers & servers
    • Boot manager / SLM (if used)
    • Optional user applications

    IPL only loads the IFS; it does not start services.

    4️⃣ Startup Program (Critical Stage)

    Executed directly from the IFS

    Responsibilities:

    • Identify CPU and SoC
    • Initialize interrupt controller
    • Initialize timers
    • Configure caches
    • Initialize MMU
    • Discover RAM & reserved regions
    • Build the System Page (syspage)
    • Register kernel callouts
    • Prepare execution environment for the kernel

    The kernel cannot run without startup completing

    5️⃣ Transfer Control to procnto

    • Startup jumps to procnto entry point

    6️⃣ procnto (Kernel + Process Manager)

    procnto contains:

    • Neutrino microkernel
    • Process manager

    Kernel responsibilities:

    • Thread scheduling
    • Interrupt handling
    • Message passing (IPC)
    • Timers
    • Signals

    Process manager responsibilities:

    • Process creation (spawn, fork)
    • Memory management
    • POSIX services
    • File descriptor handling

    At this point, the OS is alive, but no drivers or filesystems exist yet.

    7️⃣ Boot Script Execution (Buildfile Script)

    • procnto executes the startup script embedded in the IFS
    • Script is defined in the IFS buildfile

    Script launches:

    • Device drivers (resource managers)
    • Filesystems
    • Networking stack
    • Logging services

    Example:

    devc-seromap
    io-blk.so
    devb-mmcsd
    mount -t qnx6 /dev/mmc0 /
    

    Script order defines system bring-up order.

    8️⃣ Boot Manager (Optional, Policy-Based)

    Runs as a user-space process

    Responsibilities:

    • Decide boot mode:
      • Normal
      • Recovery
      • Factory
      • OTA update
    • Read:
      • GPIO
      • NVRAM
      • Reset reason
    • Select:
      • Which script
      • Which partition
      • Which system profile

    Boot Manager does not boot the OS, it selects how the OS continues.

    9️⃣ SLM – System Launch Manager (Optional but Common)

    Runs after boot decision

    Responsibilities:

    • Launch services based on policy
    • Handle:
      • Dependencies
      • Ordering
      • Restart policies
      • Monitoring

    Example:

    • Start audio only after codec driver
    • Restart camera service on crash
    • Delay UI until graphics stack is ready

    Replaces traditional init systems.

    🔟 Filesystem Mounting

    • Root filesystem mounted
    • Persistent storage mounted
    • /proc, /dev, /etc become available

    1️⃣1️⃣ System Services Running

    Examples:

    • io-pkt (networking)
    • slog2info (logging)
    • devb-* (storage)
    • Audio, camera, display services

    All run in user space.

    1️⃣2️⃣ User Applications Start

    • System enters RUNNING state
    • Real-time applications start with:
      • Assigned priority
      • Scheduling policy
    • System is fully operational

    COMPLETE FLOW DIAGRAM

    Power On / Reset
          ↓
    Firmware / ROM / UEFI
          ↓
    Initial Program Loader (IPL)
          ↓
    Load IFS into RAM
          ↓
    Startup Program
          ↓
    procnto (Kernel + Process Manager)
          ↓
    Boot Script (IFS)
          ↓
    Boot Manager (optional)
          ↓
    SLM (optional)
          ↓
    Drivers / Services
          ↓
    Applications
    

    IPL (Initial Program Loader) is the first QNX-specific software component that runs after power-on/reset.
    Its primary role is to prepare minimal hardware and load the QNX OS image (IFS) into RAM.

    Simple Definition

    IPL is a small, board-specific program that runs after firmware, initializes minimal hardware, loads the QNX Image File System (IFS) into memory, and transfers control to the startup program.

    Where IPL Fits in the QNX Boot Sequence

    Power ON / Reset
       ↓
    Firmware / Boot ROM / UEFI
       ↓
    IPL   ← (first QNX component)
       ↓
    Startup program (inside IFS)
       ↓
    procnto (kernel + process manager)
    

    Key Responsibilities of IPL

    1️⃣ Minimal Hardware Initialization

    • Initialize DRAM / RAM controller
    • Set basic CPU clocks
    • Enable caches (if required)
    • Setup minimal UART for debug logs

    Only what’s needed to load the OS — nothing more.

    2️⃣ Locate Boot Media

    • Determines where the OS image is stored:
      • NOR / NAND Flash
      • eMMC / SD card
      • Network (TFTP)
      • SPI Flash

    3️⃣ Load the IFS (Image File System)

    • Copies the QNX IFS image from boot media into RAM
    • Verifies image integrity (optional checksum/signature)

    4️⃣ Transfer Control to Startup Program

    • Jumps to the startup program entry point
    • From this point, IPL is no longer involved

    What IPL Does NOT Do

    • Does not initialize MMU
    • Does not start the kernel
    • Does not start drivers or services
    • Does not run in user space

    Characteristics of IPL

    • Board-specific
    • Very small footprint
    • Runs in physical addressing mode
    • Written in C + assembly
    • Often stored in ROM or Flash

    IPL vs Startup Program (Very Common Interview Question)

    FeatureIPLStartup Program
    Runs first✅❌
    Hardware initMinimalExtensive
    Loads IFS✅❌
    Builds syspage❌✅
    Initializes MMU❌✅
    Starts kernel❌✅ (via procnto)

    One-Line Ultra-Short Answer

    IPL is a minimal bootloader in QNX that initializes basic hardware and loads the OS image (IFS) into RAM before handing control to the startup program.

    High-Level Difference (One-Line)

    IPL is a minimal, board-specific QNX loader whose only job is to load the IFS, while U-Boot is a full-featured, OS-agnostic bootloader that can load many operating systems and provide user interaction.

    Position in Boot Flow

    QNX with IPL

    ROM / Firmware
       ↓
    IPL
       ↓
    Startup program
       ↓
    procnto (kernel)
    

    QNX with U-Boot

    ROM / Firmware
       ↓
    U-Boot
       ↓
    Load IFS into RAM
       ↓
    Startup program
       ↓
    procnto (kernel)
    

    U-Boot can replace IPL, but the startup program is still mandatory in QNX.

    Core Purpose

    AspectIPLU-Boot
    Primary goalLoad QNX IFSGeneral-purpose bootloader
    OS specificYes (QNX)No (Linux, QNX, RTOS)
    Feature setMinimalVery rich
    User interactionNoneCLI, scripting
    Typical sizeVery small (KBs)Large (100s of KBs–MBs)

    Hardware Initialization

    AreaIPLU-Boot
    DDR initMinimalFull
    ClocksMinimalFull
    GPIONoYes
    NetworkingNoYes
    USBNoYes
    DisplayNoYes

    IPL initializes only what’s needed to load IFS.

    Storage & Boot Sources

    FeatureIPLU-Boot
    NOR/NANDYesYes
    eMMC/SDYesYes
    Network bootRareCommon
    Filesystem supportNoYes (FAT, EXT, etc.)

    OS Image Handling

    FeatureIPLU-Boot
    Loads IFSYesYes
    Loads Linux kernelNoYes
    Multiple imagesNoYes
    Image selectionFixedDynamic

    Security Features

    FeatureIPLU-Boot
    Secure bootLimitedStrong
    Image authenticationBasicAdvanced
    TPM supportNoYes

    Scripting & Debugging

    FeatureIPLU-Boot
    Command lineNoYes
    Boot scriptsNoYes
    Environment variablesNoYes
    Recovery shellNoYes

    Typical Use Cases

    IPL is used when:

    • You want fast, deterministic boot
    • System is fixed-function
    • Safety-critical systems (automotive)
    • Minimal attack surface

    U-Boot is used when:

    • Multiple OS support needed
    • Development & debugging required
    • OTA updates, recovery modes
    • Rich storage & network boot options

    Common Interview Trick Question

    Q: Can QNX boot without IPL?

    ✔️ Yes, if U-Boot loads the IFS directly
    ❌ No, QNX can’t boot without the startup program

    IPL vs U-Boot vs Startup

    ComponentRole
    IPLLoads IFS
    U-BootLoads IFS or kernel
    StartupPrepares system for kernel

    Startup is mandatory. IPL is optional if U-Boot is used.

    Real Automotive Example

    • Boot ROM → U-Boot
    • U-Boot verifies image & selects slot
    • U-Boot loads QNX IFS into RAM
    • Jumps to startup program
    • QNX kernel starts

    IFS (Image File System) is a single, self-contained binary image that contains everything QNX needs to boot and start running — including the kernel, startup code, drivers, and applications.

    Simple Definition

    IFS is a bootable, in-memory filesystem image that bundles the QNX kernel, startup program, system processes, drivers, scripts, and applications into one binary loaded by the bootloader.

    Where IFS Fits in the Boot Sequence

    IPL / U-Boot
       ↓
    Load IFS into RAM
       ↓
    Startup program
       ↓
    procnto (kernel)
       ↓
    Boot scripts & services
    

    What an IFS Contains

    Mandatory Components

    • Startup program (startup-*)
    • procnto
      • Neutrino microkernel
      • Process manager

    Optional Components

    • Boot scripts
    • Device drivers (resource managers)
    • Filesystem drivers
    • Networking stack
    • Boot Manager
    • SLM (System Launch Manager)
    • System services
    • User applications
    • Shared libraries

    Everything inside the IFS is available immediately at boot.

    Why QNX Uses IFS

    1️⃣ Single Binary = Fast & Reliable Boot

    • No dependency on external filesystems
    • Ideal for real-time & safety systems

    2️⃣ Read-Only & In-Memory

    • Stored in ROM/Flash
    • Loaded into RAM
    • Immutable at runtime → improves reliability

    3️⃣ Deterministic Startup

    • Exact execution order defined in buildfile
    • No surprises during boot

    How IFS is Created

    Tool Used

    • mkifs

    Input

    • Buildfile
      • Lists binaries
      • Defines scripts
      • Sets permissions & paths

    Output

    • Single IFS binary
      • Example: ifs-qnx.bin

    Simple Buildfile Example

    [virtual=armle]
    startup-qcom
    procnto
    script=/etc/system/boot {
        devc-seromap
        io-blk.so
    }
    

    Runtime Characteristics

    FeatureIFS
    LocationRAM
    Writable (read-only)
    SizeFixed at build time
    ExecutionDirect from memory
    Mount point/ (initial root)

    IFS vs Root Filesystem

    AspectIFSRoot FS
    PurposeBoot & early systemPersistent storage
    ModifiableNoYes
    Used at bootAlwaysOptional
    ReliabilityVery highDepends on storage

    After boot, QNX may switch root to a persistent filesystem.

    Common Interview Questions

    Q. Can QNX boot without IFS?

    ❌ No
    IFS is mandatory.

    Q. Can there be multiple IFS images?

    ✔️ Yes

    • Different boot modes
    • Recovery images
    • OTA A/B partitions

    Q. Is IFS the same as Linux initramfs?

    Conceptually similar, but:

    • IFS is more deterministic
    • Built specifically for QNX
    • Integrated tightly with the kernel startup

    One-Line Ultra-Short Answer

    IFS is a single, bootable in-memory filesystem image that contains the QNX startup program, kernel, drivers, scripts, and applications.

    Startup code in QNX is the very first software that runs after the boot loader (IPL) and before the QNX Neutrino microkernel starts.

    Its main job is to initialize the hardware, prepare memory, and load the QNX kernel and system processes into RAM.

    Why is Startup Code needed in QNX?

    When the system powers on:

    • Hardware is in an unknown state
    • RAM is not initialized
    • MMU, caches, clocks are not configured

    The startup code prepares the system so the QNX kernel can run safely and deterministically.

    Position in QNX Boot Flow (Interview Point)

    Power ON
       ↓
    ROM / Boot ROM
       ↓
    IPL (Initial Program Loader)
       ↓
    Startup Code   ← (This)
       ↓
    QNX Neutrino Microkernel (procnto)
       ↓
    System Services & Applications
    

    Key Responsibilities of QNX Startup Code

    1. Basic Hardware Initialization

    • Initialize CPU
    • Configure clocks and PLL
    • Enable RAM controllers
    • Set up UART (for early debug output)

    2. Memory Setup

    • Detect available RAM
    • Build the system memory map
    • Reserve memory for:
      • Kernel
      • System processes
      • Drivers

    3. MMU and Cache Setup

    • Initialize MMU
    • Set up page tables
    • Enable instruction and data caches

    (Important for performance and protection)

    4. Load the IFS (Image File System)

    • Locate the IFS image
    • Copy it into RAM
    • Validate the image

    IFS contains:

    • Neutrino kernel (procnto)
    • Process Manager
    • Shared libraries
    • Startup services

    5. Start the QNX Microkernel

    • Transfer control to:
    procnto
    
    • After this point, QNX kernel scheduling and message passing begin

    Is Startup Code Hardware Dependent?

    Yes

    • Startup code is board-specific
    • Written per SoC / CPU architecture
    • Different for:
      • ARM
      • x86
      • PowerPC

    Where is Startup Code Located?

    • Stored inside the IFS
    • Built using:
    startup-<boardname>
    

    Example:

    startup-am335x
    startup-imx8
    

    Difference Between IPL and Startup Code (Very Common Interview Question)

    IPLStartup Code
    Runs from ROM/FlashRuns from RAM
    Very minimalMore complex
    Loads startupLoads kernel + IFS
    Hardware-agnosticHardware-specific

    One-Line Interview Answer

    Startup code in QNX is a board-specific program that runs after the IPL to initialize hardware, configure memory and MMU, load the IFS, and finally start the QNX Neutrino microkernel.

    Real-World Example (Bonus)

    On an ARM board:

    • IPL sets up SDRAM
    • Startup code:
      • Configures MMU
      • Sets UART for logs
      • Loads procnto
      • Hands control to the kernel

    Where they sit in the QNX boot flow

    Power ON
      ↓
    Boot ROM
      ↓
    IPL (Initial Program Loader)
      ↓
    Startup Code
      ↓
    QNX Neutrino Microkernel (procnto)
      ↓
    SLM (System Launch Manager)
      ↓
    Boot Manager
      ↓
    System Services & Applications
    

    1️⃣ Startup Code (Before Kernel)

    What is Startup Code?

    Startup code is a board-specific program that runs after IPL and before the QNX kernel.

    Runs in:

    • No OS context
    • No scheduling, no IPC, no processes

    Main Responsibilities

    • Initialize CPU, clocks, PLL
    • Initialize RAM
    • Set up MMU and caches
    • Build system memory map
    • Load IFS into RAM
    • Start Neutrino microkernel (procnto)

    Key Interview Line

    Startup code prepares the hardware and memory so that the QNX kernel can safely start.

    2️⃣ SLM (System Launch Manager)

    What is SLM?

    SLM is the first user-space process launched by the QNX kernel.

    It is responsible for starting all core system services.

    Runs in:

    • User space
    • Fully scheduled by the kernel
    • Uses message passing

    What SLM Does

    • Reads system launch configuration
    • Starts:
      • Process Manager
      • Path Manager
      • Device drivers
      • Filesystems
      • Networking stack
    • Handles service dependencies
    • Ensures correct startup order

    Why SLM is important

    • Provides deterministic system bring-up
    • Allows controlled, restartable services

    Key Interview Line

    SLM is responsible for launching and supervising essential system services after the kernel starts.

    3️⃣ Boot Manager

    What is Boot Manager?

    Boot Manager is a user-space component that controls which system configuration or boot image to start.

    It is commonly used in automotive and safety-critical systems.

    Runs in:

    • User space
    • After SLM starts basic services

    What Boot Manager Does

    • Selects:
      • Normal boot
      • Recovery boot
      • OTA update boot
    • Validates images (CRC / signature)
    • Handles:
      • A/B partitions
      • Rollback on failure
    • Supports safe and secure boot flow

    Why Boot Manager is needed

    • Enables fail-safe boot
    • Supports software updates
    • Required for ASIL / functional safety systems

    Key Interview Line

    Boot Manager controls system boot modes and ensures safe startup, recovery, and update handling.

    Direct Comparison Table (Very Important)

    FeatureStartup CodeSLMBoot Manager
    Boot StageBefore kernelAfter kernelAfter SLM
    Runs InNo OSUser spaceUser space
    Hardware InitYesNoNo
    Kernel LaunchYesNoNo
    Service LaunchNoYesPartial
    Boot Mode SelectionNoNoYes
    Safety / OTANoNoYes
    Board SpecificYesMostly genericGeneric

    One-Line Differentiation

    • Startup code initializes hardware and starts the kernel
    • SLM launches and manages system services
    • Boot Manager decides how the system boots (normal, recovery, update)

    Common Interview Trap

    ❌ “Boot Manager starts the kernel”
    ✅ Wrong — kernel is already running before Boot Manager starts.

    Real Automotive Example

    • Startup initializes SoC and DDR
    • Kernel starts
    • SLM launches:
      • Audio
      • Camera
      • CAN
    • Boot Manager:
      • Verifies OTA image
      • Chooses A/B partition
      • Rolls back on failure

    5-Second Interview Answer

    In QNX, startup code initializes hardware and starts the kernel, SLM launches and supervises system services, and Boot Manager controls boot modes, recovery, and updates for safe system startup.

    io-pkt is the QNX networking stack process that provides TCP/IP networking services.

    Detailed Explanation

    • io-pkt is a user-space network protocol stack
    • It implements:
      • TCP
      • UDP
      • IP
      • ARP
      • ICMP
    • Uses QNX’s message-passing microkernel architecture
    • Hardware-independent networking core

    Key Responsibilities

    • Packet routing
    • Protocol handling
    • Socket API support
    • Interface with NIC drivers

    How hardware fits in

    • NIC drivers are shared libraries loaded by io-pkt
    • Example:
    io-pkt-v6-hc -d e1000
    

    Why QNX uses io-pkt (Interview Point)

    • Fault isolation (user space)
    • Restartable networking stack
    • Deterministic behavior

    Runs in:

    • User space

    devb-* is the QNX block device driver used for storage devices.

    Detailed Explanation

    • devb stands for device block
    • Provides block-level access to storage:
      • eMMC
      • SD card
      • USB storage
      • SATA
      • NVMe

    What devb-* Does

    • Manages:
      • Read/write blocks
      • Disk partitions
      • Media detection
    • Exposes devices like:
    /dev/hd0
    /dev/hd0t77
    

    Common devb-* Examples

    DriverDevice
    devb-sdmmcSD / eMMC
    devb-umassUSB mass storage
    devb-sataSATA disk
    devb-nvmeNVMe

    Used with File Systems

    • Works with:
      • fs-qnx6
      • fs-ext4
      • fs-fat

    Runs in:

    • User space

    devc-* is the QNX character device driver for serial communication interfaces.

    Detailed Explanation

    • devc stands for device character
    • Provides serial I/O support:
      • UART
      • RS-232
      • RS-485
    • Uses termios interface

    What devc-* Does

    • Handles:
      • Baud rate
      • Parity
      • Flow control
      • Interrupts
    • Creates devices like:
    /dev/ser1
    /dev/ttyS0
    

    Common devc-* Examples

    DriverInterface
    devc-ser8250Standard UART
    devc-mx1i.MX UART
    devc-omapTI OMAP UART

    Runs in:

    • User space

    Comparison Table

    Featureio-pktdevb-*devc-*
    TypeNetwork stackBlock driverCharacter driver
    Used ForTCP/IP networkingStorage devicesSerial communication
    Device TypeNetworkBlockCharacter
    Runs InUser spaceUser spaceUser space
    RestartableYesYesYes
    Hardware SpecificPartiallyYesYes

    One-Line Difference

    • io-pkt → networking stack
    • devb-* → storage devices
    • devc-* → serial communication

    Common Interview Trap

    ❌ “These drivers run in kernel space”
    ✓ Wrong — QNX runs drivers in user space for fault tolerance.

    Real Automotive Example

    • io-pkt → Ethernet / CAN-over-IP
    • devb-sdmmc → eMMC storage
    • devc-ser8250 → Debug UART

    5-Second Interview Answer (Perfect)

    In QNX, io-pkt provides networking services, devb-* handles block storage devices, and devc-* manages serial character devices, all running safely in user space

    A startup script in QNX is a shell script that runs after the QNX kernel boots to start system services, drivers, and applications in a defined order.

    Slightly Detailed

    • Executed in user space
    • Runs after procnto (microkernel) is up
    • Typically launched by SLM (System Launch Manager)
    • Used to:
      • Start drivers
      • Mount filesystems
      • Configure networking
      • Launch applications

    What Does a Startup Script Do?

    Common tasks include:

    • Start drivers:
    devc-ser8250 &
    io-pkt-v6-hc -d e1000 &
    devb-sdmmc &
    
    • Mount filesystems:
    mount -t qnx6 /dev/hd0t177 /data
    
    • Configure networking:
    ifconfig en0 192.168.1.10
    
    • Set environment variables
    • Start applications and services

    Where Are Startup Scripts Located?

    Interview Answer

    Startup scripts are stored inside the IFS (Image File System) and are executed during system boot.

    Common Locations

    LocationPurpose
    /etc/system/Primary system startup scripts
    /etc/system/enum/Hardware enumeration scripts
    /etc/rc.d/Optional rc-style scripts
    /proc/boot/Read-only IFS contents

    Most Important File (Very Common Question)

    /proc/boot/script

    • Main startup script
    • Executed automatically during boot
    • Lives inside the IFS
    • Read-only at runtime

    How Startup Scripts Are Executed (Boot Flow)

    Kernel (procnto)
       ↓
    SLM starts
       ↓
    SLM executes /proc/boot/script
       ↓
    Drivers and services start
    

    Why Startup Scripts Are Important?

    Interview Points

    • Control boot order
    • Enable deterministic startup
    • Allow easy system customization
    • No kernel recompilation required

    Startup Script vs Startup Code

    Startup CodeStartup Script
    Runs before kernelRuns after kernel
    Written in CWritten in shell
    Hardware initializationService & driver launch
    Board-specificMostly generic

    Real-World Example (Automotive)

    • Startup script:
      • Starts audio service
      • Launches camera driver
      • Brings up Ethernet
    • Allows OTA updates without touching kernel

    One-Line Interview Answer

    A startup script in QNX is a user-space shell script stored in the IFS that runs after the kernel boots to launch system services, drivers, and applications.

    Conclusion

    The QNX boot process may look complex at first, but once you understand the role of each stage, it becomes very logical and easy to explain in interviews. From IPL and startup code preparing the hardware, to the Neutrino microkernel taking control, and finally SLM and the Boot Manager launching and managing system services, every step is designed for determinism, safety, and reliability.

    Knowing how these components work together not only helps you answer interview questions with confidence but also gives you a real-world understanding of why QNX is widely used in automotive and safety-critical systems. If you can clearly explain the boot flow and the responsibility of each layer, you already stand out as a strong embedded engineer.

    Keep revising the flow, relate it to practical use cases, and you’ll be well prepared for any QNX or embedded systems interview.

    FAQ : QNX Boot Process

    1. What is the QNX boot process?

    The QNX boot process is the sequence of steps the system follows from power-on to running applications. It involves IPL, startup code, IFS, the Neutrino microkernel, SLM, and Boot Manager.

    2. What is IPL in QNX?

    IPL (Initial Program Loader) is the first code that runs after powering on the system. It initializes basic hardware and loads the startup code into RAM.

    3. What is startup code in QNX?

    Startup code is a board-specific program that runs after IPL. It sets up memory, MMU, caches, and loads the IFS, then starts the Neutrino microkernel.

    4. What is IFS (Image File System)?

    IFS contains the QNX kernel, drivers, libraries, and startup scripts. Startup code loads IFS into RAM so the system can run all services.

    5. What is SLM in QNX?

    SLM (System Launch Manager) is the first user-space process launched by the kernel. It starts drivers, system services, and applications, handling dependencies and startup order.

    6. What is Boot Manager in QNX?

    Boot Manager controls which boot mode or image the system uses. It ensures safe boot, recovery options, and OTA updates, especially in automotive or safety-critical systems.

    7. What is io-pkt in QNX?

    io-pkt is the networking stack process in QNX. It handles TCP/IP, UDP, ICMP, and communicates with NIC drivers to provide network functionality in user space.

    8. What are devb-* drivers in QNX?

    devb-* drivers are block device drivers for storage devices like SD cards, eMMC, USB drives, and SATA/NVMe disks. They provide read/write block-level access.

    9. What are devc-* drivers in QNX?

    devc-* drivers are character device drivers used for serial communication interfaces such as UART, RS-232, and RS-485.

    10. What is a startup script in QNX?

    A startup script is a user-space shell script executed after the kernel boots. It launches drivers, services, and applications, defining the system’s startup behavior.

    11. Where are startup scripts located in QNX?

    Startup scripts are stored in the IFS, usually under /etc/system/ or /proc/boot/script. They are executed automatically during system boot.

    12. What is the difference between startup code, SLM, and Boot Manager?

    ComponentRole
    Startup CodeHardware initialization and kernel launch
    SLMLaunches system services and drivers in user space
    Boot ManagerManages boot modes, safe boot, recovery, and updates

    In short, startup code starts the kernel, SLM starts services, and Boot Manager controls boot modes.
    Read More about Process : What is is Process
    Read More about System Call in Linux : What is System call
    Read More about IPC : What is IPC
  • Master QNX OS Interview Questions and Answer 2026

    QNX OS interview questions and answers for 2026, explained in simple language. Covers microkernel architecture, IPC, scheduling, resource managers, and real-time concepts for embedded and automotive engineers.

    This collection of QNX OS interview questions and answers is designed for engineers who want to truly understand QNX, not just memorize definitions. The questions are written in a practical way, similar to what is actually asked in real technical interviews, especially for automotive, embedded, and RTOS roles.

    The content starts from basic concepts, such as what QNX is, why it is called a microkernel OS, and how it differs from Linux. As the questions progress, they move into core internal topics like kernel space vs user space, message passing, processes and threads, scheduling, IPC, and resource managers. Advanced sections cover fault tolerance, adaptive partitioning, real-time behavior, priority scheduling, and system reliability, which are commonly discussed in senior-level interviews.

    Each answer is written in simple language, focusing on clarity and understanding, not textbook definitions. Wherever possible, explanations reflect real-world behavior, how QNX works internally, and how engineers actually use it in production systems like automotive ECUs, medical devices, and industrial controllers.

    This material is especially useful for:

    • Embedded Software Engineers
    • Automotive/QNX Developers
    • RTOS and System Programming Interviews
    • Engineers working with QNX Neutrino

    The goal is not to impress with complex wording, but to help you explain QNX confidently and naturally during interviews just like an experienced engineer would.

    QNX is a POSIX-compliant, microkernel-based real-time operating system used in embedded and safety-critical systems. It provides deterministic real-time performance, high reliability, and fault isolation, making it ideal for automotive, medical, industrial, and aerospace applications.

    Key Points to Mention in Interviews

    • RTOS (Real-Time OS) → Guarantees predictable response times
    • Microkernel architecture → Only essential services (scheduler, IPC, interrupts) run in kernel
    • Fault tolerant → A crashing driver doesn’t crash the whole system
    • POSIX compliant → Familiar Linux/UNIX APIs
    • High reliability & safety → Used in ADAS, infotainment, medical devices
    • Message-passing IPC → Core communication mechanism
    • Certified OS → ISO 26262, IEC 61508, etc.

    Where QNX is Used

    • Automotive (Infotainment, ADAS, Digital Cockpits)
    • Medical Devices
    • Industrial Automation
    • Aerospace & Defense
    • Robotics

    QNX is a real-time operating system (RTOS).

    Interview-Ready Answer

    QNX is a hard real-time operating system that provides deterministic and predictable response times, which makes it suitable for safety-critical embedded systems.

    Why QNX is Real-Time

    • Deterministic scheduling → Guaranteed response within deadlines
    • Microkernel architecture → Minimal kernel, faster interrupt handling
    • Priority-based preemptive scheduling
    • Message-passing IPC → Core real-time communication mechanism
    • Low interrupt latency & jitter

    Hard vs Soft Real-Time

    • QNX = Hard real-time OS
      Missing a deadline is considered a system failure (important for automotive, medical systems).

    Interview One-Liner (Strong)

    QNX is a POSIX-compliant, microkernel-based hard real-time operating system designed for deterministic and safety-critical applications.

    In QNX, a microkernel means that only the most essential operating system services run in the kernel, such as the scheduler, interrupt handling, and inter-process communication (IPC). All other services like device drivers, file systems, networking, and protocol stacks run as user-space processes.

    Key Points to Mention

    1. Minimal Kernel → Only critical functions run in kernel space.
    2. User-space Services → Most OS services run as separate processes, improving stability and fault isolation.
    3. Fault Isolation → If a driver or service crashes, it won’t crash the whole system.
    4. Message-Passing IPC → Kernel facilitates communication between processes efficiently.
    5. Real-Time Friendly → Microkernel keeps latency low, making it suitable for hard real-time applications.

    Example Explanation

    • Suppose the audio driver crashes in QNX → Only that driver stops; the OS and other applications continue running.
    • Contrast this with monolithic kernels (like Linux), where a driver crash can crash the whole system.

    One-Liner for Interviews

    QNX’s microkernel architecture runs only essential services in the kernel, while other services run in user space, providing fault tolerance and real-time performance.

    QNX is a microkernel-based real-time operating system designed for deterministic, safety-critical embedded systems, while Linux is a monolithic, general-purpose OS that is not inherently real-time (unless using PREEMPT_RT patches).

    Key Differences to Mention

    FeatureQNXLinux
    Kernel TypeMicrokernelMonolithic
    Real-Time SupportHard real-time (deterministic)General-purpose; soft real-time with PREEMPT_RT
    Fault IsolationHigh – services run in user space; crashes don’t crash OSLow – kernel modules can crash entire system
    Inter-Process Communication (IPC)Message-passing via microkernelShared memory, signals, pipes (less deterministic)
    Typical Use CaseAutomotive, medical, industrial, aerospaceDesktop, servers, embedded systems (non-critical)
    Memory FootprintSmall, lightweightLarger, heavier
    Boot TimeFast, optimized for embedded systemsSlower, general-purpose boot
    CertificationISO 26262, IEC 61508, DO-178Not generally certified for safety-critical applications

    Example for Interview

    • Automotive Infotainment: QNX → Digital dashboard (hard real-time, fault-tolerant).
    • Desktop Application: Linux → Ubuntu OS on a laptop.

    One-Liner for Interviews

    QNX is a real-time, microkernel OS optimized for safety-critical embedded systems, whereas Linux is a general-purpose monolithic OS with limited real-time support.

    QNX is widely used in embedded and safety-critical systems where reliability, fault tolerance, and real-time performance are essential.

    Key Areas / Industries

    1. Automotive
      • Infotainment systems (digital dashboards, touchscreens)
      • Advanced Driver Assistance Systems (ADAS)
      • Digital cockpits and instrument clusters
    2. Medical Devices
      • Life-support equipment, patient monitors
      • Imaging systems
    3. Industrial Automation
      • Robotics, PLCs, factory automation controllers
      • Process control systems
    4. Aerospace & Defense
      • Avionics and flight control systems
      • Mission-critical embedded electronics
    5. Telecommunications
      • Network switches, base stations
    6. IoT and Embedded Devices
      • Smart appliances, robotics, edge devices

    Example for Interview

    “For example, in automotive, QNX is used in digital dashboards where a crash in the media player or Bluetooth module won’t take down the whole system, thanks to its microkernel architecture.”

    One-Liner

    QNX is commonly used in automotive, medical, industrial, aerospace, and telecommunications systems where reliability and real-time performance are critical.

    QNX is a microkernel-based real-time operating system with features designed for embedded and safety-critical systems, providing high reliability, determinism, and fault tolerance.

    Key Features

    1. Microkernel Architecture
      • Only essential services run in the kernel (scheduler, IPC, interrupts)
      • Other services (drivers, file systems, networking) run in user space
      • Ensures fault isolation and system stability
    2. Real-Time Performance
      • Hard real-time deterministic scheduling
      • Low interrupt latency and predictable response times
      • Priority-based preemptive multitasking
    3. POSIX Compliance
      • Supports standard UNIX/Linux APIs
      • Eases application porting from other systems
    4. Inter-Process Communication (IPC)
      • Efficient message-passing mechanism
      • Supports synchronous and asynchronous communication between processes
    5. Fault Tolerance & High Reliability
      • Crashing of a driver or service does not crash the OS
      • Critical for safety-certified applications
    6. Scalability
      • Runs on small microcontrollers to complex multi-core systems
      • Suitable for both resource-constrained devices and high-end embedded platforms
    7. File System Support
      • Journaling and networked file systems for reliability
      • Can integrate custom embedded file systems
    8. Networking & Communication
      • Supports TCP/IP, CAN, USB, and other industrial protocols
      • Suitable for connected embedded systems
    9. Security & Safety Certification
      • ISO 26262 (Automotive), IEC 61508 (Industrial), DO-178B/C (Aerospace)
      • Enables use in safety-critical applications
    10. Modularity
      • Easy to add/remove components without affecting the kernel
      • Lightweight and customizable for specific embedded use cases

    Example for Interview

    “For instance, in an automotive digital dashboard, QNX ensures that even if the media or Bluetooth service crashes, the display of speed, fuel, and engine status continues to work reliably, thanks to its microkernel architecture and fault isolation.”

    One-Liner for Interviews

    QNX features a microkernel architecture, hard real-time performance, fault tolerance, POSIX compliance, scalable modular design, and is certified for safety-critical systems.

    POSIX compliance in QNX means that the operating system supports standard UNIX/Linux APIs and interfaces, allowing developers to write portable applications that can run on QNX with minimal changes.

    Key Points to Mention

    1. Standardized API
      • QNX provides POSIX-compliant system calls for file I/O, process management, threading, signals, and IPC.
      • Makes it familiar to developers coming from Linux or UNIX environments.
    2. Portability
      • Applications written using POSIX APIs can be easily ported between QNX and other POSIX-compliant systems.
    3. Real-Time Extensions
      • QNX extends POSIX with real-time features, such as real-time scheduling (SCHED_FIFO, SCHED_RR) and priority inheritance mutexes.
    4. Example APIs in QNX
      • File operations: open(), read(), write(), close()
      • Threads: pthread_create(), pthread_join()
      • IPC: mq_open(), mq_send(), mq_receive() (message queues)
    5. Why It Matters
      • Reduces development time and learning curve
      • Enables cross-platform development for embedded systems
      • Ensures consistency and standard compliance in embedded applications

    Example for Interview

    “If you have an application written for Linux using standard POSIX threads and message queues, you can port it to QNX almost directly because QNX supports the same POSIX APIs, while also providing real-time guarantees.”

    One-Liner for Interviews

    POSIX compliance in QNX ensures standard UNIX/Linux API support, enabling application portability and consistent development while adding real-time capabilities.

    QNX is a proprietary operating system developed by BlackBerry. It is not open source, and its source code is licensed under commercial terms.

    Key Points to Mention

    1. Proprietary License
      • QNX requires a commercial license for development and deployment.
      • Source code is not freely available to the public.
    2. Commercial Support
      • BlackBerry provides official support, updates, and safety certifications.
      • Essential for automotive, medical, and industrial applications.
    3. Contrast with Open Source OS
      • Linux, FreeRTOS → Open source, source code freely available.
      • QNX → Closed-source, with guaranteed reliability and certification.
    4. Why Proprietary Matters
      • Ensures controlled development, rigorous testing, and compliance with safety standards like ISO 26262 or IEC 61508.

    One-Liner for Interviews

    QNX is a proprietary, commercially licensed real-time operating system with source code controlled by BlackBerry.

    Neutrino is the microkernel-based real-time operating system (RTOS) at the core of QNX. It provides the fundamental services like scheduling, inter-process communication (IPC), and interrupt handling, enabling QNX to deliver deterministic, reliable, and fault-tolerant performance in embedded systems.

    Key Points to Mention

    1. Core of QNX
      • Neutrino is the actual OS kernel.
      • All QNX services (file system, networking, drivers) run on top of Neutrino.
    2. Microkernel Architecture
      • Only essential functions (scheduler, IPC, interrupt handling) are in the Neutrino kernel.
      • Other services run in user space → better fault isolation.
    3. Real-Time Capabilities
      • Supports hard real-time scheduling.
      • Ensures predictable response times for critical applications.
    4. POSIX Compliance
      • Neutrino implements POSIX APIs, allowing applications to be portable from UNIX/Linux.
    5. Fault-Tolerant
      • If a driver or service crashes, Neutrino keeps the system running.

    Example for Interview

    “In an automotive dashboard, Neutrino ensures that the speedometer and fuel gauge continue updating even if a non-critical service like media playback crashes, thanks to its microkernel design.”

    One-Liner for Interviews

    Neutrino is the microkernel RTOS at the heart of QNX, providing deterministic real-time performance, POSIX compliance, and fault tolerance for embedded systems.

    Deterministic behavior in an RTOS means that the system responds to events or interrupts within a guaranteed, predictable amount of time, regardless of system load. This is essential for real-time applications where timing is critical.

    Key Points to Mention

    1. Predictable Response
      • A deterministic RTOS ensures that tasks meet their deadlines consistently.
      • Example: If a sensor triggers an interrupt, the OS handles it within a fixed maximum latency.
    2. Critical for Real-Time Systems
      • Timing guarantees are required in automotive, medical, aerospace, and industrial systems.
      • Missing deadlines can lead to system failures or safety hazards.
    3. Determinism vs Speed
      • Determinism focuses on predictability, not just fast execution.
      • Even if execution is slightly slower, as long as timing is predictable, it’s considered deterministic.
    4. Example
      • In a car’s ABS system, the RTOS must read wheel speed sensors and control brakes within exact deadlines. QNX ensures this deterministic behavior.

    One-Liner for Interviews

    Deterministic behavior in an RTOS means predictable, guaranteed response times to events or interrupts, ensuring real-time deadlines are always met.

    The latest major version of QNX is QNX Software Development Platform (SDP) 8.0. It includes:

    • QNX OS 8.0 – The core microkernel-based real-time operating system.
    • QNX OS for Safety 8.0 – Safety-certified edition for critical systems (ISO 26262, IEC 61508).
    • QNX Hypervisor 8.0 – Embedded virtualization platform.
    • QNX Momentics IDE 8.0.x – Development environment supporting SDP 8.0.

    Key Points:

    • Designed for embedded and safety-critical systems.
    • Provides deterministic real-time performance.
    • Supports fault isolation and microkernel architecture.

    One-Liner for Interviews:

    “QNX SDP 8.0 is the latest version, with QNX OS 8.0 at its core, optimized for embedded and safety-critical applications.”

    QNX Architecture

    QNX Architecture Overview

    QNX is a microkernel-based real-time operating system (RTOS). Its architecture is designed for high reliability, modularity, and real-time performance.

    The main layers are:

    1. Microkernel

    • Core of QNX.
    • Very small and minimal: only contains the most essential OS functions.
    • Responsibilities:
      • Task scheduling (prioritized, real-time scheduling)
      • Interprocess communication (IPC)
      • Interrupt handling
      • Timers
      • Low-level memory management
    • All other OS services run as user-space processes, not inside the kernel.

    Key point: This design improves stability because a crash in a service doesn’t crash the entire system.

    2. Process Managers (User-space Services)

    These are system services that run outside the kernel, providing higher-level OS functionalities:

    ServiceFunction
    File SystemManages files, directories, and storage devices.
    Network StackHandles TCP/IP, UDP, and network protocols.
    Device DriversHardware control (keyboard, serial, audio, display) as user-space tasks.
    Resource ManagersUnified interface for devices & files, exposing them as files (/dev).
    Timers / ClocksUser-space timers and scheduling assistance.
    • These services communicate with each other and with the microkernel via IPC.
    • Because they are separate from the kernel, if one fails, the system can continue running.

    3. Application Layer

    • Your user applications run here.
    • They request services via standard APIs or POSIX calls, which get translated into IPC messages to the microkernel or system services.
    • Applications are fully isolated, which enhances reliability.

    4. Communication Model

    • QNX uses message-passing IPC instead of traditional system calls.
    • Every process can send and receive messages synchronously or asynchronously.
    • This ensures determinism, essential for real-time systems.

    5. Memory Architecture

    • Microkernel handles basic memory protection.
    • Applications and services are isolated in their own address space, preventing accidental overwrites.
    • Memory faults in one service usually do not affect the kernel or other services.

    6. Highlights of QNX Architecture

    • Modular & Scalable: Add/remove services without touching the kernel.
    • Fault-Tolerant: Crashes in user-space services don’t crash the kernel.
    • Deterministic: Real-time scheduling ensures predictable behavior.
    • POSIX-Compliant: Supports standard APIs for portability.

    Architecture Diagram (Text Representation)

    +----------------------------------+
    |         User Applications        |
    +----------------------------------+
    |        POSIX APIs / Libraries    |
    +----------------------------------+
    |       User-Space Services        |
    |  (File System, Network, Drivers)|
    +----------------------------------+
    |           Microkernel            |
    |  (Scheduler, IPC, Interrupts)   |
    +----------------------------------+
    |           Hardware Layer         |
    +----------------------------------+
    

    Interview-Friendly Answer:

    “QNX has a microkernel-based architecture, where the kernel is minimal and handles only essential functions like task scheduling, interprocess communication (IPC), interrupt handling, and memory management. All other services, such as file systems, network stacks, and device drivers, run as user-space processes, communicating with the kernel and each other via IPC. Applications run on top of these services using POSIX APIs. This modular design ensures high reliability, fault tolerance, and deterministic real-time performance, making QNX ideal for embedded and safety-critical systems.”

    Explanation of the Diagram

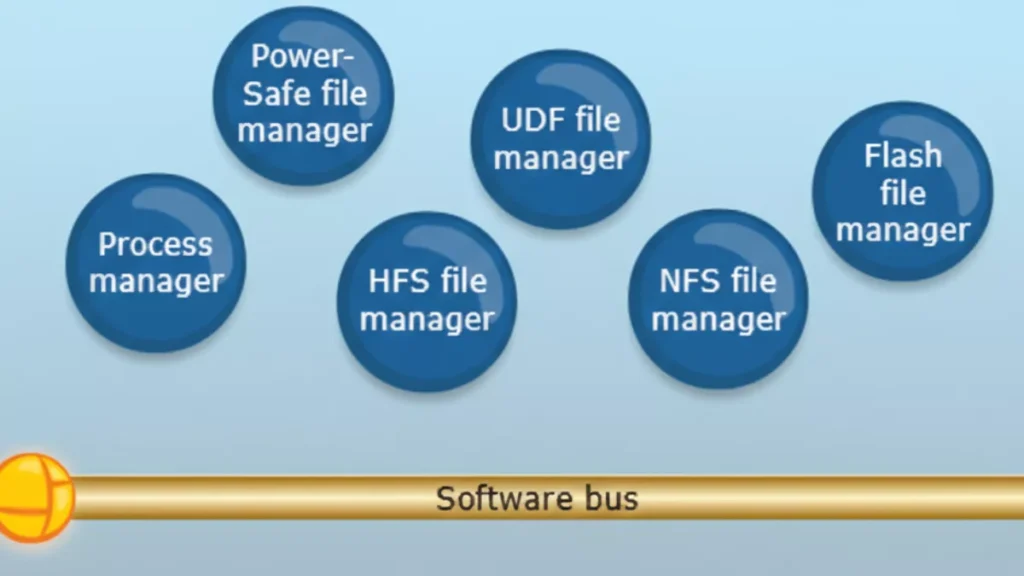
    1. Software Bus (Middle Layer)
      • Acts as a communication backbone for all user-space managers and applications.
      • All managers (file, network, GUI, character, etc.) and applications communicate with each other through this message-passing mechanism.
      • Essentially, this is how QNX implements microkernel principles: minimal kernel + IPC.
    1. Upper Layer: File and Process Managers
      These are system-level services running in user space:
      • Process Manager: Handles process creation, deletion, and scheduling requests.
      • File Managers: Manage different types of file systems:
        • Power-Safe file manager
        • UDF file manager
        • HFS file manager
        • NFS file manager
        • Flash file manager
      • These managers communicate via the software bus, instead of being inside the kernel.
    1. Lower Layer: Applications and Resource Managers
      • GUI Manager: Handles graphical interface.
      • Character Manager: Handles character devices (e.g., keyboard, serial port).
      • Network Manager: Handles network services.
      • Mqueue Manager: Manages message queues (IPC feature).
      • CIFS File Manager: For network file sharing (SMB/CIFS).
      • Applications: End-user or embedded applications running on top of these managers.

    Key Takeaways

    • This diagram shows QNX’s modular microkernel architecture in action:
      • Microkernel: Handles only essential kernel tasks (not shown explicitly in this diagram; it’s below the software bus, managing IPC, scheduling, and interrupts).
      • Software bus: Allows all user-space managers and applications to communicate.
      • Managers: Implement higher-level OS services in user space.
      • Applications: Sit at the top and use these services via message passing.
    • If one manager crashes, it doesn’t crash the kernel or other managers, highlighting QNX’s fault-tolerant design.

    Interview Tip:
    You can say:

    “This diagram shows QNX Neutrino’s user-space architecture. System managers like file managers, network manager, GUI manager, and process manager run as independent processes in user space. Applications communicate with these managers via the software bus, which implements the microkernel’s message-passing IPC. This design makes QNX highly modular, fault-tolerant, and suitable for real-time embedded systems.”

    QNX uses a microkernel architecture, meaning the operating system kernel is kept very small and only contains the most critical functions.
    All other OS services run as separate user-space processes, not inside the kernel.

    What Runs Inside the QNX Microkernel?

    The QNX Neutrino microkernel includes only four core responsibilities:

    1. Thread scheduling
      • Priority-based, fully preemptive
      • Ensures deterministic real-time behavior
    2. Inter-Process Communication (IPC)
      • Message passing (MsgSend, MsgReceive, MsgReply)
      • This is the heart of QNX
    3. Interrupt handling
      • Fast and predictable interrupt response
    4. Low-level thread and process management

    Nothing else runs in kernel space

    What Runs Outside the Kernel (User Space)?

    All higher-level OS services are implemented as user-space servers:

    • File systems (e.g., /fs-qnx6.so)
    • Device drivers (UART, I2C, SPI, Audio, Network)
    • Networking stack (TCP/IP)
    • Process manager (procnto)
    • Memory manager
    • Resource managers

    These components communicate using message passing.

    QNX Architecture Overview (Logical Flow)

    +-----------------------+
    |   Applications          |
    +-----------------------+
              |
              |  Message Passing (IPC)
              |
    +-----------------------+
    | OS Services / Servers |
    | (Drivers, FS, Net)         |
    +-----------------------+
              |
              | IPC
              |
    +-----------------------+
    |   Microkernel         |
    | (Scheduler, IPC, IRQ)|
    +-----------------------+
              |
    +-----------------------+
    |      Hardware         |
    +-----------------------+
    

    Message Passing – The Core Concept

    Unlike Linux (which uses system calls heavily), QNX uses:

    • Synchronous message passing
    • Client sends request → server processes → replies

    Example:

    • App wants to write to a UART
    • App sends message to UART driver
    • UART driver responds after operation
    • No shared memory required
    • Strong isolation
    • Predictable timing

    Why Microkernel? (Advantages)

    1. High Reliability

    • If a driver crashes, only that process restarts
    • Kernel remains unaffected

    2. Fault Tolerance

    • Ideal for safety-critical systems (ASIL-D)

    3. Deterministic Real-Time Behavior

    • Guaranteed response times
    • Used in automotive and medical systems

    4. Security

    • Smaller kernel → smaller attack surface

    QNX vs Linux (Interview Comparison)

    FeatureQNXLinux
    Kernel typeMicrokernelMonolithic
    DriversUser spaceKernel space
    IPCMessage passingSyscalls + shared memory
    Real-timeNativeNeeds RT patches
    Fault isolationStrongWeak
    Safety certificationYes (ASIL-D)Limited

    Real-World Example (Automotive)

    In a car infotainment system:

    • Audio driver crashes
    • Only audio service restarts
    • Navigation and UI keep running

    This is why QNX is used in automotive ECUs

    One-Line Interview Answer

    QNX uses a microkernel architecture where only scheduling, IPC, interrupts, and thread management run in the kernel, while all other services like drivers and file systems run in user space as separate processes, ensuring high reliability, fault isolation, and deterministic real-time behavior.

    In QNX (Neutrino), the kernel space contains only the most critical real-time components. Everything else runs in user space.

    The following run in kernel space:

    1. Thread Scheduling

    • Priority-based, fully preemptive scheduler
    • Ensures deterministic real-time behavior
    • Handles context switching

    2. Inter-Process Communication (IPC)

    • Core message passing mechanism
    • MsgSend(), MsgReceive(), MsgReply()
    • Fast, synchronous IPC

    IPC is the heart of QNX

    3. Interrupt Handling

    • Low-latency interrupt dispatching
    • Interrupt Service Routines (ISRs)
    • Interrupt events delivery to threads

    4. Low-Level Thread & Process Management

    • Thread creation and destruction
    • Basic process control
    • Kernel-level synchronization primitives

    What Does NOT Run in Kernel Space?

    These run in user space, not kernel space:

    • Device drivers (UART, I2C, SPI, Audio, Network)
    • File systems
    • Memory manager
    • Network stack (TCP/IP)
    • Process manager (procnto)
    • Resource managers

    One-Line Interview Answer

    In QNX, kernel space contains only the microkernel responsible for scheduling, message-passing IPC, interrupt handling, and low-level thread management; all other OS services and drivers run in user space.

    Memory Tip for Interviews

    Think S-I-I-T:

    • Scheduling
    • IPC
    • Interrupts
    • Threads

    In QNX Neutrino, almost everything except the microkernel runs in user space as separate processes (servers).

    Major Components Running in User Space

    1. Process Manager (procnto)

    • Handles:
      • Process creation (fork, spawn)
      • Signal delivery
      • POSIX compliance
    • Acts as the root server of the system

    2. Memory Manager

    • Virtual memory management
    • Address space creation
    • Memory protection
    • Page faults handling (with kernel support)

    3. Device Drivers

    • UART, I2C, SPI, CAN
    • Audio, Display, Camera
    • GPIO, ADC, PWM
    • Network drivers
    • Run as normal user processes
    • Can be restarted if they crash

    4. File Systems

    • QNX6 filesystem
    • Flash file systems
    • Network file systems
    • Mounted under /

    5. Network Stack

    • TCP/IP stack
    • Ethernet, Wi-Fi drivers
    • Socket services

    6. Resource Managers

    • Implement POSIX-style resources
    • Expose services as files (e.g. /dev/ser1)
    • Handle open/read/write/ioctl

    7. System Services & Daemons

    • Audio services
    • Power management
    • Clock services
    • Logging services

    8. User Applications

    • HMI / UI apps
    • Control logic
    • Diagnostic tools
    • Middleware

    QNX User Space Layout (Conceptual)

    +----------------------+
    |   User Applications  |
    +----------------------+
    | System Services      |
    | File Systems         |
    | Network Stack        |
    | Device Drivers       |
    | Resource Managers    |
    | procnto              |
    +----------------------+
            |
            | IPC (message passing)
            |
    +----------------------+
    |   Microkernel        |
    +----------------------+
    

    Why This Design Matters

    Fault Isolation

    • Driver crash ≠ system crash

    Easy Recovery

    • Restart a single service

    Safety Certification

    • Ideal for ASIL-D systems

    Secure Architecture

    • Minimal kernel attack surface

    One-Line Interview Answer

    In QNX, user space contains the process manager, memory manager, device drivers, file systems, network stack, resource managers, system services, and all applications—each running as separate processes that communicate via message passing.

    QNX uses message passing as its core communication mechanism to achieve deterministic real-time behavior, fault isolation, reliability, and scalability in a microkernel architecture.

    1. Fits the Microkernel Design

    QNX keeps the kernel very small.
    Since drivers, file systems, and services run in user space, they must communicate safely.

    ➡ Message passing replaces shared kernel data structures

    • No direct function calls across protection boundaries
    • Clean client–server model

    2. Deterministic Real-Time Behavior (Key Reason)

    Message passing in QNX is:

    • Synchronous
    • Priority-aware

    What this means:

    • Client blocks until server replies
    • Server temporarily inherits the client’s priority (priority inheritance)

    ✔ Prevents priority inversion
    ✔ Guarantees bounded latency
    ✔ Ideal for hard real-time systems

    3. Strong Fault Isolation & Reliability

    • Each driver/service runs as a separate process
    • If a driver crashes:
      • Kernel stays alive
      • Other services keep running
      • Only the failed service is restarted

    ➡ Message passing enforces strict process isolation

    4. Security by Design

    • No shared memory by default
    • No arbitrary kernel access
    • Services only expose controlled interfaces

    ➡ Smaller attack surface than monolithic kernels

    5. Unified Communication Model

    QNX uses one mechanism everywhere:

    OperationImplemented via
    File I/O (read/write)Messages
    Device accessMessages
    Network stackMessages
    Signals & eventsMessages

    ➡ Simpler OS design
    ➡ Easier to reason about timing

    6. Zero-Copy Efficiency

    Despite being message-based:

    • QNX supports zero-copy transfers
    • Uses shared memory only when explicitly needed

    ➡ High performance with real-time guarantees

    7. Easier Debugging & Maintenance

    • Services can be:
      • Stopped
      • Replaced
      • Restarted
    • No kernel rebuild required

    ➡ Faster development and safer updates

    Real Example (Automotive)

    • Audio application → sends message to audio driver
    • Audio driver crashes
    • Audio service restarts
    • Navigation & safety systems continue running

    ➡ System does not reboot

    One-Line Interview Answer

    QNX uses message passing to enable safe and deterministic communication between user-space services in its microkernel architecture, providing real-time predictability, fault isolation, priority inheritance, and high system reliability.

    Memory Trick for Interviews

    Think D-R-F-S-U:

    • Determinism
    • Reliability
    • Fault isolation
    • Security
    • Unified IPC

    Resource managers in QNX are user-space server processes that implement POSIX-style resources (files, devices, pseudo-devices) and expose them through the filesystem namespace using message passing.

    In simple words:

    A resource manager lets a user-space service behave like a file or device (e.g. /dev/ser1).

    Why Resource Managers Exist

    QNX follows the principle:

    “Everything is a file”

    Instead of placing drivers in kernel space (like Linux), QNX uses resource managers in user space to handle:

    • open()
    • read()
    • write()
    • ioctl()
    • close()

    All these calls are translated into messages.

    Where Do Resource Managers Run?

    • User space
    • As normal processes
    • Communicate with clients via QNX IPC (message passing)
    • Crash-safe
    • Restartable
    • Isolated

    Common Examples of Resource Managers

    ResourceExample
    Serial driver/dev/ser1
    GPIO/dev/gpioX
    Audio/dev/snd/*
    Custom device/dev/mydevice
    Pseudo file/proc, /dev/random

    How a Resource Manager Works (Flow)

    1. Application calls:fd = open("/dev/ser1", O_RDWR);
    2. Kernel converts this into a message
    3. Message is sent to the resource manager
    4. Resource manager processes the request
    5. Sends a reply back to the application

    Key Components of a Resource Manager

    1. Dispatch Layer

    • Receives messages
    • Routes them to appropriate handlers

    2. Connect Functions

    • Handle:
      • open()
      • close()

    3. I/O Functions

    • Handle:
      • read()
      • write()
      • ioctl()

    Types of Resource Managers

    Device Resource Managers

    • Hardware drivers (UART, I2C, CAN)

    Filesystem Resource Managers

    • QNX6, Flash FS

    Pseudo Resource Managers

    • Virtual or logical devices

    Benefits of Resource Managers

    Fault Isolation

    • Driver crash ≠ system crash

    POSIX Compliance

    • Standard file APIs

    Real-Time Friendly

    • Priority inheritance during IPC

    Easy Debugging

    • Run, stop, restart like any process

    QNX vs Linux (Quick Comparison)

    FeatureQNXLinux
    Driver locationUser spaceKernel space
    InterfaceFile-basedSyscalls
    Crash impactLocalOften system-wide
    IPCMessage passingFunction calls

    One-Line Interview Answer

    Resource managers in QNX are user-space processes that expose devices and services as POSIX-compliant files, handling open/read/write/ioctl requests via message passing, enabling fault isolation and real-time reliability.

    The microkernel’s role in QNX is to provide the core real-time foundation by handling thread scheduling, message-passing IPC, interrupt handling, and basic process/thread management, while all other OS services run in user space.

    QNX achieves fault tolerance by running drivers and OS services in user space, using message passing for isolation, and allowing failed components to be restarted without affecting the microkernel or the rest of the system.

    How QNX Achieves Fault Tolerance (Key Points)

    1. Microkernel Architecture
      • Kernel contains only scheduling, IPC, and interrupts
      • Minimal kernel → fewer failure points
    2. User-Space Drivers & Services
      • Device drivers, file systems, network stack run as separate processes
      • A crash affects only that component, not the whole OS
    3. Message Passing (Strong Isolation)
      • No shared kernel data by default
      • Faults are contained within a single process
    4. Service Restart & Recovery
      • Failed services/drivers can be restarted dynamically
      • System continues running
    5. Priority Inheritance in IPC
      • Prevents priority inversion during communication
      • Maintains real-time stability even under faults
    6. Health Monitoring (Optional)
      • Watchdogs and supervisors can detect failures and relaunch services

    Adaptive Partitioning in QNX is a CPU resource management mechanism that guarantees each group of threads a minimum percentage of CPU time, while dynamically redistributing unused CPU to other partitions.

    Key Points (Simple)

    • CPU time is divided into partitions
    • Each partition has a guaranteed minimum CPU budget
    • Unused CPU is adaptively shared with others
    • Ensures real-time tasks are never starved

    Why QNX Uses Adaptive Partitioning

    • Prevents CPU starvation
    • Improves system predictability
    • Supports mixed-criticality systems (safety + infotainment)

    Example

    PartitionCPU Guarantee
    Safety tasks40%
    Audio30%
    UI20%
    Background10%
    • If UI uses only 10%, the extra 10% is temporarily used by others
    • When UI needs CPU again, it gets its guaranteed share back

    Where It’s Used

    • Automotive ECUs
    • Medical devices
    • Industrial control systems

    One-Line Interview Answer

    Adaptive partitioning ensures guaranteed CPU bandwidth for critical tasks while efficiently sharing unused CPU among other processes.

    A thread in QNX is the smallest schedulable unit of execution that runs within a process and is scheduled by the microkernel based on priority.

    Key points:

    • Executes code
    • Has its own:
      • Program counter
      • Stack
      • Priority
    • Shares process resources (memory, file descriptors)
    • Scheduled directly by the QNX microkernel

    A process in QNX is a protected container that provides an address space and resources for one or more threads.

    Key points:

    • Owns:
      • Virtual address space
      • File descriptors
      • Signals
      • Permissions
    • Contains one or more threads
    • Provides isolation from other processes

    Relationship (Easy to Remember)

    • Process = container
    • Thread = worker
    Process
     ├── Thread 1 (main thread)
     ├── Thread 2
     └── Thread 3
    

    QNX-Specific Interview Highlight

    • Threads are the real-time scheduling entities, not processes
    • Priority, IPC, and interrupts are all thread-centric

    One-Line Comparison (Interview Gold)

    In QNX, a process provides isolation and resources, while threads are the actual execution units scheduled by the microkernel.

    Thread States in QNX

    In QNX Neutrino, a thread can exist in the following main states:

    1. READY

    • Thread is ready to run
    • Waiting for CPU
    • Placed in a priority-based ready queue

    2. RUNNING

    • Thread is currently executing on the CPU

    3. BLOCKED

    • Thread is waiting for an event or resource

    Common reasons:

    • Waiting for a message (MsgReceive)
    • Waiting for a reply (MsgSend)
    • Waiting for I/O
    • Waiting for a mutex or semaphore
    • Sleeping (nanosleep)

    4. STOPPED

    • Thread execution is suspended

    Causes:

    • Debugger attached
    • Job control signals (e.g. SIGSTOP)
    • Explicit suspension

    5. WAITING (ZOMBIE – process level)

    • Thread has exited
    • Waiting for parent process to collect status

    Note: Zombie is mainly a process concept, but threads can be in a terminated state internally.

    Simple State Diagram (Interview Friendly)

    READY → RUNNING → BLOCKED
      ↑        ↓         |
      └────────┴─────────┘
            STOPPED
    

    Important QNX Interview Points

    • Threads (not processes) are scheduled
    • Scheduling is priority-based and preemptive
    • IPC operations heavily influence BLOCKED states
    • Message passing directly affects thread transitions

    One-Line Interview Answer

    In QNX, threads transition between READY, RUNNING, BLOCKED, and STOPPED states, with scheduling handled at the thread level using priority-based preemption.

    Memory Trick

    Think R-R-B-S:

    • Ready
    • Running
    • Blocked
    • Stopped

    Thread Scheduling Algorithm in QNX

    QNX uses a priority-based, fully preemptive, deterministic thread scheduling algorithm, designed for hard real-time systems.

    Core Characteristics

    1. Priority-Based Scheduling

    • Each thread has a fixed priority
    • Priority range: 0 (lowest) to 255 (highest)
    • Highest-priority READY thread always runs

    2. Fully Preemptive

    • If a higher-priority thread becomes READY:
      • It immediately preempts the currently running thread
    • Ensures fast response for real-time tasks

    3. Round-Robin Within Same Priority

    • Threads with the same priority share CPU time
    • Each gets a time slice
    • Prevents starvation among equal-priority threads

    4. Thread-Centric Scheduling

    • QNX schedules threads, not processes
    • Each thread is an independent scheduling entity

    5. Deterministic Behavior

    • Scheduling decisions are predictable
    • No dynamic priority changes by default
    • Ideal for safety-critical systems

    Scheduling Flow (Simple)

    1. Scheduler checks READY queues (highest → lowest priority)
    2. Picks the highest-priority READY thread
    3. Thread runs until:
      • It blocks
      • Its time slice expires (same-priority case)
      • A higher-priority thread becomes READY

    Priority Inheritance (Very Important)

    • Used during message passing and mutex locking
    • If a high-priority thread is blocked by a lower-priority one:
      • Lower-priority thread temporarily inherits the higher priority
    • Prevents priority inversion

    Comparison with Linux (Interview Highlight)

    FeatureQNXLinux
    SchedulingFixed priorityCFS (dynamic)
    PreemptionAlwaysConfig-dependent
    DeterminismGuaranteedBest-effort
    Priority inheritanceBuilt-inPartial

    One-Line Interview Answer

    QNX uses a priority-based, fully preemptive scheduling algorithm where the highest-priority ready thread always runs, with round-robin scheduling among threads of equal priority and priority inheritance to prevent inversion.

    Conclusion

    QNX is not just another operating system—it is built for environments where reliability, predictability, and safety truly matter. Understanding QNX means understanding how real-time systems behave under pressure, how failures are isolated, and how software can continue running even when individual components crash.

    These interview questions and answers are meant to help you think like a QNX engineer, not just repeat definitions. By focusing on microkernel design, message passing, scheduling, fault tolerance, and system design choices, this content prepares you to explain why QNX works the way it does, not just what it is.

    If you can clearly explain these concepts in your own words during an interview, it shows strong fundamentals, real project exposure, and confidence in system-level thinking—qualities that interviewers look for in embedded and automotive roles.

    Master the concepts, relate them to real use cases, and you won’t just clear a QNX interview—you’ll stand out as someone who truly understands the system.

    FAQ : QNX OS Interview Questions

    1. What is QNX OS?

    QNX is a real-time operating system (RTOS) designed for systems that require high reliability, deterministic performance, and fault tolerance. It is widely used in automotive, medical, industrial, and safety-critical embedded systems.

    2. Why is QNX called a microkernel operating system?

    QNX uses a microkernel architecture, meaning only the most essential services (scheduling, IPC, interrupt handling) run in kernel space. All other services run in user space, improving system stability and fault isolation.

    3. How is QNX different from Linux?

    Linux uses a monolithic kernel, while QNX uses a microkernel. In QNX, drivers and services run in user space and can be restarted if they fail, whereas in Linux, a faulty driver can crash the entire system.

    4. What runs in kernel space in QNX?

    Only critical components run in kernel space:

    • Thread scheduling
    • Inter-process communication (IPC)
    • Interrupt handling
    • Low-level synchronization

    This keeps the kernel small and reliable.

    5. What runs in user space in QNX?

    Most system services run in user space, including:

    • Device drivers
    • File systems
    • Network stacks
    • Resource managers
    • System services

    This design improves fault tolerance.

    6. Why does QNX use message passing?

    QNX uses message passing for IPC to ensure:

    • Deterministic communication
    • Strong process isolation
    • Safer interaction between services
    • Easier debugging and recovery

    It is a core reason for QNX’s reliability.

    7. What is a resource manager in QNX?

    A resource manager is a user-space server that manages system resources like files, devices, or custom interfaces. Applications interact with resource managers using standard POSIX calls such as open(), read(), and write().

    8. What is the role of the microkernel in QNX?

    The microkernel acts as a traffic controller, handling communication, scheduling, and interrupts while letting user-space services do the rest. This separation makes the system robust and scalable.

    9. How does QNX achieve fault tolerance?

    QNX achieves fault tolerance through:

    • Process isolation
    • User-space drivers
    • Automatic service restart
    • Priority-based scheduling

    A failure in one component does not crash the entire system.

    10. What is adaptive partitioning in QNX?

    Adaptive partitioning ensures CPU time is reserved for critical processes. Even if one process misbehaves, real-time and safety-critical tasks continue to run without disruption.

    11. What is a process in QNX?

    A process is an independent program with its own memory space. It may contain one or more threads and communicates with other processes using message passing.

    12. What is a thread in QNX?

    A thread is the smallest unit of execution in QNX. Threads share the same address space within a process but are scheduled independently.

    13. What are the thread states in QNX?

    Common thread states include:

    • Running
    • Ready
    • Blocked (waiting for IPC or resources)
    • Stopped

    These states help manage real-time execution efficiently.

    14. What scheduling algorithm does QNX use?

    QNX uses priority-based preemptive scheduling. Higher-priority threads always run first, ensuring deterministic real-time behavior.

    Read More about Process : What is is Process
    Read More about System Call in Linux : What is System call
    Read More about IPC : What is IPC
  • QNX OS Interview Questions 2026 : Complete Guide from Beginner to Advanced

    Complete QNX OS interview guide with beginner to advanced questions on RTOS, IPC, scheduling, drivers, debugging, and automotive systems.

    QNX is widely used in safety-critical and real-time embedded systems such as automotive infotainment, ADAS, medical devices, and industrial automation. Preparing for a QNX interview requires much more than memorizing basic RTOS concepts it demands a deep understanding of microkernel architecture, message passing, real-time scheduling, device drivers, memory management, and system-level debugging.

    This article provides a complete and structured set of QNX OS interview questions, carefully arranged from beginner to advanced level. Whether you are a fresher stepping into embedded systems or an experienced engineer working on automotive or safety-critical platforms, these questions will help you assess your knowledge, identify gaps, and prepare confidently for real-world QNX interviews.

    Each section mirrors how QNX is actually used in production systems, making this guide practical, relevant, and industry-focused.

    Why These QNX Interview Questions Are Useful

    These questions are not random or theoretical. They are based on real interview patterns and day-to-day QNX development scenarios.

    Here’s why this question set is genuinely useful:

    • Covers the complete QNX ecosystem
      From microkernel basics to advanced topics like adaptive partitioning, audio services, drivers, and safety isolation, nothing important is skipped.
    • Matches real interview progression
      Interviews usually start with architecture and fundamentals, then move to IPC, scheduling, memory, drivers, and finally system design. This question flow follows the same pattern.
    • Builds strong conceptual clarity
      Many engineers “use” QNX but struggle to explain why things work the way they do. These questions force you to think at system level, not just API level.
    • Helps freshers and experienced engineers alike
      Beginners can start from the basics, while experienced candidates can focus on advanced debugging, performance tuning, audio, and safety-critical design.
    • Automotive and safety focused
      QNX is heavily used in automotive. Topics like ISO 26262, ASIL, hypervisor, fault tolerance, and real-time guarantees are frequently asked and fully covered here.
    • Excellent self-assessment tool
      If you can confidently explain most of these questions, you are interview-ready. If not, they clearly show where you need to revise.

    In short, this question set prepares you not just to pass interviews, but to think like a QNX system engineer.

    QNX OS Interview Questions

    BASIC LEVEL : QNX Fundamentals

    QNX Basics

    1. What is QNX?
    2. Is QNX a real-time operating system?
    3. What does “microkernel” mean in QNX?
    4. How is QNX different from Linux?
    5. Where is QNX commonly used?
    6. What are the main features of QNX?
    7. What does POSIX compliance mean in QNX?
    8. Is QNX open source or proprietary?
    9. What is Neutrino in QNX?
    10. What is deterministic behavior in RTOS?
    11. What is the latest version of QNX?

    QNX Architecture

    1. Explain QNX architecture
    2. Explain QNX microkernel architecture.
    3. What runs in kernel space in QNX?
    4. What runs in user space in QNX?
    5. Why does QNX use message passing?
    6. What are resource managers in QNX?
    7. What is the role of the microkernel?
    8. How does QNX achieve fault tolerance?
    9. What is adaptive partitioning?
    10. What is a thread in QNX?
    11. What is a process in QNX?

    For a detailed explanation of the answer, you can visit : QNX OS Interview Questions and Answer

    BASIC : Boot & Startup

    1. What is the QNX boot sequence?
    2. What is IPL (Initial Program Loader)?
    3. What is IFS (Image File System)?
    4. What is startup code in QNX?
    5. What is the role of procnto?
    6. What is io-pkt?
    7. What is devb-*?
    8. What is devc-*?
    9. What is a startup script?
    10. Where are startup scripts located?

    INTERMEDIATE : Process, Thread & Scheduling

    Processes & Threads

    1. Difference between process and thread in QNX?
    2. What is the default thread scheduling policy?
    3. What is priority inheritance?
    4. What is priority inversion?
    5. How does QNX handle priority inversion?
    6. What is round-robin scheduling?
    7. What is FIFO scheduling?
    8. What is sporadic scheduling?
    9. What is adaptive scheduling?
    10. How many priority levels does QNX support?

    Scheduling

    1. How does QNX guarantee real-time behavior?
    2. What happens if a high-priority thread blocks?
    3. How does QNX handle preemption?
    4. What is timeslice in QNX?
    5. What is thread affinity?
    6. How to bind threads to CPU cores?
    7. How does SMP work in QNX?
    8. How does QNX handle multicore systems?
    9. What is load balancing in QNX?
    10. What is interrupt latency?

    INTERMEDIATE : IPC & Synchronization

    IPC (Message Passing)

    1. Explain QNX message passing.
    2. What is MsgSend()?
    3. What is MsgReceive()?
    4. What is MsgReply()?
    5. What is synchronous vs asynchronous IPC?
    6. Why message passing is faster in QNX?
    7. What happens if a server crashes?
    8. How does QNX recover from server failure?
    9. What is pulse in QNX?
    10. What is a channel?

    Synchronization

    1. What is a mutex?
    2. What is a semaphore?
    3. Difference between mutex and semaphore?
    4. What is condition variable?
    5. What is read-write lock?
    6. How does QNX avoid deadlocks?
    7. What is priority ceiling?
    8. What is priority inheritance mutex?
    9. What are atomic operations?
    10. How to synchronize ISRs with threads?

    INTERMEDIATE : Memory Management

    1. How is memory managed in QNX?
    2. What is virtual memory?
    3. Does QNX support MMU?
    4. What is physical vs virtual address?
    5. What is shared memory?
    6. How to create shared memory in QNX?
    7. What is mmap()?
    8. What is memory partitioning?
    9. What is adaptive partitioning scheduler (APS)?
    10. How does QNX prevent memory starvation?

    INTERMEDIATE : Signals, Timers & Interrupts

    Signals

    1. What are signals in QNX?
    2. Difference between signals and pulses?
    3. How does QNX handle signals?
    4. What is sigaction()?
    5. What is signal masking?

    Timers

    1. What is a timer in QNX?
    2. Difference between POSIX timer and QNX timer?
    3. What is timer_create()?
    4. What is a watchdog timer?
    5. How are timers implemented internally?

    Interrupts

    1. What is ISR in QNX?
    2. How to attach an interrupt?
    3. What is InterruptAttach()?
    4. Difference between ISR and IST?
    5. What is interrupt latency?
    6. How does QNX handle nested interrupts?
    7. What is interrupt masking?
    8. What is pulse from ISR?
    9. Why ISR must be short?
    10. How does QNX handle interrupt priorities?

    ADVANCED : Device Drivers & Resource Managers

    Drivers

    1. What is a QNX device driver?
    2. Difference between Linux and QNX drivers?
    3. What is a resource manager?
    4. What is resmgr_attach()?
    5. What is iofunc_*?
    6. How does open/read/write work in QNX?
    7. What is pathname space?
    8. How does QNX handle /dev?
    9. What is io-pkt architecture?
    10. What is devb block driver?

    Character & Block Drivers

    1. How to write a character driver in QNX?
    2. How to write a block driver in QNX?
    3. How to expose hardware to user space?
    4. How does QNX handle DMA?
    5. How to handle interrupts in drivers?
    6. How to debug QNX drivers?
    7. What is driver hot-plug?
    8. What is devctl()?
    9. What is mount in QNX?
    10. How does filesystem driver work?

    ADVANCED – Networking, Filesystem & Storage

    Networking

    1. What is io-pkt?
    2. How TCP/IP stack works in QNX?
    3. Difference between QNX and Linux networking?
    4. What is socket API in QNX?
    5. How to debug network issues in QNX?
    6. What is PPS (Persistent Publish Subscribe)?
    7. What is Qnet?
    8. How IPC works across nodes?
    9. What is adaptive networking?
    10. How does QNX handle Ethernet drivers?

    Filesystem

    1. What filesystems are supported in QNX?
    2. What is QNX6 filesystem?
    3. What is flash filesystem?
    4. What is wear leveling?
    5. What is power-safe filesystem?
    6. How does QNX handle journaling?
    7. What is fs-qnx6.so?
    8. How to mount filesystem at boot?
    9. What is mount vs fstab?
    10. How to debug filesystem issues?

    EXPERT : Audio, Automotive & Safety

    Audio (Very Important for Automotive)

    1. How ALSA works in QNX?
    2. Difference between Linux ALSA and QNX audio?
    3. What is PCM in QNX?
    4. What is mixer in QNX?
    5. What is audio routing?
    6. What is TDM?
    7. What is I2S in QNX?
    8. How audio service starts in QNX?
    9. How to debug audio latency issues?
    10. How to write a custom audio codec driver?

    Automotive & Safety

    1. What is ASIL?
    2. How QNX supports functional safety?
    3. What is ISO 26262?
    4. What is safety partition?
    5. What is hypervisor in QNX?
    6. Difference between QNX Hypervisor and Linux?
    7. What is secure boot in QNX?
    8. What is trust zone usage in QNX?
    9. How to isolate safety-critical tasks?
    10. How QNX ensures freedom from interference?

    EXPERT : Debugging, Performance & Optimization

    Debugging

    1. How to debug QNX applications?
    2. What is gdb in QNX?
    3. What is pdebug?
    4. How to debug startup issues?
    5. How to debug boot failures?
    6. How to debug drivers?
    7. How to trace IPC?
    8. What is System Profiler?
    9. What is Momentics IDE?
    10. How to analyze thread states?

    Performance

    1. How to reduce IPC latency?
    2. How to optimize scheduling?
    3. How to measure interrupt latency?
    4. How to reduce boot time?
    5. How to optimize memory usage?
    6. How to profile CPU usage?
    7. How to handle CPU starvation?
    8. How to debug deadlocks?
    9. How to detect priority inversion?
    10. How to tune APS parameters?

    ARCHITECT / SYSTEM DESIGN LEVEL

    1. Design a fault-tolerant QNX system.
    2. Design an audio service architecture in QNX.
    3. Design multi-core scheduling for QNX.
    4. Design safe OTA update mechanism in QNX.
    5. Design driver recovery without reboot.
    6. Design IPC between safety and non-safety domains.
    7. Design fast boot system in QNX.
    8. Design logging framework in QNX.
    9. Design watchdog strategy.
    10. Design startup dependency ordering.

    BONUS : REAL INTERVIEW SCENARIO QUESTIONS

    1. Why did you choose QNX over Linux?
    2. How do you debug a hung QNX system?
    3. How do you recover from driver crash?
    4. How do you handle memory leaks in QNX?
    5. How do you ensure real-time guarantees?
    6. What challenges did you face in QNX?
    7. How do you debug race conditions?
    8. How do you handle CPU overload?
    9. How do you design high-availability service?
    10. Explain one QNX project you worked on.

    Conclusion

    QNX is not just another operating system — it is designed for systems where failure is not an option. That’s why interviewers expect more than surface-level knowledge. They look for engineers who understand real-time behavior, fault isolation, IPC, scheduling, drivers, and system reliability.

    This comprehensive list of QNX OS interview questions is designed to help you build that understanding step by step. If you go through these questions honestly and study the areas where you feel weak, you won’t just memorize answers — you’ll gain confidence in how QNX actually works in real products.

    Use this guide as:

    • A revision checklist before interviews
    • A learning roadmap for QNX
    • A benchmark for your embedded systems knowledge

    Mastering these concepts will not only help you clear QNX interviews, but also make you a stronger, more reliable embedded software engineer in real-world projects.

    Frequently Asked Questions (FAQ) : QNX OS Interview Preparation

    1. What is QNX and why is it used in embedded systems?

    QNX is a real-time operating system (RTOS) based on a microkernel architecture. It is widely used in embedded systems because it offers deterministic performance, high reliability, fault isolation, and strong support for safety-critical applications such as automotive infotainment, ADAS, medical devices, and industrial automation.

    2. Is QNX difficult to learn for beginners?

    QNX can feel challenging at first, especially if you are new to RTOS concepts. However, if you already understand C/C++, processes, threads, and basic OS concepts, learning QNX becomes much easier. Starting with microkernel fundamentals and message passing helps build a strong foundation.

    3. How is QNX different from Linux?

    Linux uses a monolithic kernel where most services run in kernel space, while QNX follows a microkernel approach. In QNX, drivers, filesystems, and network stacks run in user space, which improves fault tolerance and system stability—an important requirement for safety-critical systems.

    4. Why is message passing important in QNX?

    Message passing is the core IPC mechanism in QNX. It enables safe, deterministic communication between processes and threads. Because services run in user space, message passing ensures isolation while still delivering high performance and real-time guarantees.

    5. What topics are most important for a QNX interview?

    Interviewers usually focus on:

    • Microkernel architecture
    • IPC (MsgSend, MsgReceive, pulses)
    • Thread scheduling and priorities
    • Memory management
    • Interrupt handling
    • Resource managers and device drivers
    • Debugging and performance tuning
    • Automotive and safety concepts (ISO 26262, ASIL)

    6. Are QNX interview questions more theoretical or practical?

    Most QNX interviews are practical and scenario-based. Interviewers often ask how you debug issues, design fault-tolerant services, handle priority inversion, or recover from driver failures rather than just theoretical definitions.

    7. Is QNX mainly used in automotive projects?

    Automotive is the largest user of QNX today, especially for infotainment and digital cockpits. However, QNX is also widely used in medical devices, railway systems, industrial controllers, networking equipment, and aerospace applications.

    8. Do I need driver development experience to clear a QNX interview?

    Driver knowledge is not mandatory for entry-level roles, but it is a big advantage for experienced positions. Understanding resource managers, interrupt handling, and user-space drivers significantly improves your interview performance.

    9. How should I prepare for advanced QNX interview rounds?

    For advanced rounds, focus on:

    • Real-time scheduling policies
    • Adaptive partitioning (APS)
    • IPC performance tuning
    • Debugging tools (GDB, Momentics, System Profiler)
    • Multicore and SMP behavior
    • System design and fault recovery strategies

    10. Are QNX interviews harder than Linux embedded interviews?

    QNX interviews are usually more system-design oriented and focus heavily on real-time behavior and reliability. While Linux interviews test kernel and driver knowledge, QNX interviews test how well you understand deterministic systems and fault isolation.

    11. Can these QNX interview questions help in real projects?

    Yes. These questions are not just for interviews. They help you understand how QNX systems behave in real products, how services communicate, how failures are handled, and how performance is optimized—skills that are directly applicable to real-world projects.

    12. What level of C/C++ knowledge is required for QNX?

    A solid understanding of C is essential, and C++ is commonly used for application and service development. Knowledge of pointers, memory management, multithreading, and synchronization primitives is critical for working effectively with QNX.

    13. How long does it take to prepare for a QNX interview?

    Preparation time depends on your background. Freshers may need 6–8 weeks, while experienced embedded engineers can revise and prepare in 2–3 weeks by focusing on QNX-specific concepts and practical scenarios.

    14. Is QNX still relevant in 2026 and beyond?

    Yes. QNX continues to be a key platform for safety-critical and automotive systems. With the growth of software-defined vehicles and real-time computing, QNX remains highly relevant.

    15. How should I use this QNX interview question guide effectively?

    Go through the questions section by section. Try to explain each answer in your own words. Wherever you struggle, revise that topic and relate it to real scenarios. This approach will build confidence and improve both interview performance and practical understanding.

    Read More about Process : What is is Process
    Read More about System Call in Linux : What is System call
    Read More about IPC : What is IPC
  • Master Resource Manager in QNX (2026)

    In QNX, a Resource Manager is a core component of the QNX Neutrino RTOS responsible for handling I/O requests from applications for a particular device or virtual resource. It acts like a server that manages access to a resource, similar to how device drivers work in other operating systems — but with more flexibility and user-space implementation options.

    Key Concepts of Resource Manager in QNX:

    1. Abstraction of Resources:

    • Every resource (device, file, network socket, etc.) is represented as a file path in the namespace (e.g., /dev/ser1).
    • A resource manager associates this path with handling logic.

    2. Handles Client Requests:

    • It handles requests like:
      • open(), read(), write(), ioctl(), close()
    • These come from user applications via message passing.

    3. Message Passing Mechanism:

    • QNX is a microkernel OS, and most services are built on interprocess communication (IPC).
    • Applications send messages to resource managers, which process and respond to them.

    4. User-space Drivers:

    • Unlike monolithic kernels, in QNX, many drivers (resource managers) can be run in user space.
    • This improves stability and debuggability.

    5. Based on iofunc Library:

    • QNX provides iofunc_* functions and data structures to simplify resource manager development, handling common POSIX operations.

    Structure of a Resource Manager:

    A typical resource manager:

    1. Registers a path (like /dev/mydevice) using resmgr_attach().
    2. Initializes attributes and function tables (e.g., io_read, io_write).
    3. Enters a dispatch loop to receive and process client messages.

    Benefits:

    • Modular design – easy to write, update, and test drivers/services.
    • Secure – isolation between services via IPC.
    • Real-time friendly – built on QNX’s predictable scheduling and messaging.

    Example Use Cases:

    • Writing a driver for a custom hardware device
    • Creating a virtual device (e.g., /dev/random)
    • Handling a network protocol stack
    • Simulating a filesystem interface

    Simple QNX resource manager example in C

    Creates a virtual device (e.g., /dev/mydevice) and supports basic read() and write() operations.

    Goal:

    Create a resource manager for a virtual device /dev/mydevice, where:

    • read() returns a fixed message.
    • write() accepts input but doesn’t store it.

    Main Components:

    1. Initialization (dispatch, iofunc)
    2. Attaching to /dev/mydevice
    3. Handling read and write
    4. Dispatch loop

    Code: Basic Resource Manager

    #include <stdio.h>
    #include <stdlib.h>
    #include <string.h>
    #include <unistd.h>
    #include <fcntl.h>
    #include <sys/iofunc.h>
    #include <sys/dispatch.h>
    
    // Global dispatch handle
    static resmgr_connect_funcs_t connect_funcs;
    static resmgr_io_funcs_t io_funcs;
    static iofunc_attr_t attr;
    
    // Data to be returned on read
    const char* msg = "Hello from /dev/mydevice!\n";
    
    int io_read(resmgr_context_t* ctp, io_read_t* msg_hdr, iofunc_ocb_t* ocb) {
        int nbytes;
        int msg_len = strlen(msg);
    
        if (ocb->offset >= msg_len)
            return 0;  // EOF
    
        nbytes = min(msg_len - ocb->offset, msg_hdr->i.nbytes);
        _IO_SET_READ_NBYTES(ctp, nbytes);
    
        memcpy(_RESMGR_PTR(ctp, msg_hdr), msg + ocb->offset, nbytes);
        ocb->offset += nbytes;
    
        return _RESMGR_NPARTS(0);
    }
    
    int io_write(resmgr_context_t* ctp, io_write_t* msg_hdr, iofunc_ocb_t* ocb) {
        char buf[1024] = {0};
        int nbytes = msg_hdr->i.nbytes;
    
        if (nbytes > sizeof(buf) - 1)
            nbytes = sizeof(buf) - 1;
    
        resmgr_msgread(ctp, buf, nbytes, sizeof(io_write_t));
        buf[nbytes] = '\0';
    
        printf("Received from client: %s\n", buf);
    
        _IO_SET_WRITE_NBYTES(ctp, nbytes);
        return EOK;
    }
    
    int main(int argc, char** argv) {
        resmgr_attr_t resmgr_attr;
        dispatch_t* dpp;
        dispatch_context_t* ctp;
    
        dpp = dispatch_create();
        if (!dpp) {
            perror("dispatch_create");
            exit(EXIT_FAILURE);
        }
    
        memset(&resmgr_attr, 0, sizeof(resmgr_attr));
        resmgr_attr.nparts_max = 1;
        resmgr_attr.msg_max_size = 2048;
    
        iofunc_func_init(_RESMGR_CONNECT_NFUNCS, &connect_funcs,
                         _RESMGR_IO_NFUNCS, &io_funcs);
    
        io_funcs.read = io_read;
        io_funcs.write = io_write;
    
        iofunc_attr_init(&attr, S_IFCHR | 0666, NULL, NULL);
    
        if (resmgr_attach(dpp, &resmgr_attr, "/dev/mydevice", _FTYPE_ANY, 0,
                          &connect_funcs, &io_funcs, &attr) == -1) {
            perror("resmgr_attach");
            exit(EXIT_FAILURE);
        }
    
        ctp = dispatch_context_alloc(dpp);
    
        printf("Resource manager running. Access /dev/mydevice\n");
        while (1) {
            if ((ctp = dispatch_block(ctp)) != NULL)
                dispatch_handler(ctp);
        }
    
        return 0;
    }
    

    Build & Run:

    qcc -o myresmgr myresmgr.c
    ./myresmgr &
    

    Then:

    cat /dev/mydevice     # Should print "Hello from /dev/mydevice!"
    echo "test" > /dev/mydevice  # Should show output in your terminal
    

    Code Breakdown

    1. Headers and Globals

    #include <sys/iofunc.h>
    #include <sys/dispatch.h>
    
    • These are QNX-specific headers for resource manager and IPC functions.
    • iofunc.h helps handle POSIX-style operations like open, read, write.
    • dispatch.h enables message handling between client and resource manager.

    2. Resource Manager Function Tables

    static resmgr_connect_funcs_t connect_funcs;
    static resmgr_io_funcs_t io_funcs;
    static iofunc_attr_t attr;
    
    • These hold the function pointers for handling open, read, write, etc.
    • iofunc_attr_t keeps metadata (file permissions, type, etc.) for the resource.

    3. Read Handler

    int io_read(...) {
        ...
    }
    
    • This function runs when a client calls read() on /dev/mydevice.
    • ocb->offset keeps track of where reading left off.
    • _RESMGR_PTR(ctp, msg_hdr) gives the buffer to write into.
    • _IO_SET_READ_NBYTES() tells how many bytes are read.

    4. Write Handler

    int io_write(...) {
        ...
    }
    
    • Called when a client does write() to /dev/mydevice.
    • resmgr_msgread() reads data from the message sent by the client.
    • We just print it, but you could instead send it to hardware.

    5. Initialization

    dpp = dispatch_create();
    
    • This sets up the dispatch loop, which listens for client messages.
    resmgr_attr.nparts_max = 1;
    resmgr_attr.msg_max_size = 2048;
    
    • Set the resource manager’s capabilities.
    iofunc_func_init(...) 
    
    • Initializes the function tables with defaults (open, close, etc.).
    io_funcs.read = io_read;
    io_funcs.write = io_write;
    
    • Override only the functions you want to customize.

    6. Attach to /dev/mydevice

    resmgr_attach(..., "/dev/mydevice", ...);
    
    • Registers the path so it’s visible in the /dev namespace.
    • Now applications can open(), read(), and write() on /dev/mydevice.

    7. Main Loop

    while (1) {
        if ((ctp = dispatch_block(ctp)) != NULL)
            dispatch_handler(ctp);
    }
    
    • This is the event loop where the resource manager waits for and handles requests.

    Real Hardware Device Example?

    To extend this to real hardware:

    • Replace io_read/io_write with actual memory-mapped I/O or driver logic.
    • Use mmap_device_io() or mmap_device_memory() to talk to hardware registers.
    • You can also handle ioctl() to support custom control operations.
  • Master Process and Thread Management in QNX (2026)

    1. Process and Thread Management in QNX (Overview)

    QNX is a real-time, microkernel-based operating system, designed for deterministic and high-reliability environments like automotive, medical, and industrial systems.

    In QNX:

    • A process is a protected memory space that can have one or more threads of execution.
    • The microkernel handles thread-level scheduling, not process-level, making threads the core unit of execution.

    QNX uses:

    • Preemptive multitasking
    • Priority-based scheduling
    • POSIX-compliant APIs for thread/process management

    2. How Threads are Managed in QNX

    In QNX, threads are managed directly by the microkernel, and they are:

    • The basic unit of CPU execution
    • Associated with a process’s address space
    • Managed with thread control blocks (TCBs) in the kernel

    Thread States in QNX:

    • READY
    • RUNNING
    • BLOCKED (on I/O, synchronization, or time delay)
    • DEAD

    Thread Attributes:

    • Priority
    • Scheduling policy
    • Stack size
    • CPU affinity

    Threads are managed via:

    • pthread_create(), pthread_join(), pthread_cancel()
    • sched_setscheduler(), sched_getscheduler()
    • Kernel-level calls for priority and state management

    3. Thread Scheduling Policies in QNX

    QNX supports several POSIX-compliant thread scheduling policies:

    PolicyDescription
    SCHED_FIFOFirst-In-First-Out; real-time threads of same priority execute in arrival order. No timeslice.
    SCHED_RRRound-Robin; real-time threads with same priority take turns based on a timeslice.
    SCHED_OTHERDefault non-real-time policy. Time-sharing, dynamic priority changes.
    SCHED_SPORADICFor periodic tasks with hard deadlines. Maintains CPU usage within a defined budget.

    You set scheduling policies with pthread_attr_setschedpolicy() and set thread priorities with pthread_attr_setschedparam().

    4. Priority Inheritance and Ceiling Protocols in QNX

    QNX provides real-time synchronization protocols to avoid priority inversion — a situation where a low-priority thread holds a resource needed by a high-priority thread.

    A. Priority Inheritance Protocol

    • When a low-priority thread holds a mutex and a high-priority thread blocks on it, the kernel temporarily raises the low-priority thread’s priority to match the high-priority thread.
    • Once the mutex is released, the thread’s priority returns to its original value.

    Usage:

    pthread_mutexattr_t attr;
    pthread_mutexattr_init(&attr);
    pthread_mutexattr_setprotocol(&attr, PTHREAD_PRIO_INHERIT);
    pthread_mutex_t mutex;
    pthread_mutex_init(&mutex, &attr);
    

    B. Priority Ceiling Protocol

    • Each mutex is assigned a priority ceiling (the highest priority of any thread that will lock it).
    • When a thread locks the mutex, its priority is immediately raised to the ceiling.
    • Prevents deadlocks and priority inversion.

    Usage:

    pthread_mutexattr_t attr;
    pthread_mutexattr_init(&attr);
    pthread_mutexattr_setprotocol(&attr, PTHREAD_PRIO_PROTECT);
    pthread_mutexattr_setprioceiling(&attr, 20);
    pthread_mutex_t mutex;
    pthread_mutex_init(&mutex, &attr);
    

    5. Creating and Managing Processes and Threads in QNX

    A. Process Creation

    • Processes are created using fork(), spawn() family, or exec() functions.

    Example using spawn():

    #include <spawn.h>
    char *args[] = { "/bin/ls", NULL };
    spawn(NULL, "/bin/ls", 0, NULL, args, NULL);
    

    B. Thread Creation

    • Threads are created using POSIX pthread API:
    #include <pthread.h>
    
    void* thread_func(void* arg) {
        // Your thread code
        return NULL;
    }
    
    int main() {
        pthread_t tid;
        pthread_create(&tid, NULL, thread_func, NULL);
        pthread_join(tid, NULL);
        return 0;
    }
    

    Thread attributes (like priority, stack size) can be set using pthread_attr_t.

    C. Thread Priority Management

    #include <sched.h>
    struct sched_param param;
    param.sched_priority = 10;
    pthread_setschedparam(tid, SCHED_RR, &param);
    

    6. Difference Between Process and Thread in QNX

    AspectProcessThread
    Memory SpaceSeparate for each processShared within the same process
    OverheadHigherLower
    CommunicationNeeds IPC (Message Passing)Easier using shared variables
    SchedulingNot scheduled individuallyScheduled by microkernel
    Crash IsolationOne process crash won’t affect othersOne thread crash can affect others
    Creation APIspawn(), fork(), exec()pthread_create()

    Summary

    • Threads are the primary schedulable unit in QNX.
    • QNX supports real-time scheduling (FIFO, RR, Sporadic).
    • Use priority inheritance or ceiling protocols to prevent priority inversion.
    • Processes are isolated memory spaces; threads share memory and execute concurrently within a process.
    • You create processes using spawn() and threads using pthread_create().

    Practical C code examples for QNX that demonstrate:

    1. Creating a thread and setting its scheduling policy and priority
    2. Using a mutex with priority inheritance protocol
    3. Using a mutex with priority ceiling protocol

    1. Thread Creation with Scheduling Policy and Priority

    This example creates a thread with Round-Robin (SCHED_RR) scheduling and a priority of 10.

    #include <pthread.h>
    #include <sched.h>
    #include <stdio.h>
    #include <stdlib.h>
    #include <unistd.h>
    
    void* thread_function(void* arg) {
        printf("Thread is running with priority = %d\n", sched_get_priority_max(SCHED_RR));
        return NULL;
    }
    
    int main() {
        pthread_t thread;
        pthread_attr_t attr;
        struct sched_param param;
    
        // Initialize thread attributes
        pthread_attr_init(&attr);
    
        // Set scheduling policy to Round-Robin
        pthread_attr_setschedpolicy(&attr, SCHED_RR);
    
        // Set thread priority
        param.sched_priority = 10;
        pthread_attr_setschedparam(&attr, &param);
        pthread_attr_setinheritsched(&attr, PTHREAD_EXPLICIT_SCHED);
    
        // Create thread
        if (pthread_create(&thread, &attr, thread_function, NULL) != 0) {
            perror("Failed to create thread");
            return 1;
        }
    
        pthread_join(thread, NULL);
        return 0;
    }
    

    2. Mutex with Priority Inheritance

    This ensures that if a lower-priority thread holds a mutex needed by a higher-priority thread, its priority is temporarily elevated.

    #include <pthread.h>
    #include <stdio.h>
    #include <unistd.h>
    
    pthread_mutex_t mutex;
    
    void* low_priority_task(void* arg) {
        pthread_mutex_lock(&mutex);
        printf("Low-priority thread acquired the mutex\n");
        sleep(3);  // Simulate long processing
        printf("Low-priority thread releasing the mutex\n");
        pthread_mutex_unlock(&mutex);
        return NULL;
    }
    
    void* high_priority_task(void* arg) {
        sleep(1);  // Ensure low-priority locks first
        printf("High-priority thread trying to acquire mutex\n");
        pthread_mutex_lock(&mutex);
        printf("High-priority thread acquired the mutex\n");
        pthread_mutex_unlock(&mutex);
        return NULL;
    }
    
    int main() {
        pthread_mutexattr_t attr;
        pthread_mutexattr_init(&attr);
        pthread_mutexattr_setprotocol(&attr, PTHREAD_PRIO_INHERIT);
        pthread_mutex_init(&mutex, &attr);
    
        pthread_t low, high;
        pthread_create(&low, NULL, low_priority_task, NULL);
        pthread_create(&high, NULL, high_priority_task, NULL);
    
        pthread_join(low, NULL);
        pthread_join(high, NULL);
        return 0;
    }
    

    3. Mutex with Priority Ceiling

    This raises the thread’s priority to the mutex ceiling as soon as it acquires the mutex.

    #include <pthread.h>
    #include <stdio.h>
    #include <unistd.h>
    
    pthread_mutex_t ceiling_mutex;
    
    void* task(void* arg) {
        pthread_mutex_lock(&ceiling_mutex);
        printf("Thread entered critical section (priority elevated)\n");
        sleep(2);
        printf("Thread exiting critical section\n");
        pthread_mutex_unlock(&ceiling_mutex);
        return NULL;
    }
    
    int main() {
        pthread_mutexattr_t attr;
        pthread_mutexattr_init(&attr);
        pthread_mutexattr_setprotocol(&attr, PTHREAD_PRIO_PROTECT);
        pthread_mutexattr_setprioceiling(&attr, 15); // Set ceiling
    
        pthread_mutex_init(&ceiling_mutex, &attr);
    
        pthread_t t;
        pthread_create(&t, NULL, task, NULL);
        pthread_join(t, NULL);
    
        return 0;
    }
    

    Tips:

    • Always use PTHREAD_EXPLICIT_SCHED when assigning custom policies.
    • Thread priorities in QNX range typically from 1 (lowest) to 255 (highest).
    • Use sched_get_priority_min() and sched_get_priority_max() to verify valid priority ranges.

    How to Debug & Verify Thread Priority and Mutex Behavior in QNX

    1. Verify Thread Priorities at Runtime

    You can verify thread scheduling attributes in two ways:

    A. Programmatically (within your code)

    Use pthread_getschedparam() to print the thread’s current scheduling policy and priority:

    #include <pthread.h>
    #include <sched.h>
    #include <stdio.h>
    
    void print_thread_info(pthread_t tid) {
        int policy;
        struct sched_param param;
    
        if (pthread_getschedparam(tid, &policy, &param) == 0) {
            printf("Thread Priority: %d\n", param.sched_priority);
            printf("Scheduling Policy: %s\n",
                   policy == SCHED_FIFO ? "SCHED_FIFO" :
                   policy == SCHED_RR   ? "SCHED_RR"   :
                   policy == SCHED_OTHER ? "SCHED_OTHER" :
                   "UNKNOWN");
        } else {
            perror("pthread_getschedparam");
        }
    }
    

    Call this inside or right after your thread function starts.

    B. Using QNX ps and pidin utilities

    Open a terminal or shell and use:

    ps -t
    

    Or to inspect details like priority:

    pidin -p <PID> tid
    

    This lists all threads under a process and their priority, state, and scheduling policy.

    2. Verify Mutex Priority Protocol Behavior

    A. Observe Inheritance or Ceiling Effects in Logs

    Use printf() in your thread code to log:

    • When mutex is acquired/released
    • Which thread has the mutex
    • Current thread priority before and after

    For example, you might observe:

    Low-priority thread acquired the mutex
    High-priority thread trying to acquire mutex
    Low-priority thread's priority temporarily raised!
    

    This would confirm priority inheritance.

    B. Use pidin to Check Thread Priority During Blocking

    While the high-priority thread is blocked, run:

    pidin -p <PID> tid
    

    You should see the low-priority thread’s priority has been temporarily raised (for inheritance), or elevated to the ceiling (for ceiling protocol).

    Example:

    TID PRI STATE NAME
     1   15  READY  low_thread (priority raised to match ceiling/inheritance)
     2   10  BLOCKED high_thread (waiting for mutex)
    

    3. Helpful Tools for Debugging in QNX

    ToolUse
    pidinView process/thread/mutex state and scheduling
    psBasic process/thread info
    topReal-time CPU and priority monitoring
    Momentics IDEGraphical debugging and trace (if using QNX SDP)
    System ProfilerShows exact thread execution timelines, blocking, priorities, etc.

    Summary

    • Use pthread_getschedparam() and pidin to inspect thread priority and policy.
    • Log thread actions to confirm correct mutex protocol behavior.
    • Watch for temporary priority boosts (inheritance) or immediate elevation (ceiling).
    • System Profiler (Momentics) is best for full trace and visualization.
  • Understanding Memory-Mapped Registers: Master Beginner-Friendly Guide 2026

    Memory-Mapped Registers : Memory-mapped registers are a fundamental concept in embedded systems, especially when working with hardware. They bridge the gap between software and hardware, enabling direct interaction between your program and the physical components of a system. In this article, we will explore what memory-mapped registers are, how they work, and why they are essential in embedded systems programming.

    What are Memory-Mapped Registers?

    Memory-mapped registers are special areas in the memory of a computer or embedded system that are directly mapped to the physical registers of hardware components (like microcontrollers or peripherals). These registers hold the configuration or status of hardware modules and can be read from or written to by software as if they were part of the system’s normal memory.

    In simpler terms, rather than using complex instructions to communicate with hardware, we can read or write data to specific addresses in memory that correspond to hardware components. This interaction is much faster and simpler.

    How Do Memory-Mapped Registers Work?

    Each piece of hardware in a system typically has a set of control registers. These registers determine how the hardware operates. Instead of accessing the hardware through a complicated interface, memory-mapping allows software to interact with these registers directly.

    When a register is memory-mapped, its address is linked to a specific location in the system’s memory space. This means that any software can access this register like it would access regular memory. However, the data stored in the register directly affects the hardware’s behavior.

    For example, consider a simple microcontroller with a timer. The timer might have a memory-mapped register that controls its behavior, such as setting the timer interval or reading its current value. By writing a value to the register, the microcontroller will configure the timer accordingly.

    Key Features of Memory-Mapped Registers

    1. Direct Access: Memory-mapped registers can be accessed directly via the system’s memory bus, meaning the CPU doesn’t need to use complex commands to interact with hardware.
    2. Efficiency: Direct access to registers through memory-mapping is often faster than traditional I/O methods, such as using special I/O instructions.
    3. Consistency: Registers can be read or written to in the same way that you would read or write to RAM, making the programming model simpler and more consistent.
    4. Interoperability: Since the registers are mapped into memory, they can be accessed and manipulated using common operations like pointer dereferencing in C or C++.

    Practical Example: Accessing Memory-Mapped Registers in C

    Let’s take a look at an example using a simple microcontroller. Suppose we want to control a GPIO pin. The microcontroller might have a register mapped to memory that controls the direction of the pin (input or output) and another that sets or reads its value.

    Here’s a simple C code example that accesses a memory-mapped register:

    #define GPIO_REG 0x40020000  // Address of the GPIO register
    #define GPIO_PIN 0x01        // Pin 0
    
    void set_pin_high() {
        // Writing to the memory-mapped register to set the pin high
        *((volatile unsigned int*)GPIO_REG) |= GPIO_PIN;
    }
    
    void set_pin_low() {
        // Writing to the memory-mapped register to set the pin low
        *((volatile unsigned int*)GPIO_REG) &= ~GPIO_PIN;
    }
    

    In this example:

    • GPIO_REG is the address of the memory-mapped register that controls the GPIO pin.
    • GPIO_PIN represents pin 0.
    • We use a volatile pointer to ensure the compiler doesn’t optimize access to the register, as it’s hardware-dependent.

    By writing to the GPIO_REG address, we can control the GPIO pin directly. If we want to set the pin high, we perform a bitwise OR operation; to set it low, we use the bitwise AND operation with the negation of the pin bit.

    Why Are Memory-Mapped Registers Important?

    Memory-mapped registers play a crucial role in low-level hardware programming, particularly in embedded systems. Here are a few reasons why they are important:

    1. Simplified Hardware Control: By using memory-mapped registers, hardware can be controlled as easily as accessing memory. This eliminates the need for complex I/O instructions.
    2. Speed: Since the registers are part of the system’s memory, operations on them can be performed much faster than traditional I/O mechanisms, which might involve interrupt handling or other slower methods.
    3. Direct Hardware Interaction: Memory-mapped registers allow software to have direct control over hardware, making it possible to configure peripherals, read sensors, control LEDs, motors, or any other hardware component.
    4. Consistency Across Platforms: Many processors and microcontrollers use memory-mapped registers, so the concept can be applied consistently across different hardware platforms.

    Challenges and Considerations

    While memory-mapped registers offer many benefits, there are a few things to keep in mind when working with them:

    1. Addressing: Each memory-mapped register has a specific address, which can vary between different hardware platforms. Always refer to the datasheet or technical manual for your specific hardware to get the correct addresses.
    2. Access Control: Some registers may be read-only, write-only, or require specific conditions to be written to. Be sure to check the documentation to avoid erroneous writes or reads.
    3. Volatility: Registers often hold status or control information that changes frequently. Using the volatile keyword in C or C++ ensures that the compiler doesn’t optimize out accesses to these registers.
    4. Debugging: Since direct memory access is involved, debugging memory-mapped registers can be tricky. Tools like debuggers, logic analyzers, and oscilloscopes are invaluable for ensuring correct register interactions.

    Memory-Mapped Registers in STM32F407VG

    The STM32F407VG is a powerful microcontroller from STMicroelectronics, based on the ARM Cortex-M4 processor. It provides a wide range of peripherals and features, many of which are controlled through memory-mapped registers. Understanding how these registers work is crucial for programming STM32 microcontrollers, as it allows you to directly interact with the hardware components.

    In this article, we’ll explore how memory-mapped registers function in the STM32F407VG and how you can interact with them for controlling peripherals.

    1. What Are Memory-Mapped Registers in STM32F407VG?

    In STM32F407VG, memory-mapped registers are used to control the various hardware peripherals such as GPIO (General Purpose Input/Output), timers, ADC (Analog-to-Digital Converter), UART (Universal Asynchronous Receiver-Transmitter), and more. Each peripheral in the STM32F407VG has a set of registers, and these registers are mapped into the microcontroller’s memory space.

    Memory-mapped I/O allows you to access and modify these registers directly using pointers in your code. By writing to or reading from these registers, you can control the behavior of the hardware peripherals without having to use complex or slow input/output instructions.

    2. Structure of the STM32F407VG Memory Map

    The STM32F407VG memory map is divided into different regions for system memory, peripherals, and RAM. Each peripheral has a base address, and its registers are mapped sequentially from this base address. Below is a simplified breakdown of the STM32F407VG memory map:

    RegionAddress RangePurpose
    System Memory0x00000000 to 0x1FFFFFFFContains boot ROM and system initialization code
    Peripheral Registers0x40000000 to 0x500607FFRegisters for various peripherals like GPIO, ADC, Timer, etc.
    SRAM0x20000000 to 0x2001FFFFStatic RAM (SRAM) memory for data storage
    Flash Memory0x08000000 to 0x080FFFFFFlash memory for program storage

    3. Accessing Peripheral Registers

    Each peripheral on the STM32F407VG has its own block of registers. These registers are mapped to specific addresses in the peripheral region of memory. For example:

    • GPIO (General Purpose I/O) Registers: These control the GPIO pins (inputs and outputs).
      • Base Address: 0x40020000
      • Registers:
        • GPIOx_MODER: Pin mode configuration
        • GPIOx_IDR: Input data register (read to get input value from pins)
        • GPIOx_ODR: Output data register (write to set output values)
    • USART (Universal Synchronous Asynchronous Receiver Transmitter): These registers are used to configure and control the UART communication.
      • Base Address: 0x40011000
      • Registers:
        • USARTx_SR: Status register
        • USARTx_DR: Data register
        • USARTx.BRR: Baud rate register

    4. Example of Accessing a Memory-Mapped Register in STM32F407VG

    Here is a simple C code example that demonstrates how to interact with memory-mapped registers on the STM32F407VG. The example configures a GPIO pin as an output and toggles its state.

    Code Example: Toggle an LED Using GPIO Pin

    #include "stm32f4xx.h"
    
    // Define base address for GPIO port (e.g., GPIOA)
    #define GPIOA_BASE 0x40020000U
    
    // Define offsets for GPIO registers (refer to datasheet)
    #define GPIOA_MODER   (*(volatile uint32_t *)(GPIOA_BASE + 0x00))
    #define GPIOA_ODR     (*(volatile uint32_t *)(GPIOA_BASE + 0x14))
    
    #define LED_PIN       (1 << 5)   // Assuming LED is connected to pin 5
    
    void GPIOA_Init(void) {
        // Set GPIO pin 5 as output (MODER = 01 for output mode)
        GPIOA_MODER |= (0x01 << (5 * 2));  // Set bits for pin 5 as output
    }
    
    void toggle_LED(void) {
        // Toggle GPIO pin 5 (ODR = Output Data Register)
        GPIOA_ODR ^= LED_PIN;  // XOR the pin to toggle its state
    }
    
    int main(void) {
        // Initialize GPIOA and set up pin 5 as an output
        GPIOA_Init();
    
        while (1) {
            // Toggle the LED indefinitely
            toggle_LED();
            for (int i = 0; i < 1000000; i++);  // Simple delay
        }
    
        return 0;
    }
    

    In this example:

    • GPIOA_MODER controls the mode of GPIO pins. We configure pin 5 as an output.
    • GPIOA_ODR is used to write data to the output register for GPIO port A. By toggling bit 5, we control the LED connected to pin 5.

    5. Important Considerations

    When working with memory-mapped registers on the STM32F407VG (or any microcontroller), there are a few important points to keep in mind:

    • Volatility: Since these registers may be changed by the hardware asynchronously, always declare pointers to memory-mapped registers as volatile. This prevents the compiler from optimizing out reads or writes to these addresses, which could lead to unexpected behavior.
    • Base Addresses and Offsets: Always refer to the STM32F407VG reference manual for the correct base addresses and register offsets. The STM32F407VG datasheet provides detailed memory-mapping for all peripherals.
    • Peripheral Initialization: Some peripherals might require specific configurations to enable or disable them. For example, when working with UART or timers, you must configure clock settings and enable peripheral power before accessing their registers.
    • Register Access: Use pointer dereferencing to read from and write to registers. For example, *(volatile uint32_t *)0x40020000 reads the 32-bit value at address 0x40020000.

    6. Conclusion

    Memory-mapped registers are an essential part of interacting with hardware on the STM32F407VG. By understanding the memory map and knowing how to access peripheral registers, you can control hardware components like GPIO, timers, UART, and more with ease. Always consult the reference manual for your specific STM32 microcontroller to ensure correct usage of memory-mapped registers and peripheral initialization.

    FAQ: Memory-Mapped Registers

    1. What are memory-mapped registers?

    Memory-mapped registers are special areas in the memory space of a microcontroller (like the STM32F407VG) that allow software to interact directly with hardware peripherals. These registers hold control and status information for the hardware, and by reading from or writing to these registers, software can control the hardware’s operation.

    2. Why are memory-mapped registers used in STM32F407VG?

    Memory-mapped registers provide a simple and efficient way to control hardware peripherals. Instead of using complex I/O instructions, software can access the hardware directly as if interacting with regular memory. This speeds up hardware control and simplifies programming.

    3. How do I access memory-mapped registers in STM32F407VG?

    To access memory-mapped registers in STM32F407VG, you typically use pointers in your code. You declare a pointer to a specific register address, then dereference the pointer to read or write the value.

    For example, to toggle an LED connected to a GPIO pin, you can access the appropriate register using its memory address and modify the pin’s state.

    4. What is the base address of the GPIO registers in STM32F407VG?

    The base address for GPIO port A in STM32F407VG is 0x40020000. Each GPIO port (A, B, C, etc.) has its own base address, and the registers for each port are located sequentially from this address.

    5. How do I configure a GPIO pin as output in STM32F407VG?

    To configure a GPIO pin as an output, you need to modify the MODER register of the GPIO port. Each pin has two bits in the MODER register that define its mode (input, output, alternate function, or analog).

    For example, to set pin 5 of GPIOA as an output:

    GPIOA_MODER |= (0x01 << (5 * 2)); // Set bits for pin 5 as output
    

    6. What is the volatile keyword, and why is it important when working with memory-mapped registers?

    The volatile keyword tells the compiler not to optimize the access to the memory-mapped registers. Registers can change asynchronously (e.g., due to hardware interrupts), so the compiler must not assume they remain constant during program execution. Using volatile ensures the program always reads the latest value from the hardware registers.

    7. Can you give an example of reading from a memory-mapped register in STM32F407VG?

    Sure! Here’s an example of reading the input data register (IDR) for GPIO port A, which reads the state of all the pins:

    uint32_t pin_status = GPIOA_IDR;  // Read the state of all pins on GPIOA
    

    8. How can I write to a memory-mapped register?

    To write to a memory-mapped register, you directly assign a value to the register. For example, to set an output pin high or low using the GPIOA output data register (ODR):

    GPIOA_ODR |= (1 << 5);  // Set pin 5 high
    GPIOA_ODR &= ~(1 << 5); // Set pin 5 low
    

    9. What are some common peripherals that use memory-mapped registers in STM32F407VG?

    Common peripherals with memory-mapped registers include:

    • GPIO: For configuring and controlling I/O pins.
    • USART: For serial communication.
    • Timers: For generating time delays, PWM signals, etc.
    • ADC: For reading analog inputs.
    • DAC: For outputting analog signals.

    Each of these peripherals has its own set of memory-mapped registers.

    10. Where can I find the memory map and register addresses for STM32F407VG?

    The detailed memory map and register addresses for the STM32F407VG are provided in the STM32F407VG Reference Manual. This manual lists all the peripheral registers, their base addresses, and their functionalities. Always refer to the datasheet and reference manual for accurate information about register addresses.

    11. Are there any limitations to using memory-mapped registers in STM32F407VG?

    While memory-mapped registers are efficient, there are a few limitations:

    • Peripheral Configuration: Some peripherals may require specific initialization sequences before their registers can be accessed.
    • Address Space: The STM32F407VG has a limited address space for peripherals, and accessing non-existent or wrong addresses can cause undefined behavior.
    • Read/Write Restrictions: Some registers are read-only or write-only, so you need to consult the datasheet to understand the specific requirements.

    12. How do I handle interrupts when using memory-mapped registers?

    Interrupts often modify the state of registers, especially when interacting with peripherals like timers or UART. When writing code for interrupts, make sure to:

    • Use volatile for any registers accessed within the interrupt service routine.
    • Clear interrupt flags as specified in the peripheral’s control registers after processing an interrupt.

    13. Can memory-mapped registers be used in high-level programming languages?

    Memory-mapped registers are typically accessed using low-level languages like C or assembly. However, higher-level languages may allow access to memory-mapped peripherals indirectly, such as through an abstraction layer or a hardware access library. For STM32, C and C++ are most commonly used for direct register manipulation.

    14. How do I find out the correct register addresses for peripherals in STM32F407VG?

    The correct register addresses are listed in the STM32F407VG Reference Manual. This manual provides the memory addresses for every peripheral on the microcontroller, along with detailed information about each register’s functionality and bit fields.

    15. What should I do if my register access isn’t working as expected?

    If your register access is not working:

    • Double-check the base address and offsets for the peripheral registers.
    • Ensure that the peripheral’s clock is enabled (some peripherals require the system clock to be enabled before use).
    • Verify that all required initialization steps have been completed before accessing the peripheral’s registers.
    • Use debugging tools like a debugger or oscilloscope to check if the register values are changing as expected.

    This FAQ should provide you with a solid foundation for working with memory-mapped registers in the STM32F407VG. Make sure to consult the STM32F407VG Reference Manual for more in-depth information and specific peripheral details.

    You can also Visit other tutorials of Embedded Prep 

    Special thanks to @@mr-raj for contributing to this article on Embedded Prep

  • EEPROM and Flash Memory Access: Master Complete Guide 2026

    Introduction to EEPROM and Flash Memory

    EEPROM and Flash Memory Access: In embedded systems and digital electronics, memory plays a crucial role in storing data. Among various types of memory, EEPROM (Electrically Erasable Programmable Read-Only Memory) and Flash Memory are widely used for non-volatile storage. Non-volatile memory means that the data remains intact even when the power is turned off.

    While both EEPROM and Flash memory serve similar purposes, they are distinct in terms of structure, performance, and use cases. In this guide, we will explore their features, differences, and how to access and utilize them in your embedded projects.

    What is EEPROM?

    EEPROM is a type of non-volatile memory that allows for the storage of small amounts of data, typically on the order of kilobytes. The key feature of EEPROM is that it can be electrically erased and reprogrammed. This makes it ideal for storing configuration data or any data that needs to persist between power cycles.

    EEPROM is used in applications such as:

    • Storing device configurations.
    • Storing calibration data.
    • Saving user settings.

    What is Flash Memory?

    Flash Memory is another type of non-volatile memory but is designed for higher density and faster access than EEPROM. It is commonly used in applications that require large amounts of data storage, such as USB drives, memory cards, and solid-state drives (SSDs).

    Flash memory can be found in two major types: NOR Flash and NAND Flash. NOR flash provides faster read speeds, while NAND flash offers higher storage capacities and better write endurance. Flash memory is typically used for:

    • Operating system storage in embedded devices.
    • Mass data storage for digital cameras, smartphones, and tablets.
    • Boot storage in embedded systems.

    EEPROM vs Flash Memory: Key Differences

    FeatureEEPROMFlash Memory
    Storage SizeSmaller (up to a few KB)Larger (MBs to GBs)
    Write Cycle EnduranceLower (100K cycles)Higher (millions of cycles)
    Access SpeedSlowerFaster
    Data EraseByte-wiseBlock-wise
    Typical Use CasesConfiguration data, settingsLarge data storage, boot memory

    How to Access EEPROM in Embedded Systems

    Accessing EEPROM in embedded systems typically involves using a microcontroller (MCU) with built-in EEPROM support or an external EEPROM chip. Communication is often done via I2C or SPI protocols. Below is a step-by-step process for accessing EEPROM:

    1. Initialize the EEPROM

    Before accessing an EEPROM, you need to configure the communication protocol. Here’s a basic initialization using I2C:

    #include <Wire.h>
    
    #define EEPROM_ADDRESS 0x50
    
    void setup() {
      Wire.begin(); // Initialize I2C communication
    }
    

    2. Write Data to EEPROM

    To write data to EEPROM, we use the I2C write() function. Here’s how to write a byte to EEPROM:

    void writeEEPROM(int addr, byte data) {
      Wire.beginTransmission(EEPROM_ADDRESS);
      Wire.write((int)(addr >> 8));  // MSB
      Wire.write((int)(addr & 0xFF));  // LSB
      Wire.write(data);
      Wire.endTransmission();
      delay(5);  // EEPROM write time
    }
    

    3. Read Data from EEPROM

    To read data from EEPROM, you use the requestFrom() function:

    byte readEEPROM(int addr) {
      byte data = 0xFF;
      Wire.beginTransmission(EEPROM_ADDRESS);
      Wire.write((int)(addr >> 8));  // MSB
      Wire.write((int)(addr & 0xFF));  // LSB
      Wire.endTransmission();
      
      Wire.requestFrom(EEPROM_ADDRESS, 1);
      if (Wire.available()) {
        data = Wire.read();
      }
      
      return data;
    }
    

    How to Access Flash Memory in Embedded Systems

    Flash memory access is generally faster than EEPROM and is often managed by the microcontroller or external memory controller. Flash memory access can be done using standard memory-mapped I/O or via SPI.

    1. Initialize Flash Memory

    For external Flash memory connected via SPI, you need to initialize the communication:

    #include <SPI.h>
    
    #define FLASH_CS_PIN 10
    
    void setup() {
      SPI.begin();
      pinMode(FLASH_CS_PIN, OUTPUT);
    }
    

    2. Write Data to Flash Memory

    Writing to Flash involves sending commands over the SPI bus. Below is a basic method to write a byte to Flash memory:

    void writeFlash(uint32_t address, uint8_t data) {
      digitalWrite(FLASH_CS_PIN, LOW);  // Select Flash memory
      SPI.transfer(0x02);  // Write command
      SPI.transfer((address >> 16) & 0xFF);  // Address MSB
      SPI.transfer((address >> 8) & 0xFF);  // Address Mid
      SPI.transfer(address & 0xFF);  // Address LSB
      SPI.transfer(data);  // Write data
      digitalWrite(FLASH_CS_PIN, HIGH);  // Deselect Flash memory
    }
    

    3. Read Data from Flash Memory

    Reading from Flash is similar to writing, but you issue a read command:

    uint8_t readFlash(uint32_t address) {
      digitalWrite(FLASH_CS_PIN, LOW);  // Select Flash memory
      SPI.transfer(0x03);  // Read command
      SPI.transfer((address >> 16) & 0xFF);  // Address MSB
      SPI.transfer((address >> 8) & 0xFF);  // Address Mid
      SPI.transfer(address & 0xFF);  // Address LSB
      uint8_t data = SPI.transfer(0xFF);  // Dummy write to receive data
      digitalWrite(FLASH_CS_PIN, HIGH);  // Deselect Flash memory
      return data;
    }
    

    Key Considerations for EEPROM and Flash Memory Access

    1. Write Endurance: EEPROM and Flash memory have limited write cycles. It is crucial to monitor usage to avoid premature wear.
    2. Data Retention: Both EEPROM and Flash memory have a limited data retention period, which can vary based on the technology used.
    3. Power Supply: Ensure stable power supply while performing read/write operations to avoid data corruption.
    4. Access Time: Flash memory offers faster read and write speeds compared to EEPROM, making it more suitable for larger data applications.

    Conclusion

    In this guide, we’ve covered the basics of EEPROM and Flash memory, their differences, and how to access them in embedded systems. By understanding how to access and manipulate these types of non-volatile memory, you can optimize your embedded system designs for reliable data storage and retrieval.

    Whether you’re storing small configuration values in EEPROM or managing large datasets with Flash memory, the ability to efficiently work with these storage mediums is essential for building robust embedded systems.

    Frequently Asked Questions (FAQ) about EEPROM and Flash Memory Access

    1. What is the difference between EEPROM and Flash Memory?

    Answer:
    Both EEPROM and Flash Memory are types of non-volatile memory, but they differ in terms of capacity, speed, and the way data is written and erased. EEPROM is typically used for smaller data storage (a few KB), can be written byte-by-byte, and has a lower write cycle endurance (around 100,000 cycles). Flash memory, on the other hand, offers higher storage capacity (MBs to GBs), is faster, and erases data in blocks rather than bytes, making it suitable for larger data storage.

    2. Can I use EEPROM to store large amounts of data?

    Answer:
    No, EEPROM is designed for small amounts of data storage (typically up to a few kilobytes). It is ideal for storing configuration data, user settings, and calibration parameters that do not require large storage capacities. For larger data storage needs, Flash memory is the better choice.

    3. How long does data stay in EEPROM or Flash memory?

    Answer:
    Both EEPROM and Flash memory retain data even when power is removed. However, they have a limited data retention period. EEPROM typically retains data for about 10 years, while Flash memory can retain data for around 10-20 years, depending on the specific type of memory and environmental conditions. Both types of memory wear out after a certain number of write cycles, which can lead to data corruption if overused.

    4. How do I write and read data from EEPROM in my embedded system?

    Answer:
    To write and read data from EEPROM, you generally use I2C or SPI protocols depending on the specific EEPROM chip you’re using. In embedded systems, libraries like Wire.h (for I2C) are used for communication. For example, in Arduino, you can use Wire.write() to send data and Wire.read() to receive data. A typical write operation would involve addressing the EEPROM memory and sending the data byte, and a read operation would require addressing the memory and requesting the stored byte.

    5. What is the typical use case for Flash Memory in embedded systems?

    Answer:
    Flash memory is widely used in embedded systems for mass storage purposes. It stores the operating system, firmware, and application data. For example, Flash memory is used in USB drives, SD cards, and solid-state drives (SSDs). In embedded devices, Flash is commonly used to store boot code and firmware, ensuring the system can boot up reliably.

    6. How do I write and read data from Flash memory in my embedded system?

    Answer:
    To write and read data from Flash memory, you typically use SPI (Serial Peripheral Interface) or memory-mapped I/O. For SPI-based Flash memory, you send commands (like 0x02 for write and 0x03 for read) along with the address and data using the SPI protocol. Flash memory typically uses block-level operations for writing, which means a whole block of data is erased before writing new data.

    7. What are the main factors affecting the lifespan of EEPROM and Flash memory?

    Answer:
    The lifespan of EEPROM and Flash memory is affected by the number of write/erase cycles. EEPROM typically supports around 100,000 write cycles, while Flash memory can endure millions of cycles, depending on the technology (NAND or NOR Flash). Overwriting data repeatedly in the same location can cause wear and lead to data corruption. Proper wear leveling techniques are essential to extend the lifespan of Flash memory.

    8. Can I overwrite data in EEPROM and Flash memory?

    Answer:
    Yes, you can overwrite data, but the process differs for each memory type:

    • EEPROM allows you to overwrite data byte-by-byte, but this can be slow, and excessive overwriting can reduce its lifespan.
    • Flash memory works by erasing data in blocks and then writing new data to those blocks. Flash memory must be erased before it can be rewritten, which may involve a more complex process of managing wear leveling to ensure even data distribution across memory blocks.

    9. Can I use EEPROM for real-time data storage?

    Answer:
    While EEPROM can store small amounts of data over time, it is not ideal for real-time data storage due to its limited write cycles and slower speed compared to Flash memory. For real-time data storage, Flash memory or other high-speed storage systems are more appropriate.

    10. How do I handle data corruption in EEPROM or Flash memory?

    Answer:
    Data corruption can occur if the memory is overused or if power is lost during a write operation. To minimize the risk of data corruption, it’s important to:

    • Implement error-checking mechanisms such as checksums or CRC (Cyclic Redundancy Check) to verify the integrity of stored data.
    • Use wear leveling for Flash memory to evenly distribute write/erase cycles across memory blocks.
    • Ensure that the write and read operations are done in a controlled manner, minimizing sudden power failures or interruptions during critical operations.

    11. What are the typical access speeds of EEPROM and Flash memory?

    Answer:

    • EEPROM typically has slower read/write speeds compared to Flash memory due to its byte-wise write operations.
    • Flash memory offers much faster read and write speeds, especially when handling larger amounts of data, making it more suitable for applications that require fast data storage and retrieval.

    12. How can I optimize memory access in my embedded system?

    Answer:
    To optimize memory access, consider the following strategies:

    • Use caching techniques to minimize the number of read/write operations.
    • For Flash memory, use wear leveling algorithms to ensure even distribution of write/erase cycles.
    • Choose the appropriate memory type based on your application needs (use EEPROM for small data storage and Flash memory for large, fast access).
    • Implement data compression if storing large amounts of data in limited Flash memory.

    You can also Visit other tutorials of Embedded Prep 

    Special thanks to @mr-raj for contributing to this article on Embeddedprep

  • What is PWM Pulse Width Modulation ? | Master Beginner-Friendly Guide 2026

    Introduction to PWM (Pulse Width Modulation)

    PWM Pulse Width Modulation : PWM stands for Pulse Width Modulation, a technique used to control the amount of power delivered to electrical devices. It is widely used in electronics, especially when dealing with motors, LEDs, and audio signals. PWM allows you to control the intensity, speed, or output of a device without changing the voltage — just by adjusting the signal’s duty cycle.In electronic engineering, PWM (Pulse Width Modulation) is a powerful technique used to control the power delivered to electronic devices. It is especially useful when you want to simulate analog output using digital signals.

    PWM is commonly used in microcontrollers like Arduino, Raspberry Pi, and ESP32 to control devices such as LEDs, motors, and buzzers.

    Why is PWM Important?

    PWM is essential for many embedded systems and electrical engineering applications. Instead of sending a constant voltage, PWM sends a series of ON and OFF signals (called pulses). By varying how long the signal stays ON vs OFF, we can efficiently control the output without wasting energy as heat.

    How PWM Works – The Basics

    PWM works by switching a digital signal ON and OFF very quickly. The signal looks like a square wave, where the “HIGH” means ON and “LOW” means OFF.

    Instead of giving full power all the time, you control how long the signal stays ON in each cycle. This gives the effect of partial power.

    Key Concepts:

    • Duty Cycle: The percentage of time the signal is ON in one cycle.
      • 0% = always OFF
      • 50% = ON half the time
      • 100% = always ON
    • Frequency: How fast the PWM signal cycles between ON and OFF. It’s measured in Hertz (Hz). A higher frequency gives smoother control.

    Real-Life Examples of PWM

    1. LED Dimming: PWM adjusts LED brightness by controlling how long it stays ON vs OFF.
    2. Motor Speed Control: PWM drives DC motors at variable speeds using the same voltage.
    3. Audio Signal Generation: PWM is used to generate and shape sound waves in digital audio systems.
    4. Heater and Fan Control: In HVAC systems, PWM provides precise thermal and airflow control.

    PWM with Arduino (Beginner Code Example)

    Here’s a simple Arduino example to dim an LED using PWM:

    int ledPin = 9;  // PWM-capable pin
    
    void setup() {
      pinMode(ledPin, OUTPUT);
    }
    
    void loop() {
      for (int brightness = 0; brightness <= 255; brightness++) {
        analogWrite(ledPin, brightness); // 0-255 PWM value
        delay(10);
      }
    
      for (int brightness = 255; brightness >= 0; brightness--) {
        analogWrite(ledPin, brightness);
        delay(10);
      }
    }
    

    This code increases and decreases the LED brightness smoothly using PWM.

    A Pulse Width Modulation (PWM) signal is generated by rapidly switching a digital output pin ON and OFF at a fixed frequency, while varying the duration of the ON time (duty cycle) within each cycle. This switching creates a waveform that mimics an analog signal’s average power over time.

    How PWM Signal is Generated – Step-by-Step

    1. Select a PWM Frequency

    • Frequency defines how fast the signal repeats each cycle.
    • Common values: 490 Hz, 1 kHz, 20 kHz (used in motors, audio, LED dimming).

    2. Set a Duty Cycle

    • This is the percentage of time the signal stays ON in one cycle.
    • For example:
      • 25% duty cycle: ON for 25% of the time, OFF for 75%
      • 75% duty cycle: ON for 75% of the time, OFF for 25%

    3. Toggle the Digital Pin Accordingly

    Use a timer or counter (hardware or software) to toggle the pin:

    In Microcontrollers (like Arduino):

    The hardware timers generate PWM by:

    • Counting clock pulses
    • Comparing the counter to a set value
    • Turning output HIGH until the match is reached
    • Resetting the counter to repeat the cycle

    Software Example (Pseudocode):

    loop every 1 ms {
      if (time < ON_time) {
        setPinHigh();
      } else {
        setPinLow();
      }
    }
    

    PWM Generation Methods

    1. Using Microcontroller Timers (Hardware PWM)

    • Efficient
    • More accurate
    • Less CPU usage

    2. Software PWM (Bit-Banging)

    • Controlled manually in code
    • Uses delay() or timers
    • More flexible, but consumes CPU time

    PWM Signal Characteristics

    ParameterDescription
    FrequencySpeed of the PWM cycle (Hz)
    Duty Cycle% of time signal stays HIGH
    ResolutionBit-level control (8-bit = 256 steps)

    Example: Arduino 50% PWM Signal on Pin 9

    void setup() {
      pinMode(9, OUTPUT);
    }
    
    void loop() {
      analogWrite(9, 128);  // 50% of 255 = 128 duty cycle
    }
    

    This code sends a square wave on pin 9 with a 50% duty cycle, effectively simulating half power output.

    Important parameters associated with a PWM (Pulse Width Modulation)

    1. Duty Cycle (%)

    What It Is:

    The percentage of one cycle in which the signal is HIGH (ON).

    Formula:

    Duty Cycle = (ON Time / Total Time) × 100%
    

    Example:

    • 0% = Always OFF
    • 50% = ON half the time
    • 100% = Always ON

    Importance:

    Controls the average power delivered to a device.

    2. Frequency (Hz)

    What It Is:

    The number of PWM cycles per second.

    Formula:

    Frequency = 1 / Period
    

    Example:

    • 1 kHz = 1000 cycles per second

    Importance:

    • Low frequency → Visible flicker (LEDs), noise (motors)
    • High frequency → Smoother response but harder on switching circuits

    3. Period (T)

    What It Is:

    The total time for one complete PWM cycle.

    Formula:

    Period = 1 / Frequency

    Importance:

    Gives insight into how long each ON and OFF phase can last.

    4. Resolution (Bits)

    What It Is:

    The number of discrete levels for duty cycle adjustment.

    Example:

    • 8-bit = 256 levels (0–255)
    • 10-bit = 1024 levels (0–1023)

    Importance:

    Higher resolution = finer control over output (e.g., smoother dimming or speed control).

    5. Pulse Width (ON Time)

    What It Is:

    The actual duration the signal stays HIGH in a single cycle.

    Formula:

    Pulse Width = Duty Cycle × Period

    Importance:

    Used to determine how much energy is transferred to the load during each cycle.

    6. Rise Time / Fall Time

    What It Is:

    • Rise Time: Time taken for signal to go from LOW to HIGH.
    • Fall Time: Time taken for signal to go from HIGH to LOW.

    Importance:

    Critical in high-speed or precision circuits, affects signal integrity and efficiency.

    Summary Table

    ParameterDescriptionUnits
    Duty Cycle% of time signal is ON%
    FrequencyNumber of PWM cycles per secondHertz (Hz)
    PeriodTime for one complete PWM cycleSeconds (s)
    ResolutionLevels of control over duty cycleBits
    Pulse WidthActual ON duration per cycleSeconds (s)
    Rise/Fall TimeTime to switch between statesSeconds (s)

    Pulse Position Modulation vs. Pulse Width Modulation

    FeaturePulse Width Modulation (PWM)Pulse Position Modulation (PPM)
    DefinitionModulates the width (duration) of the pulseModulates the position (timing) of the pulse
    How It WorksVaries how long the signal stays ON within a fixed periodKeeps the pulse width fixed but shifts its position in time
    Signal TypePulse duration varies; position is fixedPulse position varies; duration is fixed
    Duty CycleA key parameter (affects power output)Not applicable
    Timing AccuracyLess sensitive to timing errorsHighly sensitive to synchronization and timing accuracy
    Power ControlExcellent for power control in motors, LEDs, etc.Less effective for power control
    Analog RepresentationAverage voltage corresponds to analog input levelPulse position corresponds to analog signal amplitude
    Noise ImmunityBetter resistance to noise and interferenceMore prone to noise due to time shift sensitivity
    Hardware ComplexityEasier to generate with timers (common in microcontrollers)More complex; needs precise timing circuits
    Example Use CasesMotor speed control, LED dimming, audio, power managementRemote control systems, optical communication

    In Simple Terms:

    • PWM (Pulse Width Modulation):
      ➤ “Change the length of the pulse, but send it at the same time every cycle.”
      ➤ Best for controlling power, like in fans, lights, and speakers.
    • PPM (Pulse Position Modulation):
      ➤ “Send the pulse at different times, but keep its width the same.”
      ➤ Best for data transmission, like in radio control or optical links.

    Example Illustration:

    PWM Example (50%, 75%, 25% duty cycles):

    |‾‾‾‾‾|_____|     50%
    |‾‾‾‾‾‾‾|__|     75%
    |‾‾|______|     25%
    

    PPM Example (Pulse moves in time):

    |‾|___     Low signal
    ___|‾|_     Medium signal
    ______|‾|  High signal

    Types of Pulse Width Modulation Techniques Explained

    Pulse Width Modulation (PWM) is a powerful method used to control power delivery by switching signals ON and OFF rapidly. While PWM always controls the duty cycle, there are several ways to implement PWM based on what is varied: width, leading edge, or trailing edge.

    1. Leading Edge Modulation (LEM) / Trail Constant PWM

    Description:

    • The rising edge (start of the pulse) is fixed.
    • The falling edge (end of the pulse) is varied to change the pulse width.

    Diagram:

    |‾‾‾|_____
    |‾‾‾‾‾|___
    |‾‾|______
    

    Use Case:

    • Common in motor control and power supplies where starting edge alignment is needed.

    2. Trailing Edge Modulation (TEM) / Lead Constant PWM

    Description:

    • The falling edge (end of the pulse) is fixed.
    • The rising edge is moved to change the width.

    Diagram:

    __|‾‾‾|
    _|‾‾‾‾‾|
    ___|‾‾|
    

    Use Case:

    • Often used in digital circuits, especially when a clean pulse end is required for synchronization.

    3. Center-Aligned PWM (Symmetric PWM)

    Description:

    • The pulse is centered in the middle of the period.
    • Both rising and falling edges are varied symmetrically to maintain the center.

    Diagram:

    __|‾‾|__
    _|‾‾‾‾‾|_
    |‾‾‾‾‾‾‾|
    

    Use Case:

    • Ideal for motor drives and inverters to minimize harmonic distortion.

    4. Phase-Correct PWM

    Description:

    • Counter counts up and then down (rather than resetting to 0), producing a symmetrical waveform.

    Benefit:

    • Eliminates phase shift and reduces noise in sensitive applications.

    Use Case:

    • Found in applications like servo motor control and DC motor speed control.

    Summary Table

    PWM TypeFixed EdgeVariable EdgeBest Used In
    Leading Edge ModulationRising (Start)Falling (End)Power electronics, SMPS
    Trailing Edge ModulationFalling (End)Rising (Start)Digital and timing-sensitive apps
    Center-Aligned PWMCentered PulseBoth EdgesAC motor drives, inverters
    Phase-Correct PWMSymmetric CountTime-balancedServo motors, precision control

    1. PWM Using Arduino (ATmega328p)

    The Arduino UNO uses an 8-bit timer by default for PWM. It typically supports Fast PWM and Phase Correct PWM.

    Basic Fast PWM (e.g., Trailing Edge Modulation)

    // Generates PWM on pin 9 with 50% duty cycle
    void setup() {
      pinMode(9, OUTPUT);
      analogWrite(9, 127); // 127 = ~50% of 255
    }
    
    void loop() {
      // Nothing needed here for static PWM
    }
    

    Phase Correct PWM (Using Timer1 Directly)

    This gives symmetrical PWM for precision applications.

    void setup() {
      pinMode(9, OUTPUT); // OC1A pin
    
      // Configure Timer1 for Phase Correct PWM
      TCCR1A = (1 << COM1A1) | (1 << WGM11);
      TCCR1B = (1 << WGM13) | (1 << CS11); // Prescaler = 8
      ICR1 = 39999;       // TOP value (for 50 Hz PWM)
      OCR1A = 2999;       // Duty cycle = 7.5% (centered)
    }
    
    void loop() {
      // You can adjust OCR1A dynamically for servo control
    }
    

    2. PWM Using STM32 (HAL-based, Center-Aligned & Edge PWM)

    STM32 microcontrollers offer flexible PWM control using TIMx timers.

    Center-Aligned PWM (HAL/STM32CubeIDE)

    Set the timer in Center-Aligned Mode 1:

    // Pseudo-code for STM32 HAL (CubeMX generated setup assumed)
    HAL_TIM_PWM_Start(&htim1, TIM_CHANNEL_1);
    __HAL_TIM_SET_COMPARE(&htim1, TIM_CHANNEL_1, pulseValue);
    

    Ensure in CubeMX or manually:

    • Timer mode = Center-Aligned Mode 1
    • PWM output on a GPIO pin (e.g., PA8 for TIM1_CH1)
    • Pulse width = (DutyCycle% * TimerPeriod) / 100

    Edge-Aligned PWM (Default)

    // Basic PWM Start
    HAL_TIM_PWM_Start(&htim3, TIM_CHANNEL_1);
    
    // Set Duty Cycle (50%)
    __HAL_TIM_SET_COMPARE(&htim3, TIM_CHANNEL_1, htim3.Init.Period / 2);
    

    Summary: PWM Types by Code

    PWM TypeArduino SupportSTM32 Support
    Leading EdgeanalogWrite()Timer Edge Mode
    Trailing EdgeCustom Timer ConfigDefault Mode
    Center-AlignedTimer1 Mode NeededCenter-Aligned Mode
    Phase CorrectTimer1 OCR1Available in TIMx

    Advantages of Using PWM

    • Efficient Power Control: Less heat and energy waste.
    • Digital Control: Easy to implement using microcontrollers.
    • High Precision: Fine-grained control over devices.
    • Low Cost: No need for complex analog circuits.

    Common Devices that Use PWM

    • Servo Motors
    • DC Motors
    • LED drivers
    • Power supplies
    • Embedded systems (like Arduino, ESP32, STM32)

    Conclusion

    PWM (Pulse Width Modulation) is a powerful and energy-efficient technique to control electrical devices using digital signals. From dimming lights to controlling motors, PWM is everywhere in electronics. If you’re starting your journey in embedded systems or electronics, mastering PWM will open the doors to building exciting and dynamic projects.

    Commonly asked PWM (Pulse Width Modulation) interview questions

    Basic PWM Interview Questions

    1. What is PWM and why is it used?
    2. Explain the term ‘duty cycle’ in PWM.
    3. What are the applications of PWM in embedded systems?
    4. How does PWM simulate analog output using digital signals?
    5. What is the typical frequency range used in PWM?
    6. What is the difference between duty cycle and frequency?
    7. How does changing the duty cycle affect motor speed or LED brightness?
    8. Which microcontroller pins are used for PWM output in Arduino?
    9. What is the default PWM frequency on Arduino’s analogWrite()?
    10. Can PWM signal be used to control both AC and DC devices?

    Intermediate PWM Interview Questions

    1. What are the different PWM modes in microcontrollers (e.g., Fast PWM, Phase Correct PWM)?
    2. Explain how center-aligned PWM differs from edge-aligned PWM.
    3. How is PWM implemented using timers?
    4. What is the impact of frequency on the performance of a PWM system?
    5. How do you generate a PWM signal using a timer peripheral in STM32?
    6. What are the drawbacks of using PWM?
    7. Explain how you would generate a 1 kHz PWM signal with 75% duty cycle.
    8. What are dead-time and its importance in PWM-based motor control?
    9. What is jitter in PWM signals, and how does it affect performance?
    10. Describe how a low-pass filter converts a PWM signal into analog voltage.

    Advanced PWM Interview Questions

    1. How would you implement software PWM without using a hardware timer?
    2. Explain the difference between Pulse Width Modulation (PWM) and Pulse Position Modulation (PPM).
    3. How is PWM used in Class-D audio amplifiers?
    4. What are harmonics in PWM, and how can they be reduced?
    5. How would you synchronize multiple PWM channels in real-time control systems?
    6. Describe how PWM is used in buck/boost converters.
    7. What techniques are used to improve PWM resolution in low-frequency systems?
    8. How is complementary PWM used in full-bridge motor driver circuits?
    9. Explain phase-shifted PWM and its applications.
    10. How does the resolution (bit-depth) of PWM affect output quality?

    Frequently Asked Questions (FAQs) on PWM (Pulse Width Modulation)

    What is PWM (Pulse Width Modulation)?

    PWM (Pulse Width Modulation) is a technique used to control the average power delivered to electronic devices by rapidly switching the signal between ON and OFF states. The duty cycle determines how long the signal stays ON during one cycle.

    What is the duty cycle in PWM?

    The duty cycle is the percentage of one period in which the signal is ON. For example:

    • 0% duty cycle = always OFF
    • 100% duty cycle = always ON
    • 50% duty cycle = ON for half the time

    Where is PWM used?

    PWM is commonly used in:

    • Motor speed control
    • LED dimming
    • Audio signal generation
    • Power delivery systems
    • Servo control (robotics, RC models)

    How is PWM different from analog voltage?

    PWM uses digital signals (ON/OFF pulses) to simulate analog output by changing the duty cycle. The average voltage over time can mimic analog behavior without using a true analog signal.

    What are the types of PWM techniques?

    The major types of PWM include:

    • Leading Edge Modulation (Fixed rising edge)
    • Trailing Edge Modulation (Fixed falling edge)
    • Center-Aligned PWM (Pulse is centered)
    • Phase-Correct PWM (Symmetrical counting)

    What’s the difference between PWM and PPM?

    • PWM (Pulse Width Modulation) varies the pulse width to encode data or control power.
    • PPM (Pulse Position Modulation) varies the position of a constant-width pulse within a time frame.

    How do I generate PWM in Arduino?

    Use the built-in analogWrite(pin, value) function. It takes a value between 0–255, where:

    • 0 = 0% duty cycle (always OFF)
    • 255 = 100% duty cycle (always ON)

    Example:

    analogWrite(9, 127); // ~50% duty cycle on pin 9
    

    How do I control motor speed using PWM?

    PWM controls the motor’s speed by adjusting the average voltage supplied to the motor. A higher duty cycle = more speed; a lower duty cycle = slower speed.

    Does PWM waste energy like linear voltage control?

    No. PWM is more energy-efficient because the switching components (like transistors) are either fully ON or fully OFF, which reduces power loss.

    Can PWM be used for audio signals?

    Yes. PWM can represent analog waveforms such as audio tones. After low-pass filtering, the PWM signal can be used to produce audible sound.

    You can also Visit other tutorials of Embedded Prep 

    Special thanks to @mr-raj for contributing to this article on Embedded Prep