Updated October 8, 2026. This guide is for builders setting up ArduPilot Copter with Mission Planner. Hardware menus and supported firmware targets vary by flight controller, so use the official documentation for your exact board before connecting or flying.
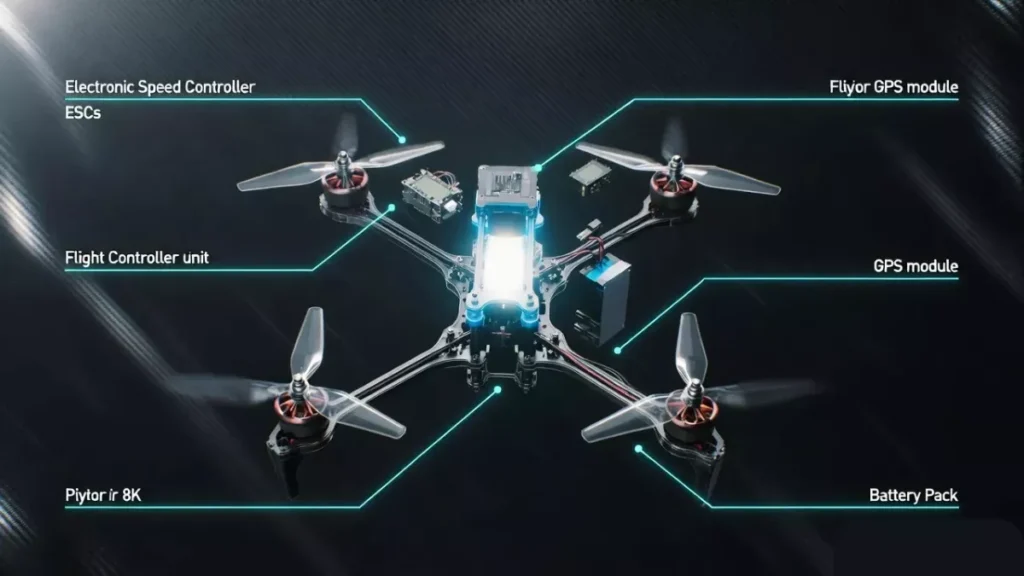
ArduPilot setup is not complete when firmware finishes uploading. You must select the correct vehicle and board firmware, configure the airframe and sensors, check radio and battery failsafes, and resolve every pre-arm warning. Work through the checks below on the bench first, then use simulation before a real flight.
Safety: Remove propellers before bench setup, motor checks, or calibration that could spin motors. Secure the aircraft, keep people clear, and follow your local aviation rules and the manufacturer instructions. Do not fly if you do not understand a warning or failsafe.
What you need
ArduPilot is open-source autopilot software for supported aircraft and other vehicles. This walkthrough focuses on ArduCopter and Mission Planner. Before starting, confirm that the exact flight-controller board is supported for your vehicle in the official autopilot hardware list.
A supported flight controller mounted in the correct orientation for your frame.
A data-capable USB cable and a Windows computer for the standard Mission Planner installation.
The receiver, GPS/compass, battery monitor or power module, ESCs, motors, and battery required by your build.
The board and frame manuals, plus a safe test area where you can keep the aircraft and bystanders clear.
1. Install Mission Planner and connect the board
Download Mission Planner from the official ArduPilot installation instructions. Install it on Windows and allow the installer to add the required drivers. Use the current installer linked by ArduPilot; avoid third-party download sites. If Windows presents a security warning, verify the publisher and file source rather than adding an antivirus exclusion.
Connect the flight controller with a data-capable cable. In Mission Planner, select the detected COM port and the appropriate baud rate, then connect. If no port appears, try a known data cable and another USB port, then follow the board vendor’s driver guidance. Do not guess at a port or firmware target.
2. Install firmware for the exact board and vehicle
Open Mission Planner’s firmware installation screen and choose ArduCopter only if you are configuring a copter. Select the firmware target recommended for the exact flight-controller board; similarly named boards can use different targets or sensor layouts. Follow the current ArduPilot firmware-loading guide and any board-specific instructions.
Keep the USB connection stable while the uploader erases, programs, and verifies the board. Wait for the successful upload message and allow the controller to reboot before reconnecting. If flashing fails, follow the board’s documented bootloader recovery process instead of repeatedly trying unrelated firmware files.
3. Complete mandatory setup in a deliberate order
Frame and board orientation
Select the frame class and type that match the physical aircraft. Confirm that the flight controller’s configured orientation matches how it is mounted. A mismatch can make sensor readings and control response incorrect; do not proceed to flight until the displayed vehicle attitude matches movements of the frame.
Accelerometer and compass
Calibrate the accelerometer with the aircraft held level and placed in the orientations requested by Mission Planner. For compass calibration, follow the official compass procedure: use a suitable outdoor location with a good GPS fix, keep away from metal and magnetic/electrical interference, and rotate the vehicle as prompted. Reboot if the ground station requests it. Do not use generic offset thresholds from an unrelated board as a substitute for diagnosing interference or orientation.
Radio, battery monitor, and failsafes
Calibrate the radio inputs and check that each stick and switch moves the correct channel in the expected direction. Configure loss-of-radio behavior for the receiver and aircraft you actually use. Set up the battery monitor for the installed power module or sensor, then verify its voltage/current readings against a trusted meter where appropriate. Use the official documentation for the receiver, battery monitor, and failsafe options; there are no safe universal parameter values for every build.
Motors, ESCs, and flight modes
With propellers removed, verify motor order and rotation against the frame diagram and the installed ESC configuration. Follow the ESC manufacturer’s instructions and ArduPilot’s board-specific setup guidance; do not run an ESC calibration procedure simply because an old tutorial recommends it. Assign flight modes only after you understand what each mode requires, and resolve all pre-arm checks rather than disabling them to make the warning disappear.
4. Test in simulation before a real flight
Use ArduPilot’s Software-in-the-Loop (SITL) simulator to learn Mission Planner, inspect mode changes, and rehearse a simple mission without a physical aircraft. Simulation is useful for finding planning mistakes, but it does not validate your specific hardware, wiring, compass environment, or local conditions.
For the first real flight, use a legal, open site and a qualified pilot who can take control. Complete the aircraft-specific pre-flight checklist, verify the home position and GPS status, test the selected failsafe behavior safely, and begin with a simple controlled flight. Do not make the first flight an autonomous mission. Only progress to autonomous operation after the aircraft has behaved predictably in simpler modes and the mission, altitude, geofence, and return behavior have been checked for the site.
Common setup problems
No COM port: confirm the cable carries data, try another port, and install only the driver recommended for the board.
Firmware upload fails: confirm the board is supported, use its documented bootloader/recovery steps, and do not select a target by guesswork.
Compass or GPS warning: move away from interference, verify sensor orientation and wiring, and follow the corresponding ArduPilot pre-arm message.
Pre-arm check remains: read the exact message in the ground station and correct its cause. Do not disable the check to force arming.
Unexpected motor response: remove the battery, keep propellers off, re-check motor order, direction, ESC configuration, and frame type before any powered test.
If you are new to the software side, continue with our drone programming development-environment guide. Keep a copy of your parameters and review the flight logs after each test; change one thing at a time and document the result.
Updated October 8, 2026. This guide sets up a Python workspace for learning drone software with MAVLink. It focuses on safe development and simulation, not instructions for flying a real aircraft. Choose one autopilot stack first—PX4 or ArduPilot—because simulator launch steps and connection addresses are not interchangeable.
A reliable starter environment has four parts: a supported Python interpreter, an isolated virtual environment, a code editor, and a simulator or documented MAVLink endpoint. Build and test in simulation before connecting code to physical hardware.
1. Choose your simulator and software library
For ArduPilot, the official SITL guide describes running the simulator on Linux or WSL2 and using Mission Planner Simulation on Windows. For PX4, follow the PX4 simulation documentation for the simulator and operating-system combination you plan to use. Start with the autopilot you actually intend to learn; do not copy a connection address or port from a different simulator.
For a new MAVLink Python project, MAVSDK is a current option. Its Python package and API have changed across major versions: the current PyPI package information and official quickstart are the source of truth. If following older tutorials, check the MAVSDK migration guide; earlier gRPC-based examples may need the separate mavsdk-grpc package or a deliberately pinned older release.
DroneKit remains relevant when maintaining an existing project, but its own repository says it is not very active and is seeking maintainers. Treat it as a legacy dependency: confirm that its versions work with your Python and autopilot before committing to it for new software.
2. Install Python and create an isolated environment
Do not hard-code Python 3.11 just because an older tutorial did. Select a Python version supported by the exact library releases you need, and check their current package metadata before installing. Use a virtual environment so project packages do not alter the system Python.
If PowerShell blocks activation, do not weaken machine-wide security settings just to continue. Use an approved shell or follow Python’s official venv documentation for your account and environment.
Use python -m pip after activation so pip installs into the selected environment. If package installation fails, check the package’s supported Python versions and operating-system wheels instead of forcing a different interpreter or installing random binary files.
3. Configure VS Code
Install VS Code from its official Python tutorial and add the Microsoft Python extension. Open the project folder, run “Python: Select Interpreter” from the Command Palette, and select the interpreter inside .venv. Open a new integrated terminal and confirm that the environment is active before running scripts.
Keep the project small at first. A practical structure is:
Add .venv/, __pycache__/, and local secret/config files such as .env to .gitignore. Never commit API keys, Wi-Fi credentials, radio details, or private telemetry logs to a public repository.
4. Start in simulation
For ArduPilot, use ArduPilot SITL or Mission Planner’s simulation feature. For PX4, use its documented simulator setup. Follow the simulator’s own output and the matching MAVSDK quickstart to choose the connection URI. Ports such as 14540 or 14550 are examples used by some setups, not universal values.
Begin by reading connection state and telemetry in the simulator. Do not run arm, takeoff, or movement commands against a real vehicle while learning, and do not copy such commands from an old tutorial. If you later connect physical hardware, first verify the endpoint, vehicle identity, failsafe configuration, and a safe test plan with a qualified operator.
Troubleshooting checklist
Import fails: activate the project virtual environment, select the same interpreter in VS Code, and check python -m pip show mavsdk.
Connection times out: confirm the simulator is running and use the endpoint it documents; check that the library API matches the installed MAVSDK major version.
Wrong Python or pip: compare python --version and python -m pip --version in the active terminal, then reselect the interpreter.
Linux serial permission error: follow your distribution and board vendor’s documented serial-device permissions; do not run every script as root.
Unexpected real-vehicle behavior: stop the test, disconnect safely, and reproduce it in simulation before changing software or parameters.
Recommended learning sequence
Create a virtual environment and verify a clean package install.
Run the autopilot’s official simulator and connect using its documented endpoint.
Read telemetry and handle connection loss before attempting any control feature.
Add automated tests and logs; record the simulator, firmware, Python, and library versions.
Move to hardware only after reviewing the board documentation, safety checklist, and failsafe behavior with an experienced operator.
For an ArduPilot hardware-setup overview, continue with our ArduPilot setup guide. Always check upstream documentation again when upgrading a simulator, Python package, or autopilot firmware.
Choosing your first drone platform made easy. Compare features, costs, flight control systems, and use cases to pick the perfect drone for beginners.
So you’ve decided you want a drone. Maybe you watched a friend’s aerial footage on YouTube and your jaw dropped. Maybe you hiked somewhere stunning and wished you had a camera in the sky. Or maybe you just love gadgets and the idea of flying something with your hands sounds like the most fun you can have on a Saturday afternoon.
Whatever got you here, welcome. You’re about to make a decision that, done right, will give you years of enjoyment. Done wrong, you’ll spend $400 on a plastic paperweight that crashes into a tree on day two and never gets turned on again.
Choosing your first drone platform is genuinely one of the trickier consumer tech decisions out there, and that’s not because drones are complicated in themselves. It’s because the market is flooded with options ranging from $30 toys to $10,000 cinematic rigs, and the marketing around all of them is aggressively optimistic. Every box says “easy to fly.” Every listing says “perfect for beginners.” Most of them are lying, at least a little.
This guide is going to cut through all of that. We’ll talk about what actually matters when you’re picking your first drone, what the different categories mean in practice, which platforms are genuinely worth your money in 2025, and what nobody in the marketing material ever tells you about flying one.
Why Your First Drone Platform Decision Actually Matters
Here’s the thing most beginner drone guides gloss over: the platform you start on shapes your entire experience with the hobby, at least for the first year or two.
If you buy something too simple, you’ll hit its ceiling within a month and feel bored. If you buy something too advanced, you’ll spend more time troubleshooting and crashing than actually flying, and you’ll either give up or burn through money on replacements. If you buy the wrong category entirely, you’ll end up with a drone that can’t do what you actually wanted.
The best first drone for someone who wants to shoot travel videos is completely different from the best first drone for someone who wants to race through gates in a field. Those are different sports that happen to share some technology.
So before we talk about any specific model, we need to talk about what you actually want to do. That question sounds obvious, but a surprising number of people skip it and just buy whatever has the most impressive spec sheet.
Step One: Be Honest About What You Actually Want to Do
This is the most important section in this entire article. Read it before you look at a single product listing.
There are three distinct worlds within consumer drones, and they don’t overlap as much as you’d think.
Camera Drones are what most people picture when they think of a drone. A small flying machine with a stabilized camera hanging underneath it. You take off, fly it somewhere interesting, shoot video or photos, land it, and use the footage. These are GPS-stabilized, usually come with automated flight modes, and are designed to be flown by people who are primarily interested in the footage rather than the flying. DJI dominates this category with models like the Mini 4 Pro and the Air 3.
FPV Drones (First Person View) are completely different. You wear goggles and you see what the drone sees in real time, flying from the drone’s perspective like you’re actually inside it. These are fast, agile, and demand real skill. The flying itself is the point, not just the footage. FPV is an actual skill-based sport, and the learning curve is steep. The footage can be breathtaking, but you will crash a lot before you get there.
Toy and Micro Drones are the $30 to $100 plastic quadcopters you see at electronics stores. They’re fine for indoor flying and learning the basic concept of how controls work, but they have almost no real-world capability. Wind is their enemy. Cameras, if they have one, are usually terrible. These aren’t really a platform, they’re a stepping stone or a kids’ toy.
Most beginners who want to actually do something with their drone, whether that’s photography, videography, travel content, real estate work, or just outdoor flying fun, belong in the camera drone category. That’s where most of this guide will focus. We’ll also cover FPV specifically because there’s a growing audience of beginners who want to get into it.
If you’re reading this because you want to take nice footage of your camping trips, your kids’ sports games, or your travels abroad, a camera drone is what you want. Keep reading.
Understanding Drone Categories and What They Actually Mean for Beginners
Camera Drones: The Practical Choice for Most People
The camera drone market in 2025 is largely split into tiers by weight and capability, and this matters more than you might expect because drone regulations worldwide are structured around weight classes.
Sub-250g Drones are the sweet spot for beginners, and for good reason. In most countries including the United States, European Union, Canada, and Australia, drones under 250 grams face significantly lighter regulatory requirements than heavier aircraft. In the US, you can fly a sub-250g drone recreationally without FAA registration (though you still need to follow flight rules). In the EU, sub-250g drones often fall into the most permissive C0 class. This means you can fly more places with fewer legal headaches.
The DJI Mini series dominates this category. The Mini 4 Pro weighs in just under 249 grams and shoots 4K video with a 1/1.3-inch sensor. That’s a genuinely capable camera in a form factor that fits in your jacket pocket. For a first drone, it’s hard to argue against it.
250g to 600g Drones offer larger sensors and more advanced features but come with more regulatory requirements. The DJI Air 3 lives here, with a dual-camera setup and a larger 1/1.3-inch main sensor. If you’re serious about aerial photography and want that step up in image quality, this is the tier to consider, but understand you’re taking on more paperwork and more locations where you’ll need to check permissions.
600g and Above is where you find prosumer and professional tools. The DJI Mavic 3 series, the Autel EVO II Pro, and similar platforms. These have large sensors, exceptional image quality, and long flight times, but they’re not beginner territory. They’re also expensive enough that crashing one is genuinely painful.
For your first drone, the answer for most people is: buy in the sub-250g category. You’ll have fewer legal barriers, the drones are physically smaller and easier to transport, and the technology has gotten good enough that you won’t feel like you’re making a meaningful sacrifice in image quality.
FPV Drones: A Completely Different Animal
If you want to get into FPV flying, understand going in that this is more like learning to ride a motorcycle than learning to drive a car. It requires dedicated practice, there will be crashes, and you’ll probably need to repair or rebuild your quad at some point.
The standard advice for FPV beginners is to start in a simulator before you ever buy real hardware. FPV simulators like Velocidrone and Liftoff are available on PC and they accurately simulate the physics of FPV flight. Spend 20 to 30 hours in a sim before spending money on hardware. This alone will save you hundreds of dollars in crash repairs.
For your actual first FPV build or prebuilt, the options have gotten much better for beginners. The DJI Neo and Avata 2 are DJI’s entry points into assisted FPV, where you get some of the FPV experience with safety nets like obstacle avoidance and stabilized flight modes. These are genuinely a good starting point if you want the FPV experience without going full manual immediately.
For traditional “freestyle” FPV, the Geprc Cinelog 25 and similar 2.5-inch quads are popular beginner choices because they’re small enough to crash without catastrophic damage but capable enough to grow with you.
We’ll come back to FPV later in the guide. For now, let’s go deep on camera drones since that’s what most people asking about choosing their first drone platform actually want.
Key Specs That Actually Matter (And Ones That Don’t)
Drone product listings are full of numbers. Most of them matter less than the marketing suggests. Here’s what’s actually worth paying attention to.
Camera Sensor Size
This matters more than megapixels. A larger sensor captures more light, which means better image quality in anything other than perfect daytime conditions. When you’re shooting at sunrise, in shade, or in any kind of low light, sensor size becomes the deciding factor between footage that looks professional and footage that looks grainy and noisy.
For reference: a 1/2-inch sensor is decent for a beginner drone. A 1/1.3-inch sensor is noticeably better. A 4/3-inch sensor (found in the Mavic 3 series) is excellent. The difference between 1/2-inch and 1/1.3-inch is clearly visible in challenging light. The difference between 12MP and 48MP matters far less than sensor size.
Video Resolution and Frame Rate
4K is now basically standard at any price point above $200, so don’t let it dazzle you. What matters more is whether the drone can shoot 4K at 60fps (useful for slow-motion) and what the color profile options are. Drones with a D-Log or similar flat color profile give you much more flexibility in post-production. If you plan to do any color grading, look for a drone that supports LOG footage.
Flight Time
This is one of the most aggressively optimistic numbers in drone marketing. When a manufacturer says a drone has a 34-minute flight time, they mean in perfect conditions, no wind, optimal speed, fresh battery, mild temperature. In real-world conditions, knock 20 to 30 percent off that number. Also remember you should land with some battery remaining, and the last 20 percent of charge often gets consumed faster than the rest.
Practically speaking: 20 to 25 minutes of real-world flight time is solid for a beginner camera drone. 15 minutes is workable. Anything under 12 minutes starts to become frustrating.
Range and Transmission System
The range listed on drone specs assumes ideal conditions with no interference. In urban environments with lots of Wi-Fi signals, your range will be lower. That said, for most beginner flying, range beyond about 1 kilometer isn’t practically useful anyway. What matters more is the quality of the video transmission link, how stable it is, and how well it handles interference.
DJI’s O3 and O4 transmission systems are genuinely best-in-class at this point. The difference between DJI’s video link and competitors shows up in real-world reliability.
Obstacle Avoidance
For beginners, this is worth paying for. Obstacle avoidance uses sensors (often infrared or camera-based) to detect objects in the drone’s path and stop or redirect. It doesn’t catch everything, and it doesn’t work in all conditions, but it will save you from many of the embarrassing beginner crashes where you didn’t see the tree branch behind you.
The DJI Mini 4 Pro has omnidirectional obstacle avoidance, meaning it can sense obstacles in all directions including below and above. The older Mini 3 Pro only has forward, backward, and downward sensing. If obstacle avoidance matters to you, it’s worth paying for the fuller implementation.
GPS and Stabilization
This is non-negotiable for a beginner camera drone. GPS allows the drone to hold its position in the air when you let go of the sticks. Without GPS, the drone will drift with the wind and require constant correction. For beginners, flying without GPS is an exercise in frustration.
Every drone in the $200-and-up camera drone category will have GPS. Just make sure it also has GLONASS support (more satellites, better positioning) and ideally Galileo or BeiDou support as well. More satellite systems equals faster lock and more stable positioning.
Wind Resistance
This matters more than beginners expect. A drone rated for Level 5 wind resistance can handle winds up to about 38 km/h (approximately 24 mph). Level 4 handles up to about 29 km/h. In practice, you can fly in wind conditions up to the drone’s rated level, but the footage will be shakier and flight time drops significantly in wind.
Heavier drones generally handle wind better than lighter ones. The sub-250g class, by being lighter, is more susceptible to wind. You’ll notice this the first time you try to fly your Mini series drone on a gusty afternoon.
Budget Breakdown: What You Actually Get at Each Price Point
Let’s be direct about money because this is where a lot of beginners go wrong, either by underspending and getting frustrated, or overspending on features they don’t need yet.
Under $100: Toy Drones
These are primarily indoor flying toys. They have cameras ranging from genuinely terrible to mediocre. They are not stable outdoors in any real wind. They are fine for learning the basic concept of how a quadcopter responds to stick inputs, especially for kids or as a gift, but they are not a platform for doing anything meaningful with aerial photography.
The Ryze Tello (made by DJI, programmed for education) is the best in this range and is worth mentioning specifically because of its flight stability and programming capabilities, but even it has severe limitations outdoors.
If your budget is genuinely under $100, buy the Tello or save up. Don’t spend $60 on a random no-name quadcopter expecting a real flying experience.
$100 to $250: Entry-Level Platforms with Real Capability
This tier is where you start to get actual value for outdoor flying. The Holy Stone HS720E and similar GPS-enabled camera drones offer real GPS stabilization, 4K cameras (often with smaller sensors but decent video in good light), and flight times around 20 minutes. These are legitimate starter platforms.
For FPV beginners, this budget range also opens up options like the DJI Neo, which brings DJI build quality and transmission technology to an accessible price point with beginner-friendly flight modes.
The limitation of this tier is image quality. Sensors in this range are small, and footage in anything other than bright daylight shows noise and limited dynamic range. If casual flying and basic aerial shots are your goal, this is fine. If you want footage you’re proud of, you’ll feel the ceiling.
$250 to $500: Where Serious Beginners Should Start
This is the sweet spot for most people reading this guide. The DJI Mini 3 (not the Pro) sits at around $299 to $399 depending on where you buy and which bundle you choose. You get DJI’s excellent O3 video transmission, a genuinely capable camera, GPS with solid stabilization, and the full DJI Fly app experience including automated flight modes.
The DJI Mini 3 Pro (now slightly reduced in price) adds forward and backward obstacle avoidance and a better camera for another $100 to $150. If you can stretch to the Mini 3 Pro over the base Mini 3, do it.
In this range you’ll also find the Autel EVO Nano+, which is a direct competitor to the Mini 3 with slightly different feature tradeoffs. Autel’s SkyPixel app is less polished than DJI Fly, but the hardware is solid.
$500 to $800: Best First Drone Platforms for Serious Aerial Photography
If your goal is to produce footage you’re genuinely proud of, the DJI Mini 4 Pro is where serious beginners with a real interest in aerial photography should be looking. At around $760 for the Fly More combo (which includes extra batteries and a bag, things you definitely want), it’s a meaningful investment but one that gives you a drone with genuinely professional-grade features.
The Mini 4 Pro shoots 4K at up to 100fps, has a 1/1.3-inch sensor with D-Log M support for color grading, omnidirectional obstacle avoidance, and ActiveTrack 360 for tracking subjects automatically. It’s the drone professional travel creators and real estate photographers actually reach for.
Above $800: Probably Not Your First Drone
The DJI Air 3, DJI Mavic 3 Classic, and Autel EVO Lite+ all live above $800. These are excellent platforms but they’re not where you should spend your first drone budget. Buy a Mini 4 Pro, learn on it, crash it a few times (hopefully minor crashes), figure out what you actually want to do with aerial footage, and then upgrade if you decide you need more. Buying a $1,500 drone as your first purchase and then discovering you only fly it twice a year is a common and expensive mistake.
Top Beginner Drone Platforms Compared: 2025 Honest Review
Let’s get into specific recommendations.
DJI Mini 4 Pro — Best All-Around First Drone
Who it’s for: Travel content creators, beginner aerial photographers, people who want footage they’re proud of without a steep learning curve.
What makes it great: The Mini 4 Pro gets almost everything right for a first serious drone. The 1/1.3-inch sensor produces footage that looks genuinely cinematic in the right conditions. Omnidirectional obstacle avoidance means it’s actively working to keep itself in one piece while you’re learning. The DJI Fly app is well-designed and the automated modes like Hyperlapse, Mastershots, and QuickShots give you impressive footage even before you learn to fly manually.
The sub-249g weight is the other major advantage. You’ll face fewer regulatory barriers, it’s small enough to pack in a regular daypack, and the propellers are less dangerous if something goes wrong.
What to know: Even with obstacle avoidance, you can still crash this drone. Obstacle avoidance doesn’t work in low light, doesn’t detect wires well, and won’t save you from dumb decisions. Fly cautiously while you learn.
Pricing note: Buy the Fly More Combo. The extra batteries make a massive difference in your actual flying sessions. One battery gives you maybe 25 minutes of real-world flight time. Three batteries gets you closer to an hour.
DJI Mini 3 — Best Value First Drone
Who it’s for: Beginners who want a capable first drone without spending $760.
What makes it great: The base Mini 3 costs significantly less than the Mini 4 Pro while still offering 4K video, solid GPS stabilization, the full DJI ecosystem experience, and that valuable sub-249g weight class. It’s a genuinely capable beginner platform.
What to know: The Mini 3 lacks obstacle avoidance (forward and side sensors only on the Pro version, nothing on the base). Its sensor is slightly smaller than the Mini 4 Pro’s. You’ll feel the difference in low-light shooting. But for daytime flying and casual aerial content, you might never notice.
Autel EVO Nano+ — Best Alternative to DJI
Who it’s for: People who specifically want an alternative to DJI, or anyone who has existing Autel gear.
What makes it great: The EVO Nano+ packs a competitive camera with a 1/1.28-inch sensor into the sub-249g form factor. It has obstacle avoidance on three sides. Autel’s color science is excellent, particularly for still photography. And buying Autel means you’re diversifying away from DJI’s sometimes-complicated relationship with export regulations and app restrictions.
What to know: The SkyPixel app isn’t as polished as DJI Fly. The transmission system is good but doesn’t quite match DJI O3’s reliability at range. Accessories and batteries are less widely available than DJI options. But if you have specific reasons to avoid DJI, the EVO Nano+ is a legitimate choice.
DJI Avata 2 — Best First FPV Drone
Who it’s for: Beginners specifically interested in the FPV experience who want guard rings and safety features.
What makes it great: The Avata 2 is DJI’s attempt to make FPV accessible. It has protective guard rings around the propellers, making it safer for indoor flying and closer proximity work. It has three flight modes including a “Normal” mode that behaves more like a regular camera drone and a “Sport” mode before you get into full manual. The DJI Goggles 3 paired with the Avata 2 give you a genuinely immersive FPV experience.
What to know: The Avata 2 isn’t what traditional FPV pilots fly. It’s a gateway drug, an introduction to the experience. Many Avata pilots end up wanting to transition to proper freestyle quads after six months. That’s fine, the skills transfer. But go in knowing you’re buying a training wheel FPV platform.
Holy Stone HS720E — Best Budget Camera Drone
Who it’s for: True beginners on a tight budget who want GPS stabilization and a real outdoor flying experience without spending $400.
What makes it great: At around $150 to $200, the HS720E gives you GPS hold, a 4K camera (small sensor but functional in daylight), and flight times around 23 minutes. It’s a genuine outdoor camera drone at an accessible price point.
What to know: Everything about this drone is a tier below the DJI and Autel options. The camera quality in anything other than perfect daylight is mediocre. The app is clunky. There’s no obstacle avoidance. Repairs and parts are harder to find. But if $200 is your budget and you want a real GPS drone, this is a legitimate starting point.
GPS vs. Non-GPS Drones: Why This Matters So Much for Beginners
This distinction deserves its own section because it’s the single most important feature for beginner safety and enjoyment.
A GPS drone holds its position automatically. When you take your hands off the sticks, the drone hovers in place. If it loses signal with the controller, it will usually Return to Home automatically, flying back to where it took off and landing itself. This is an enormous safety net for beginners.
A non-GPS drone (often called optical flow only if it has downward cameras for indoor stabilization) will drift with the wind the moment you let go of the sticks. You have to constantly make small corrections to keep it where you want it. This is a learnable skill, but it requires real attention and practice. In outdoor conditions with any wind, flying without GPS is stressful for beginners.
For your first outdoor drone, GPS is non-negotiable. Don’t let anyone convince you otherwise. Every camera drone above $200 that’s worth buying has GPS. If a listing says “optical flow only” with no mention of GPS, keep scrolling.
The only context where non-GPS flying makes sense for beginners is FPV, where it’s part of the challenge and the tradition. Even then, many new FPV pilots start in Angle mode (a stabilized flight mode that behaves similarly to GPS drones) before progressing to Acro mode.
Drone Laws for Beginners: What You Actually Need to Know
This section is important, and honestly, most drone guides either skip it entirely or bury it at the end. We’re putting it front and center because flying illegally, even accidentally, can result in real fines and legal trouble.
In the United States (FAA Rules)
The FAA governs drone flying in the US, and the rules depend on your drone’s weight and your intended use.
Recreational Flyers: If you fly purely for fun and personal use, you’re a recreational flyer. Here’s what you need to know:
Drones 250 grams and above must be registered with the FAA. Registration costs $5 and lasts three years. You register the drone, label it with your registration number, and you’re legal.
Drones under 250 grams do not need registration for recreational use. This is another reason the DJI Mini series is so popular with beginners.
You must pass The Recreational UAS Safety Test (TRUST), which is a free online test available from FAA-approved organizations. It takes about 30 minutes and the certificate has no expiration date.
You must fly below 400 feet in uncontrolled airspace.
You cannot fly over people or moving vehicles.
You cannot fly within 5 miles of an airport without checking airspace authorization through the FAA’s LAANC system (which is free and often gives near-instant authorization for certain areas).
You cannot fly at night without proper lighting on the drone.
Commercial Operations: If you fly for any commercial purpose, even just posting your footage on a monetized YouTube channel, technically you are a commercial operator. This requires a Part 107 Remote Pilot Certificate, which involves passing a real knowledge test at an FAA-approved testing center. The test costs around $175 and requires studying FAA regulations, weather, airspace, and other topics.
Many content creators and real estate photographers get their Part 107 specifically because it also opens up access to more airspace and allows waiver applications for specific operations.
Apps to Know: The B4UFLY app (official FAA app) shows you airspace restrictions for your location. The AirMap app gives similar information. These are free and you should have at least one on your phone before every flight.
In the European Union
The EU has a common drone regulation system that applies across member states with some local variations.
All drones 250 grams and above must be registered with your national aviation authority. Most EU countries have online registration systems.
Sub-250g drones without cameras can be flown without registration. Sub-250g drones with cameras fall into the Open Category A1, which allows flight over uninvolved people in most conditions.
The Open Category A2 applies to drones in the 250g to 900g class. These require a self-declaration quiz and more careful operation planning.
Night flying, flying over crowds, and flying beyond visual line of sight all require additional authorizations.
The EU Drone Regulation website has detailed country-specific information.
In Canada
Transport Canada requires registration for drones 250 grams and above, and requires pilots to pass a knowledge test. The Small Advanced Operations and Small Basic Operations categories have different requirements based on where and how you fly.
General Rules That Apply Almost Everywhere
Never fly near emergency operations (accidents, fires, police activity).
Never fly over crowds of people.
Always keep the drone within your visual line of sight unless specifically authorized.
Respect private property and don’t fly over private property without permission.
National parks in most countries have specific and often strict drone restrictions. Always check before flying in any protected area.
Essential Accessories for Your First Drone
Drone accessories are another area where marketing runs ahead of reality. Here’s what you actually need versus what’s nice to have.
Actually Essential
Extra Batteries: This is the most important accessory for any drone. One battery gives you maybe 20 to 25 minutes of real flying. Buy at least two extra batteries before your first real flying trip. Most manufacturers sell a “Fly More Combo” that includes extra batteries and a carrying case at a price that works out significantly cheaper than buying accessories separately.
ND Filters: These are tinted filters that screw onto your drone’s camera lens and reduce the amount of light entering the sensor. For video shooting, you want to follow the 180-degree shutter rule, which means your shutter speed should be approximately double your frame rate. At 30fps, you want a 1/60 shutter. In bright daylight, an ND filter is how you achieve that without overexposing your footage. An ND 4/8/16/64 set is a good starting kit. These run $30 to $80 depending on quality.
Carrying Case: Your drone is a precision instrument. Transporting it loose in a bag is asking for damage. Most Fly More combos include a shoulder bag. If yours doesn’t, buy a purpose-made case.
SD Cards: Most drones need a high-speed microSD card. Get a card rated at V30 or above for 4K recording. The SanDisk Extreme line and Samsung Pro Endurance line are reliable choices. Buy at least 64GB, preferably 128GB.
Nice to Have
Landing Pad: A foldable landing pad gives you a clean, visible surface to take off from and land on. This is especially useful on grass or dirt where debris can get sucked into motors or camera lenses. They cost about $15 to $30 and fold down to nothing.
Controller Holder for Phone: Most beginner drones use your smartphone as a screen. A controller that has a built-in phone holder is included, but if you’re using a tablet or larger phone, check that it fits the stock holder before assuming you need an upgrade.
Propeller Guards: If you’re flying indoors or in close proximity to obstacles while learning, prop guards reduce damage from minor collisions. They add weight and reduce flight efficiency slightly, so most people take them off once they’re comfortable flying.
Don’t Bother
Drone Backpacks: Most are unnecessary bulk if your drone comes with a case. An exception is if you’re hiking significant distances to flying locations, in which case a drone-specific backpack distributes weight better.
Third-Party Batteries: Tempting because they’re cheaper, but drone batteries communicate with the drone’s power management system. Third-party batteries can cause flight instability warnings or refuse to charge properly. Stick to manufacturer batteries, at least for your first drone.
How to Learn to Fly: A Practical Approach for Beginners
Buying the drone is the easy part. Actually learning to fly well takes time and intention. Here’s a structured approach that will save you frustration and money.
Before Your First Flight: Homework Required
Read the manual. This sounds obvious, but a huge percentage of beginners skip this and then wonder why their drone behaves unexpectedly. The manual covers the Return to Home behavior, low battery warnings, GPS lock requirements, and the specific behavior of different flight modes. Read it.
Practice in the DJI Fly app simulator (or equivalent for your drone). Most modern drones have a simulator built into the app that uses the actual controller. Spend a few hours here before your first real flight.
Check the airspace. Use B4UFLY or AirMap before every flight, especially when you’re getting started. Flying in controlled airspace without authorization is a real legal risk.
Find an open space. Your first flights should happen in a large open area with no obstacles, preferably on a calm day. A soccer field, an empty parking lot, or a park with no trees nearby are ideal.
Your First Real Flight Session
Start with hover practice. Take off, let the drone hover at about five feet off the ground, and just watch it. Get comfortable with the idea that it’s going to hold position and not fall out of the sky. Most beginners are anxious the first time they fly and tend to over-correct. Give the drone a chance to show you what GPS stabilization actually does.
Then practice very slow, deliberate movements. Move forward slowly, stop. Move left slowly, stop. Practice pivoting the drone to face different directions and then moving in those directions. The camera is your forward reference, and learning to think in the drone’s orientation rather than your own is one of the first real skills in drone flying.
Practice landing. Landing is where most crashes happen. Bring the drone directly over the landing pad, descend slowly, and don’t rush it. Learn to use the automatic landing function and also how to land manually.
Building Skills Over Time
Once you’re comfortable with basic movement, start flying in sport mode for short periods to understand how the drone behaves at higher speeds. Learn to use the automated modes like QuickShots and Hyperlapse, which will give you impressive footage while you’re still building your manual skills.
After a month of regular flying, try flying in a gentle crosswind. This is where you’ll really learn how to compensate for conditions. Then try flying in stronger wind. Understanding your drone’s limits and your own limits in different conditions is part of being a responsible pilot.
FPV-Specific Learning Path
If your goal is FPV, the path is different. Start in a simulator. Velocidrone, Liftoff, and DRL Simulator are all excellent options. Spend genuine hours here before touching hardware. Join local FPV communities; almost every city has an FPV racing or freestyle club and they’re usually happy to help beginners. Watch tutorials from experienced FPV pilots on YouTube. JoshardFPV, Mr. Steele, and Rotor Riot all have beginner-friendly content.
When you do buy your first FPV hardware, consider starting with a whoops-class tiny whoop (a small, protected indoor quad) before moving to outdoor freestyle.
Common Beginner Mistakes When Choosing and Flying Your First Drone
Let’s talk about the mistakes people make, because learning from others’ expensive errors is genuinely valuable.
Buying Without Knowing the Rules
Flying a drone in a national park, over a crowd, or near an airport without authorization isn’t just illegal, it’s dangerous and it gives drone pilots everywhere a bad reputation. Don’t be the person who gets their drone confiscated by a ranger. Know the rules for your area before you fly.
Buying the Wrong Category for Their Goals
We covered this at the start, but it bears repeating. If you want to shoot cinematic footage and you buy an FPV racing quad, you’re going to be very frustrated. If you want to learn to race and you buy a camera drone, you’ll hit its ceiling fast. Be honest about what you want to do.
Flying Without GPS Lock
Your drone will tell you when it has a strong GPS lock, usually through the app showing the number of satellites and a solid positioning indicator. Don’t take off until you have GPS lock. Flying without it means you lose all the stabilization and Return to Home safety features. Beginners who ignore this end up chasing a drifting drone across a field.
Ignoring Low Battery Warnings
Every drone has multiple battery warning levels. When you get the first warning, start thinking about landing. When you get the critical warning, land immediately. The temptation to squeeze another two minutes out of a session has killed many drones. Lithium batteries don’t like being fully depleted; it degrades them quickly and can cause failures.
Flying in Conditions Beyond Your Skill Level
A 20 mph crosswind is manageable for an experienced pilot. For a beginner, it’s an invitation to a crash. Start flying in calm conditions, understand your own limits, and add challenge gradually. Most beginners push their skills and their drone further than they should in the first month.
Not Calibrating Before Flights
Most modern drones don’t require manual compass calibration before every flight, but when a new location is significantly different from where you last flew (especially magnetically, near large metal structures), calibration can help. Learn what your drone’s app tells you about calibration and pay attention to any warnings.
Skipping the Fly More Combo
This is a small but common financial mistake. If you buy a drone and then realize you need extra batteries and a bag, you’ll pay significantly more buying them separately than if you’d just bought the Fly More Combo from the start. Do the math before you check out.
Choosing Your First Drone Platform Based on Your Specific Goals
Let’s bring this together with specific recommendations based on what you actually want to do.
You want to take beautiful travel videos and photos: Get the DJI Mini 4 Pro Fly More Combo. It’s the most capable beginner camera drone in a legal and practical package. If the budget is tight, the DJI Mini 3 is the next best choice.
You’re on a strict budget under $300: The DJI Mini 3 (base model) is the first recommendation. If even that’s too much, look at the Holy Stone HS720E for a real GPS camera drone experience, understanding the image quality tradeoff.
You want to get into FPV but you’re a complete beginner: Buy Velocidrone or Liftoff on Steam first. Spend a month in the simulator. Then buy the DJI Avata 2 for an FPV experience with training wheels, or jump straight to a 2.5-inch freestyle quad like the Geprc Cinelog 25 if you’re committed to learning proper manual flight.
You want to do real estate aerial photography professionally: Get your FAA Part 107 certificate first, then buy the DJI Mini 4 Pro or Air 3 depending on your budget. If you’re going pro, treat this like buying a professional camera, invest in quality.
You’re buying a drone for a kid: The DJI Mini 3 is actually appropriate for mature teenagers who will take it seriously. For younger kids or uncertain circumstances, the Ryze Tello is a better starting point because it’s safer and cheaper to crash.
You want to fly indoors primarily: The DJI Avata 2 with its prop guards, a Ryze Tello, or a tiny whoop FPV quad are all better indoor choices than a standard camera drone. Standard camera drones in tight indoor spaces are just difficult to control without reliable GPS.
What Nobody Tells You About Owning a Drone
A few honest notes from people who’ve been flying for years and wished someone had told them these things upfront.
The first crash will happen. Even with obstacle avoidance. Even with GPS. You will at some point misjudge, misread the environment, have a weird signal glitch, or just make a beginner’s mistake. Budget emotionally for this. The DJI Mini series is reasonably robust for minor crashes. DJI also offers DJI Care Refresh, an insurance plan that lets you replace a crashed drone for a significantly reduced fee. It’s worth considering if you’re worried about accidents, which all beginners should be.
The battery situation is real. You’ll never feel like you have enough batteries. Even with three batteries and a charging hub, serious flying sessions feel too short. This is just the nature of the technology right now.
You’ll become more aware of airspace. Within a few weeks of flying, you’ll start noticing restricted zones everywhere you go. You’ll look at every interesting location and think about whether you can fly there. The airspace awareness doesn’t go away; it becomes part of how you see the world.
Great footage requires more than great hardware. The drone is a tool. Composition, timing, light, movement, and storytelling are what make drone footage actually compelling. Spend as much time thinking about how to shoot as you do thinking about what drone to buy.
The community is genuinely great. There are local drone clubs in most cities. Online communities on Reddit (r/drones, r/fpv, r/djimini4pro) are active and helpful. If you get into this hobby, connecting with other pilots will accelerate your learning and make the hobby more enjoyable.
Frequently Asked Questions About Choosing Your First Drone Platform
Do I need a license to fly a drone? In the US, recreational flyers need to pass the free TRUST test and register drones over 250g. Commercial pilots need a FAA Part 107 certificate. Requirements vary by country, so always check your local aviation authority’s current rules.
What’s the best first drone for beginners in 2025? The DJI Mini 4 Pro is the best all-around first drone for most people. The DJI Mini 3 is the best value option if budget is a consideration.
How long does it take to learn to fly a drone? Basic competency comes within a few hours. Flying well enough to get consistently good footage takes weeks to months of regular practice. FPV flying takes longer, especially if you want to fly in Acro (manual) mode.
Is DJI the only brand worth buying? DJI is the dominant choice for good reasons, but Autel makes genuinely competitive hardware, particularly the EVO Nano+ and EVO Lite+ series. For FPV components, brands like Betaflight, Foxeer, Caddx, and Geprc are widely respected.
Can I fly a drone at the beach? Usually yes, but check local regulations. Many popular beaches are in controlled airspace or near restricted zones. Salt air is also hard on drones, so rinse with care and avoid flying in breaking surf.
Should I buy a drone with or without a controller screen? The DJI RC series controllers have a built-in screen, which eliminates the need for your smartphone and avoids issues with phone holders, app notifications interrupting your flying session, and battery drain on your phone. For serious flying, a built-in screen controller is worth it.
How do I protect my drone from crashes? DJI Care Refresh is the closest thing to real insurance. Fly cautiously especially while learning. Enable Return to Home. Keep your drone in visual line of sight. Enable obstacle avoidance features. And accept that occasional minor crashes are part of the learning process.
What’s the difference between a camera drone and an FPV drone for beginners? Camera drones are GPS-stabilized, fly in a traditional third-person-view style, and are designed primarily for getting aerial footage. FPV drones are flown with goggles from a first-person perspective and prioritize agility and pilot skill over stability. They’re fundamentally different experiences requiring different skills.
Final Thoughts: Making the Right Choice for You
Choosing your first drone platform doesn’t have to be complicated if you start with the right questions. What do you actually want to do with it? How much are you willing to spend? What’s your tolerance for a learning curve?
For the vast majority of people who want to capture aerial footage of their travels, their outdoor adventures, or just experience the joy of flying a real aircraft with their hands, the answer lands somewhere in the DJI Mini family. The technology has gotten genuinely good, the regulatory situation favors the sub-250g category, and the ecosystem of apps, tutorials, and community support makes learning accessible.
If you want the FPV experience, plan for a longer journey, start in a simulator, and be patient with yourself. The payoff is extraordinary once you get there, but it takes more dedication upfront.
Whatever you choose, go in with realistic expectations, respect the airspace and the people around you when you fly, and give yourself permission to take it slow at first. The drone hobby rewards patience and punishes overconfidence pretty reliably.
Now go enjoy the sky. There’s nothing quite like the first time you hover a drone two hundred feet above a landscape you’ve only ever seen from the ground, and suddenly realize you can go anywhere.
For detailed understanding of Platform Devices and Drivers on Linux, refer to the Linux documentation on
Platform Devices and Drivers
.
Learn how PID control works Proportional, Integral, and Derivative explained simply with real examples, tuning methods, and code. Perfect for beginners.
If you’ve ever wondered how a car cruise control stays locked at exactly 100 km/h on a hilly road, or how a drone hovers perfectly still in a gusty breeze, or how your home thermostat keeps the temperature from swinging wildly the answer to all three is the same thing: a PID controller. And once you understand it, you’ll start seeing it everywhere.
This guide is about understanding PID control explained in plain language. Whether you’re a hobbyist building your first Arduino project, an engineering student preparing for interviews, or a professional who wants to finally nail the intuition behind something you’ve been using for years this is for you.
What Is PID Control? Start Here Before Anything Else
PID stands for Proportional, Integral, and Derivative. It’s a control loop mechanism a feedback-based algorithm that continuously calculates an error value as the difference between a desired setpoint and a measured process variable, then applies a correction based on three terms.
Imagine you’re driving a car and you want to maintain 80 km/h. Your eyes are checking the speedometer (that’s measurement), your brain compares what it sees to what you want (that’s error calculation), and your foot adjusts pressure on the accelerator (that’s the control output). You’re already doing PID in your head without knowing it.
The PID controller just does this automatically, much faster than a human can, and with mathematical precision. It reads a sensor, compares the reading to a target (called the setpoint), computes an error, and drives an actuator a motor, a heater, a valve, a servo to reduce that error as fast as possible without overshooting.
PID control is used in robotics, industrial automation, HVAC systems, drones, chemical plants, audio equipment, and even financial algorithms. One study estimated over 90% of industrial control loops use some form of PID control. That should tell you how fundamental this is.
The History Behind PID: Where It Came From and Why It Survived
PID control wasn’t invented overnight. The roots go back to the early 1900s. Elmer Sperry is often credited with early feedback control work on ship steering gyroscopes. But the formal mathematical framework for what we now call PID was developed by Nicolas Minorsky in 1922, who studied automatic ship steering for the U.S. Navy.
In the 1930s and 40s, Taylor Instrument Companies introduced pneumatic PID controllers for industrial process control. These were entirely mechanical air pressure changed based on error, and that pressure drove valves. Remarkably, the underlying logic was identical to what we implement digitally today.
By the 1980s, digital PID controllers became standard as microprocessors got cheap enough for industrial use. Today, every major PLC (Programmable Logic Controller) platform has PID blocks built in. Every embedded platform Arduino, STM32, Raspberry Pi has open-source PID libraries. The algorithm has been around for over a century and it’s still the go-to tool because it works, it’s simple to implement, and engineers understand how to tune it.
The Three Terms Explained: P, I, and D One at a Time
Proportional Control (P): React to What’s Happening Right Now
The proportional term is the simplest. It produces an output proportional to the current error. If the error is large, the output is large. If the error is small, the output is small.
Think of it like this: you’re trying to park a car in a tight spot. The farther away you are from the target position, the harder you press the reverse pedal. As you get closer, you ease off. That’s proportional action.
Mathematically: P output = Kp x error
Where Kp is the proportional gain. A higher Kp means a more aggressive response. The main limitation of pure proportional control is that it almost always leaves a steady-state error the system gets close but never quite reaches the setpoint. This is why we need the other two terms.
Integral Control (I): Remember the Past and Fix Accumulated Error
The integral term looks at the history of the error. It accumulates the error over time. If the error has been sitting at a small positive value for a long time, the integral term keeps building up, adding more corrective force until the system is actually driven to the setpoint.
Think of a room that’s slightly colder than you want. The heater is on but not quite powerful enough to hit the target. The integral term in the thermostat notices the room has been too cold for ten minutes, adds that up, and pushes the heater harder until it actually hits the target.
Mathematically: I output = Ki x (sum of all past errors x time)
The integral term eliminates steady-state error. But it comes with its own problem: integral windup. If the system has been in error for a long time, the integral can accumulate a huge value and cause the system to overshoot badly when it finally can respond. Anti-windup clamping is the standard fix.
Derivative Control (D): Predict the Future and Slow Down Before Overshooting
The derivative term reacts to the rate of change of the error, not the error itself. If the error is rapidly decreasing, the derivative term applies a braking force it slows the correction before the system reaches the setpoint, preventing overshoot.
Think of driving toward a stop sign. A smart driver starts braking before reaching the line. The derivative term is that braking — it detects that you’re approaching the target fast and applies reverse force to prevent overshoot.
Mathematically: D output = Kd x (rate of change of error)
The practical challenge with the derivative term is noise sensitivity. Almost all real sensors have some noise, and the derivative amplifies it, causing the actuator to chatter. That’s why many real-world implementations use a derivative filter or just run a PI controller instead.
The PID Equation: Putting All Three Terms Together
The full PID control equation is:
u(t) = Kp x e(t) + Ki x integral[e(t)dt] + Kd x de(t)/dt
u(t) is the control output sent to the actuator
e(t) is the error at time t (setpoint minus measured value)
Kp, Ki, Kd are the gain parameters you tune
The integral term accumulates past errors to eliminate steady-state offset
The derivative term applies a braking force based on how fast the error is changing
In a digital system, this becomes a discrete-time approximation computed every fixed time step (the sample period). The quality of your PID implementation depends a lot on how consistently you run the loop. Use hardware timers or RTOS tasks with fixed periods — never delay() in your production PID code.
How a PID Controller Works in a Real System: Step by Step
Let’s trace through a complete PID control loop on a real example: controlling the speed of a DC motor using a microcontroller and an encoder.
Measure: The encoder reads the current motor speed. Let’s say it measures 850 RPM.
Compute P term: With Kp = 0.5, P output = 0.5 x 150 = 75.
Compute I term: Integral has accumulated. Say integrated value = 20, Ki = 0.1, so I output = 2.
Compute D term: Error improved from 180 to 150 RPM this cycle. Rate = -3000 RPM/s. With Kd = 0.001, D = -3 (small brake).
Sum: Total output = 75 + 2 + (-3) = 74. This maps to a PWM duty cycle that increases motor voltage.
Wait for next sample period (10ms), read encoder again, repeat.
After several cycles, the motor converges on 1000 RPM and holds it there, even if load changes try to drag it down. That’s PID working in real time.
PID Tuning Methods: How to Actually Find the Right Gains
Manual Tuning: The Trial-and-Error Method
Set Ki and Kd to zero. Start with only proportional control.
Increase Kp until the system responds well and starts to oscillate. Back off Kp by about 50%.
Add Ki slowly until steady-state error is eliminated. Watch for overshoot.
Add Kd carefully if still seeing too much overshoot. Filter the derivative if the system chatters.
Ziegler-Nichols Method: The Classic Engineering Approach
Developed in 1942, this method gives you a systematic starting point:
Set Ki and Kd to zero.
Increase Kp until the system oscillates steadily. This is the Ultimate Gain (Ku).
Note the oscillation period — the Ultimate Period (Tu).
Apply Z-N formulas: Kp = 0.6 x Ku, Ki = 2 x Kp / Tu, Kd = Kp x Tu / 8.
This gives an aggressive controller with ~25% overshoot. You’ll still need to fine-tune, but you’ll be in the right ballpark. Caveat: pushing a system to the edge of instability isn’t always safe or acceptable.
Step Response / FOPDT Method: Model the System First
Apply a step input open-loop and record the output response. Extract three parameters: Process gain K (how much does output change per unit input), Dead time L (how long before output starts responding), Time constant T (time to reach 63% of final value). These describe a First Order Plus Dead Time (FOPDT) model. Published formulas like IMC-based tuning or Cohen-Coon convert K, L, T directly into PID gains without needing to push the system to oscillation.
Common PID Tuning Problems and How to Recognize Them
Slow and sluggish response: Kp too low. Increase it. If still slow, Ki may also be too low.
Oscillating around the setpoint: Kp too high. Back it off. If persists, Ki may also be too high.
Large overshoot: Kp too high or Kd too low. Reduce Kp first. If still overshooting, add/increase Kd.
Steady-state error: Ki is what you need. Increase it until error is eliminated, watching for overshoot.
Chattering actuator: Derivative amplifying sensor noise. Add a low-pass filter to the sensor or the derivative calculation.
Integral windup: After long error periods, system massively overshoots. Fix with anti-windup clamping.
Types of PID Controllers: Position vs Velocity Form
When you implement a PID controller in code, you have two main options:
Position Form PID: The standard form. The output at any time is the direct sum of P, I, and D terms, representing the absolute actuator position/value. Works fine for most applications. Challenge: if the controller restarts mid-operation, the output can jump suddenly because the integral was reset.
Velocity (Incremental) Form PID: Computes the change in output (delta) at each step rather than the absolute value. Naturally bumpless — if the controller switches on or the setpoint changes, there’s no sudden jump. Preferred in industrial applications for motor drives, valve positioners, or any system where sudden output changes cause mechanical stress.
PID Control in the Real World: Industry Applications
Temperature Control
Ovens, autoclaves, injection molding machines, chemical reactors, soldering stations, 3D printer hotends — all use temperature PID loops. Temperature systems are typically slow (high thermal mass), have significant dead time, and often don’t need the derivative term at all. A PI controller is usually sufficient and preferred to avoid amplifying thermocouple noise.
Motor Speed and Position Control
Servo drives, CNC machines, robotic joints — all use PID for speed control and often cascaded PID (inner speed loop, outer position loop) for precise positioning. Motor control loops run at high frequency (1 to 10 kHz is common), making discrete-time implementation details critical. Sample time jitter can cause noticeable degradation in control quality.
Drone Flight Control (Attitude Control)
Every commercial drone uses PID control to maintain attitude (roll, pitch, yaw) and altitude. The gyroscope measures angular rate, the accelerometer measures tilt, and PID loops on each axis drive individual motor speeds to maintain stability. Flight controller firmware like Betaflight exposes PID gains directly. Drone PID tuning is a rich subculture with communities dedicated to finding optimal gains for specific airframe geometries.
Automotive Systems
Cruise control is the textbook example, but modern cars have PID loops all over: electronic throttle body control, antilock brake systems (ABS), electronic stability control, fuel injection timing, turbocharger wastegate control, and active suspension. Safety-critical PID implementations go well beyond basic gains — they include gain scheduling, state machines, saturation limits, and extensive diagnostic monitoring.
HVAC and Building Automation
Heating, ventilation, and air conditioning systems use PID to control temperature, humidity, CO2 levels, and pressure differentials. Building automation controllers often have dozens of PID loops running simultaneously. The thermal inertia of buildings means these loops have very slow dynamics — the integral term does most of the heavy lifting.
Limitations of PID Control: When It’s Not Enough
Nonlinear systems: PID is a linear controller. For highly nonlinear systems, gain scheduling (different Kp/Ki/Kd at different operating points) is a common fix.
Large dead time: If there’s a long delay between control action and measured response, the integrator accumulates a lot of error before it can see the result. Smith Predictor or model predictive control handle this better.
Coupled multi-variable systems: Multiple interacting inputs and outputs can cause PID loops to fight each other. Multi-variable control strategies or decoupling networks are needed.
Time-varying systems: If the system dynamics shift over time (wear, fouling, changing loads), fixed-gain PID eventually drifts out of optimal tuning. Adaptive PID adjusts gains automatically but adds significant complexity.
Advanced PID Concepts Worth Knowing
Cascade (Nested) PID Control
Instead of one controller, you have two — an outer loop and an inner loop. The output of the outer loop becomes the setpoint for the inner loop. Classic example: a temperature control system for a chemical reactor. The outer loop controls reactor temperature (slow dynamics). Its output becomes the setpoint for an inner loop that controls heating fluid flow (faster dynamics). Key rule: the inner loop must be at least 3 to 5 times faster than the outer loop for the approach to work properly.
Feed-Forward Control
PID is purely reactive it responds to errors after they’ve happened. Feed-forward is predictive. If you know a disturbance is coming, you can add a feed-forward term to compensate before the error even develops. In practice, feed-forward and PID feedback are used together: feed-forward handles known predictable disturbances, PID handles everything else. This gives much faster disturbance rejection than feedback alone.
Anti-Windup Strategies
Clamping: Hard limit on the integral accumulator. Simple but can be abrupt.
Back-calculation: When output saturates, feed the difference back to unwind the integrator. Smoother than clamping.
Conditional integration: Only accumulate integral when within a certain range of the setpoint.
Gain Scheduling
For nonlinear systems, define multiple sets of PID gains and switch between them based on operating point. A simple implementation might have three gain sets: low, medium, high. A sophisticated version uses continuous interpolation between gain sets. Gain scheduling is widely used in aircraft flight controllers and automotive powertrain control.
Implementing PID in Code: A Practical Example
Here’s a clean, production-quality PID implementation in pseudocode. This pattern works in C, Python, or any procedural language:
The integral is clamped before multiplying by Ki cleaner than clamping the raw accumulator
Derivative uses a first-order IIR low-pass filter controlled by N (higher = less filtering = more noise sensitivity)
Output is clamped to physical actuator limits
dt must be accurate — measure from actual system clock, don’t assume
PID in Arduino: Getting Started Quickly
The fastest way to start experimenting with PID is on an Arduino using Brett Beauregard’s well-tested PID library. Install it through the Arduino Library Manager and you’ll have a clean, anti-windup-ready implementation in minutes:
Brett’s library handles anti-windup, derivative filter, and consistent sample timing internally. Read his blog series ‘Improving the Beginner’s PID’ — it’s one of the best engineering blog posts ever written about practical PID implementation.
PID Tuning Tips from Experience That Textbooks Usually Skip
Always know your sample rate first. Before thinking about gains, make sure your PID loop runs at a consistent, appropriate frequency. For temperature: 1 to 10 Hz. For motor speed: 100 to 1000 Hz. For power converters: 10 to 100 kHz.
Fix your sensor before tuning. A noisy sensor will make your PID look like it’s misbehaving when it’s actually working fine. Filter your sensor reading first.
Check for mechanical problems before blaming the PID. Backlash, sticky actuators, and compliance look exactly like PID tuning problems but no amount of gain adjustment will fix them.
Understand your actuator limits. If your heater or motor is already saturated, PID can’t help. Make sure the actuator is sized for the job first.
Start with PI, add D only if needed. For most everyday applications — temperature, level, flow — a well-tuned PI controller performs excellently.
Document your tuning process. Write down what you changed and what happened. Without notes you’ll end up going in circles.
Frequently Asked Questions About PID Control
What’s the difference between PID and on-off control?
On-off control switches the actuator fully on or fully off based on whether the measurement is above or below the setpoint. It causes constant oscillation around the setpoint and wear on the actuator. PID produces a proportional output that varies continuously, allowing it to balance precisely at the setpoint without constant switching.
What’s the difference between PID and state-space control?
PID is an input-output controller it works with the error signal only and doesn’t need an internal model of the system. State-space control uses an explicit mathematical model of the system’s internal states and can optimize performance in ways PID cannot. State-space methods are more powerful for complex multi-variable systems, but require much more modeling work. PID wins on simplicity, robustness to model mismatch, and ease of field tuning.
What’s a good first project to learn PID hands-on?
Temperature control of a heating element with a thermocouple and SSR, or a DC motor speed controller with encoder feedback. Temperature control is slow (forgiving of timing errors), intuitive, and cheap to set up. Motor control is faster and teaches more about discrete-time implementation. Either will teach you more in two hours of hands-on work than a week of reading theory.
PID Control in Embedded Systems: Special Considerations
Fixed sample period: Use a hardware timer interrupt or RTOS periodic task to trigger PID computation. Never use delay() or sleep() — these are imprecise and will corrupt your integral and derivative.
Overflow and saturation: Check your data types. Use 32-bit or 64-bit accumulators for the integral. Clip the integral and output explicitly to their allowed ranges.
Initialization: On startup, initialize integral to zero and previous error to the current measurement to avoid derivative spikes on the first computation.
Mode switching: Implement bumpless transfer when switching between manual and automatic control.
Fault handling: A production PID controller needs watchdog monitoring, sensor failure detection, and safe output defaults.
The Big Picture: Why PID Control Still Matters in 2025 and Beyond
With machine learning and neural networks transforming engineering, you might wonder if PID control is becoming obsolete. The short answer is no — and the reason is instructive.
Neural network controllers and reinforcement learning agents can learn optimal control policies for complex nonlinear systems. But deploying such a controller in a safety-critical industrial plant, medical device, or automotive system brings huge challenges: the controller is a black box (can’t be analyzed or certified easily), it requires enormous training data, it can fail unpredictably on out-of-distribution inputs, and regulatory frameworks like ISO 26262 and IEC 61508 currently have no established certification pathway for neural network controllers in safety-critical applications.
PID, by contrast, is fully analyzable. You can prove stability mathematically. The behavior is predictable and explainable. It’s certifiable. And it works. For the vast majority of industrial, automotive, and embedded control applications, the incremental performance gain from a sophisticated AI controller doesn’t justify the engineering, certification, and maintenance overhead.
What is changing is how PID tuning is done. Machine learning is being used to automatically identify system models, run rapid auto-tuning, and implement adaptive gain scheduling. Neural networks are handling highly nonlinear dynamics while PID loops handle the linear inner control loops. The two approaches are increasingly complementary rather than competitive.
Summary: What You Should Now Understand About PID Control
A PID controller is a feedback control algorithm with three terms: Proportional (reacts to current error), Integral (corrects accumulated past error), and Derivative (anticipates future error based on trend). Each term has a gain you tune to achieve the desired balance of speed, accuracy, and stability.
Proportional gives you fast response but leaves steady-state error.
Integral eliminates steady-state error but can cause overshoot and windup.
Derivative reduces overshoot and improves damping but amplifies noise.
A well-tuned PID combines all three for fast, accurate, stable control.
Its limitations nonlinear systems, large dead time, multi-variable coupling are solvable with extensions like cascade control, feed-forward, and gain scheduling. For most practical control problems, a well-implemented PID is not just adequate — it’s the right tool for the job.
Now go build something. The best way to internalize this is to run a real loop, watch a real response graph, and tune until it behaves the way you want. That experience will teach you more than any article ever can.
Recommended Resources for Going Deeper
Brett Beauregard’s ‘Improving the Beginner’s PID’ blog series : best practical PID implementation guide ever written.
Karl Astrom and Richard Wittenmark : ‘Computer-Controlled Systems’ — authoritative textbook on discrete-time control theory.
Franklin, Powell, Emami-Naeini : ‘Feedback Control of Dynamic Systems’ — classic undergraduate control systems text.
MATLAB Control System Toolbox documentation : excellent worked examples for frequency-domain analysis and PID design.
Arduino PID Library (Brett Beauregard) : GitHub source is well-commented and worth reading to understand implementation choices.
Betaflight PID tuning guides : if you’re into drones, the Betaflight community has extremely practical real-time PID tuning guides.
A beginner’s complete guide to lift, drag, thrust, weight, Bernoulli’s principle, Newton’s laws, angle of attack, and everything else that keeps a 900,000-pound metal tube in the sky.
Picture this. You’re sitting in seat 24B, pressed back as the engines roar. The ground blurs outside the window, and then somehow hundreds of tonnes of metal just lifts off the Earth. You’ve seen it a thousand times. You’ve done it yourself. But if someone asked you to explain exactly how it works, most people go quiet.
That’s not a knock on anyone. Flight physics basics are one of those things that sound simple on the surface “wings push air down, plane goes up” but the real answer is layered, fascinating, and way more intuitive than the textbooks make it sound.
In this guide, we’re going deep. Not PhD-dissertation deep deep like the kind of conversation you’d have with an engineer friend who actually explains things without making you feel dumb. By the time you’re done reading, you’ll understand the four forces of flight, why Bernoulli’s principle matters, how Newton’s laws apply to aircraft, what angle of attack actually means, and why commercial jets stay up at 35,000 feet without falling out of the sky.
Fun fact: Flight physics isn’t magic. It’s physics figured out piece by piece over 120 years, starting with two bicycle mechanics from Ohio who refused to believe humans couldn’t fly.
Let’s start from the beginning.
1. Why Does Anything Fly? The Big Picture of Aerodynamics for Beginners
Before getting into forces and equations, let’s frame the problem correctly. For something to fly really fly, not just fall slower — it needs to overcome gravity. That’s the whole game.
Gravity pulls every object downward with a force equal to mass times gravitational acceleration (about 9.8 m/s²). For a Boeing 747 at max takeoff weight (around 412,000 kg), that’s roughly 4 million Newtons of downward force pinning it to the ground.
To get airborne, the aircraft needs to generate an equal or greater upward force. That upward force is called lift. And generating enough lift consistently, controllably, efficiently — is what the entire science of aerodynamics for beginners is really about. According to NASA’s Glenn Research Center Guide to Aerodynamics, aerodynamics affects everything from large airliners to kites — it is simply the study of forces and motion of objects moving through air.
Definition: Aerodynamics is the study of how air moves around objects and what forces that movement creates. It’s a branch of fluid dynamics — because air behaves like a fluid when objects move through it at speed.
Air Is Not Nothing
Here’s something people underestimate: air has mass. At sea level, a cubic meter of air weighs about 1.225 kg. That might not sound like much, but when wings are pushing through thousands of cubic meters of air per second, those interactions add up to millions of Newtons of force.
The key insight in understanding how do airplanes fly is that air resists being moved. When a wing moves through air, the air doesn’t politely step aside. It gets pushed, compressed, accelerated, and deflected — and it pushes back. All of those pushes and pulls, shaped correctly, sum up to lift.
What Makes a Wing Different from a Flat Board?
A flat board held at the right angle will generate some lift. A properly shaped wing called an airfoil does it far more efficiently. The shape matters enormously, and that’s where two of the most important concepts in flight physics enter: Bernoulli’s principle and Newton’s third law. We’ll look at both properly in a moment.
2. The Four Forces of Flight: Lift, Drag, Thrust, and Weight
Every aircraft — from a paper airplane to the Space Shuttle — experiences four fundamental forces during flight. These are the core of flight physics basics explained in a way that actually sticks. As NASA explains, the four forces of flight — lift, weight, thrust, and drag — make an object move up and down, and faster or slower, with the amount of each force compared to its opposing force determining how an object moves through the air.
Force
Direction
Role
Lift
Upward, perpendicular to flight path
Counters weight. Generated mainly by wings.
Weight
Downward, toward Earth’s center
Always present. Result of gravity acting on aircraft mass.
Thrust
Forward, along flight path
Generated by engines or propellers. Overcomes drag.
Drag
Backward, opposing forward motion
Air resistance. Created by shape, friction, and lift itself.
Lift vs. Weight: The Vertical Battle
When lift equals weight, the aircraft maintains altitude. When lift exceeds weight, it climbs. When weight exceeds lift, it descends. Pilots manage this balance constantly — not just by pointing the nose up or down, but by adjusting speed, flap settings, and engine power.
One thing people get wrong: an aircraft doesn’t need to be nose-up to climb. If the engines produce enough thrust and the wings generate surplus lift, a plane can climb while appearing relatively level. Conversely, an aircraft can descend with its nose slightly raised if flying slowly and losing lift.
Thrust vs. Drag: The Horizontal Battle
Thrust is what moves the aircraft forward. Without forward motion, wings can’t generate lift (in conventional fixed-wing aircraft). So thrust is indirectly responsible for keeping the plane up.
Drag is the enemy of efficiency. There are two main types. Induced drag is created as a byproduct of generating lift — it’s unavoidable. Parasite drag is everything else: friction, fuselage shape, landing gear, antennas, rivets. Aircraft designers spend enormous effort reducing parasite drag while managing induced drag through smart wing design. The SKYbrary Aviation Safety article on Lift offers an excellent technical breakdown of how these forces interact in real aircraft operations.
Key insight: When an aircraft is in straight, level, unaccelerated flight, all four forces are balanced: lift = weight, thrust = drag. Pilots call this state “trimmed flight.”
Equilibrium, Climbs, and Descents
In reality, aircraft are almost never in perfect balance — they’re constantly making small adjustments. Autopilot systems in modern commercial jets make these corrections hundreds of times per second. Understanding that flight is dynamic, not static, is one of the first mental shifts that changes how you think about aerodynamics.
3. How Wings Generate Lift: Bernoulli’s Principle and Newton’s Laws Together
This is probably the most misunderstood part of flight physics, and the internet has a bad habit of oversimplifying it. Let’s fix that.
Most school textbooks explain lift using the Bernoulli principle flight explanation alone. The story: the top of a wing is curved, so air traveling over it has farther to go than air along the flat bottom. To “keep up,” the upper air must travel faster. Faster-moving air has lower pressure (Bernoulli’s principle). Lower pressure on top, higher pressure below, pushes the wing upward. Lift!
This isn’t exactly wrong — Bernoulli’s principle is real and pressure differences do create lift. But it’s incomplete. The “equal transit time” assumption (that top and bottom air must arrive at the trailing edge simultaneously) is actually false. Air over the top of a wing arrives significantly earlier than air below — the separation is real, but it’s not explained by equal transit time.
The Bernoulli Principle: What It Actually Says
Daniel Bernoulli was an 18th-century Swiss mathematician who discovered a fundamental relationship between fluid velocity and pressure. As Britannica explains in its overview of Bernoulli’s theorem, the principle states that the total mechanical energy of a flowing fluid — comprising pressure energy, gravitational potential energy, and kinetic energy — remains constant. In practical terms: where a fluid speeds up, pressure decreases, and where it slows down, pressure increases.
Air flowing over the curved upper surface of a wing does speed up — not because it needs to “catch up,” but because the wing’s geometry directs it through a path where the airflow naturally accelerates. This acceleration reduces pressure on top. The higher-pressure air below pushes up. That pressure difference is a real, measurable component of the lift drag thrust weight equation.
But here’s what the Bernoulli-only story misses: it doesn’t fully account for how much lift is actually generated, especially at high angles of attack. That’s where Newton comes in.
Newton’s Third Law and the Deflection of Air
Newton’s third law states that for every action, there is an equal and opposite reaction. When a wing moves through air, it deflects air downward. That’s the action. The reaction is an equal upward force on the wing. That upward force is lift.
This is not a competing explanation to Bernoulli — it’s complementary. The FAA’s official Glider Flying Handbook (Chapter 3) puts it clearly: Newton’s third law describes the overall interaction between atmosphere and wing — as air deflects downward due to interaction with the wing, the wing experiences an upward lifting reaction — while Bernoulli’s principle looks at the effect of air changing speed as it moves past the wing. Together, these models provide a valid and complete explanation of lift.
Mental model: Bernoulli explains the pressure distribution around the wing. Newton explains why the air gets deflected and why that deflection means the wing must be pushed up. Both are right. Both are needed.
Modern aerodynamicists use computational fluid dynamics (CFD) software that models all these effects simultaneously to predict lift with extreme precision. For understanding how wings generate lift, just know: the wing’s shape and angle together cause air to move in ways that create more pressure below than above, and that pressure difference lifts the aircraft.
The Role of Wing Shape: Airfoil Design
Not all airfoils are equal. The shape of a wing’s cross-section — its camber, thickness, and chord length — dramatically affects how much lift it generates, at what speed, and how efficiently.
Camber: the curvature from leading to trailing edge. More camber means more lift at low speeds — which is why flaps (which increase effective camber) help during takeoff and landing.
Chord length: the straight-line distance from leading to trailing edge. Longer chord means more wing area interacting with air.
Thickness: thicker airfoils tolerate higher angles of attack before stalling; thinner airfoils suit high-speed supersonic flight.
Span: distance from wingtip to wingtip. Longer wings reduce induced drag — hence the long, slender wings on fuel-efficient jets like the Boeing 787.
Fighter jets use thin, often symmetric airfoils for high-speed maneuverability. Commercial jets use thick, cambered airfoils for efficiency at subsonic cruise speeds. Gliders use extremely high-aspect-ratio wings to maximize lift-to-drag ratios and stay airborne for hours.
4. Angle of Attack: The Most Important Variable You’ve Never Heard Of
If there’s one concept in flight physics basics explained properly that changes how you understand flying, it’s angle of attack. Not pitch angle, not nose position — angle of attack. They’re different things, and the difference really matters.
What Is Angle of Attack?
The angle of attack (AoA) is the angle between the chord line of a wing (the straight line from leading edge to trailing edge) and the relative wind — the direction air is actually coming from as seen by the aircraft.
When a pilot pulls back on the controls, they increase the angle of attack. The wing hits the incoming air at a steeper angle, deflects more air downward, and creates more lift. But only up to a point. The FAA’s Pilot’s Handbook of Aeronautical Knowledge — Chapter 5 covers this in detail, including how the FAA now promotes angle of attack indicators as a key safety tool to reduce loss-of-control accidents.
Critical distinction: Pitch angle (how high the nose is pointed) and angle of attack are NOT the same thing. An aircraft can have a low pitch angle but a high angle of attack if it’s descending rapidly. Or a high pitch angle but low angle of attack if climbing at speed.
The Lift Curve: More AoA Means More Lift… Until It Doesn’t
As angle of attack increases from zero, lift increases in a nearly linear fashion. More AoA means more air deflected downward, means more lift. This is the good part.
But at a certain critical angle — typically around 15 to 20 degrees for most subsonic aircraft — something bad happens. The airflow over the top of the wing can no longer follow the wing’s contour. It separates, becomes turbulent and chaotic, and stops generating lift. This is called a stall.
A stall has nothing to do with the engine quitting. It’s purely an aerodynamic event — the wing stops making lift because angle of attack is too high. A stall can happen at any airspeed, any attitude, any power setting. It’s purely a function of exceeding the critical angle of attack.
This is why stall training is one of the most fundamental parts of pilot education, and why commercial jets have angle of attack indicators and stick shakers — physical warnings that shake the control column to tell pilots they’re approaching the stall boundary.
Low-Speed Flight and High-Lift Devices
At low speeds, wings generate less lift. To compensate during takeoff and landing, pilots extend flaps, slats, and other high-lift devices. These increase the wing’s effective camber and area, allowing it to generate more lift at lower airspeeds — but they also increase drag, which is acceptable close to the ground at low speeds.
5. Newton’s Laws of Motion Applied to Aircraft: All Three of Them
We touched on Newton’s third law, but Newton’s laws of flight show up across every aspect of aviation. Let’s go through all three with concrete aircraft examples — because this is where aerodynamics stops being abstract and starts making real-world sense.
Newton’s First Law: Inertia and Straight-Line Flight
An object in motion stays in motion in a straight line at constant velocity unless acted on by an unbalanced force. For aircraft: in a perfect vacuum with no gravity and no air resistance, a plane would fly straight forever at the same speed without any thrust.
Reality is messier. Gravity constantly pulls the aircraft down. Drag constantly slows it. So pilots must continuously apply thrust and manage control surfaces to counteract these forces. The autopilot does this automatically on modern airliners, applying hundreds of tiny adjustments per second.
Newton’s Second Law: Force, Mass, and Acceleration
Force equals mass times acceleration (F = ma). This is the most quantitatively useful law for engineers.
In level flight, the net force in every direction is zero — no acceleration because the four forces are balanced. The moment any force becomes unbalanced, the aircraft accelerates in that direction. Pilots use this constantly during maneuvers.
This law also explains why heavier aircraft need longer runways. More mass requires more force (thrust) to reach takeoff speed. With fixed engine thrust, more mass means slower acceleration and a longer ground roll before the wings generate enough lift to become airborne.
Newton’s Third Law: Action-Reaction Throughout Aviation
Every action has an equal and opposite reaction. We covered how wings deflect air down to create upward lift. But this law appears everywhere in aviation:
Propeller thrust: a propeller accelerates air backward. That airflow pushes the aircraft forward.
Helicopter rotors: blades deflect air downward to generate lift. The torque reaction spins the helicopter body in the opposite direction — which is why helicopters need a tail rotor.
Rocket propulsion: rockets expel hot gas backward at enormous velocity. The reaction accelerates the rocket forward — even in space where there’s no air to push against.
Myth buster: A jet engine doesn’t “push against air.” It accelerates mass backward. The reaction pushes the engine forward. In space, rockets work the same way — they carry their own oxidizer since there’s no atmospheric oxygen to burn.
6. How Engines Work: Generating Thrust in Different Ways
Lift gets the aircraft up. Thrust keeps it moving. Without forward motion in a conventional fixed-wing aircraft, there is no lift. Understanding how engines generate thrust completes the picture of how does an aircraft stay up from a full systems perspective.
Piston Engines and Propellers
The Wright Brothers’ Flyer used a piston engine driving a propeller. Piston engines burn fuel in cylinders to drive pistons, which rotate a crankshaft, which turns a propeller. The propeller is just a rotating wing — it generates thrust the same way a wing generates lift, by accelerating air backward.
Piston engines dominate general aviation. They’re simple, relatively lightweight, and efficient at low altitudes. But they lose efficiency rapidly at high altitude because thinner air provides less oxygen to burn fuel.
Gas Turbine Engines: Turboprops, Turbofans, and Turbojets
Commercial aviation runs on gas turbines. These work on the Brayton cycle: compress air, mix with fuel, ignite, expand rapidly through a turbine. The turbine drives the compressor (and in turboprops, the propeller). Exhaust provides additional thrust.
The turbofan dominates modern commercial jets. It has a large fan at the front that moves enormous amounts of air. Some goes through the combustion chamber (the core). Most bypasses it entirely (bypass flow). The ratio of bypass to core flow is the bypass ratio.
High bypass ratio engines (like the GE9X at over 10:1) are far more fuel-efficient at subsonic cruise speeds and significantly quieter. Low bypass ratio engines, used in military fighters, trade efficiency for raw thrust at supersonic speeds.
The Thrust Equation
Thrust is fundamentally about momentum change: Thrust = mass flow rate × (exit velocity − inlet velocity). To maximize thrust, you either increase how much air you move or how fast you accelerate it. High-bypass turbofans move a lot of air at moderate velocity — efficient and quiet. Turbojets move less air at very high velocity — powerful but fuel-hungry.
7. Drag: The Force Nobody Wants But Everybody Gets
Drag is the aerodynamic force that opposes forward motion through air. Understanding drag determines fuel burn, range, top speed, and aircraft design. Reducing drag while maintaining lift is the central engineering challenge in aviation.
Parasite Drag
Parasite drag is generated by the aircraft’s physical presence in the airstream, regardless of what the wings are doing. It has two main components.
Form drag comes from the aircraft’s shape. A blunt nose creates far more form drag than a streamlined one — which is why aircraft have pointed noses, streamlined fuselages, and retractable landing gear.
Skin friction drag comes from air molecules sliding along the aircraft’s surface. As described in the FAA Pilot’s Handbook of Aeronautical Knowledge summary, the boundary layer between the wing and the free-stream airflow is only about as wide as a playing card — but aircraft designers still remove protrusions and use flush-mount rivets to reduce friction, because every bit of skin friction drag costs fuel over millions of flight hours.
Parasite drag increases with the square of airspeed. Double the speed, quadruple the parasite drag. This is why supersonic flight consumes disproportionately more fuel.
Induced Drag
Induced drag is created as a direct consequence of generating lift. It’s unavoidable whenever a wing is making lift. When a wing generates lift, the pressure difference between top and bottom causes air to curl around the wingtips from below to above, creating swirling vortices. These wingtip vortices tilt the lift vector slightly backward — and that backward tilt is induced drag.
Induced drag increases as airspeed decreases. At low speeds during takeoff and landing, induced drag is dominant. At high cruise speeds, parasite drag takes over. SKYbrary’s article on Bernoulli’s principle provides a detailed technical look at how pressure distributions across the wing surface contribute to both lift and the induced drag penalty that comes with it.
Real-world application: The winglets on modern commercial jets aren’t just aesthetic. They reduce the strength of wingtip vortices, cutting induced drag by 3–5%. Over a fleet of hundreds of aircraft flying millions of hours, that’s an enormous fuel saving — and the math pencils out quickly for airlines.
The Total Drag Curve and Minimum Drag Speed
Because parasite drag increases with speed and induced drag decreases with speed, there’s a speed at which total drag is minimized. This is called L/D max — the speed of maximum lift-to-drag ratio. Flying at L/D max gives the aircraft its best glide ratio (critical in engine-out emergencies) and is often close to the most fuel-efficient cruise speed.
8. Stability and Control: How Aircraft Stay Straight
An aircraft doesn’t just need to fly. It needs to fly predictably and return to stable flight when disturbed by turbulence or pilot inputs. This is where stability and control come in — two related but distinct concepts in flight physics basics.
Axes of Rotation: Roll, Pitch, and Yaw
Aircraft rotate around three axes, each controlled by different surfaces:
Pitch: nose up or nose down, controlled by the elevator. Pitching changes the angle of attack.
Roll: banking left or right, controlled by ailerons near the wingtips. Rolling tilts the lift vector, causing the aircraft to turn.
Yaw: nose left or right, controlled by the rudder on the vertical tail. Important during turns and crosswind landings.
In a coordinated turn, the pilot uses ailerons (roll) and rudder (yaw) together while adding back pressure on the elevator (pitch) to maintain altitude. Three-axis control happening simultaneously — which is why flight simulators are genuinely hard to fly realistically.
Longitudinal Stability: Why the Tail Exists
The horizontal stabilizer — the small wing on the tail — produces downward lift. This sounds counterintuitive. Why generate downward force?
Because the aircraft’s center of lift is typically behind its center of gravity, creating a nose-down pitching moment. The horizontal tail counters this by producing a downward force that creates a nose-up moment. It’s like a see-saw where the tail pushes down to keep everything level.
This design also creates positive longitudinal stability. If the nose pitches up due to a gust, the changing aerodynamic forces naturally tend to push it back down. The aircraft self-corrects — a property called static longitudinal stability.
Fly-by-Wire: When Computers Take Over
Some aircraft — the F-16 and many airliners like the Airbus A320 family — are designed to be aerodynamically unstable. Left to themselves, they would tumble out of control. Computers making thousands of corrections per second make them appear perfectly stable to the pilot.
An aerodynamically unstable aircraft is inherently more maneuverable. Military aircraft exploit this for extreme agility. Commercial fly-by-wire systems use envelope protection — the computers simply won’t allow the aircraft to exceed structural or aerodynamic limits regardless of what the pilot does.
9. High-Speed Flight: Transonic Flight, Compressibility, and the Sound Barrier
Everything above applies comfortably to subsonic flight. But at speeds approaching and exceeding Mach 1, new physical effects emerge that fundamentally change the aerodynamics. This is where flight physics basics explained gets genuinely mind-bending.
What Is the Speed of Sound and Why Does It Matter?
The speed of sound at sea level and 15°C is about 343 m/s (roughly 1,235 km/h). At altitude, where air is colder, it’s lower — around 295 m/s at 35,000 feet. Sound travels as pressure waves through air. When an aircraft approaches the speed of sound, it’s approaching the speed at which it can “warn” the air ahead of it that it’s coming.
At subsonic speeds, pressure waves propagate ahead of the aircraft, letting air start adjusting. As the aircraft approaches Mach 1, these waves bunch up. At exactly Mach 1, the aircraft keeps pace with its own pressure waves — they pile up at the nose, creating a shock wave.
Transonic Flight and the Drag Rise
Most commercial jets cruise at Mach 0.78 to 0.85. Even at these speeds, air over the curved wing surfaces accelerates to local supersonic speeds — creating pockets of supersonic flow that terminate in shock waves. This is the transonic regime.
These shock waves cause a dramatic increase in drag — wave drag. Early jets pushing into this regime experienced severe drag increases and control problems. This is what people called the “sound barrier” — not a physical wall, but a barrier of rapidly increasing drag that early aircraft couldn’t overcome.
The solution was swept wings. By sweeping the wings back, designers reduced the component of airspeed perpendicular to the leading edge, delaying the onset of local supersonic flow. Almost every commercial jet and military aircraft uses swept wings for this reason.
Supersonic Flight: Shock Waves and Sonic Booms
Once an aircraft exceeds Mach 1, it flies faster than its own pressure waves. It creates a cone-shaped shock wave — the Mach cone. This shock wave carries enormous energy and, when it reaches the ground, is heard as a sonic boom — a continuous phenomenon as long as the aircraft is supersonic, not a one-time event.
Fascinating fact: The Concorde cruised at Mach 2.04 — twice the speed of sound — at 60,000 feet. The airframe heated to over 120°C from aerodynamic friction. Its distinctive drooping nose extended for takeoff and landing visibility, then retracted for the needle-nosed shape needed to minimize supersonic drag.
10. Atmosphere and Altitude: How the Air Changes Everything
Aircraft don’t fly in a uniform medium. The atmosphere changes dramatically with altitude, affecting every aspect of flight performance. This is why what keeps a plane in the air at sea level involves different engineering considerations than what keeps it flying at 40,000 feet.
The Atmosphere in Layers
Commercial aviation takes place in the troposphere (ground to about 36,000 feet) and the lower stratosphere (above 36,000 feet). The boundary between them is the tropopause.
In the troposphere, temperature decreases with altitude at about 2°C per 1,000 feet. Weather happens here. Above the tropopause, temperature stabilizes. Commercial jets often cruise just above or at the tropopause to escape weather turbulence and get the efficiency benefits of cold, still air.
Density Altitude: The Number Pilots Really Care About
Air density decreases with altitude. Less dense air means fewer air molecules per cubic meter — which means wings generate less lift for a given speed, and engines produce less thrust because there’s less oxygen to burn. As the NASA Technical Report on Aerodynamics (NASA SP-367) explains, air density is a very important factor in lift, drag, and engine power output, and it depends on both temperature and local pressure — not just altitude alone.
Density altitude is the altitude your aircraft performs as if it were at, corrected for temperature and pressure. On a hot day at a high-elevation airport, the density altitude can be thousands of feet higher than actual elevation. Takeoffs from Denver (elevation ~5,400 feet) on a hot summer day require significantly longer runways and more speed than sea-level departures on a cool day.
Density altitude accidents are tragically common in general aviation. Pilots who don’t account for performance degradation in hot, high conditions attempt takeoffs their aircraft can’t complete.
Cruise Altitude: Why 35,000 Feet?
Commercial jets cruise at high altitudes for three reasons. First, thinner air means less parasite drag, allowing high speeds with less thrust. Second, engines are more efficient in cold, thin air. Third, weather is more predictable above the troposphere.
But altitude has limits. Above a certain point, the stall speed (minimum speed for controlled flight) approaches the maximum operating speed (above which structural damage could occur). The range between these narrows until there’s no margin left — the aerodynamic ceiling, typically around 40,000–45,000 feet for commercial jets.
11. Takeoff and Landing: Flight Physics in the Most Critical Phases
Takeoff and landing are when flight physics becomes most consequential. Most accidents occur in these phases, not during cruise. Understanding why helps explain everything from runway length calculations to approach procedures.
Takeoff Physics
During the takeoff roll, the aircraft accelerates down the runway. Wings start generating lift as soon as there’s airflow — but not enough to lift off until rotation speed (Vr) is reached. At Vr, the pilot pulls back, increasing angle of attack, generating enough lift to become airborne.
The critical speed is V1 — the decision speed. Before V1, if an engine fails, the pilot aborts the takeoff. After V1, even with an engine failure, the aircraft must continue — there’s no longer enough runway to stop. Calculating V1, Vr, and V2 (initial climb speed) for every takeoff, accounting for weight, runway length, elevation, temperature, and wind, is a precise science governed by FAA regulations and performance standards.
Landing Physics
Landing is, in one sense, a controlled stall near the ground. The pilot gradually reduces speed on approach, keeping the aircraft just above its stall speed, then flares (raises the nose) just before touchdown to reduce descent rate. The flare increases angle of attack, generating a brief moment of extra lift that slows the descent for a gentler touchdown.
Crosswind landings are a beautiful demonstration of multi-axis control. The pilot simultaneously uses rudder to align the nose with the runway centerline, ailerons to counteract sideways drift, and elevator to control descent rate — all while the wind is trying to push the aircraft sideways.
Autoland systems on modern commercial jets can land automatically in near-zero visibility. Cat III ILS approaches allow landings where the pilot literally cannot see the runway until the wheels are almost on it.
12. Stalls, Spins, and How Pilots Handle Them
Stalls deserve a deeper look — understanding them is one of the most important safety concepts in aviation, and one that’s frequently misunderstood by non-pilots.
Aerodynamic Stalls
A stall occurs when the critical angle of attack is exceeded. Airflow over the wing separates, turbulence replaces smooth laminar flow, and lift drops dramatically. The aircraft begins to descend.
In training, student pilots learn to recognize approaching stall symptoms: decreasing airspeed, mushy controls, buffeting (shaking caused by turbulent airflow hitting the tail), and the stall warning horn or stick shaker. Recovery is counterintuitive: reduce the angle of attack (lower the nose), add power, and as airspeed recovers, climb.
The counterintuitive part: when stalling and losing altitude, the instinct is to pull back harder. But that increases angle of attack further, deepening the stall. The correct recovery is to push forward — trust the physics, lower the nose, recover flying speed.
Accelerated Stalls and Overbanked Turns
The critical angle of attack doesn’t change — but the speed at which you reach it does. In a steep turn, the wing must generate more lift to maintain altitude. Without enough speed, the wing can stall at a much higher speed than in level flight — an accelerated stall.
In a 60-degree bank turn, the aircraft needs twice its normal lift. Stall speed increases by about 41%. In a 75-degree bank, the stall speed doubles — and most aircraft aren’t stressed to handle four times their weight in lift forces consistently. This is covered in detail in the FAA’s aviation aerodynamics documentation, which explains how load factor increases rapidly as bank angle increases, with stall speed rising in proportion to the square root of the load factor.
Spins: A Stall Gone Wrong
If one wing stalls before the other — which can happen if the aircraft is yawing at the moment of stall — the aircraft enters a spin. One wing generates much more lift than the other, creating a rolling and yawing motion pulling the aircraft into a rapidly rotating descent.
Spin recovery is a specific procedure: reduce power, apply full opposite rudder to stop the rotation, push forward to reduce angle of attack, then pull out of the resulting dive. In most commercial aviation, spin training isn’t required — aircraft are designed and certified with systems that prevent the conditions leading to spins.
13. The Future of Flight Physics: Electric Aviation, eVTOL, and What’s Next
The physics of flight don’t change — lift is still generated the same way it was in 1903. But the technologies used to create lift, generate thrust, and control aircraft are evolving faster than at almost any point in aviation history.
Electric Propulsion and Its Limitations
Electric motors are dramatically simpler than turbines, have fewer moving parts, and can be distributed around an aircraft in ways that enable entirely new designs. Small electric aircraft are already flying. The challenge is energy density: the best lithium-ion batteries store roughly 1/50th the energy per kilogram of jet fuel. This limits electric aircraft to short ranges and small sizes — for now.
Hybrid electric systems (a gas turbine generating electricity that powers electric motors) are a near-term solution that may enable efficiency gains for regional aircraft. But truly electric commercial aviation for long-haul routes awaits battery technology improvements that haven’t happened yet.
eVTOL: Electric Vertical Takeoff and Landing
The eVTOL category is one of the most dynamic in aviation right now. Companies like Joby Aviation, Archer, Lilium, and Wisk are developing aircraft that use multiple electric rotors — some tilting, some fixed — to take off vertically like a helicopter and cruise horizontally like a fixed-wing aircraft.
In hover mode, these aircraft support their weight entirely with rotor-generated thrust. In cruise mode, wing-generated lift takes over and the rotors tilt forward to provide thrust. The transition between these modes is one of the most complex aerodynamic challenges in modern eVTOL design.
Hypersonic Flight
At speeds above Mach 5, conventional aerodynamics breaks down. Air in front of the aircraft is heated to plasma temperatures by shock waves. Scramjet engines (supersonic combustion ramjets) can theoretically work at these speeds, but controlling and sustaining hypersonic flight remains one of the hardest engineering challenges in existence. Space planes, future long-haul transport concepts, and military vehicles are all areas where hypersonic research is accelerating rapidly.
14. Frequently Asked Questions About Flight Physics
What is the simplest explanation of how airplanes fly?
A plane generates lift by moving wings through air. The wing’s shape and angle cause air to push the wing upward with more force than the aircraft’s weight. Engines generate thrust to keep the aircraft moving forward, which keeps the wings generating lift. Four forces — lift, weight, thrust, and drag — interact to determine whether the aircraft climbs, descends, or maintains level flight.
Is Bernoulli’s principle enough to explain lift?
No. Bernoulli’s principle explains part of lift — the pressure difference between upper and lower wing surfaces. But Newton’s third law (the wing deflects air downward, creating an upward reaction force) is equally important. Real lift requires both effects simultaneously, and neither alone fully predicts the numbers that aerodynamicists actually calculate. For a deeper dive, SKYbrary’s Bernoulli’s Principle article provides a rigorous technical breakdown used by aviation safety professionals worldwide.
Can a plane fly upside down?
Yes, many aircraft can fly inverted. Aerobatic aircraft use symmetric airfoils that generate lift equally right-side-up or upside-down — the pilot simply adjusts angle of attack. Even non-aerobatic aircraft can briefly fly inverted if the pilot maintains the correct angle of attack, though engines and fuel systems may not function normally in that orientation.
Why does a plane need to maintain speed to fly?
Because wings need airflow over them to generate lift. Without relative airflow — which comes from the aircraft moving forward through air — there’s no pressure difference, no air deflection, and no lift. In a conventional fixed-wing aircraft, the minimum speed for controlled flight is the stall speed. Below that speed, the angle of attack becomes too high and the wing stops generating lift.
What actually happens during turbulence?
Turbulence is chaotic, irregular airflow caused by terrain, thunderstorms, jet streams, and clear-air turbulence. When an aircraft flies through it, the aircraft experiences rapid, irregular changes in aerodynamic forces on its wings and fuselage — which manifest as bumping and jolting. Modern aircraft are structurally stressed to handle loads far beyond what turbulence can realistically impose.
Safety note: Commercial aircraft are stress-tested to loads up to 3.75g positive and -1.5g negative — nearly four times the aircraft’s weight. Turbulence, while uncomfortable, rarely approaches these limits.
How does a pilot control which direction the plane goes?
Through three sets of control surfaces: ailerons (on the wings, control roll), elevator (on the tail, controls pitch), and rudder (on the vertical tail, controls yaw). In modern commercial jets, fly-by-wire computers translate pilot inputs into precise surface movements while applying envelope protection to prevent pilots from inadvertently exceeding structural or aerodynamic limits.
Conclusion: Flight Physics Basics Are More Intuitive Than You Think
Here’s the thing about flight physics basics explained properly: once you understand the core concepts, they stop being mysterious and start being logical. Of course wings create lift by manipulating pressure and deflecting air. Of course more speed means more lift up to the point where the airflow can’t follow the wing. Of course engines need to work harder to overcome drag that grows with the square of airspeed.
The Wright Brothers didn’t have computers, CFD software, or a century of aviation research. They had careful observation, systematic testing, and a genuine understanding of the forces at work. They built a wind tunnel in their bicycle shop and methodically worked through wing designs until they found what worked.
The physics they were working with is exactly what we’ve covered here. The four forces of flight. Bernoulli’s principle creating pressure differences. Newton’s laws governing every acceleration and reaction. Angle of attack as the primary variable controlling lift. Compressibility effects as speeds increase. Stability as the aircraft’s tendency to return to equilibrium.
Whether you’re an aviation enthusiast who wanted to understand what happens when you board a plane, a student starting your aviation journey, or someone genuinely curious about physics — you now have a solid foundation. The window seat will never look quite the same, and the next time you feel those engines spool up for departure, you’ll know exactly what’s about to happen and why.
Final thought: Flight is not magic. It’s physics applied with extraordinary precision, refined over 120 years, to achieve something that once seemed impossible. And every commercial flight you take is proof that humans got very, very good at it.
Related Topics to Explore Next
How jet engines work a detailed breakdown
Pilot training basics: what student pilots learn first
Aircraft stability and control systems explained
The history of aviation: from the Wright Brothers to modern jets
How autopilot systems work on commercial aircraft
Understanding weather and turbulence from a physics perspective
Electric aviation and the future of sustainable flight
SKYbrary Aviation Safety — Lift — Authoritative overview of how lift is generated on an aircraft, covering wing design, pressure differentials, and the relationship between lift and the other forces of flight.
Learn drone anatomy for programmers explained from scratch motors, ESCs, flight controllers, sensors, MAVLink, and PID loops all explained in plain language so your code actually makes sense.
If you have ever stared at a drone and thought “I want to program this thing, but I have no idea what I am looking at” this guide is for you.
Most tutorials online assume you either already know hardware or do not care about it. Neither of those is helpful if you want to actually write code that controls a physical flying machine. You need to understand the drone’s body before you can talk to it intelligently. Think of it like learning API docs before you start writing integrations. You would not call endpoints blindly without knowing what data goes in and what comes out.
Drone anatomy for programmers explained properly means understanding not just the names of parts, but why those parts exist, how they communicate, and what your code is actually telling them to do. That is what this article covers from the ground up.
Why Programmers Need to Understand Drone Hardware
Here is the thing most drone programming tutorials skip: you can copy-paste flight code all day and still produce a drone that flies erratically, crashes, or simply does not do what you intended. The reason is almost always a disconnect between the programmer and the physical machine.
When you write drone.move_forward(speed=50), something physical is happening. Motors are spinning at different speeds. A sensor is correcting for wind drift. A PID controller is making micro-adjustments 400 times per second. If you do not know what those layers look like, debugging is basically guesswork.
Understanding drone hardware components for developers is not about becoming a mechanical engineer. It is about knowing your interface. You do not need to build a motor from scratch, but you do need to understand that a motor has a maximum RPM, that it responds to PWM signals, and that asking it to do too much will cause brownouts or overheating.
This is the same reason good backend developers understand database internals even when using an ORM. The abstraction is useful, right up until it is not.
The Big Picture: Drone System Architecture
Before diving into individual parts, zoom out and look at the overall system. A drone is essentially a distributed embedded system. Multiple sensors feed data into a central flight controller, which makes decisions and sends commands to motors via speed controllers. Optionally, a companion computer runs your higher-level code and talks to the flight controller through a communication protocol.
Every component in that chain matters. Drop any one of them and the drone either does not fly or flies unpredictably. As someone writing code for drones, you sit in the middle of that chain, and understanding every node makes you a dramatically better programmer.
1. The Frame: The Skeleton Your Code Lives On
The frame is the physical structure that holds everything together. Most programmers ignore it completely, but the frame actually affects your code in surprising ways.
Frame Configuration and Motor Layout
Drones most commonly come in three configurations: tricopter (3 motors), quadcopter (4 motors), hexacopter (6 motors), and octocopter (8 motors). The vast majority of drones developers work with are quadcopters, and those come in two standard layouts: X configuration and + configuration.
In X configuration, the drone’s nose points between two arms. In + configuration, one arm points straight forward. This changes which motor combination the flight controller uses for forward pitch, and it also changes how your telemetry data maps to physical orientation when you are debugging flight logs.
When you work with a flight controller or autopilot system like ArduPilot or PX4, you have to tell it the frame type during configuration. Get this wrong in your setup code and the drone will flip on takeoff.
Frame Size and Its Coding Implications
Frame size is measured in millimeters diagonally between motors, so a 250mm quad has motors 250mm apart corner to corner. Larger frames carry heavier payloads including bigger cameras, more sensors, or companion computers. They also have more rotational inertia, which means the PID tuning parameters you use in your flight controller configuration need to be different.
If you are writing code that auto-tunes PID values, or if you are configuring an existing autopilot, frame size is one of the inputs you need. It is not just a hardware detail.
2. Motors: What Your ESC Commands Actually Do
Motors are where electrical signals become physical rotation. For programmers, understanding motors is about understanding the relationship between your commands and actual angular velocity.
Brushless DC Motors: How They Work
Almost every serious drone uses brushless DC (BLDC) motors. Unlike brushed motors, BLDC motors do not have physical contact between the rotating and stationary parts. Instead, the speed controller electronically commutates the three-phase power to spin the motor.
What this means for your code is that you never directly command a motor. You command an ESC, which interprets your signal and applies the appropriate voltage phasing to the motor. The motor’s actual behavior is one abstraction layer below your code.
KV Rating: The Spec That Matters for Developers
Motor KV rating tells you how many RPM the motor spins per volt of input with no load. A 2300KV motor on a 3S battery (11.1V nominal) spins at roughly 25,000 RPM unloaded.
Why does this matter to you as a programmer? Two reasons.
First, when you are doing thrust calculations or simulations, KV directly feeds into your motor model. If you are writing a physics-based simulation or a software-in-the-loop (SITL) test environment, you need this number.
Second, KV affects how quickly the motor responds to throttle changes. Higher KV motors react faster, which matters for control loop tuning. If your PID parameters were written for a low-KV motor and you swap to a high-KV motor, your code will become unstable without retuning.
Motor Direction: CW and CCW
On a quadcopter, motors spin in alternating directions. Two spin clockwise (CW) and two spin counterclockwise (CCW). This is not arbitrary. The opposing torque forces cancel out, preventing the drone from spinning uncontrollably on its yaw axis.
In code, when you issue a yaw command, the flight controller speeds up all the CW motors slightly and slows down all CCW motors (or vice versa), creating a net torque that rotates the airframe. If your motor order or direction is wrong in the flight controller configuration, yaw commands will do unexpected things. Diagnosing this almost always comes back to motor mapping.
3. ESCs: The Interface Between Code and Motors
The Electronic Speed Controller (ESC) is arguably the most important hardware interface for drone programmers to understand. Your flight controller sends signals to ESCs, and ESCs translate those signals into the three-phase AC power that spins brushless motors.
ESC Protocols: The Language Your Code Uses
This is where drone hardware gets genuinely interesting from a programming perspective. ESCs do not just accept a generic signal. They accept specific protocols, and the protocol you use has real implications for your system’s performance.
PWM (Pulse Width Modulation): The oldest and most universal protocol. A 1ms pulse means minimum throttle, a 2ms pulse means maximum, and everything in between is proportional. The issue is refresh rate, typically limited to 50Hz, which means the ESC only receives a new command 50 times per second. For a control loop running at 400Hz, that is a severe bottleneck.
OneShot125 and OneShot42: These are faster versions of PWM. OneShot125 runs pulses between 125 and 250 microseconds (8x faster than PWM). OneShot42 is even faster. They sync the ESC update rate to the flight controller’s loop rate, dramatically reducing latency.
DSHOT: This is a fully digital protocol, and it is the modern standard. Unlike PWM which uses pulse timing and is vulnerable to noise and drift, DSHOT sends actual binary packets. DSHOT300, DSHOT600, and DSHOT1200 refer to the bitrate in kbits/second. With DSHOT, you also get bidirectional communication meaning the ESC can send RPM telemetry back to the flight controller, which is extremely useful for RPM-based filtering and control.
KISS and BLHeli protocols: These are ESC firmware-level protocols that add configuration and telemetry capabilities. ESC configuration (like motor direction, timing, and demag settings) can be done programmatically if you implement these protocols in your software.
For a programmer choosing a protocol: use DSHOT if your ESC and flight controller both support it. The digital reliability and bidirectional telemetry are worth it.
ESC Firmware and What You Can Actually Configure
Modern ESCs run firmware like BLHeli_32 or AM32 that you can flash and configure via USB or via a pass-through from the flight controller. If you are building a drone automation system, knowing that ESC firmware parameters like motor timing and PWM frequency are configurable via software is useful. ESC timing affects motor efficiency and heat, and some autopilot configurations involve pushing ESC parameter changes during runtime.
Current, Voltage, and Protecting Your Hardware in Code
ESCs have a continuous current rating and a burst rating. Exceeding continuous ratings for extended periods will cause thermal shutdown or permanent damage. As a drone programmer, this means your code should respect throttle ramp rates and not issue abrupt full-throttle commands, especially during complex maneuvers.
When you write automated flight scripts, smooth throttle transitions are not just about comfortable flight, they are about hardware longevity. Hard throttle spikes also cause voltage spikes that can corrupt flight controller data or trigger brownout detection.
4. Flight Controller: The Brain You Program Against
The flight controller (FC) is the embedded computer that runs the real-time control algorithms keeping your drone stable. This is the most important piece of hardware to understand deeply because most of your code either runs on it or talks to it.
What the Flight Controller Actually Does
Every control loop cycle, the flight controller reads sensor data, runs stabilization algorithms, and outputs motor commands. This happens at rates between 1kHz and 32kHz on modern hardware. At the same time, it manages communication with your ground control station, RC receiver, GPS, and any companion computer you have connected.
Popular flight controllers include the Pixhawk series (which runs ArduPilot or PX4 firmware), Betaflight boards (popular in FPV racing), and various custom boards. Each has different capabilities and different programming interfaces.
Betaflight, ArduPilot, and PX4: What the Difference Means for Your Code
This is something beginners frequently get confused about. The flight controller is hardware, but the firmware running on it defines your programming interface.
Betaflight is optimized for manual FPV flying with extremely fast loop times. Its CLI (Command Line Interface) is accessible via serial and can be scripted. Betaflight is not really designed for autonomous flight it has limited GPS and waypoint capability. Programming against Betaflight usually means configuring its parameters, not running complex autonomous missions.
ArduPilot is the workhorse of autonomous drone programming. It runs on Pixhawk hardware and supports full GPS-based autonomous missions, guided mode control, MAVLink communication, and Python scripting via DroneKit. If you are writing code to make a drone navigate a complex route, avoid obstacles, or run automated inspection tasks, you are probably using ArduPilot.
PX4 is ArduPilot’s main competitor in the autonomous space. It has a more modern software architecture, excellent ROS (Robot Operating System) integration, and is popular in research settings. The MAVSDK library lets you control PX4-based drones in Python, C++, Swift, and Java.
Choosing between ArduPilot and PX4 is often an ecosystem decision. ArduPilot has a larger community and more vehicle types. PX4 is more developer-friendly in terms of code architecture if you want to modify the firmware itself.
PID Controllers: The Algorithm at the Heart of Stability
You will hear PID everywhere in drone programming. PID stands for Proportional, Integral, Derivative, and it is the control algorithm that keeps the drone stable. When you command a 30-degree pitch angle and the drone only achieves 28 degrees, the PID controller calculates the error (2 degrees), adjusts motor speeds to correct it, and keeps doing this hundreds of times per second.
As a programmer, you will interact with PID parameters in several ways. You will configure them in your flight controller settings, you might implement your own PID loops for position control in your companion computer, and you will need to understand them to debug unstable flight behavior.
The three parameters are:
P (Proportional): How aggressively the drone corrects errors. Too high causes oscillation. Too low causes sluggish response.
I (Integral): Corrects for persistent offset errors like steady wind drift. Too high causes slow oscillation. Too low means the drone never fully reaches its target.
D (Derivative): Dampens corrections to prevent overshoot. Too high causes high-frequency vibration. Too low causes wobbling.
PID tuning is part science, part art. Tools like Betaflight’s Blackbox logging and PX4’s Flight Review let you analyze flight data and adjust parameters algorithmically. There are also autotune functions in ArduPilot that can run flight maneuvers and calculate optimal PID values automatically.
Flight Modes and What They Mean for Your Code
Flight controllers support multiple flight modes that define how they interpret commands. This is critical to understand before writing any control code.
Acro (Rate) Mode: Your commands directly set rotation rates. Full pitch stick means spin at X degrees per second. No stabilization. Highest precision but hardest to fly. Most FPV pilots use this.
Angle (Self-Level) Mode: Your commands set a target angle, not a rate. Release the stick and the drone levels itself. Good for beginners and payload drones.
Altitude Hold Mode: The flight controller uses barometric pressure to maintain a constant altitude. Forward/backward commands still work, but the drone does not climb or descend unless you specifically command it.
Loiter/Position Hold Mode: GPS-based position hold. Release all sticks and the drone hovers in place. GPS drift can cause slow wandering, which your position control code needs to handle.
Guided Mode (ArduPilot) / Offboard Mode (PX4): This is the mode your code uses for autonomous control. In Guided/Offboard mode, the flight controller takes movement commands from an external computer via MAVLink or uORB. This is the gateway to writing code that actually makes autonomous decisions.
5. Sensors: The Data Your Code Reads and Trusts
A drone is a sensor-dense machine. Understanding each sensor type, its refresh rate, its error characteristics, and how the flight controller fuses its data is essential for writing reliable autonomous code.
Inertial Measurement Unit (IMU)
The IMU is the most fundamental sensor. It contains an accelerometer and a gyroscope in a single chip. The accelerometer measures linear acceleration (including gravity), and the gyroscope measures angular velocity.
The flight controller reads the IMU at very high rates, often 1kHz or more, and runs a complementary or Kalman filter to estimate the drone’s attitude (roll, pitch, yaw orientation). Without the IMU, the drone cannot stabilize itself at all.
What this means for your code: IMU data is your most immediate sensor reading, but it accumulates error over time (gyroscope drift) and is noisy in the short term. When you read attitude data from the flight controller, understand it has already been filtered and fused. If you are building custom state estimation, you need to implement your own filter on top of raw IMU data.
Temperature affects IMU accuracy. Consumer-grade drones usually do IMU calibration at room temperature. In cold weather operations, expect more drift and potentially more aggressive PID oscillations until the IMU warms up.
Barometric Pressure Sensor
The barometer measures atmospheric pressure to estimate altitude. It is accurate to roughly 10-20cm in calm conditions but is extremely sensitive to prop wash (airflow from the motors blowing into the barometer) and wind gusts.
Flight controllers typically have foam covers over the barometer to reduce prop wash effects. In your code, when you are doing altitude-critical operations like landing on a platform or flying at a fixed height indoors, barometer-based altitude is often not reliable enough. You need to fuse it with other sensors.
GPS: Position Data Your Autonomous Code Depends On
The GPS module gives you latitude, longitude, altitude, and speed. Most drones use an external GPS module mounted on a mast above the frame to get it away from electromagnetic interference from the power system.
GPS accuracy is typically 1-3 meters CEP (Circular Error Probable) with a standard GPS. RTK (Real-Time Kinematic) GPS can get you to centimeter-level accuracy using correction signals from a base station. If you are writing code for precision landing, surveying, or agricultural spraying, RTK GPS is often necessary.
GPS has latency. There is a delay between physical movement and the GPS position update, typically 100-200ms. In high-speed autonomous flight code, you need to account for this lag or your position corrections will always be slightly behind reality. Kalman filter implementations in autopilots do this through GPS-IMU fusion, but custom position controllers need to handle it explicitly.
GPS spoofing and jamming are real concerns for drone security. If you are writing code for critical applications, GPS sanity checking (comparing GPS position with optical flow or other position sensors) adds a layer of protection.
Optical Flow Sensor
An optical flow sensor is basically a downward-facing camera that measures how fast ground features are moving beneath the drone. Combined with a rangefinder for altitude, it gives precise horizontal velocity measurements that GPS cannot provide.
Optical flow is invaluable for indoor flight where GPS is unavailable, and for precise hovering at low altitudes outdoors. The big limitation is that it needs a textured surface to work. Flying over water, sand, or featureless white surfaces gives the optical flow sensor nothing to track, and position estimates degrade rapidly.
In your code, optical flow data typically comes in as velocity measurements in body frame (relative to where the drone is pointing). Transforming these into world-frame velocity requires knowing the drone’s current heading, which comes from the IMU.
Rangefinder and Lidar
Rangefinders measure distance to surfaces below the drone. Ultrasonic rangefinders work well indoors up to about 3-4 meters. Lidar (laser rangefinder) sensors are more accurate, work at greater ranges, and function better outdoors.
For landing code, a rangefinder is practically essential. Using barometer altitude for precision landing introduces enough error that you can easily overshoot by 20-30cm, which is fine on grass but problematic on a landing pad or ship deck.
Rangefinders are also used for terrain following, where the drone maintains a constant height above the ground rather than a constant barometric altitude. Writing terrain-following code requires reading rangefinder data in a tight control loop and adjusting throttle accordingly.
Compass (Magnetometer)
The compass measures the Earth’s magnetic field to determine the drone’s absolute heading. It is critical for GPS-based flight because the GPS tells you where you are but not which way you are facing.
Compass calibration is one of the most common sources of problems in drone programming. Magnetic interference from the power system, motors, and ESCs can overwhelm the compass reading if the magnetometer is too close to these components, which is why GPS modules with integrated compasses are mounted on masts.
In your flight code and configuration, always ensure compass offsets are calibrated before autonomous flights. ArduPilot’s automatic compass learning can help in some cases, but hard iron and soft iron calibrations done on the ground are generally more reliable.
Airspeed Sensor (Fixed-Wing and VTOL)
For fixed-wing drones and VTOL (Vertical Takeoff and Landing) aircraft transitioning to forward flight, an airspeed sensor that measures the pressure differential between pitot tube and static port gives true airspeed measurement. Ground speed from GPS and true airspeed together let you calculate wind speed and direction, which feeds into wind-aware path planning code.
6. Power System: How Voltage and Current Affect Your Code
The power system is easy to overlook from a programming perspective, but it has direct impacts on flight behavior, sensor reliability, and code stability.
LiPo Batteries: Voltage Curves and What They Mean
Lithium Polymer (LiPo) batteries are the standard for drone power. Each cell has a nominal voltage of 3.7V, a fully charged voltage of 4.2V, and a minimum safe voltage of around 3.5V per cell. A 4S battery (4 cells in series) has a nominal voltage of 14.8V.
Here is the critical insight for programmers: a LiPo battery’s voltage drops under load. At full throttle, a 4S battery might read 14.8V at rest but drop to 13.5V under full load. This voltage sag is not just a hardware problem. It affects your motor performance estimates. If you have code that calculates available thrust based on voltage, you need to account for sag under load, not just resting voltage.
More importantly, your flight controller monitors battery voltage and should trigger a low-battery warning or RTL (Return to Launch) failsafe at a configured threshold. Make sure your code handles these failsafes gracefully rather than assuming full power will always be available.
Power Distribution Board (PDB) and Voltage Regulators
The Power Distribution Board takes the battery voltage and distributes it to ESCs and other components. Many modern flight controller stacks integrate the PDB directly. The PDB also provides regulated 5V and 12V rails for the flight controller, servos, and peripherals.
Your companion computer, if you have one, also needs power. Running a Raspberry Pi or NVIDIA Jetson from the drone battery requires a quality BEC (Battery Eliminator Circuit) that provides clean regulated power. Noise on the power rail can cause I2C and SPI sensor communication errors, which show up in your code as sporadic sensor readings or communication timeouts.
Current Sensor and Power Monitor
Most advanced flight controllers include a current sensor that measures how much current the battery is supplying in real time. Combined with voltage measurement, this gives you instantaneous power draw and cumulative mAh consumption.
In your code, mAh consumed is your most reliable battery state metric. Voltage alone is noisy under load. Tracking mAh from a known capacity lets you estimate remaining flight time with much better accuracy. Implementations of battery-aware path planning typically use mAh budgets rather than voltage thresholds.
7. Communication Interfaces: How Your Code Talks to the Drone
This section is purely code-relevant. These are the actual interfaces your software uses.
MAVLink: The Protocol of Drone Autonomy
MAVLink (Micro Air Vehicle Link) is the communication protocol used by ArduPilot and PX4. It is a binary protocol that defines hundreds of message types for everything from requesting telemetry data to sending navigation commands to receiving sensor readings.
When you write Python code using DroneKit or MAVSDK, you are sending and receiving MAVLink messages under the hood. Understanding MAVLink at the packet level is useful when debugging communication issues or when you need to implement custom message types.
Key MAVLink message types you will frequently encounter:
HEARTBEAT: Sent every second by both the ground station and the autopilot. Both sides need to see heartbeats to consider the connection active. Your code must send heartbeats or the autopilot will trigger a communication loss failsafe.
COMMAND_LONG and COMMAND_INT: Used to send commands like DO_SET_MODE, NAV_TAKEOFF, NAV_WAYPOINT, NAV_LAND. COMMAND_INT uses integer coordinates (in degrees * 1e7) which avoids floating-point precision issues for GPS coordinates.
SET_POSITION_TARGET_LOCAL_NED: Used in Guided/Offboard mode to send velocity, position, or acceleration setpoints in local North-East-Down frame. This is the bread and butter of custom autonomous navigation code.
GLOBAL_POSITION_INT: Telemetry message containing current GPS position, altitude, and velocity. Your position monitoring loop reads this constantly.
Serial Communication and Baud Rates
Flight controllers have multiple UART serial ports. Each can be configured to run a different function: MAVLink telemetry, RC receiver input, GPS input, ESC telemetry, or Bluetooth/WiFi module connection.
When connecting a companion computer to a flight controller, you typically use a serial connection at 921600 baud or higher for low-latency communication. Getting the baud rate and flow control settings right in your serial configuration is necessary before MAVLink can work reliably.
ROS and MAVROS for Research Applications
If you are working in a research environment, you will likely encounter ROS (Robot Operating System). ROS provides a publish-subscribe messaging infrastructure that connects different software nodes. MAVROS is a ROS package that acts as a bridge between ROS topics/services and MAVLink, allowing you to write drone control nodes in the familiar ROS paradigm.
With MAVROS, you can subscribe to topics like /mavros/local_position/pose to get position data, publish to /mavros/setpoint_velocity/cmd_vel to command velocity, and use services like /mavros/set_mode to change flight modes. If you are doing drone swarms, sensor fusion research, or computer vision-based navigation, the ROS ecosystem has mature tools that integrate cleanly through MAVROS.
SPI, I2C, and UART: Onboard Sensor Communication
Inside the flight controller, sensors communicate with the main processor via SPI or I2C buses. The IMU typically uses SPI for its high data rate. GPS uses UART. The barometer and compass often use I2C.
This matters if you are adding custom sensors to your drone. Attaching an I2C sensor to the flight controller’s I2C bus is straightforward if the sensor has a driver in ArduPilot or PX4. Writing a custom sensor driver requires implementing the appropriate bus protocol and integrating your readings into the flight controller’s sensor fusion pipeline, which is a non-trivial firmware modification.
8. Radio Control and Telemetry
RC Receivers: The Human Pilot Interface
Even on autonomous drones, an RC receiver is typically present as a safety override mechanism. If your autonomous code behaves badly, a human pilot can take over manually.
RC receivers communicate with flight controllers via several protocols:
PPM (Pulse Position Modulation): Encodes all channels on a single wire sequentially. Simple but limited bandwidth.
SBUS: A digital serial protocol used by Futaba and FrSky systems. Sends 16 channels at 100Hz. Requires signal inversion on some flight controllers.
CRSF (Crossfire): Modern protocol from TBS. Full duplex, ultra-low latency, works over the same long-range radio link as the video feed on FPV systems.
In your flight controller configuration code, you specify the RC protocol and which channels map to which functions (throttle, roll, pitch, yaw, flight mode switch, etc.).
Telemetry Radios
Telemetry radios give you a long-range bidirectional data link between your ground station software and the drone. The SiK radio modems at 915MHz (Americas) or 433MHz (Europe/Asia) are the most common. They connect to a UART on the flight controller and present as a serial port on your laptop, allowing QGroundControl or Mission Planner to communicate with the drone in real time.
For developers, telemetry radios mean you can run DroneKit or MAVSDK commands from your laptop to a flying drone without a physical cable. The radio introduces latency (typically 50-200ms depending on configuration), which matters if you are writing tight control loops from the ground station. For mission uploads and monitoring, latency is not a significant issue.
9. Companion Computers: Where Your Smart Code Runs
For anything beyond basic waypoint missions, you need a companion computer. This is an additional onboard computer, separate from the flight controller, that runs your application code.
Common Companion Computers
Raspberry Pi 4 or 5: Affordable, good community support, runs full Linux. Plenty of community examples for drone use. Limited by relatively low performance for computer vision.
NVIDIA Jetson Nano/Orin: The choice for GPU-accelerated inference. If your code does object detection, landing target recognition, or any neural network inference, Jetson hardware is worth the extra cost and weight.
Intel NUC or similar x86 boards: Maximum compute power, but heavy and power-hungry. Used in large research drones.
STM32 or ESP32 microcontrollers: For lightweight edge tasks like sensor interfacing or data logging where a full Linux environment is overkill.
Companion Computer Communication Pattern
The standard pattern is: companion computer connects to flight controller via UART or USB-serial, runs MAVROS or DroneKit, and issues high-level commands. The flight controller handles low-level stabilization and motor control.
Your code on the companion computer should never assume it is the sole authority. The flight controller has its own failsafe logic that can override your commands. Design your code with this in mind: handle failsafe transitions gracefully, listen for mode changes that your code did not initiate, and always have a path to safe landing.
10. Propellers: The Last Hardware Link Your Motor Commands Flow Through
Propellers convert motor rotation into thrust. The relationship between propeller size, pitch, and motor KV determines how efficiently your drone converts electrical power into lift.
Propeller Specifications and Thrust Calculations
A propeller is described as diameter x pitch, for example 5×4.5 (5 inch diameter, 4.5 inch pitch). Pitch is the distance the propeller would theoretically move forward in one rotation in a solid medium. Higher pitch means more air moved per rotation but also more load on the motor.
If you are writing a thrust model for simulation or for calculating maximum payload, you need to know propeller efficiency curves. These are measured in grams of thrust per watt of electrical power, and they vary with RPM and airspeed. Propeller databases like UIUC Propeller Data Site have measured performance data for common propellers that you can feed into your simulation models.
Propeller Direction and Balance
Propellers come in clockwise (CW) and counterclockwise (CCW) versions to match motor rotation direction. An imbalanced or wrong-direction propeller causes vibration that confuses IMU readings and shows up in your flight data as high-frequency noise.
When you are debugging erratic flight behavior and the IMU logs show vibration in the 100-300Hz range, the first thing to check is propeller balance and direction. This is a hardware fix, but identifying it is a code/data analysis task.
11. Putting It All Together: A Programmer’s Mental Model of a Drone
Now let us assemble this into a coherent mental model you can use when writing code.
When you call drone.takeoff(altitude=10) in DroneKit, here is what actually happens:
DroneKit sends a COMMAND_LONG MAVLink message with the NAV_TAKEOFF command and altitude parameter to the flight controller over serial.
The flight controller receives the command and enters auto-takeoff mode.
The PID controller starts spinning up motors by increasing the throttle output.
ESCs receive DSHOT packets from the flight controller with increasing throttle values.
Motors spin up, spinning propellers that push air downward and generate lift.
The barometer and GPS measure altitude increase. The IMU measures attitude.
Sensor fusion feeds corrected altitude data back into the PID controller.
The drone reaches 10 meters, the flight controller detects the target altitude, and transitions to hover state.
DroneKit receives a COMMAND_ACK message confirming the command completed.
Your code continues.
That chain, from your Python line to actual flight, crosses serial communication, a real-time OS, sensor fusion, PID control, digital motor protocols, brushless motor physics, and aerodynamics. Every component in that chain is a potential failure point and a potential debugging location.
12. Common Programming Mistakes That Come From Not Understanding Hardware
Let me give you some specific examples of bugs that come from hardware ignorance, because these are the things that will actually cost you time.
Forgetting to arm the motors before sending throttle commands. In ArduPilot, motors are always in an armed or disarmed state as a safety measure. Sending throttle commands to a disarmed drone does nothing. You must explicitly arm via MAVLink before the ESCs will respond.
Sending commands in the wrong reference frame. MAVLink position commands can be in local NED (North-East-Down) frame, body frame (relative to where the drone is pointing), or global GPS frame. Sending a “move forward” command in body frame when the drone is pointing west means the drone moves west, not in the direction your human operator considers “forward.” Always be explicit about frames in your code.
Ignoring EKF (Extended Kalman Filter) health. The EKF is the sensor fusion algorithm in ArduPilot/PX4. If GPS, compass, and barometer data are inconsistent (for example, if the drone launches before GPS gets a good lock), the EKF health flags will indicate a problem. Sending navigation commands when EKF health is bad leads to erratic flight. Your code should check EKF_STATUS_REPORT before starting autonomous missions.
Not handling communication loss failsafes. If your companion computer crashes or your code throws an exception and stops sending heartbeats, the flight controller will trigger a failsafe after a few seconds, typically RTL (Return to Launch) or land. Design your code so that controlled shutdowns always include a graceful handoff back to the flight controller, not a hard crash that stops heartbeats suddenly.
Overwhelming the serial bus with MAVLink requests. Requesting every available telemetry stream at maximum frequency is a common beginner mistake. Serial bandwidth is finite. Requesting GPS at 50Hz, attitude at 50Hz, battery status at 50Hz, and a dozen other streams simultaneously can saturate the link and cause command delivery failures. Be selective about which streams you enable and at what rate.
13. Setting Up Your Development Environment
For anyone who wants to start coding against this hardware immediately, here is the practical path.
Software-in-the-Loop (SITL) Simulation
Before you put code near real hardware, use SITL. Both ArduPilot and PX4 support SITL, which simulates the full flight controller, sensors, and vehicle physics in software. Your code talks to SITL exactly the same way it talks to real hardware.
ArduPilot SITL can be run natively on Linux or in WSL2 on Windows. Pairing it with QGroundControl gives you a full ground station. DroneKit or MAVSDK code written against SITL runs unmodified on real hardware.
Gazebo is the most common physics simulator to pair with PX4 SITL. It renders a full 3D environment, simulates wind, simulates camera sensors, and lets you test computer vision pipelines before flying real hardware.
Logging and Analysis Tools
ArduPilot Blackbox / .bin logs: Every ArduPilot flight generates a detailed binary log of every sensor reading, control output, and mode change at high frequency. Mission Planner and MAVExplorer can open these logs for analysis.
PX4 ULog format: PX4’s logging format is similar. Flight Review at review.px4.io is a web tool that visualizes PX4 logs and automatically identifies common tuning problems.
Blackbox Explorer for Betaflight: If you are working with FPV hardware running Betaflight, Blackbox Explorer decodes the flight controller’s onboard log and shows gyro data, PID outputs, and motor commands on a timeline.
14. Where to Go From Here
If you have read this far, you now have a solid conceptual foundation for drone anatomy from a programmer’s perspective. The logical next steps depend on what you want to build.
If you want to write autonomous navigation code, start with ArduPilot SITL and the DroneKit Python library. Work through basic takeoff-fly-land missions, then add waypoints, then add sensor-based decisions.
If you want to work on computer vision-based flight, get a Raspberry Pi or Jetson, set up MAVROS, and start with marker-based landing. It is a tractable first project that forces you to understand coordinate frames, camera calibration, and closed-loop visual control all at once.
If you want to work on firmware-level code, PX4 is more approachable than ArduPilot for custom module development. Their developer documentation is excellent and the uORB message bus makes adding custom sensor drivers relatively clean.
If you want to go deep on hardware interfacing, buy a Betaflight F4 or F7 flight controller, a cheap 5-inch quadcopter kit, and flash it yourself. Configuring ESC protocols, setting up telemetry, and tuning PIDs on real hardware teaches you things no simulator can replicate.
Conclusion
Drone anatomy for programmers explained properly is not about memorizing part names. It is about building a mental model of a complex embedded system so that every line of code you write is grounded in the physical reality it controls.
You now know that a motor’s KV rating affects your PID tuning, that ESC protocol choice determines your control loop latency, that flight controller firmware defines your programming interface, that GPS latency needs to be compensated in fast autonomous code, that MAVLink is the language your software speaks to autopilots, and that sensor fusion health determines whether your navigation commands will work at all.
Every one of those connections between software concepts and physical hardware will save you debugging time and make your code more reliable. The drone is not a black box anymore. It is a system you understand, and systems you understand are systems you can build on confidently.
Quick Reference: Key Terms for Drone Programmers
Term
What It Means for Your Code
KV Rating
Affects thrust model and PID tuning sensitivity
DSHOT
Digital ESC protocol with RPM telemetry feedback
PID
Control algorithm you configure and sometimes implement
EKF
Sensor fusion health check before autonomous flight
MAVLink
The protocol your drone communication code speaks
Guided/Offboard Mode
The flight mode that allows external code control
SITL
Software simulation environment for safe code testing
RTK GPS
Centimeter-accurate positioning for precision applications
SBUS/CRSF
RC receiver protocols for human override systems
mAh Consumed
Better battery state metric than voltage for flight planning
This article covers drone hardware and software concepts for educational purposes. Always follow local regulations for drone operation and never fly autonomous drones without proper safety measures in place.
Types of drones explained for beginners quadcopter, hexacopter, fixed-wing, VTOL, and FPV racing drones. Learn use cases, pros, cons, and which drone to buy.
So you’ve decided you want a drone. Maybe you saw some insane aerial footage on YouTube. Maybe your neighbor pulled one out at a family gathering and you thought, “I want that.” Or maybe you’re in agriculture, construction, or filmmaking and someone told you drones can save you time and money. Whatever brought you here you’re in the right place.
The problem is, when most people search “types of drones explained,” they get hit with a wall of technical jargon, spec sheets, and affiliate reviews that never actually answer the simple question: What kind of drone do I need, and why?
Here’s the thing drone technology has grown so fast in the last decade that “drone” is no longer a single thing. It’s an entire family of aircraft, each designed for a completely different job. A racing FPV quad has almost nothing in common with a fixed-wing survey drone, even though both technically fly without a pilot onboard. Lumping them together is like comparing a Formula 1 car to a freight truck just because both have four wheels.
This guide breaks it all down in plain language. We’ll go through every major drone type quadcopters, hexacopters, octocopters, fixed-wing, VTOL, FPV racing drones, nano drones, and single-rotor UAVs covering what each one is built for, the real pros and cons, and exactly who should be buying (or avoiding) each type.
Quick Definition A drone also called a UAV (Unmanned Aerial Vehicle) or UAS (Unmanned Aircraft System) is any aircraft that operates without a human pilot on board. Some are remotely piloted by a human on the ground; others fly fully autonomously using GPS and onboard computers. The word “drone” originally came from military vocabulary but has become the universal term we all use today.
Quadcopter Drones : The King of Consumer UAVs
If you’ve ever seen a drone in a park, a wedding video, or a real estate listing, there’s about a 90% chance it was a quadcopter. Four rotors, a central body, usually a camera underneath, and a controller in someone’s hands. That’s the quadcopter — and it’s the most common drone type on the planet by a massive margin.
The reason quadcopters dominate is dead simple: four motors give you stability without being overly complex. Two rotors spin clockwise, two spin counterclockwise. By varying the speed of each motor independently, a flight controller (basically a tiny onboard computer) keeps the aircraft level and responds to your control inputs. Want to go left? The flight controller nudges the right-side motors slightly. It happens hundreds of times per second, which is why modern quads can hover so steadily even in light wind.
Who Makes Quadcopters Worth Buying?
DJI is the 800-pound gorilla here. The DJI Mini 4 Pro, the Air 3S, and the Mavic 3 Pro are quadcopters, and they represent the gold standard for consumer and prosumer aerial photography. But there are solid options from Autel Robotics, Skydio (known for its insane obstacle avoidance AI), and Parrot as well.
Quadcopter at a Glance
The workhorse of the drone world. Four rotors, exceptional hover stability, compact design, and a massive ecosystem of accessories and software support.
4Rotors
20–40Avg Flight (min)
5–15kmTypical Range
$150–$6,000+Price Range
Pros
Easiest to learn and fly
Compact and portable
Wide range of price points
Huge software and accessory ecosystem
Great hover stability
Most repair parts available
Cons
Limited flight time (battery hog)
Struggles in strong wind
Limited payload capacity
One motor failure = crash
Not ideal for long-range mapping
Real-World Use Cases for Quadcopters
Aerial Photography and Videography: This is the big one. Real estate agents, wedding videographers, travel YouTubers, and documentary filmmakers all rely on quadcopters. A DJI Mavic 3 Pro with a Hasselblad camera produces footage that would have required a helicopter rental ten years ago.
Recreational Flying: Just want to have fun on a Saturday morning? A quadcopter is your answer. You can learn the basics in an afternoon, and the auto-hover and return-to-home features mean a mistake won’t necessarily end in a destroyed drone.
Inspection Work: Bridge inspectors, power line technicians, and building maintenance crews use quadcopters to get eyes on structures without scaffolding or bucket trucks. Companies like Skydio have specifically designed their drones to autonomously orbit structures for inspection.
Agriculture (Light Duty): Smaller farms use quadcopters with multispectral cameras to map crop health. For spraying operations, though, you need something with more payload capacity — which brings us to hexacopters and octocopters.
Search and Rescue: Emergency services increasingly deploy quadcopters with thermal cameras to locate missing persons at night or in dense vegetation. The combination of hover capability and thermal imaging makes this a natural fit.
“The quadcopter didn’t just democratize aerial photography — it completely reinvented what a small team of two people could produce on a film shoot.”
One thing beginners often don’t realize: not all quadcopters are created equal. A $200 toy quad from Amazon and a $4,500 DJI Mavic 3 are both technically quadcopters, but they’re about as similar as a scooter and a BMW. Camera sensor quality, wind resistance, obstacle avoidance, transmission range, and software capabilities vary wildly across price points. Don’t assume quadcopter = quality. Research the specific model.
Hexacopter Drones — When Six Rotors Make Sense
Add two more rotors to a quadcopter and you get a hexacopter. Sounds simple, but those two extra motors change the game in some very specific ways that matter a lot in professional settings.
The biggest benefit that professionals care about — and that most beginner guides completely miss — is motor redundancy. On a quadcopter, if one motor fails, the aircraft drops out of the sky. There’s no saving it. With a hexacopter, a flight controller that’s been configured for it can detect a motor failure and redistribute thrust across the remaining five rotors to maintain a controlled, descent — not a crash. If you’re flying a $15,000 cinema camera payload over a stadium full of people, that redundancy isn’t optional. It’s the whole point.
Hexacopter at a Glance
Six rotors for professional reliability. Heavier lift capacity, better fault tolerance, and smoother footage under load — at the cost of portability and battery life.
6Rotors
15–30Avg Flight (min)
2–10kgTypical Payload
$1,500–$30,000+Price Range
Pros
Motor redundancy — survives one failure
Higher payload capacity than quads
Smoother, more stable footage under load
Better wind resistance
More professional-grade options
Cons
Larger and heavier — less portable
Shorter battery life per charge
Significantly more expensive
More complex to maintain
Overkill for casual use
Who Actually Uses Hexacopters?
Cinema and Broadcast Production: Hollywood productions, sports broadcasters, and commercial filmmakers use hexacopters when they need to fly heavy cinema cameras — think RED, ARRI, or Sony Venice rigs. DJI’s Matrice series and FreeFly’s Alta series are go-to platforms here. The smooth, stable footage these rigs produce is worth every penny of the premium.
Industrial Inspection: Power companies use hexacopters to carry heavier sensor payloads — LiDAR units, thermal cameras, gas detectors — for inspecting transmission towers, pipelines, and offshore platforms. The payload advantage and redundancy make it the sensible professional choice.
Agricultural Spraying: In markets like India, China, and parts of Southeast Asia, agriculture drone spraying has absolutely taken off. Hexacopters with 10–20 liter tanks spray pesticides and fertilizers over rice fields, fruit orchards, and vegetable farms with precision that ground-based equipment can’t match in difficult terrain. DJI’s Agras T series dominates this segment globally.
Scientific Research: Universities and research institutions use hexacopters for environmental monitoring, wildlife surveys, and data collection in hard-to-reach areas. The ability to carry specialized scientific sensors is the key advantage.
Here’s the honest truth about hexacopters: most hobbyists have absolutely no reason to buy one. If you’re flying for fun or even semi-professional photography, a good quadcopter will serve you better — it’s cheaper, more portable, and has a larger community and accessory ecosystem. Hexacopters earn their price tag in professional applications where payload, redundancy, and stability under load genuinely matter.
Octocopters : The Heavy Lifters
Eight rotors. More power, more redundancy, more lift — and yes, more money and more complexity. Octocopters are the domain of very serious professional operators and industrial applications. You won’t find these in consumer electronics stores.
The math on lift is straightforward: more motors and larger rotors mean more thrust. Octocopters can carry payloads that would be impossible for a quadcopter or even a hexacopter — we’re talking 5kg to 20kg or more depending on the platform. For context, a fully kitted cinema camera rig with a proper lens can easily hit 5–7kg. An octocopter handles that comfortably.
Octocopter at a Glance
Eight rotors for maximum lift, redundancy, and professional-grade performance. Used in cinema, heavy industrial inspection, and specialized commercial operations.
8Rotors
10–25Avg Flight (min)
5–20kgPayload Capacity
$5,000–$100,000+Price Range
The downside? Battery life suffers dramatically when you’re moving all that weight through the air. Don’t be surprised to see an octocopter with a 15-minute operational flight time when carrying a heavy payload. That’s not a bug — it’s the physics of lift. Operators plan flights meticulously, with multiple battery sets staged on the ground.
Key use cases: Hollywood tent-pole film productions, offshore oil rig inspection, heavy agricultural spraying, search and rescue in extreme conditions, and military logistics. These are not weekend hobbyist toys. They are serious professional tools operated by licensed, experienced pilots.
Fixed-Wing Drones — Built to Cover Distance
This is where drone types start to look genuinely different. A fixed-wing drone doesn’t have spinning rotors lifting it into the air — it has wings, just like a conventional airplane. Lift comes from air moving over the wing surface as the aircraft moves forward. A single pusher or puller propeller (or sometimes two) provides thrust, and the wing does the rest.
What does that mean in practice? Fixed-wing drones are incredibly efficient over long distances. Where a quadcopter might manage 5 kilometers on a charge, a fixed-wing UAV can cover 50, 100, or even 300+ kilometers. The wing converts forward speed into lift “for free” from an energy perspective — you’re not constantly burning power just to stay in the air the way a multirotor does.
Fixed-Wing Drone at a Glance
Airplane-style wings for maximum range and efficiency. Ideal for large-area mapping, long-range surveying, and applications where endurance matters more than hover ability.
1–2Propellers
45–120+Flight Time (min)
50–300kmRange
$2,000–$250,000+Price Range
Pros
Exceptional range and endurance
Very efficient — covers huge areas per charge
Higher cruising speed than multirotors
Can glide if power is lost
Better performance in wind
Ideal for large-scale mapping
Cons
Cannot hover — always needs to be moving
Needs runway or catapult to launch
Belly landing or parachute recovery
Less intuitive to fly
Not useful for spot inspection
Requires more space to operate
The Big Limitation You Need to Understand
Fixed-wing drones cannot hover. At all. The moment they slow below stall speed, they fall out of the sky like any airplane would. This is a fundamental limitation of fixed-wing aerodynamics — it’s not a design flaw, it’s physics. That means fixed-wing UAVs are completely useless for anything that requires stationary observation, close inspection of a specific point, or hovering over a subject.
They also need a way to get airborne. Most professional fixed-wing UAVs use a bungee catapult launcher or are hand-launched by throwing them hard into the wind. Landing typically involves either a belly landing on grass (and the airframe is usually designed to absorb this), a parachute recovery system, or a net. No wheels, no runway required — but you do need open space.
Fixed-Wing Use Cases
Large-Area Photogrammetry and Mapping: This is the killer application for fixed-wing drones. Land surveyors, mining companies, civil engineers, and urban planners use fixed-wing UAVs to map massive areas — hundreds or thousands of hectares — in a single flight. The combination of range, altitude, and camera coverage area makes this far more efficient than a quadcopter could ever be. A quadcopter might map 50 hectares in several flights; a fixed-wing covers the same area in one.
Pipeline and Power Line Corridor Inspection: Energy companies operate pipelines and transmission lines that stretch hundreds of kilometers through remote terrain. A fixed-wing drone can follow a pipeline corridor for its entire length, capturing video and thermal data, then return to base — something completely impossible for a multirotor.
Military and Defense Reconnaissance: This is where fixed-wing UAVs have dominated for decades. The Northrop Grumman Global Hawk, the General Atomics Predator, and many others are fixed-wing drones that can stay airborne for 24+ hours, operating at high altitude over target areas. The endurance advantage is unmatched.
Environmental and Wildlife Monitoring: Conservation organizations use fixed-wing drones to survey national parks, track animal migration patterns, and monitor illegal poaching activity over vast wilderness areas. The long endurance makes it feasible to actually cover the territory that needs to be watched.
Disaster Relief and Border Surveillance: Fixed-wing drones can rapidly survey large areas after earthquakes, floods, or other disasters to identify damage and locate survivors — covering territory that would take ground teams days to reach.
Practical Comparison For a 500-hectare farmland survey: a quadcopter would need 8–12 flights with battery swaps and take most of a day. A fixed-wing drone completes the same survey in 1–2 flights in under 90 minutes. That efficiency difference is exactly why commercial mapping operations choose fixed-wing.
VTOL Drones : The Best of Both Worlds
VTOL stands for Vertical Take-Off and Landing. These drones are the engineering world’s answer to a very real problem: fixed-wing drones are incredibly efficient in the air but need space and special equipment to launch and land, while multirotors can take off and land anywhere but can’t go very far. What if you could have both?
That’s exactly what VTOL drones do. They take off vertically using multirotor-style motors, transition into forward fixed-wing flight once they’re airborne, cruise efficiently for long distances, and then transition back to multirotor mode to land precisely wherever you need. The engineering challenge of transitioning between these two flight modes smoothly is significant, which is why VTOL drones tend to be expensive — but the operational benefits in the right applications are enormous.
VTOL Drone at a Glance
Vertical take-off and landing combined with fixed-wing cruising efficiency. The most versatile drone type for professional operations — takes off anywhere, flies far, lands precisely.
MixedPropulsion
60–180Flight Time (min)
50–200kmOperational Range
$8,000–$500,000+Price Range
Pros
No runway or launcher needed
Fixed-wing efficiency in cruise
Long endurance + precise landing
Can operate in confined areas
Ideal for complex terrain
Growing use in urban air mobility
Cons
Very expensive compared to either type alone
Complex systems — more failure points
Heavier than pure fixed-wing
Transition phase needs careful management
Not ideal for spot hovering tasks
VTOL Design Variations
There are several different engineering approaches to achieving vertical take-off in a fixed-wing airframe:
Tilt-Rotor VTOL: The rotors physically tilt from vertical (for take-off and landing) to horizontal (for forward flight). This is the most mechanically elegant solution. Think of the military’s V-22 Osprey — that’s a full-scale tilt-rotor aircraft using the same principle.
Tail-Sitter VTOL: The entire aircraft points nose-up for take-off and landing, then rotates horizontally for cruise. Simple mechanically, but requires sophisticated flight control to handle the transition.
Dedicated Lift + Cruise VTOL: Separate sets of rotors for vertical lift (which fold away or stop during cruise) and a conventional pusher or puller propeller for forward flight. This is the most common commercial approach because it’s mechanically simpler and proven reliable. Wingtra’s WingtraOne, senseFly eBee, and many survey drones use variations of this approach.
VTOL Use Cases
Commercial Survey and Mapping: VTOL survey drones are the fastest growing segment in professional UAV operations. They combine the take-off flexibility of a multirotor (launch from a parking lot, a rooftop, a ship deck) with the range and efficiency of a fixed-wing. For infrastructure inspection and large-area mapping in areas without open launch fields, this is the professional standard.
Drone Delivery: This is one of the most closely watched applications in the entire drone industry. Companies like Wing (Google’s drone delivery arm), Amazon Prime Air, and Zipline are all building VTOL delivery platforms because they can land in customer yards or hospital helipads without needing a dedicated runway. Zipline’s operations in Rwanda and Ghana — delivering blood and medical supplies to rural hospitals — have already saved lives.
Urban Air Mobility (UAM) and Air Taxis: Every company building an electric air taxi — Joby Aviation, Lilium, Archer, Wisk — is building a VTOL aircraft. The reason is simple: cities don’t have runways. If you want to move passengers between city center vertiports, you need an aircraft that takes off and lands vertically but then cruises efficiently like a fixed-wing. VTOL is the only engineering solution that makes urban air mobility possible.
Military ISR (Intelligence, Surveillance, Reconnaissance): Defense organizations have heavily invested in VTOL UAVs for forward operating bases where there’s no infrastructure for fixed-wing launch. The ability to operate from a small clearing or a ship deck while still conducting long-range surveillance missions is operationally critical.
Offshore Operations: Oil and gas platforms, cargo ships, and coast guard vessels use VTOL drones for inspection and monitoring tasks where deck space is limited and you need to land precisely back on a moving platform.
“VTOL drones don’t just combine two drone types — they unlock entirely new operational scenarios that neither type could handle alone.”
FPV Racing Drones — Built for Pure Speed
Everything we’ve discussed so far has been about practical applications — mapping, inspection, photography, delivery. FPV racing drones are something entirely different. They exist for one purpose: to go as fast as humanly possible while a pilot wearing video goggles feels like they’re actually inside the aircraft.
FPV stands for First Person View. A small camera mounted on the front of the drone transmits live video to a headset or monitor. The pilot sees exactly what the drone sees, in real time, often with minimal latency (under 10 milliseconds on modern systems). At 140 km/h through a forest gap the width of your shoulders, that latency matters a lot.
FPV Racing Drone at a Glance
Extreme speed, raw manual control, and an immersive first-person flying experience. Built from scratch by enthusiasts or bought as RTF (ready-to-fly) kits. Not for beginners — at all.
140–200+Top Speed (km/h)
3–8Flight Time (min)
3″–5″Prop Size
$200–$1,500+Price Range
Pros
Unmatched speed and agility
Incredibly immersive flying experience
Strong community and competitive scene
Highly customizable and repairable
Used in action sports filming too
Cons
Very steep learning curve
Crashes are frequent, especially early on
Tiny battery life
No GPS, no auto-hover (usually)
Regulatory grey area in many countries
Requires significant time investment
The FPV Culture — It’s Not Just Racing
The FPV community has evolved well beyond pure racing. Today there are three distinct disciplines that use FPV-style drones:
Racing: The original. Organized through bodies like the Drone Racing League (DRL) and MultiGP, pilots compete on courses with LED-lit gates, walls, and tunnels. DRL races have been broadcast on ESPN and Sky Sports. Top pilots have professional sponsorships. It’s a genuine competitive sport.
Freestyle: Less about lap times and more about artistic expression. Freestyle pilots perform tricks — rolls, flips, split-S maneuvers, power loops through gaps — and film them. The best freestyle content on YouTube and Instagram is genuinely jaw-dropping. Pilots like Rotor Riot and Mr. Steele have millions of followers doing this.
Cinematic FPV: This is the crossover that’s taken the film industry by storm. Productions like Red Bull’s athlete films, blockbuster trailers, and music videos now routinely use FPV drones to capture shots that no other camera platform — not a crane, not a cable cam, not a stabilized cinema drone — could achieve. The combination of speed, agility, and small size lets an FPV drone fly through a speeding car’s interior, weave through a crowd, or dive off a building alongside a BASE jumper. The image quality on purpose-built cinema FPV drones has caught up with the action dramatically.
Getting Into FPV — Honest Advice
If you want to try FPV racing or freestyle, here’s the honest path: start on a simulator. Velocidrone, Liftoff, and DRL’s official simulator are excellent. Spend at least 20–30 hours in the simulator before you touch a real quad. You’ll crash hundreds of times in the sim for free. Real crashes cost money and time — props, frames, and motors add up fast.
When you’re ready for a real quad, the Betaflight flight controller firmware ecosystem is the standard. Most serious pilots build their own quads from components or buy from brands like iFlight, Emax, or BetaFPV. The DJI FPV drone is a good intro option if you want a polished RTF (ready-to-fly) experience, but experienced racers consider it a training wheel.
FPV Simulator Recommendation Velocidrone is the most realistic physics simulator for racing. Liftoff: Micro Drones is excellent for learning freestyle. DRL’s free simulator is great if you’re interested specifically in organized racing formats. All are available on PC/Mac.
Nano and Mini Drones — Small but Mighty
Not every drone needs to cover kilometers or carry professional cameras. Nano drones (typically under 100g) and mini drones (100g–250g) occupy a unique space in the drone market — they’re small enough to fly indoors, light enough to be exempt from registration requirements in many countries, and affordable enough that losing one in a tree doesn’t ruin your week.
The DJI Mini series deserves special mention here. The Mini 4 Pro weighs just 249 grams — intentionally designed to fall just under the 250g registration threshold in many jurisdictions — yet it shoots 4K video, has obstacle avoidance, and has a range measured in kilometers. It’s genuinely remarkable what the engineering has achieved at that weight. For a casual traveler or social media content creator, it’s arguably the best drone dollar-for-dollar.
Indoor Micro Drones
Below the mini category are genuine nano drones — palm-sized quadcopters that weigh 20–50 grams and can fly indoors safely. The Ryze Tello (designed with DJI) and the Hubsan Nano are examples. These are great for kids learning to fly, indoor entertainment, and basic drone photography in tight spaces. Don’t expect professional image quality or outdoor wind resistance — they’re simply not designed for it.
The interesting frontier for nano drones is military and reconnaissance applications. DARPA and various defense contractors have developed insect-sized drones capable of surveillance in urban environments. These aren’t commercially available, but they demonstrate that drone miniaturization is a serious engineering and strategic priority.
Nano/Mini Drone at a Glance
Lightweight, portable, beginner-friendly, and often regulation-exempt. Best for travel photography, indoor flying, and learning the basics without significant financial risk.
<250gWeight
15–34Flight Time (min)
1–10kmRange
$30–$900Price Range
Single-Rotor Drones — The Helicopter-Style UAV
Before quadcopters took over the world, helicopter-style UAVs were the dominant professional drone platform. Single-rotor drones look exactly like miniature helicopters — a large main rotor provides lift and forward thrust, and a small tail rotor controls yaw (rotation around the vertical axis).
The physics advantage of a single large rotor versus four smaller ones is efficiency at scale. One big rotor moves more air per unit of energy than four small rotors — the same reason actual helicopters can hover for hours while a quadcopter burns through batteries in 30 minutes. For very heavy payloads or extended hover operations, single-rotor designs can be more efficient than multirotor alternatives.
Single-Rotor at a Glance
Helicopter-style design for heavy payload operations and extended hover time. More mechanically complex and harder to fly, but more efficient at scale for specific professional applications.
1+1Rotors (main+tail)
30–90Flight Time (min)
10–50kg+Payload Capacity
$20,000–$300,000+Price Range
The main downside of single-rotor drones is complexity. A helicopter rotor system with swashplates, pitch control linkages, and tail rotor mechanics has far more moving parts than a quadcopter with its simple brushless motors and electronic speed controllers. More complexity means more maintenance, more things that can go wrong, and significantly higher skill requirements to fly safely.
Primary use cases: Large-scale agricultural spraying (especially where very large tanks are needed), heavy lift construction work, powerline stringing in remote areas, and some military applications. The Yamaha RMAX — a gasoline-powered single-rotor agricultural drone — has been used in Japan for rice paddy spraying since the early 1990s, making it one of the first truly commercial agricultural UAVs in history.
For most commercial operations today, the mechanical complexity of single-rotor drones has made them less popular than equivalent hexacopters or octocopters, which are easier to maintain and increasingly match the single-rotor’s performance advantages with modern motor and battery technology.
Full Comparison: Every Drone Type Side by Side
Here’s the honest breakdown in one place. Use this to quickly compare what matters to you:
Drone Type
Hover Ability
Range
Payload
Ease of Use
Cost
Best For
Quadcopter
●●●●●
●●●○○
●●○○○
●●●●●
$ – $$$
Photography, recreation, inspection
Hexacopter
●●●●●
●●●○○
●●●●○
●●●○○
$$$ – $$$$
Cinema, ag spraying, industrial
Octocopter
●●●●●
●●●○○
●●●●●
●●○○○
$$$$ – $$$$$
Heavy cinema, heavy lift industrial
Fixed-Wing
○○○○○
●●●●●
●●○○○
●●○○○
$$ – $$$$$
Large-area mapping, long-range survey
VTOL
●●●●○
●●●●●
●●●○○
●●●○○
$$$$– $$$$$
Delivery, survey, UAM, military
FPV Racing
●○○○○
●●○○○
○○○○○
●○○○○
$$ – $$$
Racing, freestyle, cinematic action
Nano/Mini
●●●●●
●●●○○
●○○○○
●●●●●
$ – $$
Travel, learning, indoor flying
Single-Rotor
●●●●●
●●●○○
●●●●●
●○○○○
$$$$$ +
Heavy ag spraying, heavy lift
How to Actually Choose the Right Drone
Okay, you’ve read through all the drone types. Now you need to figure out which one to actually buy or research further. Here’s a practical decision framework — and it starts not with the drone, but with you.
Step 1: Define Your Primary Use Case
Be brutally honest with yourself here. A lot of people buy a professional drone for “photography” when what they actually want is a nice aerial shot for their Instagram occasionally. There’s nothing wrong with that — but it means you don’t need a $4,000 cinema platform. A DJI Mini 4 Pro will do everything you need for a fraction of the cost.
Answer these questions before you spend a rupee:
Are you doing this for fun or professionally? Fun means budget matters a lot; professional means ROI matters. A professional drone that saves a survey firm 40 hours of ground work per project pays for itself quickly. A toy drone for weekend entertainment is about personal budget.
Do you need to hover, or do you need range? If your job involves watching a specific point — inspecting a tower, filming a stationary subject, monitoring a construction site — you need a multirotor. If you need to cover large areas efficiently, lean toward fixed-wing or VTOL.
How much payload do you need to carry? Consumer cameras on a gimbal are fine for a quadcopter. Heavy cinema cameras need a hexacopter or octocopter. Specialized sensors (LiDAR, thermal, multispectral) vary — check their weight specs against the drone’s rated payload capacity and use only 70–80% of that rating for real-world safety.
Step 2: Match Budget to Realistic Needs
Budget Guidance by Use Case
Casual recreation / learning: ₹15,000–₹50,000 ($200–$600) — Nano/mini quad, or a good simulator + entry FPV kit
Travel content creation: ₹60,000–₹120,000 ($750–$1,500) — DJI Mini 4 Pro or similar
Semi-professional photography/video: ₹1.5L–₹4L ($1,800–$5,000) — DJI Air 3S, Mavic 3 Classic, Autel EVO II
Professional cinema: ₹4L–₹20L+ ($5,000–$25,000+) — DJI Matrice series with cinema cameras, FreeFly Alta
FPV racing / freestyle: ₹15,000–₹80,000 ($200–$1,000) — Build your own or RTF kit + simulator time
Agricultural spraying: ₹8L–₹30L ($10,000–$40,000) — DJI Agras T series, XAG P series
Step 3: Think About Long-Term Costs
The drone purchase is only the beginning. Factor in batteries (each replacement typically costs 10–25% of the drone’s price), crash repair parts (especially for FPV where crashes are frequent), accessories (filters, carrying cases, spare props), software subscriptions for mapping or mission planning, and insurance if you’re flying commercially.
For professional operations, also factor in the cost and time of getting licensed. In India, commercial drone pilots need a Remote Pilot Licence (RPL) from the Directorate General of Civil Aviation (DGCA). In the US, it’s an FAA Part 107 certificate. These require study and a fee — not optional for commercial work.
Step 4: Consider the Ecosystem
A drone doesn’t exist in isolation. The software, app support, accessory availability, repair network, and community around it matters enormously. DJI’s ecosystem is vastly more developed than any competitor — their app integrations, mission planning software (DJI Pilot 2), third-party software support (DroneDeploy, Pix4D, Agisoft Metashape), and repair service network give them a significant practical advantage.
For FPV, the open-source Betaflight ecosystem is the standard, and its community is incredibly active. You’ll find help, tutorials, and component recommendations everywhere. This is part of the culture — it’s not just a product, it’s a community you’re joining.
For Beginners : The Simple Answer
If you’re a true beginner trying to figure out where to start with drones as a hobby or for basic content creation, here’s the unambiguous answer: start with a DJI Mini 4 Pro or a comparable mini quadcopter in the sub-250g class. It’s light enough to have minimal regulatory burden in most countries, capable enough for excellent photos and videos, and forgiving enough that early mistakes won’t necessarily end in an expensive crash. When you’ve mastered that and know what you actually want from a drone, then make your next purchase.
If you already know you want to get into FPV, go straight to a simulator for a month first. Seriously. Everyone who skips that step regrets it.
Drone Regulations You Absolutely Need to Know
This section could save you from significant fines, confiscation of your aircraft, or worse. Drone regulations have tightened significantly around the world over the last several years — and for good reason. Drones flying near airports, over crowds, or in restricted airspace pose real safety risks. Regulators take it seriously. You should too.
The Global Framework
Most countries base their drone regulations around two key factors: aircraft weight and operational risk. Lighter drones (typically under 250g) have fewer restrictions because they pose less physical risk if they crash. Heavier drones and commercial operations require registration, licensing, and often third-party approval for flight in controlled airspace.
India : DGCA Framework
India’s civil aviation regulator DGCA has built a comprehensive drone regulatory framework. Here are the key points every operator in India needs to know:
Drone categories by weight: Nano (under 250g) — minimal restrictions. Micro (250g–2kg) — requires registration. Small (2kg–25kg) — registration + DGCA approval. Medium and Large — full certification required.
Digital Sky Platform: India uses an online platform called Digital Sky for drone registration, pilot licensing, and flight permission requests. All commercial and non-nano drones must be registered here with a Unique Identification Number (UIN).
Remote Pilot Licence: Commercial drone operations require an RPL. Training is offered by DGCA-approved training organizations (DTOs) across major Indian cities.
No-Fly Zones: Areas within 5km of airports, 3km of international borders, near military installations, and over sensitive government infrastructure are restricted. The Digital Sky platform has a map showing green (permitted), yellow (requires permission), and red (prohibited) zones. Always check before you fly.
BVLOS (Beyond Visual Line of Sight): Flying beyond visual line of sight requires special DGCA approval. It’s permitted for specific commercial applications (precision agriculture, infrastructure inspection) under approved conditions.
United States — FAA Part 107
The FAA governs all drone operations in US airspace. Recreational flyers using drones under 250g have minimal requirements. Anyone flying commercially — even taking money for photos — needs a Part 107 certificate, which requires passing a written knowledge test. The FAA’s B4UFLY app and AirMap provide airspace information. Flying near airports without authorization through systems like LAANC (Low Altitude Authorization and Notification Capability) is illegal and can result in serious penalties.
European Union — EASA U-Space
The European Union Aviation Safety Agency (EASA) has implemented a risk-based framework with three operational categories: Open (low risk, minimal requirements), Specific (medium risk, operational authorization required), and Certified (high risk, full aviation certification). Most recreational and light commercial flying falls in the Open category, which still requires operator registration and, for drones over 250g, a completed online training course.
General Rules That Apply Almost Everywhere
Regardless of country, most regulations agree on these core principles: fly below 120 meters (400 feet) altitude; maintain visual line of sight with your drone; never fly over crowds of people without specific authorization; never fly near airports without clearance; never fly at night without special approval; never fly over emergency response operations; always give way to manned aircraft.
Before Every Single Flight — Your Checklist
Check airspace restrictions for your location (Digital Sky in India, B4UFLY in US, Drone Assist in UK)
Check weather — don’t fly in rain, strong wind, or fog
Check your drone’s battery level and firmware version
Do a pre-flight physical inspection — props, motors, camera gimbal, body
Set your return-to-home altitude above the tallest obstacle in the area
Know your emergency procedures — what do you do if you lose signal?
Tell someone where you’re flying and when you’ll be back if operating remotely
Specialized and Emerging Drone Categories
Beyond the primary types we’ve covered, there are a few specialized categories worth knowing about — either because they’re growing fast or because they represent genuinely different use cases.
Underwater Drones (ROVs)
Technically “drones” in that they operate without a pilot onboard, remotely operated vehicles (ROVs) operate underwater rather than in the air. Used for marine research, ship hull inspection, underwater pipeline inspection, and recreational exploration. Companies like Blue Robotics, OpenROV, and Fifish make consumer and professional models. They’re not UAVs in the traditional sense, but they’re part of the broader autonomous vehicle family.
Tethered Drones
A tethered drone is connected to a ground station via a physical cable that provides power (eliminating battery life limits) and a high-bandwidth data connection. The trade-off is obvious — you can only fly as high as the tether allows (typically 50–100 meters). But for persistent surveillance applications — border monitoring, event security, disaster response — a drone that can stay airborne for 24+ hours continuously is enormously valuable. Companies like Elistair specialize in this niche.
Swarm Drones
Multiple drones operating in coordinated formation, controlled by a single operator or an autonomous swarm algorithm. Intel has famously put 1,500+ drones in the air simultaneously for light shows. Militaries are investing heavily in swarm technology for reconnaissance and coordinated strike operations. Commercially, swarms are being explored for precision agriculture (each drone covering a specific grid section), search and rescue, and entertainment.
Delivery Drones
A specialized application category that cuts across multiple drone types (mostly VTOL or advanced quadcopters). Companies like Wing, Amazon Prime Air, Zipline, and Swiggy’s drone delivery pilots in India are building the infrastructure for drone package delivery. The regulatory and technical challenges are significant, but urban drone delivery is transitioning from concept to operational reality in select markets.
Agricultural Spraying Drones
Specifically designed multirotor drones (usually hexacopters or octocopters) with large liquid tanks, nozzle arrays, and GPS-guided autonomous flight. DJI’s Agras series dominates globally. In India specifically, this category has seen extraordinary growth because of the government’s push to modernize agricultural practices, the availability of subsidies for agricultural drone purchase, and the very real efficiency gains — a drone can spray 7–10 acres per hour versus 1 acre per hour for manual spraying.
FAQ : Questions People Actually Ask
What is the best drone type for beginners?
A mini quadcopter in the sub-250g class — like the DJI Mini 4 Pro — is the best starting point for 95% of beginners. It’s lightweight (which reduces regulatory burden in most countries), has excellent camera capability, flies intuitively with GPS stabilization, and is portable enough to take anywhere. Start here, and upgrade once you know what you actually want from flying.
What is the difference between a quadcopter and a hexacopter?
Simply put: a quadcopter has 4 rotors and a hexacopter has 6. The additional rotors on a hexacopter provide more lift (bigger payload capacity), better stability under load, and — critically — motor redundancy. If one motor fails on a hexacopter, a configured flight controller can attempt to land safely on the remaining five. A quadcopter with a motor failure crashes. For professional payload applications where reliability matters, hexacopters earn their premium.
Can a fixed-wing drone hover?
No. Fixed-wing drones generate lift through forward movement over their wings. If they slow below stall speed, they lose lift and descend. This is a fundamental aerodynamic constraint, not a design limitation. For any task requiring hovering — inspection, aerial filming of a stationary subject, precise landing — you need a multirotor or VTOL drone.
What does VTOL mean and who should buy one?
VTOL stands for Vertical Take-Off and Landing. These drones take off like multirotors, transition to fixed-wing forward flight for long-range efficiency, then transition back to land precisely. They’re designed for professional applications: large-area survey, delivery operations, offshore inspection, and military ISR missions. For most individuals, VTOL drones are overkill and expensive — they’re genuinely professional tools.
Is FPV racing safe for beginners?
FPV racing and freestyle are not beginner-friendly in the traditional sense. These drones typically have no GPS, no auto-hover, and no obstacle avoidance — they respond purely to pilot inputs. Crashes at 100+ km/h are common, especially early in learning. The path is: simulator first (minimum 20–30 hours), then a budget trainer quad in a safe open area, then gradually work up to speed. The learning curve is steep but the community is welcoming to committed learners.
Do I need a license to fly a drone in India?
For recreational flying of nano drones (under 250g) without a camera, requirements are minimal. For drones above 250g, you need to register on the DGCA’s Digital Sky platform and obtain a Unique Identification Number (UIN). For any commercial drone operations — photography, surveying, inspection, agriculture — you need a Remote Pilot Licence (RPL) from a DGCA-approved training organization. Flying in controlled airspace or restricted zones requires additional permissions through Digital Sky. Laws evolve, so always check the current DGCA guidelines at dgca.gov.in.
Which drone type is best for photography and videography?
For most aerial photographers and videographers, a quadcopter is the right answer — specifically in the mid-to-high consumer or prosumer range. The DJI Mavic 3 Pro (with three cameras and Hasselblad color science) and the DJI Air 3S are the leading choices in 2026. For cinema-grade productions requiring large sensor cameras, a hexacopter or octocopter platform that can carry professional cinema cameras becomes necessary.
How long can drones fly on one battery?
It varies significantly by type. Consumer quadcopters (DJI Mini 4 Pro, Air 3S) typically fly 30–45 minutes in ideal conditions. FPV racing drones last 3–8 minutes. Hexacopters with heavy payloads drop to 15–25 minutes. Fixed-wing drones last 45–120+ minutes. VTOL drones can manage 60–180 minutes depending on payload. Gas-powered single-rotor drones can stay up for hours. Always subtract 20–25% from advertised flight time for real-world conditions — wind, temperature, and payload all reduce it.
What is the range of a typical drone?
Consumer quadcopters like the DJI Mini 4 Pro have a theoretical range of 10–20km with their OcuSync or O3 transmission systems, but you’re legally required to stay within visual line of sight in most jurisdictions — which practically limits you to 500–800 meters. Fixed-wing and VTOL drones designed for professional mapping can cover 50–300km on a single charge when authorized for BVLOS operations. FPV racing drones have limited transmission range often just 1–2km before video signal degrades.
What is a drone used for in agriculture?
Agriculture is one of the most rapidly growing sectors for drone application. Key uses include: multispectral imaging for crop health monitoring and yield prediction; precision spraying of pesticides, herbicides, and fertilizers; 3D terrain mapping for irrigation planning; livestock monitoring over large ranches; and seed spreading. In India specifically, agricultural drone adoption is accelerating rapidly with government subsidies available under the Sub-Mission on Agricultural Mechanization (SMAM) scheme for drone purchase by Farmer Producer Organizations (FPOs) and agricultural cooperatives.
The Bottom Line on Drone Types
Let’s bring this all together. The types of drones explained in this guide aren’t a hierarchy where one is better than the others — they’re specialized tools, each designed for a different job. Asking which drone type is “best” is like asking whether a hammer or a saw is the better tool. The right answer depends entirely on what you’re building.
If you’re a hobbyist or content creator, a quadcopter almost certainly a DJI product — is where you want to be. The ecosystem, image quality, ease of use, and portability are unmatched.
If you need to carry heavy professional payloads, look at hexacopters and octocopters. The motor redundancy and lift capacity justify the cost in professional contexts.
If your work covers large areas and efficiency matters above all else, fixed-wing drones are the clear answer. They’ll cover 10x the ground on the same battery charge as a quadcopter.
If you need the operational flexibility of both — vertical take-off and long-range efficiency — VTOL drones solve the problem, at a significant cost premium.
If speed, adrenaline, and the pure experience of flight is what you’re after, FPV racing drones offer something no other platform comes close to matching just be ready to invest serious time in the simulator first.
And if you’re just starting out and want to dip your toes in without spending a fortune or navigating complex regulations, a nano or mini drone in the sub-250g class is your lowest-risk, highest-fun entry point.
The drone industry is moving fast. Battery energy density is improving. AI-powered obstacle avoidance is getting genuinely good. Delivery networks are expanding. Regulations are evolving to accommodate new use cases. It’s an exciting time to understand this technology — whether you’re flying for fun, building a business, or just trying to understand the aircraft you keep seeing above city parks and construction sites.
Now you know exactly what each one is, what it does, and why it matters. Go fly something.
Ready to Go Deeper?
Whether you’re choosing your first drone, building an FPV quad, or planning a commercial mapping operation the next step is picking one drone type and learning everything about it. Don’t try to do everything at once. Pick your use case, pick your platform, and start flying.
Have questions? The drone communities on Reddit (r/drones, r/fpv, r/multicopter) and the DGCA’s Digital Sky portal are excellent next stops.
Once you’ve got your quadcopter flying confidently, the natural next step for a lot of builders is learning to program it. Not just configure Betaflight, but actually write code that controls autonomous missions, waypoints, and failsafe logic. If that interests you, check out this detailed guide on how to learn drone programming from scratch in 2026 it covers the full stack from MAVLink basics to Python DroneKit missions.
Learn how to build a Raspberry Pi powered drone from scratch with full Python code, wiring diagrams, PID tuning, and a step-by-step beginner guide.
Here’s the honest truth: building a Raspberry Pi powered drone is not the cheapest or easiest way to get something flying. You can buy a ready-to-fly drone for $50 on Amazon. So why would you spend weeks soldering wires and debugging Python code instead?
Because what you actually end up with is completely different. A commercial drone is a sealed box you point at the sky. A Raspberry Pi drone project is a computer you built that happens to fly. Once you’ve built one, you understand every single thing happening between the moment you arm it and the moment it lands. You can add a camera, hook it up to computer vision, program autonomous waypoints, or attach any sensor that communicates over I2C or SPI.
Researchers use Raspberry Pi drones for mapping. Engineering students use them for autonomous flight experiments. Hobbyists build them because flying something you wrote from scratch hits differently than anything you can buy off a shelf.
This guide is written for someone who has maybe played with a Raspberry Pi before, knows basic Python, and can follow instructions carefully. You don’t need an electrical engineering degree. You do need patience.
What you’ll have at the end: A fully functional quadcopter with a Raspberry Pi 4 as the flight controller brain, running a custom Python PID control loop, controllable via radio transmitter, with real-time telemetry. Total cost: roughly $180–$250 USD depending on where you source parts.
Build a Raspberry Pi Powered Drone
Raspberry Pi Powered Drone from Scratch
1. Complete Parts List and Budget Breakdown
Before you buy anything, read this section twice. Parts compatibility is the single biggest source of frustration in DIY drone building. Everything here has been chosen to work together without modification.
Component
Recommended Model
Approx. Cost
Notes
Flight Computer
Raspberry Pi 4 (2GB or 4GB)
$35–$55
Pi Zero 2W also works for weight savings
Frame
F450 Quadcopter Frame
$12–$18
450mm wheelbase, includes PCB power distribution board
Brushless Motors (x4)
EMAX RS2205 2300KV
$10–$14 each
Match KV rating to battery voltage
ESCs (x4)
LittleBee 30A BLHeli-S
$8–$12 each
Must support PWM or DSHOT protocol
Propellers
5045 Tri-blade (4 pairs)
$8 total
Buy extras — they break
Battery
3S 2200mAh 40C LiPo
$18–$25
3S = 11.1V nominal
IMU
MPU-6050 breakout board
$3–$6
6-DOF, I2C interface
Barometer
BMP280
$2–$4
Altitude hold capability
RC Receiver
FlySky FS-iA6B
$15–$20
6-channel, iBUS protocol
RC Transmitter
FlySky FS-i6X
$45–$55
Pairs with FS-iA6B receiver
BEC / UBEC
5V 3A UBEC
$5–$8
Powers Pi from LiPo cleanly
LiPo Charger
iMAX B6AC
$25–$35
Balance charging is non-negotiable for safety
Misc
Wires, heat shrink, standoffs, zip ties
$10–$15
JST connectors are your best friend
⚠ Safety First: LiPo batteries are not forgiving. Always use a proper balance charger, never charge unattended, and store them in a LiPo-safe bag. A puffed or punctured LiPo can catch fire within seconds. This is not fear-mongering — it’s the one thing you take seriously throughout this entire build.
Tools You’ll Need
Soldering iron (60W minimum, adjustable temperature preferred)
Rosin-core solder (63/37 tin/lead or lead-free)
Digital multimeter
Hex screwdriver set (M2, M3)
Wire strippers and crimping tool
Hot glue gun for vibration management
Laptop or desktop with SSH access
MicroSD card (16GB+ Class 10)
2. Assembling the Drone Frame
The F450 frame is the gold standard entry-level quadcopter frame for a reason. The four arms bolt onto a central PCB that doubles as your power distribution board, which means you’re soldering motors to the frame itself rather than running eight separate power wires everywhere. Clean, simple, effective.
Step 1 — Identify Your Arms
The F450 uses two red arms (front) and two white arms (rear). This color coding is how you’ll know which way your drone is pointing in the air. Front-left and front-right go red. Rear-left and rear-right go white. Bolt them to the bottom PCB plate first using M3 screws — don’t fully tighten yet.
Step 2 — Solder Power Pads
The F450’s bottom PCB has labeled solder pads. Tin the pads with your iron before attaching wires. You’ll solder your ESC power leads (red=positive, black=negative) to the corresponding pads on each arm. The main battery leads connect to the large pads in the center. Use 14AWG wire for the battery connector — anything thinner will heat up under current load.
Step 3 — Mount Motors to Arms
Each EMAX RS2205 motor bolts to the end of its arm using M3 screws through the motor mount. Thread the three motor phase wires down through the arm channel. Don’t worry about which order you connect them yet — motor direction is determined by which two of the three phase wires you swap, and you’ll sort that out during testing.
Step 4 — Mount Top Plate and Standoffs
Once the bottom assembly is solid, add M3 brass standoffs (35mm height recommended) to mount the top plate. This is where your Raspberry Pi, IMU, and receiver will live. Use a tiny drop of Loctite Blue on each threaded connection — vibration will loosen screws during flight.
Motor Layout and Spin Direction
This is critical. Quadcopters need specific motor spin directions to maintain yaw stability:
If you want your DIY Raspberry Pi drone to actually lift off the ground, you need to understand the relationship between your motor’s KV rating, your battery voltage, and your propeller size.
Understanding KV Ratings
KV is RPM per volt. A 2300KV motor on a 3S LiPo (12.6V fully charged) spins at approximately 29,000 RPM unloaded. Under load with a 5-inch prop, you’re looking at 18,000–22,000 RPM. The general rule: higher KV = smaller props, more speed, less torque. For our F450 build, 2300KV motors with 5045 props gives you 600–800g of thrust per motor — more than enough to lift our ~600g finished build.
Connecting ESCs
Each ESC has three connections:
Power input (thick red/black wires): Soldered to the F450 power distribution pads
Motor output (three phase wires): Connected to your brushless motor
Signal wire (thin 3-pin servo connector): Goes to your Raspberry Pi GPIO
The BLHeli-S ESCs support standard 50Hz PWM signals from 1000–2000 microseconds pulse width. 1000μs = motors off. 2000μs = full throttle. Your Python code outputs these signals through the Pi’s GPIO pins using the pigpio library.
ESC Calibration
With props OFF and battery disconnected, connect the ESC signal wire to the Pi
Power on the ESC while sending a 2000μs (full throttle) signal
Wait for the confirmation beeps (usually 2–3 beeps)
Immediately drop to 1000μs (zero throttle)
Wait for the arm beeps
Repeat for all four ESCs
⚠ Always remove propellers during ESC calibration and any software testing. An accidentally armed motor with propellers on is how people lose fingers. Every experienced builder has a story. Learn from theirs, not yours.
4. Setting Up Your Raspberry Pi for Flight Control
Your Raspberry Pi is about to become the brain of a flying machine, so the OS setup matters more than on a normal Pi project. We need real-time performance, minimal latency, and reliable GPIO control.
OS Installation
Download Raspberry Pi OS Lite (64-bit) from the official Raspberry Pi website. We’re using Lite because we don’t need a desktop environment, and every megabyte of unused software is latency we don’t need. Flash it to your MicroSD using Raspberry Pi Imager.
Before your first boot, create an empty file called ssh in the boot partition to enable SSH, and add your WiFi credentials:
Linux is not a real-time OS by default. The kernel scheduler can interrupt your control loop at inconvenient moments. For a flight controller, even a 50ms hiccup can cause instability:
# Set CPU governor to performance mode
echo performance | sudo tee /sys/devices/system/cpu/cpu*/cpufreq/scaling_governor

# Disable unnecessary services
sudo systemctl disable bluetooth
sudo systemctl disable avahi-daemon
sudo systemctl disable triggerhappy
5. Full Wiring Guide with GPIO Pinout
This is the section where most beginners make irreversible mistakes. Take your time, use a multimeter to verify every connection before applying power, and label your wires.
⚠ Critical Wiring Warning: Do NOT connect the ESC’s red 5V wire to the Pi’s 5V rail. This creates a ground loop and can destroy your Pi. Tape off the red wire on every ESC signal connector — only signal (white/yellow) and ground (black) connect to the Pi.
Power Architecture
High-power domain: LiPo → Power Distribution Board → ESCs → Motors. Carries up to 30A and produces electrical noise that corrupts sensor readings.
Low-power domain: UBEC takes LiPo voltage in, outputs regulated 5V → Raspberry Pi + sensors. The UBEC isolates the Pi from the noisy motor circuit.
Always connect your main battery last and disconnect it first. Every time. Without exception.
6. IMU and Sensor Integration
The MPU-6050 is your drone’s inner ear. It contains a 3-axis accelerometer and 3-axis gyroscope. The gyroscope measures how fast the drone rotates around each axis (roll, pitch, yaw). The accelerometer measures linear acceleration including gravity. Your PID controller uses these readings hundreds of times per second.
Verify I2C Connection First
# Scan I2C bus — run this before writing any code
sudo i2cdetect -y 1

# You should see:
# 0x68 = MPU-6050
# 0x76 = BMP280
mpu6050.py — IMU Driver
import smbus2
import time
import math

class MPU6050:
    ADDR         = 0x68
    PWR_MGMT_1   = 0x6B
    ACCEL_XOUT_H = 0x3B
    GYRO_XOUT_H  = 0x43
    GYRO_CONFIG  = 0x1B
    ACCEL_CONFIG = 0x1C

    def __init__(self):
        self.bus = smbus2.SMBus(1)
        # Wake up the MPU-6050 (exits sleep mode)
        self.bus.write_byte_data(self.ADDR, self.PWR_MGMT_1, 0x00)
        time.sleep(0.1)
        # Set gyro full-scale range to +-500 deg/s
        self.bus.write_byte_data(self.ADDR, self.GYRO_CONFIG, 0x08)
        # Set accel full-scale range to +-4g
        self.bus.write_byte_data(self.ADDR, self.ACCEL_CONFIG, 0x08)
        self.gyro_offset = {'x': 0.0, 'y': 0.0, 'z': 0.0}

    def _read_raw_data(self, reg):
        high  = self.bus.read_byte_data(self.ADDR, reg)
        low   = self.bus.read_byte_data(self.ADDR, reg + 1)
        value = (high << 8) | low
        if value > 32767:
            value -= 65536
        return value

    def get_gyro(self):
        scale = 65.5  # LSB per deg/s for +-500 range
        return {
            'x': (self._read_raw_data(self.GYRO_XOUT_H)     / scale) - self.gyro_offset['x'],
            'y': (self._read_raw_data(self.GYRO_XOUT_H + 2) / scale) - self.gyro_offset['y'],
            'z': (self._read_raw_data(self.GYRO_XOUT_H + 4) / scale) - self.gyro_offset['z'],
        }

    def get_accel(self):
        scale = 8192.0  # LSB per g for +-4g range
        return {
            'x': self._read_raw_data(self.ACCEL_XOUT_H)     / scale,
            'y': self._read_raw_data(self.ACCEL_XOUT_H + 2) / scale,
            'z': self._read_raw_data(self.ACCEL_XOUT_H + 4) / scale,
        }

    def get_angle(self):
        a     = self.get_accel()
        roll  = math.atan2(a['y'], a['z']) * (180 / math.pi)
        pitch = math.atan2(-a['x'], math.sqrt(a['y']**2 + a['z']**2)) * (180 / math.pi)
        return roll, pitch

    def calibrate_gyro(self, samples=2000):
        print("Calibrating gyro... keep drone perfectly still")
        sx = sy = sz = 0.0
        for _ in range(samples):
            g = self.get_gyro()
            sx += g['x']
            sy += g['y']
            sz += g['z']
            time.sleep(0.002)
        self.gyro_offset = {
            'x': sx / samples,
            'y': sy / samples,
            'z': sz / samples
        }
        print(f"Gyro offsets: {self.gyro_offset}")
7. Complete Python Flight Controller Code
This is the core of your Raspberry Pi flight controller build. The loop runs at 100Hz: read IMU → compute orientation → read RC inputs → calculate PID corrections → output PWM to ESCs. Every iteration should complete in under 10ms.
complementary_filter.py
class ComplementaryFilter:
    def __init__(self, alpha=0.98):
        # alpha: weight for gyro (trust gyro 98%, accel 2%)
        # Gyro is accurate short-term but drifts over time
        # Accel is noisy but drift-free — blend both
        self.alpha = alpha
        self.roll  = 0.0
        self.pitch = 0.0

    def update(self, gyro, accel_angle, dt):
        roll_accel, pitch_accel = accel_angle
        self.roll  = self.alpha * (self.roll  + gyro['x'] * dt) + (1 - self.alpha) * roll_accel
        self.pitch = self.alpha * (self.pitch + gyro['y'] * dt) + (1 - self.alpha) * pitch_accel
        return self.roll, self.pitch
import serial
import threading

class IBUSReceiver:
    IBUS_LENGTH = 32
    IBUS_HEADER = 0x20

    def __init__(self, port='/dev/serial0', baud=115200):
        self.ser      = serial.Serial(port, baud, timeout=0.1)
        self.channels = [1500] * 6
        self.channels[2] = 1000   # Throttle defaults to zero
        self._lock   = threading.Lock()
        self._thread = threading.Thread(target=self._read_loop, daemon=True)
        self._thread.start()

    def _read_loop(self):
        while True:
            try:
                data = self.ser.read(1)
                if not data:
                    continue
                if data[0] == self.IBUS_HEADER:
                    packet = data + self.ser.read(self.IBUS_LENGTH - 1)
                    if len(packet) == self.IBUS_LENGTH:
                        self._parse(packet)
            except Exception:
                pass

    def _parse(self, packet):
        # Validate checksum
        checksum = 0xFFFF
        for i in range(self.IBUS_LENGTH - 2):
            checksum -= packet[i]
        if checksum != (packet[30] | (packet[31] << 8)):
            return
        with self._lock:
            for i in range(6):
                offset = 2 + i * 2
                self.channels[i] = packet[offset] | (packet[offset + 1] << 8)

    def get_channels(self):
        with self._lock:
            return list(self.channels)
flight_controller.py — Main Entry Point
import pigpio
import time
import os
from mpu6050 import MPU6050
from complementary_filter import ComplementaryFilter
from pid import PID
from rc_receiver import IBUSReceiver

# ── CONFIGURATION ────────────────────────────────────────────────────
MOTOR_PINS = {'m1': 18, 'm2': 23, 'm3': 24, 'm4': 25}
MOTOR_MIN  = 1000   # microseconds (disarmed)
MOTOR_MAX  = 2000   # microseconds (full throttle)
LOOP_HZ    = 100    # target control loop frequency

# PID gains — conservative starting values, tune after first hover
ROLL_PID  = PID(kp=1.2, ki=0.02, kd=0.15)
PITCH_PID = PID(kp=1.2, ki=0.02, kd=0.15)
YAW_PID   = PID(kp=2.0, ki=0.0,  kd=0.0)

# ── SETUP ────────────────────────────────────────────────────────────
def setup():
    os.nice(-10)   # elevate process priority
    pi = pigpio.pi()
    if not pi.connected:
        raise RuntimeError("pigpiod not running. Run: sudo systemctl start pigpiod")
    for name, pin in MOTOR_PINS.items():
        pi.set_servo_pulsewidth(pin, MOTOR_MIN)
    print("Motors initialized at DISARMED state")
    time.sleep(2)  # give ESCs time to register min signal
    imu = MPU6050()
    imu.calibrate_gyro()
    return pi, imu, ComplementaryFilter(0.98), IBUSReceiver()

# ── MOTOR MIXING ─────────────────────────────────────────────────────
def motor_mix(throttle, roll_corr, pitch_corr, yaw_corr):
    """
    X-frame quadcopter motor mixing.
    Diagonal motors spin same direction; adjacent motors spin opposite.
    """
    def clamp(v):
        return int(max(MOTOR_MIN, min(MOTOR_MAX, v)))
    return {
        'm1': clamp(throttle - roll_corr + pitch_corr - yaw_corr),  # Front-Left  CCW
        'm2': clamp(throttle + roll_corr + pitch_corr + yaw_corr),  # Front-Right CW
        'm3': clamp(throttle + roll_corr - pitch_corr - yaw_corr),  # Rear-Right  CCW
        'm4': clamp(throttle - roll_corr - pitch_corr + yaw_corr),  # Rear-Left   CW
    }

# ── MAIN CONTROL LOOP ────────────────────────────────────────────────
def run():
    pi, imu, cf, rc = setup()
    dt_target = 1.0 / LOOP_HZ
    armed  = False
    t_prev = time.time()
    print("Flight controller ready. Arm: throttle to minimum.")

    try:
        while True:
            t_now = time.time()
            dt    = t_now - t_prev
            t_prev = t_now

            # Read sensors
            gyro        = imu.get_gyro()
            roll, pitch = cf.update(gyro, imu.get_angle(), dt)

            # Read RC channels
            # Ch mapping: 0=Roll, 1=Pitch, 2=Throttle, 3=Yaw
            ch = rc.get_channels()

            # Arming logic
            if ch[2] < 1050:
                armed = True
            if ch[2] < 1050 and ch[3] < 1050:
                armed = False
                ROLL_PID.reset()
                PITCH_PID.reset()
                YAW_PID.reset()

            if not armed:
                for _, pin in MOTOR_PINS.items():
                    pi.set_servo_pulsewidth(pin, MOTOR_MIN)
                time.sleep(dt_target)
                continue

            # Convert RC to setpoints
            ROLL_PID.setpoint  = (ch[0] - 1500) * 0.03   # +-15 degree range
            PITCH_PID.setpoint = (ch[1] - 1500) * 0.03
            YAW_PID.setpoint   = (ch[3] - 1500) * 0.2    # degrees/sec

            # Compute PID corrections
            roll_corr  = ROLL_PID.compute(roll,      dt)
            pitch_corr = PITCH_PID.compute(pitch,    dt)
            yaw_corr   = YAW_PID.compute(gyro['z'], dt)

            # Mix and output to motors
            motors = motor_mix(ch[2], roll_corr, pitch_corr, yaw_corr)
            for name, pin in MOTOR_PINS.items():
                pi.set_servo_pulsewidth(pin, motors[name])

            # Maintain loop timing
            elapsed = time.time() - t_now
            if dt_target - elapsed > 0:
                time.sleep(dt_target - elapsed)

    except KeyboardInterrupt:
        print("\nShutting down safely...")
    finally:
        # Emergency stop — always runs even on crash
        for _, pin in MOTOR_PINS.items():
            pi.set_servo_pulsewidth(pin, 0)
        pi.stop()
        print("Motors stopped. GPIO released.")

if __name__ == '__main__':
    run()
Run command:sudo python3 flight_controller.py — sudo is required for pigpio hardware access and the os.nice() priority elevation.
8. PID Tuning for Stable Flight
PID tuning is where your Raspberry Pi drone build goes from “terrifying bouncing machine” to something that actually hovers. There’s no shortcut — every airframe behaves differently depending on motor placement, prop size, battery weight, and center of gravity.
Understanding the Three Terms
Kp (Proportional) is the main correction force. If the drone is tilted 10 degrees and Kp is 1.2, it applies 12 units of correction. Too low and the drone is sluggish. Too high and it overshoots and starts oscillating — a drone with excessive P gain looks like it’s bouncing on a spring in mid-air.
Ki (Integral) corrects for sustained errors — things like a center-of-gravity offset or unequal motor outputs that cause slow drift. Keep Ki very low. Integral windup is a real problem: if the drone sits on the ground while armed, the I term winds up to a huge number and causes a violent snap on takeoff. The anti-windup clamp in our code prevents this.
Kd (Derivative) dampens oscillations caused by high Kp. Think of it as a shock absorber. Too much D and the drone responds to sensor noise rather than actual movement — this is called “D term buzz” and you’ll hear it as a high-pitched hum in the motors.
Tuning Sequence
Start with Ki=0, Kd=0. Increase Kp until oscillations begin, then back off 20%
Add Kd gradually until oscillations are dampened without introducing buzz
Add Ki last, in tiny increments, to eliminate long-term drift
Tune roll and pitch independently — they can have different values if your frame is not perfectly symmetrical
Only tune yaw after roll/pitch are solid
Pro Tip: Tune over a soft surface — grass, foam mats, or even a pile of pillows under your test area. Hover-tune at one inch altitude so crashes are cheap. Your first 20 tuning flights will involve unexpected behavior. Plan for it.
9. Adding RC Control and Telemetry
Binding the FlySky System
Power off everything
On the FS-iA6B receiver, insert the bind plug into the BAT port
Power up the receiver — LED will flash rapidly
On the FS-i6X transmitter, hold BIND KEY while powering on
Wait for “Bind success” message on transmitter screen
Remove bind plug from receiver
Power cycle both — solid LED on receiver means bound and working
Enable iBUS Output
On transmitter: SYSTEM → RX Setup → Serial receiver type → iBUS
The receiver reconfigures automatically after re-binding
Connect the iBUS port (not the PWM ports) to your Pi’s UART RX pin
Simple WiFi Telemetry Server
Install the library first: pip3 install websockets
The difference between a successful first flight and an expensive rebuild comes down to how carefully you work through this list every single time.
Physical Inspection
All motor screws tight — zero play when you wiggle each motor
Props seated correctly, bolted down, correct spin direction per motor
Frame arms show no cracks or stress marks
All wires routed completely away from propeller arc
LiPo cell voltage: all cells within 0.1V of each other, total above 11.1V for 3S
LiPo shows no puffing, heat, or physical damage
Pi boots cleanly via SSH with no filesystem errors
Software Checks
systemctl status pigpiod — daemon must show active/running
sudo i2cdetect -y 1 — 0x68 must appear for IMU
RC receiver getting valid channels — print them and move sticks
Motor test with props OFF: each motor spins correct direction
Failsafe confirmed: RC signal loss stops all motors within 0.5 seconds
Legal Requirements
In India, the DGCA (Directorate General of Civil Aviation) requires drone pilots to register aircraft and obtain a Remote Pilot Certificate for drones above 250g. Our build exceeds 250g. Check current rules at digitalsky.dgca.gov.in before flying outdoors. Never fly near airports, above 60m without authorization, or over populated areas.
⚠ First Flight Location: Choose a large open field well away from people, roads, and overhead wires. Bring a fire extinguisher or bucket of sand. Keep the drone under 3 feet altitude for your first 10 flights. Low crashes are repairable. High crashes are not.
11. Troubleshooting Common Problems
Drone Flips Immediately on Takeoff
The most common first-flight problem. Three causes:
Wrong motor spin direction: Swap any two of the three phase wires on the offending motor. A CW motor running CCW causes an instant flip toward that corner.
Props on wrong motors: CW props have a right-hand blade twist. CCW props twist left. They’re not interchangeable. Most packs are labeled R (CW) and N (CCW).
Motor mix polarity wrong: Double-check your motor_mix() function matches the actual physical position of each motor.
Motors Beeping Constantly
ESC arming beeps are normal (3 descending tones = armed). Constant rapid beeping means the ESC isn’t receiving a valid signal. Check that pigpiod is running, your GPIO pin numbers match physical connections, and common ground is established between Pi and ESC signal wires.
IMU Not Detected on I2C
Run sudo i2cdetect -y 1. If 0x68 doesn’t appear: check 3.3V power to the MPU-6050, check that SDA and SCL aren’t swapped, confirm I2C is enabled in raspi-config. Cheap MPU-6050 boards sometimes have AD0 floating — add a 4.7kΩ pull-down resistor to ground to force address 0x68.
RC Channels Not Reading
Confirm iBUS is enabled in transmitter settings (not PPM). Then verify /dev/serial0 exists and UART is enabled in /boot/config.txt with Bluetooth disabled. Quick debug:
from rc_receiver import IBUSReceiver
import time

rc = IBUSReceiver()
while True:
    print(rc.get_channels())
    time.sleep(0.1)
Drone Oscillates in Hover
Classic Kp-too-high symptom. Drop Kp by 20% on both roll and pitch. Slow, lazy oscillations = Kp too low. Fast, high-frequency shaking = D term picking up sensor noise. Reduce Kd or add a low-pass filter to your gyro readings.
Control Loop Running Under 80Hz
Check CPU usage with htop. Common culprits: WiFi scanning, system logging, background OS updates. Disable unnecessary services. Also set I2C clock to 400kHz in /boot/config.txt: dtparam=i2c_arm_baudrate=400000
12. Frequently Asked Questions
Can I use a Raspberry Pi Zero 2W instead of the Pi 4?
Yes, and it’s a great choice for weight savings. The Zero 2W is about 10g vs the Pi 4’s 46g — significant on a small frame. The CPU handles a 100Hz control loop just fine. Main tradeoff: fewer GPIO pins and only one hardware UART. Setup steps are identical.
Is this safer to fly indoors or outdoors?
Outdoors, without question, for your first flights. Indoors means confined space, turbulence from walls, and nowhere to run if something goes wrong. Start in a large open outdoor field, keep altitude low, and stay well clear of people.
How do I add GPS for autonomous flight?
Connect a u-blox NEO-M8N GPS module to your second UART port (/dev/serial1 or via USB adapter). Parse NMEA sentences directly or use the gpsd library. For full autonomous navigation, look into ROS (Robot Operating System) on the Pi — it has mature navigation stacks built for exactly this use case.
What flight time can I expect?
With the 2200mAh 3S battery, expect roughly 8–12 minutes of actual flight time. Highly dependent on how aggressively you fly, total build weight, and ambient temperature (LiPo capacity drops in cold weather). Add a low-voltage beeper to your LiPo balance connector to know when to land.
Why not just use ArduPilot or Betaflight instead of custom code?
You can — ArduPilot Linux runs well on the Pi. But writing your own flight controller teaches you things that using ArduPilot never will: PID control, sensor fusion, real-time constraints, motor mixing. Once you’ve built one from scratch, you’ll actually understand what ArduPilot is doing under the hood, which matters when you want to debug unexpected behavior or add custom autonomous logic.
Can I add a camera to this build?
Yes. The Raspberry Pi Camera Module 3 connects directly to the CSI port. For FPV, use a dedicated analog FPV camera with a video transmitter — the Pi camera has too much latency for real-time FPV. For vision processing, recording, or machine learning, the Pi 4 handles 1080p30 comfortably.
What if I accidentally over-discharge my LiPo?
A LiPo below 3.0V per cell (9.0V total for 3S) is over-discharged and likely permanently damaged. A puffed LiPo must be disposed of at a battery recycling facility — never in regular trash. Always use a low-voltage alarm that beeps when cells drop below 3.5V per cell during flight.
Final Thoughts
Building a Raspberry Pi powered drone from scratch is genuinely one of the most satisfying things you can build as an electronics hobbyist or engineer. Every part you’ve chosen, every wire you’ve soldered, every line of Python you’ve written is doing real physics work in real time, keeping your machine in the air. That first hover — even if it’s shaky and lasts three seconds before you land nervously — is unforgettable.
The code in this guide is production-ready for a first build, but treat it as a living codebase. Add sensor filtering. Implement proper failsafes. Experiment with altitude hold using the BMP280. Add GPS waypoint navigation. The Raspberry Pi gives you the compute headroom to keep building long after your first successful flight. That’s the whole point.
Once you’ve got your quadcopter flying confidently, the natural next step for a lot of builders is learning to program it. Not just configure Betaflight, but actually write code that controls autonomous missions, waypoints, and failsafe logic. If that interests you, check out this detailed guide on how to learn drone programming from scratch in 2026 it covers the full stack from MAVLink basics to Python DroneKit missions.
Learn how to build a quadcopter drone from scratch with this complete step-by-step guide. Covers parts list, wiring, Betaflight setup, ESC calibration, cost breakdown, and beginner mistakes to avoid. Start building today.
So you’ve been watching FPV videos on YouTube at 2 AM, your jaw dropping every time a drone slices through a forest at 120 km/h, and now you’re thinking: can I actually build one of these myself?
Yes. You absolutely can.
Building a quadcopter drone from scratch is one of the most satisfying technical projects a hobbyist can take on. It sits at the crossroads of electronics, physics, software, and pure mechanical creativity. And the best part? You don’t need an engineering degree to pull it off.
This guide on building a quadcopter drone is written for beginners who are serious about learning. Not the kind of “beginner content” that glosses over everything important, but the real, honest breakdown that covers every component, every wire, every mistake, and every decision you’ll face along the way.
By the end of this article, you’ll know exactly what parts to buy, how to wire everything together, how to configure your flight controller, and how to actually get your build off the ground safely.
What Is a Quadcopter Drone?
A quadcopter is a type of multirotor aircraft that uses four motors and four propellers to fly. The “quad” part just means four. Each motor spins a propeller, and by varying the speed of individual motors, the drone can move in any direction, hover in place, or rotate on its axis.
Here’s the simple version of how it works:
Two motors spin clockwise (CW), two spin counter-clockwise (CCW)
This cancels out torque and keeps the drone stable
To move forward, the rear motors speed up and front motors slow down slightly
To rotate (yaw), motors on one diagonal speed up while the other diagonal slows down
The flight controller (a small onboard computer) handles all of this automatically, dozens of times per second. You don’t manually control each motor. You give inputs through a radio transmitter, and the flight controller translates those inputs into motor commands in real time.
That’s the magic of modern drone building. The physics are complex, but the electronics and software handle most of the heavy lifting.
Why Build Your Own Quadcopter Instead of Buying One?
Fair question. You can walk into a store and buy a DJI Mini or a Parrot drone off the shelf. Why go through the trouble of building?
Here are the honest reasons:
1. You learn how drones actually work. When something breaks (and it will break), you’ll know exactly what failed and how to fix it. RTF (ready-to-fly) drone owners are often helpless when their quad crashes.
2. You can build exactly what you want. Want a 5-inch freestyle quad? A 7-inch long-range cruiser? A tiny 3-inch indoor ripper? Building your own means you choose every component based on your specific use case.
3. It’s cheaper at the performance tier you’re targeting. A DIY 5-inch freestyle build that rips at 100+ km/h will cost you around $200-350 USD. A prebuilt with equivalent performance would run $400-600+, if you can even find one.
4. Upgrades become trivial. Want better motors? Swap them. Cracked a frame? $20 for a new one. Prebuilt drones often have proprietary parts that are expensive and hard to find.
5. The community is incredible. DIY drone building has one of the most active, helpful communities in any tech hobby. Places like Reddit’s r/Multicopter and RCGroups have millions of collective hours of experience you can tap for free.
The downside? There’s a learning curve. But that’s the point of this guide.
Parts Required to Build a Quadcopter Drone
This is where most beginners get overwhelmed, so let’s walk through each component clearly. We’ll use a 5-inch freestyle/racing quad as our build target since it’s the most popular starting point and has the best community support.
1. Frame
The frame is the skeleton. Everything bolts onto it.
For a 5-inch build, you want a 5-inch frame, which refers to the diagonal motor-to-motor distance that accommodates 5-inch propellers.
What to look for:
Material: Carbon fiber (standard for any serious build)
Weight: 70-100g is a good range for 5-inch frames
Design: “True-X” or “Stretched-X” layout (motor positions affect flight characteristics)
Stack mounting: Ensure it fits 30x30mm or 20x20mm flight controller stacks
Popular beginner-friendly frames:
Diatone Roma F5
Flywoo Explorer LR4
iFlight Nazgul5 frame
2. Motors (4x)
Motors convert electrical energy into rotational force (torque) that spins the propellers. This is one of the most important specs you’ll choose.
Brushless motors are standard for any quadcopter build. They’re efficient, powerful, and long-lasting compared to old brushed motors.
Motor specs you need to understand:
Stator size (e.g., 2306, 2207, 2306): First two digits = stator diameter in mm, last two = stator height in mm. Bigger stator = more torque and power.
KV rating: Revolutions per minute per volt (with no load). Higher KV = faster spin but less torque. For 5-inch props on 4S battery: 1700-2300KV. For 6S: 1400-1700KV.
Motor direction: Two CW (clockwise) and two CCW (counter-clockwise)
Good motors for beginners:
T-Motor F40 Pro IV (2306, 1950KV)
XING2 2207 by iFlight
Emax Eco II 2207
Pro tip: Don’t cheap out on motors. They’re the heart of your build. A motor failure mid-flight usually means a crash, so quality matters.
3. ESCs – Electronic Speed Controllers (4x or 1x 4-in-1)
The ESC sits between the flight controller and each motor. It receives a digital signal from the FC and converts it into a three-phase AC signal the brushless motor understands.
You have two options:
Individual ESCs (one per motor): More flexible, easier to replace one if it fails. Slightly more wiring.
4-in-1 ESC: All four ESCs on a single board. Cleaner build, less wiring, more popular in modern builds.
Key specs:
Current rating: For a 5-inch freestyle build, 35A-45A per ESC is fine. Go 50A+ if you’re planning aggressive flying.
Input voltage: Check it matches your battery (4S = up to 16.8V, 6S = up to 25.2V)
Protocol support: DSHOT (300, 600, or 1200) is the standard digital protocol now. Avoid older analog protocols.
Firmware: BLHeli_32 or AM32 are the current standards. Both allow ESC telemetry.
4. Flight Controller (FC)
This is the brain. The flight controller receives your radio inputs, reads sensor data from its onboard gyroscope and accelerometer, and sends precise speed commands to the ESCs to keep the drone stable.
Almost every modern freestyle and racing quad runs Betaflight firmware. Your flight controller needs to be Betaflight-compatible.
What to look for:
F7 or H7 processor (faster processing, better for modern builds)
On-board barometer and magnetometer (optional but useful)
OSD (On-Screen Display) built-in for FPV overlay
UART ports: You need at least 3 free UARTs for receiver, video transmitter, and GPS (if used)
30x30mm or 20x20mm mounting holes to match your frame
Popular beginner-friendly flight controllers:
Matek F405-CTR
Speedybee F405 V3
Holybro Kakute H7
5. Radio Receiver (RX)
The receiver is what listens to your transmitter (radio controller). It plugs into the flight controller and feeds it your stick inputs.
The protocol ecosystem matters. Your receiver must match your transmitter:
ExpressLRS (ELRS): Currently the best option. Open source, ultra-low latency (~2ms), long range, affordable. Available in 2.4GHz and 900MHz.
FrSky (ACCESS/D16): Reliable, widely used. Good range.
If you’re buying a transmitter fresh, go ExpressLRS. It’s the community standard in 2024-2025.
6. FPV Camera (Optional but Recommended)
If you want first-person view flying (seeing what the drone sees through goggles), you need an FPV camera.
For analog FPV:
Runcam Robin 3
Foxeer Razer Nano
For digital FPV (HD quality):
DJI O3 Air Unit (expensive but excellent)
HDZero Whoop Lite (lower latency than DJI)
Beginners often start with analog FPV since the complete ecosystem is cheaper.
7. Video Transmitter (VTX)
The VTX takes the camera signal and broadcasts it wirelessly to your FPV goggles. It connects to the FC for OSD data overlay and power.
Key specs:
Output power: 200mW-1W depending on local regulations (always check your country’s RF laws)
Smart Audio or Tramp protocol support: Lets you control VTX settings through Betaflight OSD without touching the board
8. Battery
LiPo (Lithium Polymer) batteries are the standard for drone power. They deliver high current bursts that LiPo chemistry handles well.
Key specs:
Cell count (S): 4S (14.8V nominal) is standard for 5-inch builds. 6S gives more punch but requires lower KV motors.
Capacity (mAh): 1300-1800mAh for 5-inch freestyle. More capacity = more weight = shorter punchy flights.
C-rating: Indicates max continuous discharge. 75C+ is preferred for freestyle. Don’t cheap out here; low C-rating batteries sag under load and perform poorly.
Connector: XT60 is standard for 5-inch builds.
9. Propellers
Propellers (props) are consumable items. You’ll break them. Buy a lot.
For 5-inch builds:
Pitch: 4.something is typical (e.g., 5148, 5147, 5045)
Blade count: 3-blade (triblade) is most common. 2-blade is more efficient for long-range.
Material: PC (polycarbonate) for durability, Nylon for lighter weight
Popular picks: HQ Props 5×4.8×3, Gemfan 51477, DAL Cyclone
10. Miscellaneous Components
Capacitor: A 35V 1000uF electrolytic capacitor across the battery leads reduces voltage spikes and motor noise. Cheap and important.
XT60 connector + pigtail: For connecting the battery to the power distribution system.
Antenna: For receiver and VTX (if external antennas required)
You don’t need a professional workshop. But you do need the right basics:
Soldering iron: A temperature-controlled iron is essential. Hakko FX-888D or TS100 are beloved community staples. Don’t use a cheap $10 iron; bad solder joints are responsible for more drone failures than any other single cause.
Solder: 63/37 or 60/40 rosin core solder. 0.8mm diameter is easiest to work with.
Flux: No-clean flux paste makes soldering motor wires and ESC pads dramatically easier.
Hex drivers: M2 and M3 sizes. A ball-end hex driver set is worth the investment.
Digital multimeter: For checking continuity, voltage, and diagnosing shorts before you power on.
Smoke stopper: A DIY in-line current limiter that prevents your ESC/FC from catching fire if there’s a short. Literally a light bulb in series. Make one before your first power-on.
Prop removal tool / prop gripper: Makes removing tight propellers much easier.
Helping hands / PCB holder: For soldering without burning your fingers.
Heat shrink tubing: Various sizes, for protecting solder joints.
Wire: 16AWG for battery leads, 22-24AWG for signal wires.
Zip ties and double-sided tape: For securing components in the frame.
Optional but helpful:
Oscilloscope (for advanced debugging)
Bench power supply (for testing without a LiPo)
Hot air gun (for heat shrink)
Step-by-Step Build Guide
Okay. Here’s where it all comes together. Take your time with each step. Rushing is how you end up with a $300 paperweight.
Step 1: Prepare Your Workspace
Clean, flat surface. Good lighting. Organize your components so you can see everything. Take photos of component layouts before you bolt things down, because you’ll thank yourself later.
Print out or open on a second screen:
Your frame’s wiring diagram
Your FC’s pinout diagram
Your ESC’s documentation
Step 2: Assemble the Frame
Start with the bottom plate. Most frames require you to thread motor mounts or arm plates through the bottom.
Install the motor mounts/arms without fully tightening yet
Route the ESC/motor wire paths through the frame cutouts (do this before motors are mounted)
Check that standoffs for the FC stack are in place
Fully tighten arm screws with thread-locker (Loctite Blue, not Red) on critical bolts
One thing beginners forget: check that the frame arms are all identical in length and angle. An asymmetric frame will fly weird and waste your tuning time.
Step 3: Mount and Wire the Motors
Each motor has three phase wires (usually labeled A, B, C or just left bare). The order you connect them to the ESC determines motor spin direction.
Procedure:
Mount motors to the arms. Motor screws should not be so long they contact the motor windings inside. Rule of thumb: screw length = motor mounting hole depth (usually 3-4mm).
Apply thread-locker to motor screws.
Route phase wires toward the ESC or 4-in-1 ESC board.
Tin (pre-coat with solder) the motor pads on the ESC and the motor wire ends.
Solder motor wires to ESC motor pads (A to A, B to B, C to C for now, direction will be reversed in software later).
Pro tip: Twist the three motor wires together loosely before routing. It reduces EMI (electromagnetic interference) slightly and looks clean.
Step 4: Install the ESC (or 4-in-1 Stack)
For a 4-in-1 ESC:
Thread the FC standoffs through the frame’s stack holes.
Seat the ESC board on the bottom standoffs.
Pass the motor wires through frame cutouts and solder them to the ESC.
Solder the battery lead/pigtail to the ESC’s VBAT and GND pads. Make these joints clean and solid, this joint carries ALL the current.
Solder the capacitor across VBAT and GND pads at the battery connection point, as close to the ESC as possible. Observe polarity (negative stripe on cap = GND).
For individual ESCs, mount each one on the arm near the motor, run signal and power wires back to the FC/PDB, and repeat motor wire soldering for each.
Step 5: Mount the Flight Controller
Seat the FC on top of the ESC (in a stack configuration) using nylon standoffs, not metal ones directly under the FC. Metal can cause shorts.
Connect the ESC-to-FC signal cable. On a 4-in-1 ESC, this is usually a 8-pin or 10-pin ribbon cable. Motor 1 signal → FC Motor 1 pad, etc.
If using separate ESCs, run individual signal wires from each ESC to the corresponding FC motor output pad.
Connect the ESC telemetry wire to a free FC UART RX pad (for ESC telemetry in Betaflight).
Check your FC orientation. If it’s not centered or not aligned with the nose of the frame, you’ll configure the mount orientation in Betaflight later. Mark which direction is forward on the FC before sealing everything up.
Step 6: Install the Receiver
Mount the receiver somewhere protected inside the frame (usually under the FC or on the rear arm).
Solder the RX to the FC:
RX 5V → FC 5V
RX GND → FC GND
RX TX → FC UART RX (for SBUS, CRSF, or ELRS protocols, the RX transmits data to the FC’s receive pin)
Route antenna wires out of the frame. For 2.4GHz ELRS, keep antennas at 90 degrees to each other for best signal coverage.
The UART assignment matters. Write down which UART port you connected the receiver to. You’ll need this in Betaflight.
Step 7: Install Camera and VTX
Mount the FPV camera in the camera bracket at the front of the frame. Typical tilt angle is 20-30 degrees for freestyle, 40-60 degrees for racing.
Connect:
Camera video out → VTX video in
Camera power (usually 5V or direct battery voltage depending on cam specs) → FC CAM output or a regulated pad
Mount VTX in the frame. If it runs hot, don’t enclose it completely.
Connect:
VTX video in → Camera video out
VTX power → ESC VBAT (many VTXes can take direct battery voltage with an internal regulator)
VTX Smart Audio or Tramp wire → FC TX pad on a free UART
VTX GND → FC GND
Antenna placement is critical. Keep the VTX antenna as far from carbon fiber as possible. Carbon absorbs RF signals. Route it out the side or back of the frame and use an antenna mount.
Wiring and Connections Explained
A lot of beginners wire everything up and then stare blankly wondering why nothing works. Here’s a mental model that helps:
Think of your drone’s electrical system in layers:
Layer 1 – Power: Battery → ESC → Motors (high current path) Layer 2 – Regulated power: ESC BEC or separate BEC → FC, Camera, VTX (5V regulated) Layer 3 – Signal: FC → ESC (motor commands), RX → FC (pilot inputs), FC → VTX (OSD data)
Every component needs power from the right layer and a common ground reference. If you have a “floating ground” (a component that shares no ground with the FC), it won’t communicate properly.
Ground loop rule: Every component’s GND wire should ultimately connect back to the battery negative. You can daisy-chain grounds, but if you break the chain, you break communication.
The smoke stopper test: Before connecting a real battery, use your smoke stopper (DIY current-limiting device). If the bulb glows bright and stays on, you have a short. Disconnect immediately and find it before you destroy your ESC.
Flight Controller Setup: Betaflight Configuration
Betaflight is free, open-source firmware that runs on your flight controller. You configure it through Betaflight Configurator, a desktop app available for Windows, Mac, and Linux.
Initial Connection
Connect FC to your PC via USB (micro-USB or USB-C depending on FC)
Open Betaflight Configurator
Click “Connect” in the top right corner
If the FC isn’t detected, install the appropriate driver (ImpulseRC Driver Fixer is a lifesaver here)
Step-by-Step Betaflight Setup
Firmware tab: Flash the latest stable Betaflight release for your FC target. Don’t flash the latest release candidate unless you know what you’re doing.
Ports tab:
Set the UART where your receiver is connected to “Serial RX”
Set the UART where your VTX SmartAudio/Tramp is connected to “VTX (TBS SmartAudio)” or “IRC Tramp”
Enable ESC telemetry if your ESC supports it
Configuration tab:
Set your receiver protocol (CRSF for ELRS/Crossfire, SBUS for FrSky, etc.)
Enable features you need: Air Mode, Anti-Gravity, Dynamic Notch filter
Set board alignment if your FC is rotated (enter degrees in Roll/Pitch/Yaw)
Set motor protocol to DSHOT600
Receiver tab:
Verify stick inputs are moving the bars correctly
Set stick ranges (usually 1000-2000us)
Assign channel map (AETR1234 is common for most radios)
Modes tab:
Assign Arm to a switch on your transmitter
Assign Angle/Horizon/Acro to switches
Assign Beeper to a switch (saves crashed drones)
OSD tab: Configure what’s shown on your FPV display: battery voltage, RSSI, flight timer, mAh consumed, etc.
Motors tab: This is critical. With props OFF, connect your battery (use smoke stopper first), go to Motors tab, enable the motor test slider, and spin each motor individually. Verify:
Each motor spins when its slider is moved
Motor direction is correct (checking against Betaflight’s motor direction diagram)
If a motor spins the wrong direction, go to the ESC telemetry/BLHeli_Suite and reverse that motor’s direction in software. No rewiring needed.
PIDs tab: Leave PIDs at defaults for your first flight. Betaflight’s defaults are flyable. Don’t touch PIDs until you’ve done several flights and identified specific behavior issues.
Calibration and Testing
ESC Calibration
With DSHOT protocol, ESC calibration is handled automatically via Betaflight. No manual calibration needed. This is one of the biggest advantages of DSHOT over older analog protocols.
If you’re using older analog protocols (not recommended), you’ll need to perform manual ESC calibration by following the ESC’s manual.
Accelerometer Calibration
In Betaflight’s Setup tab, click “Calibrate Accelerometer” with the drone on a flat, level surface. This teaches the FC what “level” means. Important for Angle and Horizon modes, but not strictly needed for Acro (manual) mode.
Radio Calibration
In the Receiver tab, check all your sticks and switches register correctly. Set the channel ranges so min is ~1000 and max is ~2000.
Set your arm switch. In Betaflight Modes tab:
Arm switch at full position should arm the drone
Ensure the “minimum throttle” requirement is set (you usually need throttle at zero to arm)
Pre-Flight Checklist (Every Single Time)
Never skip this. Experienced pilots run this checklist every flight:
Props tight and secure (check each one with a twist)
Battery fully charged and plugged in securely
All motor screws tight
Range check on radio (walk 30 paces, ensure full control)
OSD showing correct battery voltage
Arm in a safe direction (nose pointing away from people)
Common Mistakes Beginners Make
These are the top failures I see, in real builds:
1. Wrong prop direction. Props have a top and bottom side. Flat face up, curved face toward the ground (the curve creates lift as air moves over it). Many beginners install them upside down and wonder why the drone won’t lift.
2. Not using thread-locker on motor screws. Vibration loosens screws. A motor that falls off mid-flight is a disaster. Use Loctite Blue (removable) on all motor screws.
3. Cold solder joints. These look shiny but have a grainy, dull texture under good light. They make intermittent contact. Heat both the pad and the wire simultaneously, then flow solder into the joint. Don’t touch solder to the iron directly.
4. Wrong UART assignment. Plugging the receiver into UART2 but telling Betaflight it’s on UART1. Always double-check port assignments.
5. Skipping the smoke stopper. One short can kill your FC, ESC, and battery in seconds. The smoke stopper is not optional.
6. Flying in Acro mode before you’re ready. Acro mode has no self-leveling. If you let go of the sticks, the drone maintains whatever angle it’s at. Learn in Angle mode first, or use a simulator (Velocidrone, Liftoff) before touching a real quad.
7. Not trimming PID gains. Flying a quad with stock PIDs is fine for testing, but a quad that oscillates violently or feels sluggish needs PID adjustment. Learn the basics of PID tuning or use Betaflight’s RPM filter and Blackbox for data-driven tuning.
8. Ignoring motor temperature. After test flights, touch the motors (carefully). If they’re hot enough to hurt, they’re being pushed too hard. Check for incorrect prop choice, motor direction, or ESC settings.
9. Battery over-discharge. Don’t fly until your battery is at 3.0V per cell or lower. LiPo batteries damaged by over-discharge can swell, catch fire, or simply lose 50% of their capacity permanently. Land at 3.5V per cell.
10. Not labeling wires. Inside a drone frame it gets chaotic. Use small pieces of colored heat shrink or marker labels so you know what each wire does six months later when you’re troubleshooting.
Safety Tips for Drone Builders
Safety isn’t just about not crashing. It’s about not hurting yourself, others, or property.
Electrical safety:
Never charge LiPo batteries unattended
Charge in a LiPo-safe bag or metal container
If a battery swells (puffy), stop using it immediately. Dispose at a battery recycling facility.
Never short a LiPo. Even briefly shorting a charged 4S can release enough energy to cause severe burns.
Flying safety:
Always fly in legally permitted areas. In most countries (including India), you need a DGCA Remote Pilot Certificate to fly drones above 250g.
Never fly over people or near airports without proper clearance
Keep visual line of sight unless you’re certified for BVLOS
Always have a spotter when flying FPV (someone watching the physical drone)
Never arm a drone with props on while working on it or near people
Build safety:
Don’t solder in an enclosed space without ventilation. Solder flux fumes are unpleasant and potentially harmful.
Wear safety glasses when spinning props for testing. A broken prop at 20,000 RPM is a projectile.
Keep props off the drone until all electronics are configured and tested
In India specifically: The DGCA has specific rules under the Drone Rules 2021. Nano drones (under 250g) have minimal restrictions. Micro drones (250g-2kg) need registration and a pilot certificate for outdoor flying. Build accordingly.
Cost Breakdown
Here’s a realistic parts cost for a 5-inch freestyle quad in 2025 (USD):
Component
Budget Option
Mid-Range
Frame
$15-20
$25-45
Motors (x4)
$40-50
$60-100
4-in-1 ESC
$25-35
$40-65
Flight Controller
$25-35
$45-75
Receiver (ELRS)
$15-20
$25-35
FPV Camera (analog)
$15-20
$25-40
VTX (analog)
$15-20
$25-40
Props (10-pack)
$5-10
$10-15
Battery (x2)
$30-40
$55-80
Misc (hardware, wire, capacitor)
$10-15
$15-20
Total (build only)
$195-265
$325-515
Additional costs if starting from zero:
Radio transmitter: $30 (Radiomaster Pocket with ELRS) to $200+ (Radiomaster TX16S)
FPV goggles (analog): $50-150
Battery charger: $30-60
Soldering iron + supplies: $40-80
Budget full setup (build + radio + goggles + charger): ~$350-500 Mid-range full setup: ~$600-900
DIY vs Prebuilt Drone Comparison
Factor
DIY Build
Prebuilt RTF
Upfront cost
Lower at performance level
Higher
Time to first flight
10-30 hours
Minutes
Repairability
Excellent
Poor (proprietary parts)
Customizability
Unlimited
Very limited
Knowledge gained
High
Minimal
Performance tuning
Full control
Limited or locked
Beginner friendliness
Lower
Higher
Community support
Huge
Depends on brand
The verdict: If you want to truly understand drones, fly better, and maintain your aircraft independently, DIY is the path. If you just want aerial footage and aren’t interested in the technical side, DJI makes excellent prebuilt products.
Most serious FPV pilots build their own for performance and freestyle. Photography pilots often go prebuilt for reliability.
Upgrades and Customization
Once you have your first build flying, the rabbit hole opens up. Some popular upgrade paths:
HD Digital FPV: Switching from analog to DJI O3 Air Unit or HDZero dramatically improves your FPV video quality. Expect to spend $100-250 for this upgrade.
GPS and Return-to-Home: Adding a GPS module ($20-30) and configuring GPS Rescue in Betaflight gives you a safety net if you lose signal. Essential for longer-range flying.
Blackbox logging: Many FCs have onboard Blackbox (data logging). Enabling this and using Betaflight Blackbox Explorer lets you see exactly what your FC was doing during a flight, invaluable for PID tuning.
RPM filtering: If your ESC supports DSHOT with telemetry, you can use RPM-based dynamic notch filtering in Betaflight. This dramatically reduces propwash and oscillations by filtering out motor harmonics. It’s one of the biggest flight quality improvements available.
Custom motor mounts and TPU parts: 3D-printed TPU (thermoplastic polyurethane) camera mounts, antenna holders, and battery straps let you protect components and personalize your build. The FPV community shares thousands of free designs on Thingiverse and Printables.
Longer antennas and external VTX antennas: If your range is limited, upgrading to a better VTX antenna (pagoda, lollipop, or patch array on your goggles) can significantly improve FPV signal.
Troubleshooting Guide
Drone won’t arm:
Is throttle at zero?
Is the arm switch assigned correctly in Betaflight Modes tab?
Check Betaflight’s Arming Flags in the main Setup tab. Hover over the flag for an explanation.
Common culprits: RXLOSS (receiver not detected), THROTTLE (throttle not at zero), ANGLE (roll/pitch angle too steep)
Motors not spinning when testing:
Check DSHOT protocol is selected in Configuration tab
Verify motor signal wires are connected to correct FC pads
Check ESC is powered (battery connected, not just USB)
One motor spinning wrong direction:
Reverse in BLHeli Suite or via Betaflight motor direction settings (DSHOT command)
Drone flips on takeoff:
Wrong motor direction for one or more motors
Props installed on wrong motors (CW prop on CCW motor)
Check motor diagram in Betaflight against your physical layout
FPV image is black or fuzzy:
Check camera power voltage (some cameras need 5V, others run on 12V or battery voltage)
Verify camera video wire is connected to VTX video input, not another pin
Check VTX channel and band matches your goggles
RSSI is low or connection drops:
Antenna orientation (keep at 90 degrees for omni coverage)
Antenna too close to carbon fiber or battery
Check receiver bind and protocol in Betaflight
Motors getting very hot:
Wrong prop pitch/size for your motor KV
Flying with damaged/unbalanced props
Low C-rating battery causing voltage sag and motors working harder
Excessive vibration in flight:
Unbalanced or damaged props (replace immediately)
Loose motor screws
Motor bearing worn out (listen for a gritty sound when spinning by hand)
FAQs: Building a Quadcopter Drone
How long does it take to build a quadcopter drone from scratch?
For a first-time builder, expect 15-30 hours spread over several days. This includes component sourcing time, reading documentation, soldering, configuring Betaflight, and testing. With experience, builders can complete a new build in 3-5 hours. Don’t rush your first build. Every hour you spend double-checking connections saves you from expensive mistakes.
What is the best motor KV for a 5-inch quadcopter?
For a 4S LiPo battery with 5-inch props, 1900-2300KV is the sweet spot. For 6S, drop to 1400-1700KV. Higher KV on 6S would overspin the motor and burn it out. The KV, battery voltage, and prop size are a triangle: change one and you need to reconsider the others.
Do I need to register my DIY drone in India?
Yes, if your completed drone weighs more than 250 grams. Under India’s Drone Rules 2021, drones in the Micro category (250g-2kg) require registration with the DGCA’s Digital Sky Platform and a Remote Pilot Certificate (RPC) for outdoor flying in most zones. Nano drones (under 250g) have fewer restrictions but still cannot be flown in certain zones like airports, military areas, and national parks.
What is the difference between Acro mode and Angle mode?
Angle mode uses the accelerometer to keep the drone level. If you release the sticks, it self-levels. Great for beginners. Acro mode (full manual) does not self-level. The drone holds whatever angle you put it in. It feels like the difference between driving a car with traction control (Angle) versus a rear-wheel-drive car with traction control off (Acro). Acro feels more natural with practice and gives much more control, but requires proper stick technique.
What is ESC calibration and do I need to do it?
ESC calibration is a process of teaching the ESC what throttle range corresponds to minimum and maximum power. With analog protocols (PPM, PWM), this is required manually. With DSHOT digital protocol (which is what you should be using), calibration is handled automatically by Betaflight sending digital values. If you’re using a modern build with DSHOT, you do not need to manually calibrate your ESCs.
How far can a DIY quadcopter fly on one battery?
For a typical 5-inch freestyle build, expect 4-6 minutes of aggressive flying on a 1500mAh 4S battery, or 7-10 minutes of cruising. Range in terms of distance is limited by your FPV signal and radio link. With ExpressLRS 2.4GHz and decent antennas, you can maintain link at 2-4km, though flying that far FPV on analog with a 200mW VTX would be challenging. Long-range builds with 7-inch+ frames and 900MHz ELRS can cover 10-20km+ on a single charge.
How do I choose between a 4S and 6S build?
4S (14.8V nominal, 16.8V full) is the standard recommendation for beginners. More components are available, tuning is more forgiving, and batteries are cheaper. 6S (22.2V nominal, 25.2V full) gives more motor efficiency, cooler-running motors, and generally crisper throttle response. But it requires lower KV motors and costs more in batteries. Start with 4S, move to 6S if you want to optimize performance later.
What simulator should I use before flying my first quadcopter?
Velocidrone is the gold standard for learning quad control. It has realistic physics and is used by professional FPV racers for training. Liftoff is more accessible and visually polished. DRL Simulator (Drone Racing League) is free on Steam and a decent introduction. Spend 10-20 hours in a simulator before your first real flight. Your muscle memory from the sim will translate directly, and you’ll crash virtual quads instead of real ones while learning the basics.
Can I build a quadcopter that takes photos or video for real estate or photography?
Yes, but the architecture is different from a freestyle build. Photography quads prioritize stability, smooth gimbal-stabilized camera movement, and long flight time over raw performance. For this purpose, starting with a prebuilt like a DJI Mini 4 Pro is probably smarter unless you specifically want the DIY experience. If you do DIY for photography, you’d pair a 7-inch+ long-range frame with a gimbal, GPS, and an HD camera. This is a significantly more complex build than a freestyle quad.
Final Thoughts
Building your first quadcopter drone is a journey that touches every corner of electronics, software, and physics. You’ll solder your first joint, watch a motor spin for the first time when you push the slider in Betaflight, and feel a completely different kind of excitement when that machine you built with your own hands lifts off a field for the first time.
It’s going to be frustrating at points. A solder joint that looks fine will cause intermittent problems. Betaflight will show an error flag you’ve never seen. A prop will shatter on the first landing.
That’s normal. Every experienced builder has a graveyard of broken components behind them.
The community around DIY drone building is genuinely one of the most welcoming and knowledgeable technical communities online. Don’t hesitate to post questions on r/Multicopter, the Betaflight GitHub issues page, or dedicated FPV Discord servers. The odds are high that someone has encountered your exact problem before.
Keep your first build simple. Get it in the air. Get some flights under your belt. Then start asking yourself “what would I change?” That question is what drives every upgrade, every next build, and every hour of tinkering in this hobby.
The sky is literally the limit, but it starts on your workbench with a soldering iron.
Once you’ve got your quadcopter flying confidently, the natural next step for a lot of builders is learning to program it. Not just configure Betaflight, but actually write code that controls autonomous missions, waypoints, and failsafe logic. If that interests you, check out this detailed guide on how to learn drone programming from scratch in 2026 — it covers the full stack from MAVLink basics to Python DroneKit missions.
Learn drone programming step by step with this beginner-friendly guide. Understand drone coding, Python, DJI drones, FPV learning, simulators, and real-world drone skills.
If you are curious about drone programming, you are already ahead of most people. Drones are no longer just flying toys. They are used in photography, videography, agriculture, mapping, delivery, defense, and research. Behind every smooth takeoff and stable landing is code. In this guide, I will walk you through how to learn drone programming step by step, like I would explain it to a smart friend over coffee. No fluff, no corporate talk, just clear and practical guidance.
This article is written for beginners but goes deep enough to help you grow into real-world skills. Whether you want to learn drone coding for fun, education, or a future career as a drone programmer, everything starts here.
What Is Drone Programming and Why It Matters
Drone programming is the process of writing software that controls how a drone behaves. This includes flight control, navigation, obstacle avoidance, camera movement, and communication with ground systems.
When people say programming a drone, they usually mean one or more of these:
Controlling flight direction and speed
Automating takeoff and landing
Making drones follow GPS paths
Adding camera logic for photos and videos
Coordinating multiple drones together
Learning drone programming gives you control. Instead of just flying a drone manually, you can tell it exactly what to do.
Is It Easy to Learn to Fly a Drone?
This is one of the most common questions beginners ask: is it easy to learn to fly a drone?
The honest answer is yes, basic flying is easy. Modern drones are stable and beginner-friendly. Many people can learn how to fly a drone in 7 minutes using beginner modes.
But there is a difference between flying and programming.
Another common question is is it hard to learn to fly a drone? Advanced flying like FPV drone learning, manual mode, and precise movements takes practice. Programming adds another layer, but it is not scary if you start correctly.
Learn Drone Programming vs Learn to Fly First
You do not need to be an expert pilot before learning drone programming. Many developers start with simulations and virtual environments.
A good learning path looks like this:
Learn basic drone controls
Understand how drones stay stable
Start with virtual drone programming
Move to real hardware
This approach saves money and reduces risk.
Learn Drone Programming Step by Step
Step 1: Understand How Drones Work
Before coding, you should understand:
What a quadcopter is
How motors and propellers work
What sensors like gyroscope and accelerometer do
How GPS helps drones navigate
This foundation makes programming logical instead of confusing.
Step 2: Choose the Right Programming Language for Drones
A very common question is what programming language do drones use?
The answer depends on the drone and your goal.
Python
Most popular for beginners
Used widely in programming drones with python
Great for automation and AI
Perfect if you want to programming a drone with python
C and C++
Used in low-level flight controllers
Common in drone programming C
Faster and closer to hardware
JavaScript
Used in some web-based drone control systems
Useful for dashboards and interfaces
Known as drone programming javascript
Scratch
Visual programming for beginners
Ideal for students and kids
Popular in drone programming with scratch
If you are new, Python is the best place to start.
How to Program a Drone with Python
Many beginners search for how to program a drone with python because Python is readable and powerful.
You can use Python to:
Control takeoff and landing
Move the drone forward, backward, up, and down
Read sensor data
Control camera actions
Libraries like DroneKit and ROS make this easier. You will often see tutorials titled programming a drone with python or programming drones with python, and for good reason. Python lowers the entry barrier.
Programming a Drone from Scratch
When people hear programming a drone from scratch, they imagine building everything themselves. In reality, it means:
Using a flight controller
Writing custom logic on top of existing firmware
Controlling behavior through code
You rarely write everything from zero, but you control how the drone behaves.
This is where you truly learn to program drones instead of just flying them.
Drone Programming Tutorial: What You Should Learn First
A solid drone programming tutorial should cover:
Basic movement commands
Orientation and rotation
Sensor data reading
Safety checks
Emergency landing logic
Once these basics are clear, advanced topics become easier.
Learn Drone Coding Through Courses and Classes
Many learners prefer structured learning.
Beginner Drone Training
Beginner drone training focuses on:
Safety rules
Manual flight basics
Introduction to drone programming
Beginner Drone Classes Near Me
Searching for beginner drone classes near me can help you find local workshops. These often combine flying and coding.
Drone Coding Course and E-Learning
Online options include:
Drone coding course platforms
Drone programming with python course
Drone e-learning portals
These are flexible and beginner-friendly.
Programmable Drones for Education
If you are just starting, using programmable drones for education is a smart move.
Popular options include:
Mini drones with Python support
Scratch-based learning drones
DJI learning drone models
These drones are designed to help you learn without breaking expensive hardware.
Programming DJI Drones
Many people want to know about programming DJI drones because DJI is popular.
DJI provides SDKs that allow:
Automated flights
Camera control
Waypoint missions
Using a DJI learning drone is a great way to practice safely while learning real skills.
Mini Drone Programming for Beginners
Mini drone programming is perfect for beginners. These drones:
Are affordable
Can be flown indoors
Support basic coding
They help you learn logic without worrying about crashes.
FPV Drone Programming and Learning
FPV drones are different. FPV drone programming focuses more on:
Flight controller tuning
Manual control logic
Custom firmware
If you are interested in racing or freestyle, FPV drone learning and FPV drone lesson programs teach both flying and technical setup.
Drone Lessons for Beginners
Good drone lessons for beginners include:
Theory
Simulator practice
Real flight sessions
You may also find simple drone lesson videos and tutorials online.
Learn Drone Photography and Videography
Not all drone programmers focus on flight alone.
Many learners want to:
Learn drone photography
Learn drone videography
Programming helps automate camera movements, smooth shots, and repeatable paths.
UAV Drone School and Professional Coaching
If you want a career path, consider:
UAV drone school programs
Working with a UAV drone coach
These focus on regulations, safety, and advanced programming.
Virtual Drone Programming and Simulators
Before flying real drones, use simulators for virtual drone programming.
This skill is used in research and defense applications.
Programming Quadcopter Systems
A quadcopter is the most common drone type. Programming quadcopter systems involves:
Balancing thrust
Stabilization logic
Sensor fusion
This is where theory meets real engineering.
Community Learning and Drone Programming Reddit
Learning alone can be hard. Communities like drone programming reddit help you:
Ask questions
Share projects
Learn from real mistakes
This keeps learning realistic and human.
Special and Niche Drone Topics
You may also come across:
Q10 drone tutorial content
X drone instructions
Models like Z L drone
These are brand-specific but still useful for practice.
Drone Programming Kits
Drone programming kits bundle hardware, software, and tutorials. They are great for:
Students
Self-learners
Classrooms
These kits often support Python or Scratch.
R Programming Lessons and Drones
Some learners explore data analysis using R learn programming and R programming lessons for drone data. While R is not used to control drones directly, it helps analyze flight data, mapping, and research results.
Drone Programmer Career Path
A drone programmer works on:
Autonomous navigation
Computer vision
Control systems
This role blends software engineering with robotics.
Final Thoughts: How to Learn Drone Programming the Smart Way
Learning drone programming is not about memorizing commands. It is about understanding how machines think and move in the real world.
Start small. Use simulations. Learn Python. Practice with mini drones. Join communities. Take structured courses when needed.
If you stay consistent, drone programming becomes less mysterious and more exciting. With time, you will not just fly drones, you will tell them exactly how to behave.
That is when learning turns into real skill.
Frequently Asked Questions (FAQ) About Drone Programming
1. What is drone programming in simple words?
Drone programming means writing code that tells a drone how to fly, where to go, and what actions to take, like taking photos, avoiding obstacles, or landing safely.
2. How can a beginner start learning drone programming?
A beginner should start by understanding how drones work, then learn a simple programming language like Python, practice with simulators, and finally move to a small programmable drone.
3. Is drone programming hard for beginners?
Drone programming is not hard if you start step by step. Basic concepts are easy to learn, especially with Python and visual tools like Scratch. Advanced features take time but are achievable with practice.
4. Which programming language is best for drone programming?
Python is the best choice for beginners because it is easy to read and widely used. C and C++ are also used for low-level control, while Scratch is great for students and kids.
5. Do I need to learn flying before learning drone programming?
You do not need expert flying skills. Basic understanding of drone movement is enough. Many people learn drone programming using simulators before flying a real drone.
6. Can I program DJI drones?
Yes, many DJI drones support programming through official SDKs. You can automate flights, control cameras, and build custom drone applications.
7. What are programmable drones for beginners?
Programmable drones for beginners are small, affordable drones designed for learning. They often support Python or Scratch and are used in schools and training programs.
8. How long does it take to learn drone programming?
Basic drone programming can be learned in a few weeks with regular practice. Becoming advanced or professional may take several months depending on your learning speed and goals.
9. Can I learn drone programming without buying a drone?
Yes, you can start with virtual drone programming using simulators. This allows you to practice coding and flight logic without any risk or cost.
10. Is drone programming useful for a career?
Yes, drone programming is used in industries like photography, agriculture, mapping, security, and research. Skilled drone programmers are in growing demand.
11. Are there online courses for drone programming?
Yes, there are many drone coding courses, drone programming with Python courses, and drone e-learning platforms that teach from beginner to advanced levels.
12. What is the difference between flying a drone and programming a drone?
Flying a drone means controlling it manually, while programming a drone means writing code so the drone can fly and make decisions automatically.