Master common CPU architectures in 2026 with a clear comparison of AVR, ARM Cortex-M, RISC-V, x86, and AArch64, covering design, use cases, and performance.
Common CPU Architectures : When you’re diving into embedded systems or general computing, you often hear names like AVR, ARM Cortex-M, RISC-V, x86, or AArch64. These are not just fancy words , they are the backbones of how your devices think and operate.
Let’s break down each architecture, starting from the basics, and understand what makes them unique.
What is a CPU Architecture?
Before jumping into each type, let’s clear one thing — what even is a CPU architecture?
In simple terms, a CPU architecture is like a blueprint for building processors. It defines:
The instruction set (what operations the CPU can perform)
How memory and registers are managed
The data width (8-bit, 16-bit, 32-bit, 64-bit)
How peripherals and hardware communicate with it
Think of it like the grammar rules of a language. Every architecture has its own “grammar” that software and hardware follow.
AVR Architecture – Great for Getting Started
AVR is an 8-bit microcontroller architecture developed by Atmel (now part of Microchip Technology). It’s the heart of many Arduino boards — perfect for beginners in electronics.
Key Features:
8-bit RISC (Reduced Instruction Set Computing)
Very power-efficient and cheap
Simple instruction set, easy to learn
Popular in hobby electronics
Where it’s used:
Arduino Uno
Basic robotics
Small DIY gadgets
Good for:
Learning embedded systems
Building small-scale hardware projects
ARM Cortex-M – King of Embedded Systems
ARM (Advanced RISC Machines) doesn’t make chips — it designs architectures that companies like STMicroelectronics, NXP, and TI use to build microcontrollers.
Cortex-M is ARM’s lightweight series made especially for embedded applications.
Key Features:
32-bit RISC architecture
Super low power and high performance
Widely used in IoT, automotive, medical devices
Has several series: M0, M3, M4, M7, M33, etc.
Where it’s used:
STM32 microcontrollers
Fitbit, Nest, automotive ECUs
Industrial control systems
Good for:
Real-time systems
Projects that need better performance than AVR
Learning RTOS (Real-Time Operating Systems)
RISC-V – The Open Revolution
RISC-V (pronounced “risk-five”) is a modern, open-source instruction set architecture developed at UC Berkeley.
Unlike ARM or x86, anyone can use RISC-V to design their own CPU — no licensing fee needed. This is a big deal!
Key Features:
Modular design — use only what you need
Completely open and free to use
Growing ecosystem in research and startups
Can be used for both microcontrollers and powerful processors
Where it’s used:
SiFive chips
Kendryte K210 (AI edge devices)
Educational tools
Good for:
Learning how CPUs work
Designing custom hardware
Supporting open-source hardware movement
x86 – The Veteran of Desktop Computing
x86 is the architecture developed by Intel, and it powers most of our desktops and laptops.
It started as a 16-bit architecture and has evolved into 32-bit and 64-bit versions.
Key Features:
CISC (Complex Instruction Set Computing)
Very powerful and capable of multitasking
Not as power-efficient as RISC-based designs
Massive software support
Where it’s used:
Windows/Linux PCs
Laptops, desktops
Some servers and industrial machines
Good for:
Running complex software
Desktop application development
Learning low-level system programming
AArch64 – ARM’s 64-bit Powerhouse
AArch64 is the 64-bit version of the ARM architecture, often seen in smartphones, tablets, and even servers. This architecture runs ARMv8-A and newer.
Key Features:
64-bit version of ARM (supports more memory and better performance)
Powers most Android and iOS phones
Very energy efficient
Used in Apple M-series chips (with some tweaks)
Where it’s used:
Smartphones (Snapdragon, MediaTek)
Raspberry Pi 4 (64-bit OS)
Apple M1, M2, M3 chips (heavily customized ARM)
Good for:
Mobile app development
High-performance embedded systems
Learning modern computing architecture
Quick Comparison Table:
Architecture
Bit Width
Type
Typical Use
Beginner Friendly?
AVR
8-bit
RISC
Arduino, DIY electronics
✅ Yes
ARM Cortex-M
32-bit
RISC
IoT, industrial, medical devices
✅ Yes
RISC-V
32/64-bit
RISC
Research, open-source CPUs
✅ Yes (growing)
x86
32/64-bit
CISC
Desktops, laptops
❌ Not really
AArch64
64-bit
RISC
Smartphones, tablets, servers
⚠️ Intermediate
Compiling code for different architectures ?
Great question, Nish! Compiling code for different architectures requires cross-compilation, which means compiling the code on one machine (host) for a different architecture (target). Let’s break down how to compile code for each of these architectures.
AVR Architecture
For AVR (typically used in Arduino), you’ll use AVR-GCC, which is a cross-compiler that generates code for AVR microcontrollers.
Steps:
Install AVR-GCC:
On Ubuntu, you can install it using: sudo apt-get install avr-gcc avr-libc
Write Your Code: Write your C or C++ code for the AVR microcontroller.
Compile Code: Use the avr-gcc tool to compile the code. For example, to compile a file main.c for an Arduino (AVR-based): avr-gcc -mmcu=atmega328p -o main.elf main.c
Generate Hex File: After compiling, you need to generate the hex file to upload it to the AVR device: avr-objcopy -O ihex main.elf main.hex
Upload to Arduino: You can use the avrdude tool to upload the compiled hex file to your Arduino: avrdude -c arduino -p m328p -P /dev/ttyACM0 -U flash:w:main.hex:i
ARM Cortex-M (Using GCC Toolchain)
For ARM Cortex-M (common in embedded systems), you’ll use the GNU Arm Embedded Toolchain.
Steps:
Install the Toolchain:
On Ubuntu, you can install it using: sudo apt-get install gcc-arm-none-eabi
Write Your Code: Write your code for the ARM Cortex-M microcontroller.
Set Up the Makefile: You’ll need a Makefile for your project, specifying the target architecture (-mcpu=cortex-m4 for example). A simple example of a Makefile: TARGET = main MCU = cortex-m4 CC = arm-none-eabi-gcc CFLAGS = -mcpu=$(MCU) -mthumb -nostdlib all: $(TARGET).elf $(TARGET).elf: $(TARGET).c $(CC) $(CFLAGS) -o $(TARGET).elf $(TARGET).c
Compile the Code: Run make to compile the code: make
Generate the Bin or Hex File: Use objcopy to generate a .bin or .hex file: arm-none-eabi-objcopy -O binary main.elf main.bin
Upload to Device: To upload, you’ll typically use a JTAG/SWD programmer, such as OpenOCD, to load the firmware onto the device.
RISC-V Architecture
For RISC-V, you need the RISC-V GCC Toolchain. RISC-V is gaining popularity, so it’s an exciting choice!
Steps:
Install RISC-V Toolchain: You can download and install the toolchain from SiFive or build it yourself from source: sudo apt-get install gcc-riscv64-linux-gnu
Write Your Code: Write your code as usual for a RISC-V target.
Compile the Code: To compile for a RISC-V target, use the riscv64-unknown-elf-gcc: riscv64-unknown-elf-gcc -o main.elf main.c
Generate Binary or Hex: Convert the .elf file to a binary file: riscv64-unknown-elf-objcopy -O binary main.elf main.bin
Upload to Device: Similar to ARM Cortex-M, uploading to RISC-V requires a JTAG/SWD programmer and appropriate tools (like OpenOCD or custom scripts).
x86 Architecture
For x86, which is commonly used in desktop computing, you use the GCC or Clang toolchain.
Steps:
Install GCC: Most Linux systems already have GCC installed, but if not, you can install it: sudo apt-get install build-essential
Write Your Code: Write code for the x86 architecture, usually in C or C++.
Compile the Code: To compile for an x86 target, use gcc (it’s the same on most systems): gcc -o main main.c
Generate Binary: The output will already be in an executable format (main in this case).
Run on the Device: Simply run the compiled program on an x86 machine: ./main
AArch64 (ARM 64-bit)
For AArch64, which is used in 64-bit ARM devices like smartphones and newer embedded systems, you’ll use the ARM64 GCC toolchain.
Steps:
Install AArch64 GCC: You’ll need the 64-bit ARM toolchain, which you can install like this: sudo apt-get install gcc-aarch64-linux-gnu
Write Your Code: Write the code for ARM 64-bit processors.
Compile for AArch64: Use aarch64-linux-gnu-gcc to compile: aarch64-linux-gnu-gcc -o main main.c
Generate Binary: If you need to generate a binary, you can convert it: aarch64-linux-gnu-objcopy -O binary main.elf main.bin
Upload to Device: Like RISC-V and ARM, upload to AArch64-based devices using tools like OpenOCD, JTAG/SWD, or through specific device flashing tools.
Summary of Tools:
Architecture
Compiler/Toolchain
Command to Compile
AVR
avr-gcc
avr-gcc -mmcu=atmega328p
ARM Cortex-M
arm-none-eabi-gcc
arm-none-eabi-gcc -mcpu=cortex-m4
RISC-V
riscv64-unknown-elf-gcc
riscv64-unknown-elf-gcc
x86
gcc (or clang)
gcc -o main main.c
AArch64
aarch64-linux-gnu-gcc
aarch64-linux-gnu-gcc
Cross-compiling can seem tricky at first, but it’s all about setting up the right toolchain and making sure you’re compiling for the correct architecture. Each architecture has specific tools that let you tailor the build to the needs of that system.
A toolchain is a set of tools used to build software for a specific target system or platform. In the context of cross-compilation, it typically refers to a collection of tools that allow you to compile code on one machine (host) for a different architecture or platform (target).
To explain this clearly, think of a toolchain as a factory line for building software — you feed in the source code, and the toolchain “produces” the compiled output (like a binary file) that runs on your target machine.
A typical toolchain for building software includes:
Compiler: The compiler translates the source code (C, C++, etc.) into machine code (binary) for the target platform. For example:
gcc for compiling C code for x86
arm-none-eabi-gcc for ARM microcontrollers
riscv64-unknown-elf-gcc for RISC-V platforms
Assembler: Converts assembly language code into machine code. It’s often bundled with the compiler, but it can be an independent tool.
Linker: Takes the object files (compiled code) and links them together into a single executable. It resolves references between different parts of the code and libraries.
Debugger: Helps you debug your program, finding and fixing issues in the compiled code. Examples include gdb or lldb.
Libraries: Precompiled functions or routines that your code can use, like standard libraries (libc for C programs). These libraries are also specific to the target architecture.
Other Tools:
Build Systems: These tools automate the compilation process (e.g., Make, CMake, Bazel).
Object File Utilities: Such as objcopy for manipulating binary files and objdump for inspecting them.
Why Use a Toolchain?
Cross-compilation: If you’re writing software for a device or platform that uses a different CPU architecture (like ARM, RISC-V, or embedded systems), you need to use a toolchain that understands how to compile code for that specific architecture.
Platform-Specific Code: Different architectures have different instruction sets, which means the code must be compiled differently for each one. A toolchain for each target handles this automatically.
Development Efficiency: A well-configured toolchain streamlines your development, letting you focus on writing code instead of figuring out how to compile it for your target platform.
Follow-up questions you could explore for each of the common CPU architectures:
AVR:
What are the main differences between the AVR microcontrollers and ARM Cortex-M microcontrollers?
How does the Harvard architecture in AVR affect memory access compared to the von Neumann architecture?
Can you explain the significance of the RISC architecture in AVR microcontrollers?
What are the most common AVR families and their key differences?
How does AVR handle interrupt processing and how does it compare with other architectures like ARM Cortex-M?
How do you perform in-system programming on an AVR microcontroller?
ARM Cortex-M:
What are the different ARM Cortex-M series (M0, M3, M4, M7, M33, etc.), and how do they differ in terms of performance and power consumption?
Can you explain the concept of ARM’s Thumb mode and how it benefits embedded applications?
How does ARM Cortex-M handle real-time interrupts, and how does it differ from other architectures like x86?
How does ARM Cortex-M implement the memory protection unit (MPU), and how is it useful in embedded systems?
What are ARM’s TrustZone technology and how does it enhance security in Cortex-M based systems?
What tools are most commonly used for developing ARM Cortex-M software (e.g., Keil, IAR, GCC)?
RISC-V:
What are the advantages of using RISC-V over traditional architectures like ARM or x86?
How does RISC-V’s open-source nature impact the development of embedded systems?
Can you explain the RISC-V instruction set architecture (ISA) and how it differs from ARM and x86?
What are the main features of the RISC-V privileged architecture and how is it implemented in embedded systems?
How do RISC-V processors handle memory management and protection?
What is the ecosystem around RISC-V (tools, libraries, etc.) for embedded systems development?
x86:
How does the x86 architecture’s backward compatibility impact modern embedded systems?
What are the main differences between x86-32 (x86) and x86-64 (AArch64)?
How does x86 handle context switching and multitasking in real-time systems?
What role does SIMD (Single Instruction, Multiple Data) play in optimizing performance on x86 processors?
How do you handle low-level device drivers on an x86-based embedded system?
How do x86 processors handle power management, and how does this compare with ARM-based systems?
AArch64:
How does AArch64 architecture provide better performance over the older ARMv7-A architecture?
What is the significance of the AArch64 architecture’s 64-bit registers compared to 32-bit ARM Cortex-M?
How does AArch64 implement virtual memory and page table management?
What are the security features in AArch64, such as ARM TrustZone or ARMv8 Security Extensions?
What are the main use cases for AArch64 in embedded systems and how does it compare to traditional x86 in terms of performance?
How is the AArch64 toolchain different from ARM’s 32-bit toolchain (e.g., differences in GCC for ARM and AArch64)?
Follow-up questions on architecture and toolchain aspects
AVR Architecture + Toolchain:
What is the role of the avr-gcc compiler when cross-compiling for AVR microcontrollers, and how does it differ from standard GCC used for x86 platforms?
How do you set the correct MCU model (e.g., atmega328p) in your toolchain when compiling for AVR microcontrollers?
What are some common challenges you might face when cross-compiling for AVR, and how can the avrdude tool help during deployment?
Why is it necessary to convert the ELF file to a hex file when working with AVR microcontrollers, and what tool is used for this conversion?
ARM Cortex-M Architecture + Toolchain:
What are the key flags you need to use with arm-none-eabi-gcc to compile for an ARM Cortex-M microcontroller, and why are they important?
How does the toolchain for ARM Cortex-M (e.g., arm-none-eabi-gcc) differ from those used for general-purpose CPUs like x86?
In ARM Cortex-M development, how do you use OpenOCD or similar tools for debugging and uploading code to the microcontroller?
Can you explain the role of FPU (Floating Point Unit) and how it might affect your toolchain setup when compiling for ARM Cortex-M?
RISC-V Architecture + Toolchain:
What are the advantages of using RISC-V as an architecture, and what specific toolchain do you need to compile code for RISC-V (e.g., riscv64-unknown-elf-gcc)?
How would you configure a Makefile for cross-compiling C code to a RISC-V target? What specific flags or options would you include?
How does RISC-V’s open-source nature affect its toolchain, and what are some considerations when using a RISC-V toolchain for custom processors?
In what scenarios would you use the RISC-V toolchain over other architectures, and what benefits does it offer for embedded development?
x86 Architecture + Toolchain:
How does cross-compiling for x86 architecture differ from ARM or RISC-V, considering both the toolchain setup and the target platform?
What options do you need to provide to the GCC toolchain to specify that you are compiling for x86 architecture, and how do you configure it for 64-bit versus 32-bit targets?
How does compiling and debugging differ between desktop x86 platforms and embedded systems with microcontrollers (e.g., ARM, AVR)?
What are some common performance optimization techniques you can apply when compiling code for x86 systems, and how does your toolchain support them?
AArch64 Architecture + Toolchain:
How do you configure the AArch64 toolchain (aarch64-linux-gnu-gcc) for compiling code for 64-bit ARM-based systems like smartphones or servers?
What are the key differences between the toolchain used for AArch64 (ARM 64-bit) and ARM Cortex-M, considering factors like performance and compatibility?
How do you ensure that the code you compile for AArch64 is optimized for mobile devices or servers, and what tools are used for this process?
How would you debug and deploy code to an AArch64-based device using tools like OpenOCD or JTAG, and how does the toolchain assist in this process?
General Architecture + Toolchain Questions:
How do you select the correct toolchain when working with different architectures (e.g., ARM vs. x86 vs. RISC-V), and what factors influence this decision?
What are the common issues you might face when trying to port software between different architectures, and how does the toolchain help in resolving them?
How do you configure cross-compilation toolchains to ensure that the generated code is optimized for the target architecture’s instruction set?
Can you describe the process of compiling and linking code for an embedded system, taking into account the architecture, toolchain, and hardware requirements?
You can also Visit other tutorials of Embedded Prep
What is a Microcontroller : Have you ever wondered how devices like washing machines, microwave ovens, or even your TV remote work? What’s the tiny brain behind these smart machines? The answer is: a Microcontroller, often called MCU.
Let’s break it down step by step so it’s super easy to understand!
So, What is a Microcontroller?
A microcontroller is a small computer on a single chip. It’s designed to do specific tasks like turning on a motor, blinking an LED, or reading the temperature from a sensor.
Unlike your laptop or smartphone, which can run lots of complex software, a microcontroller usually runs one program again and again — and it’s really good at it!
Think of it Like a Tiny Brain
Imagine you have a robot friend. This robot needs to know when to move, when to stop, or when to wave. The microcontroller is like the robot’s brain — it reads the inputs (like sensors), makes decisions, and gives outputs (like turning on lights or moving motors).
What’s Inside a Microcontroller?
A microcontroller is made of a few basic parts:
CPU (Central Processing Unit) – The brain that does the thinking.
Memory (RAM and ROM) – RAM for working space, ROM for storing the program.
I/O Ports (Input/Output) – To connect buttons, sensors, LEDs, etc.
Timers and Counters – To keep track of time or events.
Communication Interfaces – Like UART, I2C, SPI to talk to other devices.
All of these are packed into a tiny chip!
Where Do We Use Microcontrollers?
Microcontrollers are everywhere! Some common places include:
Home Appliances (Washing machines, Microwaves)
Remote Controls
Automobiles (For engine control, airbag system)
Toys and Games
Industrial Machines
Wearable Devices (Like fitness trackers)
Basically, any small device that performs a specific task likely uses an MCU.
Popular Microcontrollers for Beginners
If you’re just starting out, here are a few MCUs that are beginner-friendly:
Arduino UNO (ATmega328p) – Great for beginners and hobbyists.
ESP32 – Has built-in Wi-Fi and Bluetooth.
STM32 – Widely used in industries and learning advanced embedded systems.
Raspberry Pi Pico – Tiny and powerful MCU from the Raspberry Pi family.
What Can You Do with a Microcontroller?
With just a microcontroller and a few components, you can build cool projects like:
An automatic plant watering system 🌱
A smart home light controller 💡
A temperature and humidity display 🌡️
A Bluetooth-controlled robot 🤖
Quick Summary
Feature
Microcontroller
Purpose
Performs specific tasks
Size
Small chip
Power
Low power
Program
One simple program
Examples
Arduino, ESP32, STM32
How do microcontrollers work?
Think of a microcontroller as a tiny computer running a small city 🏙️ on a single chip.
Microcontroller Architecture – The City Analogy
Imagine a microcontroller is a smart city where different departments work together to keep things running:
1. CPU – The Mayor’s Office
The Central Processing Unit (CPU) is like the mayor of the city.
It makes decisions, runs the rules, and tells other departments what to do.
It reads instructions (program code) and acts accordingly.
2. Memory – The Filing Cabinets
There are two main types:
a. Flash Memory (Code Storage) – City Blueprints
Stores the permanent instructions (firmware/program).
Think of it as the library where city plans are stored.
b. SRAM (Data Memory) – Temporary Task Sheets
Stores temporary data the CPU works with.
Like desk space or sticky notes on office desks.
c. EEPROM (optional) – Sticky Notes That Stay After Power Loss
Stores data that must be remembered even after power is off (e.g., settings).
3. Timers – The City Clock Tower
Keeps track of time.
Helps in tasks like delays, alarms, or scheduling traffic lights.
4. I/O Ports – The City Gates
These are Input/Output pins through which the city talks to the outside world.
For example:
Input: Reading from a button or sensor
Output: Lighting up an LED, turning on a motor
5. Communication Buses – The City Roads
Roads that help different departments or even other cities talk.
Types of roads (protocols):
I2C – Like a bus stop system (multi-device communication)
SPI – Like a direct highway (faster, short distance)
UART – Like a post office (sends letters, i.e., data)
6. Power Supply – The Power Plant
Powers the whole city.
Microcontrollers usually work on 3.3V or 5V.
7. Peripherals – Specialized Departments
Additional built-in helpers that handle specific tasks:
ADC (Analog to Digital Converter) – Converts analog signals (like sound) to digital
PWM (Pulse Width Modulation) – Controls devices like fans or dim LEDs
DAC (Digital to Analog Converter) – Outputs analog signals (optional)
How It All Works Together (Simple Flow)
You write a program (city rules) in C or C++.
It gets compiled and stored in Flash Memory.
When powered on, CPU fetches instructions from Flash.
CPU uses RAM to temporarily store and compute data.
It reads sensors (input), makes decisions, and controls outputs (e.g., turns on a fan).
Timers, peripherals, and buses help it work smartly.
Bonus Tip: Real Examples
Turning on an LED: Input button pressed → CPU checks input → turns ON output pin.
Reading temperature: ADC reads analog signal → CPU processes it → displays on screen.
Common features of microcontrollers?
Feature
Description
CPU (Core)
Performs arithmetic and logic operations; examples: ARM Cortex-M, AVR, 8051
Clock Speed
Determines processing speed; typically in MHz (e.g., 16 MHz, 72 MHz)
Flash Memory
Non-volatile memory to store firmware/program code
SRAM (Static RAM)
Used for temporary data storage during execution
EEPROM
Non-volatile memory used for storing small, permanent data (e.g., config)
GPIO Pins
General-purpose I/O pins for digital input/output
Timers/Counters
Used for timing operations, delays, PWM generation
ADC (Analog to Digital Converter)
Converts analog input signals to digital values
DAC (Digital to Analog Converter)
Converts digital values to analog signals (if available)
Communication Interfaces
UART, SPI, I2C, CAN, USB, etc. for device communication
Interrupts
Allows hardware-based task switching or response to events
PWM (Pulse Width Modulation)
Used for motor control, LED dimming, etc.
Watchdog Timer
Resets the system if it hangs or crashes
Power Modes
Sleep, standby, and other low-power modes for energy efficiency
Operating Voltage
Typical range is 1.8V to 5.5V depending on the microcontroller
Packaging Type
DIP, QFP, BGA, etc., determines physical form factor
Debugging Interface
JTAG, SWD, ISP, or others for programming and debugging
Peripheral Support
Built-in support for peripherals like LCD, keypad, RTC, etc.
Types of Microcontrollers
Microcontrollers are compact integrated circuits designed to perform specific tasks within embedded systems. They typically combine a processor, memory, and input/output peripherals on a single chip. Microcontrollers are categorized based on various factors such as architecture, memory type, and application area. Here’s a detailed look at the different types:
1. Based on Bit Architecture
a. 8-bit Microcontrollers
These process 8 bits of data at a time.
Suitable for simple applications like timers, keyboards, and home appliances.
Example: Atmel ATmega328p, Intel 8051
b. 16-bit Microcontrollers
Capable of handling more complex operations than 8-bit.
Used in automotive systems and industrial controls.
Example: MSP430 from Texas Instruments
c. 32-bit Microcontrollers
Handle 32 bits of data, offering higher processing speed and advanced features.
Commonly used in IoT devices, multimedia applications, and advanced automation systems.
Example: ARM Cortex-M series, STM32
2. Based on Memory Architecture
a. Harvard Architecture
Has separate memory spaces for program and data.
Allows simultaneous access to both, improving speed.
Used in PIC microcontrollers.
b. Von Neumann Architecture
Shares the same memory space for data and instructions.
Easier to design, but slightly slower in performance.
3. Based on Application
a. General Purpose Microcontrollers
Versatile, used in a wide range of embedded applications.
Example: Arduino (based on AVR/ARM)
b. Application-Specific Microcontrollers
Designed for specific tasks such as motor control, automotive systems, or wireless communication.
AVR (by Atmel/Microchip) – Known for simplicity and widely used in education and hobby projects.
PIC (by Microchip) – Popular in industrial and automotive applications.
ARM (by ARM Holdings, licensed to others) – Offers high performance and low power, used in smartphones and IoT.
Intel 8051 – A classic microcontroller architecture still used in legacy systems.
Microcontroller Applications: Transforming the Future of Embedded Technology
Microcontrollers are at the heart of today’s digital transformation—compact, cost-effective, and powerful computing engines that bring intelligence to everyday devices. From consumer electronics to industrial automation, microcontroller applications have revolutionized the way machines think and respond.
1. Automotive Systems
Microcontrollers power various functions in modern vehicles including:
Engine Control Units (ECUs)
Anti-lock Braking Systems (ABS)
Airbag Deployment Systems
Infotainment Systems
They ensure safety, fuel efficiency, and a smarter driving experience by processing real-time sensor data.
2. Home Automation
Smart homes rely heavily on microcontrollers to manage:
Lighting Systems
Smart Thermostats
Security Cameras
Voice-Controlled Devices
These embedded brains allow users to control appliances remotely and automate routines for energy efficiency.
3. Healthcare Devices
In medical electronics, microcontrollers provide precision and reliability in:
Portable ECG Machines
Glucometers
Smart Inhalers
Wearable Health Trackers
They enable real-time monitoring, data logging, and wireless communication with health apps.
4. Agriculture and Farming
Smart farming uses microcontrollers for:
Soil Moisture Sensing
Automated Irrigation
Crop Monitoring Drones
Livestock Tracking Systems
These systems improve yield, reduce waste, and support sustainable agriculture.
5. Industrial Automation
From factory floors to smart grids, microcontrollers are vital in:
Robotic Arms
Process Controllers
Energy Management Systems
Predictive Maintenance Devices
They allow seamless integration of sensors, actuators, and control logic for increased productivity.
6. Consumer Electronics
Everyday devices like:
TV Remotes
Gaming Consoles
Digital Cameras
Microwave Ovens use microcontrollers for enhanced user interaction and device control.
7. Aerospace and Defense
Microcontrollers help in:
Flight Data Recorders
Missile Guidance Systems
Environmental Control Systems in Aircrafts They ensure mission-critical performance in high-stakes environments.
How to Select a microcontroller for your project ?
Choosing the right microcontroller (MCU) is one of the most important steps in any embedded systems or electronics project. Whether you’re building a smart home device, an IoT system, or a simple LED controller, the microcontroller acts as the brain of your project.
But with so many options available—ATmega328P, STM32, ESP32, PIC, and more—it can be confusing to know where to start.
Don’t worry! In this guide, we’ll break it down step-by-step so you can confidently choose the best microcontroller for your needs.
Step-by-Step Guide to Choosing the Right Microcontroller
1. Understand Your Project Requirements
Ask yourself the following:
What does the project need to do?
What kind of input/output (I/O) will it handle?
How much processing power is needed?
Will it need to connect to Wi-Fi, Bluetooth, or other communication protocols?
Example: If you’re controlling LEDs and reading a temperature sensor, a simple 8-bit MCU like the ATmega328P may be enough.
2. Count the I/O Pins
Check how many digital and analog input/output pins you’ll need. Each component (sensor, display, button, etc.) will require a pin.
Tip: Always leave 2-3 pins extra for future expansion or debugging.
3. Memory Requirements
Different MCUs have different sizes of:
Flash (for program code)
SRAM (for temporary data)
Rule of Thumb:
Simple applications: 16KB Flash, 2KB RAM may be enough.
Complex tasks like image processing or web servers need more (e.g., ESP32 with 520KB SRAM).
4. Clock Speed
Measured in MHz, the clock speed affects how fast your MCU executes instructions.
For blinking LEDs or reading sensors: 8–16 MHz is fine.
For real-time processing, voice/audio, or networking: 50+ MHz or more might be needed.
5. Power Consumption
If your project runs on batteries (like a wearable or sensor node), look for:
Low-power modes
Sleep mode support
Efficient architecture
MCUs like the STM32L series or ATmega328P are great for low-power applications.
6. Communication Interfaces
Decide what peripherals you’ll talk to. Common interfaces include:
UART/USART – Serial communication (for GPS, Bluetooth modules)
I2C – For sensors like temperature, pressure, RTC
SPI – For fast communication with displays, memory
CAN, USB, Ethernet, Wi-Fi – For advanced or connected applications
Need Wi-Fi? Consider ESP8266 or ESP32.
Need CAN bus? Many STM32 MCUs support it.
7. Development Tools & Community Support
Especially as a beginner, this is super important. Ask:
Is the development board easily available?
Is there beginner-friendly documentation?
Can you find tutorials, libraries, and forums for help?
Arduino (ATmega328P) and ESP32 have huge communities.
STM32 has a steep learning curve but is very powerful.
8. Programming Language & IDE
Most MCUs are programmed in C/C++, but some support Python or other languages.
Popular IDEs include:
Arduino IDE – Great for beginners.
PlatformIO – Professional yet friendly.
STM32CubeIDE – For STM32 chips.
MPLAB X – For PIC microcontrollers.
9. Cost & Availability
Always check:
Is the MCU or development board in stock?
Is it within your budget?
Budget MCUs: ATmega328P (Arduino), ESP8266
Powerful but affordable: STM32F103, ESP32
10. Scalability and Future Needs
Think long term. If you’re planning to scale your project (like making 100+ units), consider:
MCU availability in bulk
Support for external programming/debugging
Upgradability or feature expansion
Comparison Table (Popular Choices)
MCU
Features
Ideal For
Notes
ATmega328P
8-bit, simple, low-power
Beginners, Arduino Projects
Tons of tutorials
STM32F103
32-bit, powerful, low-cost
Intermediate users
Needs more setup
ESP8266
Wi-Fi, low-cost, moderate power
IoT projects, beginners
Simple to use via Arduino IDE
ESP32
Dual-core, Wi-Fi & Bluetooth
IoT, complex projects
Very powerful
PIC16F877A
8-bit, robust, good for industry
Industrial applications
Needs MPLAB & PICKit
Final Tips Before Buying
Start with a development board – like Arduino Uno, NodeMCU, or STM32 Nucleo. Breadboard your design before creating a PCB. Buy from trusted sellers to avoid fake chips. Make sure to download datasheets and reference manuals!
Note :So go ahead — grab a beginner board like Arduino and start exploring! Who knows? You might just build the next big thing in tech
You can also Visit other tutorials of Embedded Prep
What is a Clock : When working with embedded systems, one of the most important but often overlooked topics is the clock system. Just like our body has a heartbeat that keeps everything in sync, a microcontroller also relies on a clock to function properly.
In this post, we’ll break down the clock system in simple terms perfect for beginners looking to build a solid foundation in embedded development.
What is a Clock ?
In simple terms, a clock is a type of signal used to keep digital systems in sync. It’s like a heartbeat for electronic circuits, telling different parts when to start and stop tasks.
Technically, a clock is a square wave signal that switches between two logic levels:
High (H) – represents logic 1
Low (L) – represents logic 0
These transitions happen at regular intervals, creating a steady rhythm. This rhythm is crucial for coordinating operations in digital systems like microcontrollers, processors, and other integrated circuits.
To generate this clock signal, we use a component called an oscillator. Think of the oscillator as the “clockmaker” —> it’s the device responsible for producing the precise timing signals that drive the entire circuit.
What Does the MCU Do with the Clock Signal?
On your microcontroller board (MCU), there’s a small device called an oscillator. This oscillator sends out a steady stream of pulses—like ticking sounds of a clock. For example, it might be sending 20 million ticks per second (20 MHz).
Now the question is: What does the MCU actually do with those ticks?
1. The Clock Keeps the CPU Running
Inside the MCU, there’s a tiny computer brain called the CPU (Central Processing Unit). This CPU runs the program you’ve written—whether it’s blinking an LED or controlling a robot.
But the CPU doesn’t work randomly. It moves in steps, and each step is timed using the clock. For every tick (or pulse) from the oscillator, the CPU performs a small part of its job.
To run any program, the CPU repeats a 3-step cycle:
Fetch – Get the instruction from memory (like reading a recipe).
Decode – Understand what the instruction means (what kind of task it is).
Execute – Perform the task (do the actual work like math or moving data).
Every single line of code you write goes through these 3 steps, over and over again. And all of it happens in sync with the clock.
So, faster clock = faster program execution. That’s why high-performance MCUs can run at clock speeds like 200–300 MHz.
2. The Clock Also Powers the Peripherals
An MCU isn’t just a CPU—it also includes peripherals like timers, ADCs, UARTs, and more.
These peripherals also need the clock to function properly. For example:
A Timer uses the clock to count time and generate delays or periodic events (like a 1ms interrupt).
A Serial Port uses the clock to know when to send or receive data bits.
So the clock isn’t just the CPU’s heartbeat—it’s the lifeline of the whole system.
Boosting Clock Speed Using PLL
Here’s an interesting twist: Even though the oscillator provides only 20 MHz, many MCUs can run much faster.
How?
They use a special module called a PLL (Phase-Locked Loop). PLL takes the base clock (20 MHz) and multiplies it to reach higher speeds like 200 MHz.
So, the clock that finally runs the CPU is not always the same as what the oscillator gives. It’s first amplified using PLL, and then distributed to the CPU and peripherals.
In a Nutshell:
The clock tells the CPU when to run each part of your program.
It also powers the peripherals so they work properly.
Faster clocks = faster MCU performance.
The PLL boosts the clock to reach higher speeds.
You can think of the clock as the energy that drives everything inside the MCU.
Here’s a more human-friendly version:
Types of Clocks in a System:
System Clock: This is the heartbeat of your system, setting the pace for how fast the processor and all other parts of your device run.
Peripheral Clocks: These clocks are specialized for specific tasks. For example, they control things like timers, sensors, and communication ports (like UART or SPI) to keep everything running smoothly.
Real-Time Clock (RTC): This clock is used to keep track of the actual time, like a regular calendar. It’s low power, so it can keep running even when the rest of the system is powered down, which is handy for things like logging events or setting alarms.
Why is the Clock Important?
Every task inside a microcontroller — from blinking an LED to sending data over UART — depends on precise timing. Without a clock, nothing would run in sync.
Here’s why the clock is essential:
It defines the speed of the CPU.
It controls the timing of peripherals like timers, communication ports, and ADCs.
It affects power consumption and system performance.
Basic Components of a Clock System
Let’s look at the basic parts that make up a clock system:
1. Clock Source
This is where the clock signal originates. Common sources include:
Internal RC Oscillator – Built into the microcontroller, good for low-cost, less precise tasks.
External Crystal Oscillator – Very accurate, used when timing needs to be precise (e.g., real-time clocks or communication).
2. System Clock (SYSCLK)
This is the main clock used by the CPU and most of the system. It often comes from the selected clock source after processing (like through a PLL).
3. PLL (Phase-Locked Loop)
The PLL is used to multiply the base clock to get higher frequencies. For example, a 8 MHz crystal can be boosted to 72 MHz using a PLL.
4. Prescalers
Prescalers divide the clock frequency to provide slower clocks for specific modules like timers or ADCs.
5. Clock Tree
The clock tree distributes the clock to different parts of the microcontroller. Each branch can have different settings depending on the peripheral’s needs.
How to Choose the Right Clock?
Choosing the right clock source depends on:
Accuracy needed (crystal vs. internal).
Power consumption goals (lower frequency = less power).
Application requirements (e.g., high-speed data processing may need a faster clock).
For example:
A battery-powered sensor might use a low-frequency internal oscillator to save power.
A USB device needs a precise 48 MHz clock, typically achieved using a PLL with an external crystal.
Common Mistakes Beginners Make
Ignoring clock settings in code or configuration tools.
Choosing an unstable or inaccurate clock for communication protocols.
Not understanding how prescalers affect timing and delays.
Pro Tip for Beginners
When starting with a microcontroller, use the default clock settings first. Once you’re comfortable, experiment with different sources and frequencies to see how they impact the system.
Tools like STM32CubeMX, Atmel START, or ESP-IDF menuconfig can help configure clock systems without writing low-level code.
Follow-up interview questions based on your understanding of what is clocks ?
Clock & MCU Related Interview Questions
Basic Level
What is the purpose of a clock signal in a microcontroller?
What is the fetch-decode-execute cycle? Can you explain each step in simple terms?
Why does the CPU need to be synchronized with a clock signal?
What happens if the clock signal stops or becomes unstable?
How does increasing the clock frequency affect the performance of the MCU?
Intermediate Level
What is the role of an oscillator in a microcontroller system?
What is the difference between an internal and external clock source? When would you use each?
How does a PLL (Phase-Locked Loop) work and why is it used in MCUs?
What are the limitations of just increasing the clock speed in a microcontroller?
Explain how a peripheral like a Timer uses the clock to generate periodic interrupts.
Advanced Level
How would you configure the clock tree in an STM32 or similar MCU using CubeMX or directly in code?
Describe the impact of clock jitter on system performance, especially in ADCs or communication modules.
How do power consumption and clock speed relate in embedded systems?
Can you explain clock gating and how it helps in power optimization?
What’s the difference between synchronous and asynchronous clocks? When would asynchronous clocks be used inside an MCU?
Basic Level Answer :
What is the purpose of a clock signal in a microcontroller?
The purpose of a clock signal in a microcontroller is to provide a regular timing reference that synchronizes the operations of all internal components. In simple terms, the clock acts like a metronome, setting the pace for when the microcontroller fetches instructions, processes data, and communicates with peripherals.
More specifically:
It controls the speed at which the microcontroller executes instructions (called the clock frequency, usually measured in MHz).
It coordinates timing between the CPU, memory, and peripherals so they can work together properly.
It ensures deterministic behavior — meaning actions happen in predictable, timed cycles, which is very important in real-time systems.
Without a clock signal, the microcontroller wouldn’t know when to move from one operation to the next, and the system would not function correctly.
2.What is the fetch-decode-execute cycle? Can you explain each step in simple terms?
Ans : The fetch-decode-execute cycle is the basic process that a microcontroller (or any CPU) uses to run programs. You can think of it like a simple loop that happens over and over for each instruction.
Here’s a simple explanation of each step:
1. Fetch
The microcontroller reads (fetches) the next instruction from memory (usually from flash or RAM).
It uses a special pointer called the Program Counter (PC), which tells it where in memory the next instruction is.
Think of it like the microcontroller picking up the next task from a to-do list.
2. Decode
Once it has fetched the instruction, it figures out (decodes) what the instruction is asking it to do.
For example, is it an addition, a comparison, a memory load, or something else?
This is like the microcontroller reading the task and understanding what it needs to do.
3. Execute
The microcontroller carries out (executes) the instruction.
If the instruction says “add two numbers,” it adds them.
If it says “move data,” it moves it.
If it says “jump to a different part of the program,” it changes the Program Counter.
This is like the microcontroller actually doing the task, like calculating a result or turning on an LED.
Summary: Fetch → Get the instruction. Decode → Understand the instruction. Execute → Do the instruction.
Then it repeats for the next instruction… and that’s how your program runs!
3.Why does the CPU need to be synchronized with a clock signal?
The CPU needs to be synchronized with a clock signal because it ensures that all operations happen in a controlled, predictable, and orderly manner.
Here’s the simple idea:
A CPU is made of millions (or billions) of small circuits.
These circuits can’t all act randomly — they need to know exactly when to start and stop an operation.
The clock signal acts like a drumbeat, giving a steady rhythm.
On each clock pulse (rising or falling edge), the CPU knows it’s time to move to the next step: fetch an instruction, decode it, execute it, etc.
If there were no clock, or if parts of the CPU moved at different timings, it would cause:
Incorrect operations (data might not be ready yet).
Race conditions (two parts fighting over the same data).
System crashes (because sequences would happen out of order).
In short:
The clock keeps everything in sync, making sure the CPU works like a perfectly timed machine.
Real-world example: Imagine a group of dancers performing. If they don’t hear the same music beat, some will move early, some will move late — the whole performance will be a mess. The clock is like the music beat that keeps all dancers (circuits) in perfect harmony.
Would you also like me to explain how different clock speeds (like 8 MHz vs 100 MHz) affect CPU performance? ⏲️🚀
4.What happens if the clock signal stops or becomes unstable?
If the clock signal stops or becomes unstable, here’s what happens:
1. If the clock stops completely:
The CPU immediately freezes.
It can’t fetch, decode, or execute any more instructions.
The whole system halts — it’s like pressing pause on a video.
If it’s an embedded system (like a washing machine controller or a car ECU), the device will stop working instantly.
Simple way to think about it: If the drummer in a band stops beating the drum, the whole band will be confused and stop playing.
2. If the clock becomes unstable (irregular, noisy, glitchy):
Instructions might be fetched incorrectly or halfway.
Timing problems can cause:
Corrupted data.
Wrong instructions being executed.
Random system crashes (sometimes very hard to debug).
In embedded systems, this can lead to dangerous failures (like an airbag deploying at the wrong time or a motor running out of control).
Simple way to think about it: If the drummer starts beating randomly — sometimes too fast, sometimes too slow — the band members will get out of sync, play wrong notes, and the performance will collapse.
Summary:
Clock Condition
Result on CPU/System
Clock stops
System freezes
Clock unstable
System behaves unpredictably (crashes, errors, corruption)
In real devices:
Designers often use watchdog timers or clock monitors to reset the system automatically if the clock fails or becomes unstable.
5.How does increasing the clock frequency affect the performance of the MCU?
When you increase the clock frequency of a microcontroller (MCU):
➔ What happens?
The MCU can execute more instructions per second.
It fetches, decodes, and executes operations faster.
Overall performance improves — tasks are completed more quickly.
✅ Example: If an MCU runs at 8 MHz, it can (theoretically) process 8 million cycles per second. If you increase it to 16 MHz, it can process 16 million cycles per second — almost double the speed.
➔ But there are trade-offs:
Benefit
Drawback
Faster task execution
More power consumption
Quicker response time
More heat generation
Can handle more complex programs
May cause stability issues if clocking beyond design limits
➔ Simple analogy:
Clock frequency is like the heartbeat of the microcontroller. A faster heartbeat lets it work quicker, but tires it out faster (uses more energy and can overheat).
➔ Important notes:
In battery-powered devices (like sensors or wearables), lower frequencies are often used to save power.
Some MCUs allow dynamic frequency scaling — they increase speed when needed and lower it when idle to balance performance and power.
Summary: 🔵 Higher clock frequency = Faster MCU, but more power and heat. 🔵 Lower clock frequency = Slower MCU, but more energy-efficient.
You can also Visit other tutorials of Embedded Prep
Microcontroller vs Microprocessor vs SoC : Whether you’re a beginner stepping into embedded systems or an experienced engineer brushing up on core concepts, understanding the difference between a Microcontroller (MCU), Microprocessor (MPU), and System on Chip (SoC) is crucial. These are the brains behind every smart gadget—from your smartwatch to a satellite!
In this post, we’ll break it down simply with clear definitions, use cases, and a side-by-side comparison.
Microcontroller vs Microprocessor vs SoC
What is a Microcontroller (MCU)?
A Microcontroller is a compact integrated circuit designed to perform a specific control task in embedded systems.
Key Features:
Includes CPU + RAM + ROM + I/O peripherals on a single chip
Meant for real-time control
Low power, cost-effective
Runs simple firmware or embedded applications
Use Cases:
Washing machines, microwave ovens
Wearables like fitness trackers
Automotive dashboard systems
Arduino-based hobby projects
Note: Microcontrollers are ideal for small, low-power, task-specific systems.
What is a Microprocessor (MPU)?
A Microprocessor is a general-purpose CPU integrated into a single chip, but without built-in memory or peripherals.
Key Features:
Just the CPU
Needs external RAM, ROM, I/O
Designed for high performance and complex computing
Used in general-purpose computing
Use Cases:
Personal computers
Servers
Laptops
Desktop applications
Note : Microprocessors power general computing systems requiring external memory and peripherals.
What is a System on Chip (SoC)?
A System on Chip combines all components of a computer—CPU, GPU, RAM, storage, wireless modules, and I/O—on a single chip.
Key Features:
Combines MCU/MPU + peripherals + connectivity
Compact and power-efficient
Highly integrated
Custom-built for specific devices
Use Cases:
Smartphones and tablets
IoT devices
Smart TVs
Raspberry Pi
✅ Note : SoCs are the powerhouse of modern smart devices combining performance and efficiency.
Quick Comparison Table onMicrocontroller vs Microprocessor vs SoC
Feature
Microcontroller (MCU)
Microprocessor (MPU)
System on Chip (SoC)
Integration
CPU + RAM + ROM + I/O
CPU only
CPU + GPU + Memory + I/O
Application Type
Specific tasks (real-time)
General computing
Versatile, integrated systems
Cost & Power
Low
Higher
Medium to low
Performance
Moderate
High
High
Memory
Built-in
External
Built-in
Typical Use
Embedded devices
Computers, servers
Smartphones, IoT, tablets
Conclusion for Microcontroller vs Microprocessor vs SoC
Understanding the difference between a Microcontroller, Microprocessor, and SoC helps you pick the right solution for your embedded project or product. Here’s a quick rule of thumb:
🧩 Use MCU when you need low cost, low power, and a focused task
💻 Use MPU when you need high computation with external resources
📱 Use SoC when you want an all-in-one compact powerhouse
Follow-up interview questions Interviewer might askonMicrocontroller vs Microprocessor vs SoC
🔧 Microcontroller-Specific Questions:
Can you name a few popular microcontrollers you’ve worked with?
What are the advantages of using an MCU in real-time embedded systems?
How do you program a microcontroller, and which tools have you used?
What’s the difference between Harvard and Von Neumann architecture in the context of MCUs?
🖥️ Microprocessor-Focused Questions:
Why would you choose a microprocessor over a microcontroller in a design?
How do you handle memory management in systems using microprocessors?
What kind of operating systems typically run on microprocessor-based systems?
📱 SoC-Related Questions:
Can you give an example of a SoC you’ve worked with and what peripherals it included?
What challenges have you faced while developing software for SoCs?
How do SoCs support power optimization in battery-powered devices?
🤖 System Design and Application:
Suppose you have to design a smart home device. Will you choose an MCU, MPU, or SoC? Why?
Have you worked on bare-metal programming or RTOS on any MCU? Explain.
What are the criteria you consider while selecting between MCU, MPU, or SoC for an embedded product?
🧠 Conceptual or Deep-Dive Questions:
How does interrupt handling differ in MCUs vs MPUs?
Explain the boot process for an SoC-based system.
What’s the role of MMU in a microprocessor, and is it present in microcontrollers?
Can you compare an SoC running Android vs an MPU running embedded Linux?
You can also Visit other tutorials of Embedded Prep
Embedded Software Roadmap is a clear, step-by-step guide for beginners and professionals who want to build a strong career in embedded systems.
Are you eager to dive into the world ofembedded systems but don’t know where to start? This beginner-friendly roadmap will guide you step-by-step, from basic concepts to real-time projects, helping you build a strong foundation and become a successful embedded software engineer in 2025.
Embedded Software Roadmap
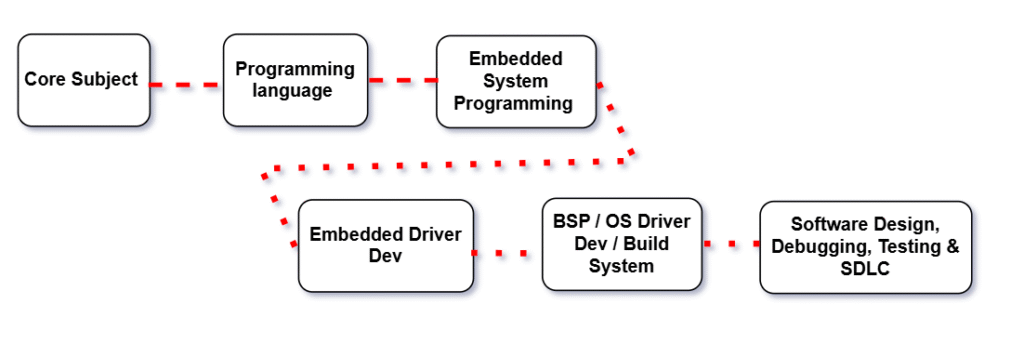
Step 1: Master the Core Subjects of Embedded Systems
1.1 Digital Electronics
Digital Electronics is the foundation of modern computing and embedded systems. It harnesses the power of binary logic—0s and 1s—to design systems that are precise, reliable, and scalable. As the first step in the Embedded Software Roadmap, mastering digital electronics is essential. From microprocessors to embedded controllers, digital electronics enables the creation of intelligent hardware through logic gates, Boolean algebra, and state-driven systems. This knowledge sets the stage for developing efficient and robust embedded software.
At its core, digital electronics replaces analog ambiguity with digital precision, making it the heart of systems like communication devices, automation units, robotics, and consumer electronics. By combining combinational and sequential circuits, engineers can design everything from simple adders to complex programmable logic devices like FPGAs.
With digital design, we build the brains of technology—machines that think, decide, and act based on logic and encoded instructions. It’s not just about electronics—it’s about empowering innovation through logical architecture.
Understand how electronic signals represent data:
Number systems: Binary, Hexadecimal, BCD
Logic Gates: AND, OR, NOT, NAND, NOR, XOR
Flip-Flops and Registers
Combinational vs Sequential Circuits
Multiplexers, Encoders, Decoders
Popular Microcontrollers to Explore:
AVR: ATmega328P (used in Arduino)
ARM: STM32, ESP32, nRF52
1.2 Operating Systems (OS)
Digital Electronics is the foundation of modern computing and embedded systems. It harnesses the power of binary logic—0s and 1s—to design systems that are precise, reliable, and scalable. As the first step in the Embedded Software Roadmap, mastering digital electronics is essential. From microprocessors to embedded controllers, digital electronics enables the creation of intelligent hardware through logic gates, Boolean algebra, and state-driven systems. This knowledge sets the stage for developing efficient and robust embedded software.
As we move forward in theEmbedded Software Roadmap, we encounter the critical role of Operating Systems.
An Operating System (OS) is the unseen force that transforms hardware into a functional and responsive digital environment. Acting as the central coordinator, it manages everything—from running applications and allocating memory to handling user input and controlling hardware components.
It provides an abstraction layer, allowing developers and users to interact with complex machines through simple, intuitive interfaces. Whether it’s scheduling tasks, managing filesystems, or ensuring secure multitasking, the OS silently enforces structure and efficiency beneath every click and tap.
From real-time embedded platforms like FreeRTOS, QNX, and VxWorks to general-purpose systems like Linux, Windows, and macOS, Operating Systems are not just software—they are digital ecosystems that balance performance, reliability, and usability.
Why it’s important: Many embedded systems run on RTOS (like FreeRTOS, VxWorks) or Embedded Linux. Understanding OS concepts helps you manage processes, memory, and scheduling efficiently.
Topics to Cover:
Process vs Thread
Memory Management (Heap, Stack, Paging)
CPU Scheduling Algorithms
Interprocess Communication (IPC): semaphores, mutex, pipes
Real-Time Operating Systems (RTOS): concepts of tasks, preemption, priority inversion
Embedded Linux basics: init system, daemons, file system layout
1.3 Computer Architecture
Computer Architecture defines the conceptual design and operational framework of a computer system. It is the strategic art of organizing hardware components and establishing how they interact to execute instructions efficiently and reliably.
In the Embedded Software Roadmap, understanding computer architecture is a critical step—especially for developers working close to the hardware. This architectural blueprint includes the internal structure of the CPU—such as the control unit, ALU, and registers—as well as memory hierarchy, I/O mechanisms, and instruction sets. It governs how software communicates with hardware, how data moves through the system, and how performance can be improved using techniques like pipelining, caching, and parallel processing.
Why it matters: Embedded development often involves bare-metal programming, writing assembly code, or optimizing C/C++ for resource-constrained environments. A solid grasp of computer architecture empowers developers to write efficient code, debug at the hardware level, and fine-tune performance for real-time applications.
In essence, computer architecture transforms raw silicon into a purposeful computing engine—balancing speed, power, and scalability to meet the demands of modern embedded systems..
Topics to Cover:
Instruction Set Architecture (ISA): RISC vs CISC
ARM Cortex-M and ARMv7 architecture
Registers, ALU, Control Unit
Pipelining and hazards
Caches (L1/L2), memory hierarchy
Memory-mapped I/O
Endianness
1.4 Computer Networks
As embedded systems evolve, connectivity becomes increasingly vital. Computer Networks form the backbone of modern communication, enabling devices to share data, resources, and services—whether they’re part of a smart home, a vehicle, or a global cloud infrastructure.
In the Embedded Software Roadmap, understanding computer networks is crucial for building connected and intelligent embedded systems. Networks are built on layered protocols, starting from physical connections and data link layers to higher-level transport and application services. These layers work together to define how information is packaged, transmitted, routed, and received reliably and securely.
From wired LANs in industrial automation to wireless technologies powering IoT ecosystems, networks allow embedded devices to interact in real-time, share sensor data, receive firmware updates, and integrate with cloud platforms.
Why it’s important: Many modern embedded systems are no longer standalone. Devices often operate as part of a larger connected environment, making it essential to understand networking protocols like TCP/IP, UDP, MQTT, HTTP, and Bluetooth. This knowledge allows developers to implement secure, scalable, and efficient communication in embedded applications.
More than just infrastructure, computer networks serve as the digital nervous system of embedded and IoT applications—ensuring smooth, synchronized, and intelligent operations across distributed systems.
Topics to Cover:
OSI Model and TCP/IP
IP, UDP, TCP – Packet structures, handshakes
HTTP/HTTPS protocols
MQTT and CoAP (for IoT)
Bluetooth, Wi-Fi, ZigBee (basic wireless comm.)
Socket programming basics
Step 2: Master the Programming Language
At the heart of embedded software development lies programming languages—tools that transform ideas into functional systems. In the Embedded Software Roadmap, mastering the right programming languages is a fundamental step. These languages enable developers to write efficient, optimized code that directly controls hardware and processes data in real-time.
For embedded systems, C and C++ are the most widely used languages due to their efficiency, low-level hardware access, and performance. C is often preferred for bare-metal development because it allows precise control over system resources, while C++ introduces object-oriented features that enhance code structure, maintainability, and scalability.
In addition to C/C++, many embedded developers also explore Python for higher-level tasks like testing, automation, and scripting, as well as Assembly for low-level performance tuning. Understanding these languages provides the flexibility to tackle various embedded development challenges, whether you’re programming microcontrollers, designing device drivers, or developing real-time applications.
Why it’s important: Mastery of these languages allows embedded engineers to write efficient, low-level code that interacts directly with hardware, ensuring fast execution and minimal resource consumption. Additionally, knowledge of object-oriented programming in C++ supports building modular and maintainable systems, which is crucial for complex embedded projects.
In essence, mastering programming languages empowers embedded software engineers to translate hardware requirements into functional code—balancing performance, resource utilization, and reliability in every line of code.
2.1 Start with Embedded C Programming
Why C? C is the de facto standard for embedded development because of its:
Low-level access to memory (pointers)
Speed and minimal overhead
Hardware-level register manipulation
Portability across microcontrollers
Topics to Master in C:
Basics:
Data types (uint8_t, uint16_t, etc. from <stdint.h>)
Operators, Control flow, Functions
Intermediate:
Pointers, Arrays, Strings
Bitwise operations (|, &, ^, ~, <<, >>)
Structs, Enums, Typedef
Header files and Modular programming
Makefiles and Compilation
Advanced:
Memory management: Stack vs Heap
const, volatile, static, extern
Inline functions, Macros, Preprocessor directives
Interrupt Service Routines (ISRs) in C
Working with hardware registers (*(volatile uint32_t*)0x40021000 = 0x01;)
Category
Topics
Notes / Relevance
Basics of C
Introduction to C
Data Types, Variables, Constants
Operators: Arithmetic, Relational, Logical, Bitwise, Assignment
Expressions & Precedence
Input/Output functions (printf, scanf)
Comments & Coding Standards
Foundation for Embedded C programming
Control Statements
if, if-else, nested if
switch-case
Loops: for, while, do-while
break, continue, goto statements
Essential for program flow and decision-making
Functions
Function declaration & definition
Parameter passing: by value, by reference
Recursion
Inline functions
Library functions & custom headers
Code modularity and reusability in embedded projects
Arrays & Strings
Single & Multidimensional arrays
String handling & manipulation
Memory considerations in embedded systems
Used for data storage and sensor/memory interfacing
Pointers & Memory Management
Pointer basics & arithmetic
Pointers with arrays, strings, and functions
Dynamic memory allocation: malloc, calloc, free
Memory-mapped I/O in embedded systems
Critical for efficient memory use and hardware interfacing
Structures & Unions
struct declaration & usage
Nested structs
Union & enum usage
Bit-fields for memory optimization
Typedef usage
Used for organizing sensor data, registers, and peripherals
Direct MCU programming and real-time embedded applications
File Handling & EEPROM/Flash
File handling in C (for RTOS/host environment)
Reading/writing persistent memory
EEPROM/Flash interfacing
Persistent storage for embedded systems
Advanced Embedded C Concepts
Memory alignment & padding
Inline assembly in C
Using const, static, extern effectively
Real-Time Operating System (RTOS) integration basics
Modular programming & header/source file structure
Advanced control over performance, memory, and RTOS integration
Debugging & Testing
Using GDB for embedded systems
Unit testing with Google Test or Ceedling
Using serial debugging (UART)
LED and buzzer debugging
Watchpoints, breakpoints, and logging
Critical for reliable embedded software development
Step 2.1: C++
Once you’ve got a handle on C, it’s time to go deeper into C++, which is widely used in automotive, RTOS-based, and IoT embedded systems.
a)Learn Basic C++
Keywords: basic C++ tutorial, C++ syntax, C++ for beginners
Start with the fundamentals:
Data types & variables
Conditionals and loops
Functions and recursion
Arrays and strings
Pointers and references
Dynamic memory (new, delete)
Namespaces, inline functions, function overloading
🎯 Practice via platforms like LeetCode, HackerRank, or using mini console-based apps.
b) Understand OOPs Concepts
In the world of embedded software development, Object-Oriented Programming (OOP) is a powerful design paradigm that structures code around real-world entities. Instead of focusing solely on procedures or functions, OOP organizes software into objects—modular, reusable units that encapsulate both data and behavior. This approach makes the code more intuitive, maintainable, and scalable.
In the Embedded Software Roadmap, understanding OOP concepts like encapsulation, inheritance, polymorphism, and abstraction is essential for developing robust embedded systems, especially as applications grow in complexity. By focusing on what things are (objects) and what they do (methods), developers can model real-world systems more naturally, improving both code readability and flexibility.
Why it’s important: For embedded systems, OOP allows you to write cleaner, more organized code. It enables better reuse of software components, which can be critical when developing complex systems with limited resources. By applying OOP principles, embedded developers can design more scalable and maintainable systems, while also reducing errors and simplifying debugging.
In essence, mastering OOP in embedded software development provides the tools to design systems that are not only functional but also easier to manage and extend over time—ensuring long-term efficiency and adaptability.
Object-Oriented Programming is what gives C++ its real power.
Classes and Objects
Encapsulation, Abstraction
Inheritance (single, multiple, hybrid)
Polymorphism (compile-time & runtime)
Constructors and Destructors
this pointer, friend functions, operator overloading
const, static, virtual, pure virtual functions
Note: In embedded, avoid dynamic memory allocation and deep inheritance trees.
c)Learn STL (Standard Template Library)
The Standard Template Library (STL) is a powerful feature of C++ that brings the elegance of generic programming to everyday development. It offers a rich set of predefined classes and functions—ready to manage data structures and algorithms with optimal efficiency and minimal effort.
STL is useful even in high-end embedded systems or while writing test utilities.
Iterators: Input, Output, Forward, Bidirectional, Random access
Function Objects & Lambda Expressions
Templates: Function and class templates
d)Practice DSA (Data Structures & Algorithms)
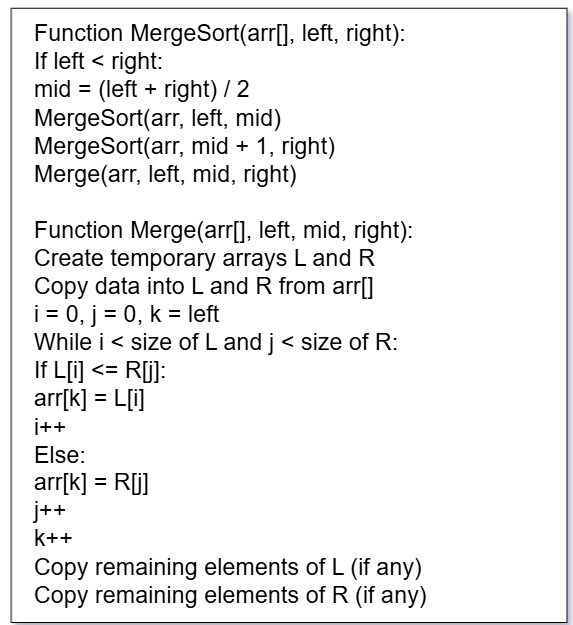
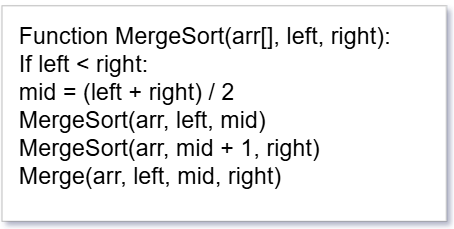
Data Structures and Algorithms (DSA) form the strategic core of software development, providing the tools and techniques needed to organize data and solve problems efficiently. While data structures define how information is stored, algorithms dictate the logic to process and transform it.
From managing dynamic memory with linked lists and trees to optimizing decisions through sorting, searching, and graph traversal, DSA equips developers to think critically and code smartly. It transforms brute-force solutions into optimized, scalable approaches—essential in everything from system design to real-time applications.
Mastering DSA isn’t just about writing code—it’s about developing a problem-solving mindset that balances time, space, and logic to build high-performance software in the real world.
Embedded engineers may not need complex DSA every day, but knowing it improves problem-solving and code quality.
🎯 Practice on Codeforces, LeetCode, and GeeksforGeeks.
💛 Support Embedded Prep
If you find our tutorials helpful and want to support our mission of sharing high-quality embedded system knowledge, you can contribute by buying us a coffee.
Every small contribution helps us keep creating valuable content for learners like you. ☕
Thank you for your support — it truly keeps Embedded Prep growing. 💻✨
e)Build a C++ Project Using Qt
Creating a C++ project with Qt is the perfect fusion of high-performance backend logic and a powerful cross-platform GUI framework. Qt empowers developers to bring their C++ code to life with intuitive interfaces, event-driven programming, and modular architecture.
In this approach, core functionality is implemented using the robustness of C++, while Qt handles the presentation layer through its flexible widgets, signals and slots mechanism, and UI design tools. Whether it’s a data visualization dashboard, a custom tool, or a real-time system monitor, Qt makes it easy to integrate rich user experiences with efficient native code.
Building a project with Qt not only sharpens object-oriented programming skills but also teaches practical concepts like multi-threading, event handling, resource management, and cross-platform deployment—all in a unified development environment.
Qt is widely used in embedded GUIs (especially for infotainment, industrial devices, dashboards).
Steps:
Install Qt Creator and set up a CMake-based project
Learn Qt Widgets or QML for UI
Connect buttons, sliders, and sensors using signals and slots
Use multithreading with QThread or QtConcurrent
Integrate serial communication with QSerialPort (to talk to microcontrollers)
Home automation GUI to control ESP32/Arduino via serial
🛠 Bonus: Try to cross-compile the Qt app for ARM/Linux target (e.g., Raspberry Pi or BeagleBone).on bare-metal safe subsets.
2.3 Assembly Language (Bonus)
Assembly Language is the closest human-readable form of programming that directly interacts with a system’s hardware. It acts as a thin layer between machine code and high-level programming, providing fine-grained control over a processor’s operations.
Each instruction in Assembly corresponds to a single machine-level command, allowing developers to manipulate registers, memory addresses, I/O ports, and control flow with exact precision. This low-level access makes Assembly indispensable for performance-critical, time-sensitive, and resource-constrained environments such as embedded systems, operating systems, and device drivers.
Learning Assembly Language offers deep insights into CPU architecture, instruction sets, and how software translates into actual machine operations. It is not just a programming tool—it’s a window into the very core of computing.
When ultra-precise control is needed:
Learn basic ARM Cortex-M Assembly (or AVR)
Understand registers, stack frames
Learn how to optimize critical sections
2.4 Python for Embedded Automation and Tools
Python has become an indispensable tool in the embedded systems world, offering a high-level language that enhances productivity while maintaining the low-level precision required for embedded automation. By leveraging Python in embedded environments, developers can rapidly prototype, automate processes, and streamline toolchains without sacrificing performance.
Python excels in creating custom automation scripts, interacting with hardware interfaces, and building tooling that simplifies development workflows. Whether it’s controlling GPIO pins, interfacing with sensors, or automating testing procedures, Python brings simplicity and flexibility to embedded systems, making tasks like data logging, hardware testing, and system monitoring much more efficient.
With libraries such as RPi.GPIO, PySerial, and PyTest, Python enables seamless integration between embedded platforms and the tools used for development, testing, and debugging. It’s the perfect language for rapid development and automation, bridging the gap between embedded hardware and sophisticated software control.
Python isn’t usually used directly on MCUs but is great for:
Writing test scripts for embedded hardware
Serial communication (pyserial)
Parsing logs, files, and test reports
GUI with Tkinter or PyQt
Data plotting with matplotlib
Embedded Use Cases:
Automate firmware flashing over USB/UART
Data logger scripts
Backend control panel for IoT devices
Unit test automation
2.5 Shell Scripting (Bash) for Embedded Linux
Shell scripting, particularly with Bash, is a powerful and flexible tool for managing and automating tasks in Embedded Linux environments. It allows developers to streamline system administration, automate device configurations, and control the boot process—all through simple, concise commands.
In the realm of embedded systems, Bash scripts serve as the bridge between hardware and software, facilitating tasks like system startup configuration, file manipulation, hardware diagnostics, and process management. The efficiency of Bash lies in its ability to manipulate files, manage system resources, and interact with the Linux kernel—all without needing to write complex C code.
A must-have for embedded Linux developers:
Basics: if, for, while, variables, functions
File operations, logging, redirections
Using grep, awk, sed, cut
Automate build, flash, and deploy pipelines
Write scripts to configure GPIO, I2C, or SPI on Linux boards
Used heavily in Yocto, Buildroot, init scripts, and service management.
Step 3: Systems Programming and Embedded Driver Development with ARM Cortex M3/M4
Note : To gain a deeper understanding of Systems Programming on ARM Cortex-M3/M4 MPU, it is highly recommended to engage in hands-on practical exercises
Communication Protocol
I2C
SPI
UART / USART
I2S
TC/IP
UDP
Ethernet
CAN
LIN
BT / WIFI / USB
Note : For an in-depth understanding, consider mastering microcontroller development with a focus on embedded driver development, including I2C, GPIO, USART, timers, PWM, CAN, RTC, STM32-LTDC, LCD-TFT, and LVGL.
Popular MCUs to practice:
Atmega328p (Arduino Uno)
STM32F103, STM32F4 series
ESP32 (for Wi-Fi + BLE)
NXP, Renesas, TI MCUs
Complete Electronics Core Topics Every Embedded Software Engineer Must Know (ECE/EEE)
Category
Topics
Notes / Relevance
Basic Electrical & Electronics
Voltage, Current, Resistance, Power, Energy
Ohm’s Law & Kirchhoff’s Laws
Series & Parallel Circuits
AC & DC Fundamentals, RMS & Peak values
Passive Components: Resistors, Capacitors, Inductors
Semiconductors: Diodes, LEDs, BJTs, MOSFETs
Voltage dividers, RC/RL/RLC circuits
Foundation for understanding circuits and embedded interfacing
Special thanks to @mr-raj for contributing to this article on Embedded Prep
Important Embedded C Questions
S.No
Question
1
What is embedded C?
2
What is an embedded system?
3
Differentiate between a microprocessor and a microcontroller.
4
Explain the various data types in C used for embedded systems.
5
What are the basic differences between C and embedded C?
6
How do you declare a constant in embedded C?
7
What is the keyword “volatile” used for in embedded C?
8
Explain the difference between static and dynamic memory allocation in embedded C.
9
What is an interrupt and how is it handled in embedded C?
10
Explain the concept of polling versus interrupt-driven I/O.
11
How do you perform bitwise operations in embedded C?
12
Describe the process of creating a delay in embedded C.
13
What is the significance of the “restrict” keyword in embedded C?
14
Explain the purpose of the “const” keyword in embedded C.
15
How do you declare and use a pointer in embedded C?
16
What is a structure in embedded C and how is it used?
17
Describe the role of the “typedef” keyword in embedded C.
18
Explain the concept of bit fields in embedded C.
19
What is a union and how is it used in embedded C?
20
What are the advantages of using bit manipulation in embedded C?
21
Describe the “volatile” keyword and its importance in embedded C.
22
Explain the concept of portability in embedded C programming.
23
How do you implement a circular buffer in embedded C?
24
What is the difference between little-endian and big-endian byte ordering in embedded systems?
25
How do you implement a finite state machine in embedded C?
26
Describe the process of handling errors in embedded C programming.
27
Explain the role of the linker in embedded C programming.
28
What is the significance of the “extern” keyword in embedded C?
29
How do you perform input/output operations in embedded C?
30
Describe the concept of real-time operating systems (RTOS) in embedded C.
31
How do you handle multi-threading in embedded C?
32
What is the purpose of the “inline” keyword in embedded C?
33
Explain the concept of interrupt latency in embedded systems.
34
How do you implement a watchdog timer in embedded C?
35
Describe the process of programming timers in embedded C.
36
What are the different types of memory available in embedded systems?
37
How do you perform memory-mapped I/O in embedded C?
38
Explain the concept of DMA (Direct Memory Access) in embedded systems.
39
How do you handle endianness issues in embedded C?
40
Describe the process of implementing a software stack in embedded C.
41
What is the role of a bootloader in embedded systems?
42
How do you debug embedded C code?
43
Explain the concept of cache memory and its impact on embedded systems.
44
How do you handle floating-point arithmetic in embedded C?
45
Describe the process of implementing a communication protocol in embedded C.
46
What is the role of the startup code in embedded systems?
47
How do you perform memory alignment in embedded C?
48
Explain the concept of memory-mapped peripherals in embedded systems.
49
How do you handle power management in embedded C?
50
Describe the process of implementing a state machine in embedded C.
51
What is a pointer-to-function in embedded C?
52
How do you perform code optimization in embedded C?
53
Explain the concept of real-time scheduling in embedded systems.
54
How do you implement a circular linked list in embedded C?
55
Describe the process of implementing a hardware driver in embedded C.
56
What is the role of the stack pointer in embedded systems?
57
How do you perform memory pooling in embedded C?
58
Explain the concept of hardware-software co-design in embedded systems.
59
How do you handle multi-tasking in embedded C?
60
Describe the process of implementing a state transition table in embedded C.
61
What is the role of the program counter in embedded systems?
62
How do you perform fixed-point arithmetic in embedded C?
63
Explain the concept of real-time constraints in embedded systems.
64
How do you implement a priority queue in embedded C?
65
Describe the process of implementing a device driver in embedded C.
66
What is the role of the status register in embedded systems?
67
How do you perform memory-mapped file I/O in embedded C?
68
Explain the concept of multi-core processing in embedded systems.
69
How do you handle concurrency issues in embedded C?
70
Describe the process of implementing a message passing mechanism in embedded C.
71
What is the role of the interrupt vector table in embedded systems?
72
How do you perform fixed-size memory allocation in embedded C?
73
Explain the concept of real-time task synchronization in embedded systems.
74
How do you implement a priority-based scheduler in embedded C?
75
Describe the process of implementing a file system in embedded C.
76
What is the role of the system control register in embedded systems?
77
How do you perform memory-mapped I/O with direct addressing in embedded C?
78
Explain the concept of hardware acceleration in embedded systems.
79
How do you handle resource contention in embedded C?
80
Describe the process of implementing a power management scheme in embedded C.
81
What is the role of the interrupt service routine in embedded systems?
82
How do you perform dynamic memory allocation in embedded C?
83
Explain the concept of real-time task synchronization using semaphores in embedded systems.
84
How do you implement a round-robin scheduler in embedded C?
85
Describe the process of implementing a communication protocol stack in embedded C.
86
What is the role of the memory management unit in embedded systems?
87
How do you perform memory-mapped I/O with indirect addressing in embedded C?
88
Explain the concept of hardware/software partitioning in embedded systems.
89
How do you handle inter-process communication in embedded C?
90
Describe the process of implementing a real-time operating system kernel in embedded C.
91
What is the role of the system timer in embedded systems?
92
How do you perform memory-mapped I/O with bank switching in embedded C?
93
Explain the concept of hardware verification in embedded systems.
94
How do you handle synchronization issues in embedded C?
95
Describe the process of implementing a memory management scheme in embedded C.
96
What is the role of the interrupt controller in embedded systems?
97
How do you perform memory-mapped I/O with memory-mapped registers in embedded C?
98
Explain the concept of hardware-in-the-loop testing in embedded systems.
99
How do you handle real-time constraints in embedded C?
100
Describe the process of implementing a task scheduler in embedded C.
101
What is the role of the watchdog timer in embedded systems?
102
How do you perform memory-mapped I/O with memory-mapped files in embedded C?
103
Explain the concept of hardware debugging in embedded systems.
104
How do you handle exception handling in embedded C?
105
Describe the process of implementing a device driver framework in embedded C.
106
What is the role of the reset vector in embedded systems?
107
How do you perform memory-mapped I/O with memory-mapped peripherals in embedded C?
108
Explain the concept of hardware emulation in embedded systems.
109
How do you handle real-time task synchronization using message queues in embedded C?
110
Describe the process of implementing a real-time scheduler in embedded C.
111
What is the role of the memory protection unit in embedded systems?
112
How do you perform memory-mapped I/O with memory-mapped ports in embedded C?
113
Explain the concept of hardware co-simulation in embedded systems.
114
How do you handle real-time task synchronization using event flags in embedded C?
115
Describe the process of implementing a fault-tolerant system in embedded C.
116
What is the role of the power management unit in embedded systems?
117
How do you perform memory-mapped I/O with memory-mapped devices in embedded C?
118
Explain the concept of hardware validation in embedded systems.
119
How do you handle real-time task synchronization using mutexes in embedded C?
120
Describe the process of implementing a real-time communication protocol in embedded C.
121
What is the role of the memory controller in embedded systems?
122
How do you perform memory-mapped I/O with memory-mapped buffers in embedded C?
123
Explain the concept of hardware synthesis in embedded systems.
124
How do you handle real-time task synchronization using condition variables in embedded C?
125
Describe the process of implementing a real-time file system in embedded C.
126
What is the role of the peripheral controller in embedded systems?
127
How do you perform memory-mapped I/O with memory-mapped displays in embedded C?
128
Explain the concept of hardware modelling in embedded systems.
129
How do you handle real-time task synchronization using semaphores and priority inversion in embedded C?
130
Describe the process of implementing a real-time network stack in embedded C.
131
What is the role of the DMA controller in embedded systems?
132
How do you perform memory-mapped I/O with memory-mapped sensors in embedded C?
133
Explain the concept of hardware simulation in embedded systems.
134
How do you handle real-time task synchronization using spinlocks in embedded C?
135
Describe the process of implementing a real-time file system journal in embedded C.
136
What is the role of the interrupt controller in embedded systems?
137
How do you perform memory-mapped I/O with memory-mapped timers in embedded C?
138
Explain the concept of hardware acceleration using FPGA in embedded systems.
139
How do you handle real-time task synchronization using priority inheritance in embedded C?
140
Describe the process of implementing a real-time memory management scheme in embedded C.
141
What is the role of the interrupt vector table in embedded systems?
142
How do you perform memory-mapped I/O with memory-mapped ADCs in embedded C?
143
Explain the concept of hardware co-design using high-level synthesis in embedded systems.
144
How do you handle real-time task synchronization using priority ceiling protocol in embedded C?
145
Describe the process of implementing a real-time communication protocol stack in embedded C.
146
What is the role of the system timer in embedded systems?
147
How do you perform memory-mapped I/O with memory-mapped DACs in embedded C?
148
Explain the concept of hardware-in-the-loop testing using virtual prototypes in embedded systems.
149
How do you handle real-time task synchronization using reader-writer locks in embedded C?
150
Describe the process of implementing a real-time fault-tolerant system in embedded C.
151
What is the role of the watchdog timer in embedded systems?
152
How do you perform memory-mapped I/O with memory-mapped PWMs in embedded C?
153
Explain the concept of hardware debugging using JTAG in embedded systems.
154
How do you handle real-time task synchronization using priority ceiling emulation in embedded C?
155
Describe the process of implementing a real-time virtual file system in embedded C.
156
What is the role of the reset vector in embedded systems?
157
How do you perform memory-mapped I/O with memory-mapped UARTs in embedded C?
158
Explain the concept of hardware emulation using virtual platforms in embedded systems.
159
How do you handle real-time task synchronization using message-passing rendezvous in embedded C?
160
Describe the process of implementing a real-time distributed system in embedded C.
161
What is the role of the memory protection unit in embedded systems?
162
How do you perform memory-mapped I/O with memory-mapped SPIs in embedded C?
163
Explain the concept of hardware co-simulation using System C in embedded systems.
164
How do you handle real-time task synchronization using priority-based spinlocks in embedded C?
165
Describe the process of implementing a real-time fault-tolerant communication protocol in embedded C.
166
What is the role of the power management unit in embedded systems?
167
How do you perform memory-mapped I/O with memory-mapped I2Cs in embedded C?
168
Explain the concept of hardware validation using formal methods in embedded systems.
169
How do you handle real-time task synchronization using priority-based semaphores in embedded C?
170
Describe the process of implementing a real-time secure file system in embedded C.
171
What is the role of the memory controller in embedded systems?
172
How do you perform memory-mapped I/O with memory-mapped GPIOs in embedded C?
173
Explain the concept of hardware synthesis using high-level languages in embedded systems.
174
How do you handle real-time task synchronization using priority-based condition variables in embedded C?
175
Describe the process of implementing a real-time embedded database system in embedded C.
176
What is the role of the peripheral controller in embedded systems?
177
How do you perform memory-mapped I/O with memory-mapped PWMs in embedded C?
178
Explain the concept of hardware modeling using hardware description languages in embedded systems.
179
How do you handle real-time task synchronization using priority-based mutexes in embedded C?
180
Describe the process of implementing a real-time secure communication protocol stack in embedded C.
181
What is the role of the DMA controller in embedded systems?
182
How do you perform memory-mapped I/O with memory-mapped UARTs in embedded C?
183
Explain the concept of hardware acceleration using GPU in embedded systems.
184
How do you handle real-time task synchronization using priority-based reader-writer locks in embedded C?
185
Describe the process of implementing a real-time embedded web server in embedded C.
186
What is the role of the interrupt controller in embedded systems?
187
How do you perform memory-mapped I/O with memory-mapped SPIs in embedded C?
188
Explain the concept of hardware co-design using IP cores in embedded systems.
189
How do you handle real-time task synchronization using priority-based rendezvous in embedded C?
190
Describe the process of implementing a real-time distributed communication protocol stack in embedded C.
1. What is embedded software?
Embedded software is a specialized type of software designed to run on hardware devices like microcontrollers, sensors, or boards such as Arduino, STM32, or Raspberry Pi. It controls specific functions within a larger system, often in real-time.
2. Is this roadmap suitable for complete beginners?
Yes! This roadmap is designed for absolute beginners with no prior experience in embedded systems. Whether you’re a student or a career switcher, you’ll find easy-to-follow steps, project ideas, and learning paths.
3.Do I need to know C or C++ to get started?
Knowing C is highly recommended, as it’s the foundation of embedded programming. However, our roadmap starts from scratch and will guide you to learn C and eventually C++ at a comfortable pace.
4.What hardware do I need as a beginner?
You can start with basic, affordable boards like: Arduino Uno ESP32 or ESP8266 (for IoT projects) STM32 (for advanced learning) These boards are beginner-friendly and widely supported by tutorials.
5.Do I need electronics knowledge to start embedded programming?
Only basic electronics knowledge is needed. The roadmap includes beginner-friendly explanations of resistors, capacitors, GPIOs, sensors, and circuits with diagrams and examples.
6.Can I follow this roadmap while working or studying full-time?
Absolutely! The guide is broken down into Step wise milestones, so you can learn at your own pace — even if you have just a few hours per week.
7.What tools and software are covered in the roadmap?
You’ll learn how to use: Arduino IDE PlatformIO STM32CubeIDE QEMU (for emulation) Git & GitHub Linux terminal basics GCC compiler and Makefiles
8.Does the roadmap include real-world projects?
Yes! You’ll work on practical projects like: LED blinking Temperature & humidity monitor IoT gas alert system Audio player with amplifier Real-time sensor dashboard with Python and web interface
9.Is Linux knowledge required?
Basic Linux knowledge is helpful but not mandatory. The roadmap includes a beginner section to get you comfortable with Linux commands, scripting, and embedded Linux fundamentals.
10.What’s the goal of this roadmap?
The roadmap aims to help you: ✅ Build a strong foundation in embedded systems ✅ Learn to work with real hardware ✅ Understand drivers, RTOS, and protocols ✅ Create portfolio-worthy projects ✅ Prepare for embedded job interviews
11.Where can I find the full roadmap?
The complete guide is available on our website/blog: Embedded Prep Master – Make sure to bookmark it and follow us for updates!
You can also Visit other tutorials of Embedded Prep
Bubble Sort Algorithm: Bubble Sort is one of the most fundamental and widely recognized sorting algorithms in computer science. Its simplicity and educational value make it a popular choice for introducing beginners to the concept of algorithmic thinking and sorting mechanisms. Though not the most efficient for large datasets, Bubble Sort’s step-by-step operation provides an excellent foundation for understanding how comparison-based sorting works.
Bubble Sort Key Features
In-place sorting algorithm
Stable sorting technique
Works in O(n²) time complexity
Best sorting algorithm for small data sets
Bubble Sort Algorithm Explained
Bubble Sort goes through the list, swapping neighboring elements that are out of order, and keeps repeating this process until the entire list is sorted.
How does bubble sort work ?
Start from the beginning of the array
Compare each pair of adjacent elements
If two neighboring elements aren’t in the correct order, simply swap them to move closer to the desired sequence.
Repeat until no swaps are needed
Bubble Sort Code in C
#include <stdio.h>

void bubbleSort(int arr[], int n) {
    for (int i = 0; i < n - 1; i++) {
        for (int j = 0; j < n - i - 1; j++) {
            if (arr[j] > arr[j + 1]) {
                // Swap
                int temp = arr[j];
                arr[j] = arr[j + 1];
                arr[j + 1] = temp;
            }
        }
    }
}
Bubble Sort Code in C++
#include <iostream>
using namespace std;

void bubbleSort(int arr[], int n) {
    for (int i = 0; i < n - 1; i++) {
        for (int j = 0; j < n - i - 1; j++) {
            if (arr[j] > arr[j + 1]) {
                swap(arr[j], arr[j + 1]);
            }
        }
    }
}
What is the best case time complexity of bubble sort?
Case
Time Complexity
Best Case
O(n)
Average Case
O(n²)
Worst Case
O(n²)
Space Complexity: O(1) – No extra space used
Best for educational purposes, interview preparation, and embedded systems sorting problems
Can bubble sorter used in alphabetical order?
we can compare strings using comparison operators like > or <, or use string comparison functions depending on the programming language.
Exmaple in C
#include <iostream>
#include <string>
using namespace std;

void bubbleSort(string arr[], int n) {
    for (int i = 0; i < n-1; ++i) {
        for (int j = 0; j < n-i-1; ++j) {
            if (arr[j] > arr[j+1]) {
                // Swap if out of order
                string temp = arr[j];
                arr[j] = arr[j+1];
                arr[j+1] = temp;
            }
        }
    }
}

int main() {
    string names[] = {"banana", "apple", "grape", "cherry"};
    int n = sizeof(names)/sizeof(names[0]);

    bubbleSort(names, n);

    cout << "Sorted names:\n";
    for (int i = 0; i < n; ++i)
        cout << names[i] << endl;

    return 0;
}
Can bubble sort be used for descending order ?
Bubble sort can be easily modified to sort in descending order by just changing the comparison condition.
Key Difference:
Ascending order: if (arr[j] > arr[j+1])
Descending order: if (arr[j] < arr[j+1])
Example: Descending Order (C++)
#include <iostream>
using namespace std;

void bubbleSortDescending(int arr[], int n) {
    for (int i = 0; i < n - 1; ++i) {
        for (int j = 0; j < n - i - 1; ++j) {
            if (arr[j] < arr[j + 1]) {
                // Swap for descending order
                int temp = arr[j];
                arr[j] = arr[j + 1];
                arr[j + 1] = temp;
            }
        }
    }
}

int main() {
    int numbers[] = {10, 4, 7, 1, 9};
    int n = sizeof(numbers) / sizeof(numbers[0]);

    bubbleSortDescending(numbers, n);

    cout << "Sorted in descending order:\n";
    for (int i = 0; i < n; ++i)
        cout << numbers[i] << " ";

    return 0;
}
Output:
Sorted in descending order:
10 9 7 4 1
You can do the same thing with strings for reverse alphabetical order:
if (arr[j] < arr[j+1]) // for strings
Benefits of Bubble Sort
Easy to implement
Perfect for beginner programmers
Helps understand the concept of element swapping and iteration
Frequently asked in coding interviews and technical exams
Applications of Bubble Sort
Embedded software systems
Microcontroller data sorting
Sorting sensor values
Small dataset processing in IoT
💛 Support Embedded Prep
If you find our tutorials helpful and want to support our mission of sharing high-quality embedded system knowledge, you can contribute by buying us a coffee.
Every small contribution helps us keep creating valuable content for learners like you. ☕
Thank you for your support — it truly keeps Embedded Prep growing. 💻✨
Final Thoughts
Use Bubble Sort to master the basics of sorting algorithms. With its simple logic and straightforward code, it’s ideal for learning, teaching, and solving real-world problems in C and C++.
What is Bubble Sort in C and C++
Bubble Sort is a simple sorting algorithm used in C and C++ that repeatedly compares and swaps adjacent elements if they are in the wrong order. It continues this process until the entire array is sorted in ascending or descending order.
Why is it called Bubble Sort?
It’s called Bubble Sort because the largest (or smallest) elements “bubble up” to the end (or beginning) of the array after each iteration, just like bubbles rising to the surface of water.
Can I use Bubble Sort for large datasets?
While Bubble Sort works for small arrays, it is inefficient for large datasets due to its O(n²) time complexity. For larger datasets, more advanced algorithms like Quick Sort or Merge Sort are recommended.
Is Bubble Sort stable and in-place?
Yes, Bubble Sort is a stable sorting algorithm (it maintains the order of equal elements) and it is in-place, meaning it does not require extra memory space.
You can also Visit other tutorials of Embedded Prep
If you’re diving into sorting algorithms, the selection sort algorithm is one of the simplest and most intuitive methods to start with. Despite being basic, it’s a great way to understand the fundamentals of sorting logic. In this blog post, we’ll walk through what selection sort is, how it works, its time complexity, and a sample code in C++.
What is selection sort ?
What is selection sort : Selection sort is a kind of sorting method based on comparisons technique. It separates the array into a sorted parts and an unsorted parts, then repeatedly selects the smallest element from the unsorted parts and places it at the end of the sorted parts
How the Selection Sort Algorithm Works
Here’s a step-by-step working techinuque of selection sort explanation:
Start from the first element of the array.
Search the smallest element in the unsorted portion.
Swap the smallest element with the first element.
Shift the dividing line between the sorted and unsorted parts one position forward (next).
Repeat until the array is sorted.
Example of Selection Sort Algorithm
Let’s say we have an below array:
[45, 22, 89, 33, 10]
How selection sort works ?
Let’s gone through below steps how selection sort would organize it:
First, examine the entire list [45, 22, 89, 33, 10]. The smallest value is 10. Swap it with the first element 45 → [10, 22, 89, 33, 45]
Next, look at the subarray [22, 89, 33, 45]. The smallest number is 22, which is already in place. No swap needed.
Now move to [89, 33, 45]. The minimum here is 33. Swap it with 89 → [10, 22, 33, 89, 45]
Then, in [89, 45], the smallest is 45. Swap it with 89 → [10, 22, 33, 45, 89]
The array is now sorted using selection sort algorithm.
Is selection sort stable ?
Selection sort is stable or not : Selection Sort is inherently unstable — but not because it swaps elements, rather because it does not respect the original order of equivalent elements when finding the minimum.
Let’s reimagine this through a theater analogy:
Imagine you’re organizing people (elements) by height (value) for a stage performance. You always pick the shortest person (minimum) and move them to the front — but without caring whether two people of the same height had different roles (original positions). You just swap whoever is found first in your search, even if it pushes someone with an earlier role to the back.
So in essence:
Selection Sort does not maintain “role memory” for equal values.
It simply grabs the minimum, regardless of earlier appearances.
This causes instability, because if two equal elements are separated by a swap, the relative order is broken.
However — and here’s the twist Google doesn’t tell you:
Selection Sort can be made stable with a simple tweak: instead of swapping, insert the minimum in-place while shifting others to the right.
But that tweak costs performance. So while basic Selection Sort is not stable, a thoughtful rewrite can make it so, at the cost of efficiency.so now we able to understand why selection sort is not stable .
What is selection sort in c ++?
#include <iostream>
using namespace std;

void selectionSort(int arr[], int n) {
    for (int i = 0; i < n - 1; i++) {
        int minIdx = i;

        for (int j = i + 1; j < n; j++) {
            if (arr[j] < arr[minIdx])
                minIdx = j;
        }

        swap(arr[minIdx], arr[i]);
    }
}

void printArray(int arr[], int size) {
    for (int i = 0; i < size; i++)
        cout << arr[i] << " ";
    cout << endl;
}

int main() {
    int arr[] = {45,22,89,33,10};
    int n = sizeof(arr) / sizeof(arr[0]);

    cout << "Original array of array is : ";
    printArray(arr, n);

    selectionSort(arr, n);

    cout << "Sorted array: ";
    printArray(arr, n);

    return 0;
}
Output :
💛 Support Embedded Prep
If you find our tutorials helpful and want to support our mission of sharing high-quality embedded system knowledge, you can contribute by buying us a coffee.
Every small contribution helps us keep creating valuable content for learners like you. ☕
Thank you for your support — it truly keeps Embedded Prep growing. 💻✨
What is the best case and worst case complexity of selection sort ?
Case
Time Complexity
Best case
O(n²)
Avg case
O(n²)
Worst case
O(n²)
Space Complexity: O(1) Because selection sort sorts elements directly within the original array, it maintains a constant space complexity throughout the process.
What is selection sort in c ?
#include <stdio.h>

int digitSum(int n) {
    int sum = 0;
    while(n) {
        sum += n % 10;
        n /= 10;
    }
    return sum;
}

void selectionSortByDigitSum(int arr[], int n) {
    for(int i = 0; i < n - 1; i++) {
        int min = i;
        for(int j = i + 1; j < n; j++) {
            if(digitSum(arr[j]) < digitSum(arr[min])) {
                min = j;
            }
        }
        int temp = arr[i];
        arr[i] = arr[min];
        arr[min] = temp;
    }
}

int main() {
    int arr[] = {91, 34, 23, 82, 17};
    int n = sizeof(arr)/sizeof(arr[0]);

    selectionSortByDigitSum(arr, n);

    for(int i = 0; i < n; i++)
        printf("%d ", arr[i]);

    return 0;
}
When to Choose Selection Sort?
Selection sort may not be the most efficient option for large datasets, but it excels in the following scenarios:
Simple to grasp
Ideal for small arrays
Excellent for teaching and learning purposes
Conclusion
The selection sort algorithm is a simple yet powerful concept that helps build a strong foundation in sorting logic. Though it’s not the fastest for large arrays, its ease of implementation and step-by-step nature make it ideal for beginners.
Thank you for exploring Selection sort algorithm tutorials ! Stay ahead in embedded systems with expert insights, hands-on projects, and in-depth guides. Follow Embedded Prep for the latest trends, best practices, and step-by-step tutorials to enhance your expertise. Keep learning, keep innovating!
What is Selection Sort?
Answer: Selection Sort is a simple sorting algorithm that works by repeatedly finding the smallest element and swapping it with the current element.
How does Selection Sort work?
Answer: The algorithm divides the array into two parts: sorted and unsorted. It selects the minimum element from the unsorted part and swaps it with the leftmost unsorted element.
What is the time complexity of Selection Sort?
Answer: The time complexity of Selection Sort is O(n^2) in all cases (best, worst, and average).
Is Selection Sort stable?
Answer: No, Selection Sort is not a stable sorting algorithm, as it may change the relative order of equal elements.
You can also Visit other tutorials of Embedded Prep
Merge sort algorithm:Sorting is a fundamental concept in computer science, and one of the most efficient and widely used sorting techniques is Merge Sort. Whether you’re preparing for coding interviews or building real-world software, understanding Merge Sort can boost your algorithmic thinking.
What is Merge Sort?
Merge Sort is a divide-and-conquer algorithm that works by breaking down a list into smaller chunks, sorting those pieces individually, and then merging them back together in the correct order. It’s known for its reliable performance, even with large datasets.
Key Characteristics:
Stable Sort: Maintains the relative order of equal elements.
Time Complexity: O(n log n) in all cases (best, average, worst).
Space Complexity: O(n) due to the temporary arrays used for merging.
How Does Merge Sort Work?
Imagine you have a messy pile of cards. Instead of sorting them all at once, you divide them into smaller piles, sort each pile, and then combine the sorted piles into one organized deck. Merge Sort does exactly that, but with numbers (or any sortable data).
Step-by-Step Process:
Divide the array into two halves.
Recursively sort each half.
Merge the sorted halves into a single sorted array.
Sorting plays a crucial role in organizing data efficiently. Among the various algorithms, Merge Sort stands out for its efficiency and reliability. Let’s break it down in the simplest way possible.
Example
Let’s say you have the following array:
[38, 27, 43, 3, 9, 82, 10]
Your goal is to sort this array in ascending order using Merge Sort.
Step-by-step:
Divide: Split the array until each part has a single element: [38] [27] [43] [3] [9] [82] [10]
Sort and Merge:
Merge [38] and [27] → [27, 38]
Merge [27, 38] and [43] → [27, 38, 43]
Merge [3] and [9] → [3, 9], then merge with [82] → [3, 9, 82], and finally merge with [10] → [3, 9, 10, 82]
Final Merge: Merge [27, 38, 43] and [3, 9, 10, 82] → [3, 9, 10, 27, 38, 43, 82]
Intuition
Imagine you are sorting playing cards. It’s easier to sort two small piles and then combine them than to sort a large pile all at once. That’s what Merge Sort does.
It divides the problem into smaller sub-problems.
Solves each smaller problem (sorts each half).
Then combines the solutions (merges sorted halves).
This divide-and-conquer strategy makes Merge Sort powerful and predictable.
Approach
Merge Sort follows a recursive strategy:
Divide the array into two halves.
Recursively apply merge sort to each half.
Merge the two sorted halves into one.
Key Points:
Uses extra space (temporary arrays).
Always has time complexity of O(n log n).
Performs well with large datasets and linked lists.
Pseudocode
Here’s the simplified pseudocode for Merge Sort:
Merge Sort Pseudocode
What’s the Goal?
We want to take an unsorted array and sort it in ascending order. Merge Sort does this by splitting the array, sorting the parts, and then merging them.
MergeSort(arr, left, right)
Explanation:
arr[] – This is the array we want to sort.
left – The starting index of the array.
right – The ending index of the array.
Step-by-step:
If left is smaller than right, it means we still have more than one element in the array.
Find the middle point (to divide the array into two halves).
Recursively sort the first half.
Recursively sort the second half.
Merge the two sorted halves.
It keeps calling itself (recursion) until each half has only one element. That’s when sorting begins.
Merge(arr, left, mid, right)
Explanation:
This function merges two already sorted halves of the array into one sorted array.
Step-by-step:
Make two temporary arrays – one for the left part and one for the right part.
Copy elements from the original array into these two parts.
Start comparing the first elements from both halves:
Put the smaller one back into the original array.
Keep comparing and placing until one of the arrays is empty.
If anything is left over in L or R, just copy it into the original array.
💛 Support Embedded Prep
If you find our tutorials helpful and want to support our mission of sharing high-quality embedded system knowledge, you can contribute by buying us a coffee.
Every small contribution helps us keep creating valuable content for learners like you. ☕
Thank you for your support — it truly keeps Embedded Prep growing. 💻✨
Real-Life Analogy
Think of Merge Sort like sorting pages of a book:
You split the book in half.
Ask two people to sort each half separately.
Then you take both sorted stacks and combine them one page at a time in the correct order.
Visual Example
Suppose we want to sort the array: [38, 27, 43, 3, 9, 82, 10]
Split into two halves: [38, 27, 43] and [3, 9, 82, 10]
Keep splitting until you reach single-element arrays:
[38] [27] [43] [3] [9] [82] [10]
Merge step-by-step:
[27, 38], [3, 43], [9, 10], [9, 10, 82]
Final result: [3, 9, 10, 27, 38, 43, 82]
Merge Sort in Java
public class MergeSort {
    public static void mergeSort(int[] arr, int left, int right) {
        if (left < right) {
            int mid = (left + right) / 2;

            mergeSort(arr, left, mid);
            mergeSort(arr, mid + 1, right);

            merge(arr, left, mid, right);
        }
    }

    public static void merge(int[] arr, int left, int mid, int right) {
        int n1 = mid - left + 1;
        int n2 = right - mid;

        int[] L = new int[n1];
        int[] R = new int[n2];

        for (int i = 0; i < n1; i++)
            L[i] = arr[left + i];
        for (int j = 0; j < n2; j++)
            R[j] = arr[mid + 1 + j];

        int i = 0, j = 0, k = left;

        while (i < n1 && j < n2) {
            if (L[i] <= R[j]) {
                arr[k++] = L[i++];
            } else {
                arr[k++] = R[j++];
            }
        }

        while (i < n1)
            arr[k++] = L[i++];

        while (j < n2)
            arr[k++] = R[j++];
    }

    public static void main(String[] args) {
        int[] arr = {38, 27, 43, 3, 9, 82, 10};
        mergeSort(arr, 0, arr.length - 1);

        for (int num : arr)
            System.out.print(num + " ");
    }
}
Merge Sort in C++
#include <iostream>
using namespace std;

void merge(int arr[], int left, int mid, int right) {
    int n1 = mid - left + 1;
    int n2 = right - mid;

    int L[n1], R[n2];

    for (int i = 0; i < n1; i++) L[i] = arr[left + i];
    for (int j = 0; j < n2; j++) R[j] = arr[mid + 1 + j];

    int i = 0, j = 0, k = left;

    while (i < n1 && j < n2) {
        arr[k++] = (L[i] <= R[j]) ? L[i++] : R[j++];
    }

    while (i < n1) arr[k++] = L[i++];
    while (j < n2) arr[k++] = R[j++];
}

void mergeSort(int arr[], int left, int right) {
    if (left < right) {
        int mid = (left + right) / 2;

        mergeSort(arr, left, mid);
        mergeSort(arr, mid + 1, right);

        merge(arr, left, mid, right);
    }
}

int main() {
    int arr[] = {38, 27, 43, 3, 9, 82, 10};
    int n = sizeof(arr) / sizeof(arr[0]);

    mergeSort(arr, 0, n - 1);

    for (int i = 0; i < n; i++)
        cout << arr[i] << " ";
    return 0;
}
Merge Sort in C
#include <stdio.h>

void merge(int arr[], int left, int mid, int right) {
    int i, j, k;
    int n1 = mid - left + 1;
    int n2 = right - mid;

    int L[n1], R[n2];

    for (i = 0; i < n1; i++) L[i] = arr[left + i];
    for (j = 0; j < n2; j++) R[j] = arr[mid + 1 + j];

    i = 0; j = 0; k = left;

    while (i < n1 && j < n2) {
        if (L[i] <= R[j]) arr[k++] = L[i++];
        else arr[k++] = R[j++];
    }

    while (i < n1) arr[k++] = L[i++];
    while (j < n2) arr[k++] = R[j++];
}

void mergeSort(int arr[], int left, int right) {
    if (left < right) {
        int mid = (left + right) / 2;

        mergeSort(arr, left, mid);
        mergeSort(arr, mid + 1, right);

        merge(arr, left, mid, right);
    }
}

int main() {
    int arr[] = {38, 27, 43, 3, 9, 82, 10};
    int n = sizeof(arr) / sizeof(arr[0]);

    mergeSort(arr, 0, n - 1);

    for (int i = 0; i < n; i++)
        printf("%d ", arr[i]);
    return 0;
}
Merge Sort in Python
def merge_sort(arr):
    if len(arr) > 1:
        mid = len(arr) // 2

        left = arr[:mid]
        right = arr[mid:]

        merge_sort(left)
        merge_sort(right)

        i = j = k = 0

        # Merge the two halves
        while i < len(left) and j < len(right):
            if left[i] <= right[j]:
                arr[k] = left[i]
                i += 1
            else:
                arr[k] = right[j]
                j += 1
            k += 1

        # Remaining elements
        while i < len(left):
            arr[k] = left[i]
            i += 1
            k += 1

        while j < len(right):
            arr[k] = right[j]
            j += 1
            k += 1

# Example usage
arr = [38, 27, 43, 3, 9, 82, 10]
merge_sort(arr)
print(arr)
Merge Sort in JavaScript
function mergeSort(arr) {
    if (arr.length <= 1) return arr;

    const mid = Math.floor(arr.length / 2);
    const left = mergeSort(arr.slice(0, mid));
    const right = mergeSort(arr.slice(mid));

    return merge(left, right);
}

function merge(left, right) {
    let result = [], i = 0, j = 0;

    while (i < left.length && j < right.length) {
        if (left[i] <= right[j]) {
            result.push(left[i++]);
        } else {
            result.push(right[j++]);
        }
    }

    return result.concat(left.slice(i)).concat(right.slice(j));
}

// Example usage
const arr = [38, 27, 43, 3, 9, 82, 10];
const sorted = mergeSort(arr);
console.log(sorted);
Merge Sort vs Bubble Sort
Feature
Merge Sort
Bubble Sort
Approach
Divide and Conquer
Repeatedly swapping
Time Complexity
O(n log n)
O(n²)
Best Case
O(n log n)
O(n) (if optimized)
Stable?
Yes
Yes
Recursive?
Yes
No
Use Case
Large datasets
Teaching / simple examples
Extra Space?
Yes (O(n))
No
🔸 Merge Sort is way faster than Bubble Sort for large arrays.
Merge Sort vs Insertion Sort
Feature
Merge Sort
Insertion Sort
Approach
Divide and Conquer
Builds final array one item at a time
Time Complexity
O(n log n)
O(n²)
Best Case
O(n log n)
O(n) (when array is sorted)
Stable?
Yes
Yes
Recursive?
Yes
No
Use Case
Large datasets
Small or nearly sorted arrays
Extra Space?
Yes
No
🔸 Insertion Sort is good for small or nearly sorted arrays. Merge Sort is better for general use.
Merge Sort vs Selection Sort
Feature
Merge Sort
Selection Sort
Approach
Divide and Conquer
Finds minimum each pass
Time Complexity
O(n log n)
O(n²)
Best Case
O(n log n)
O(n²)
Stable?
Yes
No
Recursive?
Yes
No
Use Case
General purpose sorting
Educational purposes
Extra Space?
Yes
No
🔸 Selection Sort is simple but not efficient. Merge Sort wins in speed.
Merge Sort vs Quick Sort
Feature
Merge Sort
Quick Sort
Approach
Divide and Conquer
Divide and Conquer
Time Complexity
O(n log n)
Average: O(n log n), Worst: O(n²)
Best Case
O(n log n)
O(n log n)
Stable?
Yes
No (unless modified)
Recursive?
Yes
Yes
Use Case
Linked lists or when stability is required
Faster on arrays, commonly used
Extra Space?
O(n)
O(log n) (in-place)
🔸 Quick Sort is generally faster in practice but not stable. Merge Sort is more predictable.
Summary Table
Sort
Time (Best)
Time (Worst)
Stable
Space
Suitable For
Merge Sort
O(n log n)
O(n log n)
✅
O(n)
Large, stable sorting
Quick Sort
O(n log n)
O(n²)
❌
O(log n)
Fast general purpose
Bubble Sort
O(n)
O(n²)
✅
O(1)
Educational, small sets
Insertion
O(n)
O(n²)
✅
O(1)
Nearly sorted data
Selection
O(n²)
O(n²)
❌
O(1)
Simple, not efficient
Real-World Use Cases of Merge Sort
External Sorting: Ideal for sorting huge files on disk where memory is limited.
Linked Lists: Performs better than quicksort on linked lists.
Parallel Processing: Merge Sort can be efficiently parallelized due to its divide-and-conquer nature.
Advantages and Disadvantages
Pros:
Predictable time complexity (O(n log n)).
Great for sorting linked lists.
Stable sort.
Cons:
Uses extra memory.
Slower for small datasets compared to quicksort or insertion sort.
Basic-Level Interview Questions
What is Merge Sort?
Can you explain the Merge Sort algorithm in simple terms?
What is the time and space complexity of Merge Sort?
Best, worst, average case complexities?
Is Merge Sort a stable sorting algorithm? Why?
What is the difference between Merge Sort and Quick Sort?
Which one is preferred and when?
Does Merge Sort work in-place?
If not, how much additional memory does it need?
What do you mean by Divide and Conquer approach?
Can you give a real-world analogy for it?
Intermediate-Level Questions
Can you write the Merge Sort algorithm in any language of your choice?
Explain the merge process in Merge Sort.
How does the merging step maintain order?
How is Merge Sort implemented on a linked list?
Why is it more efficient in that case?
How would you modify Merge Sort to count the number of inversions in an array?
Can you implement Merge Sort iteratively (bottom-up approach)?
Advanced/Real-World Questions
How would you handle very large datasets that don’t fit into memory using Merge Sort?
External sorting techniques?
How can you optimize the space complexity of Merge Sort?
What are the cache performance issues in Merge Sort compared to Quick Sort?
Where is Merge Sort used in real-world systems or libraries?
(e.g., Timsort is based on Merge Sort + Insertion Sort)
How would you parallelize Merge Sort in a multi-threaded system?
Bonus Conceptual Questions
Why does Merge Sort have consistent O(n log n) time complexity regardless of input?
Can you identify when Merge Sort is not the best option to use?
Explain Merge Sort using recursion stack trace.
What happens in each call?
Why do some standard libraries prefer Quick Sort or Timsort over Merge Sort?
Thank you for exploring Merge Sort tutorials ! Stay ahead in embedded systems with expert insights, hands-on projects, and in-depth guides. Follow Embedded Prep for the latest trends, best practices, and step-by-step tutorials to enhance your expertise. Keep learning, keep innovating!
You can also Visit other tutorials of Embedded Prep
Introduction | How to Read and Understand Schematics of Hardware
How to Read and Understand Schematics of Hardware : In the world of embedded systems, understanding hardware schematics is an essential skill for both hardware and software engineers. Schematics act as the blueprints of electronic circuits, guiding engineers through the design, debugging, and troubleshooting phases.
This blog post provides a step-by-step guide on how to effectively read and interpret hardware schematics, covering core symbols, power distribution, communication interfaces, and debugging techniques.
1. Understanding the Basics of a How to Read and Understand Schematics
A schematic diagram represents the electronic components and their connections in a circuit. It uses standardized symbols instead of physical representations of the components. The key elements of a schematic include:
a) Reference Designators
Each component in a schematic is labeled with a unique identifier, known as a reference designator. Common examples include:
R1, R2, R3 – Resistors
C1, C2, C3 – Capacitors
U1, U2 – Integrated Circuits (ICs)
D1, D2 – Diodes
Q1, Q2 – Transistors
b) Symbols and Notations
Some commonly used symbols include:
Resistor (R) – A zig-zag line
Capacitor (C) – Two parallel lines (polarized capacitors have a positive and negative marking)
Diode (D) – A triangle pointing to a line
Transistor (Q) – Different types (NPN, PNP, MOSFET) have unique symbols
Microcontroller (U) – A rectangular box with labeled pins
Power and Ground (VCC, GND) – Symbols representing power supply connections
c) Nets and Nodes
Nets (Lines) – Represent electrical connections between components.
Nodes (Junctions) – Where multiple connections meet.
Net Labels – Named connections, reducing wire clutter (e.g., SDA, SCL for I2C communication).
2. Power Distribution in a Schematic
a) Identifying Power Sources
Most circuits operate on specific voltage levels. Common designations include:
VCC (or VDD) – Positive power supply (+5V, +3.3V, etc.)
GND (or VSS) – Ground reference
b) Voltage Regulators
Voltage regulators ensure a stable power supply to the circuit. Examples:
7805 Regulator – Provides a 5V output from a higher voltage source
AMS1117-3.3V – Converts 5V to 3.3V
c) Decoupling and Filtering Capacitors
Capacitors are used for noise reduction and power stability:
Ceramic capacitors (0.1µF, 1µF) – Placed near IC power pins
Electrolytic capacitors (10µF, 100µF) – Used in power regulation circuits
UART (TX, RX, GND) – Serial communication interface
CAN (CANH, CANL) – For automotive applications
4. Understanding Peripheral Circuits
a) Sensors and Actuators
Temperature Sensors (e.g., LM35, DHT11) – Analog or digital output
Motors (DC, Servo, Stepper) – Driven by H-bridge circuits
b) Display Modules
OLED/LCD (I2C, SPI, Parallel) – Requires appropriate power levels
7-segment Displays – Uses multiplexing
5. Analyzing Protection Circuits
a) Pull-up and Pull-down Resistors
Used for GPIO stabilization (e.g., 10kΩ pull-up on RESET pin)
b) Reverse Polarity Protection
Diodes in series with power lines prevent reverse voltage damage
c) Fuse and Overcurrent Protection
PTC Resettable Fuses – Protect against short circuits
TVS Diodes – Absorb voltage spikes
6. Debugging Using Schematics
a) Finding Test Points
Test points are designated spots where you can measure signals with a multimeter or oscilloscope.
b) Checking Signal Flow
Trace the signals from power to microcontroller and peripherals.
c) Identifying Common Issues
No power? Check the voltage regulator and power traces.
Unstable signals? Check capacitors and grounding.
Microcontroller not working? Verify clock and reset circuits.
7. Tools for Schematic Analysis
a) Software Tools
KiCad – Open-source schematic and PCB design tool
Altium Designer – Industry-standard for professional PCB design
Eagle – Used for PCB and schematic layout
OrCAD – Professional circuit design software
b) Hardware Debugging Tools
Multimeter – For voltage and continuity checks
Oscilloscope – To analyze signal waveforms
Logic Analyzer – To debug communication protocols
💛 Support Embedded Prep
If you find our tutorials helpful and want to support our mission of sharing high-quality embedded system knowledge, you can contribute by buying us a coffee.
Every small contribution helps us keep creating valuable content for learners like you. ☕
Thank you for your support — it truly keeps Embedded Prep growing. 💻✨
8. Practical Example (How to Read and Understand Schematics) Analyzing an Embedded Schematic
Let’s analyze a simple ESP32-based IoT sensor circuit:
ESP32 Module
VCC → 3.3V Regulator (AMS1117-3.3V)
GND → Common ground
GPIO21 (SDA) & GPIO22 (SCL) → I2C OLED Display
GPIO4 → DHT11 Temperature Sensor (with a pull-up resistor)
UART TX/RX → Debugging interface
Power Management
5V input from USB → 3.3V regulator
Decoupling capacitors (100µF, 10µF, 0.1µF) near power pins
Communication
I2C lines have 4.7kΩ pull-up resistors
UART connected to debugging console
This schematic shows how power, communication, and sensors are connected in an embedded system.
The topics required How to Read and Understand Schematics
1. Basic Electrical & Electronics Engineering
📚 Topics Covered:
Ohm’s Law, Kirchhoff’s Laws
Resistors, Capacitors, Inductors
Diodes, Transistors, MOSFETs
Power Supply Circuits (Voltage Regulators, SMPS, Batteries)
AC & DC Circuits
👨🏫 Relevant Subject Names:
Basic Electrical Engineering (BEE)
Circuit Theory
Electronic Devices & Circuits (EDC)
2. Analog & Digital Electronics
📚 Topics Covered:
Op-Amps, Comparators
Filters, Amplifiers (LM386, etc.)
Logic Gates (AND, OR, NOT, XOR, etc.)
Flip-Flops, Counters, Registers
ADC/DAC Converters
👨🏫 Relevant Subject Names:
Analog Electronics
Digital Logic Design
Digital Signal Processing (DSP)
3. Microprocessors & Microcontrollers
📚 Topics Covered:
Microcontroller Architecture (8051, ARM Cortex, STM32, ESP32)
GPIOs, Timers, Interrupts
Memory (Flash, EEPROM, RAM)
Peripheral Interfaces (SPI, I2C, UART, CAN, PCIe)
👨🏫 Relevant Subject Names:
Microprocessor and Microcontroller (MPMC)
Embedded Systems
4. Embedded System Design
📚 Topics Covered:
Schematic Reading & PCB Layout
Bootloaders & Firmware
Low Power Design & Power Management
Real-Time Operating Systems (RTOS)
👨🏫 Relevant Subject Names:
Embedded Systems
Real-Time Systems
Hardware-Software Co-design
5. Communication Protocols & Interfaces
📚 Topics Covered:
Serial & Parallel Communication (SPI, I2C, UART, CAN, USB)
Wireless Communication (Bluetooth, Wi-Fi, Zigbee, LoRa)
Requirement Gathering Tools for Embedded Firmware Development | How to Read and Understand Schematics
Requirement gathering is crucial in embedded firmware development to ensure clarity, traceability, and compliance. Here are some tools categorized based on their purpose:
1. Requirements Management & Traceability Tools
These tools help capture, manage, and track requirements throughout the development lifecycle.
IBM DOORS (Dynamic Object-Oriented Requirements System) – Industry-standard for requirements management, widely used in automotive (ASPICE), aerospace (DO-178C), and medical fields.
Visure Requirements ALM – Focused on automotive (ASPICE), aerospace, and industrial compliance.
Choosing the Right Tool for Embedded Systems
Use Case
Recommended Tool
Basic Requirement Documentation
Excel, Confluence, ReqView
Agile-based Embedded Projects
Jira, Azure DevOps, Notion
Safety-Critical Systems (ASPICE, ISO 26262)
IBM DOORS, Jama Connect, codeBeamer ALM
Model-Based Requirement Engineering
Enterprise Architect, Cameo Systems Modeler
Open-Source Solution
LibrePlan, ReqView
Interview questions on How to Read and Understand Schematics :
Basic Questions on How to Read and Understand Schematics
What is a schematic diagram in electronics?
Why is it important to read and understand schematics in embedded systems?
What are the common symbols used in schematics?
How do you differentiate between power rails (Vcc, Vdd, GND, etc.) in a schematic?
What is the role of reference designators (R1, C1, U1, etc.) in a schematic?
Components & Symbols for How to Read and Understand Schematics
How do you identify resistors, capacitors, inductors, diodes, and transistors in a schematic?
What is a pull-up resistor, and how can you recognize it in a schematic?
How can you tell if a capacitor is being used for decoupling or filtering in a circuit?
What does a fuse or TVS diode symbol indicate in a schematic?
How do you recognize an operational amplifier (Op-Amp) configuration in a schematic?
Power and Signal Flow for How to Read and Understand Schematics
How do you determine the power source of a circuit from a schematic?
What are bypass capacitors, and where do they appear in a schematic?
How can you trace signal flow from input to output in a schematic?
How do you identify and differentiate between analog and digital signal paths?
What is a ground plane, and why is it important in PCB design?
Microcontroller & Communication Interfaces for How to Read and Understand Schematics
How do you recognize a microcontroller (MCU) or processor in a schematic?
How can you identify and verify connections for I2C, SPI, UART, and CAN in a schematic?
What are the key components required for an external crystal oscillator in an MCU circuit?
How do you identify reset and boot mode circuits in a microcontroller schematic?
What is a JTAG/SWD header, and why is it used in embedded systems?
Debugging & Troubleshooting Schematics for How to Read and Understand Schematics
How can you identify floating (unconnected) pins in a schematic?
How do you check for short circuits or incorrect connections in a schematic?
How can you use a multimeter or oscilloscope to verify circuit behavior based on a schematic?
What are test points, and why are they included in schematics?
How do you identify and correct a missing or incorrectly placed component in a schematic?
Advanced & Industry-Specific Questions on How to Read and Understand Schematics
How do you read power management schematics (buck converters, LDOs, etc.)?
How can you interpret impedance-matching networks in high-speed PCB designs?
What is EMI/EMC shielding, and how can you recognize it in a schematic?
How do you analyze a differential pair (LVDS, USB, Ethernet) in a schematic?
How do you ensure compliance with industry standards (ISO 26262, IPC-2221, etc.) when analyzing schematics?
Master the Art of How to Read and Understand Schematics of Hardware (2025)
Frequently Asked Questions (FAQ) on How to Read and Understand Schematics
1. What is a schematic diagram in electronics?
A schematic is a graphical representation of an electronic circuit, showing components and their connections using standardized symbols.
2. Why is reading schematics important in embedded systems?
Schematics help engineers understand circuit design, debug hardware issues, and integrate firmware with the correct electrical components.
3. What are the most commonly used symbols in schematics?
Some common schematic symbols include:
Resistor (R) – Zigzag line
Capacitor (C) – Two parallel lines
Inductor (L) – Coiled loops
Diode (D) – Triangle pointing to a line
Transistor (Q) – NPN/PNP or MOSFET symbols
Ground (GND) – Three descending lines
Microcontroller (U) – Rectangular block with pins
4. How do I identify power and ground in a schematic?
Vcc/Vdd/Vss – Represents different voltage levels in the circuit
GND (Ground) – Common return path for current
Battery (BAT) – Alternating long and short lines
5. How can I trace signal flow in a schematic?
Start from inputs (sensors, buttons, communication lines) and follow the signal through processing elements (MCUs, ICs) to outputs (displays, motors, LEDs).
6. How do I find the microcontroller in a schematic?
Look for a large rectangle (U1, U2, etc.) with multiple labeled pins, often connected to memory, sensors, and communication interfaces.
7. What is a pull-up/pull-down resistor, and how do I find it in a schematic?
A pull-up resistor (connected between Vcc and a signal) ensures a default high state, while a pull-down resistor (between GND and a signal) ensures a default low state.
8. How can I identify communication protocols like I2C, SPI, UART in a schematic?
I2C – Look for SDA (Data) and SCL (Clock) lines, often with pull-up resistors.
SPI – Consists of MOSI, MISO, SCK, and CS (Chip Select) lines.
UART – Identified by TX (Transmit) and RX (Receive) connections.
9. What are decoupling/bypass capacitors, and why are they used?
Decoupling capacitors (placed near IC power pins) stabilize voltage and filter out noise from the power supply.
10. What are test points in a schematic?
Test points are designated locations for measuring voltage, signals, and debugging during hardware testing.
11. How do I detect errors in a schematic?
Check for:
Floating (unconnected) pins
Short circuits or incorrect connections
Missing pull-up/pull-down resistors
Incorrect capacitor or diode placement
12. What tools can help in reading schematics?
KiCad, Eagle, Altium Designer, OrCAD – For viewing and designing schematics
LTspice, Proteus, TINA-TI – For simulating circuits
13. What is a ground plane, and why is it important?
A ground plane is a large conductive layer used in PCBs to provide a low-resistance return path for current and reduce noise.
14. How can I interpret differential pair signals (LVDS, USB, Ethernet)?
Differential pairs use two closely routed traces with opposite signals to reduce noise and improve signal integrity.
15. What is EMI/EMC shielding, and how is it represented in schematics?
Electromagnetic Interference (EMI) shielding protects sensitive signals and is typically represented by grounded shielding enclosures or ferrite beads.
16. What is the difference between schematic and PCB layout?
A schematic is a logical diagram of a circuit, while a PCB layout is the physical design that places components on a board.
17. How do I ensure a schematic follows industry standards?
Follow IPC standards, ISO 26262 (automotive), and best practices like using proper symbols, grounding, and labeling.
18. What is a Bill of Materials (BOM), and how is it related to schematics?
A BOM lists all components used in a schematic, including part numbers, values, and footprints for PCB design.
19. How do I verify a schematic before designing a PCB?
Cross-check with component datasheets
Simulate circuits using SPICE tools
Review connections using ERC (Electrical Rule Check)
20. How can I improve my schematic reading skills?
Practice analyzing real schematics
Refer to component datasheets
Use online tools like Digi-Key, Mouser, and Altium for circuit examples
Debugging & Testing Tools
If you\’re interested in learning about debugging tools, check out below detailed guide about tools:
Multimeter – Basic voltage and continuity checking
Oscilloscope – Debugging signals in real-time
Logic Analyzer – Capturing and analyzing digital communication (I2C, SPI, UART)
JTAG/SWD Debuggers – Segger J-Link, ST-Link, OpenOCD for debugging and flashing firmware
Thank you for exploring How to How to Read and Understand Schematics Stay ahead in embedded systems with expert insights, hands-on projects, and in-depth guides. Follow Embedded Prep for the latest trends, best practices, and step-by-step tutorials to enhance your expertise. Keep learning, keep innovating!
You can also Visit other tutorials of Embedded Prep
Linux Boot Process : Learn about the Linux boot process step by step. Understand BIOS/UEFI, bootloaders like GRUB, kernel initialization, init systems, and runlevels.
Introduction of Linux Boot Process
The Linux boot process is the sequence of events that occur from the moment a computer is powered on until the operating system is fully loaded and ready for use. Understanding this process is essential for system administrators, embedded engineers, and Linux users troubleshooting boot issues.
In this guide, we will explore the Linux boot sequence, covering each stage in detail, from BIOS/UEFI initialization to reaching the login prompt.
1. BIOS/UEFI – Hardware Initialization
The boot process begins with the BIOS (Basic Input/Output System) or UEFI (Unified Extensible Firmware Interface). This firmware checks the system hardware and locates a bootable disk.
Key Functions of BIOS/UEFI:
✅ Performs Power-On Self-Test (POST) to detect hardware issues. ✅ Initializes the CPU, RAM, and storage devices. ✅ Searches for a bootable disk (HDD, SSD, USB, Network). ✅ Loads the bootloader from the Master Boot Record (MBR) or EFI partition.
📌 Related: How to Check BIOS Version in Linux
2. Bootloader – Loading the Linux Kernel
The bootloader is responsible for loading the Linux kernel and passing necessary parameters.
Common Bootloaders in Linux:
GRUB (GRand Unified Bootloader) – Most widely used.
LILO (Linux Loader) – Legacy bootloader, less common.
systemd-boot – Used in systemd-based distributions.
U-Boot – Popular for embedded Linux (ARM-based systems).
Bootloader Responsibilities:
✅ Loads the Linux kernel into RAM. ✅ Passes kernel parameters (e.g., root filesystem location). ✅ Loads the initial RAM disk (initramfs/initrd).
Once the bootloader executes, the Linux kernel takes control.
Kernel Responsibilities:
✅ Initializes memory management, CPU scheduling, and process handling. ✅ Detects and initializes hardware components. ✅ Mounts the root filesystem (/). ✅ Starts the init system (PID 1).
📌 Related: Linux Kernel vs Unix Kernel
4. Initramfs/Initrd – Temporary Root Filesystem
Before mounting the main root filesystem, Linux uses a temporary filesystem (initramfs/initrd) to: ✅ Load necessary kernel modules (e.g., RAID, LVM). ✅ Mount the actual root filesystem.
🔹 How to View Initramfs Contents:
lsinitrd /boot/initramfs-$(uname -r).img
📌 Related: How to Rebuild Initramfs in Linux
5. Init System – Starting User Space Processes
The init system is the first user-space process executed by the Linux kernel (PID 1). It manages system services and startup scripts.
Popular Init Systems in Linux:
Systemd (Modern Linux distributions)
SysVinit (Older Linux distributions)
Upstart (Legacy Ubuntu versions)
🔹 Systemd Process Tree Example:
systemctl list-units --type=service
📌 Related: Systemd vs SysVinit
💛 Support Embedded Prep
If you find our tutorials helpful and want to support our mission of sharing high-quality embedded system knowledge, you can contribute by buying us a coffee.
Every small contribution helps us keep creating valuable content for learners like you. ☕
Thank you for your support — it truly keeps Embedded Prep growing. 💻✨
6. Runlevels & System Targets
Runlevels (SysVinit) or system targets (systemd) define the state of a Linux system at boot.
Runlevels (SysVinit):
0 – Shutdown
1 – Single-user mode
3 – Multi-user, no GUI
5 – Multi-user with GUI
6 – Reboot
Systemd Targets:
poweroff.target – Shutdown
rescue.target – Single-user mode
multi-user.target – CLI mode
graphical.target – GUI mode
reboot.target – Reboot
🔹 How to Change Runlevel in Systemd:
systemctl isolate multi-user.target
📌 Related: Linux Runlevels Explained
7. User Login & Shell Execution
Once all system services are initialized, the Linux system presents: ✅ A text-based shell (Bash, Zsh). ✅ A graphical login manager (GDM, SDDM, LightDM).
🔹 How to Check Running Shell:
echo $SHELL
📌 Related: Bash vs Zsh – Which Shell is Better?
8. Linux Boot Process in Embedded Systems (ARM)
For ARM-based Linux systems, the boot sequence differs slightly:
1️⃣ ROM Code Execution – Loads the primary bootloader (MLO/SPL). 2️⃣ Primary Bootloader (U-Boot SPL) – Initializes RAM. 3️⃣ Secondary Bootloader (U-Boot) – Loads the Linux kernel. 4️⃣ Kernel Decompression & Execution 5️⃣ Device Tree Parsing 6️⃣ Init System Execution
📌 Related: How U-Boot Works in Linux
Frequently Asked Questions (FAQs)
What is the Linux boot process in simple terms?
It’s the sequence of events from powering on a system to reaching the user login prompt, involving BIOS, bootloader, kernel, init system, and services.
Why does Linux use Initramfs?
Initramfs provides a minimal root filesystem for loading essential kernel modules before mounting the main filesystem.
How to reduce Linux boot time?
✅ Disable unnecessary kernel modules. ✅ Optimize systemd services using systemctl disable <service>. ✅ Use lightweight bootloaders like systemd-boot.
📌 Related: How to Speed Up Linux Boot Time
Conclusion
The Linux boot process is a crucial aspect of system administration and embedded Linux development. Understanding how Linux boots—from BIOS/UEFI to user space—helps in troubleshooting, optimizing, and customizing the system.
Did you find this guide helpful? Share your thoughts in the comments below!
Thank you for exploring Linux Boot Process! Stay ahead in embedded systems with expert insights, hands-on projects, and in-depth guides. Follow Embedded Prep for the latest trends, best practices, and step-by-step tutorials to enhance your expertise. Keep learning, keep innovating!
You can also Visit other tutorials of Embedded Prep